UPSTREAM RIGHTS
OpenQuadruped by Adham Elarabawy (original creator), adham-elarabawy/open-quadruped commit b0ab4fa599f94460828bf3aa4514240ae917ed38. The root LICENSE is the MIT License, "Copyright (c) 2020 Adham Elarabawy", followed by an added clause: "In order to use any of the works or derivative works that this license covers, explicit & formal credit must be granted to the original creator (Adham Elarabawy). Any violation of this clause will result in a DMCA claim against the violator." Open Source Robotics gives that explicit and formal credit: OpenQuadruped was created by Adham Elarabawy. The ROS package.xml declares "TODO". urdf/stl/LICENSE.txt licenses the separate SpotMicro meshes (Spotmicro - robot dog by KDY0523, CC BY 3.0) in urdf/stl/; those files are not used by this preview and are not included. The README notes that the URDF joint layout was ported from a collaborator model by Maurice Rahme.
Open Source Robotics hosts the unchanged xacro sources, launch file, checked-in spot.urdf, the 17 STL files of urdf/stl/OpenQuadruped, package.xml and the notices below in a ZIP bundle, and a triangulated preview of spot.urdf.xacro (as loaded by launch/sim.launch, expanded without changes) at zero joint positions. No manufacturing or other clearance is claimed.
--- UPSTREAM LICENSE ---
MIT License
Copyright (c) 2020 Adham Elarabawy
Permission is hereby granted, free of charge, to any person obtaining a copy
of this software and associated documentation files (the "Software"), to deal
in the Software without restriction, including without limitation the rights
to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
copies of the Software, and to permit persons to whom the Software is
furnished to do so, subject to the following conditions:
The above copyright notice and this permission notice shall be included in all
copies or substantial portions of the Software.
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE
SOFTWARE.
In order to use any of the works or derivative works that this license covers,
explicit & formal credit must be granted to the original creator (Adham Elarabawy).
Any violation of this clause will result in a DMCA claim against the violator.
--- UPSTREAM README.md ---
# open-quadruped
[](https://github.com/adham-elarabawy/OpenQuadruped/graphs/commit-activity)
[](https://github.com/adham-elarabawy/OpenQuadruped/pulls)
[](https://github.com/adham-elarabawy)
[](https://github.com/adham-elarabawy/OpenQuadruped)
An open-source 3D-printed quadrupedal robot. Intuitive gait generation through 12-DOF Bezier Curves. Full 6-axis body pose manipulation. Custom 3DOF Leg Inverse Kinematics Model accounting for offsets.

 ## Current Status
### To-Do List
- [x] *Hardware* // Redesign legs to move actuators closer to hip + reinforce all servo mounting.
- [ ] *Design* // Research transition between gait & body pose.
- [x] *Software* // Implementing ROS infrastructure for all control processes (including cpp on teensy).
- [ ] *Software* // Write & automate pytest unit tests.
- [ ] *Software* // Integrate unit tests with github actions.
- [x] *Simulation* // Create URDF model. (or port collaborater's URDF: Maurice Rahme)
- [x] *Simulation* // Gazebo
- [ ] *Simulation* // RViz Realtime Model
- [ ] *Design* // Solve offset 3DOF IK model for right limbs _OR_ validate that mirroring angles works for left/right legs
- [ ] *Simulation* // Implement WebGazebo clientside support for non-linux users
- [ ] *Sim-to-Real* // Joint servo calibration
- [ ] *Sim-to-Real* // Refining gait parameters
- [ ] *Simulation* // Reinforcement learning via ARS
- [ ] *Software* // Raibert Huerestic for converting desired velocities into gait parameters
- [ ] *Software* // ROS Nav Stack Layer

 ## Papers
I've been formally documenting this project in the form of papers. You can find them here: [adhamelarabawy.com/images/IK_Model.pdf](https://www.adhamelarabawy.com/images/IK_Model.pdf)
## Documentation
You can find a summary of this project on [my portfolio website's project page](https://www.adhamelarabawy.com).
I'm hosting most of the technical documentation for this project on [this repo's wiki](https://github.com/adham-elarabawy/OpenQuadruped/wiki).
## 3D Model
In the [model](https://github.com/adham-elarabawy/OpenQuadruped/tree/master/model) folder, you can find all of the step & stl files that I used for my build of OpenQuadruped. There, you can also find a Bill of Materials, and some guides (in progress).
## Hardware
I made a custom pcb board to control the position and speed of 12 servos simultaneously, as well as interface with all of the sensors.
You can find the gerber files for the custom pcb in the [hardware folder](https://github.com/adham-elarabawy/OpenQuadruped/tree/master/hardware) in this repository.
 You can find the bill of materials for this project [here](https://docs.google.com/spreadsheets/d/12QX1ca9LHZEThukprlz0DARR9_lmf6FJI8Tg-O4qcdc/edit?usp=sharing).
## Visualization Usage
*NOTE: There are 3 different visualization tools: Gazebo Simulator (ROS + Physics), RViz (ROS), & my custom 3d-matplotlib visualization tool (body IK model + leg IK model). The latter tool is still under development, and I haven't ported it to use my new control library yet, so it is likely broken for the time being.*
To try the visualization tool out, you'll need to run the [animate.py](https://github.com/adham-elarabawy/OpenQuadruped/blob/master/visualization/animate.py) python file with the proper libraries installed. (matplotlib 3.0.3 supported).
You can then use keyboard controls: use x, y, z, a, p, r to select (x axis, y axis, z axis, yaw, pitch, roll), and then the up and down buttons to increment the selected position. If you click '1' on your keyboard, it will reset the position.
Right now, if you try to go to an impossible pose that would result in collisions, the body will do some weird things. If that happens, just click "1" on your keyboard to reset the position.
*Note: Pitch and Roll are currently not working. I am currently trying to fix that.*
## More Demos
[](https://www.youtube.com/watch?v=z8j-Z9Bwn58)[](https://www.youtube.com/watch?v=79kFujIpjgo)[](https://www.youtube.com/watch?v=cCMvCH0m9TA)[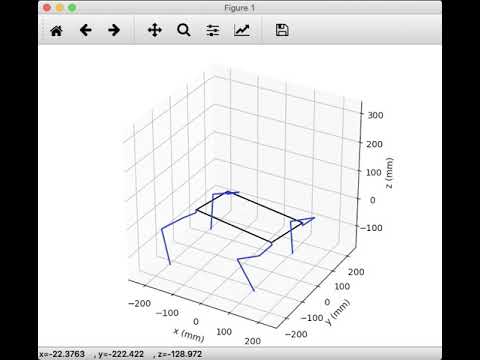](https://www.youtube.com/watch?v=LBjqJVEXwhM)
--- UPSTREAM ros-workspace/src/open_quadruped/package.xml ---
open_quadruped
0.0.0
The open_quadruped package
Adham Elarabawy
TODO
catkin
joy
roscpp
rospy
rosserial_python
std_msgs
message_generation
gazebo_ros
joy
roscpp
rospy
rosserial_python
std_msgs
joy
roscpp
rospy
rosserial_python
std_msgs
message_runtime
gazebo_ros
controller_manager
joint_state_controller
robot_state_publisher
rqt_gui
effort_controllers
--- UPSTREAM ros-workspace/src/open_quadruped/urdf/stl/LICENSE.txt ---
Spotmicro - robot dog (http://www.thingiverse.com/thing:3445283) by KDY0523 is licensed under the Creative Commons - Attribution license.
http://creativecommons.org/licenses/by/3.0/