Aero Hand Open
End effectorA five-finger tendon-driven hand with seven actuators, sixteen joints and separate hardware/software licenses. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Includes noncommercial terms. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-NC-SA-4.0 (noncommercial) · Details by part
Is this for you?
- Known limitations
- README USD 314 kit headline and BOM numeric total 316.482991 are not established as directly comparable; BOM currency/pack assumptions need reconciliation. Quote exact purchased kit or self-source configuration.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
3D preview
Aero Hand Open right-hand robot description. The project's own right-hand robot description (aero_hand_open_right.urdf in the aero_hand_open_description ROS 2 package at commit 7bb2f23) at zero joint positions: 22 link meshes on the source joint tree, with 16 revolute finger and thumb joints. The left-hand description in the same package is included in the download but is not shown. Tendons, pulleys and actuators are not modeled as separate parts. Licensed CC BY-NC-SA 4.0 (noncommercial, share-alike); no commercial-use or manufacturing clearance is claimed. Fit, tendon routing and motion are not verified.
Noncommercial license: the repository LICENSE.md licenses the hardware design files (CAD/STEP/STL) under Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International and says commercial manufacturing from them requires a separate license from Chestnut Robotics. The description package itself states different terms (package.xml: CC-BY-SA-4.0; package README: Apache License 2.0); this preview applies the most restrictive hardware terms. The preview and hosted original remain under CC BY-NC-SA 4.0 with attribution to Chestnut Robotics, Inc. (formerly TetherIA, Inc.); no commercial-use or manufacturing clearance is claimed. License: CC BY-NC-SA 4.0 · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Chestnut Robotics, Inc. (formerly TetherIA, Inc.), revision 7bb2f23485a7d440960c21046da642de132b7745. Original and preview: CC-BY-NC-SA-4.0 (hardware design files). Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Dexterous hands
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
- Assembly
Choose left/right geometry, print parts, route/tension tendons, assemble electronics, flash matching hand configuration and calibrate; retensioning is a maintenance task.
Research synopsis of upstream route; not independently executed instructions.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Configuration and sourcing
The reviewed commit is 7bb2f23485a7d440960c21046da642de132b7745, accessed September 30, 2026. Select left or right hardware before reconciling the seven-actuator tendon system. Begin with the pinned hardware/Assembly/BOM.csv and hardware/CAD files; the README links the upstream assembly guide, whose complete contents were not reviewed here. [1] [3] [5]
7 Feetech HLS3606M servos, springs, tendons, pins/bearings, ESP32-S3, TTL linker, printed structures and soft pads. BOM contains optional parts and blank cost rows. Its notes assume PLA printing with a 0.4 mm nozzle and give fit guidance for undersized pins and bearings. The BOM recommends silicone pads for compliance and grip and reports reduced functionality with TPU; this is upstream guidance, not our measurement. Reconcile that choice and choose the intended electronics route: servo junction boards, optional protoboard parts or PCB. [1] [2] [3] [4] [5] [6] [7] [8]
Choose left/right geometry, print parts, route/tension tendons, assemble electronics, flash matching hand configuration and calibrate; retensioning is a maintenance task. [1] [2] [3] [4] [5] [6] [7] [8]
Integration
Repository lists Piper, tripod and Unitree G1 adapters; source availability does not establish every host/control combination. [1] [2] [3] [4] [5] [6] [7] [8]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 7bb2f23485a7d440960c21046da642de132b7745; Pinned current commit; left/right hardware and 7-actuator tendon system
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-NC-SA-4.0 Hardware/docs CC BY-NC-SA 4.0; firmware and SDK Apache-2.0. Licensing guide separately describes commercial integration of purchased units; not manufacture permission for files. [1] [2] [3] [4] [5] [6] [7] [8] |
| electronics | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] [7] [8] |
| firmware | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] [7] [8] |
| software | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] [7] [8] |
| model weights | not found · License not fully assessed No complete matched external training-data/weight set verified for this configuration. [1] [2] [3] [4] [5] [6] [7] [8] |
| datasets | not found · License not fully assessed No complete matched external training-data/weight set verified for this configuration. [1] [2] [3] [4] [5] [6] [7] [8] |
| documentation | available · CC-BY-NC-SA-4.0 Hardware/docs CC BY-NC-SA 4.0; firmware and SDK Apache-2.0. Licensing guide separately describes commercial integration of purchased units; not manufacture permission for files. [1] [2] [3] [4] [5] [6] [7] [8] |
Design limits and source rights
README USD 314 kit headline and BOM numeric total 316.482991 are not established as directly comparable; BOM currency/pack assumptions need reconciliation. Obtain an itemized kit contents list before attributing the discrepancy to scope; quote either an exact kit or a reconciled self-source configuration. [1] [2] [3] [4] [5] [6] [7] [8]
Hardware/docs CC BY-NC-SA 4.0; firmware and SDK Apache-2.0. Licensing guide separately describes commercial integration of purchased units; that does not authorize commercial manufacture from design files, which the guide says requires a separate commercial manufacturing license. Noncommercial redistribution and modified files require attribution and sharing under the same license as described by the guide. [1] [2] [3] [4] [5] [6] [7] [8]
Upstream describes a research prototype without prolonged or heavy-duty validation. [1]
This is a source-researched design profile. We have not assembled or tested this configuration; no complete current setup price is established.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Chestnut-Robotics/aero-hand-open: README.md
Revision, date & where cited
github.com · revision
7bb2f23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S002 Chestnut-Robotics/aero-hand-open: LICENSE.md
Revision, date & where cited
github.com · revision
7bb2f23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S003 Chestnut-Robotics/aero-hand-open: files
Revision, date & where cited
github.com · revision
7bb2f23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S004 licensing
Revision, date & where cited
github.com · revision
7bb2f23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S005 bom
Revision, date & where cited
github.com · revision
7bb2f23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S006 hardware_license
Revision, date & where cited
github.com · revision
7bb2f23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S007 firmware_license
Revision, date & where cited
github.com · revision
7bb2f23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S008 adapters
Revision, date & where cited
github.com · revision
7bb2f23· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S010 Upstream image and reuse attribution
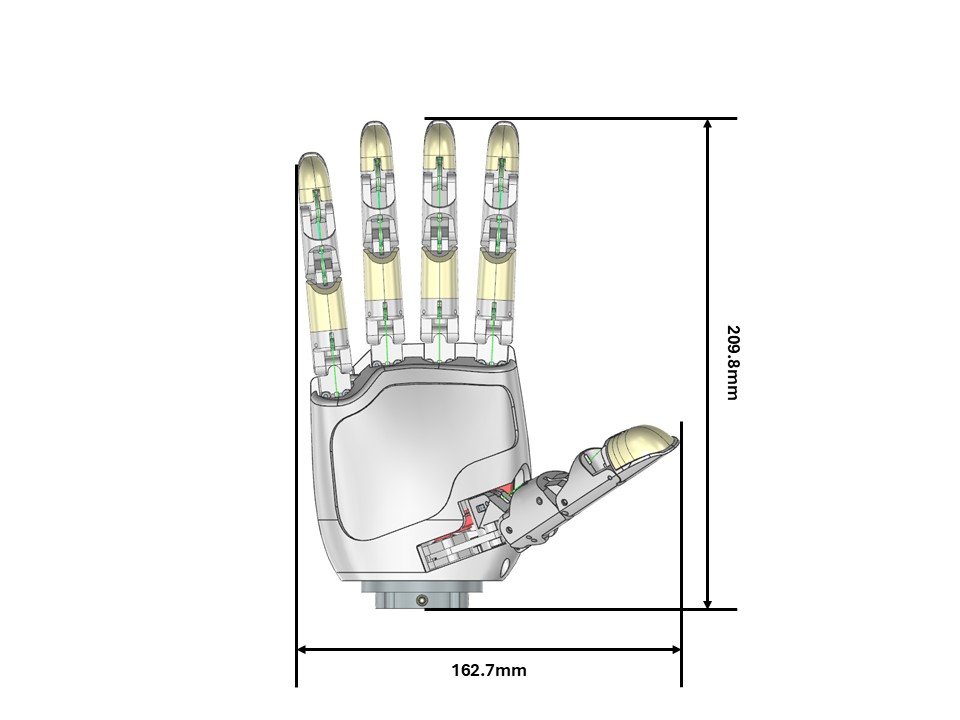
Media-only review: Upstream website illustration of Aero Hand Open, showing a dimensioned front view. Website-image reuse is CC BY-SA 4.0; the hardware and build documentation have separate noncommercial terms. Reuse basis: CC-BY-SA-4.0; inspected the published page, image caption and reuse footer; no image-specific exception found for this selected image. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Chestnut Robotics, Inc. (formerly TetherIA) · github.com · Image SHA-256 c77978d5380c5887ba49364bf23e86903d30ad4456180ffc7279aca8656f5bd5; source revision page SHA-256 7f95df55cdf2743013a3a31b9dd70fbcfaec3e36a74b70e8e83ac9b5fffa50a7 · Accessed Oct 26, 2026
Videos
- S009 ChestnutRobotics (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel ChestnutRobotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-04 — Added 1 YouTube reference(s) (S009): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.