AlohaMini2
Robot / hardware buildPrintable three-wheel mobile base with a motorized lift and two AM-ARM200 arms, run as a Raspberry Pi 5 host with a PC client through the lerobot_alohamini fork. [1] [4] [11]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Researchers and makers with a Bambu P2S-class printer who can assemble servo-driven arms and run a Pi host / PC client LeRobot workflow [1] [11]
- Cost
- USD 950.00–1,097.00 upstream parts estimates for 2 versions [4] [1] · checked Oct 5, 2026 · DetailsNot included: filament (about 5 to 6 kg), common tools and client PC and more.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- Ecosystem
- LeRobot, Raspberry Pi
- License
- Apache-2.0 · Details by part
Overview
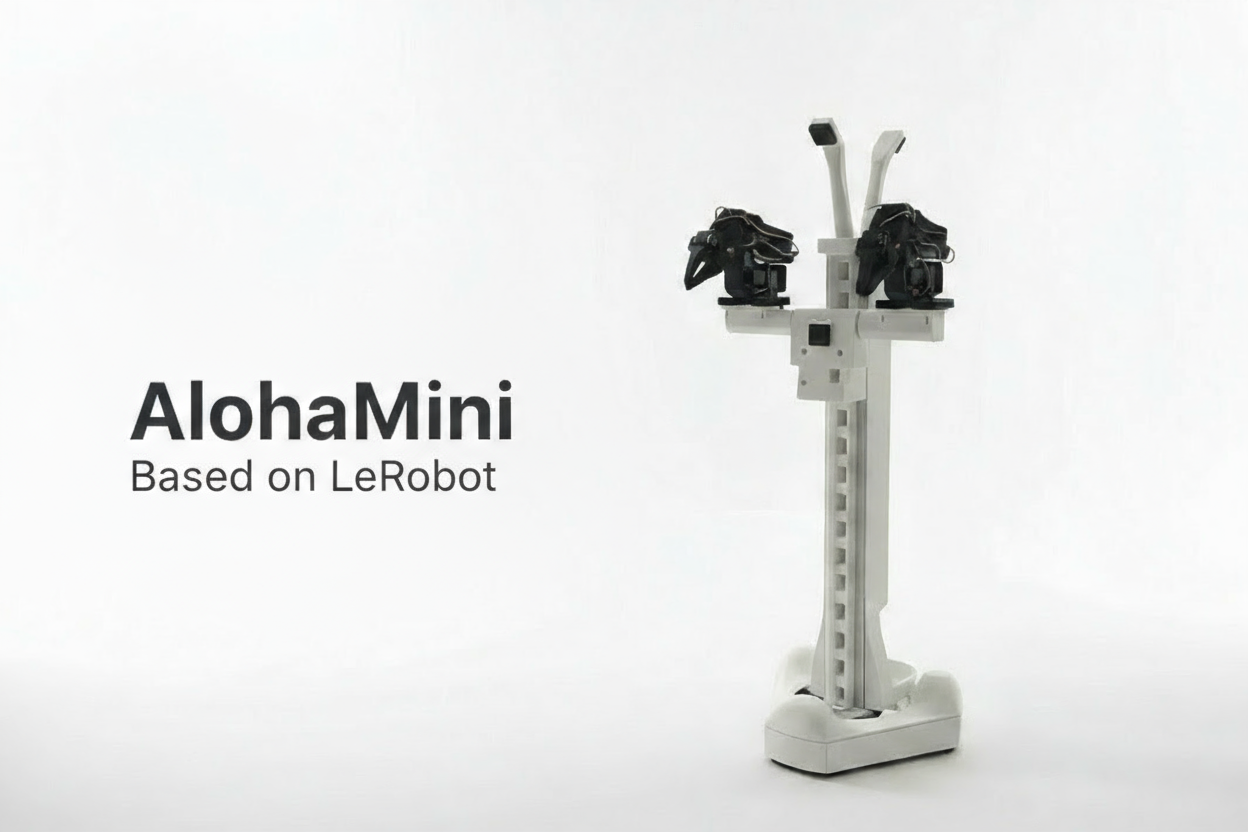
AlohaMini2 is a three-wheel mobile base with a vertical lift and two AM-ARM200 follower arms, teleoperated from two AM-ARM200 leader arms. Li Yiteng and Wu Zhiyong publish it as the June 2026 successor to AlohaMini1, which used SO-ARM100/101 arms. The README claims a 70 kg base load, 30 kg lift capacity, 1 kg arm payload, 52 cm reach and five cameras. These are upstream figures; nothing was printed, assembled or driven for this entry. [1]
Is this for you?
- Use cases
- Bimanual teleoperation from leader arms
- Dataset recording and replay
- Policy training and evaluation
- Pi 0.5 fine-tuning example
- Known limitations
- Arms and software live in separate repositories
- BOM print-file paths do not match the tree
- Leader servo voltage differs between AlohaMini2 and AM-ARM BOMs
- Printed substitutes reduce strength
- Load and lift claims unverified
Source-review boundaries; no hardware tests.
What you need
- Host computer
Raspberry Pi 5 (2 GB) on the robot as host; PC workstation as client for leader arms, recording and training.
- Dependencies
- lerobot_alohamini (LeRobot fork; v0.6.0 notes state sync with LeRobot 0.6)
- AM-ARM200 arm design from liyiteng/AM-ARM
- Tools
- Bambu P2S-class FDM printer
- Table clamp, soldering iron and screwdriver set (listed as common tools, not in BOM)
- Epoxy adhesive
Hardware & parts
Upstream bill of materials [4]
- Hardware configuration
Three-wheel omni base with a motorized vertical lift carrying two 6+1 DoF arms; separate leader arms.
- Actuators
- Base: 3× STS3215 wheel servos, 1× STS3095 lift servo
- Followers: 8× STS3215 and 6× STS3095 (two arms)
- Leaders: 14× STS3215 7.4 V 1/147 per AlohaMini2 BOM
- Controller
Raspberry Pi 5 with Waveshare bus servo adapters
- Power
Two 12 V 11200 mAh Li-ion batteries with a 12 V to 5 V 5 A buck converter for the Pi; 5 V adapter for leaders
Assembly & first use
Open the upstream getting-started guide [1]
- Source parts per the AlohaMini2 BOM
- Print structural parts (about 6 kg filament)
- Build AM-ARM200 arms, then assemble Mobile Base 2 (about 120 minutes)
- Install lerobot_alohamini on Pi and PC, calibrate, teleoperate and record
- Assembly
Mobile Base 2 guide: assign servo IDs, epoxy chassis segments, install wheels, stack and epoxy the lift tower, then shoulder lift block; arms built per AM-ARM200 guide.
- Calibration
Follower calibration on the Pi with --robot_model alohamini2; leader calibration from the PC with am-leader-6dof; power-cycle afterwards.
- Assembly time
About 120 minutes with arms pre-assembled (upstream estimate)
Cost
| Version | Price |
|---|---|
| AlohaMini2 complete set: mobile base, two followers, two leaders, fasteners (BOM.md at 17c6a98) | USD 1097.00 [4] Parts estimate |
Upstream USD column (CNY total also given) · Checked 2026-10-05
| Included | Mobile base parts incl. Raspberry Pi 5, cameras, batteries, omni wheels; Two follower arms; Two leader arms; Fasteners and consumables |
|---|---|
| Not included | Filament (about 5 to 6 kg); Common tools; Client PC; Shipping, taxes and assembly labor |
| Stock | Vendor stock not rechecked. |
| Delivery and tax | Not established. |
Price details
Upstream BOM total estimate ¥7,548 / ~US$1,097 (self-print); not re-quoted.
Upstream USD column (CNY total also given) · Checked 2026-10-05 · Quantity 1
Printed parts, client PC.
| Version | Price |
|---|---|
| AlohaMini2 robot major components without leader arms (README summary) | USD 950.00 [1] Parts estimate |
Upstream USD approximation · Checked 2026-10-05
| Included | Servos, bus controllers, Raspberry Pi 5, five cameras, omni wheels, batteries |
|---|---|
| Not included | Leader arms; Filament (about 5 to 6 kg); Common tools; Client PC; Shipping, taxes and assembly labor |
| Stock | Vendor stock not rechecked. |
| Delivery and tax | Not established. |
Price details
README summary of major components, excluding leader arms; approximate; not re-quoted.
Upstream USD approximation · Checked 2026-10-05 · Quantity 1
Printed parts, leader arms for teleoperation, client PC.
Cost scope
The BOM's total estimate is ¥7,548, about US$1,097, for the base, two followers, two leaders and fasteners, self-printed and excluding filament (the BOM note says about 5 kg; the README says about 6 kg). The README instead gives about US$950 for major components without the leader arms. Common tools are not listed, and the BOM does not price the client PC, shipping or tax. These are dated upstream figures, not re-quoted prices. [1] [4]
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
Configuration a builder must reconcile
The system splits like LeKiwi: a Raspberry Pi 5 host on the robot runs the base, lift, follower arms and cameras, while a PC client runs the leader arms, recording and training on the same LAN. The base uses three STS3215 wheel servos, an STS3095 lift servo, 127 mm omni wheels, two 12 V 11200 mAh batteries and a 12 V to 5 V buck converter. Each follower uses four STS3215 and three STS3095 servos plus a wrist camera; the leaders use fourteen 7.4 V STS3215 servos in this BOM. [4] [11]
Three cross-checks matter. The arms are not in this repository; AlohaMini2's arm folder points to the separate AM-ARM repository. The BOM points to hardware/mobile_base/stl and hardware/arms/stl, but the tree contains mobile_base2/stl and no arms STL folder. The AM-ARM BOM specifies 5 V leader servos, while this BOM lists 7.4 V servos with a 5 V supply. [4] [8] [9] [10]
Assembly uses epoxy on chassis and tower joints. The print guide offers printed substitutes for the aluminium T-frame and steel pins, but warns they significantly reduce strength. [5] [6]
Software route
Software lives in the separate lerobot_alohamini fork, which the repository calls the single source of truth. Its v0.6.0 notes state a sync with LeRobot 0.6. The workflow calibrates followers on the Pi with --robot_model alohamini2, then runs teleoperation, recording and replay from the PC with the am-leader-6dof profile. Recording uploads to the Hugging Face Hub unless push_to_hub is disabled. [7] [11] [12]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links. AI-assisted drafting with a separate LLM editorial judge; no independent human technical review.
Not yet established
- Requirements: operating system
Updates
- Upstream last updated
- Jul 1, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- 17c6a98d79881a45ab869c1f392ed89c0723a298 (commit snapshot; no published release; AlohaMini2 configuration) · combined hardware and software repository
Source files and licenses
Base CAD, URDF and documentation plus a separately licensed software fork are available; electronics and firmware sources are not, and the full archive could not be preserved.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Apache-2.0 Mobile Base 2 STL and STEP files and URDF in the tree; arms are in the AM-ARM repository. Root Apache-2.0 is the only license file; no hardware-specific license. Full archive not preserved (size); geometry not inspected. [3] [6] [9] |
| electronics | not found · License not fully assessed Purchased Raspberry Pi, buck converter, servo adapters and batteries; no custom electronics design files identified. [4] [9] |
| firmware | not found · License not fully assessed No firmware source identified; servos run vendor firmware. Arm pointer mentions firmware notes in AM-ARM, where none were identified. [8] [9] |
| software | available · Apache-2.0 Separate lerobot_alohamini fork (v0.6.0 preserved); upstream dependencies carry their own terms. [7] [11] [13] |
| documentation | available · Apache-2.0 README, BOM, print and assembly guides under the root Apache-2.0 license file. [1] [3] [4] [5] |
No trained weights distributed in the inspected sources.
No dataset distributed in the inspected sources; users record their own.
Licenses and gaps
The root LICENSE is Apache-2.0, the only license file identified; it is declared at repository level for STL, STEP and URDF files, and no hardware-specific license was found. The arms and software sit under their own repositories' licenses. The full repository, about 613 MB of files, exceeded the 150 MiB intake limit, so only selected documents and the file tree were preserved, and CAD and URDF geometry were not inspected. The reviewed commit, 17c6a98 of July 1, 2026, had 1,076 GitHub stars at retrieval, a dated popularity signal only. Load, lift and battery-runtime claims remain unverified. [2] [3] [9] [13]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 AlohaMini README
AlohaMini2 overview, updates, comparison with AlohaMini1, summary BOM, quick start, product line and team.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · revision
17c6a98· README.md at ; preserved snapshot sha256 f7163abb6b84… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 liyiteng/AlohaMini: commit 17c6a98
No published release; archive blocked by the 150 MiB intake limit; dated repository popularity.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · ; commit date 2026-07-01T16:17:18Z; manifest retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: What we checked, Source files and licenses - S003 liyiteng/AlohaMini: LICENSE
Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · revision
17c6a98· LICENSE; preserved snapshot sha256 c71d239df917… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Source files and licenses - S004 AlohaMini2 bill of materials
Host/client split, mobile base, follower and leader arm parts, fasteners and total estimate.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · revision
17c6a98· AlohaMini2/docs/BOM.md; preserved snapshot sha256 80eddaab3564… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Hardware & parts, Cost and 2 more - S005 AlohaMini2 assembly guide
Mobile Base 2 assembly: servo IDs, chassis epoxy, wheels, lift tower.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · revision
17c6a98· AlohaMini2/docs/assembly_guide.md; preserved snapshot sha256 36e022a22f36… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: What you need, Assembly & first use, Configuration a builder must reconcile, Source files and licenses - S006 AlohaMini2 print guide
Printer class, settings, STL list under mobile_base2/stl, printed-substitute warning.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · revision
17c6a98· AlohaMini2/docs/print_guide.md; preserved snapshot sha256 064b93bb19dd… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Configuration a builder must reconcile, Source files and licenses - S007 AlohaMini software pointer
Software maintained in lerobot_alohamini as single source of truth.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · revision
17c6a98· software/README.md; preserved snapshot sha256 634958346071… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: What you need, Software route, Source files and licenses - S008 AlohaMini2 arm pointer
Arm CAD, assembly guide and firmware notes maintained in liyiteng/AM-ARM.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · revision
17c6a98· AlohaMini2/hardware/am_arm200/README.md; preserved snapshot sha256 8f8893dc3688… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: What you need, Assembly & first use, Configuration a builder must reconcile, Source files and licenses - S009 Repository file tree at the reviewed commit
AlohaMini1 and AlohaMini2 hardware, URDF and docs folders; no arm STL folder under AlohaMini2.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AlohaMini contributors · github.com · revision
17c6a98· GitHub git/trees API, recursive, 360 entries, not truncated; filenames and sizes only · Accessed Oct 5, 2026
Used for: Is this for you?, Configuration a builder must reconcile, Source files and licenses - S010 AM-ARM200 bill of materials
Arm-level leader and follower servo specifications.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· am-arm200/bom.md at (preserved archive) · Accessed Oct 5, 2026
Used for: Is this for you?, Configuration a builder must reconcile - S011 lerobot_alohamini AlohaMini workflow and profiles
Pi host / PC client architecture, calibration, teleoperation, recording; robot_model profiles.Revision, date & where cited
Li Yiteng / lerobot_alohamini contributors (fork of Hugging Face LeRobot) · github.com · revision
e9d6362· docs/alohamini/alohamini.md and profiles.md at (release v0.6.0) · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration a builder must reconcile and 2 more - S012 lerobot_alohamini release notes
v0.6.0 sync with LeRobot 0.6; v0.3.0 added AlohaMini2 support.Revision, date & where cited
Li Yiteng / lerobot_alohamini contributors (fork of Hugging Face LeRobot) · github.com · GitHub releases v0.6.0 and v0.3.0 · Accessed Oct 5, 2026
Used for: What you need, Software route - S013 lerobot_alohamini license
Revision, date & where cited
Li Yiteng / lerobot_alohamini contributors (fork of Hugging Face LeRobot) · github.com · revision
e9d6362· LICENSE (Apache License 2.0) · Accessed Oct 5, 2026
Used for: Source files and licenses - S014 Upstream image and reuse attribution
Media-only review: Upstream photograph of an AlohaMini arm; the pictured arm does not establish a complete leader-and-follower setup. Reuse basis: Apache-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
liyiteng and AlohaMini contributors · github.com · revision
17c6a98· Image SHA-256 0e74b5425e864114e2e460fa16b571c1b11590c044a26a7691bab1103d79f814; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Created from Growbotics-listing lead; all claims checked against preserved upstream sources. No physical build or test.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.