AM-ARM200
Robot / hardware buildPrintable 6+1 DoF leader/follower arm pair using Feetech STS3215 and STS3095 servos, with LeRobot support supplied through the separate lerobot_alohamini fork. [1] [4] [8]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Makers, students and research labs with an FDM printer who are comfortable with the LeRobot command-line workflow [1] [8]
- Cost
- USD 144.44–243.33 upstream parts estimates for 2 versions [4] · checked Oct 5, 2026 · DetailsNot included: 3D-printed parts and filament, optional camera and bearings and host computer and more.
- Source rights
- Named licenses are documented by part. Review licenses
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- Ecosystem
- LeRobot
- License
- Apache-2.0 · Details by part
Overview
AM-ARM200 is a 3D-printed leader and follower arm pair from Li Yiteng and Wu Zhiyong. The README describes a 6+1 DoF arm with a 1 kg payload and 52 cm reach, built for embodied-AI research and modelled on SO-ARM100. Payload and reach are upstream claims; this entry is source research only, with no build, calibration or teleoperation performed. [1]
It suits builders who already know the SO-ARM and LeRobot workflow. The README's motor list adds a wrist_yaw joint and assigns STS3095 servos to shoulder pan, shoulder lift and elbow. The BOM page says SO100/SO101 owners can upgrade "by simply adding the missing parts", but the inspected files do not list which existing parts carry over. [1] [4]
Is this for you?
- Use cases
- Leader/follower teleoperation
- Dataset recording and replay
- Policy training and evaluation through the lerobot_alohamini workflow
- Arm platform for AlohaMini2
- Known limitations
- Software and calibration depend on a separate LeRobot fork or a manual upstream patch
- No firmware folder identified despite README claim
- README and BOM disagree on the STS3095 gear ratio and leader total
- Payload and reach are unverified upstream claims
Source-review boundaries; no hardware tests.
What you need
- Operating system
- Linux (install guide targets x86-64 Ubuntu PCs)
- Host computer
One PC for teleoperation and recording (no Raspberry Pi required); the training example uses a CUDA device or a rented cloud GPU.
- Dependencies
- lerobot_alohamini (LeRobot fork; v0.6.0 notes state sync with LeRobot 0.6)
- Python 3.12 conda environment
- feetech-servo-sdk, pyzmq and ffmpeg 7.1.1
- Tools
- Well-tuned FDM printer (Bambu Lab P2S or higher recommended)
- Heat source for heat-set inserts
Hardware & parts
Upstream bill of materials [4]
- Hardware configuration
Tabletop serial arm with a gripper; a servo-based leader arm drives the follower for teleoperation.
- Actuators
- Follower: 4× Feetech STS3215 (12 V, 1/345) and 3× Feetech STS3095 (12 V)
- Leader: 7× Feetech STS3215 (5 V, 1/147)
README lists STS3095 as 1/399 while bom.md lists 1/345.
- Controller
Waveshare bus servo controller per arm, connected to the host PC by USB-C
- Power
12 V 4 A adapter for the follower; 5 V adapter for the leader
- Degrees of freedom
6
README states 6+1 DoF: six arm joints plus the gripper.
- Dimensions
Reach about 52 cm (upstream claim)
Assembly & first use
Open the upstream getting-started guide [1]
- Buy servos, controllers, power supplies and small parts per bom.md
- Print parts (about 20 hours on an FDM printer)
- Set servo IDs (and leader phase) and assemble leader and follower
- Install lerobot_alohamini, find ports, calibrate with the AM arm profiles, then teleoperate, record, train and evaluate
- Assembly
Photo-illustrated leader and follower guides: set servo IDs first, reset leader servos to single-turn, assemble base, shoulder, elbow, wrist and gripper, install heat-set inserts, camera mount and controller.
- Calibration
Servo IDs via the lerobot_alohamini debug command or Feetech FD tool; LeRobot calibration with am-leader-6dof and am-follower-6dof profiles, then power-cycle.
- Assembly time
About 60 minutes for a leader and follower pair, plus about 20 hours of printing (upstream estimates)
Cost
| Version | Price |
|---|---|
| AM-ARM200 follower arm, commit 5b03af1 bom.md | USD 243.33 [4] Parts estimate |
Upstream US/EU price column · Checked 2026-10-05
| Included | 4× STS3215 and 3× STS3095 servos; Waveshare bus servo controller; 12 V 4 A power supply; USB-C cable and servo extension cables |
|---|---|
| Not included | 3D-printed parts and filament; Optional camera and bearings; Host computer; Shipping, taxes and assembly labor |
| Stock | Vendor stock and current prices not rechecked. |
| Delivery and tax | Not established; no delivered total quoted. |
Price details
Upstream bom.md follower total in its US/EU column; screws and heat-set inserts carry no US price. README rounds to about $240/$243. Not re-quoted.
Upstream US/EU price column · Checked 2026-10-05 · Quantity 1
Printed parts, host computer; leader arm needed for teleoperation.
| Version | Price |
|---|---|
| AM-ARM200 leader arm, commit 5b03af1 bom.md | USD 144.44 [4] Parts estimate |
Upstream US price column · Checked 2026-10-05
| Included | 7× STS3215 5 V servos; Waveshare bus servo controller; 5 V power supply; USB-C cable |
|---|---|
| Not included | 3D-printed parts and filament; Optional camera and bearings; Host computer; Shipping, taxes and assembly labor |
| Stock | Vendor stock and current prices not rechecked. |
| Delivery and tax | Not established; no delivered total quoted. |
Price details
Upstream bom.md leader total; the README leader table totals about $137 using a $5 controller price. Not re-quoted.
Upstream US price column · Checked 2026-10-05 · Quantity 1
Printed parts; follower arm and host computer.
Cost scope
bom.md totals US$243.33 for the follower and US$144.44 for the leader in its US/EU price column; printed parts are self-printed and unpriced, and screws and inserts have no US price. The README instead gives about $243 and $137 in its tables and about $380 for the full kit. Treat these as dated upstream estimates, not re-quoted prices; filament, camera, host computer, shipping and tax are excluded. [1] [4]
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
What to buy and print
Each arm needs its own Waveshare bus servo controller, USB-C cable and power adapter. The follower adds four STS3215 servos (12 V, 1/345), three STS3095 servos, six servo extension cables and a 12 V 4 A adapter; the leader uses seven 5 V, 1/147 STS3215 servos and a 5 V adapter. The follower list adds 74 M3×10 screws and four M3×5×4 heat-set inserts; the leader insert row (same M3×5×4 size) gives both 4 and "total 36 pcs", so confirm that quantity. The README lists the STS3095 as 1/399, while bom.md lists 1/345; confirm before ordering. [1] [4]
Print files sit in separate am-arm200/stl/follower and am-arm200/stl/leader folders (STEP copies in stp/), and the elbow and wrist pins come in bearing and no-bearing versions. No per-arm print manifest with quantities was identified, so reconcile file choices against the assembly guide. Parts print in PLA, PETG or ABS, and the guide strongly recommends six walls for the follower. The README estimates about 20 hours of printing and about 60 minutes to assemble a pair. [1] [5] [6] [7]
Route to a working pair
1. Assign each servo's ID before assembly, and reset the leader servos from factory multi-turn mode with the phase command. [6] 2. Assemble both arms from the photo guides, including heat-set inserts. [6] 3. Install lerobot_alohamini on one PC: the guide targets an x86-64 Ubuntu machine with a Python 3.12 conda environment, feetech-servo-sdk, pyzmq and FFmpeg 7.1.1. [8] 4. Calibrate leader and follower with the so101_leader and so101_follower types and the am-leader-6dof and am-follower-6dof profiles, then power-cycle both arms. [8] [9] 5. Teleoperate and record; the training example uses a CUDA device or a rented cloud GPU. [8]
The fork's v0.6.0 release notes say it was synced with LeRobot 0.6. The README also describes patching upstream LeRobot's motor table instead; neither route was tested here. The README says "CAD, firmware, and software included", yet the pinned archive contains no code, and no firmware folder was identified. [1] [7] [9]
What we checked
Source research only; no installation, physical build, calibration or performance test performed. No affiliate links. AI-assisted drafting with a separate LLM editorial judge; no independent human technical review.
Updates
- Upstream last updated
- Jun 18, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- 5b03af1ef6c80595bd988e0137cf8e7c35811eb6 (commit snapshot; no published release found) · repository
Source files and licenses
Mechanical files, documentation and a separately licensed software fork are available; firmware and electronics sources are not, and hardware-specific licensing is not established.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Apache-2.0 STL and STEP files for leader and follower plus URDF models in the pinned archive. Apache-2.0 is the repository-level license file; no hardware-specific license identified. Purchased parts are not covered. [3] [7] |
| electronics | not found · License not fully assessed Uses purchased Waveshare bus servo controllers and Feetech servos; no custom electronics design files identified in the inspected sources. [4] [7] |
| firmware | not found · License not fully assessed README says firmware is included, but no firmware folder was identified in the pinned archive. Servos run vendor firmware configured with ID/phase tools. [1] [7] |
| software | available · Apache-2.0 Software is the separate lerobot_alohamini fork (release v0.6.0 preserved). Upstream LeRobot and Python dependencies carry their own terms. [8] [10] |
| documentation | available · Apache-2.0 README, BOM, print and assembly guides in the pinned archive under the root Apache-2.0 license file. [1] [3] [4] [6] |
No trained policy weights are distributed in the inspected sources; users train their own.
No dataset is distributed in the inspected sources; users record their own.
Licenses and open questions
The only license file identified is the root Apache-2.0 LICENSE, declared at repository level for the CAD files and documentation; no hardware-specific license or NOTICE file was found, and purchased servos and boards are outside it. lerobot_alohamini carries its own Apache-2.0 LICENSE. [3] [7] [10]
The repository has no published release; this entry covers commit 5b03af1 from June 18, 2026, which had 80 GitHub stars at retrieval, a dated popularity signal only. The README still says URDF files are "coming soon", although the archive contains URDF models. Servo firmware provenance, payload at full reach and the "Coming Soon" Pro variant remain unverified. [1] [2] [7] [11]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 AM-ARM README
Overview, headline specifications, summary BOM tables, getting-started route, product line and team.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· README.md at · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 4 more - S002 AM-ARM repository revision and acquisition metadata
No published release in the first 100 releases; default-branch commit snapshot archived with SHA-256 0d411bc8…; dated repository popularity.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· ; commit date 2026-06-18T10:35:49Z; manifest retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: What we checked, Source files and licenses - S003 AM-ARM repository license
Root Apache-2.0 license file; only license file identified in the pinned archive.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· LICENSE (Apache License 2.0 text) · Accessed Oct 5, 2026
Used for: Source files and licenses - S004 AM-ARM200 bill of materials
Follower, leader and optional part tables with US/EU and CN prices and per-arm totals.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Hardware & parts, Cost and 2 more - S005 AM-ARM200 3D printing guide
Printer, material, wall/infill and orientation recommendations.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· Accessed Oct 5, 2026
Used for: What you need, What to buy and print - S006 AM-ARM200 hardware assembly guide
Servo ID and phase configuration, leader and follower assembly sequence.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· Accessed Oct 5, 2026
Used for: What you need, Hardware & parts, Assembly & first use, What to buy and print and 2 more - S007 Pinned AM-ARM archive file inventory
Lists STL, STP, URDF, documentation and media paths; no firmware or software source folder identified.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· Complete filename inventory of archive (155 members); not a completeness or printability test · Accessed Oct 5, 2026
Used for: Is this for you?, What to buy and print, Route to a working pair, Source files and licenses - S008 lerobot_alohamini README and AM-ARM200 workflow
Shared software layer; installation, calibration, teleoperation, recording, training and evaluation commands for AM-ARM200.Revision, date & where cited
Li Yiteng / lerobot_alohamini contributors (fork of Hugging Face LeRobot) · github.com · revision
e9d6362· README.md, docs/alohamini/install.md and docs/alohamini/am-arm200.md at (release v0.6.0) · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, Route to a working pair and 1 more - S009 lerobot_alohamini release notes and hardware profiles
v0.6.0 notes state sync with upstream LeRobot 0.6; v0.3.0 added AM-ARM200 support; arm-profile names per SKU.Revision, date & where cited
Li Yiteng / lerobot_alohamini contributors (fork of Hugging Face LeRobot) · github.com · GitHub releases v0.6.0 and v0.3.0; docs/alohamini/profiles.md at · Accessed Oct 5, 2026
Used for: What you need, Assembly & first use, Route to a working pair - S010 lerobot_alohamini license
Revision, date & where cited
Li Yiteng / lerobot_alohamini contributors (fork of Hugging Face LeRobot) · github.com · revision
e9d6362· LICENSE (Apache License 2.0, Hugging Face copyright header) · Accessed Oct 5, 2026
Used for: Source files and licenses - S011 AM-ARM200 Pro note
Pro variant marked Coming Soon; STS3250 servo upgrade described.Revision, date & where cited
Li Yiteng and Wu Zhiyong / AM-ARM contributors · github.com · revision
5b03af1· Accessed Oct 5, 2026
Used for: Source files and licenses - S012 Upstream image and reuse attribution
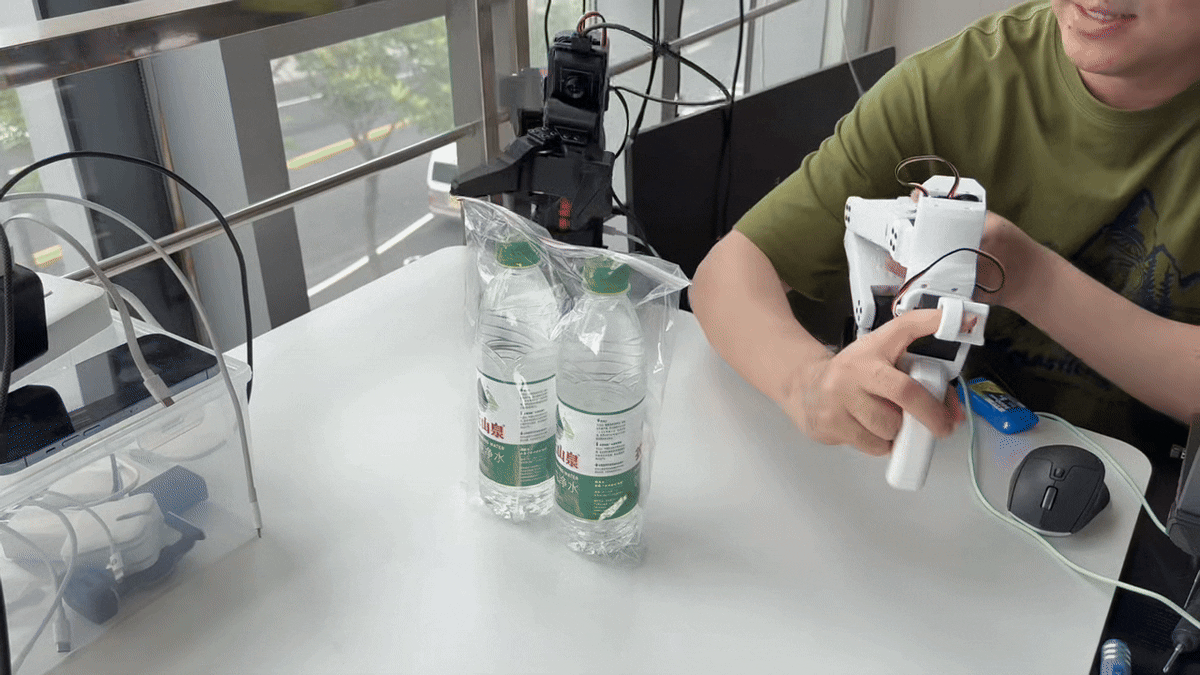
Media-only review: Still from an upstream demonstration: an AM-ARM200 manipulation setup; the operator and laboratory equipment are demonstration context. Reuse basis: Apache-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Still taken from the upstream animation; no other changes. This does not refresh technical or cost evidence.Revision, date & where cited
liyiteng and AM-ARM contributors · github.com · revision
5b03af1· Image SHA-256 cc6fa41beabdd7cfd16cf77cee2cb07723c6deeb5d85e074ea7b9502e1ca74c5; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Created from Growbotics-listing lead; all claims checked against preserved upstream sources. No physical build or test.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.