Amazing Hand
End effectorA printable four-finger hand with eight actuators and a Reachy 2 wrist interface. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- EUR 116.89–142.29 upstream parts estimates for 3 versions [4] · checked Sep 30, 2026 · DetailsNot included: external 5 V supply unpriced, host computer and tools and labor and more.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-4.0, Apache-2.0 · Details by part
Overview
Amazing Hand packages four fingers and eight Feetech SCS0009 servos into a printable hand. Its v1.0 README describes a wrist interface for Reachy 2's Orbita 3D and offers two control routes: a serial-bus board with Python, or an Arduino with a Feetech TTL linker. Builders adapting it to another arm need a separate mounting check. [1] [3]
Is this for you?
- Known limitations
- External BOM not pinned to the mechanical release; resolve screw-label/link-column length mismatch, external 5 V supply, servo ID mapping and destination quotes. Upstream reports prototype angle discrepancies and untested long/complex grasping.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
3D preview
Left hand plate. One left-hand plate component from the mechanical STEP files, not the complete hand. This is the left-hand variant.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
This model contains one geometric body.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Pollen Robotics contributors, revision 23a262c94748ac061a63c6d32158a7f094c25b6e. Original and preview: CC-BY-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Dexterous hands
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
Build files and instructions follow below.
Build files and instructions
Start with the original standalone right hand at v1.0. Our print manifest maps 14 file types to 45 pieces, including one tooling piece. The “Soft Shell” row is mapped to the right palm shell by name and function; its fit and the mutable spreadsheet's agreement with v1.0 CAD still need verification. [91]
- Download the pinned v1.0 source archive or browse the STL and STEP files.
- Open the purchased-parts BOM and printed-parts sheet. [4] [5]
- Use our print-file manifest with individual download links or spreadsheet-ready CSV, alongside the assembly PDF and printing PDF.
- For the Python/Waveshare route, use the Python demo. The alternative Arduino demo is a separate route. These links correct the reversed folder destinations in the upstream basic-demo section. [1] [8]
Cost
| Version | Price |
|---|---|
| Hand BOM without control electronics | EUR 116.89 [4] Parts estimate |
France-linked upstream supplier examples; destination unspecified · Checked 2026-09-30
| Included | Hand mechanical/electromechanical BOM; EUR 15 upstream print allowance |
|---|---|
| Not included | External 5 V supply unpriced; Host computer; Tools and labor; Shipping and destination taxes not established |
| Stock | Supplier stock and package quantities not re-quoted. |
| Delivery and tax | Not established for a destination; no delivered total. |
Price details
Dated external spreadsheet snapshot, not current supplier quotations or a release-matched BOM. Alternative controller routes must not be summed.
France-linked upstream supplier examples; destination unspecified · Checked 2026-09-30 · Quantity 1
Host, power, tools and host-arm integration must be reconciled; one end-effector subsystem, not a complete arm.
| Version | Price |
|---|---|
| Hand BOM with Waveshare board | EUR 128.28 [4] Parts estimate |
France-linked upstream supplier examples; destination unspecified · Checked 2026-09-30
| Included | Hand BOM; Waveshare serial-bus board |
|---|---|
| Not included | External 5 V supply unpriced; Host computer; Tools and labor; Shipping and destination taxes not established |
| Stock | Supplier stock and package quantities not re-quoted. |
| Delivery and tax | Not established for a destination; no delivered total. |
Price details
Dated external spreadsheet snapshot, not current supplier quotations or a release-matched BOM. Alternative controller routes must not be summed.
France-linked upstream supplier examples; destination unspecified · Checked 2026-09-30 · Quantity 1
Host, power, tools and host-arm integration must be reconciled; one end-effector subsystem, not a complete arm.
| Version | Price |
|---|---|
| Hand BOM with Arduino Mega and TTL linker | EUR 142.29 [4] Parts estimate |
France-linked upstream supplier examples; destination unspecified · Checked 2026-09-30
| Included | Hand BOM; Arduino Mega; Feetech TTL linker |
|---|---|
| Not included | External 5 V supply unpriced; Host computer; Tools and labor; Shipping and destination taxes not established |
| Stock | Supplier stock and package quantities not re-quoted. |
| Delivery and tax | Not established for a destination; no delivered total. |
Price details
Dated external spreadsheet snapshot, not current supplier quotations or a release-matched BOM. Alternative controller routes must not be summed.
France-linked upstream supplier examples; destination unspecified · Checked 2026-09-30 · Quantity 1
Host, power, tools and host-arm integration must be reconciled; one end-effector subsystem, not a complete arm.
Project notes
Choose the controller before budgeting
The external BOM retrieved on September 30, 2026 lists EUR 116.89 for the hand parts, including eight servos and an estimated EUR 15 of printing. Adding its EUR 11.39 Waveshare board gives EUR 128.28. Choosing the EUR 24 Arduino Mega and EUR 1.40 TTL linker instead gives EUR 142.29. These are alternative upstream estimates; do not buy both control routes simply to reproduce the quoted totals. [4]
The sheet also lists an external 5 V supply without a price. Its totals therefore do not establish a complete powered setup. Shipping, destination taxes, host computer, tools and labor are not established in those totals. The sheet's dollar conversions use its own exchange-rate assumption and are not current foreign-exchange quotes. The external sheet is a dated snapshot, not an immutable component of the v1.0 release. [4]
Fabrication and setup checks
The print list separates PLA structural components from flexible shells. It specifies four copies of the main finger parts and eight spacers, with left/right geometry handled in the repository. The control examples link servo-ID setup instructions; the Arduino route calls for SCServo and distinguishes Uno and Mega serial connections. Those steps need configuration matching before a build pack is called complete. [1] [5] [6] [7]
There is also a purchasing detail to resolve: the BOM's 2.5 × 6 and 2.5 × 8 thermoplastic-screw row labels conflict with the length annotations in its link column. Preserve the specified lengths and check the assembly instead of silently following either link. Mechanical files are stated as CC BY 4.0 and project code as Apache-2.0. Those statements do not establish the design or firmware terms of purchased servos and controller boards; external libraries need separate review. [4] [1] [2]
The upstream README reports differences between theoretical and prototype joint angles, says long and complex grasping tasks have not yet been tested, and says additional control software is needed to avoid damaging components during grasping. These are upstream limitations, separate from our own lack of physical assembly or performance testing. [1]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Research scope and retained receipts
The check receipt records syntax checks for the Python examples and successful imports of the controller class and required methods with Python 3.14.7, rustypot 1.10.0 and numpy 2.5.3 on macOS ARM64. No controller was instantiated, serial port opened or hand operated. This candidate environment is not an upstream compatibility guarantee. [90]
Before running the demo, follow the motor-ID setup notes to configure the servo IDs and replace its example serial port and calibration offsets for the actual hand. The upstream motor-configuration utility is Windows-specific and was not executed; motor setup on the chosen host remains an open step. The Arduino route was not compiled in this check. [8] [90]
Not yet established
- Requirements: operating system, host computer, tools
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 23a262c94748ac061a63c6d32158a7f094c25b6e; v1.0 repository; dated external BOM snapshot, exact left/right configuration still required
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-4.0 CC BY 4.0 mechanical design; Apache-2.0 project code. Third-party servos and controller boards are purchased components. [1] [2] [3] [4] [5] [6] [7] |
| electronics | not found · License not fully assessed A complete configuration-matched source set for this layer is not established by this review; purchased parts and linked repositories must be assessed separately. This is not a claim that the layer is closed source. [1] [2] [3] [4] [5] [6] [7] |
| firmware | available · Apache-2.0 Arduino/Python examples in this repository; purchased servo firmware and external libraries are separate. [1] [2] [3] [4] [5] [6] [7] |
| software | available · Apache-2.0 Arduino/Python examples in this repository; purchased servo firmware and external libraries are separate. [1] [2] [3] [4] [5] [6] [7] |
| documentation | available · CC-BY-4.0 CC BY 4.0 mechanical design; Apache-2.0 project code. Third-party servos and controller boards are purchased components. [1] [2] [3] [4] [5] [6] [7] |
This configuration is reviewed as a physical end effector with ordinary control, without a selected learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 pollen-robotics/AmazingHand: README.md
Revision, date & where cited
github.com · revision
23a262c· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S002 pollen-robotics/AmazingHand: LICENSE
Revision, date & where cited
github.com · revision
23a262c· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Fabrication and setup checks and 1 more - S003 pollen-robotics/AmazingHand: files
Revision, date & where cited
github.com · revision
23a262c· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Assembly & first use and 1 more - S004 bom
Revision, date & where cited
pollen-robotics / project contributors · docs.google.com · source.bin · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Build files and instructions and 4 more - S005 prints
Revision, date & where cited
pollen-robotics / project contributors · docs.google.com · source.bin · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Build files and instructions and 2 more - S006 arduino
Revision, date & where cited
github.com · revision
23a262c· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Fabrication and setup checks and 1 more - S007 python
Revision, date & where cited
github.com · revision
23a262c· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Fabrication and setup checks and 1 more - S008 Pinned Python demo
Python demo uses numpy and rustypot with a configured serial port, servo IDs and offsets. These values must be adapted to the actual hand.Revision, date & where cited
Pollen Robotics / Amazing Hand contributors · github.com · revision
23a262c· Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: Build files and instructions, What we checked - S094 Upstream image and reuse attribution
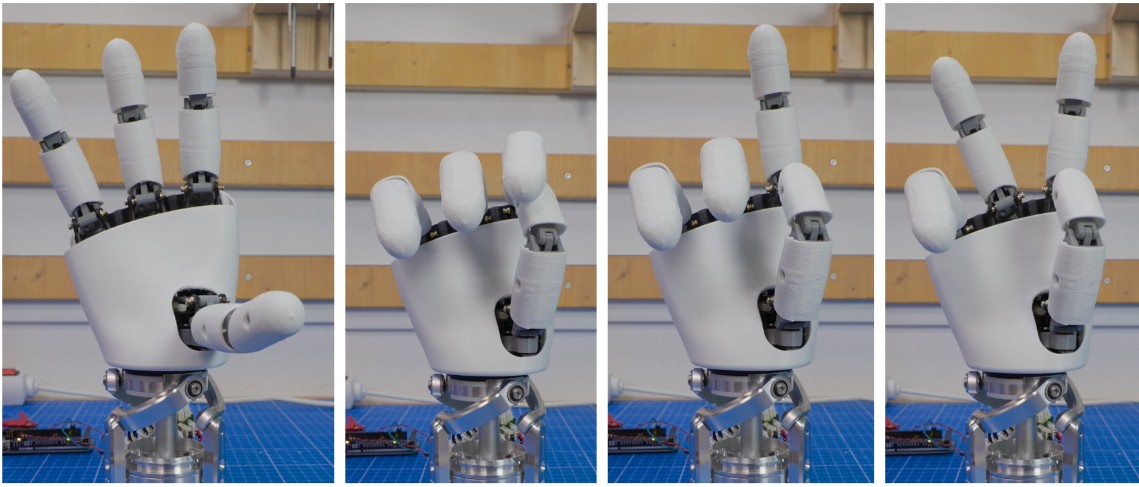
Media-only review: Upstream photographs of AmazingHand demonstrating different finger poses. Reuse basis: Apache-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Pollen Robotics contributors · github.com · revision
23a262c· Image SHA-256 0eb72bd5d826357f3805f01aa467513fd535a7bbeeb530f0b4b7e88e9878ab25; repository · Accessed Oct 25, 2026
Our checks and receipts
- S090 Build-file and software-check receipt
Revision, date & where cited
Open Source Robotics · opensourcerobotics.dev · Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: What we checked - S091 Configuration-specific print-file manifest
Revision, date & where cited
Open Source Robotics · opensourcerobotics.dev · Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: Build files and instructions
Videos
- S092 Pollen Robotics (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Pollen Robotics · youtube.com · Accessed Oct 4, 2026
- S093 AH! (Amazing Hand!) demo (YouTube video)
Video uploaded by Steve N'Guyen, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Steve N'Guyen · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-09-30 — Added configuration-specific build resources, print-file manifests and scoped software-check evidence; physical testing remains unperformed.
2026-10-04 — Added 2 YouTube reference(s) (S092, S093): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.