Annin AR4 (MK3 configuration)
Robot / hardware buildA six-axis workshop arm with printed or aluminum structure; this review covers MK3 and its matching 6.3-series controls. [1]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Experienced makers; Robotics educators [1]
- Cost
- No current cost yet. Upstream bill of materials [6]
- Source rights
- Some licenses are unresolved. Includes noncommercial terms. Review licenses
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- Annin Robotics custom noncommercial license v1.1 (2025) (noncommercial) · license not fully assessed for documentation · Details by part
Overview
AR4-MK3 offers a choice between printed structural parts and an aluminum structure, but either route involves substantial mechanical and electrical assembly. The manual groups the build into printed covers and spacers, structure, mechanical hardware, six stepper motors with drivers, and electrical components. A gripper adds its own parts list. Even the printed version needs a cut and drilled aluminum J4 tube. [6]
Is this for you?
What you need
- Operating system
- Windows 10/11 x64 recommended by the control README
- Linux/macOS source-build support reported, not reproduced
- Dependencies
- Python 3.11–3.12 for the inspected source application
- requirements.txt; kinematics extension must match host Python/platform
- Tools
- Metric hand tools, soldering equipment and multimeter
- 3D printer, drill bits, M3/M4 taps, calipers and angle gauge
- Bearing press or suitable vise for square bearing insertion
Hardware & parts
Upstream bill of materials [6]
- Actuators
- Six stepper motors and separate drivers
Assembly & first use
Open the upstream getting-started guide [1] [6]
- Assembly
Choose printed or aluminum structure. Printed builds still require a cut/drilled aluminum J4 tube; wiring, bearing fitting and threaded-hole finishing remain necessary.
- Calibration
Chapter 8 sequences wiring checks, motor direction/travel, limit switches, encoder checks and individual joint offsets. Not reproduced here.
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
No hosted 3D preview: the upstream license restricts hosting and commercial use of the AR4 design files, so Open Source Robotics does not host a model or derived preview of them. Annin Robotics Open Source Non-Commercial License Agreement, Version 1.1 (2025), Section 2.2 states: “No Redistribution: Redistribution, republishing, or hosting of design files or physical components in any form is strictly prohibited.” The same license limits the design files to educational, research and personal non-commercial use and prohibits selling robots, parts, kits or derivatives without written permission. License: LICENSE.txt v1.1 in Annin-Robotics/ar4-hmi.
Model sources
The upstream license (Annin Robotics LICENSE.txt v1.1, Section 2.2) prohibits hosting of the design files, so no hosted preview is offered (user decision, October 4, 2026). The original design is linked.
Project notes
Keep the MK3 files together
The official downloads page separates MK3, MK4 and MK5. Its MK3 section lists control source 6.3.1, Teensy firmware 6.3 and Nano/Mega sketches 1.3. This profile preserves the GitHub 6.3.1 snapshot, the MK3 version 1.8 manual and the separate MK3 print archive. Newer version numbers elsewhere on that page do not establish compatibility with this configuration. [2] [5] [6] [7]
There is also a concrete setup discrepancy: the repository README tells readers to enter a Control Software directory, but the inspected archive has AR4.py and requirements.txt at its root, with firmware under Sketches. The README recommends Windows 10/11 x64 and Python 3.11–3.12, and reports source-build support for Linux and macOS. Match the kinematics extension to the host rather than treating the presence of several prebuilt binaries as a tested installation. [1] [4]
Assembly includes fitting, wiring and calibration
Budget for tools as well as parts. The manual calls for soldering, drilling and tapping printed holes, bearing fitting, and angle measurement. Chapter 8 proceeds through wiring checks, motor direction and travel, switches and encoders before joint calibration. These steps provide a concrete future test plan; we have not performed them. A current complete delivered cost remains unknown, including the chosen structure, gripper, host computer and tools. [6]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A step-by-step setup summary
Updates
- Upstream last updated
- Nov 4, 2025 [2]
- Latest release
- Nov 4, 2025 [2]
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- cac21f5b33c6b26c1416efca3e7f4dad0b8b0a39 (GitHub v6.3.1); MK3 manual 1.8 and separately preserved MK3 print archive. Official MK3 download section pairs source 6.3.1 with Teensy 6.3 and Nano/Mega 1.3. · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Annin Robotics custom noncommercial license v1.1 (2025) Printable MK3 files preserved; does not establish complete editable CAD or purchased-component manufacturing sources. License section 2 restricts redistribution and commercial use. [3] [6] [7] |
| electronics | not found · License not fully assessed Wiring and component BOM documented, but complete manufacturing sources for all purchased controllers/drivers were not established in this review. [4] [6] |
| firmware | available · Annin Robotics custom noncommercial license v1.1 (2025) Custom terms, not ordinary BSD-3-Clause. Commercial licensing and redistribution conditions require separate review. [3] [4] |
| software | available · Annin Robotics custom noncommercial license v1.1 (2025) Custom terms, not ordinary BSD-3-Clause. Commercial licensing and redistribution conditions require separate review. [3] [4] |
| documentation | available · License not fully assessed Public build manual; separate reuse license for this PDF not established. [6] |
This profile covers programmed arm control, without a specified learned policy.
Read the custom license before planning an offer
The pinned license grants noncommercial software use under its conditions, while its hardware section restricts redistribution and commercial use of the designs. It directs commercial product or service proposals to a separate licensing discussion. Its optional BSD-related badge text should not be read as an ordinary BSD-3-Clause grant. The files are useful for research, but this catalog entry does not establish permission to sell a robot, kit or support bundle. [3]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Annin-Robotics/ar4-hmi: README.md
Revision, date & where cited
github.com · revision
cac21f5· Accessed Sep 30, 2026
Used for: What you need, Hardware & parts, Assembly & first use, Keep the MK3 files together - S002 Annin-Robotics/ar4-hmi: commit cac21f5
Revision, date & where cited
github.com · Accessed Sep 30, 2026
Used for: Keep the MK3 files together, What we checked - S003 Annin-Robotics/ar4-hmi: LICENSE.txt
Revision, date & where cited
github.com · revision
cac21f5· Accessed Sep 30, 2026
Used for: Is this for you?, Source files and licenses - S004 Annin-Robotics/ar4-hmi: files
Revision, date & where cited
github.com · revision
cac21f5· archive file inventory · Accessed Sep 30, 2026
Used for: Is this for you?, Keep the MK3 files together, Source files and licenses - S005 Official generation-specific downloads
Revision, date & where cited
Annin-Robotics / project contributors · anninrobotics.com · MK5, MK4 and MK3 download sections · Accessed Sep 30, 2026
Used for: Is this for you?, Keep the MK3 files together - S006 AR4-MK3 build manual version 1.8
Revision, date & where cited
Annin-Robotics / project contributors · anninrobotics.com · Overview, assembly tools, printed structure and Chapter 8 startup · Accessed Sep 30, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 3 more - S007 MK3 print archive and preservation receipt
Revision, date & where cited
Annin-Robotics / project contributors · anninrobotics.com · ZIP member inventory; integrity and SHA-256 verified · Accessed Sep 30, 2026
Used for: Keep the MK3 files together, Source files and licenses - S011 Upstream image and reuse attribution
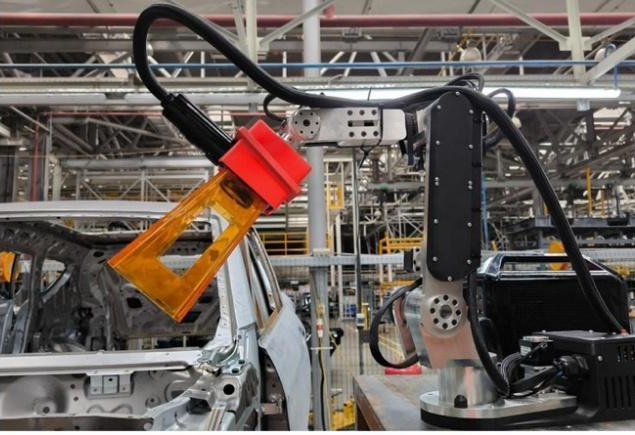
Media-only review: Paper photograph of an Annin AR4-MK3 fitted with the study’s electromagnetic marking tool, cropped from its experimental workcell figure. Reuse basis: CC-BY-4.0. The actual paper’s abstract, section III.A and Figure 1 identify AR4-MK3, matching the selected MK3 record. Its interface panel also identifies AR4-MK3 HMI 6.3. Crop selects the upper-right physical arm/tool photograph, excluding the screen and second closeup. Caption discloses the added marking tool. The publisher’s exact article page explicitly grants commercial reuse under CC BY 4.0; no restriction or third-party credit is attached to the authors’ experimental figure. Image provenance does not establish measured performance. Embedded image extracted from page 3 of the source PDF and losslessly decoded to PNG; no retouching. Cropped to isolate the AR4-MK3 arm and marking tool in the upper-right photo panel; full extracted image retained. Technical/cost evidence dates unchanged.Revision, date & where cited
Olzhas Olzhayev, Akhanserі Ikramov and Sayat Ibrayev · doi.org · A Vision-Based Error Compensation Method for Accurate Robotic Positioning in Automated Marking, page 3 Figure 1 upper-right photograph; publisher article reuse declaration; image SHA-256 1bf833f65fef18b8741dbc7c7096326e7a80d1acad32f40efc21e2e7ea9effcc · Accessed Oct 26, 2026
Videos
- S008 Chris Annin (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Chris Annin · youtube.com · Accessed Oct 4, 2026
- S009 Affordable 6 Axis Desktop Robot Arm - educational & industrial DIY robot kit - Arduino controller (YouTube video)
Video from the project’s own channel (Chris Annin), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Chris Annin · youtube.com · Accessed Oct 4, 2026
- S010 AR4 robot grippers and IO connections (YouTube video)
Video from the project’s own channel (Chris Annin), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Chris Annin · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 3 YouTube reference(s) (S008, S009, S010): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.