Asimov v0
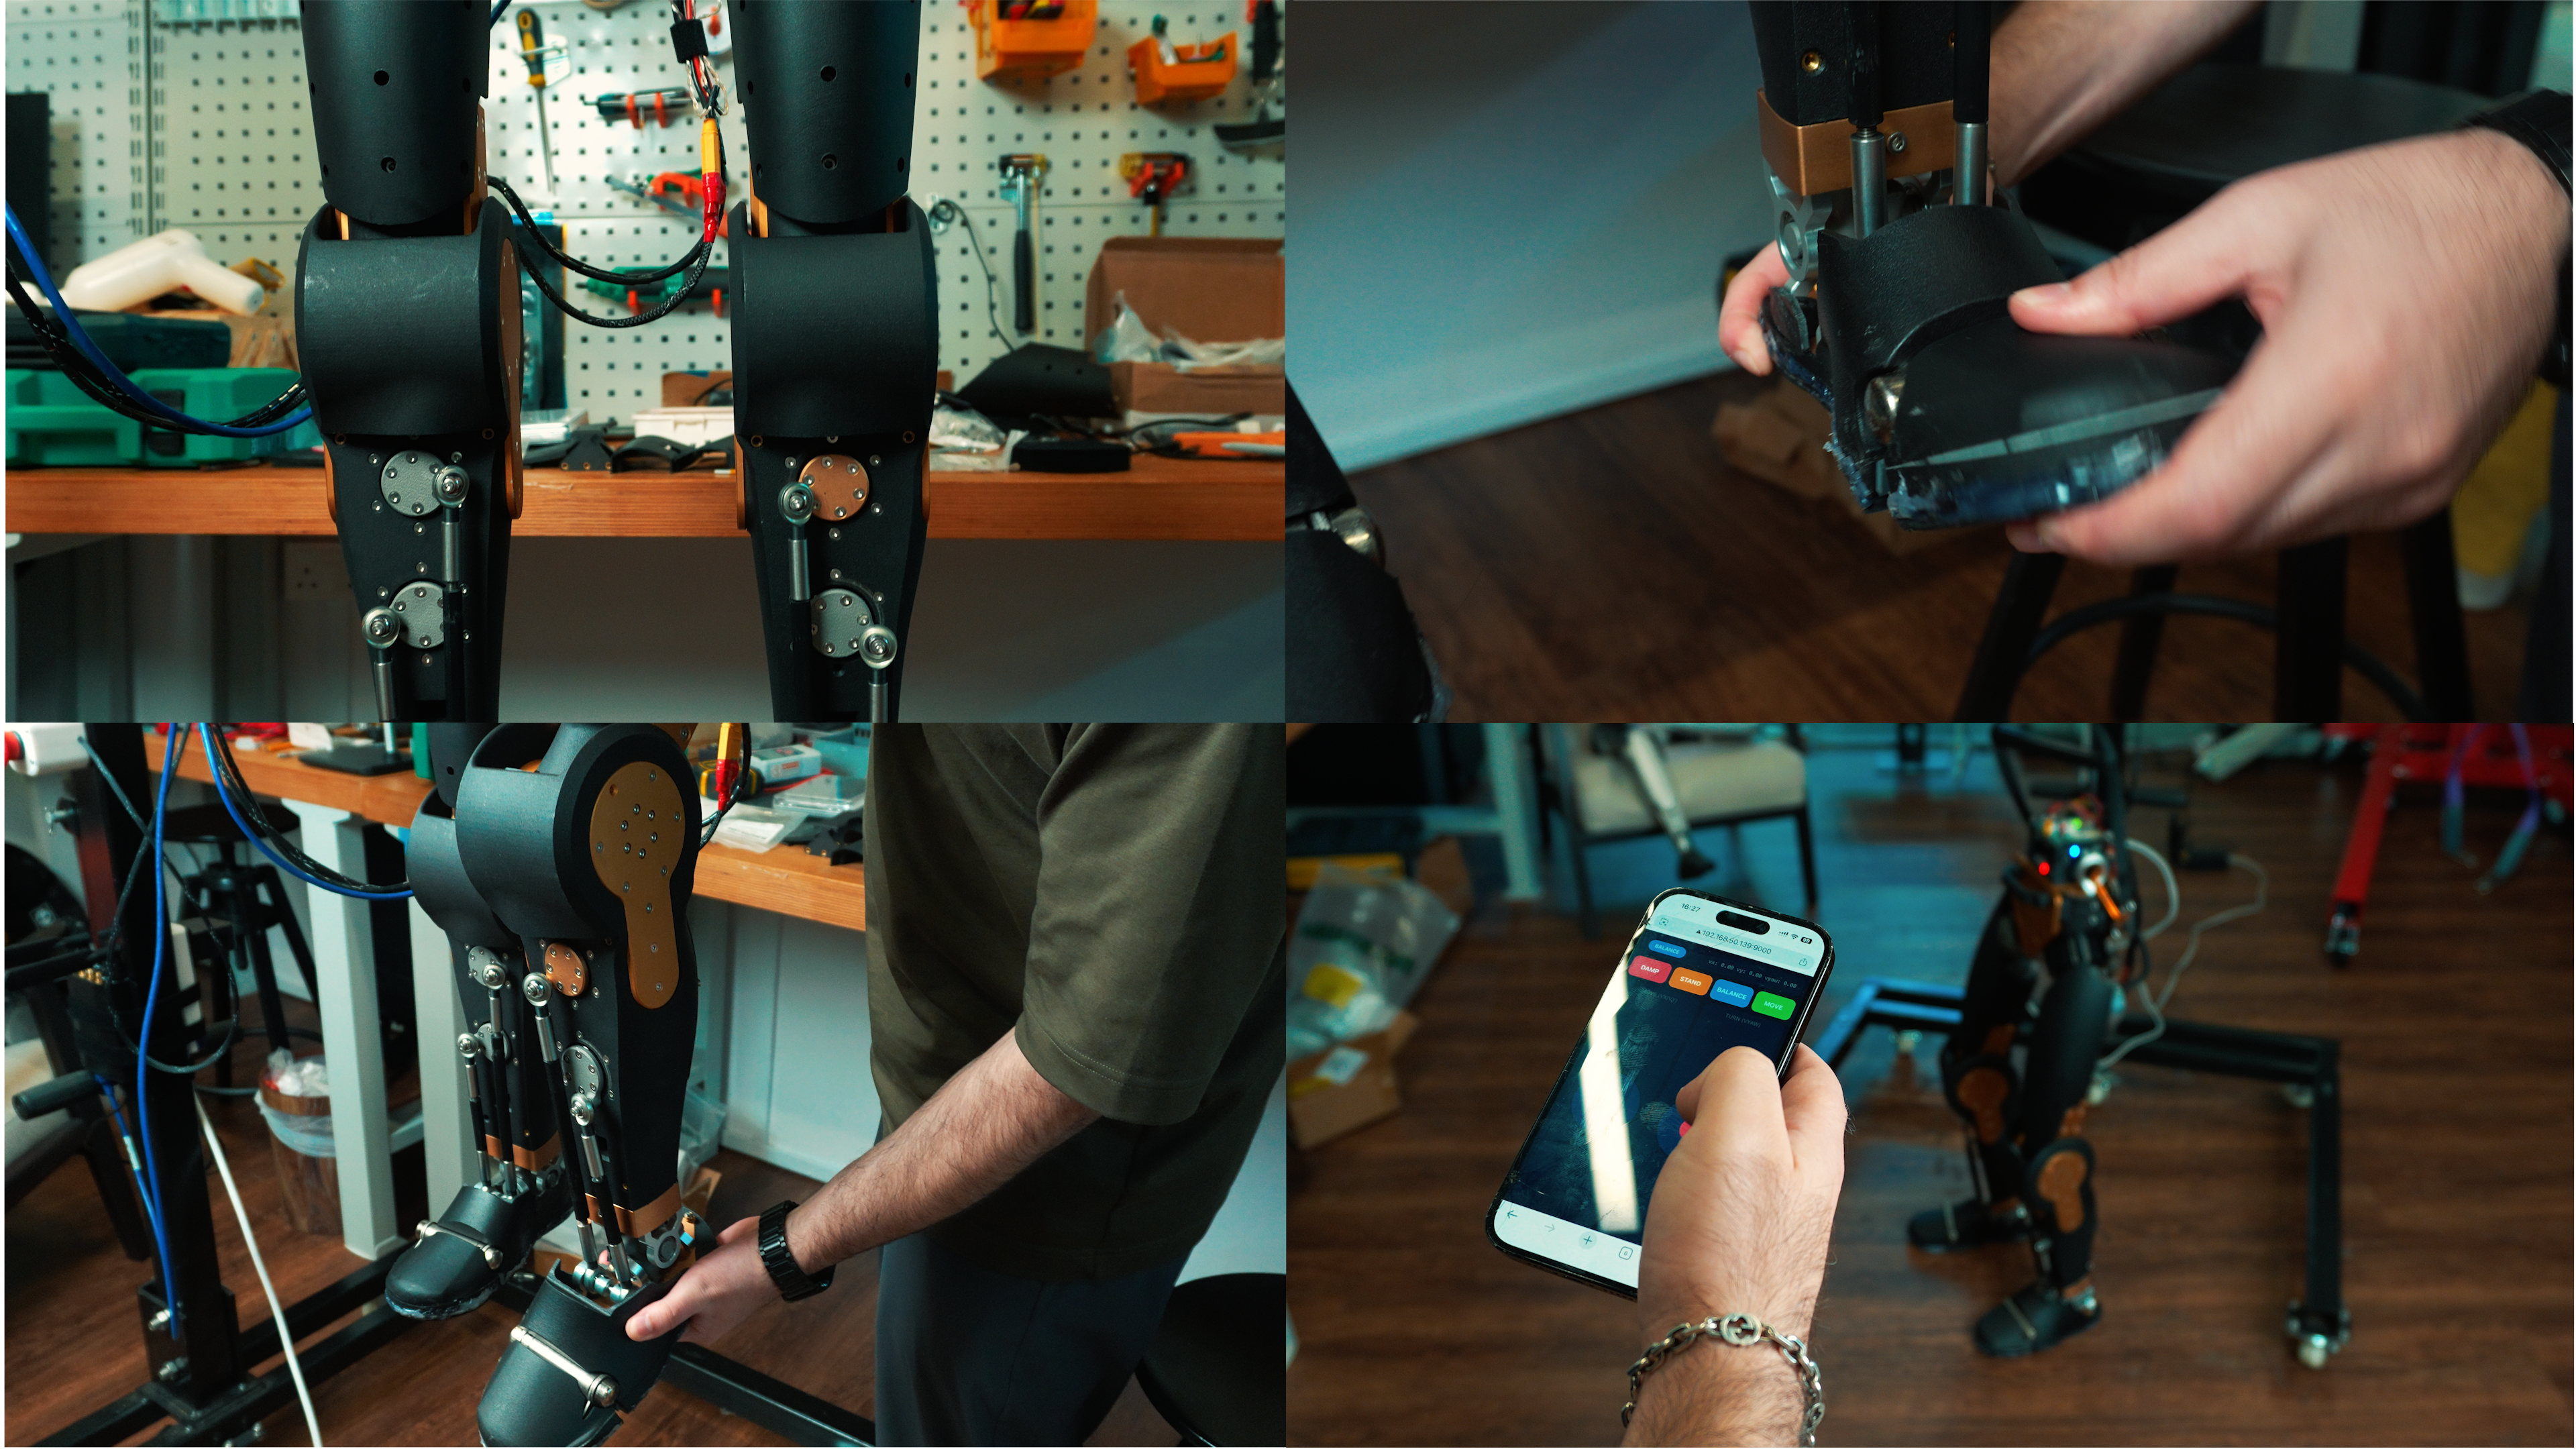
Leg subassemblyTwelve-actuator bipedal leg set (lower body only) with articulated toes and a two-motor RSU ankle, published as STL simulation meshes, an MJCF model and an LFS-stored STEP assembly. [1] [5] [6]
Build & first use →Official website
- For
- Humanoid hardware developers able to source Encos actuators, MJF-printed parts and their own electronics and control stack [1] [6]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- Ecosystem
- MuJoCo
- License
- CERN-OHL-S-2.0 · Details by part
Overview
Asimov v0 is Menlo Research's earlier open-source release of a bipedal lower body: two legs with six actuated joints each, an articulated toe and an RSU (revolute–spherical–universal) ankle linkage. The README describes it as built from off-the-shelf components and compatible with MJF printing and other low-volume processes. It suits developers who already have, or will build, their own electronics and control stack. [1]
It is easy to confuse with Asimov 1, whose separate repository describes a 1.2 m, 35 kg humanoid with 25 actuated joints, arms, a head, onboard computers, electrical CAD and onboard software. None of those upper-body, compute or electrical parts appear in the v0 archive. [6] [7]
Is this for you?
- Known limitations
- Lower body only; no arms, torso electronics or controller are specified
- STEP assembly is a Git LFS pointer in the source archive; payload not retrieved or validated
- No electronics, wiring, firmware, controller software or procurement BOM identified in the repository
- MJCF ankle joints are modeled as pitch and roll, while the hardware drives them through motors A and B
- No build, actuation or walking test performed for this profile
Source-review boundaries; no hardware tests.
What you need
- Dependencies
- MuJoCo-compatible simulator for the provided MJCF model (no version stated)
Inferred from the MJCF file format; the README states no software dependency.
[5] · Editorial assessment
Hardware & parts
- Hardware configuration
Bipedal lower body: six actuated joints per leg plus a spring-loaded articulated toe.
- Actuators
- Encos EC-A6416-P2-25 (hip pitch)
- Encos EC-A5013-H17-100 (hip roll)
- Encos EC-A3814-H14-107 (hip yaw)
- Encos EC-A4315-P2-36 (knee pitch)
- Encos EC-A4310-P2-36 x2 (ankle motors A and B)
Per leg; two legs give twelve actuators.
- Sensors
- IMU site in the pelvis (simulation model)
Only the MJCF defines an IMU site; no physical sensor part is named.
- Degrees of freedom
12
README: 12 DOF actuation, 6 per leg. The MJCF toe joints carry a spring and are not counted.
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Cost and license scope
No upstream BOM, price or cost figure was identified. The actuators, MJF parts, electronics and power system therefore need separate quotes. [1] [6]
The root CERN-OHL-S-2.0 is the only license file. It is strongly reciprocal: anyone who makes and conveys products must give recipients the complete source or its location. The purchased Encos motors are not part of the published design files. [1] [3]
No fabrication, assembly, actuation or simulation run was performed for this profile.
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
What the pinned repository contains
The archive holds the README, the CERN-OHL-S-2.0 license, a mechanical folder and a simulation folder. The simulation folder has fifteen STL link meshes and a MuJoCo (MJCF) model. The mechanical folder links an externally hosted 3D viewer and explains the ankle mapping. Its STEP assembly is a 134-byte Git LFS pointer to a payload of about 101 MB. We did not retrieve that payload, so we cannot say whether it is a fabrication-ready model. No print-ready part set, drawings, BOM, wiring or firmware was identified. [4] [6]
Joints, motors and the ankle mapping
The README lists hip pitch at 120 Nm peak, hip roll 90 Nm, hip yaw 60 Nm, knee 75 Nm and each ankle motor 36 Nm. Left and right ranges are mirrored; for example, left hip pitch is −120° to +57° and right is −57° to +120°. Each joint names an Encos motor model, and both ankle motors use the EC-A4310-P2-36. [1]
The ankle table describes motors A and B, each ±70°, rather than pitch and roll directly. Two linkages move a bar, and the mechanism note derives a small-angle mapping between motor angles and ankle pitch and roll. The MJCF model instead defines ankle pitch and roll joints with their own limits (left pitch −0.349 to 0.5 rad, roll ±0.1 rad). A controller therefore has to convert between the two, and the simulation limits should not be read as the motor table. [1] [4] [5]
In the model, each toe joint has a spring stiffness and no motor class, so we read it as passive. That is an inference from the model file. The model's inertial masses add up to about 15.9 kg across its fifteen bodies. That is our sum of simulation values, not a measured weight. [5]
What we checked
Source research only; no fabrication, assembly, actuation or simulation run performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Jan 28, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- 759204f531b071e65540e8b31d89736a3d09e0dd (commit snapshot; no published stable release found) · repository
Source files and licenses
Licensed mechanical and simulation sources are published, but electronics, firmware, BOM and assembly material were not identified.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-S-2.0 The STEP assembly is stored through Git LFS: the source archive holds a pointer naming a 101,206,631-byte payload, which was not retrieved or checked. STL meshes under sim-model are simulation assets; no print-ready part set or fabrication drawings identified. [1] [3] [6] |
| electronics | not found · License not fully assessed No schematics, wiring or board files identified in the pinned repository; motors are purchased Encos units. [6] |
| firmware | not found · License not fully assessed No actuator or controller firmware identified. The ankle mapping note includes C++ snippets, not a firmware package. [4] [6] |
| software | available · CERN-OHL-S-2.0 Only a MuJoCo model is published; no control, training or deployment code identified. Root license is the only license file. [3] [5] [6] |
| documentation | available · CERN-OHL-S-2.0 README joint/motor tables and the ankle derivation; root license applies as declared. [1] [3] [4] |
No trained policy is part of this release.
No dataset is part of this release.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Asimov v0 README
Lower-body scope, joint table with ranges and peak torques, Encos motor models and fabrication notes.Revision, date & where cited
Menlo Research (Asimov) / asimov-v0 contributors · github.com · revision
759204f· README.md at 759204f5 · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S002 menloresearch/asimov-v0: commit 759204f
Selected commit, date, archive checksum, popularity counts and license hint.Revision, date & where cited
Menlo Research (Asimov) / asimov-v0 contributors · github.com · ; default-branch snapshot, no stable release in first 100 · Accessed Oct 5, 2026
Used for: What we checked - S003 Repository license (CERN-OHL-S-2.0)
CERN Open Hardware Licence v2 Strongly Reciprocal text.Revision, date & where cited
Menlo Research (Asimov) / asimov-v0 contributors · github.com · revision
759204f· Accessed Oct 5, 2026
Used for: Cost, Source files and licenses - S004 Mechanical notes and ankle mechanism derivation
External 3D viewer link and the two-motor ankle pitch/roll mapping.Revision, date & where cited
Menlo Research (Asimov) / asimov-v0 contributors · github.com · revision
759204f· mechanical/README.md; mechanical/ankle_mechanism.md · Accessed Oct 5, 2026
Used for: Is this for you?, What the pinned repository contains, Joints, motors and the ankle mapping, Source files and licenses - S005 MuJoCo model
Body tree, joint ranges, inertial masses, toe spring and IMU sensor site.Revision, date & where cited
Menlo Research (Asimov) / asimov-v0 contributors · github.com · revision
759204f· Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Hardware & parts, Joints, motors and the ankle mapping and 1 more - S006 Pinned archive inventory and Git LFS pointer
File list showing STL meshes, MJCF and a 134-byte LFS pointer in place of the STEP assembly.Revision, date & where cited
Menlo Research (Asimov) / asimov-v0 contributors · github.com · revision
759204f· archive member list; .gitattributes; mechanical/ASV0_lowerBody.STEP pointer · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Cost, What the pinned repository contains and 1 more - S007 Asimov 1 README (separate repository, for disambiguation)
Asimov 1 scope used only to distinguish it from v0.Revision, date & where cited
Asimov / asimov-1 contributors · github.com · revision
35ae7b3· README.md at 35ae7b35 (preserved archive) · Accessed Oct 5, 2026
Used for: Overview - S008 Upstream image and reuse attribution
Media-only review: Upstream photograph of Asimov v0 lower-body hardware during development, not a complete finished humanoid. Reuse basis: CERN-OHL-S-2.0; inspected LICENSE.txt and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Menlo Research and Asimov v0 contributors · github.com · revision
759204f· Image SHA-256 80f72df99bbad3771d1a65b0a3c46008588868f89636885b955e9e8191b0dddb; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Initial source-researched profile from pinned commit 759204f5.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.