BamBot
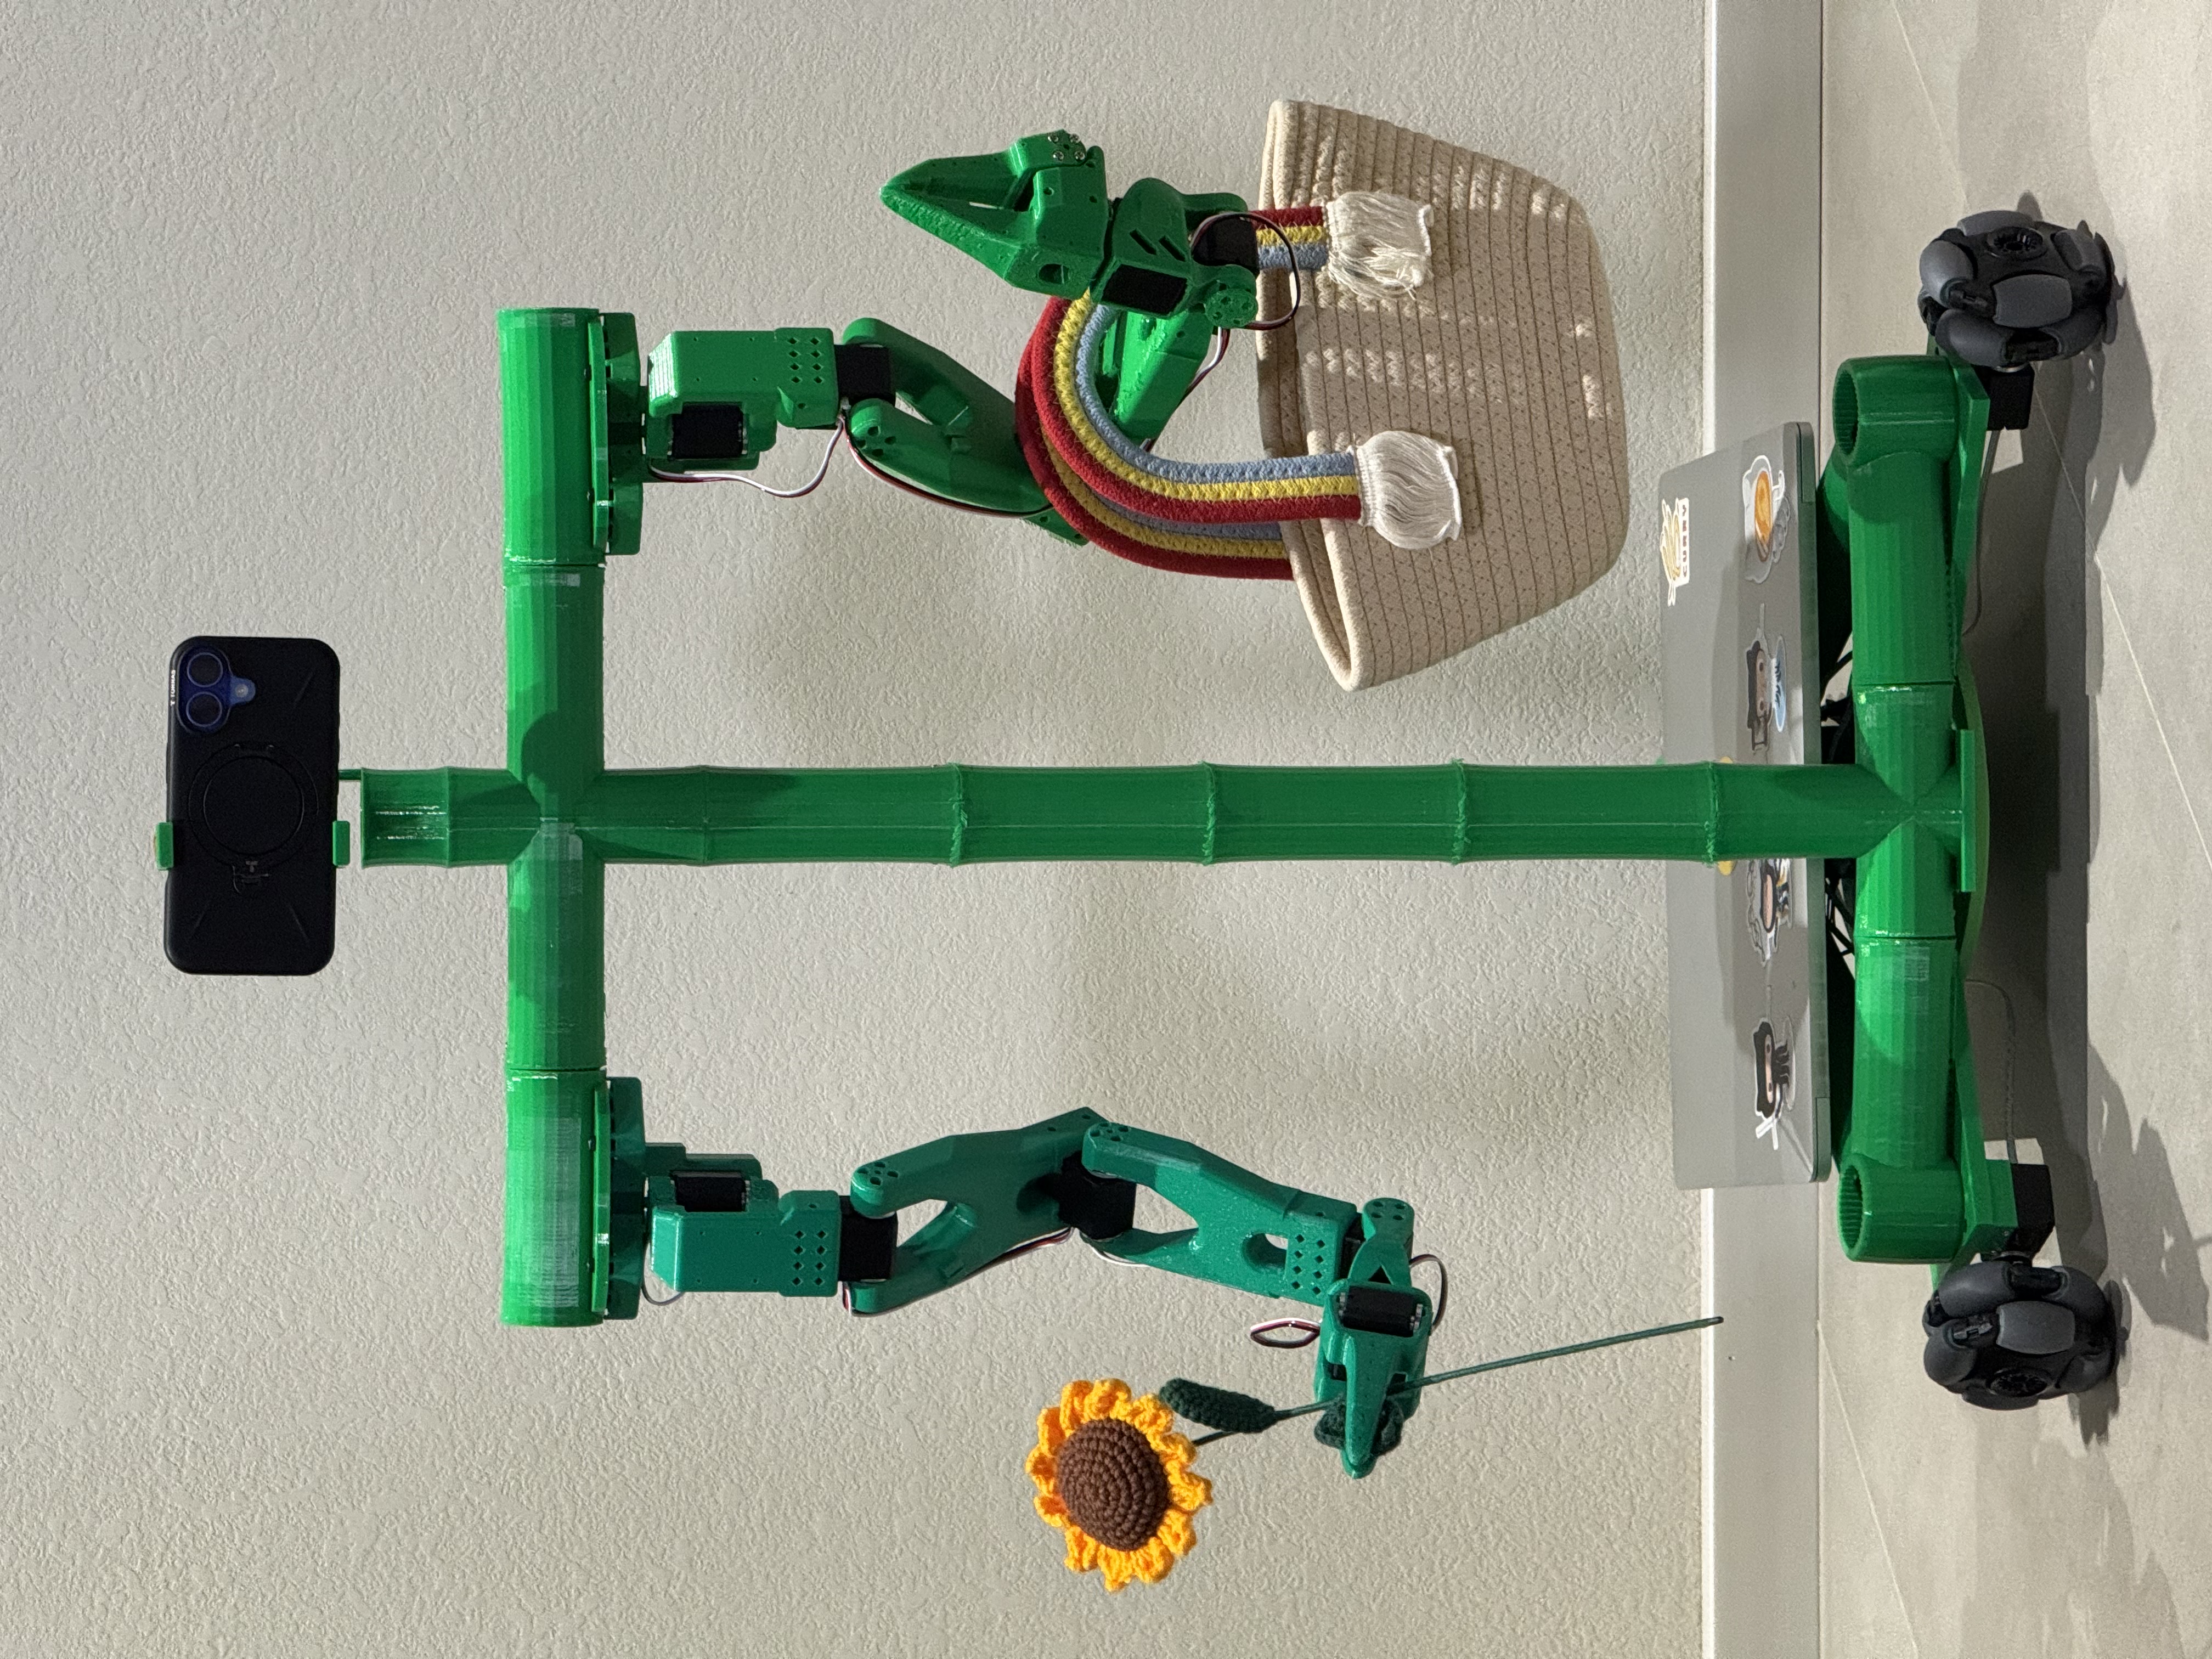
Robot / hardware buildTwo-arm mobile manipulator with a three-wheel omnidirectional base, released printable parts and a modified LeRobot control repository. [5] [7] [8] [12]
Build & first use →Official websiteBill of materials
- For
- Builders able to configure Feetech servos, print parts and reconcile a developing LeRobot fork [1]
- Cost
- No current cost yet. Upstream bill of materials [5]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- Apache-2.0 · license not fully assessed for mechanical design, documentation · Details by part
Overview
BamBot combines two arms with a three-wheel omnidirectional base. Although its overview calls it a low-cost humanoid, the documented mechanism is wheeled. The hardware list specifies 15 STS3215 servos for the follower, while two-arm teleoperation adds another 12 servos and another control board. The control repository's short introduction says two wheels, but its connection instructions and actual configuration specify three wheel channels. [1] [5] [7] [8]
Is this for you?
- Known limitations
- Hardware guide is a draft with placeholder prices
- Inherited LeKiwi guide uses single-arm IDs that differ from the BamBot code
- Regional wheel and servo variants require geometry and power matching
- Hardware repository license text differs from standard Apache 2.0 wording
3D preview
BamBot playground simulation assembly. The repository playground model with its source visual meshes and zero joint positions. This is a simulation configuration, not a verified fabrication package or every BamBot revision.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Tim Qian / BamBot contributors; source project acknowledges SO-100 and LeKiwi, revision 9e9d504a867c785499b2f31d005b3fa4424da391. Original and preview: Apache-2.0-based source license (modified Section 6). Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Upstream bill of materials [5]
- Hardware configuration
Two-arm mobile manipulator on a three-wheel omnidirectional base.
Upstream calls the appearance humanoid; selected hardware is wheeled, not bipedal.
- Actuators
- 15 STS3215 servos for follower: 12 arm/gripper channels and 3 wheel channels
- 12 additional servos for the two-arm leader
- Controller
Feetech-compatible bus servo control board, with a separate board for the leader setup.
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
The headline price is not a complete teleoperation setup
The hardware page's approximate $300 or €300 total belongs to its follower parts table. Printing, the leader hardware, computing and camera arrangements, tools and a complete power setup must be accounted for separately. Several US and EU cable entries show zero with unfinished purchase links; those are unresolved prices, not evidence that the parts are free. No current delivered price was verified. [5]
The table selects 12 V STS3215 servos but discusses a 7.4 V alternative requiring different power provision. Its wheel links also span nominal four-inch, 100 mm and 80 mm products. Match the selected servo supply, wheel adapters and geometry before treating regional links as interchangeable. [5]
Project notes
Preserve the print release and control fork separately
The hardware guide links the v0.0.0 release. Its preserved STLs.zip contains 25 printable files, including arm, wheel, connector and body components. The separately linked editable Tinkercad assembly was not preserved, and the hardware guide remains marked drafting. File availability does not establish a verified assembly sequence or tested fit. [5] [12]
The main repository's software directory provides browser serial examples. The complete BamBot workflow instead points to timqian/lerobot-bambot, preserved here at commit 501d4414ed70bc6fa8641f58484960bb310e5e68. Its README tells readers to use the inherited LeKiwi guide with BamBot-specific changes. This review did not install either software route. [6] [7]
Follow the two-arm motor map
In the fork's LeKiwiRobotConfig, arm and gripper channels occupy IDs 1–12. The follower's left, back and right wheels are IDs 13, 14 and 15; the leader contains only IDs 1–12. The inherited guide still shows single-arm wheel IDs 7–9. Copying that example without adapting it would conflict with the second arm's IDs in the BamBot configuration. [8] [9]
The default camera is index 1, and the serial paths are machine-specific examples. The configuration uses a loopback address with ports 5555 and 5556; the guide distinguishes a wired arrangement running both processes on a laptop from a remote arrangement whose host address must be configured. Select one route and replace device identifiers consistently. [8] [9]
BamBot's README instructs both arms to be placed in the same pose simultaneously during calibration. The inherited guide describes manual arm calibration and says the wheel motors do not need that arm-calibration step. However, the calibrate_follower method filters out names beginning with wheel_, while the configured names are left_wheel, back_wheel and right_wheel. Those names are not excluded by that filter. The applicable calibration path needs tracing or upstream clarification before relying on the guide's wheel exclusion; this is a static observation, not an observed runtime failure. The motion conversion code defaults to a 0.05 m wheel radius and 0.125 m base radius, so those source values also need matching to the actual geometry. They are not measured dimensions or validated limits for every listed wheel. [7] [9] [10]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed 25 STL files preserved; no license file in release asset. Hardware-specific scope and modified root license wording need clarification; external editable Tinkercad model not preserved. [3] [5] [12] |
| electronics | not found · License not fully assessed Purchased controller and servo components specified, but complete matching editable board design and firmware source not established in this review. [5] [6] [8] |
| firmware | not found · License not fully assessed Purchased controller and servo components specified, but complete matching editable board design and firmware source not established in this review. [5] [6] [8] |
| software | available · Apache-2.0 Selected control fork has Apache 2.0 terms plus MIT/Apache third-party notices; dependency terms remain separate. [7] [8] [10] [11] |
| documentation | available · License not fully assessed Hardware repository root text is labeled Apache 2.0 but differs in trademark clause wording; exact rights are not normalized to an unqualified SPDX claim. [3] [5] [6] |
Selected manual teleoperation route needs no pretrained model or existing dataset; training is a separate workflow.
Keep source rights and build readiness explicit
The control fork carries Apache 2.0 terms and additional notices for included third-party code. The hardware repository's root file is labeled Apache 2.0, but its trademark clause omits wording present in the standard text. The print archive itself contains no license file. This profile therefore leaves hardware-specific rights unresolved instead of treating all hardware and external models as unambiguously covered by a standard license. [3] [11] [12]
No parts were purchased, printed or assembled, and no servo configuration, calibration, driving, teleoperation or learning experiment was performed. The entry records a source-backed configuration to investigate, with the inherited-guide differences and incomplete cost made explicit. [5] [7] [8] [9]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 timqian/bambot: README.md
Revision, date & where cited
github.com · revision
9e9d504· Accessed Oct 1, 2026
Used for: Overview, Assembly & first use - S002 timqian/bambot: commit 9e9d504
- S003 timqian/bambot: LICENSE
Revision, date & where cited
github.com · revision
9e9d504· Accessed Oct 1, 2026
Used for: Is this for you?, Source files and licenses - S004 timqian/bambot: files
Revision, date & where cited
github.com · revision
9e9d504· archive file inventory · Accessed Oct 1, 2026 - S005 BamBot hardware/README.md
Revision, date & where cited
github.com · revision
9e9d504· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S006 BamBot software/README.md
Revision, date & where cited
github.com · revision
9e9d504· Accessed Oct 1, 2026
Used for: What you need, Preserve the print release and control fork separately, Source files and licenses - S007 BamBot control fork: README.md
Revision, date & where cited
github.com · revision
501d441· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 3 more - S008 BamBot control fork: lerobot/common/robot_devices/robots/configs.py
Revision, date & where cited
github.com · revision
501d441· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S009 BamBot control fork: examples/11_use_lekiwi.md
Revision, date & where cited
github.com · revision
501d441· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Assembly & first use, Follow the two-arm motor map and 1 more - S010 BamBot control fork: lerobot/common/robot_devices/robots/mobile_manipulator.py
Revision, date & where cited
github.com · revision
501d441· Accessed Oct 1, 2026
Used for: Is this for you?, Hardware & parts, Follow the two-arm motor map, Source files and licenses - S011 BamBot control fork: LICENSE
Revision, date & where cited
github.com · revision
501d441· Accessed Oct 1, 2026
Used for: Source files and licenses - S012 Released printable parts inventory
Revision, date & where cited
github.com · STLs.zip verified archive inventory · Accessed Oct 1, 2026
Used for: Assembly & first use, Preserve the print release and control fork separately, Source files and licenses - S013 Upstream image and reuse attribution
Media-only review: Upstream photograph of a Bambot arm mounted to a table. Reuse basis: Apache-derived terms; modified trademark clause; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
timqian and Bambot contributors · github.com · Image SHA-256 c3894a6b5b314e75404a41baa75e0c5b3713e91b56a674cead8e1d6a7c24d6db; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.