BiDexHand
Robot / hardware buildBiDexHand V4 is a 16-DoF tendon-driven hand with printed parts, a Servo2040 PWM route and ROS 2 control packages. [1]
Build & first use →Official website
- For
- Robotics builders able to assemble tendon mechanisms and debug ROS 2 integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for software · Details by part
Overview
BiDexHand V4 provides a 16-DoF hand mechanism, STEP and STL assets, a bill of materials and ROS 2 packages. Fifteen joints use a cable-and-pulley arrangement, with a four-bar mechanism for the remaining joint. The fingers couple distal motion to the proximal interphalangeal joint; visible joint motion should not be counted as an extra independently driven degree of freedom. [1] [13]
This profile selects the V4 PWM build using Servo2040. The alternative SCS bus-servo BOM is a different configuration, and the README sends that route to a V3 fork that was not matched and reviewed here. Neither route was physically assembled or tested for this entry. [1] [5]
3D preview
BiDexHand v4 model. Source STEP geometry for the named configuration. Purchased-component representations are included where supplied; this preview does not verify physical fit or a working build.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP (gzip) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Zhengyang Kris Weng / BiDexHand contributors, revision 0f50498626e5f02cdc10c44cb2c18d4e7b3bb45e. Original and preview: MIT. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Budget for the mechanism and its integration
The PWM BOM lists 16 FeeTech FT90M servos, one Servo2040 and a 6 V 5 A supply. It also calls for printed components, precision shoulder screws, bushings, springs, inserts, tendon line and PTFE tubing. Those are part of the mechanism, not incidental extras. The BOM also includes a wrist camera; this review has not established that camera as mandatory for basic direct servo commands. No complete current delivered cost was verified. [5] [7]
STEP and STL files establish available design artifacts, not dimensional fit or fabrication success. The README links an external Onshape design and demonstrations; those external models and videos were not inspected as an assembly qualification. Tendon routing, tension and individual joint limits still need a builder-specific check. [1] [13]
Project notes
The quickstart and the preserved launch file differ
The README says ROS 2 Jazzy is the primary tested environment and gives rosdep/colcon build steps. Its direct-control quickstart names multi_servo_control.launch.xml, but the archived package supplies multi_servo.launch.xml and installs that filename in setup.py. This is a source-level mismatch, not a launch command verified by this publication. [1] [8] [9] [13]
The supplied launch file starts the serial-control node unconditionally and starts it again in streaming mode, using the same USB argument. That needs reconciliation before treating the launch as a ready-to-run recipe. The control node opens its port at 115200 and requires exactly 16 streamed positions, mapped to channels 0–15. A successful serial write is what its service reports; it is not measured joint feedback. [7] [8]
Controller capacity does not establish joint travel
The firmware initializes and enables all 18 Servo2040 outputs at startup, while the hand and streaming interface use 16. Its position labels span minus to plus 140, but the implementation maps those values linearly to 1000–2000 microsecond pulses. Those labels do not independently establish the travel of the installed servos or the assembled tendon mechanism. Startup centering is a real commanded behavior in the source and needs consideration before attaching a tensioned mechanism. [6] [7]
The ROS node formats positions to three decimal places, while the firmware uses integer parsing before the pulse calculation. Fractional command precision is therefore discarded on this inspected path. This finding comes from reading the two implementations; no board communication or physical positioning accuracy was measured. [6] [7]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A limitations summary
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT Repository root MIT terms; purchased components and external resources retain separate scope. Source availability is not build validation. [1] [3] [13] |
| electronics | not found · License not fully assessed BOM uses purchased Servo2040 and servos; no complete custom electronics design established in this reviewed archive. [5] [13] |
| firmware | available · MIT Repository root MIT terms; purchased components and external resources retain separate scope. Source availability is not build validation. [1] [3] [13] |
| software | available · License not fully assessed Mixed package licensing: root MIT and package-level Apache-2.0, including hand_servo_control. Do not treat root MIT as the sole license for every package. [3] [10] [13] |
| documentation | available · MIT Repository root MIT terms; purchased components and external resources retain separate scope. Source availability is not build validation. [1] [3] [13] |
Selected direct PWM servo-control route requires no learned model or dataset; external VR integration is outside this assessment.
Calibration and licensing are separate checks
The calibration node uses AprilTag measurement services, with configurable motor and tag mappings. The supplied configuration identifies specific MCP and PIP calibration mappings; it is not evidence that every joint in a newly built hand has already been calibrated. Camera setup, tag geometry, tendon adjustment and a complete whole-hand sequence remain unverified here. [11] [12]
The root repository provides MIT terms, while hand_servo_control includes an Apache-2.0 license. Package-level notices must remain part of the software assessment rather than being replaced with the root label. Purchased electronics, the alternative bus-servo route, external VR tracking and Franka integration have separate requirements. This entry covers available sources and concrete setup gaps, not a reproduced dexterity or teleoperation result. [1] [3] [5] [10]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 wengmister/BiDexHand: README.md
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 3 more - S002 wengmister/BiDexHand: commit 0f50498
- S003 wengmister/BiDexHand: LICENSE
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: Source files and licenses - S004 wengmister/BiDexHand: files
Revision, date & where cited
github.com · revision
0f50498· archive file inventory · Accessed Oct 1, 2026 - S005 BOM.md
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Cost and 1 more - S006 scripts/Servo2040/servo2040_controller.cpp
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: Controller capacity does not establish joint travel - S007 src/hand_servo_control/hand_servo_control/servo_control_node.py
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: What you need, Cost, The quickstart and the preserved launch file differ, Controller capacity does not establish joint travel - S008 src/hand_servo_control/launch/multi_servo.launch.xml
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: The quickstart and the preserved launch file differ - S009 src/hand_servo_control/setup.py
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: The quickstart and the preserved launch file differ - S010 src/hand_servo_control/LICENSE
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: Source files and licenses - S011 src/hand_calibration/config/calibration_params.yaml
Revision, date & where cited
github.com · revision
0f50498· Accessed Oct 1, 2026
Used for: Assembly & first use, Source files and licenses - S012 src/hand_calibration/hand_calibration/motor_calibrator.py
Revision, date & where cited
github.com · revision
0f50498· src/hand_calibration/hand_calibration/motor_calibrator.py lines 1–140 · Accessed Oct 1, 2026
Used for: Assembly & first use, Source files and licenses - S013 Complete archive filenames
Revision, date & where cited
github.com · revision
0f50498· Complete archive file inventory; no geometry validation · Accessed Oct 1, 2026
Used for: Overview, Cost, The quickstart and the preserved launch file differ, Source files and licenses - S015 Upstream image and reuse attribution
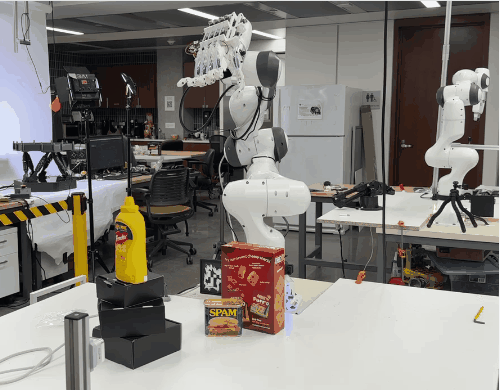
Media-only review: Still from an upstream demonstration: a BiDexHand experiment with a host robot arm; the arm and surrounding equipment are separate from the hand design. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Still taken from the upstream animation; no other changes. This does not refresh technical or cost evidence.Revision, date & where cited
Zhengyang Kris Weng and BiDexHand contributors · github.com · revision
0f50498· Image SHA-256 e21b2e2d985d10538f6530c4181ab6467b5d52581bb80be875ea1b2e442a0bad; repository · Accessed Oct 25, 2026
Videos
- S014 Open-Source Dexterous Robotic Hand | 16-DoF, VR-Controlled, ROS 2-Ready (Built in 10 Weeks) (YouTube video)
Video uploaded by Zhengyang Kris Weng, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Zhengyang Kris Weng · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S014): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.