Bloft Bad-Ass Pellet Extruder
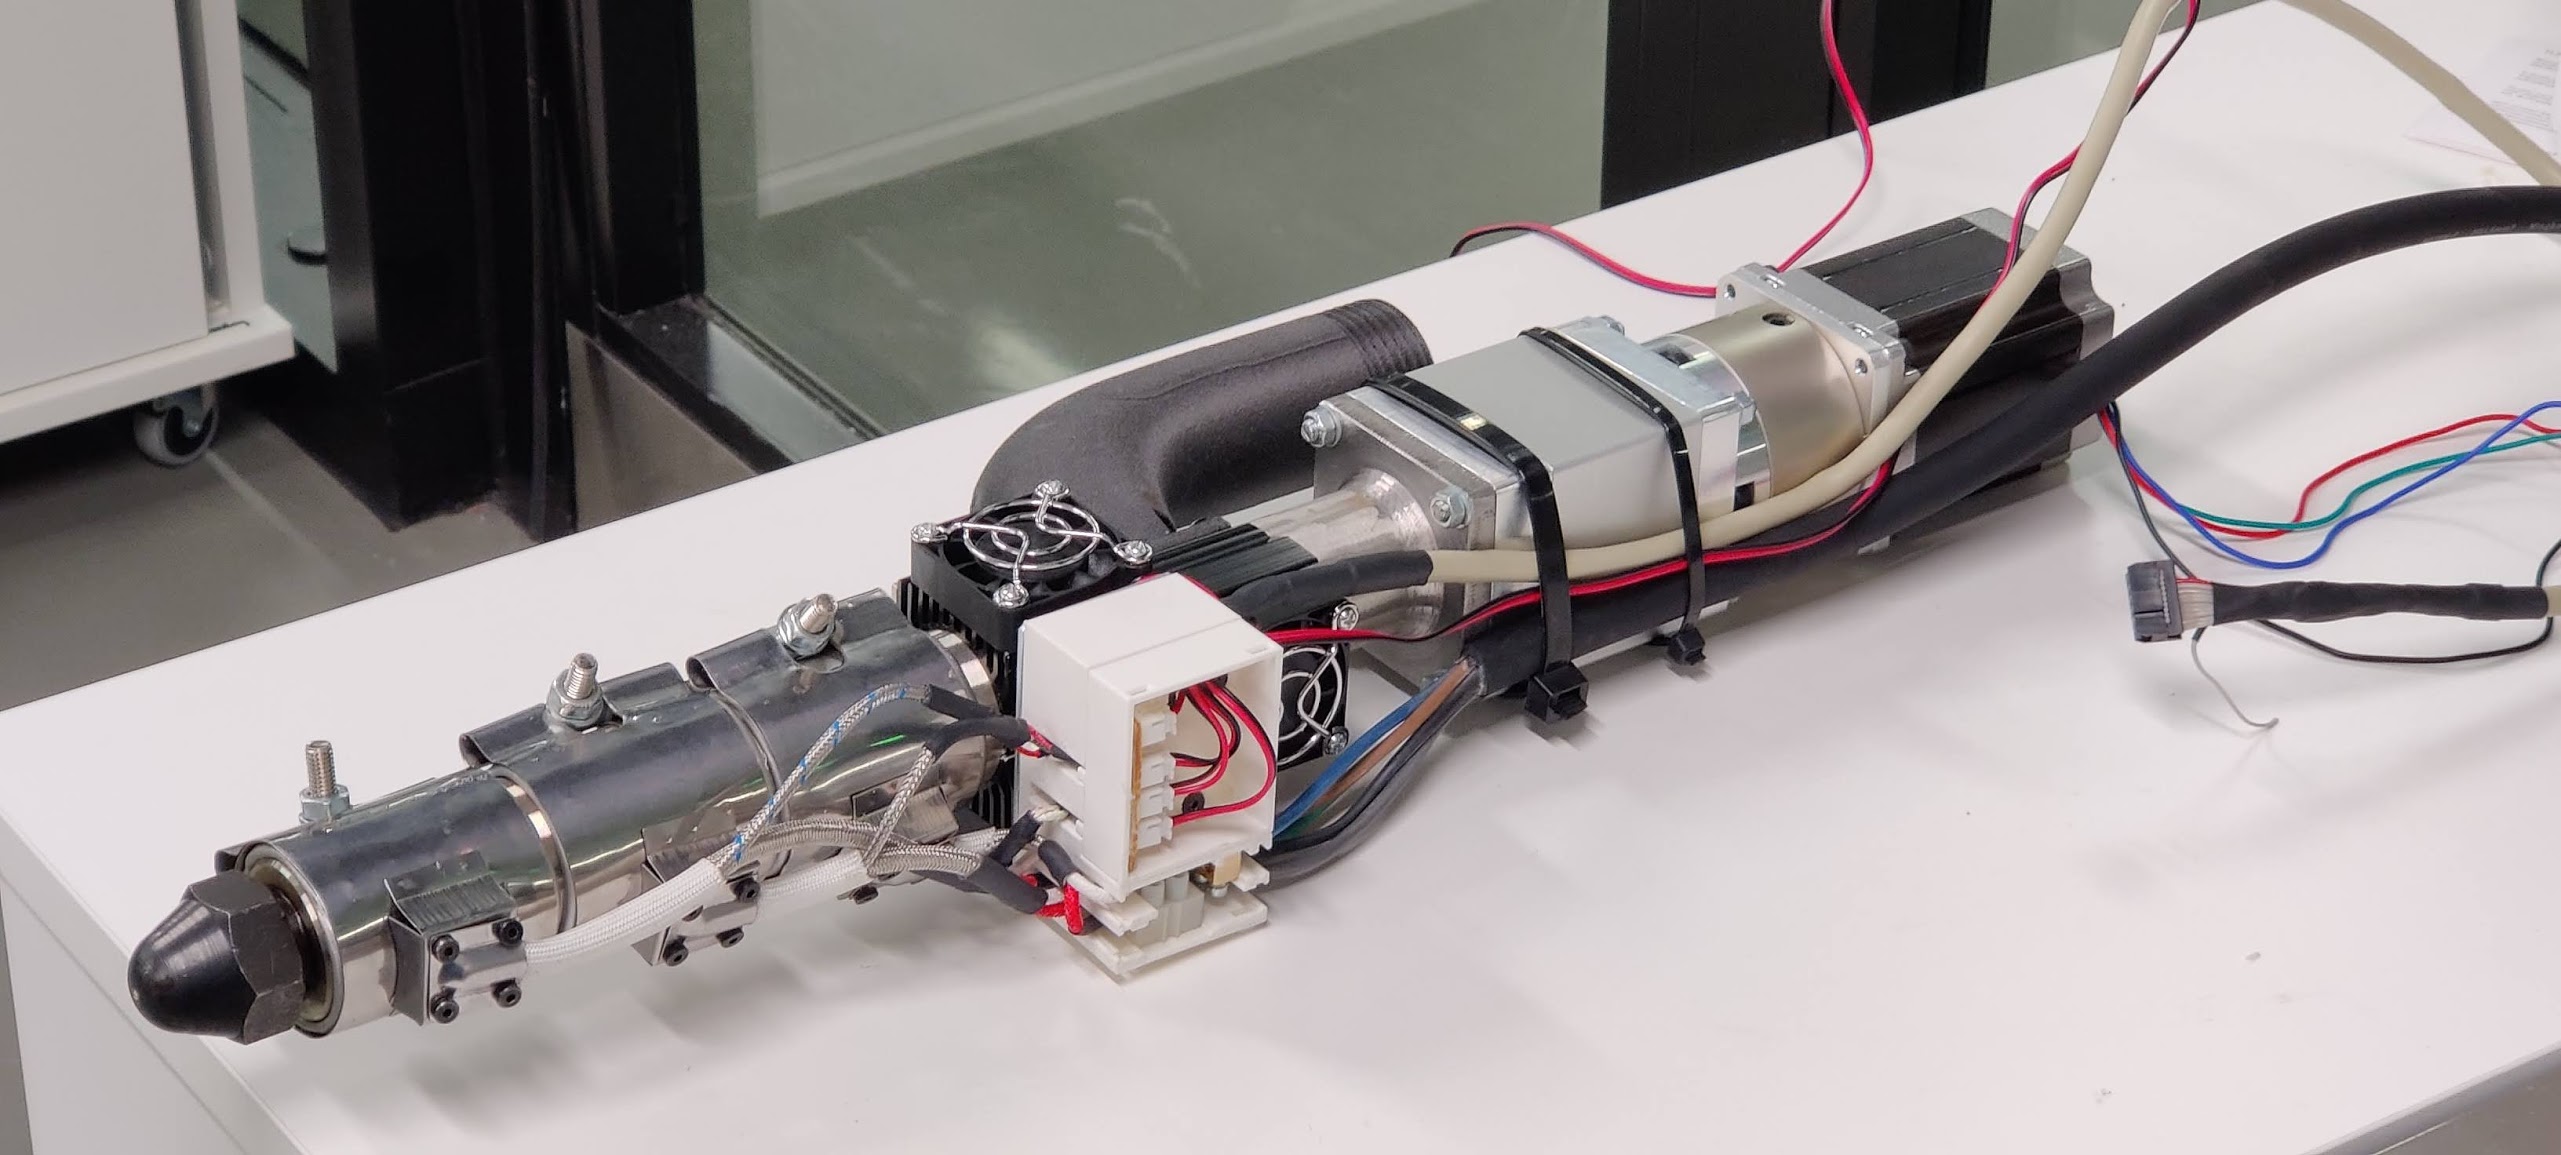
End effectorLarge-format pellet screw extrusion around a purchased RobotDigg 16 mm compression screw/barrel and NEMA23 flange. [1] [2] [3]
Build & first use →Official website
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-SA-4.0 · license not fully assessed for documentation · Details by part
Is this for you?
- Known limitations
- 1–2 kg/h is listed as a design driver, not independently verified throughput. Machining, heater/power package, feed system, moving mass and robot synchronization need reconciliation.
- No hardware build or test performed.
Source-researched; no physical verification.
3D preview
Bad Ass Pellet Extruder v13 assembly. Assembly geometry from the upstream STEP. Purchased components are represented; their manufacturing sources and physical fit are not established by this preview.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: bloft-design-lab contributors, revision b5b26ed17850488f22e8cc4d13b27e8d10c22e62. Original and preview: CC-BY-SA-4.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Project documentation [1] [2] [3]
- Assembly
1–2 kg/h is listed as a design driver, not independently verified throughput. Machining, heater/power package, feed system, moving mass and robot synchronization need reconciliation.
Known prerequisites and unresolved assembly decisions; not a complete build instruction.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Mounting and application
Designed for Hangprinter cable robot; no cobot/delta mount verified. [1] [2] [3]
Before sourcing the build
1–2 kg/h is listed as a design driver, not independently verified throughput. The README calls for a drill bench, soldering, 3D printing and CNC access. It warns about mains-powered mica band heaters and electric-shock, burn and fire hazards, recommending experienced electrical help. Reconcile the heater/power package, feed system, moving mass and robot synchronization. [1] [2] [3]
Files and reuse terms
CC-BY-SA-4.0 license and README; a template badge says MIT and should not override the license. [1] [2] [3]
The pinned inventory lists Fusion 360, IGES, STEP and Inventor files, without identified BOM paths. CAD availability was assessed from that inventory; fabrication suitability was not validated. Establish a configuration-specific purchasing list and matched control sources, including the separate reuse terms of purchased components and controls. Current delivered cost and measured performance are not established; no hardware was built or tested for this profile.
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
b5b26ed
Source files and licenses
CC-BY-SA-4.0 license and README; a template badge says MIT and should not override the license. 1–2 kg/h is listed as a design driver, not independently verified throughput. Machining, heater/power package, feed system, moving mass and robot synchronization need reconciliation.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 CC-BY-SA-4.0 license and README; a template badge says MIT and should not override the license. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] |
| electronics | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] |
| firmware | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] |
| software | not found · License not fully assessed A complete revision-matched source set for this tooling configuration was not established in the inspected documents. Standalone controls and purchased components require separate review; this is not a claim that no code or electronic files exist. [1] [2] [3] |
| documentation | available · License not fully assessed CC-BY-SA-4.0 license and README; a template badge says MIT and should not override the license. Availability refers to the scoped files described here, not a complete configuration-matched manufacturing pack. [1] [2] [3] |
This profile scopes hardware tooling, without selecting a learned controller or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Bloft Bad-Ass Pellet Extruder pinned tree
Revision, date & where cited
github.com · revision
b5b26ed· Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S002 Bloft Bad-Ass Pellet Extruder / LICENSE.txt
Revision, date & where cited
Bloft-Design-Lab · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S003 Bloft Bad-Ass Pellet Extruder / README.md
Revision, date & where cited
Bloft-Design-Lab · raw.githubusercontent.com · Accessed Sep 30, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Mounting and application and 3 more - S005 Upstream image and reuse attribution
Media-only review: Upstream photograph of the Bad Ass Pellet Extruder assembly. Reuse basis: CC-BY-SA-4.0; inspected LICENSE.txt and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Bloft Design Lab contributors · github.com · revision
b5b26ed· Image SHA-256 31bfc08714dda433cbcd9274aff225f058f21365c0f6d4a78298c4cd6d9c0915; repository · Accessed Oct 25, 2026
Videos
- S004 bloft design lab (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel bloft design lab · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-04 — Added 1 YouTube reference(s) (S004): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.