CMU MicroDuck
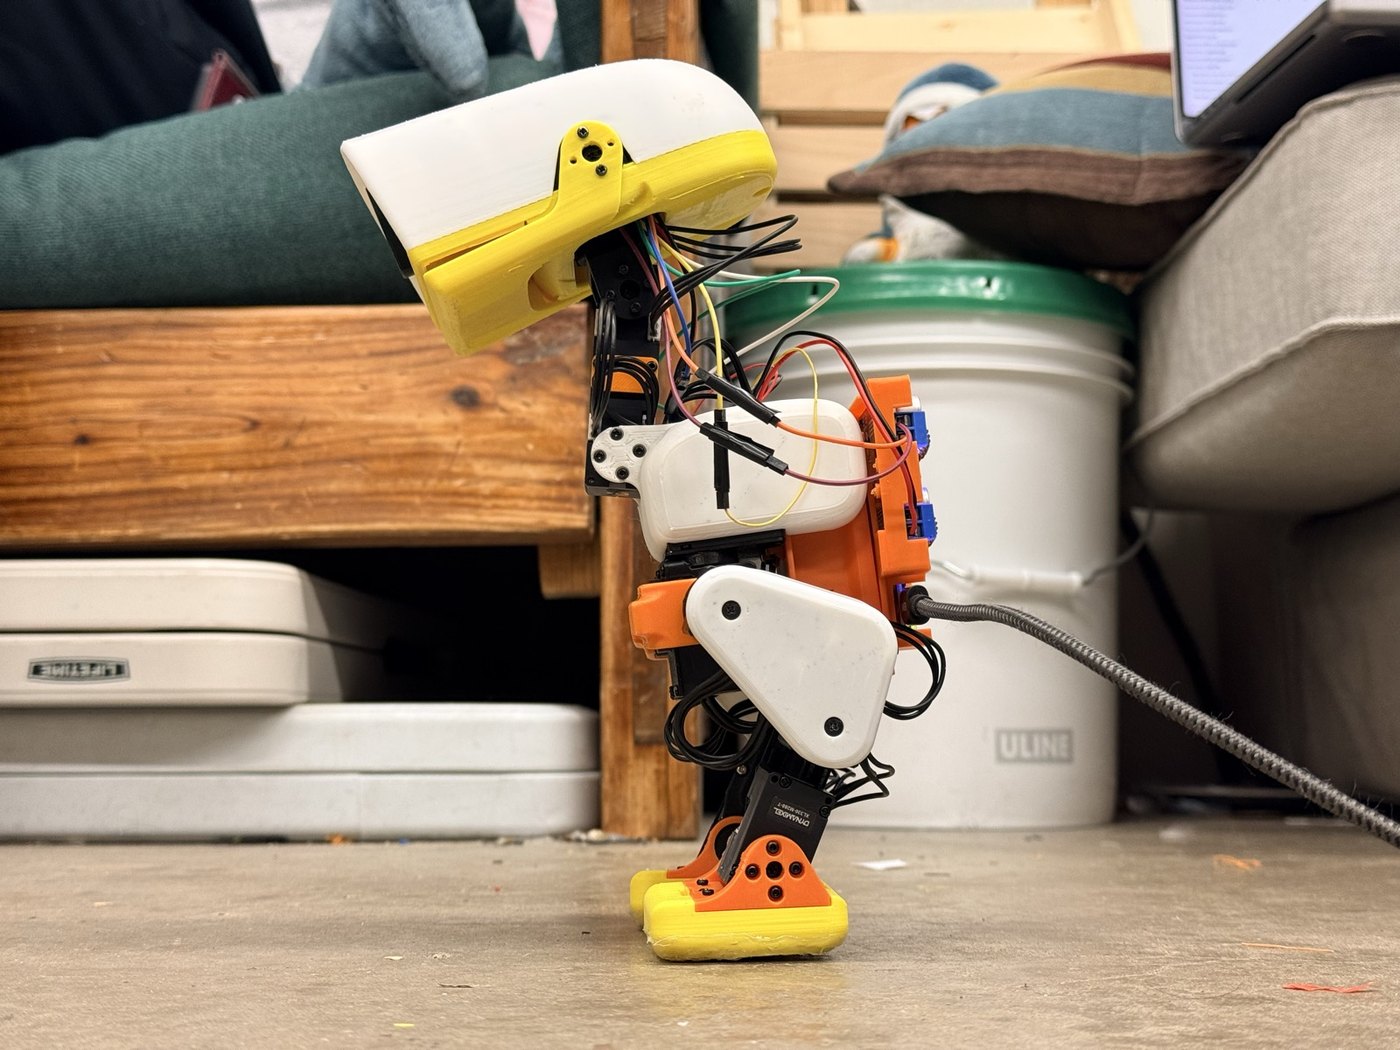
Robot / hardware buildCMU RoboClub’s 15-joint MicroDuck build with a Radxa head computer and touch-sensitive cap. [1]
Build & first use →Official websiteSource codeUpstream build guideBill of materials
- For
- Robot builders researching small 3d-printed biped with a duck-shaped body. [1]
- Cost
- No current cost yet. Upstream bill of materials [1] [2]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT for club files; upstream meshes retain separate terms, MIT for club changes; upstream sketch Apache-2.0, Mixed terms; see README licenses, MIT · license not fully assessed for model weights · Details by part
Overview
CMU RoboClub’s October 23 build adds touch pads in the head, a Radxa Cubie A7Z and a rear converter box. It uses 15 XL330-M288-T servos and an OpenRB-150. The club sourced them with cables and XL4015 modules through two ROBOTIS OMX-AI kits. Check the finished-robot BOM before using the older harness notes. Several purchase prices were not recorded, including the prices of the two kits. A complete build cost is unknown. [1] [2]
The documented build uses printed parts, a Mac for the upstream workflow, a BNO085 IMU, a XIAO ESP32-S3 for touch sensing and a Radxa camera. The wired power guide calls for a 20 V, 5 A USB-C PD source. Use the servo setup, OpenRB flashing and head wiring sections before putting the case together. The first-run instructions use Pollen’s stand61, walk61 and groundpick61 policies. The fetch script downloads the upstream files with hashes. [1] [2]
The club reports thermal throttling in the closed head, sessions of about 30 minutes before cooldown, leftward drift and occasional falls. Its battery backpack remained untested. The club’s own files use MIT terms, with separate terms for upstream meshes, code and policies. This is a source review without a physical build or walking test. [1] [3]
Is this for you?
- Known limitations
- The BOM omits some purchase prices. Policy downloads and mesh reuse depend on their upstream sources.
Scoped to the inspected sources and verification performed.
[1] · Editorial assessment
Hardware & parts
Upstream bill of materials [1] [2]
- Hardware configuration
Small 3D-printed biped with a duck-shaped body
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The upstream design is linked below. An interactive preview has not been prepared for this profile.
Model sources
The upstream design is linked below. An interactive preview has not been prepared for this profile.
What we checked
Source review only. No physical build or runtime test. Image credited to upstream.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Nov 15, 2026
- Sources last checked
- Nov 15, 2026
- Next review
- Dec 15, 2026
- Reviewed revision
19f3b0e
Source files and licenses
Includes a documented physical robot design with scope and reuse terms described by artifact.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT for club files; upstream meshes retain separate terms No separately licensed implementation located for this layer in the reviewed sources. [1] |
| electronics | not found · License not fully assessed Wiring and off-the-shelf electronics are documented; no custom PCB source located in the inspected build documentation. [1] |
| firmware | available · MIT for club changes; upstream sketch Apache-2.0 No separately licensed implementation located for this layer in the reviewed sources. [1] |
| software | available · Mixed terms; see README licenses No separately licensed implementation located for this layer in the reviewed sources. [1] |
| model weights | available · License not fully assessed Walking policies are fetched from upstream by the documented script. [1] |
| documentation | available · MIT No separately licensed implementation located for this layer in the reviewed sources. [1] |
This entry scopes the physical robot and its build documentation.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 qilinxiaoxiang/cmu-microduck README.md
Revision, date & where cited
Shawn Xiang and CMU RoboClub · github.com · revision
19f3b0e· README.md at · Accessed Nov 15, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S002 qilinxiaoxiang/cmu-microduck BOM.md
Upstream BOM.md for this project.Revision, date & where cited
Shawn Xiang and CMU RoboClub · github.com · revision
19f3b0e· BOM.md at · Accessed Nov 15, 2026
Used for: Overview, Hardware & parts - S003 qilinxiaoxiang/cmu-microduck LICENSE
Upstream LICENSE for this project.Revision, date & where cited
Shawn Xiang and CMU RoboClub · github.com · revision
19f3b0e· LICENSE at · Accessed Nov 15, 2026
Used for: Overview
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-11-15 — Initial source-reviewed hardware profile and attributed upstream image.