D'Claw
Robot / hardware buildNine-axis three-finger manipulation benchmark with a separately instrumented object. Historical v0.9 hardware and legacy software requirements are scoped separately. [1] [5] [7]
Build & first use →Official website
- For
- Researchers able to assemble and configure Dynamixel-based experimental hardware [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- Apache-2.0 · license not fully assessed for mechanical design · Details by part
Overview
D’Claw is a 9-degree-of-freedom ROBEL platform for dexterous manipulation. This profile pairs the selected software revision 5b0fd3704629931712c6e0f7268ace1c2154dc83 with separately hosted v0.9 hardware documents from 2019. It does not establish that a current commercial kit matches those documents. [1] [2] [5] [6]
Is this for you?
3D preview
D-Claw three-finger simulation assembly. The source robot visual geometry and body hierarchy at its reference pose. Collision geometry, overlays and the surrounding scene are excluded. This is not a verified manufacturing package.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original MJCF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: The ROBEL Authors, revision 9d774735f5d6a599774d01d8808f411054f8cf28. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. Source visual shapes and body transforms evaluated at the reference pose by MuJoCo, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
- Calibration
Historical pre-build instructions require unique motor IDs, 1Mbps baud, PWM limit200 and response delay0 before assembly; horn alignment is specified separately.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
What the physical setup includes
The v0.9 parts list specifies ten XM430-W210-R motors: nine for the hand and one for the object. Treating a nine-motor hand as the complete object-manipulation setup would omit that additional component. The listed hardware also includes H101K and S102K brackets, printed fingers, a back plate, U2D2, a six-port power hub and a 12 V supply rated 5 A or 10 A in the historical parts list. [5]
The pre-build guide assigns three finger chains IDs 10–12, 20–22 and 30–32, with object ID 50. The assembly guide orders the chains clockwise when viewed from above and emphasizes cable management because moving fingers can pull their own cables loose. Its diagrams remain necessary for orientation; this profile does not replace them. [6] [7]
Configure motors before assembling the chains
The historical pre-build guide starts by connecting one motor at a time through U2D2 and the powered hub. It describes Windows R+ Manager, with Dynamixel Wizard 2.0 as an alternative, and changes the default connection from 57,600 baud to 1 Mbps. It also specifies PWM limit 200 and response-time delay zero, followed by ID labeling and horn-case alignment. These are source-reported settings for the documented setup, not settings tested on a reader's hardware. No firmware or motor configuration was changed during this review. [7]
Simulation and hardware are different execution paths
The selected README uses Gym environments with a MuJoCo backend. Its DClaw example selects hardware by supplying a serial device path; omitting that path selects simulation. The same interface does not prove that running a simulated benchmark validates a physical build. D’Claw tasks include Pose, Turn and Screw. [1]
The README requires Python 3.5 or higher and an additional DynamixelSDK Python API installation for hardware operation. Installation instructions target the historical MuJoCo Pro 2.00, mujoco_py and license-key workflow. They should not be presented as a tested installation recipe for current MuJoCo or Gym versions. This catalog did not install the environment, train a policy or reproduce benchmark performance. [1]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Feb 12, 2020 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- 5b0fd3704629931712c6e0f7268ace1c2154dc83 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Official folders list CAD ZIP, SolidWorks plates and STL parts. Raw geometry and reuse licenses were not independently preserved or established. Assembly text was read; diagrams were not inspected. [5] [6] [8] [9] |
| electronics | not found · License not fully assessed Parts and setup documents identify purchased servos, interface and power hub. A complete matched electronics/firmware source package and its licenses were not established; this does not imply all component sources are unavailable. [5] [7] |
| firmware | not found · License not fully assessed Parts and setup documents identify purchased servos, interface and power hub. A complete matched electronics/firmware source package and its licenses were not established; this does not imply all component sources are unavailable. [5] [7] |
| software | available · Apache-2.0 ROBEL repository material only; external hardware PDFs, CAD and third-party dependencies are not assigned this license. [1] [3] |
| model weights | not found · License not fully assessed The project describes learning benchmarks, but matched pretrained-policy/data payloads and their licenses were not established in this review. [1] [4] |
| datasets | not found · License not fully assessed The project describes learning benchmarks, but matched pretrained-policy/data payloads and their licenses were not established in this review. [1] [4] |
| documentation | available · Apache-2.0 ROBEL repository material only; external hardware PDFs, CAD and third-party dependencies are not assigned this license. [1] [3] |
Source availability and remaining gaps
The official hardware folders list CAD archives, printable STL parts and SolidWorks plate files. Their raw geometry and hardware reuse licenses were not independently verified. The assembly and parts documents were read as connector-extracted text; PDF diagrams were not inspected. This establishes documented hardware coverage without claiming a complete fabrication review. [5] [6] [8] [9]
The preserved September 30, 2026 repository metadata reports the software repository as archived. This is maintenance context for that repository, not evidence that all related hardware or community work has stopped. [2]
The selected ROBEL software repository is Apache-2.0 licensed. That license is not automatically assigned to external CAD, hardware PDFs, purchased servo firmware or other dependencies. Matched pretrained weights and datasets were not established. A current complete delivered price also remains unknown. [1] [3] [4] [5]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 google-research/robel: README.md
Revision, date & where cited
github.com · revision
5b0fd37· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 google-research/robel: commit 5b0fd37
Revision, date & where cited
github.com · Accessed Oct 1, 2026
Used for: Overview, What we checked, Source files and licenses - S003 google-research/robel: LICENSE
Revision, date & where cited
github.com · revision
5b0fd37· Accessed Oct 1, 2026
Used for: Source files and licenses - S004 google-research/robel: files
Revision, date & where cited
github.com · revision
5b0fd37· archive file inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S005 ROBEL_D'Claw_PartList.pdf
Revision, date & where cited
google-research / project contributors · drive.google.com · v0.9 document; connector-readable text, diagrams not inspected · Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, What the physical setup includes and 1 more - S006 ROBEL_D'Claw_Assembly.pdf
Revision, date & where cited
google-research / project contributors · drive.google.com · v0.9 document; connector-readable text, diagrams not inspected · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What the physical setup includes, Source files and licenses - S007 ROBEL_PreBuild.pdf
Revision, date & where cited
google-research / project contributors · drive.google.com · v0.9 document; connector-readable text, diagrams not inspected · Accessed Oct 1, 2026
Used for: Assembly & first use, What the physical setup includes, Configure motors before assembling the chains, Source files and licenses - S008 Official hardware folder inventory
Revision, date & where cited
google-research / project contributors · drive.google.com · Root and nested folder listings retrieved October 1 2026 · Accessed Oct 1, 2026
Used for: Is this for you?, Source files and licenses - S009 Official ROBEL hardware links
Revision, date & where cited
google-research / project contributors · sites.google.com · Retrieved October 1 2026 · Accessed Oct 1, 2026
Used for: Source files and licenses - S010 Upstream image and reuse attribution
Media-only review: Upstream ROBEL photograph showing D’Claw manipulators alongside D’Kitty quadrupeds; the full group is not one D’Claw configuration. Reuse basis: Apache-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
The ROBEL Authors · github.com · revision
5b0fd37· Image SHA-256 73a3a29103e369a6c9720fa2c16f4645f004293b7dbe43054a0478d2efd02199; repository · Accessed Oct 25, 2026 - S011 Upstream image and reuse attribution
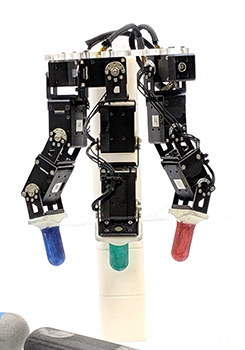
Media-only review: Upstream ROBEL photograph cropped to show D’Claw individually. The full group photograph is linked in the reuse notice. Reuse basis: Apache-2.0. Inspected the pinned original group photo, Apache-2.0 license and original README caption identifying D’Kitty on the left and D’Claw in the middle/right. Crops preserve exact source pixels and do not add or remove robot components. Cropped to isolate D’Claw from the source image; no retouching. Full original retained. Technical/cost evidence dates unchanged.Revision, date & where cited
The ROBEL Authors · github.com · revision
5b0fd37· media/cover.png at ; README identifies D’Kitty left, D’Claw middle/right; image SHA-256 73a3a29103e369a6c9720fa2c16f4645f004293b7dbe43054a0478d2efd02199 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.
2026-10-26 — Replaced shared group photo with a credited robot-specific crop; technical evidence dates unchanged.