DARwIn-OP
Robot / hardware buildA historical small humanoid platform with original mechanical CAD and an assembly manual; electronics and software rights remain separate. [1] [2] [3]
Build & first use →Official websiteUpstream build guide
- For
- Humanoid robotics researchers; Experienced mechanical/electronics builders [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Includes noncommercial terms. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-NC-SA-3.0 (noncommercial) · license not fully assessed for mechanical design · Details by part
Overview
DARwIn-OP is a miniature humanoid research platform from RoMeLa and ROBOTIS. We preserved the original 2011 mechanical part archive: 114 ZIP members include IGS, STEP and native PRT geometry. The v1.0.1 assembly manual gives a parts-sequenced procedure and explicitly requires its companion wiring and fabrication manuals. This is a historical mechanical design and assembly reference, not a verified complete build package. [1] [2] [3]
Begin at the ROBOTIS reference manual to keep the original DARwIn-OP separate from later OP2 designs. The selected platform uses an onboard PC, CM-730 subcontroller and 20 DYNAMIXEL MX-28 modules. Inspect the part ZIP against the manual's part numbers before planning fabrication, then obtain the matching wiring and electronics documentation. We did not reconcile every purchased part or attempt assembly. [1] [2] [3]
The assembly manual grants CC BY-NC-SA 3.0 rights for that document. This review did not establish a matching license for the CAD archive or inspect the linked main/CM-730 firmware sources. ROBOTIS explicitly says FSR firmware is not open source. Current component availability, a complete cost and physical operation remain unverified. [1] [2] [3]
Is this for you?
- Known limitations
- The preserved part ZIP provides mechanical CAD, not the complete electronics, firmware, wiring or procurement package.
- The assembly manual's CC BY-NC-SA terms apply to that document; CAD reuse rights were not established here.
- ROBOTIS states the FSR firmware is not open source.
- Current components, exact revision matching and physical operation were not verified.
Source-layer and reproduction limits.
What you need
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [1]
- Assembly
RoMeLa's v1.0.1 assembly manual gives a parts-sequenced procedure and says to use its wiring and fabrication manuals alongside it.
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The original CAD ZIP is preserved; component selection, assembly placement and reuse rights need review before generating a hosted model.
Model sources
The original CAD ZIP is preserved; component selection, assembly placement and reuse rights need review before generating a hosted model.
What we checked
Source research only; no fabrication, hardware commissioning, software installation or performance test performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Oct 24, 2026
- Next review
- Nov 24, 2026
- Reviewed revision
- DARwIn-OP 2011 part-file archive SHA-256 8507c9a69335a595…; assembly manual v1.0.1, modified 2011-07-26
Source files and licenses
Original CAD geometry and licensed assembly documentation make a useful historical design reference; other layers and CAD rights are unresolved.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Original mechanical STEP/IGS/PRT files were downloaded and ZIP integrity checked; CAD-specific reuse grant unresolved. [1] [2] |
| electronics | not found · License not fully assessed The e-Manual links electronics material, but the payload was not acquired or inspected in this bounded mechanical review. [1] |
| firmware | not found · License not fully assessed Main/CM-730 firmware sources were not acquired; ROBOTIS explicitly says FSR firmware is not open source. [1] |
| software | not found · License not fully assessed Framework source is linked but not pinned or inspected in this mechanical design profile. [1] |
| documentation | available · CC-BY-NC-SA-3.0 RoMeLa's v1.0.1 assembly manual explicitly licenses that document under CC BY-NC-SA 3.0. [1] [3] |
No independent artifact in the selected configuration established during this review.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 ROBOTIS OP reference manual
Links DARwIn-OP CAD and manuals and identifies non-open FSR firmware.Revision, date & where cited
ROBOTIS · emanual.robotis.com · Mechanical, controller and FSR firmware sections · Accessed Oct 24, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S002 DARwIn-OP part-file ZIP
Includes original IGS, STEP and PRT mechanical geometry; complete ZIP SHA-256 and members preserved.Revision, date & where cited
ROBOTIS / RoMeLa project · sourceforge.net · 2011 part archive, 114 files · Accessed Oct 24, 2026
Used for: Overview, Is this for you?, Source files and licenses - S003 DARwIn-OP assembly manual v1.0.1
Names manual version, collaborators, CC BY-NC-SA document license and companion wiring/fabrication manuals.Revision, date & where cited
RoMeLa at Virginia Tech · sourceforge.net · Title page, parts list and assembly sequence · Accessed Oct 24, 2026
Used for: Overview, Is this for you?, What you need, Assembly & first use and 1 more - S004 Upstream image and reuse attribution
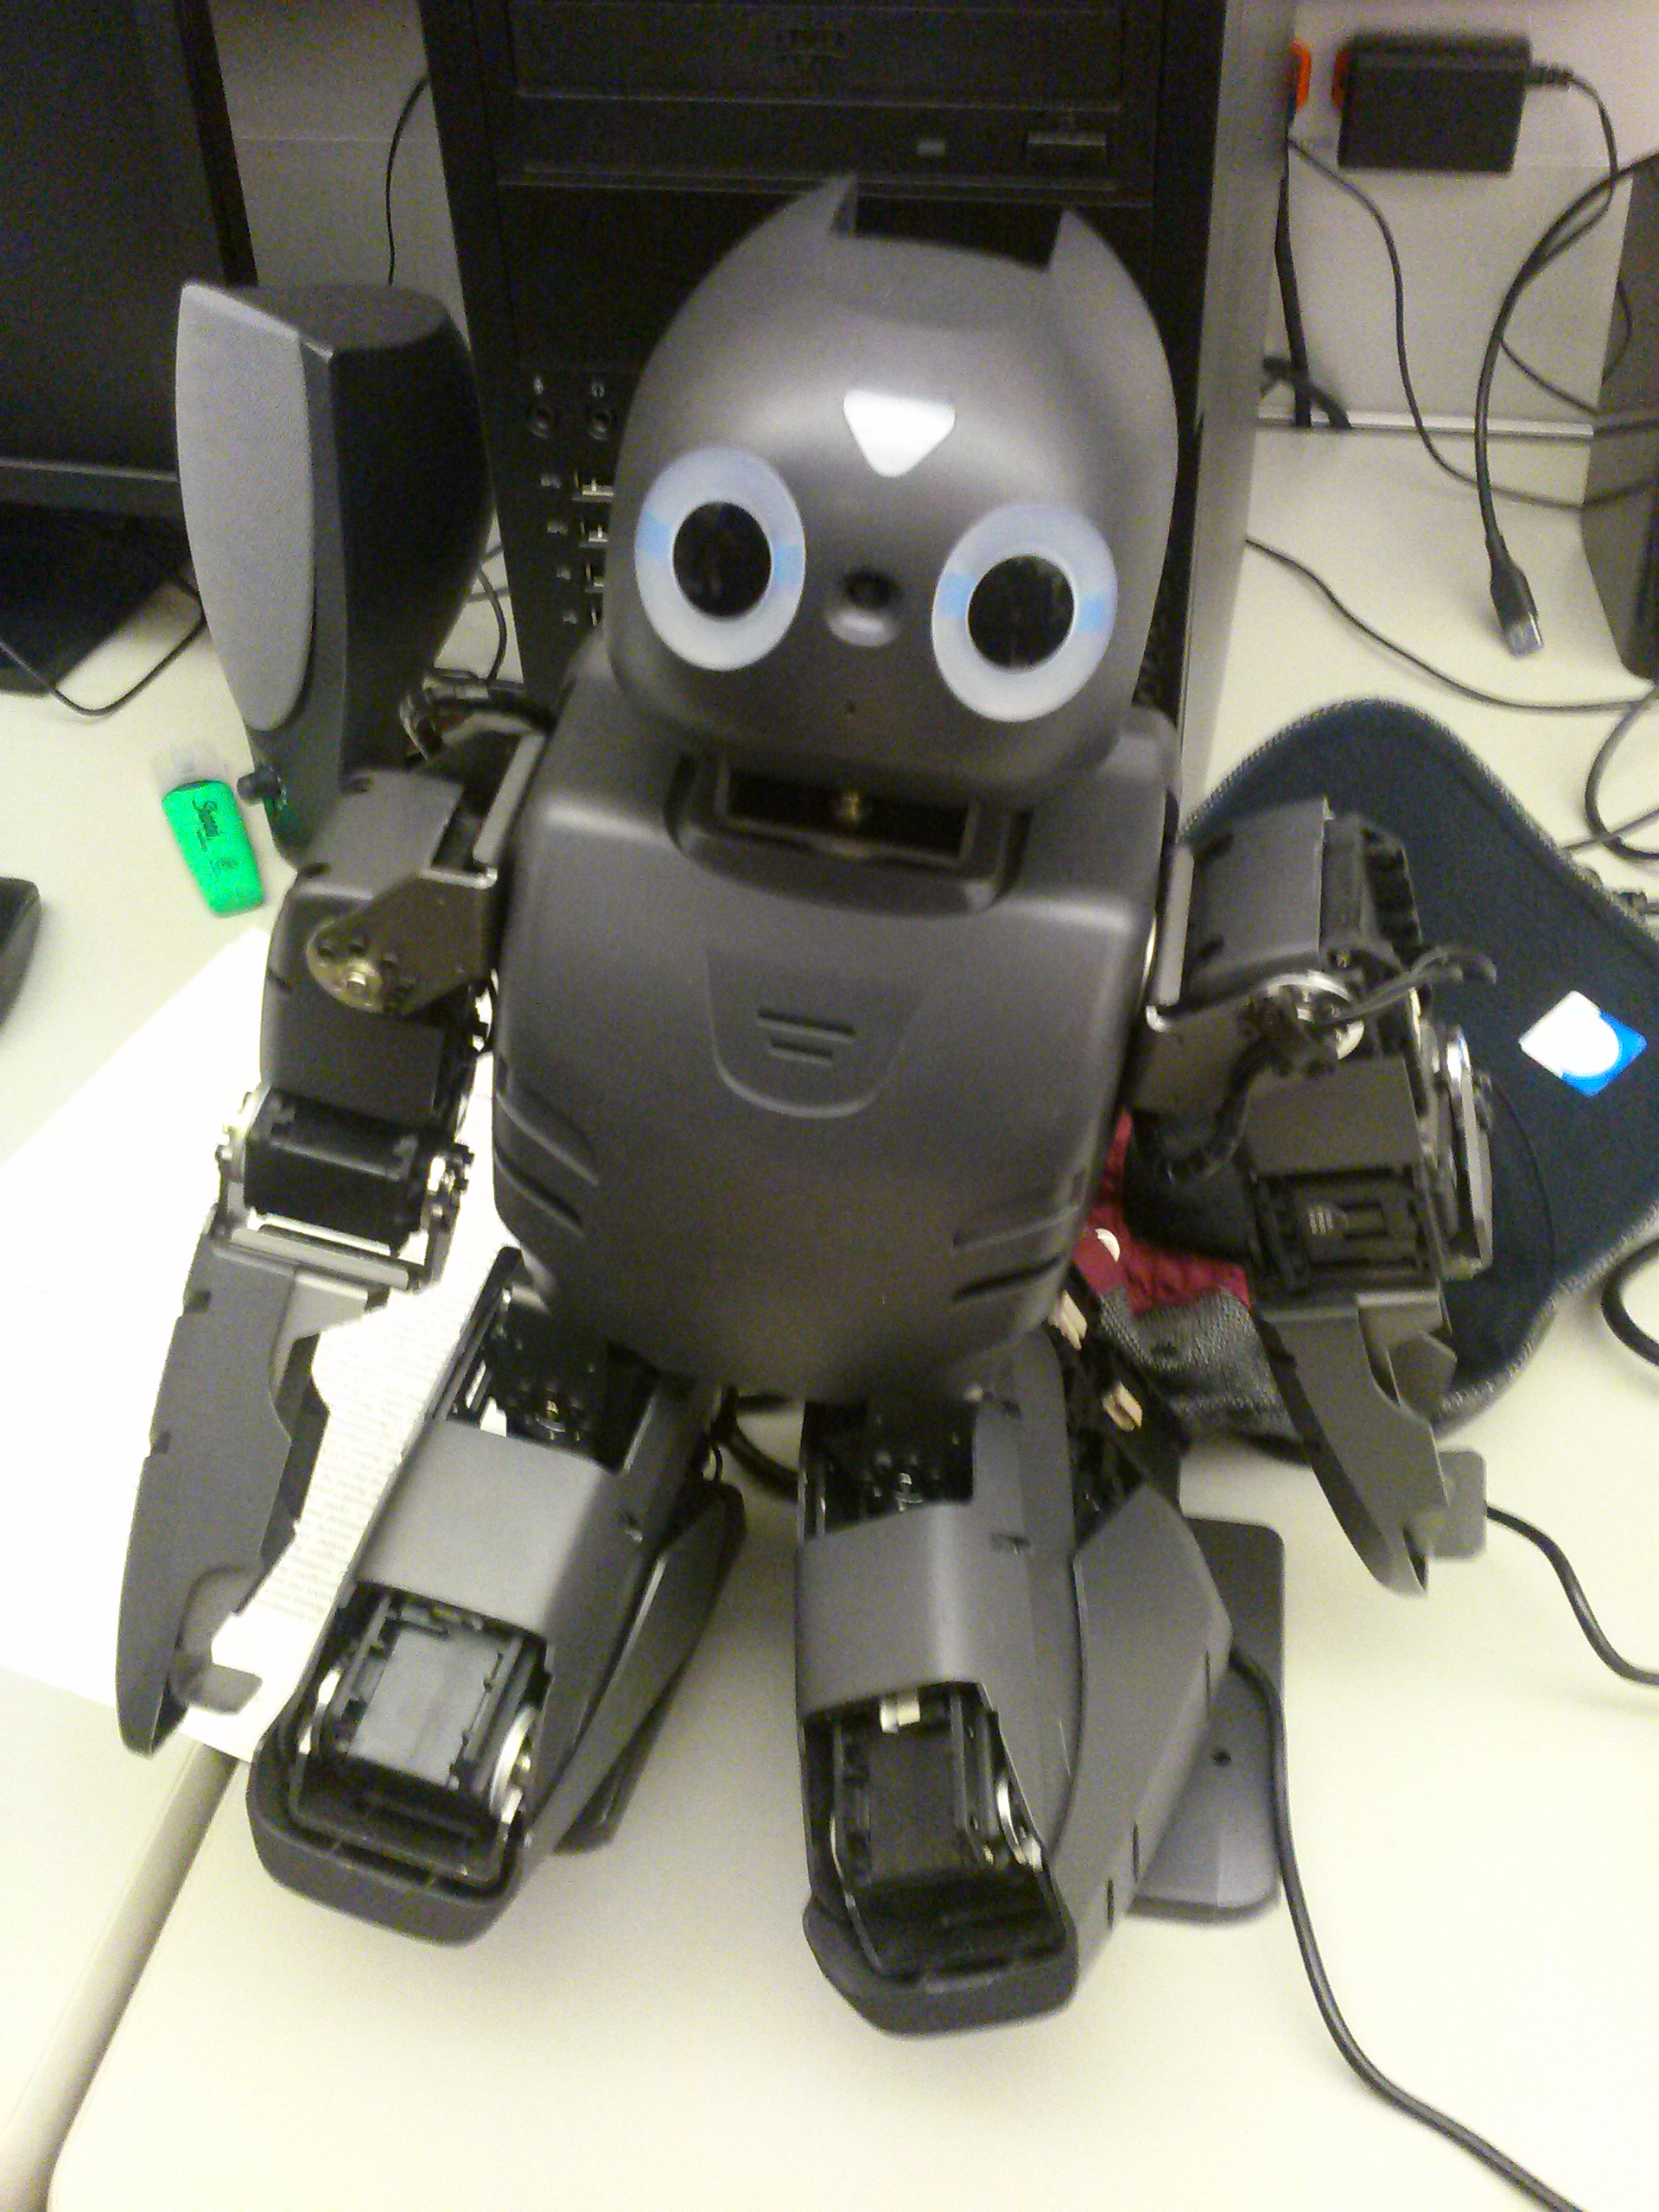
Media-only review: Photograph of a DARwIn-OP in the University of Minnesota Distributed Robotics Laboratory (2015). Reuse basis: CC-BY-SA-4.0. Inspected the actual original image, the file-specific copyright-holder declaration and creator attribution. Historical device/version context is disclosed. This media grant does not change hardware or software rights. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
KaputJonny · commons.wikimedia.org · File-specific creator, licensing declaration and original file history; image SHA-256 878d49962164b7ac348471989485569cf0643d67f6ee9a887d214c7c985b955c · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.