E3D ToolChanger hardware
End effectorTool-coupling hardware with dimensioned aluminum parts, a stepper-driven latch and V6/Hemera tool variants. [1]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Builders comparing tool-coupling geometry and fabrication requirements. [1]
- Cost
- No current cost yet. Upstream bill of materials [2]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
CAD render fallback — view still image
Overview
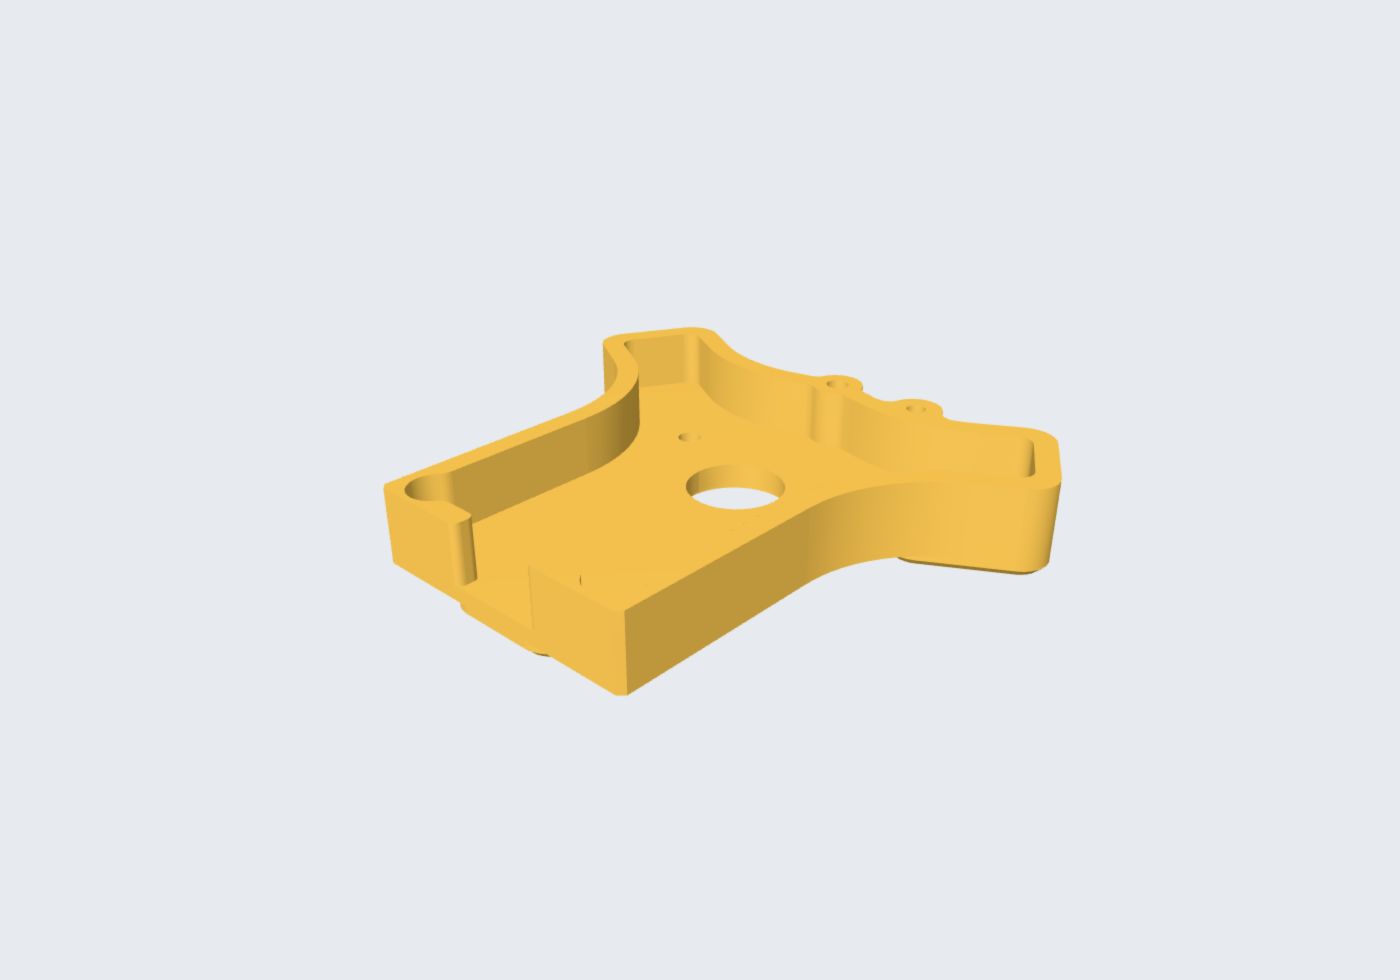
E3D's repository is useful for studying and fabricating a tool-coupling mechanism: it preserves STEP geometry, dimensioned drawings and printed accessories, plus separate V6 and Hemera tool folders. This profile covers the coupling hardware rather than a complete printer or a verified cobot adapter. The interactive preview is the TC-FACE v1.4 aluminum face plate, one component of the assembly. [1] [2] [3]
Is this for you?
3D preview
E3D tool-head face plate. One aluminum face-plate component, not a complete tool changer.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
This model contains one geometric body.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: E3D-Online Ltd, revision d36e0c769d69dac384e7e89e62ec0254aefb45b1. Original and preview: GPL-3.0-or-later. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [1]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Separate machining from printing
The TC-COUPLER-KIT drawing includes an exploded assembly and a 20-line parts list. It calls for a stepper motor, motor bracket, 40-tooth and 20-tooth module-0.5 gears, an endstop switch, MR105RS bearing, shaft, dowel pin, standoff, screws, printed cover and face assembly. A collection of STLs alone therefore does not reproduce the coupling. The TC-FACE drawing specifies aluminum and millimetres; its STEP preview should not be mistaken for a qualified plastic substitute. [2] [3]
The printed-accessory README lists a cover body, cable bracket, cable guide and two Hemera Bowden brackets. Its typical settings are 0.20 mm layers, a 0.40 mm nozzle, three perimeters, five top and bottom layers and 12% infill. These are accessory settings, not manufacturing instructions for the machined face plate. [5]
Match a tool variant before sourcing
The drawing revisions are component-specific: the coupling-kit file is v1.1 while the face plate is v1.4. Keep those identifiers with the selected files instead of treating the repository snapshot as one universal hardware revision. Begin with the coupling drawing and selected tool folder, then reconcile purchased motor, bearing and switch specifications with the controller and docking arrangement you intend to use. [2] [3]
A complete current BOM price, matched controller configuration, homing procedure and cycle-life evidence were not established in this review. Neither robot-arm mounting nor operation in arbitrary orientations is demonstrated by these sources. Those gaps need resolving before adapting this printer-oriented design to an arm. No complete setup quote or physical test is claimed.
E3D explicitly releases the hardware files and drawings under GPL-3.0-or-later. Original STEP bytes are provided unchanged; the triangulated preview and shaded image are labelled derivatives under the same license, with the source drawing and license linked. The image is a CAD render of one plate, not a photograph of a complete tool changer. [1] [3] [4]
What we checked
Source research only. No physical build, procurement, calibration or performance testing.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 4, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
d36e0c7
Source files and licenses
Licensed mechanical source is available; purchased components and complete robot integration are not fully open or verified.
| Layer | Availability / license |
|---|---|
| mechanical design | available · GPL-3.0-or-later Repository hardware license; purchased components retain their own rights. [1] [4] |
| electronics | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. [1] [2] |
| firmware | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. [1] [2] |
| software | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. [1] [2] |
| documentation | available · GPL-3.0-or-later Repository hardware license; purchased components retain their own rights. [1] [4] |
Mechanical tooling profile without a selected learned controller or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Hardware source overview
Revision, date & where cited
E3D-Online Ltd · github.com · revision
d36e0c7· README.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S002 Coupling-kit drawing and parts list
Revision, date & where cited
E3D-Online Ltd · github.com · revision
d36e0c7· PDFs/TC-COUPLER-KIT v1.1.pdf at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S003 Face-plate drawing
Revision, date & where cited
E3D-Online Ltd · github.com · revision
d36e0c7· PDFs/TC-FACE v1.4.pdf at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Assembly & first use, Separate machining from printing and 1 more - S004 e3donline/ToolChanger: LICENSE
Revision, date & where cited
E3D-Online Ltd · github.com · revision
d36e0c7· LICENSE at · Accessed Sep 30, 2026
Used for: Match a tool variant before sourcing, Source files and licenses - S005 Printed accessory settings
Revision, date & where cited
E3D-Online Ltd · github.com · revision
d36e0c7· STLs/README.md at · Accessed Sep 30, 2026
Used for: Assembly & first use, Separate machining from printing
Videos
- S006 E3D (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel E3D · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S006): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.