ESP-Drone
Robot / hardware buildESP32-based educational quadcopter with a documented S2 V1.2 build and sensor-dependent assisted flight modes. [1] [5] [6]
Build & first use →Official website
- For
- Embedded developers and supervised robotics learners [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- GPL-3.0 · license not fully assessed for electronics · Details by part
Overview
ESP-Drone is Espressif's small Wi-Fi-controlled quadcopter project, with flight-control code derived from Crazyflie. This profile selects the documented ESP32-S2-Drone V1.2 configuration. The repository supports other ESP32-family targets, but their board layouts and setup requirements should not be combined into one build. Upstream states that support has been limited since December 2022. [1] [5]
Is this for you?
What you need
Hardware & parts
- Hardware configuration
Small quadcopter; selected ESP32-S2-Drone V1.2
- Actuators
- Four 716 brushed motors; optional720 variant requires motor configuration change
- Controller
ESP32-S2-WROVER with 4 MB flash and 2 MB PSRAM
- Sensors
- MPU6050 on main board
- Optional PMW3901 optical flow and VL53L1X ranging for position hold
- Optional MS5611 pressure sensor
- Power
Selected base list: 300 mAh 1S LiPo and separate 1S charger; 350 mAh alternative
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Model sources
Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Project notes
What the base configuration contains
The V1.2 parts list specifies an ESP32-S2-WROVER/MPU6050 main board, four 716 motors with rubber mounting rings, two A and two B 46 mm propellers, a 300 mAh 1S LiPo battery, a separate 1S charger and pin headers. It lists 720 motors, 55 mm propellers and a 350 mAh battery as alternatives. Selecting the 720 motor also requires changing the motor setting in menuconfig; these alternatives are not extra items to add to the base bill. A current delivered cost was not established. [5]
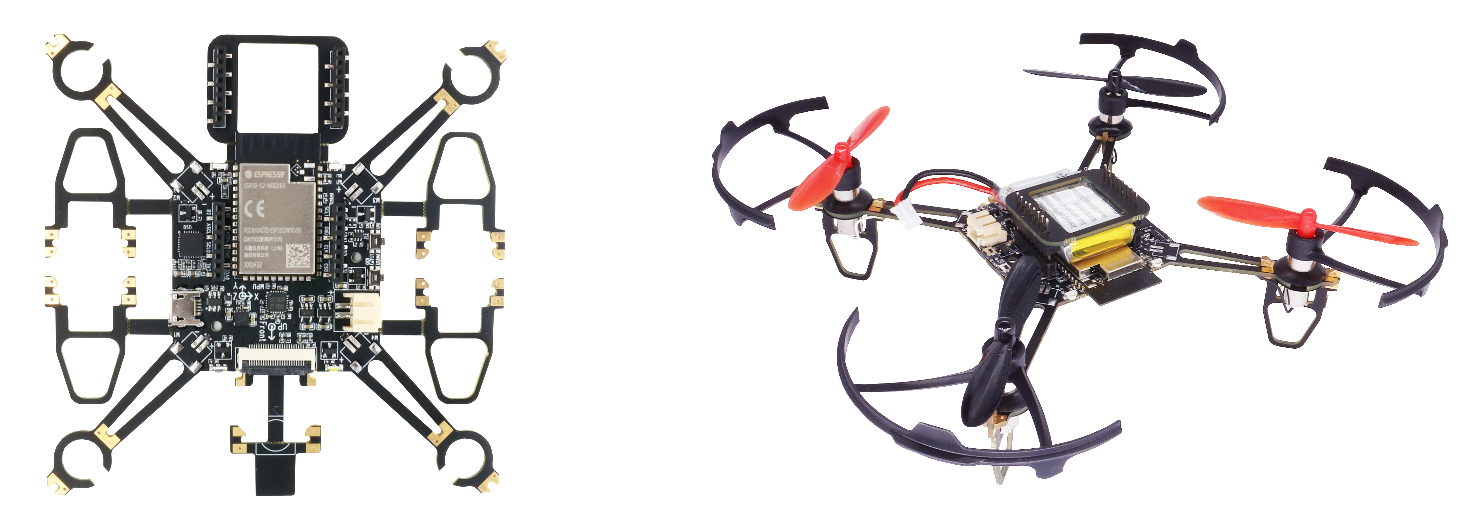
The selected board integrates the airframe arrangement rather than using the separate frame required by the older ESPlane-FC-V1. The assembly guide includes motor soldering and a separate A/B propeller-direction diagram. Follow the diagram for the exact board rather than assuming all four propellers are interchangeable. No assembly or flight was performed for this review. [5] [6] [11]
Assisted flight requires additional hardware
The main-board MPU6050 supports the basic flight configuration. The position-hold extension uses PMW3901 optical flow plus VL53L1X ranging and mounts underneath, facing the ground. A pressure-sensor route uses MS5611. The guide further distinguishes pressure-based altitude hold from ranging-based height hold, so the word “hold” alone is insufficient to identify the required sensors or operating conditions. [5] [6]
These documented modes are upstream capabilities, not catalog-tested performance. The guide includes level-surface startup, sensor orientation and battery-status checks. A successful Wi-Fi connection does not establish that the sensor stack, motor directions or control mapping are correct. [6]
Keep the development and control software matched
The documented development environment is ESP-IDF release/v5.0. Upstream's preserved build workflow includes v4.4 and v5.0 containers, but that workflow configuration is not evidence that this review built either version successfully. Record the source revision, target chip and selected hardware settings together before flashing. [7] [9]
Control can use a mobile app, with a customized cfclient route for PC debugging and gamepad input. The README points to the leeebo cfclient fork while the detailed guide names qljz1993. That mismatch remains unresolved here; compatibility of either fork with the selected firmware was not tested. The guide also warns that online parameter changes are for debugging and do not survive power-down. Preserve final tuning in the appropriate persistent configuration rather than relying on a running session. [1] [6]
Source coverage and remaining gaps
The main repository carries GPL-3.0 and attributes its Crazyflie-derived code. Its third-party table leaves the DSP library's license field blank, so the root license is not presented as a complete audit of every dependency. External mobile applications and client forks require their own source and license checks. [1] [3] [8]
The archive includes hardware schematics, PCB PDFs and BOM spreadsheets, including the S2 V1.2 board and flow deck. Their presence does not establish a complete editable manufacturing package or specific hardware reuse terms. BOM rows and circuit correctness were not validated. No firmware build, flashing, radio-control test or flight test was performed. [5] [10]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Jun 4, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- db0f6562e4f67cccee3acac4dff39c9aaea4e5fa (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | not found · License not fully assessed Selected PCB-based assembly is documented, but a separately licensed editable mechanical fabrication package was not established. [5] [10] |
| electronics | available · License not fully assessed Schematics, PCB PDFs and BOM spreadsheets are present. Specific hardware reuse terms and editable manufacturing completeness were not established; not inferred from firmware GPL. [5] [10] |
| firmware | available · GPL-3.0 Repository GPL3 license; DSP attribution table leaves its license blank. No blanket dependency-license or compatibility certification. [1] [3] [8] [10] |
| software | not found · License not fully assessed External Android/iOS repositories and customized cfclient forks are linked, but their matched sources and licenses were not included in this review. This is not a closed-source finding. [1] [6] |
| documentation | available · GPL-3.0 Repository GPL3 license; DSP attribution table leaves its license blank. No blanket dependency-license or compatibility certification. [1] [3] [8] [10] |
Selected flight-control route does not require learned weights or training data.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 espressif/esp-drone: README.md
Revision, date & where cited
github.com · revision
db0f656· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Assembly & first use, Keep the development and control software matched and 2 more - S002 espressif/esp-drone: commit db0f656
- S003 espressif/esp-drone: LICENSE
Revision, date & where cited
github.com · revision
db0f656· Accessed Oct 1, 2026
Used for: Source coverage and remaining gaps, Source files and licenses - S004 espressif/esp-drone: files
Revision, date & where cited
github.com · revision
db0f656· archive file inventory · Accessed Oct 1, 2026 - S005 docs/en/rst/hardware.rst
Revision, date & where cited
github.com · revision
db0f656· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S006 docs/en/rst/gettingstarted.rst
Revision, date & where cited
github.com · revision
db0f656· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, What the base configuration contains, Assisted flight requires additional hardware and 2 more - S007 docs/en/rst/getespidf.rst
Revision, date & where cited
github.com · revision
db0f656· Accessed Oct 1, 2026
Used for: What you need, Keep the development and control software matched - S008 docs/en/rst/notice.rst
Revision, date & where cited
github.com · revision
db0f656· Accessed Oct 1, 2026
Used for: Source coverage and remaining gaps, Source files and licenses - S009 .github/workflows/build_project.yml
Revision, date & where cited
github.com · revision
db0f656· Accessed Oct 1, 2026
Used for: Keep the development and control software matched - S010 Complete archive inventory
Revision, date & where cited
github.com · revision
db0f656· Pinned archive filenames · Accessed Oct 1, 2026
Used for: Source coverage and remaining gaps, Source files and licenses - S011 Assembly image labels
Revision, date & where cited
github.com · revision
db0f656· docs/_static/assembling_en.png; visual transcription · Accessed Oct 1, 2026
Used for: What the base configuration contains - S013 Upstream image and reuse attribution
Media-only review: Upstream project image showing ESP-Drone hardware configurations; this is not an independently tested build. Reuse basis: GPL-3.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Espressif Systems and ESP-Drone contributors · github.com · revision
db0f656· Image SHA-256 b8d3468396a4ba6bbdc7292bd7ef1c804b4af9dc152cfc4d3532b9c2bd84cabc; repository · Accessed Oct 25, 2026

Videos
- S012 Espressif Systems (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Espressif Systems · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S012): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.