F1TENTH / RoboRacer
Robot / hardware buildAckermann-steered racing research platform; the preserved Xavier NX/Slash guide differs from its newer Orin Nano Super/Fiesta parts list and requires configuration-specific calibration. [1]
Build & first use →Official websiteBill of materials
- For
- Robotics labs comfortable with RC hardware, Jetson setup and ROS configuration [1]
- Cost
- No current cost yet. Upstream bill of materials [9]
- Source rights
- Some licenses are unresolved. Includes noncommercial terms. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- MIT, CC-BY-NC-SA-4.0 (noncommercial) · license not fully assessed for mechanical design, electronics · Details by part
Overview
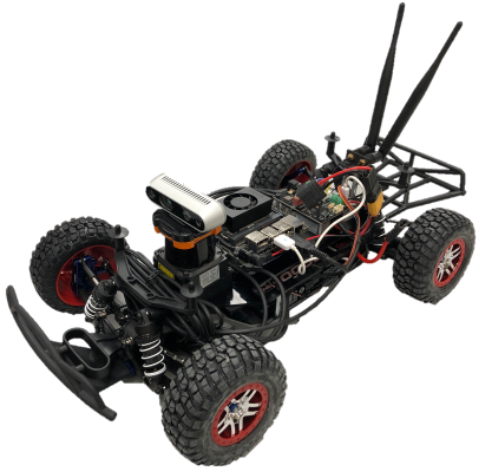
The preserved documentation uses the RoboRacer name for this F1TENTH-linked RC racing platform. Its build page selects a Traxxas Slash 4x4 chassis and Jetson Xavier NX, while the linked workbook now includes a newer Fiesta ST Rally VXL and Orin Nano Super configuration. These are different build generations. This entry records the pinned guide and the newer workbook without claiming that their instructions form one validated configuration. [1] [5] [9]
Is this for you?
- Known limitations
- Pinned guide and live workbook describe different chassis/compute generations
- Deck3.1 folder contains V3 filenames despite changed file sizes
- External deck rights and complete matched firmware configuration unresolved
Source comparison, not a fit or operation test.
3D preview
F1TENTH official RViz proxy. The official F1TENTH Gym ROS RViz proxy: a source-sized chassis box, four wheels and laser cylinder at zero steering positions. It is a simplified simulation visualization, not detailed chassis CAD, a manufacturing model or verification of a selected physical build.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: F1TENTH contributors / Hongrui Zheng, revision 883394df0964c555ee05bea69c3002daf6f2d405. Original and preview: MIT. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Upstream bill of materials [9]
- Hardware configuration
RC-based Ackermann-steered racing platform; pinned guide selects Traxxas Slash4x4 and Jetson XavierNX.
- Controller
Jetson ROS driver stack and VESC motor/steering interface; newer workbook lists OrinNanoSuper and VESC6MkVI.
- Sensors
- Hokuyo10LX lidar in both inspected parts-list generations
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Choose a complete hardware generation before ordering
The workbook section dated May 15, 2026 lists Orin Nano Super, Hokuyo 10LX, a power board and VESC 6 MkVI, with an estimated total of 3022.29. Optional equipment and separate tools/peripheral sections complicate that total; this review did not verify a current delivered quote. Older workbook sections retain Xavier NX and TX2-era choices. Do not copy a price from one section and assembly assumptions from another. [9]
The linked deck folder contains V3 files and a V3.1 folder labeled for a new power board. Files inside the latter still use V3 names, with different sizes from the older files. A filename alone therefore does not establish the deck revision. The listings were preserved, but the geometry, fit and linked-file licenses were not verified. [10] [11]
The pinned driver guide is a Foxy-era setup
The native driver instructions describe ROS 2 Foxy on Ubuntu 20.04 with Xavier-or-newer Jetson hardware and JetPack 5-era setup. They direct older configurations to a separate Docker route. This is the scope of the saved guide, not evidence that the same image and commands reproduce the newer Orin configuration. [6]
The separately preserved f1tenth_system stack provides launch files and parameters and depends on VESC, Ackermann command multiplexing and teleoperation packages. Its README and submodule file name different VESC branches; exact dependency commits were preserved to avoid relying on those moving branch names. No stack compilation or device connection was performed. [12] [14] [15]
Calibrate the actual car before autonomy experiments
VESC setup varies with controller hardware and tool generation. The guide distinguishes servo-output configuration methods, including older non-default firmware. A firmware recipe for an older controller is not established as compatible with every newer VESC in the workbook. [7] [9]
After manual control works, upstream calibrates motor direction, steering center and gain, and the conversion between motor electrical RPM and vehicle speed. Initial checks use a supported car with its wheels free; later distance and turning measurements depend on the actual wheelbase and drivetrain. Record those measurements and configuration values before using odometry for mapping or localization. The guide’s example turn diameter is not a universal target for every chassis. [8]
The driver README also distinguishes the Logitech F710 deadman controls for manual driving and navigation. Confirm the selected joystick mapping rather than assuming those buttons apply unchanged to the newer workbook’s controller. [9] [12]
The documentation carries CC-BY-NC-SA-4.0 terms; the separately inspected driver-stack root uses MIT. Neither establishes blanket rights for linked CAD, purchased components or all dependencies. This is a source-based platform profile with explicit version gaps, not a tested racing build or performance result. [3] [13]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed CAD filenames and revisions listed; raw geometry, complete chassis source and explicit linked-file license not verified. [10] [11] |
| electronics | available · License not fully assessed Build integration instructions and parts evidence; matched complete board manufacturing source and rights not established. [5] [9] |
| firmware | not found · License not fully assessed Guide describes VESC firmware choices, but complete matched firmware source for the selected hardware build not established here; ROS driver source is separate. [7] [15] |
| software | available · MIT Driver-stack root license; dependencies preserved separately and retain their own terms. [12] [13] [15] |
| documentation | available · CC-BY-NC-SA-4.0 Noncommercial documentation license; not blanket licensing for linked CAD, software or purchased hardware. [1] [3] |
Selected physical and driver-stack profile does not select a learned model or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 f1tenth/f1tenth_doc: README.md
Revision, date & where cited
github.com · revision
94efb99· Accessed Oct 1, 2026
Used for: Overview, Assembly & first use, Source files and licenses - S002 f1tenth/f1tenth_doc: commit 94efb99
- S003 f1tenth/f1tenth_doc: LICENSE.txt
Revision, date & where cited
github.com · revision
94efb99· Accessed Oct 1, 2026
Used for: Calibrate the actual car before autonomy experiments, Source files and licenses - S004 f1tenth/f1tenth_doc: files
Revision, date & where cited
github.com · revision
94efb99· archive file inventory · Accessed Oct 1, 2026 - S005 Preserved RoboRacer guide: getting_started/build_car/bom.rst
Revision, date & where cited
github.com · revision
94efb99· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S006 Preserved RoboRacer guide: getting_started/firmware/drive_workspace.rst
Revision, date & where cited
github.com · revision
94efb99· Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, The pinned driver guide is a Foxy-era setup - S007 Preserved RoboRacer guide: getting_started/firmware/firmware_vesc.rst
Revision, date & where cited
github.com · revision
94efb99· Accessed Oct 1, 2026
Used for: Calibrate the actual car before autonomy experiments, Source files and licenses - S008 Preserved RoboRacer guide: getting_started/driving/drive_calib_odom.rst
Revision, date & where cited
github.com · revision
94efb99· Accessed Oct 1, 2026
Used for: Assembly & first use, Calibrate the actual car before autonomy experiments - S009 Linked multi-version parts workbook
Revision, date & where cited
f1tenth / project contributors · docs.google.com · Retrieved workbook text; newest section dated2026-05-15, not pinned to documentation commit · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S010 Linked platform deck inventory
Revision, date & where cited
f1tenth / project contributors · drive.google.com · Drive listing only; geometry and reuse terms not verified · Accessed Oct 1, 2026
Used for: Is this for you?, Assembly & first use, Choose a complete hardware generation before ordering, Source files and licenses - S011 Linked platform deck inventory
Revision, date & where cited
f1tenth / project contributors · drive.google.com · Drive listing only; geometry and reuse terms not verified · Accessed Oct 1, 2026
Used for: Is this for you?, Assembly & first use, Choose a complete hardware generation before ordering, Source files and licenses - S012 Separate driver stack: README.md
Revision, date & where cited
github.com · revision
ae64e05· Accessed Oct 1, 2026
Used for: Hardware & parts, The pinned driver guide is a Foxy-era setup, Calibrate the actual car before autonomy experiments, Source files and licenses - S013 Separate driver stack: LICENSE
Revision, date & where cited
github.com · revision
ae64e05· Accessed Oct 1, 2026
Used for: Calibrate the actual car before autonomy experiments, Source files and licenses - S014 Separate driver stack: gitmodules.txt
Revision, date & where cited
github.com · revision
ae64e05· Accessed Oct 1, 2026
Used for: The pinned driver guide is a Foxy-era setup - S015 Driver stack and dependency acquisition
Revision, date & where cited
github.com · revision
ae64e05· Exact gitlink snapshots preserved; no runtime validation · Accessed Oct 1, 2026
Used for: The pinned driver guide is a Foxy-era setup, Source files and licenses - S016 Upstream image and reuse attribution
Media-only review: Upstream paper photograph of an F1TENTH course vehicle with Jetson Xavier NX, extracted from Figure 3. This is the older course configuration, not the newer Orin Nano Super/Fiesta parts list. Reuse basis: CC-BY-4.0. Actual author-accepted PDF carries explicit CC BY 4.0 on each page. Figure 3 on page 5 identifies F1TENTH hardware setup and labels Jetson Xavier NX; adjoining text discusses the modular configuration. Embedded car photograph is original to this figure with no separate third-party credit or rights exclusion. Extract only the complete car image, preserving exact PDF pixels, rather than unrelated accessory photos in Figure 4. Caption distinguishes old course vehicle from newer parts list. No current component availability claim. Embedded image extracted from page 5 of the source PDF and losslessly decoded to PNG; no retouching. Technical/cost evidence dates unchanged.Revision, date & where cited
Johannes Betz, Hongrui Zheng, Felix Jahncke, Zirui Zang, Florian Sauerbeck, Y. Rosa Zheng, Joydeep Biswas, Venkat Krovi and Rahul Mangharam · doi.org · Accepted author manuscript, page 5 Figure 3, complete car photograph; CC BY 4.0 footer; image SHA-256 a216d63547bdd6bafc0600845a5e72abf06590d09d54fa320b90210ffe0ecb42 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.