Grabette
Robot / hardware buildPollen Robotics handheld demonstration recorder (Raspberry Pi 4, fisheye camera, OAK-D SR, finger angle sensors) with an offline SLAM pipeline that exports LeRobot datasets. [1] [6] [7]
Build & first use →Official websiteUpstream build guideBill of materials
- Cost
- EUR 585.03 upstream parts estimate [8] · checked Oct 5, 2026 · DetailsNot included: printed parts and filament, post-processing workstation and target robot and Gripette and more.
- Source rights
- Named licenses are documented by part. Review licenses
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- Ecosystem
- LeRobot, Raspberry Pi
- License
- Apache-2.0 · Details by part
Overview
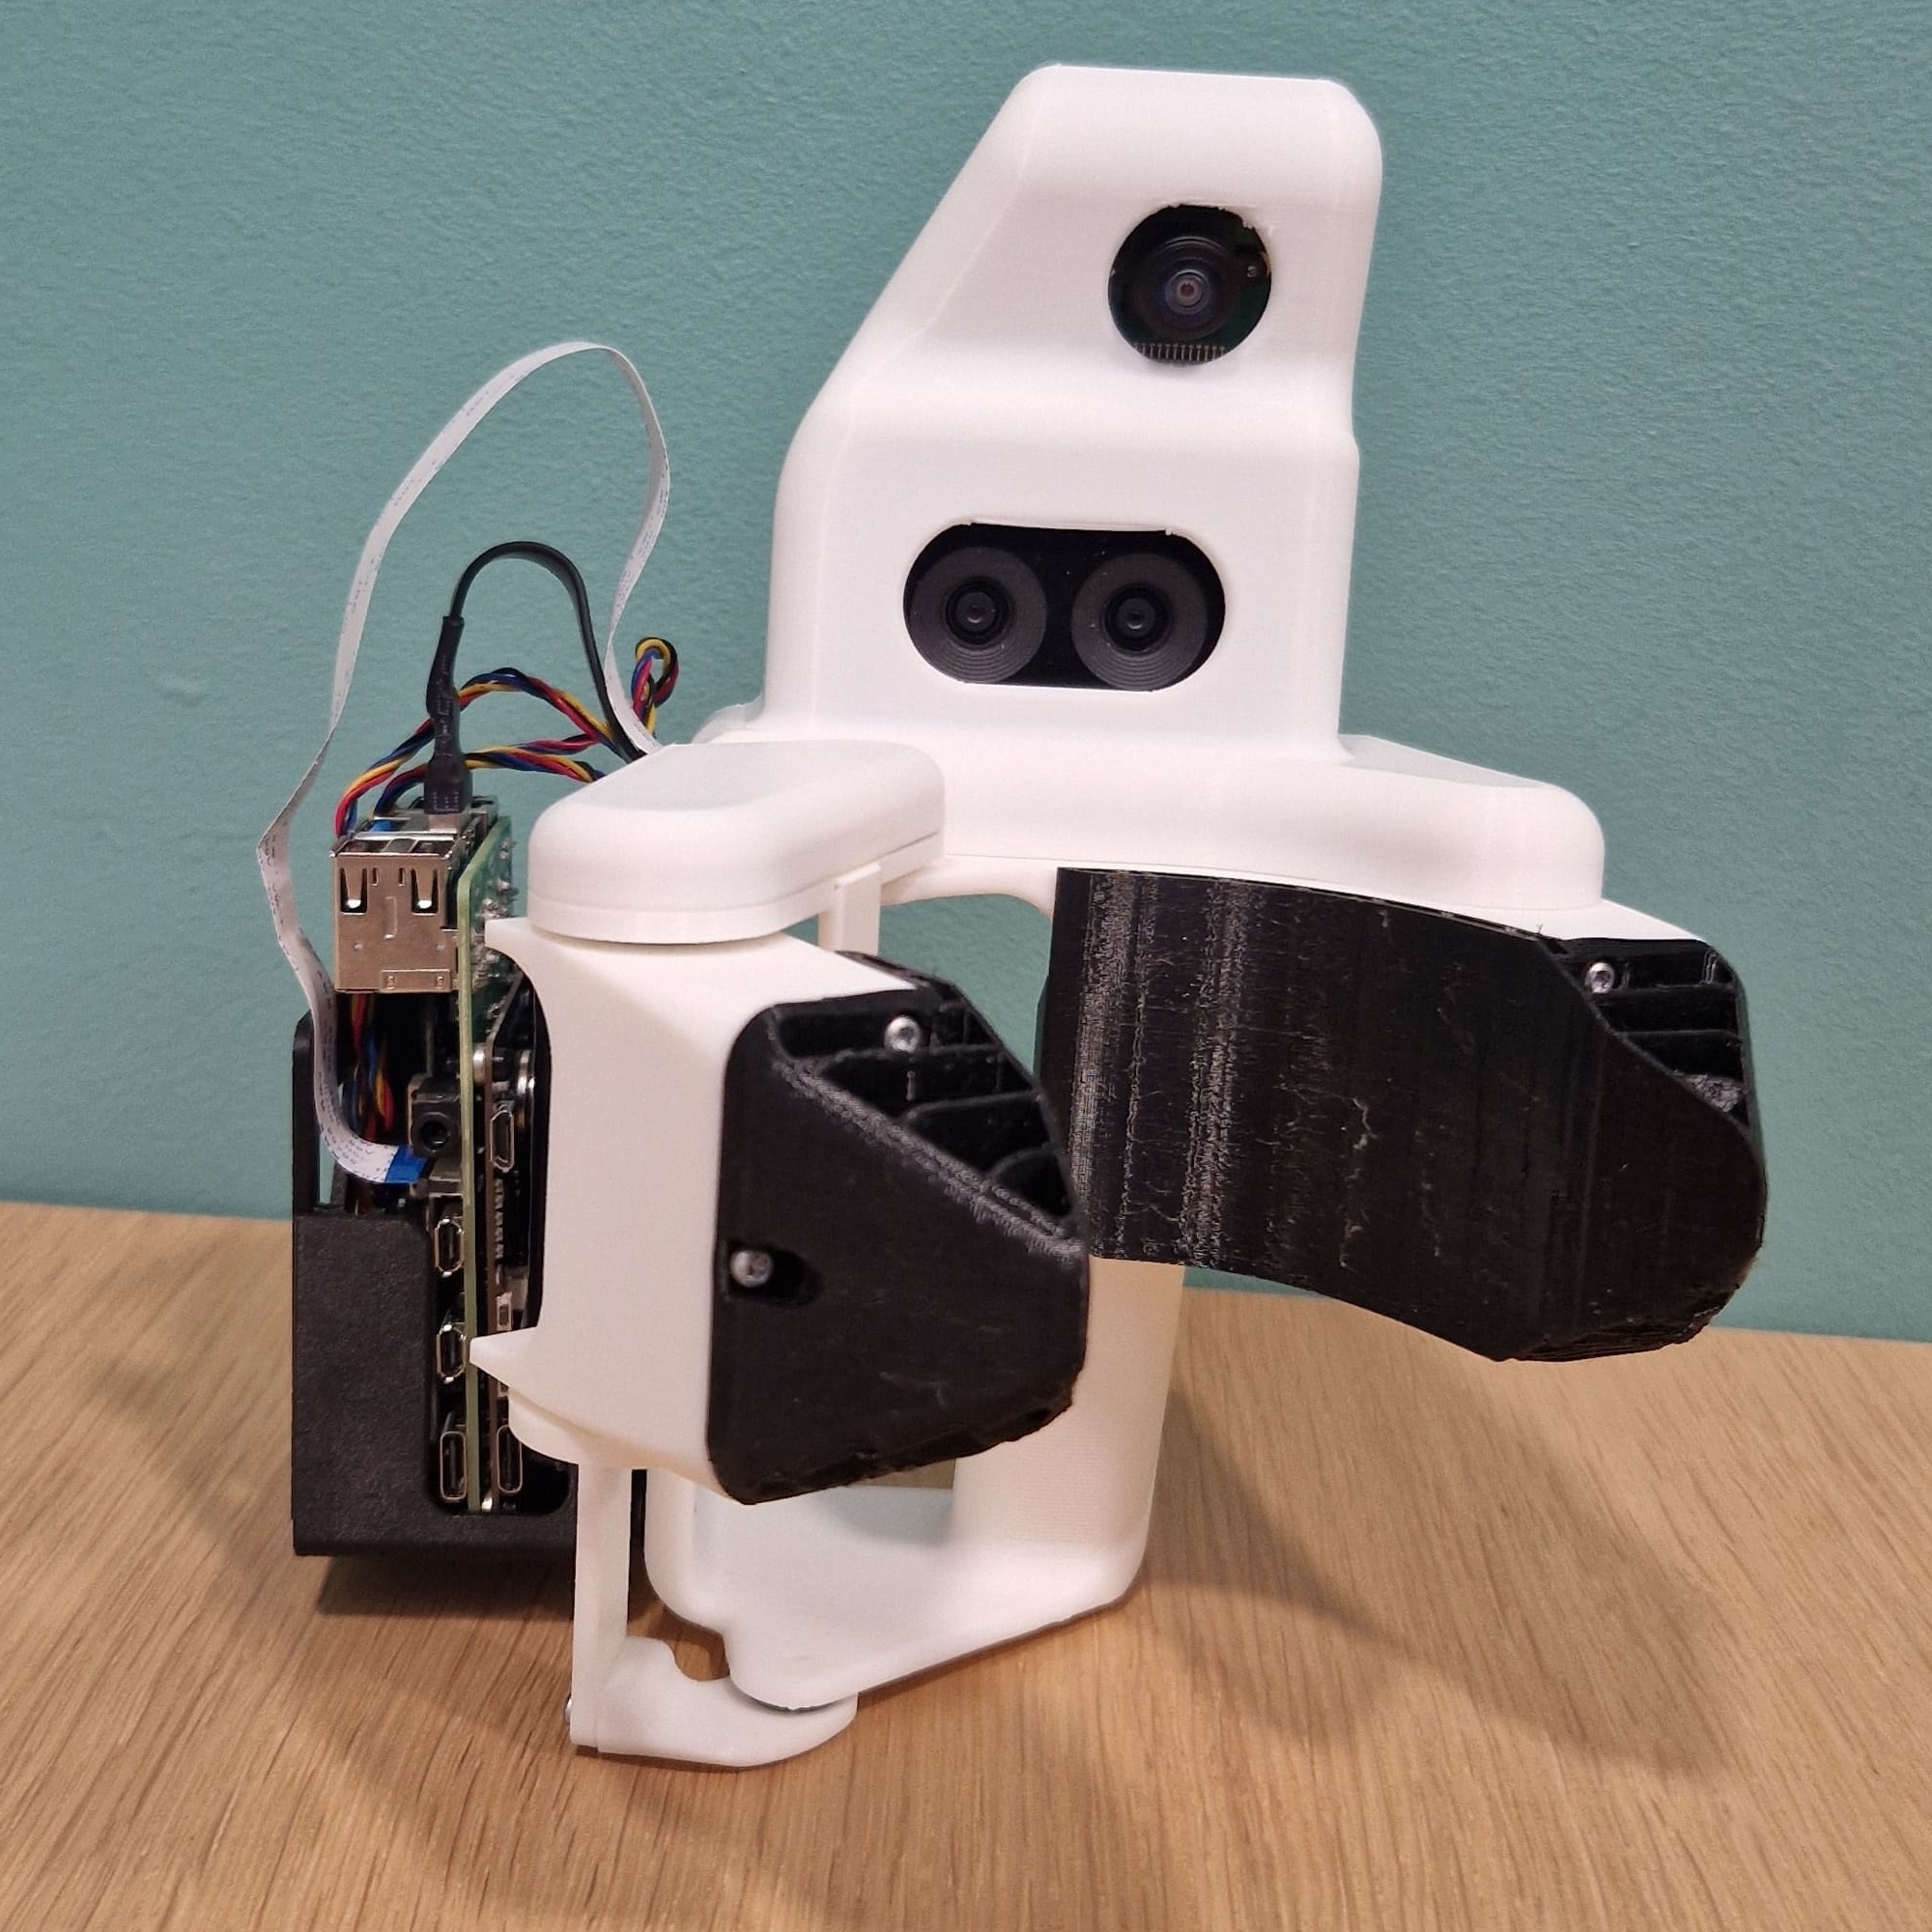
Grabette is a handheld data-collection device from Pollen Robotics, together with a pipeline that turns its recordings into LeRobot datasets. It is not a robot: the operator holds the device, whose finger joints carry angle sensors, while cameras and an IMU record the motion. The same repository also contains Gripette, a robot-mounted gripper on a Raspberry Pi Zero 2W with two STS3215 servos; an OpenArm integration; and a work-in-progress head-mounted device. This entry covers the handheld Grabette at release v1.0.1. Nothing was built, installed or recorded for this entry. [1] [2] [6] [10]
Is this for you?
- Use cases
- Handheld demonstration recording
- SLAM trajectory recovery and LeRobot v3 dataset export
- Diffusion Policy and π0.5 training on OpenArm-Gripette
More on fit and limitations
Who it suits
It suits labs collecting handheld demonstrations, UMI-style, that can run Docker on a workstation and integrate a target robot themselves. The README calls the collection pipeline robot-agnostic, but OpenArm with Gripette is the only robot integration provided; another arm needs its own integrations folder. [1] [11]
What you need
- Operating system
- Raspberry Pi OS Bookworm (Debian 12) and Trixie (Debian 13) on the device
- Host computer
Raspberry Pi 4 on the device; a workstation with Docker for SLAM post-processing
- Dependencies
- uv workspace
- Docker image built from docker/oak_vslam (RTAB-Map v0.23.1)
- LeRobot for dataset generation
- picamera2/libcamera on the Pi
- Git LFS for mesh assets
- Tools
- FDM printer able to print PLA, PETG and TPU
Hardware & parts
Upstream bill of materials [1] [8]
- Hardware configuration
Handheld two-finger data-collection device; not actuated. Built as a left or right hand.
- Controller
Raspberry Pi 4
- Sensors
- Raspberry Pi camera module with fisheye lens (1296×972 @ 46 fps)
- OAK-D SR stereo RGB-D camera with on-board IMU (200 Hz)
- 2× AS5600L rotary encoders on finger joints
- Power
PiSugar3+ battery module listed in the BOM
Assembly & first use
Open the upstream getting-started guide [6]
- Build the handheld device from the BOM, STEP files and assembly/print guides
- Flash Raspberry Pi OS Lite (64-bit) and run make install-rpi HAND=left|right
- Record episodes via the button or dashboard
- Run grabette-postprocess SLAM in Docker and export a LeRobot dataset
- Assembly
packages/grabette/assembly holds left/right STEP files and assembly and print-guide PDFs; the assembly PDF is an LFS payload (about 24.7 MB) not preserved here.
- Calibration
Hand (left/right) chosen at install; angle-convention configuration documented in package docs (not inspected in detail).
Cost
| Version | Price |
|---|---|
| One Grabette handheld device (Grabette tab of the published BOM) | EUR 585.03 [8] Parts estimate |
Upstream EUR column (USD column also given) · Checked 2026-10-05
| Included | Raspberry Pi 4 (4 GB); OAK-D SR; PiSugar3+; Arducam B0404; 128 GB SD card; Angle sensor modules, HAT, switch, cables, magnets, bushings, screws |
|---|---|
| Not included | Printed parts and filament; Post-processing workstation; Target robot and Gripette; Shipping and taxes |
| Stock | Supplier stock not rechecked. |
| Delivery and tax | Not established. |
Price details
Published BOM total for one handheld device; sheet also gives US$655.88. OAK-D SR is €293.46 of the total. Not re-quoted.
Upstream EUR column (USD column also given) · Checked 2026-10-05 · Quantity 1
Printed parts; workstation with Docker; a robot for deployment.
Cost scope
The Grabette tab of the published BOM totals €585.03 (US$655.88) for one device. The OAK-D SR accounts for €293.46 of that, about half. Printed parts and filament, the workstation and any target robot are not in the sheet. These are the sheet's figures, not re-quoted prices. [8]
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
What the device contains
The handheld device runs a Raspberry Pi 4 with a fisheye Raspberry Pi camera module (1296×972 at 46 fps) and an OAK-D SR stereo RGB-D camera. The OAK-D SR supplies depth and its on-board IMU supplies inertial data; the README marks the camera as required for trajectory recovery and notes that its stream is off by default to save battery, so it must be switched on before recording episodes for the pipeline. Two AS5600L encoders measure the proximal and distal finger joints, and a Grove LED button starts and stops recording. Each device is built as a left or right hand, chosen at install time. The software is tested on Raspberry Pi OS Bookworm and Trixie and serves a dashboard on port 8000. The BOM also lists a PiSugar3+ battery, a 128 GB SD card and a Raspberry Pi HAT. [6] [8]
From recording to dataset
grabette-postprocess runs offline RTAB-Map visual-inertial SLAM in a locally built Docker image to recover camera trajectories, then writes LeRobot v3 datasets as Parquet and MP4. The device README also mentions uploading episodes to Hugging Face "for cloud SLAM processing"; the inspected postprocess guide documents only the local Docker route. Python requirements need checking: the root README says postprocessing needs Python 3.12 or newer, while the postprocess README says 3.11 or newer. Diffusion Policy and π0.5 training integrations are included. [1] [6] [7]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links. AI-assisted drafting with a separate LLM editorial judge; no independent human technical review.
Updates
Source files and licenses
Software, documentation and STEP part files are released under Apache-2.0 with notices; the full Onshape CAD is external, and STL and assembly-guide payloads sit in Git LFS.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Apache-2.0 Left and right STEP part files in packages/grabette/assembly under the package Apache-2.0 LICENSE; STL copies are LFS pointers. Full Onshape CAD is external and not preserved; its license coverage is not established. STEP geometry not inspected. [1] [6] [9] |
| electronics | not found · License not fully assessed Off-the-shelf modules (Pi 4, OAK-D SR, encoders, HAT); no custom PCB or wiring design files identified. [6] [8] |
| software | available · Apache-2.0 Device service, post-processing and integrations; third-party components listed with their own licenses. [1] [3] [4] [5] |
| documentation | available · Apache-2.0 Package READMEs and docs in the repository. [1] [3] [6] |
Device runs Python services on Raspberry Pi OS; no microcontroller firmware in the handheld configuration.
No trained weights distributed in the inspected sources.
Users record their own; no dataset distributed in the inspected sources.
Sources and licenses
The repository carries an Apache-2.0 LICENSE, a NOTICE crediting Pollen Robotics and a third-party notices file listing RTAB-Map (BSD-3-Clause), DepthAI (MIT), OpenArm and LeRobot (Apache-2.0) and onshape-to-robot (MIT). The device package has its own Apache-2.0 LICENSE, and its assembly folder holds left and right STEP part files. The STL copies, the assembly PDF and the print-guide PDF are Git LFS pointers in the archive. The print guide's payload was retrieved separately and matches its pointer checksum; it splits parts across PLA, PETG and TPU soft tips, with 0.2 mm layers and 30 to 100% infill depending on the part. The 24.7 MB assembly PDF and the STL payloads were not preserved, and STEP geometry was not inspected. The full CAD is an external Onshape document; whether the Apache-2.0 grant covers it is not established. [1] [3] [4] [5] [6] [9] [12]
Release v1.0.1 was published on July 21, 2026, from a commit dated July 17; the repository had 118 GitHub stars at retrieval, a dated popularity signal only, and its default branch has moved on since the release. [2]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 GRABETTE README
Toolkit purpose, components, BOM and Onshape links, LFS note, development requirements, license.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· README.md at release v1.0.1 () · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S002 Release v1.0.1 and acquisition metadata
Latest stable release selected; archive SHA-256 recorded; dated repository popularity.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · GitHub release v1.0.1 published 2026-07-21; tagged commit dated 2026-07-17; manifest retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Overview, What we checked, Source files and licenses - S003 GRABETTE license
Repository license file.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· LICENSE (Apache License 2.0 text) · Accessed Oct 5, 2026
Used for: Source files and licenses - S004 GRABETTE NOTICE
Copyright 2026 Pollen Robotics; Apache-2.0; third-party notice pointer.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· Accessed Oct 5, 2026
Used for: Source files and licenses - S005 GRABETTE third-party notices
Third-party components and licenses.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· Accessed Oct 5, 2026
Used for: What you need, Source files and licenses - S006 Grabette device package README
Handheld hardware table, BOM/CAD/assembly links, Raspberry Pi install, hand selection, dashboard.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S007 grabette-postprocess README
Offline RTAB-Map SLAM in Docker and LeRobot v3 dataset generation.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, From recording to dataset - S008 Grabette bill of materials (published Google Sheet, Grabette tab)
Per-part EUR and USD prices and device total.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · docs.google.com · CSV of the published Grabette tab (gid 0); snapshot sha256 e4b87742d817… retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Hardware & parts, Cost, What the device contains, Source files and licenses - S009 Release archive inventory and LFS check
Left/right STEP part files present; STL meshes and assembly/print PDFs are Git LFS pointers; package-level Apache-2.0 LICENSE.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· Filename inventory of the v1.0.1 archive (800 members), .gitattributes, LFS pointer files and packages/grabette/LICENSE · Accessed Oct 5, 2026
Used for: Is this for you?, Assembly & first use, Source files and licenses - S010 Gripette package README
Robot-mounted gripper hardware: Pi Zero 2W, camera, two STS3215 servos, optional OAK-D SR.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· Accessed Oct 5, 2026
Used for: Overview - S012 Grabette 3D print guide (PDF, LFS payload)
Material and print settings per part group.Revision, date & where cited
Pollen Robotics SAS · github.com · revision
dcad06f· LFS payload fetched from media.githubusercontent.com at ; sha256 9a75d40f3900… matches the pointer OID · Accessed Oct 5, 2026
Used for: What you need, Source files and licenses - S011 OpenArm-Gripette integration README
Custom 7-DoF OpenArm follower with Gripette; sim/real gRPC design.Revision, date & where cited
Pollen Robotics / GRABETTE contributors · github.com · revision
dcad06f· Accessed Oct 5, 2026
Used for: Is this for you? - S013 Upstream image and reuse attribution
Media-only review: Upstream photograph of the Grabette handheld interface, including its cameras and gripper. Reuse basis: Apache-2.0; inspected packages/grabette/LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Pollen Robotics contributors · github.com · revision
dcad06f· Image SHA-256 d431b576d23df1e046d9ac5f0fe5d8121821d8a032f05b43c278bdd41d740973; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Created from Growbotics-listing lead; all claims checked against preserved upstream sources. No physical build or test.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.