iCub
Robot / hardware buildA research humanoid family whose hardware revisions, robot configuration and software distribution must be matched before reproduction. [1]
Build & first use →Official websiteUpstream build guide
- For
- Humanoid research laboratories; Experienced C++ robotics developers [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- Mixed/unreconciled: COPYING GPL-2.0-or-later; LICENSE BSD-3-Clause, BSD-3-Clause · license not fully assessed for mechanical design, electronics · Details by part
Overview
iCub is a family of research humanoids, not a single set of parts identified by the icub-main release number. The official hardware table distinguishes changes to hands, tactile sensing, cameras, compute and batteries across versions. For example, its v2.10 entry adds 4K FRAMOS cameras and an Orin NX to a v2.7-based platform; the experimental v3 family is listed separately. These distinctions must be resolved before a lab can reproduce another installation. [5]
Is this for you?
3D preview
iCub v2.7 simulation model. The official iCubGazeboV2_7 visual model at zero joint positions, with source link hierarchy and component placement. This v2.7 example does not represent every iCub revision, including v2.10 or iCub3, and is not manufacturing CAD or a demonstration of motion.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Istituto Italiano di Tecnologia / robotology contributors, revision dca8c618c264be70ce285bad38040411725e3551. Original and preview: CC-BY-SA-4.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Host computer
Developer machine, robot laptop and icub-head have different documented installation roles
- Dependencies
- Select a released robotology-superbuild distribution for a matched software set
- Robot-specific configuration and firmware require separate matching
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [5] [6] [7] [8] [10] · Project documentation [5] [6] [7] [8] [10]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Start from the robot's configuration
The hardware documentation points to separate mechanical CAD libraries, robot mechanics, electronics boards and wiring repositories. It also treats upgrade kits and tendon replacement as their own tasks. The preserved icub-main package is therefore a software starting point, not a complete manufacturing archive. This review has not selected a physical revision or verified its BOM, controller firmware, delivered cost or replacement-part supply. [1] [4] [8]
The inspected documentation is maintained under MESH, with its source snapshot preserved alongside the main software. Use that hardware version table and the robot's actual installed configuration to narrow the next review. [5] [8]
Preserve a distribution, not only icub-main
The installation guide distinguishes a developer computer from the special icub-head setup. It recommends released software distributions for users outside the core development team, with robotology-superbuild providing a coordinated source-installation route. The Linux guide explicitly checks out a dated distribution tag before following the superbuild instructions. Capturing one icub-main release does not pin that distribution or establish that it will run on a particular robot. [6] [7]
Licensing also needs a closer pass before reuse. The inspected main archive contains a GPL-2.0-or-later declaration in COPYING and a BSD-3-Clause declaration in LICENSE, plus additional license files. We retain that unresolved file-level scope rather than labeling the entire robot BSD or GPL. No software installation, robot calibration or hardware test was carried out. [3] [10]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Jul 24, 2026 [2]
- Latest release
- Jul 24, 2026 [2]
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- icub-main 719ae2a66be7175efc9b9bb99dc72ce2fda0449e (release v2.12.1); relocated documentation 4df9fd755f0d2054ce93144e457a517c442d929f (commit snapshot). No matched complete physical robot build selected. · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Official hardware index links this separate repository. Contents, matched revision and manufacturing rights remain unreviewed; icub-main archive is not a hardware copy. [8] |
| electronics | available · License not fully assessed Official hardware index links this separate repository. Contents, matched revision and manufacturing rights remain unreviewed; icub-main archive is not a hardware copy. [8] |
| firmware | not found · License not fully assessed Complete matched robot firmware not established in inspected main software and documentation; separate firmware/configuration review required. [4] [8] |
| software | available · Mixed/unreconciled: COPYING GPL-2.0-or-later; LICENSE BSD-3-Clause Do not apply one root declaration to all files. A component-level license inventory remains necessary. [3] [10] |
| documentation | available · BSD-3-Clause Inspected documentation repository declaration; not a license for the entire robot. [11] |
No particular learned policy or dataset selected by this family-level source review.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 robotology/icub-main: README.md
Revision, date & where cited
github.com · revision
719ae2a· Accessed Sep 30, 2026
Used for: Start from the robot's configuration - S002 robotology/icub-main: commit 719ae2a
- S003 robotology/icub-main: COPYING
Revision, date & where cited
github.com · revision
719ae2a· Accessed Sep 30, 2026
Used for: Preserve a distribution, not only icub-main, Source files and licenses - S004 robotology/icub-main: files
Revision, date & where cited
github.com · revision
719ae2a· archive file inventory · Accessed Sep 30, 2026
Used for: Start from the robot's configuration, Source files and licenses - S005 MESH iCub documentation: docs/icub_versions/index.md
Revision, date & where cited
robotology / project contributors · github.com · revision
4df9fd7· docs/icub_versions/index.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S006 MESH iCub documentation: docs/sw_installation/index.md
Revision, date & where cited
robotology / project contributors · github.com · revision
4df9fd7· docs/sw_installation/index.md at · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 1 more - S007 MESH iCub documentation: docs/sw_installation/linux_from_sources_superbuild.md
Revision, date & where cited
robotology / project contributors · github.com · revision
4df9fd7· docs/sw_installation/linux_from_sources_superbuild.md at · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 1 more - S008 MESH iCub documentation: docs/icub_hw.md
Revision, date & where cited
robotology / project contributors · github.com · revision
4df9fd7· docs/icub_hw.md at · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S009 MESH iCub documentation: docs/sw_installation/check_your_installation.md
Revision, date & where cited
robotology / project contributors · github.com · revision
4df9fd7· docs/sw_installation/check_your_installation.md at · Accessed Sep 30, 2026 - S010 Additional iCub license declarations
Revision, date & where cited
github.com · revision
719ae2a· COPYING, LICENSE, LICENSE.BSD and LICENSE.GPL-2 · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S011 Documentation repository license
Revision, date & where cited
robotology / project contributors · github.com · revision
4df9fd7· LICENSE at · Accessed Sep 30, 2026
Used for: Source files and licenses - S014 Upstream image and reuse attribution
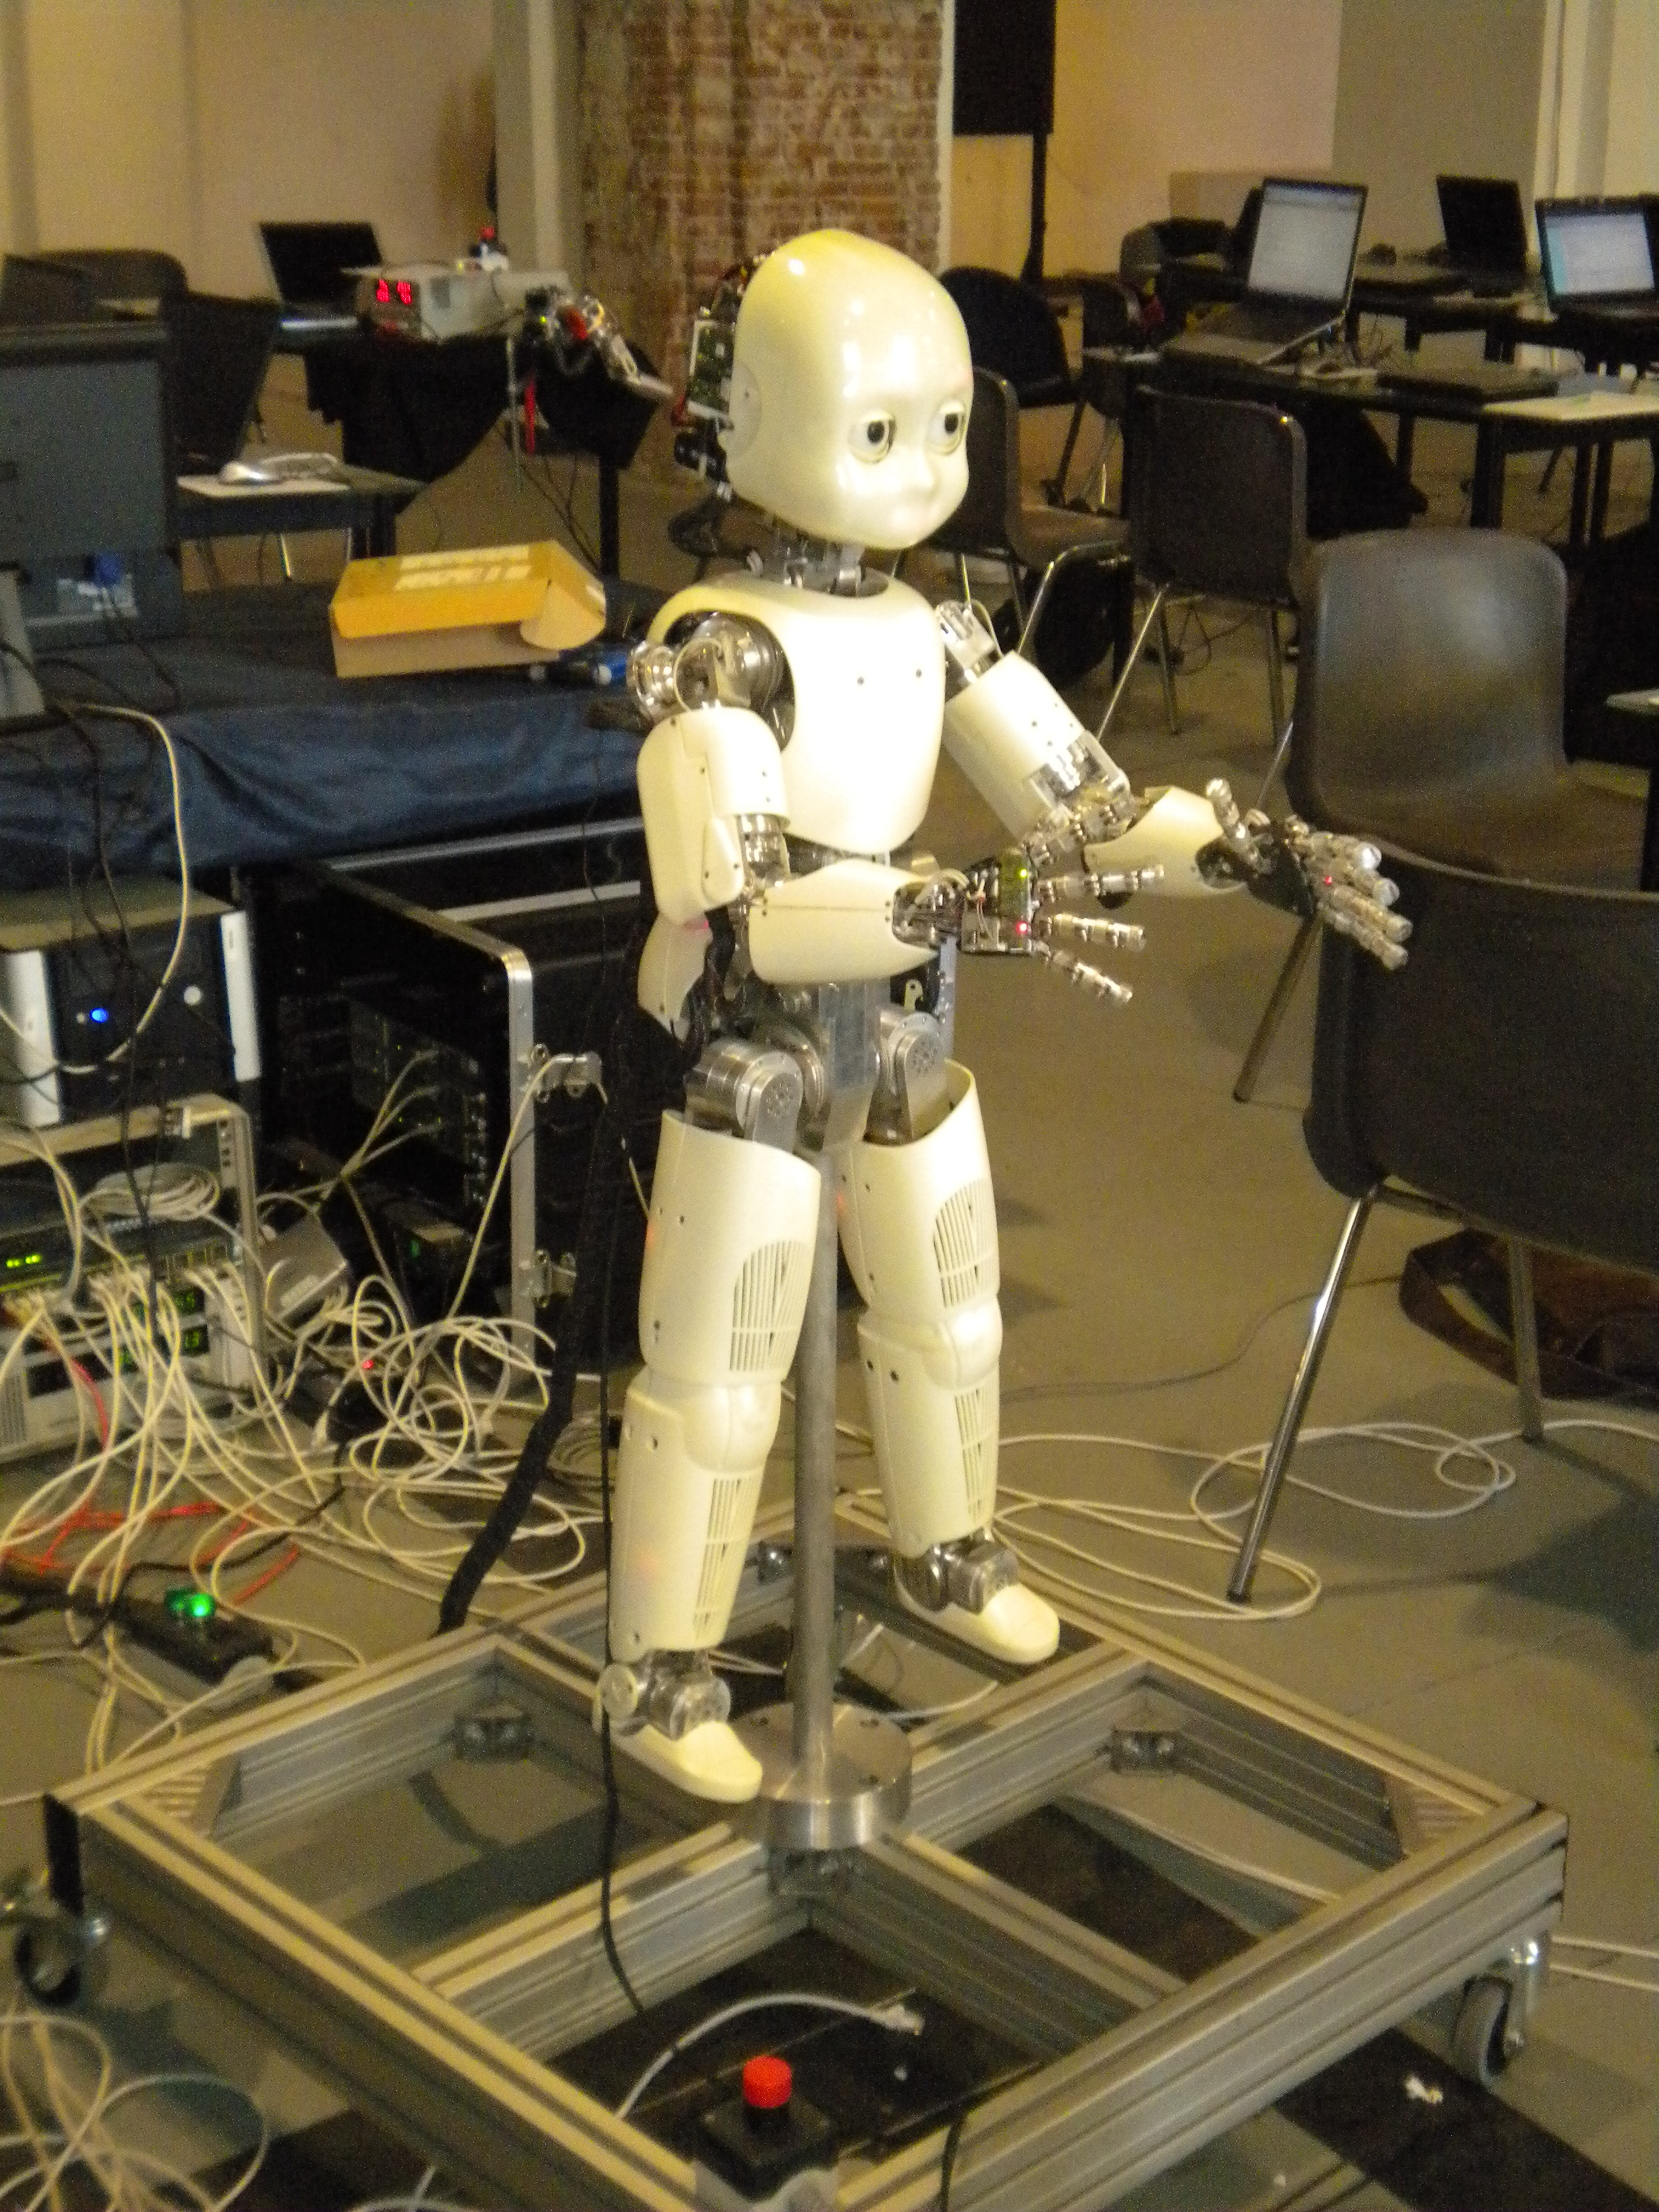
Media-only review: Historical photograph of an iCub mounted on a supporting frame (uploaded in 2010); later iCub versions may differ. Reuse basis: CC-BY-SA-3.0. Inspected the actual original image, the file-specific copyright-holder declaration and creator attribution. Historical device/version context is disclosed. This media grant does not change hardware or software rights. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
Jll at English Wikipedia · commons.wikimedia.org · File-specific creator, licensing declaration and original file history; image SHA-256 1996612a45d4bf0dc3275cbc58371dc216dee49ef77057940553c806072e4228 · Accessed Oct 26, 2026
Videos
- S012 A Cartesian 6-DoF Gaze Controller for Humanoid Robots (YouTube video)
Video from the project’s own channel (iCub HumanoidRobot), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video iCub HumanoidRobot · youtube.com · Accessed Oct 4, 2026
- S013 motionCUT (YouTube video)
Video from the project’s own channel (iCub HumanoidRobot), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video iCub HumanoidRobot · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 2 YouTube reference(s) (S012, S013): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.