InMoov
Robot / hardware buildA modular printable humanoid with body-section tutorials, tendon-driven hands and a separate MyRobotLab control route. [1] [2] [3] [5]
Build & first use →Official websiteUpstream build guide
- For
- Makers interested in incremental humanoid construction; Educational builders with fabrication support [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Includes noncommercial terms. Review licenses
- Unknowns
- host computer, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-NC-3.0 (noncommercial) · license not fully assessed for documentation · Details by part
Overview
InMoov is organized as a modular humanoid build, with separate finger, hand, arm, head and torso instructions. That makes a small mechanism a useful starting point, but it also means the STL library is not one ready-to-order robot configuration. Our local collection preserves 413 linked STL files across 36 categories, including different generations and optional parts. Each file has a checksum; the collection is a dated download snapshot, not a single upstream release or a verified complete build. [1] [5]
Is this for you?
What you need
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [1] [2] [3] [5] · Project documentation [1] [2] [3] [5]
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The reviewed design license includes a noncommercial restriction. The original design is linked; a hosted derivative needs a separate reuse decision.
Model sources
The reviewed design license includes a noncommercial restriction. The original design is linked; a hosted derivative needs a separate reuse decision.
Project notes
A finger test and an i2 hand have different scopes
The Finger Starter tutorial uses four named printed parts, one servo and an Arduino Uno. It asks builders to print a fit calibrator before the full part set and to clear hinge holes after printing. It also warns that servo current can reset the Arduino and recommends an appropriate external supply. A successful finger build would test one mechanism and its power arrangement, not qualify a full humanoid. [2]
The i2 hand is a larger task. Its one-right-hand list specifies six JX-6225MG 300-degree servos, springs, braided line, PTFE guides, five AH3503 Hall sensors and magnets. The assembly includes drilling, tapping, fitting finger joints, routing tendons and soldering sensor wires. Printer access alone therefore does not describe the tools or labor required. [3]
The i2 instructions also refer to forearm and wrist-interface parts during assembly. Reconcile those adjoining modules with the selected hand before ordering or printing; the hand list should not be treated as the BOM for an entire arm. Keep the calibration sample, file versions, servo choice and cable route with that selected configuration. [3]
Separate the printed files from the control system
The main guide describes an Arduino and MyRobotLab/Python route. The Finger Starter page distinguishes scripts for different MyRobotLab generations. We preserved selected tutorials and the STL collection, but did not establish a complete matched software, electronics and firmware pack or reproduce the control setup. [1] [2] [5]
The STL library identifies Gaël Langevin's design under CC BY-NC 3.0. That noncommercial declaration matters when considering a kit or fabricated-parts offer. Current component quotations, rights for the intended offer, and measured assembly, calibration and support work remain unresolved. [4]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 2026-09-30 website and per-file checksum snapshot
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-NC-3.0 Library declaration credits Gaël Langevin; noncommercial terms do not establish permission for commercial kits. [4] [5] |
| electronics | not found · License not fully assessed Tutorials identify Arduino, sensors and MyRobotLab routes, but a complete matched source/software pack was not preserved in this STL and tutorial review. [1] [2] [3] |
| firmware | not found · License not fully assessed Tutorials identify Arduino, sensors and MyRobotLab routes, but a complete matched source/software pack was not preserved in this STL and tutorial review. [1] [2] [3] |
| software | not found · License not fully assessed Tutorials identify Arduino, sensors and MyRobotLab routes, but a complete matched source/software pack was not preserved in this STL and tutorial review. [1] [2] [3] |
| documentation | available · License not fully assessed Selected tutorials preserved; complete hardware map, all modules and controls not reconciled. [1] [2] [3] |
No learned model or dataset selected for the finger/hand build route.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 InMoov build overview
Revision, date & where cited
Gaël Langevin / InMoov · inmoov.fr · Captured source d77e0bc8ac68cc7c2b4d8e2121874c7b0a3c736cc87c19d400bc971187c00c86 · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 Finger Starter assembly tutorial
Revision, date & where cited
Gaël Langevin / InMoov · inmoov.fr · Captured source dba1f37ec89b7abca1e872dd3689768242fc7a5bcf7cbee7d02aa53616884380 · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S003 Hand i2 assembly and component list
Revision, date & where cited
Gaël Langevin / InMoov · inmoov.fr · Captured source 26f0fa27ff40bbca868544f736631ab7026e78b104c7afa221aca3f2e2155721 · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S004 STL library and license declaration
Revision, date & where cited
Gaël Langevin / InMoov · inmoov.fr · Captured source 1dd00d7bf9269bdaec8baf5b0ca3aeb9ed772eafdc398cd195c662f3fc049b84 · Accessed Sep 30, 2026
Used for: Separate the printed files from the control system, Source files and licenses - S005 Preserved STL file inventory
Revision, date & where cited
Gaël Langevin / project contributors · inmoov.fr · Local acquisition receipt for public STL URLs; individual SHA-256 values · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S006 Upstream image and reuse attribution
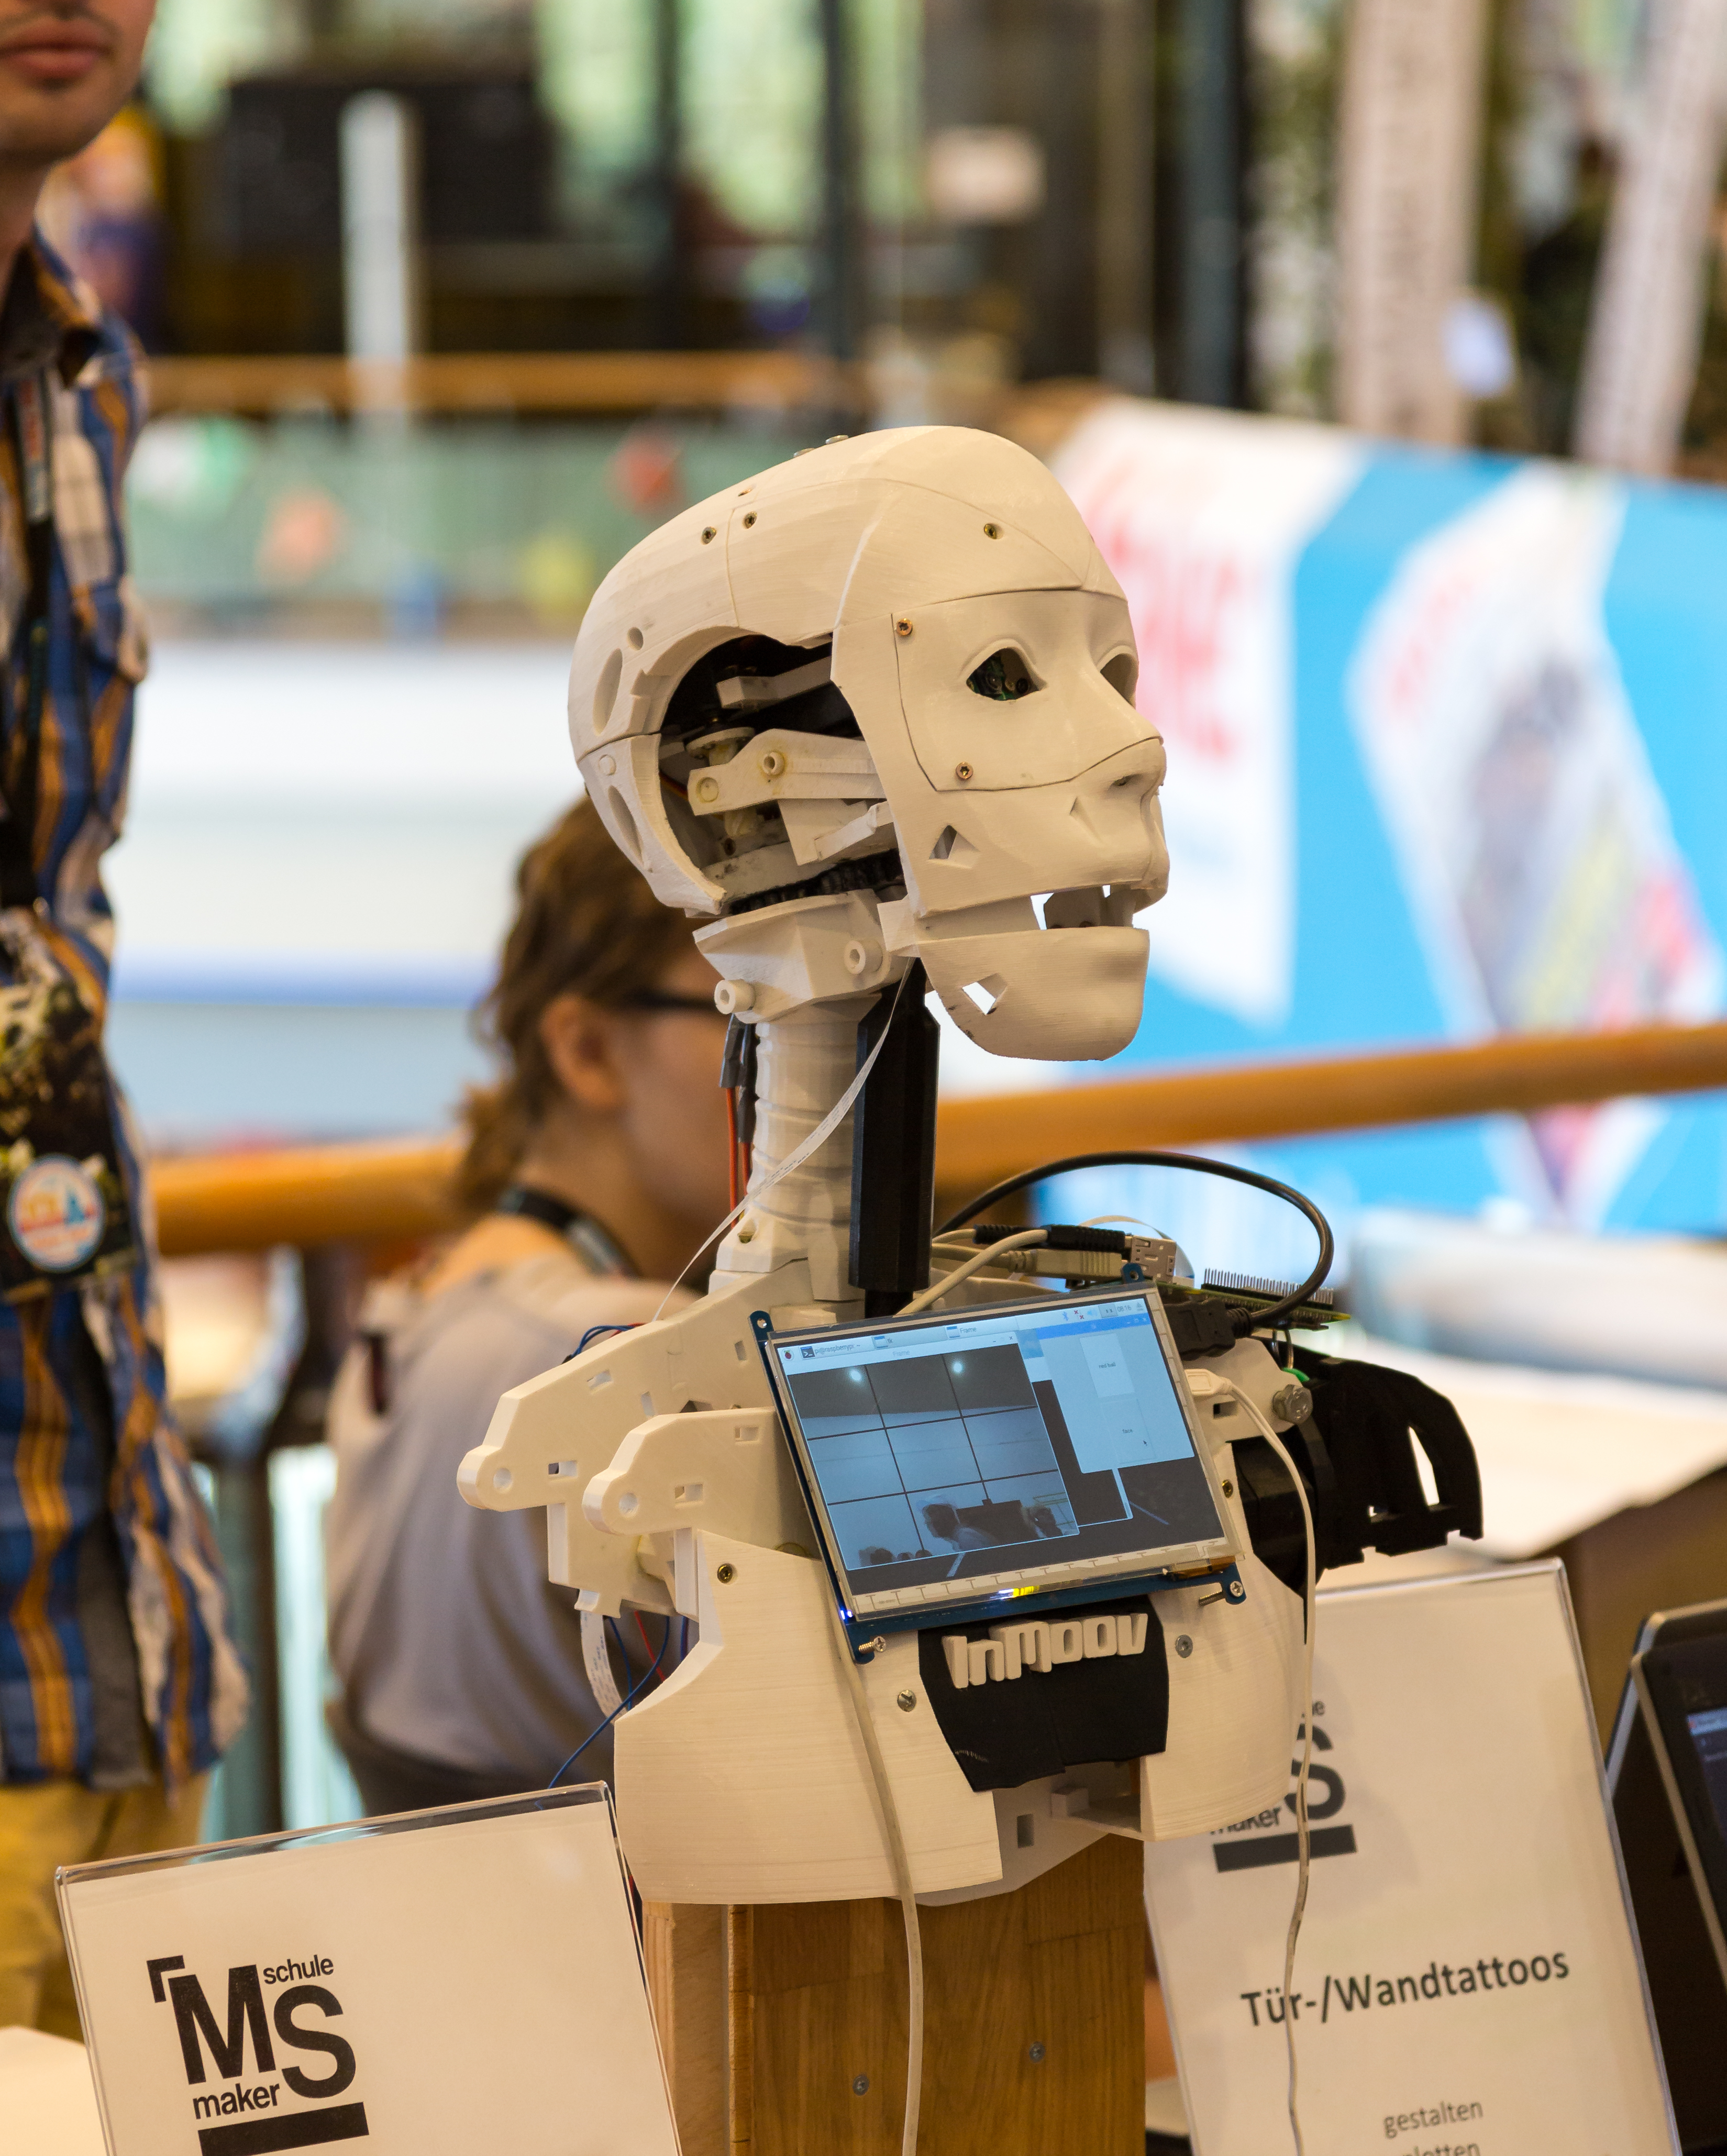
Media-only review: Photograph of an InMoov head and upper torso at Maker Faire Berlin, May 26, 2018; a historical build, not a complete assembled humanoid. Reuse basis: CC-BY-SA-4.0. The photographer explicitly identifies InMoov at Maker Faire Berlin 2018. Visual review shows the modular printed head and partial torso with InMoov identification. Caption limits the pictured assembly and date; no claim it represents every current body section. Photographer rights declaration saved, not the Commons page-text license. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
Matti Blume · commons.wikimedia.org · File description, author, date, Licensing and original photograph; image SHA-256 037642d5d3b2c0631012f60b30d92c2f1822d874d5ccdb775d13aa6035f182bb · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.