LEAP Hand
End effectorAn anthropomorphic hand with Full and Lite motor options and separate CAD downloads. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- not fully assessed for mechanical design, documentation · Details by part
Is this for you?
- Known limitations
- Resolve SDK licensing discrepancy and CAD license version; verify Full/Lite revisions and current motor/kit prices. CAD downloads are unversioned website snapshots.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
3D preview
LEAP Hand simulation robot description. The LEAP Hand simulation robot description (assets/leap_hand/robot.urdf in the first-party LEAP_Hand_Sim repository at commit 150bc3d) at zero joint positions: the palm, three fingers and thumb as 17 link meshes on the source joint tree, with 16 revolute joints. This simulation model does not distinguish the Full and Lite motor options in the profile's LEAP_Hand_API revision. Motor shapes included in the link meshes cannot be separated, and their third-party terms are unknown. Displayed under the stricter noncommercial CAD terms; no commercial-use or manufacturing clearance is claimed. Fit and function are not verified.
Noncommercial license: the LEAP Hand CAD is published by Kenny Shaw and Deepak Pathak under noncommercial Creative Commons terms. The LEAP_Hand_API LICENSE file states “Creative Commons Attribution-NonCommercial 4.0 International License (CC BY-NC 4.0)”, while its readme states “CAD: CC BY‑NC‑SA (non‑commercial use with attribution)” without a version. The separate LEAP_Hand_Sim repository that contains this URDF carries an MIT notice (Copyright 2023 Ananye Agarwal). This preview applies the stricter noncommercial terms, keeps attribution and is shared alike; no commercial-use or manufacturing clearance is claimed. License: CC BY-NC 4.0 (LEAP_Hand_API LICENSE) · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Kenny Shaw and Deepak Pathak (LEAP Hand CAD); Ananye Agarwal (LEAP_Hand_Sim), revision 150bc3d4b61fd6619193ba5a8ef209f3609ced89. Original and preview: CAD: CC BY-NC 4.0 (LICENSE) / CC BY-NC-SA (readme, no version); simulation repository: MIT. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Dexterous hands
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
- Assembly
Choose Full or Lite and left/right hand, print the appropriate palm/fingertips, assemble and assign IDs, connect external power and USB, calibrate for the selected build.
Research synopsis of upstream route; not independently executed instructions.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Configuration and sourcing
This profile covers LEAP v1 Full and Lite, which use different motor selections.
Full: 16 XC330-M288-T motors; Lite: 16 XL330-M288-T motors. U2D2, motor brackets, power wiring, the upstream-listed 5 V 30 A supply, printed palm/fingers and fasteners. Upstream describes Lite motors as weaker and less durable. Upstream describes construction, assembly and control as shared between Full and Lite. It lists PLA printed parts, a soldering iron and assembly tools. Optional soft fingertips use different CAD and require a direct-drive printer; that fabrication choice is separate from Full versus Lite motors. [1] [2] [3] [4] [5] [6]
Choose Full or Lite and left/right hand, print the appropriate palm/fingertips, assemble and assign IDs, connect external power and USB, verify the selected build’s calibration procedure, which is not established by this review. [1] [2] [3] [4] [5] [6]
Integration
CAD download page offers a top plate labelled Xarm/Franka/UR5 and a blank plate. SDK supports Python/C++/ROS/ROS2; exact software versions require review. [1] [2] [3] [4] [5] [6]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- b0d00c881d0119077b2cab771a6de44f5aaec904; LEAP v1 Full and Lite retained as separate configurations
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed CAD page states CC BY-NC-SA. SDK README states MIT code but root LICENSE says CC BY-NC 4.0; conflict unresolved. [1] [2] [3] [4] [5] [6] |
| electronics | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] |
| firmware | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] |
| software | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] |
| documentation | available · License not fully assessed CAD page states CC BY-NC-SA. SDK README states MIT code but root LICENSE says CC BY-NC 4.0; conflict unresolved. [1] [2] [3] [4] [5] [6] |
This configuration is reviewed as a physical end effector with ordinary control, without a selected learned policy or dataset.
Design limits and source rights
Resolve SDK licensing discrepancy and CAD license version; verify Full/Lite revisions and current motor/kit prices. CAD downloads are unversioned website snapshots. [1] [2] [3] [4] [5] [6]
The CAD page states CC BY-NC-SA: attribution, noncommercial use and ShareAlike terms. Its precise license version needs clarification. The SDK README says MIT for code, but its root LICENSE says CC BY-NC 4.0. That conflict remains unresolved; do not use either statement as blanket permission for the complete hand. [1] [2] [3] [4] [5] [6]
This is a source-researched design profile. We have not assembled or tested this configuration; no complete current setup price is established.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 leap-hand/LEAP_Hand_API: readme.md
Revision, date & where cited
github.com · revision
b0d00c8· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S002 leap-hand/LEAP_Hand_API: LICENSE
Revision, date & where cited
github.com · revision
b0d00c8· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S003 leap-hand/LEAP_Hand_API: files
Revision, date & where cited
github.com · revision
b0d00c8· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S004 parts
Revision, date & where cited
leap-hand / project contributors · v1.leaphand.com · text.txt · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S005 cad
Revision, date & where cited
leap-hand / project contributors · v1.leaphand.com · text.txt · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S006 cad_terms
Revision, date & where cited
leap-hand / project contributors · v1.leaphand.com · text.txt · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S007 Upstream image and reuse attribution
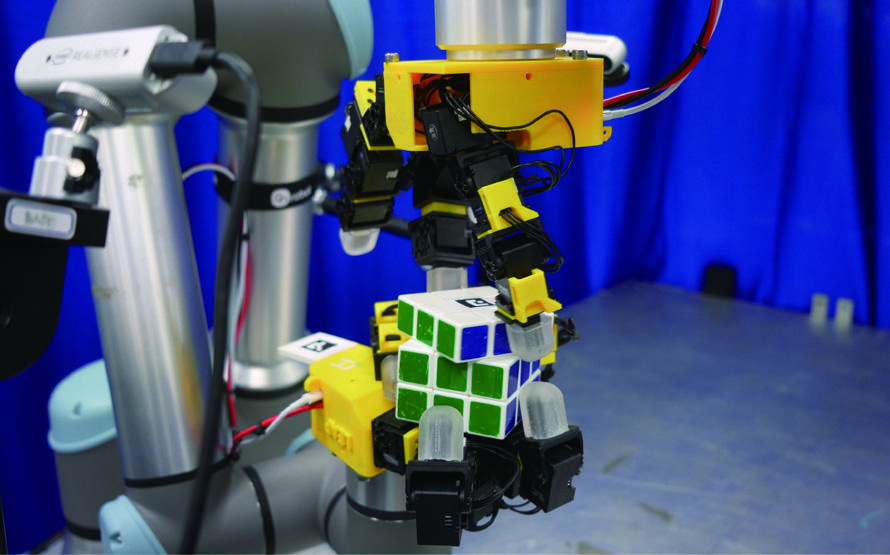
Media-only review: Photograph of two original LEAP v1 hands on UR5e arms in a bimanual cube experiment (2025). The researchers replaced the rigid fingertips with elastomer tips of the same geometry; the paper does not identify Full versus Lite motors. Reuse basis: CC-BY-4.0. The authors’ own physical experiment, explicitly identified in section3.2 as UR5e arms each coupled to a16DoF LEAP-Hand. Photograph shows the original v1 four-finger direct servo-actuated palm/finger architecture, not tendon-driven LEAPv2 or Leap Motion optical tracking. The selected profile explicitly covers LEAPv1 Full and Lite, shared printed construction and optional soft fingertips. Photograph is not proof of Full/Lite motor variant, software commit or hidden motor IDs, which are explicitly left unspecified. The authors disclose replacement elastomer tips of identical geometry; caption preserves that modification and the arm installation context. Page1 grants CC BY4.0 to this original article; no third-party photo credit or exclusion was found for Figure1. This permission comes from the independent experiment authors and does not infer a photo grant from the LEAP developer’s noncommercial hardware/API licenses. Only the real photograph is extracted, not simulation views, diagram panels or externally sourced human demonstration images. Embedded image extracted from page 3 of the source PDF and losslessly decoded to PNG; no retouching. Technical/cost evidence dates unchanged.Revision, date & where cited
Kang-Won Lee, Jung-Woo Lee, Seongyong Kim and Soo-Chul Lim · mdpi.com · Lee et al., Progressive Policy Learning: A Hierarchical Framework for Dexterous Bimanual Manipulation, Mathematics 2025, 13, 3585, DOI 10.3390/math13223585; PDF page3 Figure1 upper-left real-world setup photograph, embedded image4 (Im1.jpg),890x555.; image SHA-256 e3f08865b1ca3066d9010adc370ddf43d834648b70ddf29920d50422a99d94d9 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.