MEVIUS
Robot / hardware buildTwelve-joint quadruped with purchased actuators and fabricated metal parts; its preserved ROS 1 control snapshot warns that the supplied policy is not very stable. [1]
Build & first use →Official websiteBill of materials
- For
- Researchers equipped for metal fabrication, CAN actuator integration and learned locomotion experiments [1]
- Cost
- No current cost yet. Upstream bill of materials [6]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for mechanical design, model weights · Details by part
Overview
MEVIUS is a quadruped whose reference configuration has twelve AK70-10 actuators and three controlled joints per leg. Its sources combine fabricated metal structures, a purchased-component parts list, ROS 1 control code and learned locomotion. The preserved README explicitly warns that its supplied policy is simple and not very stable; its statement that an improved policy will be uploaded is not evidence that this snapshot contains that improvement. [1] [6] [8]
Is this for you?
- Known limitations
- External STEP assembly bytes and geometry not validated
- Complete current delivered build cost not established
- Root MIT license does not establish external hardware or inherited-code rights
- Preserved README warns supplied policy is simple and not very stable; promised improvement not verified
Source-review boundaries; no hardware tests.
3D preview
MEVIUS simulation assembly. The repository simulation model at zero joint positions. Mesh references are mapped to the supplied model files; this is not a manufacturing CAD package.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Kento Kawaharazuka / MEVIUS contributors, revision 35fdb6ca6b9e0f4fb441126ec95b88e1c5586cad. Original and preview: MIT. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Dependencies
- ROS 1 / catkin
- PyTorch, SciPy, MuJoCo and mujoco-python-viewer
- Project-specific haraduka/legged_gym training branch
- realsense-ros ros1-legacy with T265 launch configuration
Hardware & parts
Upstream bill of materials [6]
- Actuators
- Twelve T-Motor AK70-10 actuators
Listed build configuration; substitutions and vendor firmware must be validated separately.
- Controller
Intel NUC12WSKi7 with ESD CAN-USB/2 in the reference parts list
- Sensors
- Intel RealSense T265 tracking camera/IMU in reference BOM
- Degrees of freedom
12
Assembly & first use
- Review mechanical and purchased-component configuration
- Match motor identities, CAN routing and calibration to the physical assembly
- Prepare the documented ROS 1 dependencies
- Review the project-specific training branch and policy export path
- Inspect the MuJoCo --sim route before any hardware commissioning
Editorial source-navigation sequence, not reproduced installation or safe-to-run hardware instructions.
Cost
No current, complete configuration-specific build cost has been established for this profile.
A concrete reference build, with incomplete cost coverage
The parts list names welded A5052 and machined A7075 components, printed calf/foot parts, an Intel NUC12WSKi7, ESD CAN-USB/2 and RealSense T265. The linked folder lists an assembly STEP file, manufacturing STEP files, printing files and a URDF-model folder. These links and document text were inspected, but the raw assembly transfer failed and no geometry or fit checks were performed. [5] [6] [7]
The spreadsheet displays a US$12,390.09143 reference sum and a US$5,304.105714 low-price sum. Printed parts and screws are unpriced. The low-price column also substitutes components and removes the wireless emergency-stop cost, so it is not a like-for-like validated build budget or a recommended configuration. Neither sum is a current delivered quote. [6]
Project notes
The software route is revision-specific
The README builds with catkin, launches roscore and uses realsense-ros's ros1-legacy T265 configuration. Its learning instructions select haraduka/legged_gym's mevius branch and describe two training phases with command and friction-range changes, followed by policy export. A MuJoCo --sim option is documented. The pinned archive contains models/policy.pt, but no installation, training reproduction or physical walking test was performed here. [1] [9]
CAN identities, direction signs and standby angles are explicit in parameters.py. These are configuration evidence, not proof that another assembly is calibrated. The README's warning about the supplied policy should be resolved against a specific updated revision before relying on later performance claims. [1] [8]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer, tools
Updates
- Upstream last updated
- Jun 10, 2025 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- 35fdb6ca6b9e0f4fb441126ec95b88e1c5586cad (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed External STEP assembly and manufacturing folders are listed; explicit external hardware license and complete assembly validation not established. Raw STEP transfer to local workspace returned HTTP 403. [5] [7] |
| electronics | not found · License not fully assessed Purchased electronics BOM is supplied; no complete board-manufacturing source established. [6] |
| firmware | not found · License not fully assessed Vendor actuator configuration is required; open actuator firmware source not established. Motor MIT mode is a protocol mode, not a copyright license. [1] |
| software | available · MIT Root license applies as declared by repository; README attributes inherited helpers to IsaacGym, LeggedGym and a third-party T-Motor driver. Their full provenance and external training dependency terms remain separate. [1] [3] |
| model weights | available · License not fully assessed Pinned archive contains policy.pt; separate weight-specific rights, training provenance and reproduced performance not established. [1] [9] |
| documentation | available · MIT MIT identification is scoped to repository documentation; external Drive documents do not show a separate rights grant in the inspected text. [1] [3] [5] [6] |
Selected workflow trains locomotion in simulation; no separately distributed dataset is selected.
Reuse rights are separate across layers
The repository carries MIT, while its README attributes helpers to IsaacGym, LeggedGym and a separate T-Motor driver. External training dependencies, inherited code and weight provenance require their own checks. The linked hardware README does not state an explicit hardware license in the inspected text, so repository MIT is not extended automatically to the Drive STEP files. Motor MIT mode refers to the actuator protocol rather than copyright terms. [1] [3] [5]
The useful result is a documented research configuration with preserved software and model artifacts, plus linked fabrication sources. Complete manufacturing validation, external hardware rights, stable-policy matching and a current full build budget remain open. [1] [5] [6] [9]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 haraduka/mevius: README.md
Revision, date & where cited
github.com · revision
35fdb6c· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 haraduka/mevius: commit 35fdb6c
- S003 haraduka/mevius: LICENSE
Revision, date & where cited
github.com · revision
35fdb6c· Accessed Sep 30, 2026
Used for: Is this for you?, Source files and licenses - S004 haraduka/mevius: files
Revision, date & where cited
github.com · revision
35fdb6c· archive file inventory · Accessed Sep 30, 2026 - S005 MEVIUS linked hardware readme
Revision, date & where cited
haraduka / project contributors · docs.google.com · Drive readable-text snapshot; modified 2025-03-19T10:39:32.700Z · Accessed Sep 30, 2026
Used for: Is this for you?, Assembly & first use, Cost, Source files and licenses - S006 MEVIUS linked hardware parts
Revision, date & where cited
haraduka / project contributors · docs.google.com · Drive readable-text snapshot; modified 2025-04-29T07:16:34.291Z · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Cost and 1 more - S007 Linked hardware folder inventory
Revision, date & where cited
haraduka / project contributors · drive.google.com · Direct-child metadata; raw STEP preservation failed with HTTP 403; no geometry validation · Accessed Sep 30, 2026
Used for: Is this for you?, Assembly & first use, Cost, Source files and licenses - S008 Pinned robot joint configuration
Revision, date & where cited
github.com · revision
35fdb6c· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S009 Complete pinned repository filenames
Revision, date & where cited
github.com · revision
35fdb6c· Complete archive filename inventory; not a completeness test · Accessed Sep 30, 2026
Used for: The software route is revision-specific, Source files and licenses - S011 Upstream image and reuse attribution
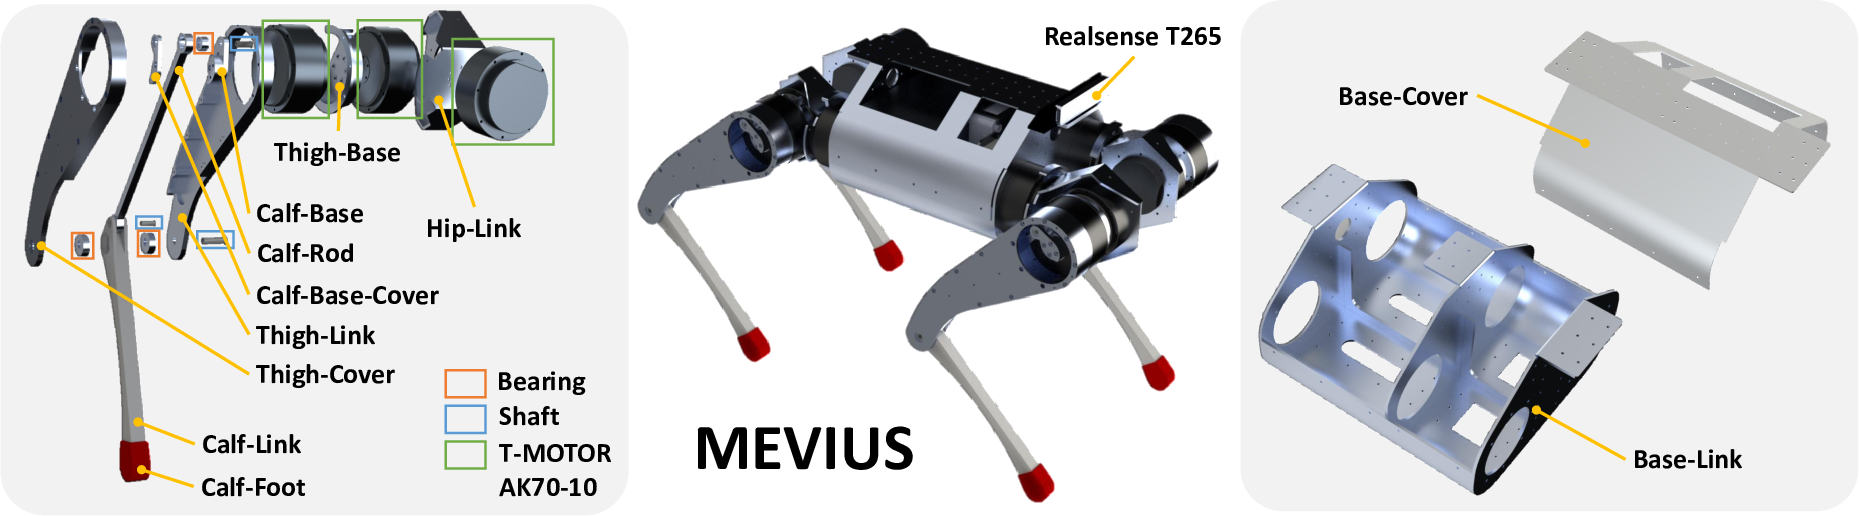
Media-only review: Upstream illustration of the MEVIUS quadruped and its components, not a photograph of a tested build. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Kento Kawaharazuka and MEVIUS contributors · github.com · revision
35fdb6c· Image SHA-256 186b3f0a9587948c8779bf8ed44fcf73c738a5da1cbdfcc60c7b7977829e14db; repository · Accessed Oct 25, 2026
Videos
- S010 MEVIUS: A Quadruped Robot Easily Constructed through E-Commerce (Humanoids 2024) (YouTube video)
Video uploaded by JSK / EVARL / Kento Kawaharazuka, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video JSK / EVARL / Kento Kawaharazuka · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S010): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.