MiniRHex
Robot / hardware buildA six-legged educational robot with printable chassis and legs, Dynamixel motors and Arduino control. [1] [2] [3]
Build & first use →Official websiteUpstream build guideBill of materials
- Cost
- USD 286.51 upstream parts estimate [2] · checked Sep 30, 2026 · DetailsNot included: host computer and printer, tools and labor and destination shipping and taxes not established.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- BSD-3-Clause · license not fully assessed for mechanical design, documentation · Details by part
Overview
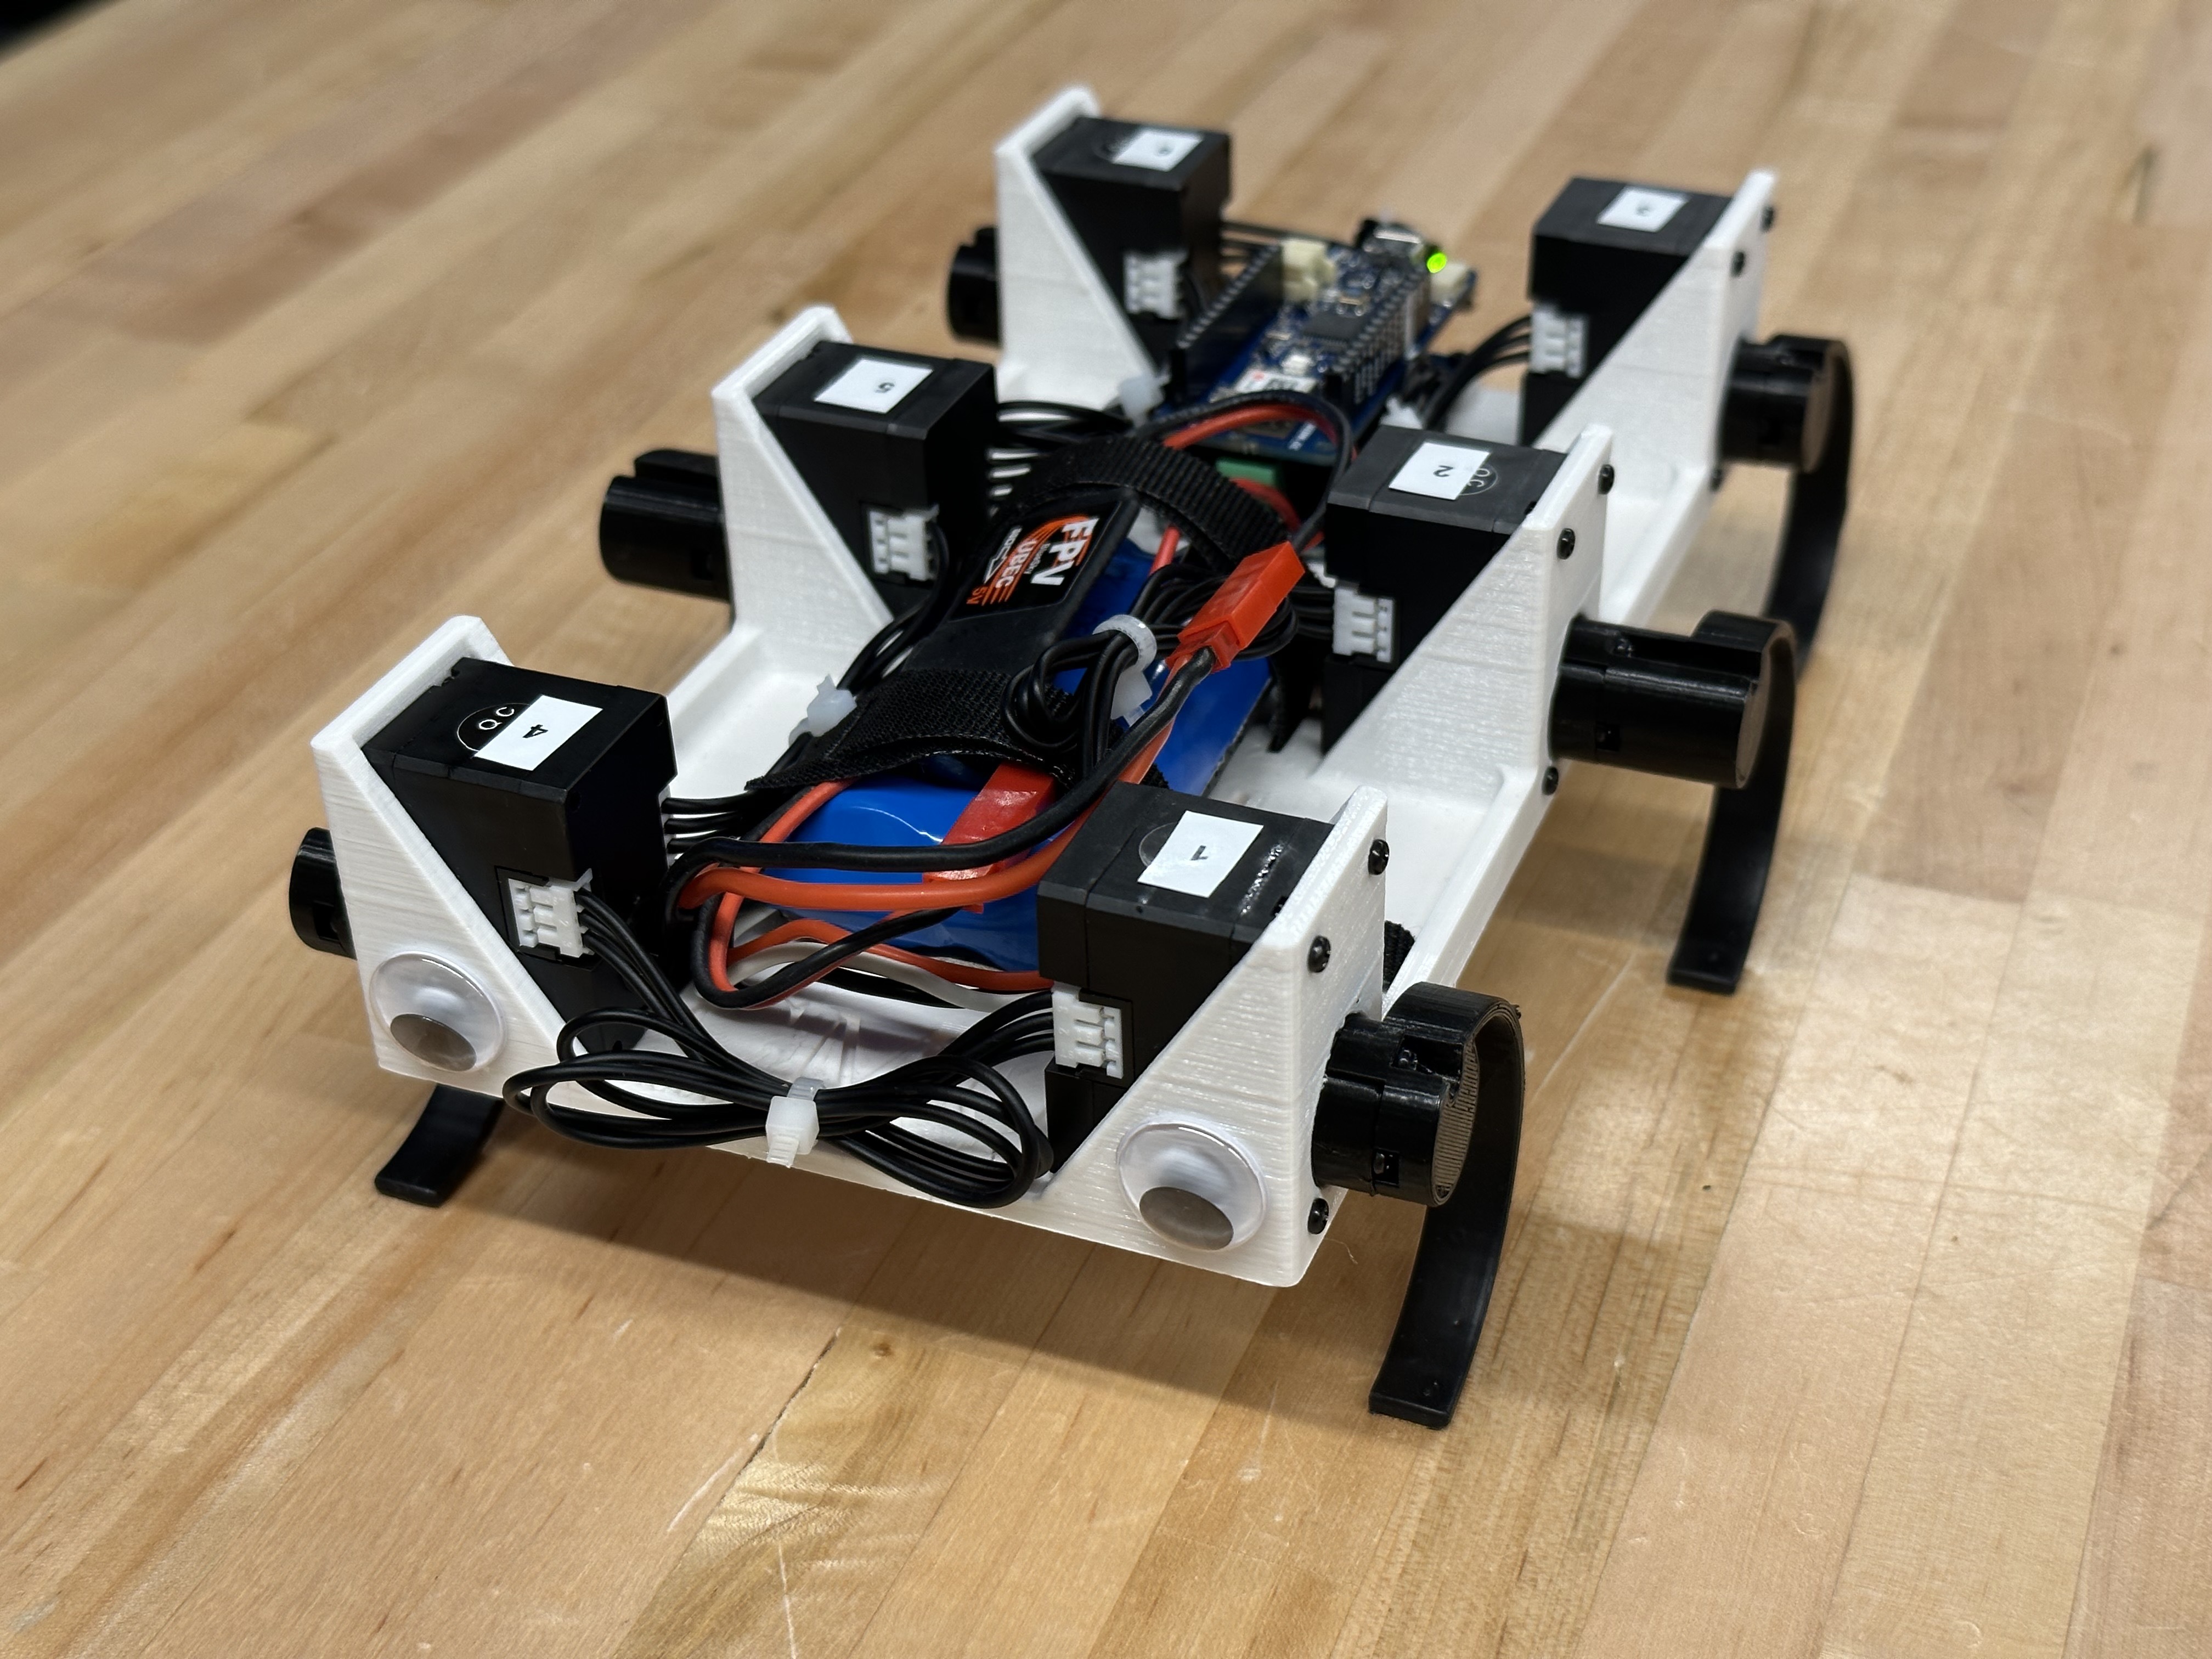
MiniRHex is a small six-legged robot from the Robomechanics Lab for learning about gait and leg design. The documented build combines a printed chassis and legs with six Dynamixel XL330-M077-T motors and an Arduino MKR WiFi 1010. A computer uploads the firmware; the documented serial and local Wi-Fi interfaces provide movement controls. [1] [2]
Is this for you?
- Known limitations
- No physical build or walking test by this publication.
- Historical BOM is not a current delivered quote.
- CAD manufacturing-rights scope needs separate confirmation.
Editorial assessment based on documented educational purpose, parts and assembly workflow; no physical validation.
What you need
Hardware & parts
Upstream bill of materials [1] [2] [3]
Assembly & first use
Open the upstream getting-started guide [1] [2] [3]
- Source the parts list and choose standard or quick-connect legs.
- Print and assemble using the illustrated guide; configure motor IDs.
- Install Arduino SAMD board support and required libraries, compile and upload the matching sketch.
- Use serial or the documented local Wi-Fi interface for the first movement test.
Build files and instructions
This guide selects standard legs. Quick-connect legs are an alternative with additional hubs; mixing the two print lists would give the wrong parts set. The standard configuration has five STL types and seven printed pieces: one body, two front/rear left legs, two front/rear right legs and one middle leg for each side. [2] [3] [91]
- Download the pinned source archive, including CAD, assembly images and firmware.
- Open the purchased-parts BOM, STL directory and print manifest with quantities and individual download links. A spreadsheet-ready CSV is also available.
- Follow the illustrated assembly and motor-ID instructions. The source specifies PLA, 15–20% body infill and 100% leg infill with build-plate supports. It also calls for traction coating on the legs. [3]
- Read the software installation and operating instructions, then open MiniRHex.ino and its adjacent source files. Set the board to Arduino MKR WiFi 1010 and configure the six motor IDs before the movement test. [1] [3]
Cost
| Version | Price |
|---|---|
| Standard MiniRHex historical upstream parts estimate (December 2024) | USD 286.51 [2] Parts estimate |
US-linked upstream suppliers; destination unspecified · Checked 2026-09-30
| Included | Six motors; Arduino and shield; Listed power and assembly supplies; Approximate PLA allowance |
|---|---|
| Not included | Host computer and printer; Tools and labor; Destination shipping and taxes not established |
| Stock | Stock, package quantities and current supplier prices not re-quoted. |
| Delivery and tax | Not established for a destination. |
Price details
Upstream labels this as one robot as of 2024-12-28; several supplies are sold in multi-robot quantities. Do not interpret as a fresh single-unit checkout.
US-linked upstream suppliers; destination unspecified · Checked 2026-09-30 · Quantity 1
Printer, host, tools and destination procurement reconciliation.
Budget and remaining checks
The upstream BOM lists USD 286.51 as of December 28, 2024. It includes an approximate PLA allowance, but some supplies are sold in quantities covering multiple robots. Treat it as a historical planning figure, not a current single-robot checkout: destination shipping, taxes, host computer, printer, tools and labor still need accounting. [2]
Follow the assembly guide's power arrangement: the battery connects through the specified 5 V regulator, not directly to the Arduino shield. Verify the selected parts, wiring and motor positions before upload. [3]
The repository makes CAD, firmware and documentation available. Its root license contains BSD-style software terms; this profile does not establish manufacturing rights for every CAD artifact or source availability for purchased electronics. Those questions are separate from the successful firmware compile. [4] [2]
3D preview
Preview not available yet. Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Model sources
Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Project notes
Firmware compiles; walking remains untested
The unmodified firmware at this revision compiled for arduino:samd:mkrwifi1010 with SAMD core 1.8.14. The public check receipt records the exact library versions, 80,044 bytes of flash and 7,880 bytes of RAM. No firmware upload, physical assembly or walking test was performed. This result establishes a working compiler configuration, not the robot's mechanical fit or performance. [90]
What we checked
Source-researched profile with a limited firmware compile check. No physical build, upload, calibration or walking test performed.
Not yet established
- Requirements: operating system
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
7904cd2
Source files and licenses
CAD, printable geometry, assembly and Arduino firmware are available. Purchased electronics and artifact-specific manufacturing rights remain separate checks.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Root license uses software language; do not infer hardware manufacturing clearance. [1] [3] [4] |
| electronics | not found · License not fully assessed The reviewed MiniRHex repository and parts list specify purchased Arduino, shield and servos; complete electronic design sources for that component set were not established in this scope. [2] |
| firmware | available · BSD-3-Clause Original notices retained; purchased component firmware is outside this source scope. [1] [3] [4] |
| software | available · BSD-3-Clause Original notices retained; purchased component firmware is outside this source scope. [1] [3] [4] |
| documentation | available · License not fully assessed Original notices retained; purchased component firmware is outside this source scope. [1] [3] [4] |
Not required for the documented Arduino walking-control route.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 MiniRHex overview and software setup
Educational six-legged Arduino-controlled robot with documented software setup and movement controls.Revision, date & where cited
Robomechanics Lab · github.com · revision
7904cd2· Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 Purchased and printed parts list
Standard-leg parts and print quantities; historical USD 286.51 estimate dated December 28, 2024.Revision, date & where cited
Robomechanics Lab · github.com · revision
7904cd2· Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S003 Assembly and motor configuration
Printed-parts preparation, traction coating, mechanical and power assembly, servo alignment and IDs.Revision, date & where cited
Robomechanics Lab · github.com · revision
7904cd2· Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S004 robomechanics/MiniRHex: license.txt
Root BSD-style software license; artifact-specific mechanical manufacturing scope remains a separate check.Revision, date & where cited
Robomechanics Lab · github.com · revision
7904cd2· Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: Cost, Source files and licenses - S093 Upstream image and reuse attribution
Media-only review: Upstream photograph of a MiniRHex six-legged robot build. Reuse basis: BSD-3-Clause; inspected license.txt and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Robomechanics Lab and MiniRHex contributors · github.com · revision
7904cd2· Image SHA-256 72ff824bf8e84dc5027d276b01df963cc8f4288e9850dfc9e2528f9168fa30f3; repository · Accessed Oct 25, 2026
Our checks and receipts
- S090 Build-file and software-check receipt
Revision, date & where cited
Open Source Robotics · opensourcerobotics.dev · Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: Firmware compiles; walking remains untested - S091 Configuration-specific print-file manifest
Revision, date & where cited
Open Source Robotics · opensourcerobotics.dev · Pinned source / audit snapshot, September 30, 2026 · Accessed Sep 30, 2026
Used for: Build files and instructions
Videos
- S092 Introducing MiniRHex (YouTube video)
Video from the project’s own channel (Robomechanics Lab), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Robomechanics Lab · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Added configuration-specific build resources, print-file manifests and scoped software-check evidence; physical testing remains unperformed.
2026-10-04 — Added 1 YouTube reference(s) (S092): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.