MuSHR
Robot / hardware buildRC-based research racecar; the reviewed Nano route uses V3 printed parts and separately versioned ROS control packages, with older firmware/image assumptions requiring validation. [1]
Build & first use →Official websiteBill of materials
- For
- Research and teaching labs comfortable with RC assembly and Linux/ROS configuration [1]
- Cost
- No current cost yet. Upstream bill of materials [7]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- BSD-3-Clause · license not fully assessed for electronics · Details by part
Overview
MuSHR is an RC-based research racecar platform with several hardware and software components. This entry follows the Nano build guide: a Redcat Blackout chassis, Jetson Nano, VESC and printed upper frame. The guide replaces the stock drive motor and steering servo; it also offers a Pro chassis with a brushless motor already fitted. Those alternatives affect the assembly work and parts list. [5] [7]
Is this for you?
3D preview
MuSHR Nano simulation assembly. The upstream Nano simulation chassis, four wheels, lidar and simplified camera at their source reference poses. Wheel collision proxies and the floor are excluded. Source body grouping is retained; the chassis mesh combines several components. This is a simplified simulation model, not manufacturing CAD or a verified physical build.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original MJCF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: MuSHR / University of Washington Personal Robotics Lab contributors, revision c86eef33dadb0e98fe916a55ac6aa1fc03af027e. Original and preview: BSD-3-Clause. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. Source visual shapes and body transforms evaluated at the reference pose by MuJoCo, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Host computer
Jetson Nano plus host computer or monitor/keyboard/mouse for setup.
Hardware & parts
Upstream bill of materials [7]
- Hardware configuration
Selected Nano configuration: Redcat Blackout RC-based car with V3 printed upper frame.
- Actuators
- Replacement brushless drive motor and steering servo; Pro chassis offers preinstalled brushless motor alternative
- Sensors
- YDLIDAR option
- RealSense camera alternatives; match the chosen sensor configuration and mounts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Use the Nano-specific printed parts
The separately preserved CAD repository identifies V3 as the Nano design and V2 as the TX2 design. Its README directs Nano builders to print the files in v3/stl once each, except racecar_cover_image, which is printed twice. OpenSCAD source is provided for modifying the parts. The archive was preserved, but no print, geometric fit or chassis assembly was tested here. [8] [10]
The parts document lists purchased electronics, fasteners, power components and sensor alternatives. It lists RealSense alternatives and notes that fitting missing motor bullet connectors may require soldering. The build guide also describes a D435i/T265 dual-camera arrangement. As an editorial next step, select the camera configuration and reconcile its mounts and wiring with the chosen guide before ordering. [5] Consequently, the project overview’s general no-soldering description depends on the parts actually purchased. Historical item prices are not a current complete delivered budget. [1] [7]
Preserve the software environment separately
The main repository is an index and integration layer. Its dependency manifest points to moving branches for the base controller, VESC and camera packages. This review separately preserved the base-control repository and CAD, but that does not establish a fully pinned, installed system across every dependency. [1] [11] [13] [14]
The build guide offers a preconfigured Nano image and a stock-image installation route for image problems or smaller storage. It also instructs builders to select the older bldc-tool/firmwares/hw_410_411_412/VESC_servoout.bin binary for that hardware family. Record and verify the selected board, firmware and image combination; these instructions do not establish compatibility with arbitrary newer Jetson or VESC hardware. Neither image installation nor firmware flashing was performed here. [5]
Distinguish command priority from an implemented safety controller
The base configuration gives the safety input higher priority than teleoperation, followed by navigation and a default input. However, the base README describes the safety controller input as currently null. A named high-priority channel does not demonstrate that an active safety controller is installed or publishing commands. [11] [15]
Upstream begins software setup with the car supported so its wheels are clear of the ground, then configures the VESC and controller before teleoperation. Confirm the actual motor/servo behavior and joystick mapping before moving on to navigation experiments. This review does not claim a tested stop behavior, navigation result or calibrated vehicle. [5] [11]
The main and CAD repositories carry BSD-3-Clause license text. The separate base repository also contains that license text, with its own copyright line and bundled component notices. These do not establish blanket rights to website content, all external drivers or purchased RC components. Source availability and a successfully reproduced build remain separate findings. [3] [9] [12]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Feb 10, 2022 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- 2030b907822ac333d00cc9674625198dde1886ed (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · BSD-3-Clause V3 printed additions and design files; not complete manufacturer source for purchased chassis. [8] [9] [10] |
| electronics | available · License not fully assessed Integration and wiring instructions; website reuse license and complete purchased-board source not established. [5] |
| firmware | not found · License not fully assessed Guide selects a historical VESC servo-output binary; complete matching firmware source for the selected controller not preserved here. [5] [14] |
| software | available · BSD-3-Clause Main repository scope; website, separate packages and purchased components require separate terms. [3] [4] |
| documentation | available · BSD-3-Clause Main repository scope; website, separate packages and purchased components require separate terms. [3] [4] |
No learned model or dataset selected for this physical platform and teleoperation profile.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 prl-mushr/mushr: README.md
Revision, date & where cited
github.com · revision
2030b90· Accessed Oct 1, 2026
Used for: Assembly & first use, Use the Nano-specific printed parts, Preserve the software environment separately - S002 prl-mushr/mushr: commit 2030b90
- S003 prl-mushr/mushr: LICENSE.md
Revision, date & where cited
github.com · revision
2030b90· Accessed Oct 1, 2026
Used for: Distinguish command priority from an implemented safety controller, Source files and licenses - S004 prl-mushr/mushr: files
Revision, date & where cited
github.com · revision
2030b90· archive file inventory · Accessed Oct 1, 2026
Used for: Source files and licenses - S005 MuSHR website: build
Revision, date & where cited
prl-mushr / project contributors · mushr.io · Retrieved website text; separate from pinned main repository · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 5 more - S006 MuSHR website: overview
Revision, date & where cited
prl-mushr / project contributors · mushr.io · Retrieved website text; separate from pinned main repository · Accessed Oct 1, 2026
- S007 Nano bill of materials
Revision, date & where cited
github.com · revision
2030b90· DOCX table extraction · Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Use the Nano-specific printed parts - S008 Separate MuSHR cad: README.md
Revision, date & where cited
github.com · revision
d1289d3· Accessed Oct 1, 2026
Used for: Hardware & parts, Assembly & first use, Use the Nano-specific printed parts, Source files and licenses - S009 Separate MuSHR cad: LICENSE.md
Revision, date & where cited
github.com · revision
d1289d3· Accessed Oct 1, 2026
Used for: Distinguish command priority from an implemented safety controller, Source files and licenses - S010 Preserved cad inventory
Revision, date & where cited
github.com · revision
d1289d3· Separate snapshot; no complete matched build assertion · Accessed Oct 1, 2026
Used for: Use the Nano-specific printed parts, Source files and licenses - S011 Separate MuSHR base: README.md
Revision, date & where cited
github.com · revision
d20b3d0· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Preserve the software environment separately, Distinguish command priority from an implemented safety controller - S012 Separate MuSHR base: LICENSE.md
Revision, date & where cited
github.com · revision
d20b3d0· Accessed Oct 1, 2026
Used for: Distinguish command priority from an implemented safety controller - S013 Preserved base inventory
Revision, date & where cited
github.com · revision
d20b3d0· Separate snapshot; no complete matched build assertion · Accessed Oct 1, 2026
Used for: Preserve the software environment separately - S014 Main repository dependency manifest
Revision, date & where cited
github.com · revision
2030b90· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Preserve the software environment separately, Source files and licenses - S015 Command priority configuration
Revision, date & where cited
github.com · revision
d20b3d0· Accessed Oct 1, 2026
Used for: Is this for you?, Distinguish command priority from an implemented safety controller - S016 Upstream image and reuse attribution
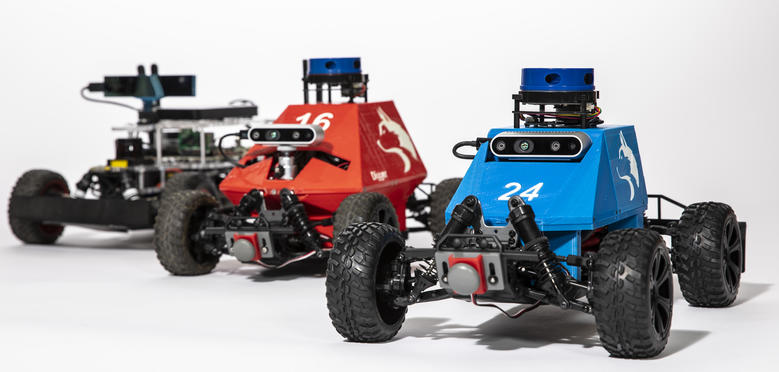
Media-only review: Upstream photograph of several MuSHR car configurations; these are separate builds. Reuse basis: BSD-3-Clause; inspected LICENSE.md and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Mark Stone / University of Washington; MuSHR contributors · github.com · revision
2030b90· Image SHA-256 2c2711ba9bc02a2723c3cce7c8a14920731f8d14ccb2f95611980094d60a6b7d; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.