NimbRo-OP2 / OP2X
Robot / hardware buildTwo humanoid soccer research designs with separate CAD, actuator selections and fabrication requirements. [1]
Build & first use →Official websiteBill of materials
- For
- Humanoid research laboratories; Teams with mechanical fabrication and ROS integration experience [1]
- Cost
- No current cost yet. Upstream bill of materials [1] [5] [6] [9]
- Source rights
- Some licenses are unresolved. Includes noncommercial terms. Review licenses
- Unknowns
- operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CC-BY-NC-SA-3.0 (noncommercial), BSD-3-Clause · license not fully assessed for documentation · Details by part
Overview
OP2 and OP2X share a hardware repository, but each has its own CAD directory and bill of materials. Their actuator rows specify 34 MX106 units for OP2 and 34 XM540-W270 units for OP2X. These are actuator counts, not a claim that either robot has 34 independent joint axes. Match the controller, cabling and mechanical files to the chosen variant. [1] [5] [6]
Is this for you?
3D preview
NimbRo-OP2X robot description (humanoid_op_ros). NimbRo-OP2X only. The NimbRo-OP2 variant of this profile is not shown, because no robot description named for OP2 was found at the pinned revisions. The AIS Bonn humanoid_op_ros repository at commit e8be8c4 (the NimbRo-OP2X functionality release) supplies nimbro_op2x.xacro, expanded without changes, and its STL link meshes, shown at zero joint positions: 27 visual meshes on the source joint tree, with each leg drawn by the source parallel-linkage visual links. Each link mesh is one fused STL that includes modeled housings of the purchased servo actuators; those vendor shapes cannot be separated, and their third-party CAD terms are unknown. The hardware design is licensed CC BY-NC-SA 3.0 (noncommercial, share-alike) and the description repository carries a BSD-3-Clause LICENSE; no commercial-use or manufacturing clearance is claimed. This is a ROS robot description, not the printable part set. Fit and motion are not verified.
Noncommercial license: the NimbRo-OP2 and NimbRo-OP2X hardware repository states that “The CAD drawings in this repository are released under the Attribution-NonCommercial-ShareAlike 3.0 (CC BY-NC-SA 3.0) license”. The previewed robot description and its link meshes come from the separate humanoid_op_ros repository, whose LICENSE is BSD-3-Clause (Copyright (c) 2016, Autonomous Intelligent Systems Group, University of Bonn) and whose model package license field is an unfilled placeholder; Open Source Robotics applies the stricter hardware license. This preview and the hosted files remain under CC BY-NC-SA 3.0 with attribution to the Autonomous Intelligent Systems Group, University of Bonn; no commercial-use or manufacturing clearance is claimed. The link meshes include modeled housings of purchased servo actuators, whose third-party terms are unknown. License: CC BY-NC-SA 3.0 (NimbRo-OP2/OP2X hardware license) · upstream notice.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP, LZMA compression) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Autonomous Intelligent Systems Group, University of Bonn (NimbRo), revision e8be8c445ead8c0d470c7998fdc28446ca9eb47a. Original and preview: CC-BY-NC-SA-3.0 (NimbRo-OP2/OP2X hardware); humanoid_op_ros repository LICENSE BSD-3-Clause. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Fabrication choices change the order
OP2 offers machined brass gears or printed alternatives, while printed gears are the default for OP2X. The BOMs point to a durable SLS printing service for gears. OP2 also lists milled and printed neck-part alternatives; buying both would double-count a choice. Both lists call for bearing modifications, including drilling the slewing-ring mounting holes, so the work extends beyond ordering prints and tightening screws. [1] [5] [6]
OP2X's list needs further reconciliation before purchasing. Several fastener quantities are blank, and the section says values and types remain to be verified. It recommends spare master/slave synchronization cables because they tend to break. These are useful maintenance inputs, but neither a completed procurement list nor a measured failure rate. [6]
The computer configurations also differ. OP2 lists an Intel NUC reference without RAM or SSD. OP2X lists a mini-ITX reference with an i7-8700T, emphasizes the low-current T model and treats the low-profile GTX 1050 Ti as optional for deep learning. Those historical choices need current availability, fit and power checks before substitution. No delivered total has been established. [5] [6]
Software is a separate preservation and integration task
The university download page links a separate ROS framework, which we preserved at an immutable commit alongside the hardware archive. Its published installation requirements specify Ubuntu 14.04 and ROS Indigo. That documents a legacy starting point; this review has not established a working modern replacement or reproduced the selected robot's configuration. [8] [9] [10]
The hardware CAD uses CC BY-NC-SA 3.0, while the framework has BSD-3-Clause software terms. A commercial build or parts offer therefore cannot rely on the software license alone. Assembly, calibration, replacement parts and support effort remain to be tested for one exact configuration. [7] [8]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system
- A step-by-step setup summary
Updates
- Upstream last updated
- Sep 26, 2018 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- a38bab234578511220a4d4940209a92644f70636 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-NC-SA-3.0 CAD terms are noncommercial; software permission does not override hardware terms. [1] [7] |
| electronics | not found · License not fully assessed BOM identifies purchased controllers and actuators; their complete manufacturing and firmware sources were not reconciled. [4] [5] [6] |
| firmware | not found · License not fully assessed BOM identifies purchased controllers and actuators; their complete manufacturing and firmware sources were not reconciled. [4] [5] [6] |
| software | available · BSD-3-Clause Separate framework archive preserved; exact robot configuration and complete dependencies not reproduced. [8] [9] [10] |
| documentation | available · License not fully assessed BOMs and legacy framework documentation inspected; complete revision-matched build procedure unresolved. [1] [5] [6] [9] |
No particular learned policy or training dataset selected for this hardware review.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 NimbRo/nimbro-op2: README.md
Revision, date & where cited
github.com · revision
a38bab2· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 NimbRo/nimbro-op2: commit a38bab2
- S004 NimbRo/nimbro-op2: files
Revision, date & where cited
github.com · revision
a38bab2· archive file inventory · Accessed Sep 30, 2026
Used for: Source files and licenses - S005 NimbRo-OP2/NimbRo-OP2_Bill_of_Materials.xls
Revision, date & where cited
github.com · revision
a38bab2· Sheet1, all populated rows; extracted read-only from preserved XLS · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S006 NimbRo-OP2X/NimbRo-OP2X_Bill_of_Materials.xls
Revision, date & where cited
github.com · revision
a38bab2· Sheet1, all populated rows; extracted read-only from preserved XLS · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S007 Hardware license
Revision, date & where cited
github.com · revision
a38bab2· Accessed Sep 30, 2026
Used for: Software is a separate preservation and integration task, Source files and licenses - S008 Separate ROS framework snapshot and license
Revision, date & where cited
NimbRo / project contributors · github.com · revision
e8be8c4· README and LICENSE at · Accessed Sep 30, 2026
Used for: Software is a separate preservation and integration task, Source files and licenses - S009 Framework release requirements
Revision, date & where cited
NimbRo / project contributors · nimbro.net · Installation and Dependencies · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S010 University project download links
Revision, date & where cited
NimbRo / project contributors · nimbro.net · Software and Download · Accessed Sep 30, 2026
Used for: Software is a separate preservation and integration task, Source files and licenses - S013 Upstream image and reuse attribution
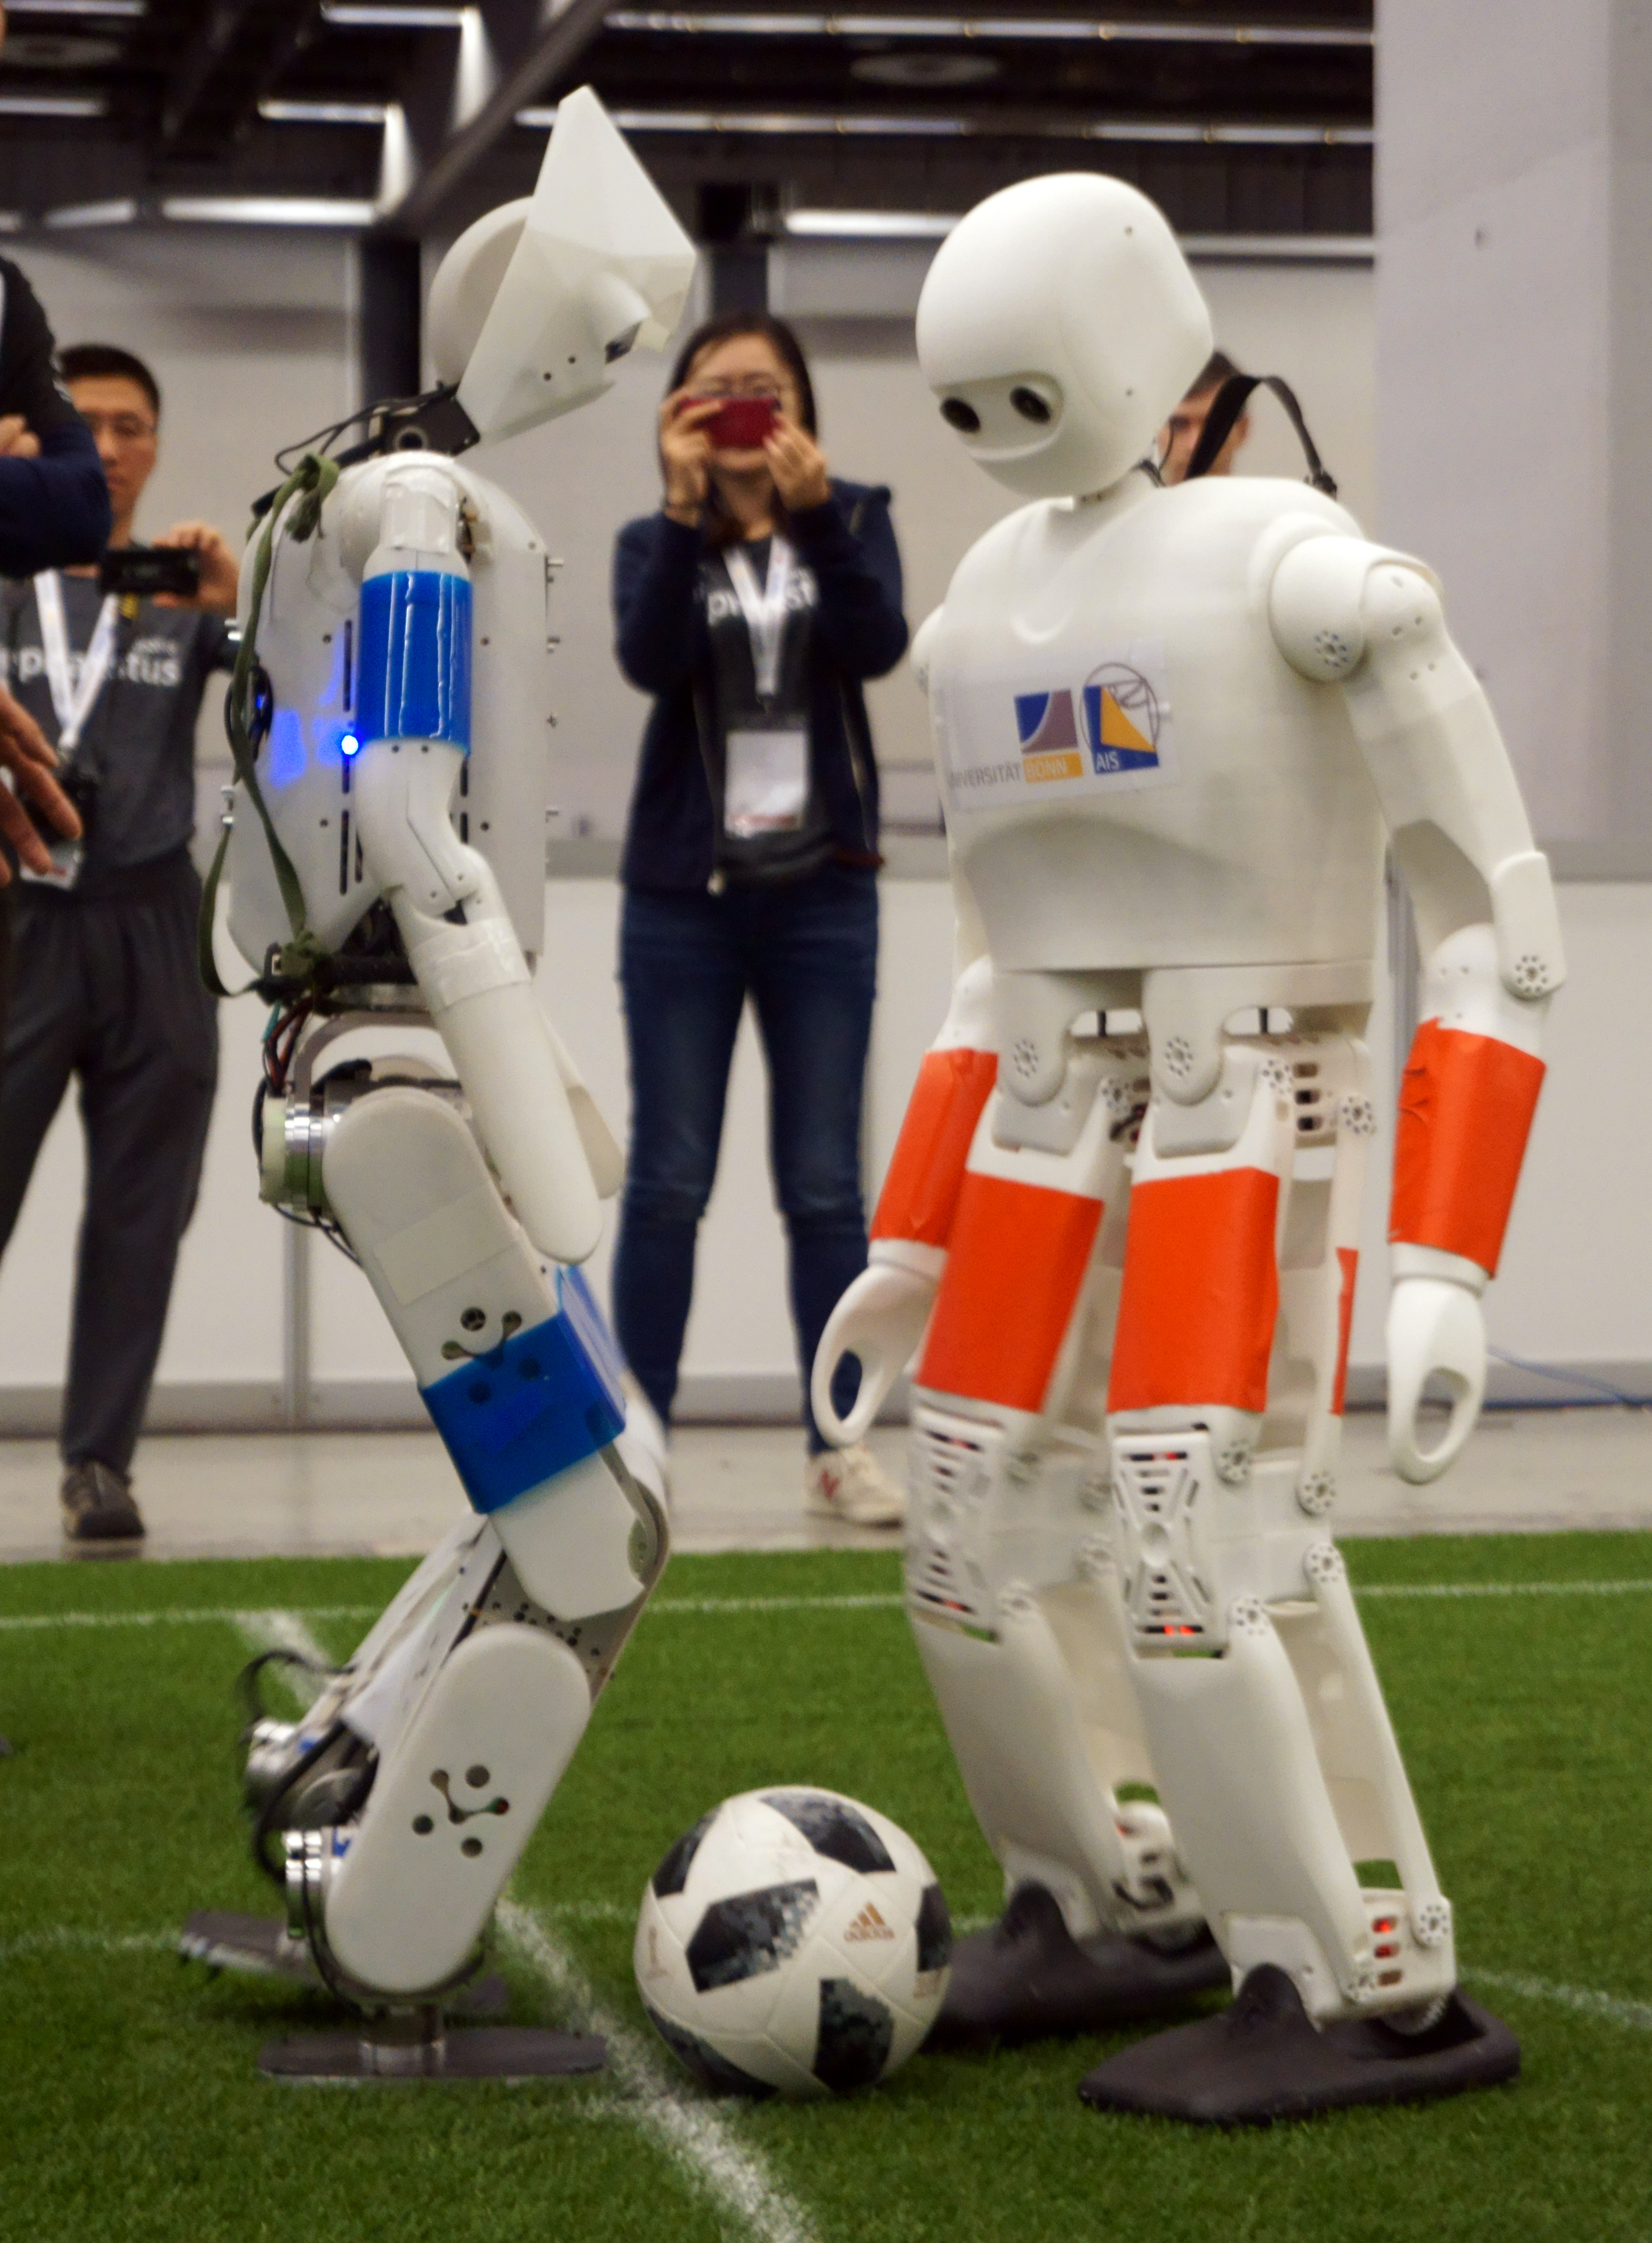
Media-only review: Photograph of NimbRo-OP2X facing a Tsinghua robot at RoboCup 2018 in Montreal; this shows OP2X, not the earlier OP2. Reuse basis: CC-BY-SA-4.0. Inspected the original photo and file-specific own-work creator/license declaration. The pictured version and other robot in the frame are disclosed. This image permission does not change hardware reuse restrictions. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
Sven Behnke · commons.wikimedia.org · File-specific creator, own-work declaration, licensing and file history; image SHA-256 35de0bc9c44de5eba86fde23172320a2dd8cdbe3fc7b6914a7c6db6ab8f12bd3 · Accessed Oct 26, 2026
Videos
- S011 NimbRo-OP2X: Adult-sized Open-source 3D Printed Humanoid Robot (YouTube video)
Video from the project’s own channel (nimbro), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video nimbro · youtube.com · Accessed Oct 4, 2026
- S012 nimbro (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel nimbro · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 2 YouTube reference(s) (S011, S012): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.