Niryo One
Robot / hardware buildPrintable Niryo One arm designs with a separate ROS stack and a documented older-hardware archive. [1]
Build & first use →Official website
- For
- Owners maintaining an existing Niryo One; Builders comfortable reconciling legacy hardware and software [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Includes noncommercial terms. Review licenses
- Unknowns
- host computer, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- CC-BY-NC-SA-4.0 (noncommercial) · Details by part
Overview
The Niryo One repository provides printable parts, but it makes a specific revision distinction: robots received before September 2018 use the older v1.1.0 archive. Identify the unit before selecting files for a replacement part or a rebuild. The README calls for a printer with at least a 200 × 200 × 200 mm build volume. [1]
Is this for you?
- Known limitations
- Units received before September 2018 require the older design archive
- Hardware design license includes a noncommercial condition
3D preview
Niryo One v2 ROS visualization model. The first-party Niryo One v2 ROS visualization model at zero joint positions, using its supplied link hierarchy and mesh placement. These GPL-licensed simulation assets are separate from the noncommercial mechanical-design repository and do not grant manufacturing rights or verify physical fit.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Niryo Robotics, revision e8a218cbafd03111298c7752f9b272e3b0b623bd. Original and preview: GPL-3.0-or-later. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Printed articulated arm
Editorial form classification from the inspected upstream overview.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
The ROS stack is a separate source
This archive contains STL, BOM, Electronics and Integration directories. The README links a separate niryo_one_ros repository for the ROS stack. Preserving the mechanical archive therefore does not freeze a working software configuration or establish that current ROS packages fit an older arm. [1] [4]
Public files have noncommercial terms
The repository license is CC BY-NC-SA 4.0. Its NonCommercial condition matters for a proposed manufactured-parts or kit offer; the fact that the files can be downloaded is not commercial clearance. No separate permission has been established in this review. [3]
Current sourcing, delivered costs and revision-specific calibration remain unresolved. We have not printed a replacement part, assembled the arm or run the separate ROS stack.
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer
- A step-by-step setup summary
Updates
- Upstream last updated
- Oct 8, 2020 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- b4b0a02245f56afd5d59a28cc4d2446bd397d074 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-NC-SA-4.0 Root design license includes NonCommercial; do not assume authorization for a commercial parts offer. [1] [4] [3] |
| electronics | available · CC-BY-NC-SA-4.0 Files present in the source tree; completeness and purchased-component terms still need review. [1] [4] [3] |
| firmware | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| software | not found · License not fully assessed No complete artifact for this layer established in the inspected primary repository overview and archive inventory. External component/dependency sources require separate collection; this is not a claim of closed source. [1] [4] |
| documentation | available · CC-BY-NC-SA-4.0 Repository documentation scope. [1] [4] [3] |
This profile covers the described physical configuration and control route without a particular learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 NiryoRobotics/niryo_one: README.md
Revision, date & where cited
github.com · revision
b4b0a02· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S002 NiryoRobotics/niryo_one: commit b4b0a02
- S003 NiryoRobotics/niryo_one: LICENSE.md
Revision, date & where cited
github.com · revision
b4b0a02· Accessed Sep 30, 2026
Used for: Public files have noncommercial terms, Source files and licenses - S004 NiryoRobotics/niryo_one: files
Revision, date & where cited
github.com · revision
b4b0a02· archive file inventory · Accessed Sep 30, 2026
Used for: The ROS stack is a separate source, Source files and licenses - S006 Upstream image and reuse attribution
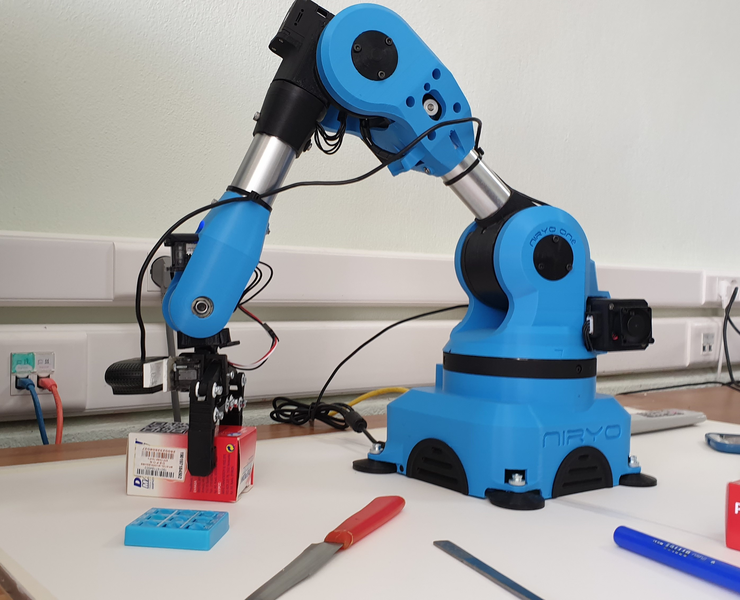
Media-only review: Paper photograph of a Niryo One grasping an object in the authors’ 2021 experiment, with an added USB camera at the gripper. Reuse basis: CC-BY-4.0. The paper identifies the physical arm as Niryo-One in section 4.1 and describes its added USB camera. Figure 7 is the authors’ experimental photograph, not Figure 4’s separately credited manufacturer product image. Visible Niryo One markings, blue shell and metal links match the selected original model, not Ned/Ned2. Actual paper CC BY 4.0 declaration covers this original figure without a separate restriction. No performance or current version claim adopted. Embedded image extracted from page 11 of the source PDF and losslessly decoded to PNG; no retouching. Technical/cost evidence dates unchanged.Revision, date & where cited
George Nantzios, Nikolaos Baras and Minas Dasygenis · doi.org · Design and Implementation of a Robotic Arm Assistant with Voice Interaction Using Machine Vision, page 11 (printed 248), Figure 7; image SHA-256 f8ac6c944c588f7b8f4638a860d936a2f2371de3d3dac406237fdcac4a289466 · Accessed Oct 26, 2026
Videos
- S005 Niryo (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Niryo · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S005): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.