Open Duck Mini
Robot / hardware buildA small printed biped with bus servos, a Raspberry Pi runtime and learned walking policies; the reviewed v2 build still has documentation and configuration gaps. [1]
Build & first use →Official website
- For
- Experienced makers; Robotics learners with printing, soldering and Linux skills [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- Apache-2.0 · Details by part
Overview
Open Duck Mini v2 offers a relatively small printed biped, but its files span the physical design, onboard runtime and a changing training workflow. Start with the standard v2 print list and the 7.4 V servo configuration. STEP files under community modification folders describe alternate heads and other changes; they are not an exported, complete CAD assembly for the standard robot. The primary CAD link remains an external Onshape workspace. [1] [5] [8] [10]
3D preview
TPU foot pad. This preview shows one component, not the complete robot.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STL · File checksums and provenance
This model contains one geometric body.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Open Duck Mini contributors, revision b23317a485b3cec7d8417f352478778b3475173c. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STL does not declare units; confirm dimensions against the project design. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
The spreadsheet is more useful than the headline price
The README's under-$400 ambition is not a delivered build quote. The captured spreadsheet is denominated in euros: its main total is €398.10, rising to €432.34 with the listed expression package. Its lower €331.10 estimate assumes, among other things, existing PLA and a cheap IMU alternative that the author says still needs testing. Do not use that lower column as a verified equivalent build. [1] [8]
The sheet includes cells, a holder, BMS, regulator and charger, but it does not establish a complete delivered price including tools, shipping, tax and all fasteners. Several expression parts require buying packs larger than the quantity used; camera and microphone integration are marked unfinished in the captured sheet. The exact expression configuration therefore needs reconciliation before ordering. [6] [8]
Project notes
Print the standard parts before selecting modifications
The print guide calls for standard PLA at 15% infill, except the two foot-bottom pads, which use TPU at 40%. It lists quantities for each named part. Keep that list alongside the preserved STL files: the repository also contains optional modifications and simulation meshes, so printing every mesh would not produce one coherent robot. We have preserved the repository at an immutable commit, including its print files and policy files; we have not exported the external standard Onshape assembly. [5] [10]
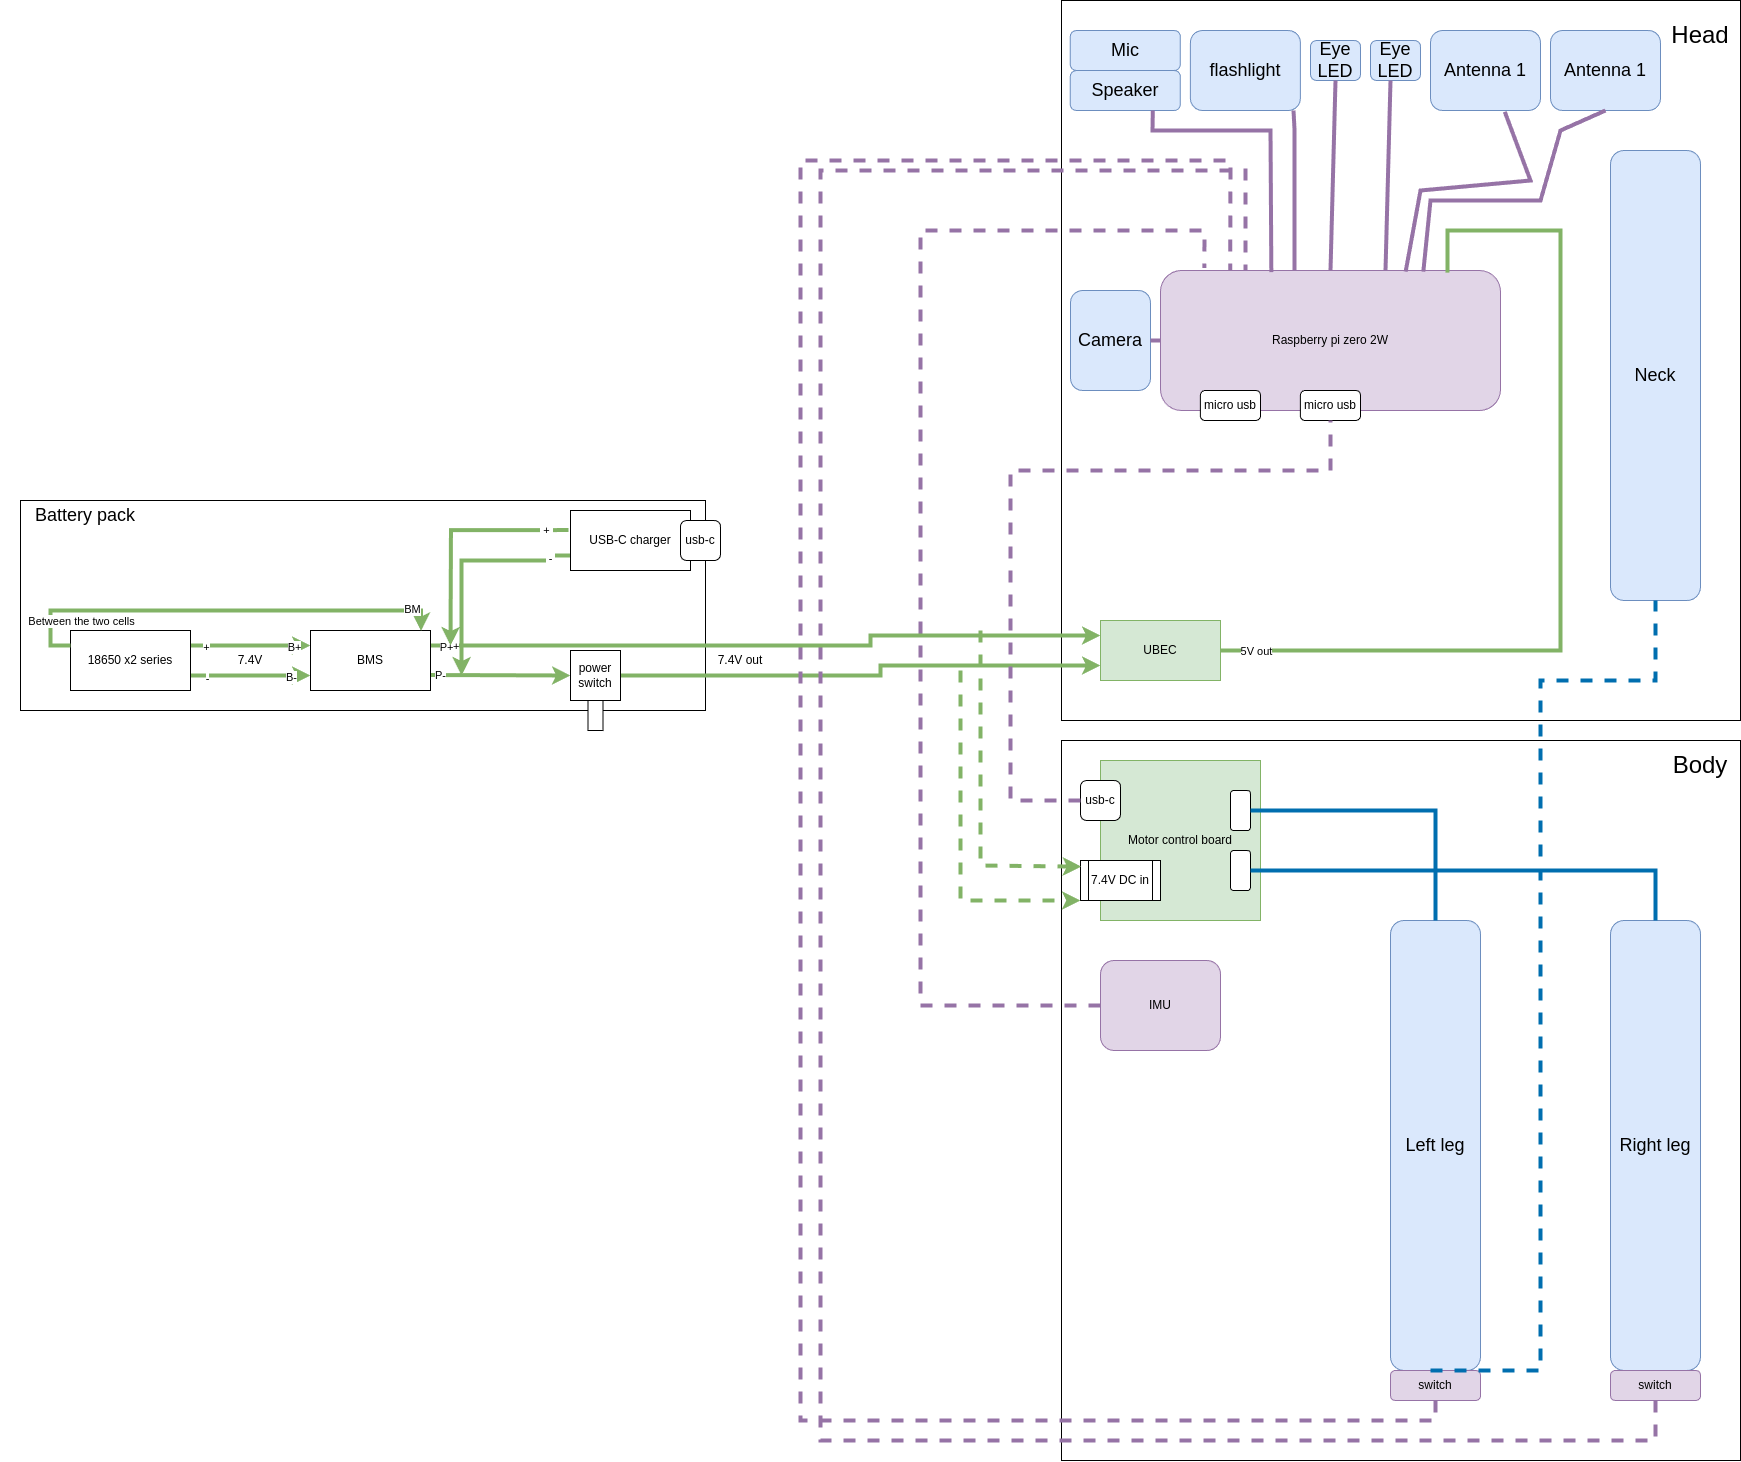
Configure the motors before mechanical assembly. The BOM identifies fourteen Feetech STS3215 servos specifically in the 7.4 V version, plus two small antenna servos, a Pi Zero 2 W, BNO055 IMU and a Waveshare bus-servo adapter. Assembly requires soldering, M3 inserts and threadlocker on specified metal connections. The guide still leaves the overall M3 screw quantity unspecified, so it is not yet a complete purchasing checklist. [6] [7] [8]
Match the runtime, policy and calibration
The separate runtime instructions use Raspberry Pi OS Lite 64-bit and the v2 branch. They cover I2C, controller pairing, motor checks and a per-robot duck_config.json. That file records expression options, IMU orientation and measured joint offsets. The instructions link a walking-policy file from a moving branch; preserve the selected runtime commit and policy checksum together before comparing results across builds. Both repositories are now held locally, but we have not established a tested compatible combination. [9]
Check IMU orientation explicitly: the assembly guide notes that its photographs show the IMU upside down and explains that configuration must match its installation. The runtime also labels head control experimental and warns that it can damage the head. These are practical limits to retain in any demonstration or support plan. No walking, calibration or hardware test has been performed for this profile. [6] [9]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- A limitations summary
- A step-by-step setup summary
Updates
- Upstream last updated
- Jan 31, 2026 [2]
- Latest release
- Not established
- Profile updated
- Sep 30, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- b23317a485b3cec7d8417f352478778b3475173c (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Apache-2.0 Repository license applies to reviewed repository files; purchased electronics and external Onshape model require their own scope checks. Electronics coverage is wiring documentation, not complete board manufacturing sources. [3] [4] [5] [6] |
| electronics | available · Apache-2.0 Repository license applies to reviewed repository files; purchased electronics and external Onshape model require their own scope checks. Electronics coverage is wiring documentation, not complete board manufacturing sources. [3] [4] [5] [6] |
| firmware | not found · License not fully assessed Servo setup is documented; complete source for purchased servo firmware was not established. [7] [8] |
| software | available · Apache-2.0 Repository license applies to reviewed repository files; purchased electronics and external Onshape model require their own scope checks. Electronics coverage is wiring documentation, not complete board manufacturing sources. [3] [4] [5] [6] |
| model weights | available · Apache-2.0 Pinned ONNX payload preserved; compatibility and walking performance have not been tested. [1] [3] [10] |
| documentation | available · Apache-2.0 Repository license applies to reviewed repository files; purchased electronics and external Onshape model require their own scope checks. Electronics coverage is wiring documentation, not complete board manufacturing sources. [3] [4] [5] [6] |
No training dataset selected or reproduced for this configuration.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 apirrone/Open_Duck_Mini: README.md
Revision, date & where cited
github.com · revision
b23317a· Accessed Sep 30, 2026
Used for: Overview, Assembly & first use, Cost, Source files and licenses - S002 apirrone/Open_Duck_Mini: commit b23317a
- S003 apirrone/Open_Duck_Mini: LICENSE
Revision, date & where cited
github.com · revision
b23317a· Accessed Sep 30, 2026
Used for: Source files and licenses - S004 apirrone/Open_Duck_Mini: files
Revision, date & where cited
github.com · revision
b23317a· archive file inventory · Accessed Sep 30, 2026
Used for: Source files and licenses - S005 docs/print_guide.md
Revision, date & where cited
github.com · revision
b23317a· Accessed Sep 30, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 2 more - S006 docs/assembly_guide.md
Revision, date & where cited
github.com · revision
b23317a· Accessed Sep 30, 2026
Used for: What you need, Hardware & parts, Assembly & first use, Cost and 3 more - S007 docs/configure_motors.md
Revision, date & where cited
github.com · revision
b23317a· Accessed Sep 30, 2026
Used for: What you need, Hardware & parts, Assembly & first use, Print the standard parts before selecting modifications and 1 more - S008 Open Duck Mini component spreadsheet
Revision, date & where cited
apirrone / project contributors · docs.google.com · Feuille 1, rows 5–41; dated XLSX snapshot · Accessed Sep 30, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 3 more - S009 Onboard runtime setup
Revision, date & where cited
github.com · revision
3203734· README.md at · Accessed Sep 30, 2026
Used for: What you need, Hardware & parts, Assembly & first use, Match the runtime, policy and calibration - S010 Exact print, model and policy filenames
Revision, date & where cited
github.com · revision
b23317a· Pinned archive payload inventory · Accessed Sep 30, 2026
Used for: Overview, Print the standard parts before selecting modifications, Source files and licenses
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1