Open-Gripper-mini
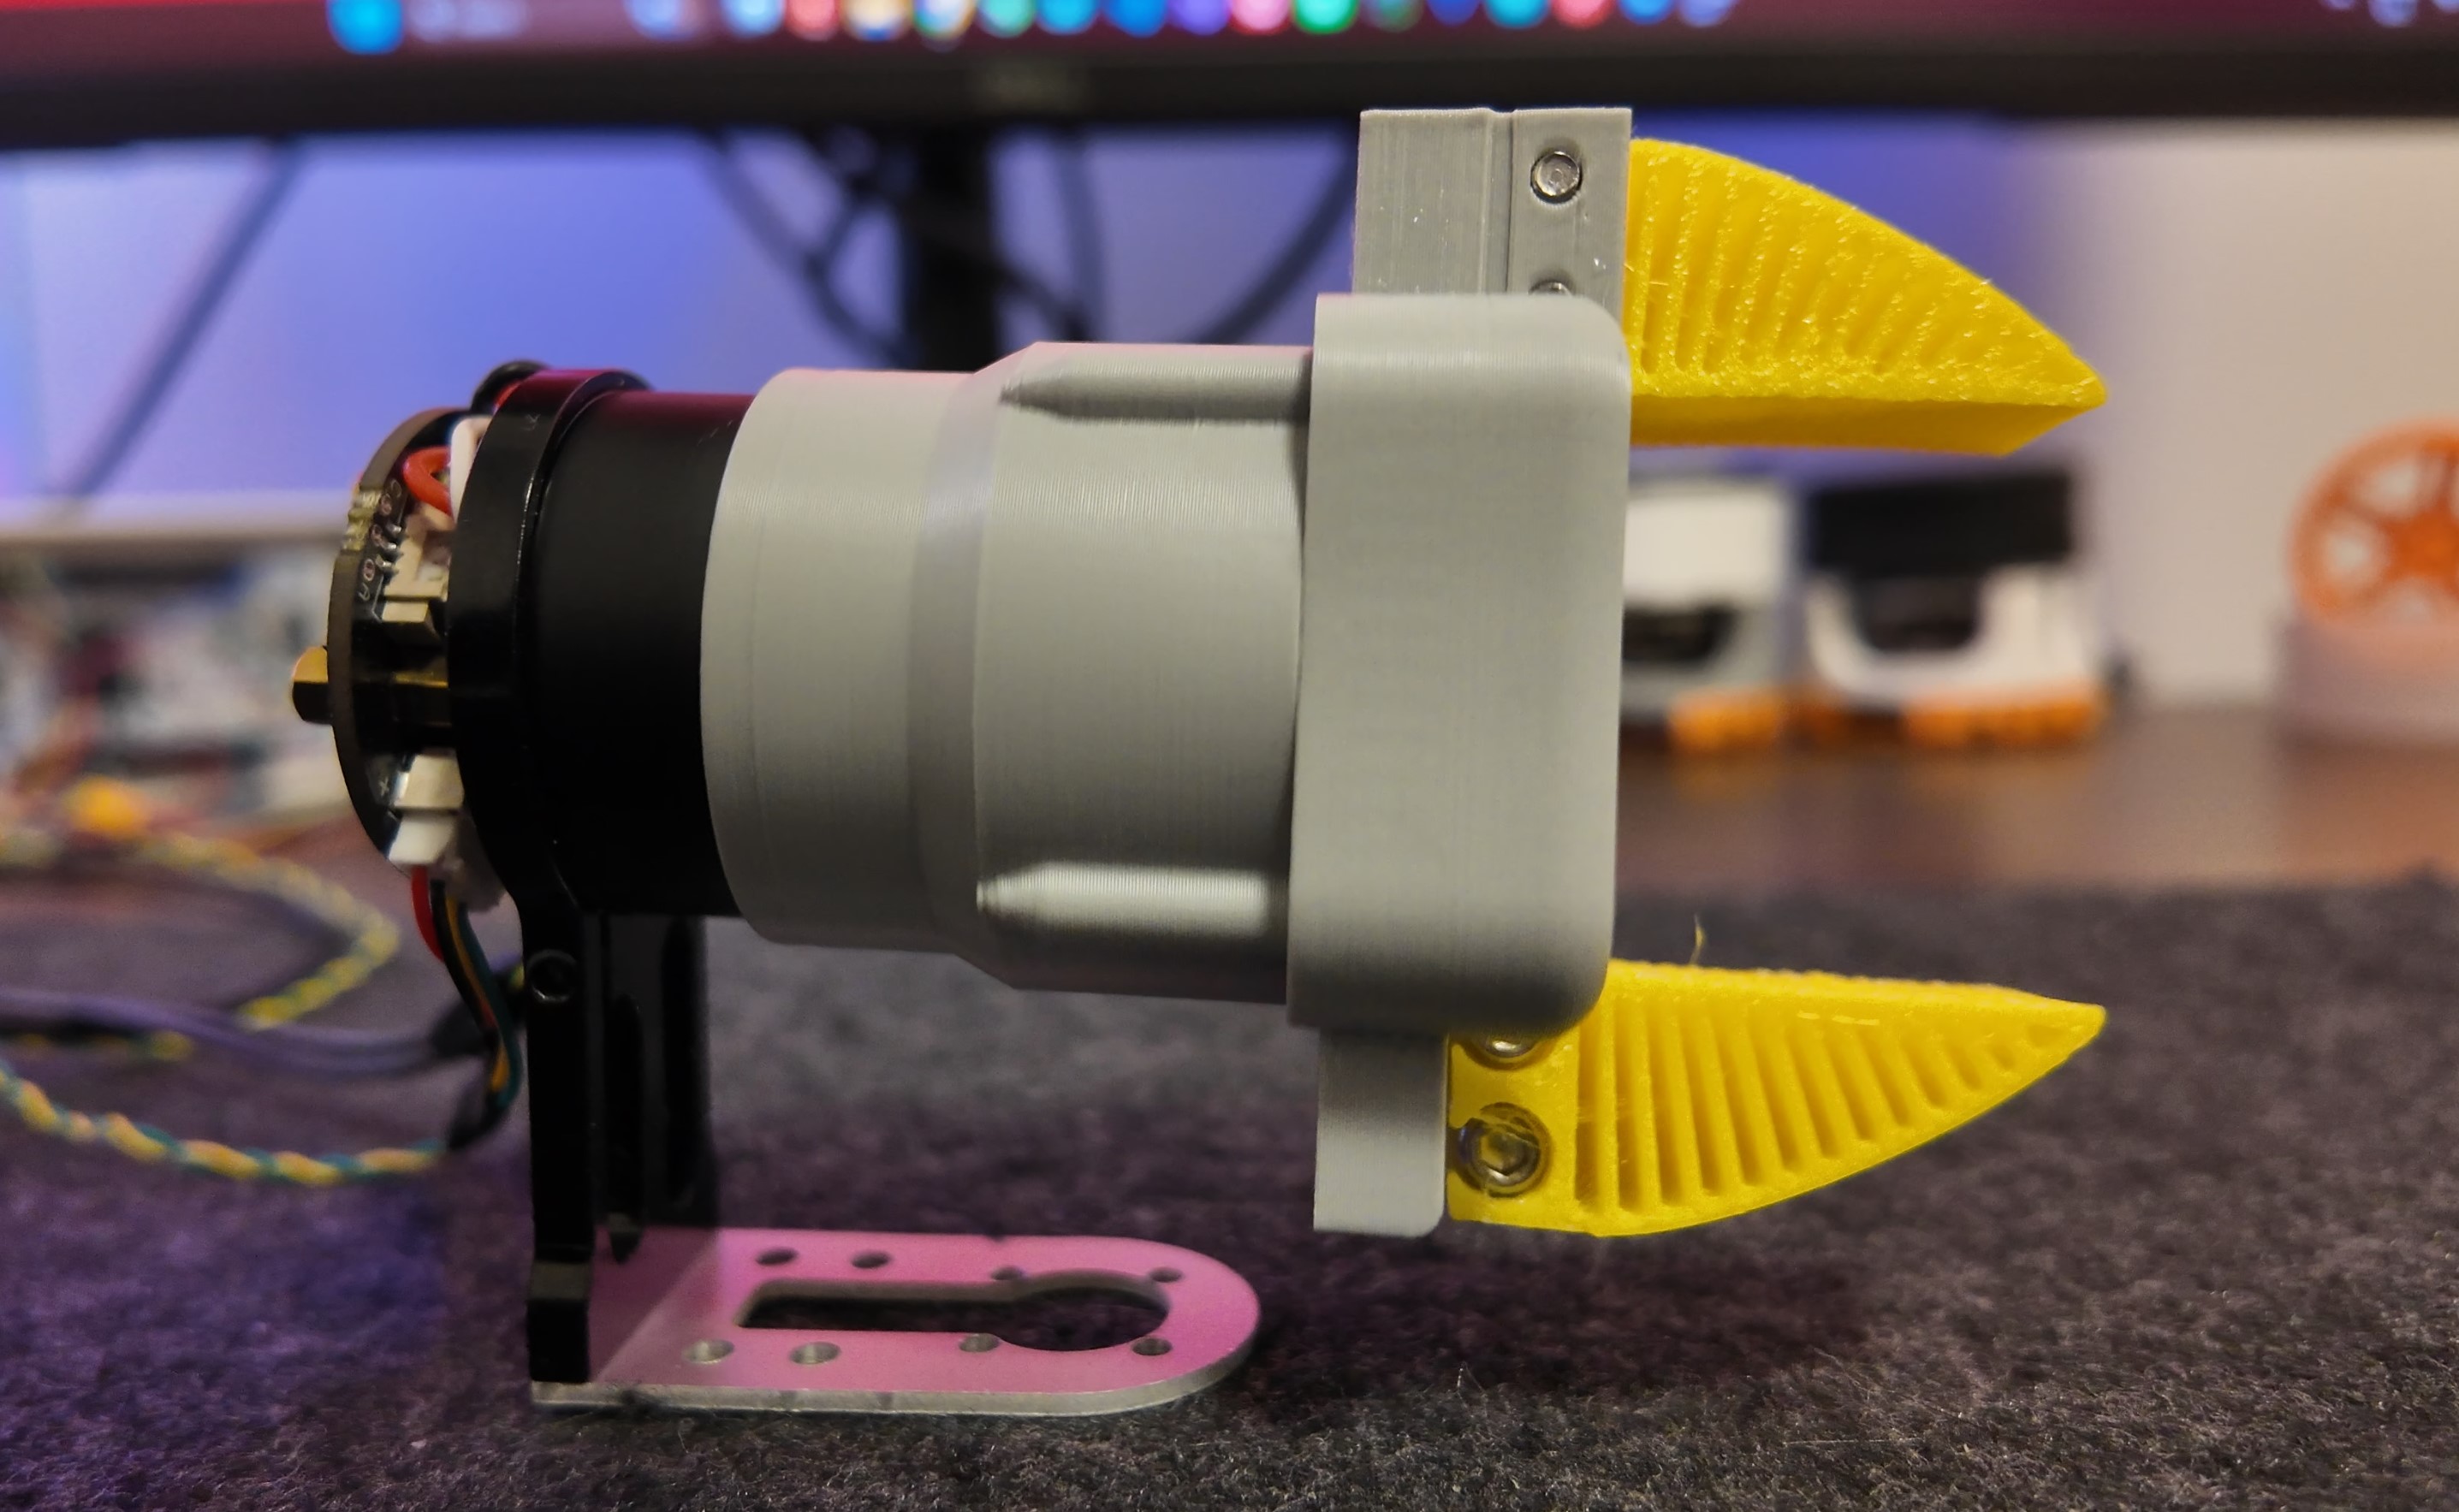
End effectorCompact rack-driven gripper with an assembly STEP and upstream build photo; exact actuator, BOM and control integration still need to be specified. [1] [3] [4]
Build & first use →Official websiteUpstream build guide
- For
- Builders able to inspect CAD, source parts and reconcile control integration. [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
Open-Gripper-mini is a compact rack-driven gripper design for builders who can finish the mechanical and control integration themselves. The preserved source supplies an assembly STEP and a photograph of a physical build, but not a matched purchasing and commissioning package. Treat it as a design starting point, not a ready-to-reproduce kit. [1] [3] [4]
Is this for you?
- Known limitations
- Exact actuator, motor supply, full gripper BOM and mounting pattern are not established.
- Named gripper CAD directory has an assembly STEP but no ready-to-print STL set.
- No matched gripper firmware or complete current cost verified.
Editorial synthesis of inspected sources; not physical qualification.
3D preview
Open-Gripper-mini assembly. Assembly geometry from the upstream STEP; includes represented motor and mounting hardware. Exact actuator, bill of materials and host-arm fit remain unverified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: N-B-Studio, revision 794cd3a623d686796c85b360036860fa97d3fb0d. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [1]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
What is actually in the download
The README says that STEP, SLDPRT and ready-to-print STL files are provided. In the named 3D file directory, however, this snapshot contains only 3d-model.step and a short text file. Other CAD files in the archive belong to vendor motor/controller references. Do not count those as a missing gripper print set: isolate the required gripper bodies from the assembly and establish their print exports before fabrication. [1] [3]
The README suggests 20% infill and M2/M3 fasteners, but it does not give a complete gripper BOM, exact actuator designation, material-specific print settings or a dimensioned host-arm interface. The build photograph shows one implementation, not a source-backed substitute for those missing specifications. Confirm the motor envelope, rack travel, bearings, fastener lengths and mounting pattern in CAD before ordering parts. No current complete build cost is established. [1] [3] [4]
Keep vendor examples separate from a control solution
The README explicitly describes the STM32-H723 examples as unrelated to the gripper mechanics. The archive also contains vendor motor documentation, examples and controller CAD under Document/. Their presence does not establish a validated motor, power supply or matched controller for this gripper. A build still needs a chosen actuator, driver, wiring, travel limits and control interface; no compilation or powered setup was performed for this profile. [1] [3]
The root Apache-2.0 license supports reuse of the first-party design and supplied project image with its notice. It does not establish manufacturing rights for purchased components or relicense all bundled third-party vendor material. The photograph is credited to the upstream project; the interactive preview shows the separate assembly geometry. Neither is a test of grip force, payload or cobot/delta compatibility. [2] [3] [4]
What we checked
Source and geometry review only. No procurement, assembly, firmware build, calibration or physical performance testing.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 4, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
794cd3a
Source files and licenses
Licensed first-party mechanical design and documentation; purchased components and a matched working build remain separate checks.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Apache-2.0 First-party project files under root license; vendor artifacts and purchased-component manufacturing not included in this grant assessment. [2] [3] |
| electronics | not found · License not fully assessed A revision-matched gripper solution was not established; unrelated STM32 examples and vendor references are not treated as that solution. [1] [3] |
| firmware | not found · License not fully assessed A revision-matched gripper solution was not established; unrelated STM32 examples and vendor references are not treated as that solution. [1] [3] |
| software | not found · License not fully assessed A revision-matched gripper solution was not established; unrelated STM32 examples and vendor references are not treated as that solution. [1] [3] |
| documentation | available · Apache-2.0 First-party project files under root license; vendor artifacts and purchased-component manufacturing not included in this grant assessment. [2] [3] |
No learned model or dataset required by the documented mechanical design.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Project description and build outline
Revision, date & where cited
github.com · revision
794cd3a· README.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S002 N-B-Studio/Open-Gripper-mini: LICENSE
Revision, date & where cited
github.com · revision
794cd3a· LICENSE at · Accessed Sep 30, 2026
Used for: Keep vendor examples separate from a control solution, Source files and licenses - S003 Preserved artifact inventory
Revision, date & where cited
github.com · revision
794cd3a· @inventory at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S004 Upstream build photograph and preview inspection
Revision, date & where cited
github.com · revision
794cd3a· @media at · Accessed Sep 30, 2026
Used for: Overview, Hardware & parts, What is actually in the download, Keep vendor examples separate from a control solution
Videos
- S005 Open-Source 3D Printed FOC Gripper with Force Feedback (YouTube video)
Video from the project’s own channel (N.B.Studio), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video N.B.Studio · youtube.com · Accessed Oct 4, 2026
- S006 N.B.Studio (YouTube channel)
The project’s own YouTube channel, found by searching YouTube and checked against the channel page. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel N.B.Studio · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 2 YouTube reference(s) (S005, S006): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.