OpenAMRobot mobile base (OpenAMR)
Robot / hardware buildDifferential-drive AMR base with a sheet-metal chassis, Raspberry Pi 5, Teensy 4.0, two 60 W ZD BLDC gearmotors, RPLIDAR A1 and ROS 2 Jazzy; upstream discloses open safety gaps such as no battery fuse or hardware E-stop. [1] [17]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Labs and experienced builders with sheet-metal fabrication access, 24 V power-wiring skills and ROS 2 experience [1] [7] [17]
- Cost
- No current cost yet. Upstream bill of materials [6]
- Source rights
- Some licenses are unresolved. Review licenses
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- Ecosystem
- ROS 2, Raspberry Pi, Gazebo
- License
- CERN-OHL-P-2.0, MIT (repository); Apache-2.0 on overlay files derived from linorobot2, MIT, CC-BY-4.0 per LICENSING.md (NOTICE.md states MIT) · license not fully assessed for electronics · Details by part
Overview
OpenAMRobot is a differential-drive autonomous mobile robot base for research, prototyping and education. The documented configuration that has run the real robot uses a Raspberry Pi 5 (8 GB) with ROS 2 Jazzy, a Teensy 4.0 for motor control, two ZD 24 V 60 W BLDC gearmotors with ZBLD.C20-120L2R drivers, AS5040 wheel encoders, an MPU-6500 IMU, an RPLIDAR A1 and a Pi camera, on a laser-cut and bent sheet-metal chassis. [1] [17]
Is this for you?
- Use cases
- Autonomous mobile robot research and prototyping
- ROS 2 navigation, mapping and docking development
- Hardware, firmware and UI education
- Known limitations
- No fuse or battery-side disconnect/hardware E-stop fitted yet
- Raspberry Pi 5 without active cooler throttles under the full stack
- Real-robot bring-up, control and driver ROS packages are placeholders
- Firmware is an overlay requiring a pinned linorobot2_hardware checkout
- Not certified for safety-critical or industrial use
What you need
- Operating system
- Ubuntu Server 24.04 on the robot
- Ubuntu 24.04 or Docker for development and simulation
- Host computer
Onboard Raspberry Pi 5 (8 GB) running Ubuntu Server 24.04 and ROS 2 Jazzy; Teensy 4.0 handles real-time motor control.
- Dependencies
- ROS 2 Jazzy, Gazebo Harmonic and Nav2
- linorobot2_hardware firmware base at aaf9d59 (jazzy branch)
- PlatformIO, teensy_loader_cli and micro-ROS agent
- Docker and Docker Compose (optional simulation route)
- Tools
- Sheet-metal cutting and bending from PDF/DXF production drawings
- SolidWorks 2017+ for native CAD (STEP for other tools)
- PlatformIO and a Teensy loader
Hardware & parts
Upstream bill of materials [6]
- Hardware configuration
Differential-drive base with a laser-cut, bent sheet-metal chassis, two driven 200 mm wheels and swivel castors.
- Actuators
- Two ZD Z4BLD60-24GN-30S 24 V 60 W BLDC motors with 4GN 25K (25:1) gearboxes
- Two ZBLD.C20-120L2R BLDC drivers
- Controller
Teensy 4.0 running micro-ROS motor control, with a Raspberry Pi 5 (8 GB) as main computer
- Sensors
- RPLIDAR A1 2D LiDAR (model sticker still to confirm)
- Two AS5040 magnetic wheel encoders
- MPU-6500 IMU (board silkscreen says MPU-6050)
- Raspberry Pi Camera Module 3 NoIR
- Power
Any 24 V battery; the reference build uses 12 V 7 Ah lead-acid batteries two in series, a 24 V-to-5 V buck for the Pi, and no fuse or battery disconnect yet
- Dimensions
Wheel diameter 0.2 m and track 0.46 m (firmware values, tape-measured); upstream calls the 0.4075 m CAD/URDF track a CAD artifact
Assembly & first use
Open the upstream getting-started guide [1]
- Read the v0.0.1 release notes and known limitations
- Fabricate sheet-metal parts from the production drawings and source the listed motors, drivers, wheels and sensors
- Add a battery fuse and disconnect, then wire per the pinout (AS5040 encoders on 3.3 V, driver DIP set for 5 pole pairs)
- Apply the firmware overlay to the pinned linorobot2_hardware commit and flash the Teensy 4.0
- Run the Docker simulation, Nav2 and docking stack before physical bring-up
Editorial source-navigation sequence, not reproduced instructions.
- Assembly
A wheel-module assembly guide is included; a complete written robot assembly guide was not identified in the inspected sources.
Video content not reviewed.
[1] · Editorial assessment
Cost
No current, complete configuration-specific build cost has been established for this profile.
Cost and licensing
No upstream price or parts total was identified; the BOMs list parts without prices, so budget remains unknown. The hardware repository's LICENSE is CERN-OHL-P-2.0 and LICENSING.md maps code to MIT and documentation to CC BY 4.0, but NOTICE.md still says documentation and BOM are MIT and hardware files are planned. Software and firmware repositories are MIT, while the modified linorobot2 overlay files keep Apache-2.0 headers. Re-hosted datasheets remain manufacturer copyright. [3] [4] [5] [10] [12] [15] [16]
This is source research only: the software was not installed or built, CAD geometry and production drawings were not opened or checked, and nothing was fabricated, wired, flashed or driven for this profile.
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
Where the sources are now
The listed openAMRobot/openamr repository now describes itself as a legacy monorepo kept for historical reference. Current material is split into hardware, software and firmware repositories, and a v0.0.1 release from July 2026 bundles them as a separate 113 MiB source zip. This profile covers October 2 commit snapshots of the three platform repositories; the release zip was not preserved, so v0.0.1 contents were not compared. [18] [19]
The hardware repository holds a full STEP assembly, per-part PDF, DXF and SolidWorks production files, sheet-metal bend parameters, electrical and mechanical BOMs, wiring documentation and a wheel-module assembly guide. No custom PCB exists yet; the electronics are off-the-shelf modules wired per the pinout. [1] [7] [9]
What a builder must reconcile
The firmware is not standalone. It is three overlay files to copy onto linorobot2_hardware at a pinned jazzy-branch commit, then build with PlatformIO and run with a micro-ROS agent. That base was not preserved here. The overlay covers motor control, encoders, IMU and a 200 ms command watchdog; battery monitoring is not implemented. [13] [14]
The software README says its Gazebo simulation, Nav2 and AprilTag docking stack runs end to end, but its bring-up, control and driver packages are placeholders. The hardware BOM corrects the drivetrain to a 0.2 m wheel and 0.46 m track and warns that the simulation file still uses wrong wheel values. Measure the assembled robot and drive 1 m to check odometry rather than trusting CAD-derived numbers. [6] [11]
Upstream lists safety gaps that are not yet fixed: no fuse on the 24 V battery, no battery-side disconnect or hardware E-stop, and a Pi 5 without active cooling that throttles. Encoders must run at 3.3 V because the Teensy inputs are not 5 V tolerant. The release is described as hobby/research-grade and not safety certified. [1] [6] [17]
What we checked
Source research only; no installation, physical build, calibration or test performed. No affiliate links; upstream sponsorship and support tiers were not evaluated.
Updates
- Upstream last updated
- Oct 2, 2026 [2]
- Latest release
- Jul 11, 2026 [18]
- Profile updated
- Oct 26, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- openamr-platform-hw 9703a5f13ffc009db8ff3fa979470179afe3d26b, openamr-platform-sw 12de3ef9503073ab41fd4118f3a018809ad51c4e and openamr-platform-fw 732f0027be891d09603385f16abbfac1d30f4987 (commit snapshots, 2026-10-02). The v0.0.1 platform release (2026-07-11) packaged earlier main-branch snapshots in a source zip that was not preserved. · repository
Source files and licenses
CAD, wiring documentation, firmware overlay and ROS 2 software are public with stated permissive licenses; documentation licensing conflicts, the linorobot2 firmware base and the frozen release package were not preserved, and costs are unpublished.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-P-2.0 Full STEP assembly, per-part PDF/DXF/SLDPRT/SLDDRW/STEP production files and a 9.8 MB SolidWorks zip are in the pinned snapshot; geometry not opened. The CAD README calls the native SolidWorks package a release asset, but no hardware-repository release was found. NOTICE.md still describes hardware files as planned. Purchased motors, wheels and sensors are not covered. [1] [3] [4] [5] [9] |
| electronics | available · License not fully assessed Wiring/pinout, power and sensor documentation with an electrical BOM; no custom PCB (electrical/pcb is a placeholder). LICENSING.md maps documentation to CC BY 4.0 and schematic source to CERN-OHL-P-2.0, while NOTICE.md says documentation and BOM are MIT; no single license assigned here. [1] [4] [5] [6] |
| firmware | available · MIT (repository); Apache-2.0 on overlay files derived from linorobot2 Three overlay files to copy onto linorobot2_hardware at aaf9d59; that base was not preserved here. Modular firmware directories are placeholders; battery monitoring not implemented. [13] [14] [15] [16] |
| software | available · MIT Description, Gazebo, Nav2 and AprilTag docking packages; bring-up, control and driver packages are placeholders. The hardware BOM notes the simulation robot.sdf still uses wrong wheel radius and separation. [11] [12] |
| documentation | available · CC-BY-4.0 per LICENSING.md (NOTICE.md states MIT) Conflicting statements inside the hardware repository. Re-hosted third-party datasheets remain manufacturer copyright and are excluded from the repository license. [4] [5] [10] |
Navigation and docking workflow uses no distributed learned weights.
No dataset is part of the selected workflow.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 OpenAMRobot platform hardware README
Validated hardware configuration, drivetrain values, release scope, known hardware limitations and license summary.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· README.md at · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S002 Hardware repository revision and popularity metadata
Commit snapshot (no repository release), commit date, archive checksum and dated repository-level popularity.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· ; GitHub repository and commit API fields · Accessed Oct 5, 2026
Used for: What we checked - S003 Hardware repository license
CERN Open Hardware Licence Version 2 - Permissive text at the repository root.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· Accessed Oct 5, 2026
Used for: Cost, Source files and licenses - S004 OpenAMRobot licensing standard (hardware repository)
Per-material license map: MIT for code, CC BY 4.0 for documentation, CERN-OHL-P-2.0 for CAD and design source.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· Accessed Oct 5, 2026
Used for: Cost, Source files and licenses - S005 Hardware repository notice
Older licensing summary (documentation and BOM MIT; hardware files planned under CERN-OHL-P-2.0) and third-party notes.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· Accessed Oct 5, 2026
Used for: Cost, Source files and licenses - S006 Electrical components BOM
Part numbers, confirmation status, motor/gearbox, drivetrain dimensions, encoder supply fix and battery notes.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· manufacturing/bom/components-bom.md (last updated 2026-06-19) · Accessed Oct 5, 2026
Used for: Hardware & parts, Assembly & first use, What a builder must reconcile, Source files and licenses - S007 Mechanical and preliminary electronics BOM
Sheet-metal parameters, purchased mechanical components, preliminary electronics BOM and interface summary.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· Accessed Oct 5, 2026
Used for: What you need, Hardware & parts, Assembly & first use, Where the sources are now - S008 Product architecture: base build versus options
What the base build includes and which attachments and parts are roadmap options.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· Accessed Oct 5, 2026 - S009 Mechanical CAD README and file inventory
STEP full assembly, production files and SolidWorks package location; files listed, geometry not opened.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· mechanical/cad/README.md plus archive inventory of mechanical/cad · Accessed Oct 5, 2026
Used for: What you need, Where the sources are now, Source files and licenses - S010 Datasheets README
Third-party datasheets re-hosted with manufacturer copyright; base versus optional components.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
9703a5f· Accessed Oct 5, 2026
Used for: Cost, Source files and licenses - S011 OpenAMRobot platform software README
ROS 2 Jazzy simulation, Nav2 and AprilTag docking; experimental status; placeholder bring-up, control and driver packages.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
12de3ef· README.md at (status, quickstart table and repository layout sections) · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, What a builder must reconcile and 1 more - S012 Software repository license
MIT License text.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
12de3ef· Accessed Oct 5, 2026
Used for: Cost, Source files and licenses - S013 OpenAMRobot platform firmware README
Teensy 4.0 linorobot2 overlay, prerequisites, pinned linorobot2_hardware commit and flashing route.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
732f002· README.md at · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, What a builder must reconcile and 1 more - S014 Teensy 4.0 linorobot2 overlay README
Module coverage (watchdog partial, battery monitor not implemented) and robot-specific configuration changes.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
732f002· Accessed Oct 5, 2026
Used for: What a builder must reconcile, Source files and licenses - S015 Firmware repository license
MIT License text for the firmware repository.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
732f002· Accessed Oct 5, 2026
Used for: Cost, Source files and licenses - S016 Overlay firmware source header
Apache-2.0 notice retained on the modified linorobot2 firmware file.Revision, date & where cited
Juan Miguel Jimeno (linorobot2); modified by OpenAMRobot · github.com · revision
732f002· src/firmware.ino header comment · Accessed Oct 5, 2026
Used for: Cost, Source files and licenses - S017 OpenAMRobot v0.0.1 release metadata
Release scope, notes, known limitations and the component repositories packaged from main branches.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
2e447ab· release-metadata/*.md and release-config.json at v0.0.1 () · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S018 OpenAMRobot v0.0.1 GitHub release record
Release published 2026-07-11 with a 118,878,506-byte source zip asset (not preserved here).Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · GitHub releases API: tag, publication date and asset list · Accessed Oct 5, 2026
Used for: Where the sources are now, What we checked - S019 Legacy openamr monorepo metadata
The originally listed monorepo describes itself as legacy and retained for historical reference.Revision, date & where cited
OpenAMRobot (Botshare LTD) · github.com · revision
2c42612· GitHub repository API description and acquisition record () · Accessed Oct 5, 2026
Used for: Where the sources are now - S020 Upstream image and reuse attribution
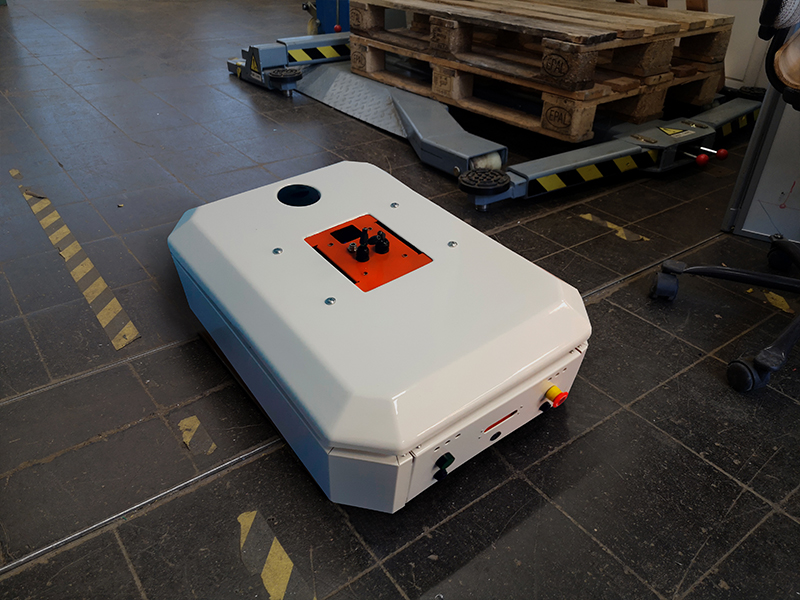
Media-only review: Photograph of the OpenAMRobot differential-drive mobile base in a workshop, as identified in the selected hardware documentation (October 2026 snapshot). This shows the base with its cover fitted, without the newer dual-arm lift assembly. Reuse basis: CC-BY-4.0. Exact selected hardware snapshot README explicitly identifies this image as the physical OpenAMRobot base in a workshop, white chassis, orange top mounting plate and front E-stop. It appears directly beside the selected Pi5/Teensy/ZD60W configuration, distinct from the optional newer dual OpenArm/lift product-vision renderings. The actual image bytes match selected tree Git blob2353254e5109136eeb7f66cc148df155eea3a35e, independently also present in legacy design repository2c426120f0044c3cc186be7f524585e1395a8629. Pinned LICENSING explicitly includes original images under CC BY4.0. NOTICE contains an older MIT summary for documentation/notes/BOM, but no image-specific restriction; it does not contradict the explicit original-image grant. This is a physical photograph, not CAD-derived geometry, despite being stored in a renderings folder. Mechanical README distinguishes actual mobile base from product vision; no separately credited third-party photo or more specific image exclusion found. Branding rights are reserved; incidental marks are shown only in the robot photograph and attribution, with no endorsement claim. Photograph does not independently verify hidden electronics, runtime, payload, manufacturing quality or current support. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
OpenAMRobot (Botshare LTD) / OpenAMRobot contributors · github.com · revision
9703a5f· Selected openamr-platform-hw snapshot9703a5f13ffc009db8ff3fa979470179afe3d26b, README physical robot section and mechanical/renderings/AMR_SME_logistics.jpg; blob2353254e5109136eeb7f66cc148df155eea3a35e,800x600.; image SHA-256 afc4dde8ace3e42fd71f9f73a2caee5342305e038e71f823f85ed0855a969ac1 · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Initial intake profile. Lead pointed to the legacy openamr monorepo; profile covers the current split platform repositories.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.