OpenBionics Prosthetic Hands
End effectorSingle-actuator, tendon-driven anthropomorphic hand design from the OpenBionics initiative, with 3D-printed and laser-cut variants, parametric SolidWorks CAD and a 2015 assembly report; repository-wide CC BY-SA 4.0 statement. [1] [3] [5]
Build & first use →Official websiteUpstream build guide
- For
- Makers and researchers studying underactuated, tendon-driven hand mechanisms who can 3D print or laser cut parts, stitch flexure joints and edit SolidWorks models [6] [7] [8] [10]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
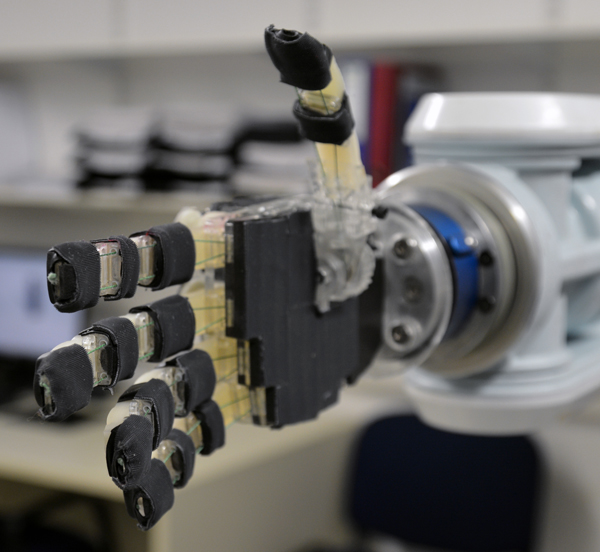
This repository from the OpenBionics initiative publishes a five-finger hand that upstream presents as an affordable prosthetic hand, stating a cost under USD 200 and a weight under 300 g. A whiffletree differential lets a single actuator close all fingers, and locking buttons block each finger independently; the README credits this with 144 different grasps. [1] The 2015 report gives index to pinky three flexion joints each and the thumb two flexion joints plus a lockable abduction/adduction mechanism. Joints are silicone or polyurethane flexures, and Dyneema tendons in low-friction tubes provide flexion. [14] Its authors list affiliations at the National Technical University of Athens, Yale and Cornell. [16]
The design suits makers and researchers studying underactuated, tendon-driven hands. No medical certification or clinical evaluation was identified in the inspected sources, and this catalog makes no safety or medical-suitability assessment.
Is this for you?
- Known limitations
- No medical certification or clinical-suitability evidence identified in the inspected sources
- Parametric editing requires SolidWorks 2014 or later; the FreeCAD migration is partial
- Breakout board described upstream as under testing
- Last repository commit 2018-02-10
- Full repository archive not preserved because of its size
Source-review boundaries; no build or test.
What you need
- Dependencies
- SolidWorks 2014 or later for parametric edits
- Arduino with the modified Herkulex DRS-0201 library
- MATLAB with a robotics toolbox for the kinematics scripts
- Tools
- Long needles
- Precision ruler
- Long-nose pliers and cutter
- Scissors
- Phillips screwdrivers no. 1 and 2
- M3 open-end wrench
- 2.5 mm Allen wrench
Hardware & parts
- Hardware configuration
Five-finger anthropomorphic hand: index to pinky with three flexion DoF each, thumb with two flexion DoF and one lockable abduction/adduction DoF, all driven by a single actuator through a whiffletree differential with per-finger locking buttons.
- Controller
Arduino Micro Pro (ATmega32U4) on an OpenBionics breakout board described upstream as under testing.
- Power
Breakout board powered by an external supply or a battery; voltage not stated in the inspected sources.
- Degrees of freedom
15
Sum of the joint DoF described in the report (4 x 3 + 2 + 1); one actuator drives them through tendons, so this is not a count of independently controlled joints.
[14] · Editorial assessment
- Dimensions
Reference hand (19 cm hand length): 190 mm long, 90 mm breadth, 62.5 mm wide, 300 g.
Assembly & first use
Open the upstream getting-started guide [4] [5] · Project documentation [5]
- Choose left or right hand and the 3D-printed or laser-cut variant
- Set hand length and breadth in the SolidWorks parameter file if personalizing, then rebuild and export parts
- Fabricate rigid parts and gather the listed tools, silicone sheets and Dyneema line
- Assemble fingers and palm following the 2015 report
- Wire the HerkuleX servo to an Arduino and load the example firmware
Editorial source-navigation sequence, not reproduced instructions.
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
Variants to choose between
- 3D-printed: ABS parts printed on a Lulzbot TAZ 4, with about 6 hours of printing reported. [7]
- Laser-cut: acrylic parts, with about 2 hours of cutting reported. [8]
- Personalized size: left and right SolidWorks models scale from hand length (182–225 mm) and breadth (82.5–110 mm); editing requires SolidWorks 2014 or later. A FreeCAD migration covers only the palm, differential and thumb abduction/adduction mechanisms; the fingers remain outside the documented migration. [6] [9]
- Experimental options: a molded HDM finger design that relies on an external GrabCAD hand model, and a body-powered harness that upstream prices under USD 25. [10] [11]
The reference hand in the report measures 190 × 90 × 62.5 mm and weighs 300 g. [14]
What a build involves
The parts list names one HerkuleX DRS-0201 servo as the actuator. [15] The report's experiments drove it from an Arduino Micro through a custom board. The repository's breakout board (Arduino Micro Pro, with analog inputs for sensors such as EMG) is described as "currently under testing". [12] [14] The firmware is a simple sketch using a modified Herkulex library. [13] Assembly involves stitching rigid phalanges to silicone sheets with needles and fishing line, using hand tools such as long-nose pliers, an M3 wrench and a 2.5 mm Allen key. [10] [15] A separate OpenBionics ROS package mentioned in the report was not inspected. [14]
What the repository contains and how it is licensed
The pinned tree holds SolidWorks parts and assemblies with STL and DXF exports, Eagle files for the breakout board, the Arduino sketch and Herkulex library, two MATLAB kinematics scripts that use a robotics toolbox, and the assembly report. [1] [4] LICENSE.txt places "this work" under CC BY-SA 4.0 without separate terms per folder, so that statement is the only license identified for the CAD, board files, sketch and MATLAB scripts; the report repeats it. Sharing covered material requires appropriate credit, a license link and an indication of changes. Distributed adaptations must keep the same license. [3] [16] The bundled Herkulex library is third-party code whose header states LGPL 2.1 or later. [13] Terms for the external GrabCAD model used by the HDM variant were not reviewed. [10]
What remains unknown
The inspected default-branch snapshot dates to 2018-02-10, and no stable release was found among the repository's published releases. The full repository archive exceeds this catalog's 150 MiB intake limit, so CAD, STL, board files and the report PDF were listed but not preserved or checked. [2] [4] No fabrication, assembly or test was performed.
What we checked
Source research only; no fabrication, assembly, firmware installation or test performed. The catalog makes no safety, medical-suitability or certification assessment; upstream describes the design as a prosthetic hand, and no certification evidence was identified. No affiliate links.
Not yet established
- Requirements: operating system, host computer
Updates
- Upstream last updated
- Feb 10, 2018 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- 639aca3a53c682d00c5a10d9c96e47c74e04a57c (master commit snapshot dated 2018-02-10; no published release found) · repository
Source files and licenses
Complete mechanical, electronics, firmware and assembly sources are published with a repository-wide CC BY-SA 4.0 statement and a separately noticed LGPL library. Included as a historical hand design; inclusion is not a medical-suitability or certification claim.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-SA-4.0 (repository-wide statement) SolidWorks parts and assemblies, STL (left and right) and DXF laser files listed in the pinned tree; payloads not preserved or geometry-checked. The HDM finger variant depends on an external GrabCAD model whose terms were not reviewed. [3] [4] [6] [7] [8] |
| electronics | available · CC-BY-SA-4.0 (repository-wide statement) Eagle-format breakout board (uC_Board.sch/.brd) listed; described upstream as under testing. Covered only by the repository-wide statement. [3] [4] [12] |
| firmware | available · LGPL-2.1-or-later (Herkulex library header); sketch covered only by repository-wide CC BY-SA 4.0 statement Modified third-party Herkulex library by Alessandro Giacomel carries its own LGPL notice; the HerkulexSerial sketch has no separate license notice in inspected sources. [3] [13] |
| software | available · CC-BY-SA-4.0 (repository-wide statement) Two MATLAB kinematics scripts; the robotics toolbox they use is a separate dependency. The ROS package mentioned in the report lives outside this repository and was not inspected. [1] [3] [4] |
| documentation | available · CC-BY-SA-4.0 The report source states CC BY-SA 4.0 explicitly; the compiled PDF was listed but not preserved. [3] [5] [16] |
Mechanical hand design; no learned model.
No dataset is part of the design release.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Prosthetic-Hands README
States cost under USD 200, weight under 300 g, single-actuator differential, parametric personalization and repository contents.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· README.md at master commit snapshot · Accessed Oct 5, 2026
Used for: Overview, What you need, Hardware & parts, Cost and 2 more - S002 OpenBionics/Prosthetic-Hands: commit 639aca3
Commit date 2018-02-10; full archive blocked by the 150 MiB intake limit; dated popularity counts.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · (default-branch snapshot; no stable release); GitHub API metadata · Accessed Oct 5, 2026
Used for: Is this for you?, What remains unknown, What we checked - S003 Repository license statement
States the work is licensed under Creative Commons Attribution-ShareAlike 4.0 International.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: What the repository contains and how it is licensed, Source files and licenses - S004 Pinned repository file tree
Lists SolidWorks sources, STL and DXF files, Eagle board files, Arduino code, MATLAB kinematics and the assembly-guide PDF.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· GitHub git trees API (recursive) at the pinned commit; selected paths · Accessed Oct 5, 2026
Used for: Assembly & first use, What the repository contains and how it is licensed, What remains unknown, Source files and licenses - S005 Assembly guide overview
Technical report as step-by-step replication tutorial; hand design summary and references.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: Assembly & first use, Source files and licenses - S006 Parametric 3D design guide
Personalization via hand length and breadth parameters in SolidWorks 2014 or later; supported hand-size range.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, Variants to choose between and 1 more - S007 3D-printed parts notes
ABS on a Lulzbot TAZ 4; about 6 hours fabrication time.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: What you need, Assembly & first use, Variants to choose between, Source files and licenses - S008 Laser-cutter files notes
Acrylic (Plexiglas) laser-cut version; about 2 hours fabrication time.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: What you need, Assembly & first use, Variants to choose between, Source files and licenses - S009 FreeCAD migration notes
Partial FreeCAD migration (palm, differential, thumb); fingers to follow.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: Is this for you?, Variants to choose between - S010 HDM finger design notes
Alternative hybrid-deposition finger design relying on an external GrabCAD human-hand model; original fingers use silicone sheets stitched with needles.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: What you need, Assembly & first use, Variants to choose between, What a build involves and 1 more - S011 Body-powered harness notes
Optional body-powered harness; upstream cost under USD 25 and 250 g.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: Variants to choose between - S012 Electronics breakout board notes
Breakout board for servo control with analog/digital inputs and I2C; Arduino Micro Pro (ATmega32U4); board under testing.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, What a build involves, Source files and licenses - S013 Arduino firmware notes and Herkulex library header
Simple Arduino firmware using a modified third-party Herkulex DRS-0201 library whose header states LGPL 2.1 or later.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Software/README.md; Software/libraries/Herkulex/Herkulex.h header · Accessed Oct 5, 2026
Used for: What you need, Hardware & parts, Assembly & first use, What a build involves and 2 more - S014 Assembly guide technical report: design and results
Finger DoF and flexure joints, tendon routing, reference hand dimensions, cost and weight table, experiment setup.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Assembly Guide/tex/Description.tex (2015 report source) · Accessed Oct 5, 2026
Used for: Overview, Hardware & parts, Assembly & first use, Cost and 2 more - S015 Assembly guide technical report: tools and parts
Tools and materials boards; auxiliary parts list including one HerkuleX DRS-0201 actuator.Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Assembly Guide/tex/Appendix1.tex and Appendix2.tex · Accessed Oct 5, 2026
Used for: What you need, Hardware & parts, Assembly & first use, What a build involves - S016 Assembly guide technical report: title and license page
Report title, CC BY-SA 4.0 statement and author affiliations (NTUA Control Systems Lab, Yale, Cornell).Revision, date & where cited
OpenBionics initiative / project contributors · github.com · revision
639aca3· Accessed Oct 5, 2026
Used for: Overview, What the repository contains and how it is licensed, Source files and licenses - S017 Upstream image and reuse attribution
Media-only review: Upstream photograph of an OpenBionics prosthetic hand assembly. Reuse basis: CC-BY-SA-4.0; inspected LICENSE.txt and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
OpenBionics and Athens Hackerspace contributors · github.com · revision
639aca3· Image SHA-256 82956fadbfbb6a2f41ad5f15a0514a520c46dde98286ec456205462716b89a2c; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Initial intake from the Growbotics comparison lead; verified against the upstream repository at the pinned commit.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.