OpenFlexure Microscope
Robot / hardware buildMotorized printed microscope with an RMS-objective build route, separate controller and software dependencies, and explicit beta-version compatibility limits. [1] [5] [11]
Build & first use →Official websiteSource code
- For
- Researchers and builders able to validate printed mechanics, optics and motorized microscopy [1] [5]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CERN-OHL-S-2.0-or-later · license not fully assessed for electronics, firmware, software · Details by part
Overview
OpenFlexure combines a printed flexure mechanism with sample positioning and optical focusing. This profile reviews the motorized high-resolution build in mechanical release v7.0.0-beta5, commit 4828ffa5c4a115caa1970b71efdc32e3a05c09e1. It is a prerelease configuration, not a claim that all microscope variants or current vendor kits have been checked. [1] [2] [5]
Is this for you?
- Known limitations
- Selected mechanical release is a beta
- Software v3 beta excludes legacy motor boards and server extensions in retrieved guide
- No positioning accuracy, imaging resolution or biological application validated by this catalog
Evidence scope and unreproduced performance boundary.
What you need
- Operating system
- OpenFlexure Raspbian v3.0.0 beta for the selected Pi4/Sangaboard route
- v2.11.0 stable is a separate older compatibility route, with an OS that no longer receives updates
- Host computer
Selected v3 beta software route: Raspberry Pi 4 with 4GB or more RAM for Full OS; 2GB can run Lite with possible performance impact. Pi 5 unsupported in the retrieved guide.
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The checked file inventories did not establish a supported 3D payload. The design may be supplied as drawings, an external CAD document or a separate download.
Model sources
The checked file inventories did not establish a supported 3D payload. The design may be supplied as drawings, an external CAD document or a separate download.
Project notes
The selected optical and printed configuration
The high-resolution instructions use an RMS-threaded objective, a 12.7 mm achromatic tube lens and a Raspberry Pi Camera Module v2 with its original lens removed. The guide reports an approximately 360 by 270 micrometre field of view with a 40x objective; this is not a catalog measurement or a universal resolution specification. The specified camera ribbon cable is Type B, with contacts on opposite sides at the ends. The guide warns that the wrong cable type can damage the camera. [6]
Printing instructions specify PLA, a 0.4 mm nozzle and 0.2 mm layers, with no added supports. The flexure mechanism and integrated brim make slicer gap-closing behavior important, so the guide includes leg and nut-trap test prints. The high-resolution assembly passes a 375 g PLA quantity into its printing instructions; that is a material allowance, not a complete build price. [5] [7] [10]
Hardware and software versions must agree
The mechanical guide selects Sangaboard v0.5, an RP2040-based controller, and reports most testing with v0.5.3. It calls for a USB-C supply capable of at least 3 A. Header height also affects the printed enclosure: the documented supplier uses 11 mm headers, whereas an 8.5 mm version needs a different electronics drawer. These are configuration details, not interchangeable shopping-list entries. [8]
The current installation page, preserved October 1, 2026, describes two software routes. Its v3.0.0 beta requires a Raspberry Pi 4 and Sangaboard v0.5 running firmware 1.3 or later. It lists 4 GB or more RAM for the Full OS and permits 2 GB for Lite with possible performance impact. It does not support Pi 5, earlier Pi models, alternative motor boards, the Delta stage or server extensions at the documented stage. [11]
The separate v2.11.0 stable route supports older hardware and workaround motor controllers, but its OS no longer receives updates and uses at most 4 GB RAM. Neither route supports Pi 5 in the retrieved guide. The existence of legacy controller instructions therefore does not establish compatibility with v3 beta. [8] [11]
The selected Pi requires the microscope operating-system image on an SD card and the controller requires firmware. The current guide recommends Raspberry Pi Imager 2 because older 1.9 versions may not customize the image correctly. No SD card was written and no firmware was flashed during this review. [9] [11]
Source coverage and untested performance
The mechanical repository states CERN-OHL-S version 2.0 or later and includes editable OpenSCAD design files and assembly documentation. The controller PCB, controller firmware, microscope server and clients are separately linked projects. Their complete payloads and licenses were not independently preserved here, so the mechanical repository license is not assigned to those components. [1] [3] [4] [8]
The installation guide offers OpenFlexure Connect or a browser on the same network. Its current macOS Connect route requires a source build; the browser route is a separate option. Full OS supports a directly attached display and input devices, while Lite is for network control. [11] [12]
Complete delivered cost remains unresolved because optics, electronics, printing, hardware and sourcing choices vary. This catalog has not printed the mechanism, assembled optics, measured stage precision, reproduced imaging performance or validated any biological application. [1] [5] [6]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-S-2.0-or-later Selected mechanical repository sources and documentation; third-party libraries and separately hosted software/controller sources require their own terms. [1] [3] [4] |
| electronics | available · License not fully assessed Official documentation links the separate Sangaboard design repository. Exact board payload/revision and its license were not independently preserved here. [1] [8] |
| firmware | available · License not fully assessed Official documentation links separate firmware; v3 beta requires firmware 1.3 or later. Exact firmware payload and license were not independently preserved here. [1] [8] [11] |
| software | available · License not fully assessed Official overview links the separate microscope server and current install page describes OS images. Payloads, exact builds and component licenses were not independently preserved here. [1] [11] |
| documentation | available · CERN-OHL-S-2.0-or-later Selected mechanical repository sources and documentation; third-party libraries and separately hosted software/controller sources require their own terms. [1] [3] [4] |
Selected motorized imaging route does not require a learned policy or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 OpenFlexure overview
Revision, date & where cited
openflexure / project contributors · gitlab.com · README.md · Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use, Source coverage and untested performance and 1 more - S002 Preserved beta release metadata
Revision, date & where cited
openflexure / project contributors · gitlab.com · Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What we checked - S003 Hardware repository license
Revision, date & where cited
openflexure / project contributors · gitlab.com · Full License · Accessed Oct 1, 2026
Used for: Source coverage and untested performance, Source files and licenses - S004 Archive inventory
Revision, date & where cited
openflexure / project contributors · gitlab.com · Complete preserved archive filenames · Accessed Oct 1, 2026
Used for: Source coverage and untested performance, Source files and licenses - S005 docs/high_res_microscope.md
Revision, date & where cited
openflexure / project contributors · gitlab.com · Accessed Oct 1, 2026
Used for: Overview, Hardware & parts, Assembly & first use, The selected optical and printed configuration and 1 more - S006 docs/high_res_optics_module.md
Revision, date & where cited
openflexure / project contributors · gitlab.com · Accessed Oct 1, 2026
Used for: What you need, Hardware & parts, The selected optical and printed configuration, Source coverage and untested performance - S007 docs/test_your_printer.md
Revision, date & where cited
openflexure / project contributors · gitlab.com · Accessed Oct 1, 2026
Used for: What you need, The selected optical and printed configuration - S008 docs/parts/electronics/sangaboard.md
Revision, date & where cited
openflexure / project contributors · gitlab.com · Accessed Oct 1, 2026
Used for: What you need, Hardware and software versions must agree, Source coverage and untested performance, Source files and licenses - S009 docs/prepare_pi_and_sangaboard.md
Revision, date & where cited
openflexure / project contributors · gitlab.com · Accessed Oct 1, 2026
Used for: Hardware and software versions must agree - S010 docs/printing.md
Revision, date & where cited
openflexure / project contributors · gitlab.com · Accessed Oct 1, 2026
Used for: The selected optical and printed configuration - S011 Current official install guide
Revision, date & where cited
openflexure / project contributors · openflexure.org · Retrieved October 1 2026 · Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Assembly & first use, Hardware and software versions must agree and 2 more - S012 Current official control guide
Revision, date & where cited
openflexure / project contributors · openflexure.org · Retrieved October 1 2026 · Accessed Oct 1, 2026
Used for: Source coverage and untested performance - S015 Upstream image and reuse attribution
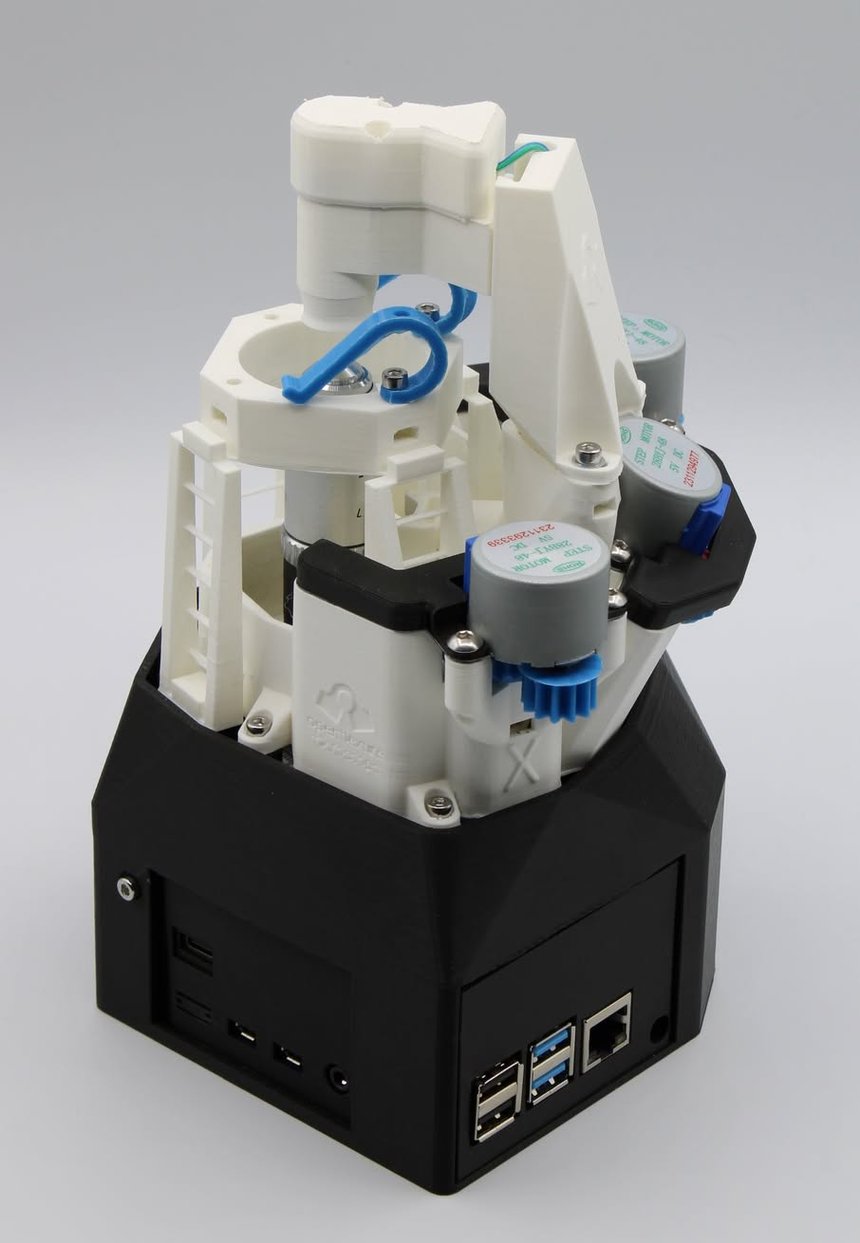
Media-only review: Upstream photograph of an OpenFlexure Microscope v7 configuration; this is a microscopy instrument, not a complete mobile robot. Reuse basis: CC-BY-SA-4.0; inspected the published page, image caption and reuse footer; no image-specific exception found for this selected image. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
OpenFlexure contributors · openflexure.org · Image SHA-256 790833ea98fba054a9cd1bd738cafb011f276c5c573fe5ee6bed79d958ad4042; source revision page SHA-256 d2641a48dfc8c61b4b4733008e548b6a91210ca8b6eca5e80c1c608f9bcd5764 · Accessed Oct 25, 2026
Videos
- S013 OpenFlexure (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel OpenFlexure · youtube.com · Accessed Oct 4, 2026
- S014 Test assembly of new base OpenFlexure Microscope for v7.0-alpha (No Audio) (YouTube video)
Video from the project’s own channel (OpenFlexure), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video OpenFlexure · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 2 YouTube reference(s) (S013, S014): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.