OpenSimpleLidar
Sensor componentDIY triangulation scanning laser rangefinder (STM32F030, TSL1401CL line sensor, 780 nm laser, slip-ring head) rated by its author at 5 scans/s, 2-degree steps and up to 4 m; a sensor component for robots, not a robot. [1] [4] [10]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Electronics builders comfortable with SMD soldering, optical alignment and STM32 programming [5] [10] [11]
- Cost
- USD 23.17 upstream parts estimate [1] [4] · checked Oct 5, 2026 · DetailsNot included: delivery (stated in the sheet), motor pulley (no price; can come from a DVD drive) and small SMD parts and regulator not itemized in TotalBOM and more.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- Ecosystem
- ROS 1
- License
- MIT, MIT (author code); bundled ST library under MCD-ST Liberty V2, MIT (root); BSD header on ROS node files derived from xv_11_laser_driver · license not fully assessed for documentation · Details by part
Overview
OpenSimpleLidar is not a robot. It is an open-hardware 2D scanning rangefinder that a mobile robot could use in place of a purchased LiDAR. Its author reports 5 scans per second, 180 measurements per rotation (2-degree steps), a 4 m maximum distance and roughly 3–5 cm accuracy at 3 m depending on surface colour. These are the author's figures, not catalog measurements. [1]
Is this for you?
- Use cases
- 2D scanning for SLAM (author shows a Hector SLAM map)
- Autonomous robot navigation experiments
- Known limitations
- Author says CommonPCB v1.1M, v1.2 and v1.2M project files and MainPCB v1.1 were not tested
- Each unit needs laser alignment, focusing and its own calibration coefficients
- IR laser eye hazard, higher with the test2 firmware
- ROS integration is a ROS 1 node
- Interference filter optional; performance effect not quantified in inspected sources
- Wiki guidance retrieved separately from the v1.1 release; match not verified
What you need
- Host computer
A host reads scans over UART (USB-UART converter during alignment); the ROS 1 node publishes scans on the host.
- Dependencies
- IAR EWARM 7.50 to rebuild firmware (prebuilt HEX provided)
- STMicroelectronics StdPeriph library (bundled)
- ROS 1 for the roomba_lidar node
- Tools
- Soldering tools for SMD parts
- 3D printer or cutting for holders and base plate
- USB-UART converter
- PC to run the alignment and scan utilities
Hardware & parts
Upstream bill of materials [4]
- Hardware configuration
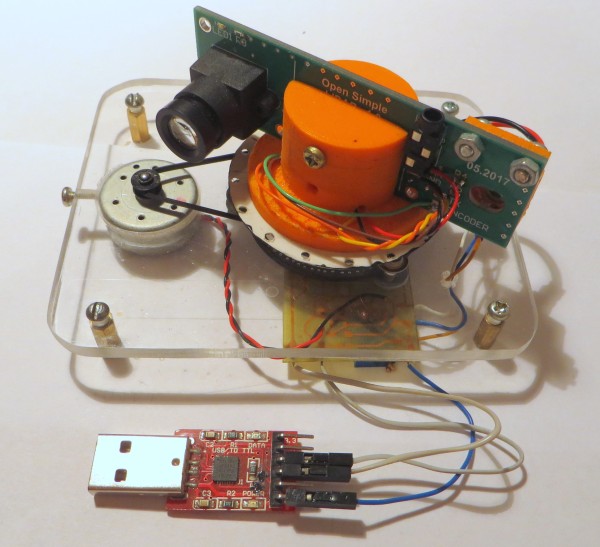
Rotating triangulation laser rangefinder: main PCB with laser and lens spins on a slip ring, belt-driven by a small DC motor (sensor component).
- Actuators
- 3 V DC motor driving the head through a 150 mm rubber belt; pulley can be taken from a DVD drive
- Sensors
- TSL1401CL linear image sensor
- 3 mW 780 nm IR laser diode
- RPI-352 encoder sensor reading an encoder ring
- Dimensions
CommonPCB panel 99 × 26 mm, 1.6 mm thick (split into main and motor boards); overall sensor dimensions not stated
Assembly & first use
Open the upstream getting-started guide [10]
- Order a board variant and populate it (MCU, TSL1401CL sensor, regulator, SMD parts)
- Fit the laser, M12 lens holder, lens and optional filter on the main PCB
- Program the STM32 and run first tests
- Assemble the scanning head on the slip ring, encoder ring, motor and belt
- Align the laser and focus the lens with test firmware and the raw-capture utility
- Calibrate and enter the per-device coefficients in the ROS launch file
Order follows the wiki page list; individual pages beyond alignment and calibration were not preserved.
Cost
| Version | Price |
|---|---|
| OpenSimpleLidar TotalBOM component prices (release v1.1 spreadsheet) | USD 23.17 [1] [4] Parts estimate |
eBay, Taobao, AliExpress and JLCPCB examples; destination unspecified · Checked 2026-10-05
| Included | Laser diode, M12 lens and lens holder; Optional 780 nm interference filter (upper bound only); Main PCB order (price for 10 boards); TSL1401CL sensor and STM32F030F4P6 MCU; Slip ring, 3 V motor, bearing, encoder sensor and belt |
|---|---|
| Not included | Delivery (stated in the sheet); Motor pulley (no price; can come from a DVD drive); Small SMD parts and regulator not itemized in TotalBOM; Printed or cut plastic parts; USB-UART converter, programmer and tools |
| Stock | Supplier links and prices not re-checked; dates not stated. |
| Delivery and tax | Sheet states delivery is excluded; taxes not stated. |
Price details
Lower bound excludes the optional interference filter; upper bound is the spreadsheet SUM total. Currency is not labeled in the sheet; the README says components cost less than $30. Price dates not stated; PCB price is for 10 boards.
eBay, Taobao, AliExpress and JLCPCB examples; destination unspecified · Checked 2026-10-05 · Quantity 1
Unitemized SMD parts, plastic parts, USB-UART converter, programmer, host robot or PC.
Cost scope
The spreadsheet totals 29.17, or 23.17 without the optional 780 nm interference filter, and says delivery is excluded. The README describes this as under $30. The PCB line is the price of a 10-board order, the motor pulley has no price, and small SMD parts, printed parts, the USB-UART converter and a programmer are not itemized. Price dates are not stated. [1] [4]
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
How it works and what you build
The main board carries a 780 nm laser diode, an M12 lens, a TSL1401CL linear image sensor and an STM32F030 microcontroller, and measures distance by triangulation. The board spins on a slip ring, driven by a small 3 V motor and belt, with an RPI-352 sensor reading an encoder ring. Printed STL holders and DXF base-plate and encoder-ring outlines make up the mechanics. [1] [4] [10] [13]
The wiki splits the build into populating the main board, fitting the optics, programming and first tests, assembling the scanning head, laser alignment and focusing, and calibration. Alignment uses test firmware, a USB-UART converter and a PC capture utility to find and sharpen the laser peak; a badly printed laser holder may need filing. Calibration produces per-device coefficients that must be entered in the ROS launch file. The calibration procedure itself is a linked video that was not reviewed. [8] [10] [11] [12]
Which files are tested
This matters before ordering boards. The PCB notes say the author did not test CommonPCB v1.1M, v1.2, v1.2M or MainPCB v1.1. Editable Altium projects exist only for those three CommonPCB variants, all carrying that warning; the split MainPCB v1.0 with MotorPCB v1.0, which the notes do not flag as untested, comes as Gerbers and schematic images. Firmware is STM32 C code with IAR 7.50 projects and prebuilt HEX files. ROS support is a ROS 1 node adapted from xv_11_laser_driver. Repository files were reviewed at release v1.1 from October 2021; later default-branch changes are not covered. The wiki guidance was retrieved separately and the alignment page was edited in May 2026, so its match to the v1.1 files was not verified. [2] [5] [6] [8] [11]
What we checked
Source research only; no installation, physical build, calibration or test performed. Performance figures are author-reported. No affiliate links.
Not yet established
- Requirements: operating system
Updates
- Upstream last updated
- Jul 22, 2025 [2]
- Latest release
- Oct 9, 2021 [2]
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- Release v1.1 (published 2021-10-09), commit b9e5e821971be54b083016067ac54c679cf76682. The default branch was pushed later (2025-07-22); those changes are not covered. · combined hardware and software repository
Source files and licenses
Complete open sensor package (mechanics, PCB, firmware, ROS node, BOM) under an MIT root license with separately licensed vendor and derived files; included as a sensor component in category other, not as a complete robot. Partial because several board revisions are untested by the author and the wiki carries no license.
| Layer | Availability / license |
|---|---|
| mechanical design | available · MIT Four STL parts and DXF base plate and encoder ring; no parametric CAD identified. Root MIT license applies as declared; purchased lens, slip ring, bearing and motor are not covered. [3] [13] |
| electronics | available · MIT Altium projects (SchDoc/PcbDoc) for CommonPCB v1.1M, v1.2 and v1.2M, which the author says were not tested; the tested split MainPCB v1.0 has Gerbers and schematic images only. Gerbers and PCB BOM spreadsheets for each variant. [3] [5] |
| firmware | available · MIT (author code); bundled ST library under MCD-ST Liberty V2 STM32 C source with IAR projects and prebuilt HEX files. Bundled StdPeriph files carry STMicroelectronics terms, separate from the root MIT license. test2 omits the library and points to test1. [3] [6] [7] |
| software | available · MIT (root); BSD header on ROS node files derived from xv_11_laser_driver ROS 1 node and PC utilities; the scan utility is published with source, the raw-capture tool is a prebuilt executable. [3] [8] [9] |
| documentation | available · License not fully assessed README is in the MIT-licensed repository; the separate wiki pages show no license in the inspected text. Calibration instructions are a linked video that was not reviewed. [1] [3] [10] [11] [12] |
Sensor hardware and firmware; no learned models.
No dataset is distributed with the selected release.
Licenses and safety
The repository's LICENSE is MIT. Bundled STMicroelectronics peripheral-library files carry the MCD-ST Liberty V2 license instead, and the ROS parser file carries a BSD header from its original authors. The wiki pages show no license. The firmware notes warn that the test2_capture_image build keeps the IR laser on most of the time and is more dangerous for eyes. Nothing was built, aligned, calibrated or range-tested for this profile. [3] [6] [7] [8]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 OpenSimpleLidar README
Stated scan rate, angular resolution, range, accuracy, component cost claim and triangulation method.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · revision
b9e5e82· README.md at release v1.1 () · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Hardware & parts, Cost and 2 more - S002 Release and repository metadata
Latest stable release, commit, archive checksum, later default-branch push date and dated popularity.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · Release v1.1 (2021-10-09), commit ; GitHub API fields · Accessed Oct 5, 2026
Used for: Is this for you?, Which files are tested, What we checked - S003 iliasam/OpenSimpleLidar: LICENSE
MIT License, copyright 2019 Ilia Samokhin.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · revision
b9e5e82· Accessed Oct 5, 2026
Used for: Source files and licenses - S004 Total bill of materials spreadsheet
Itemized component prices, totals with and without the optional filter, and delivery exclusion.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · revision
b9e5e82· TotalBOM.xlsx, sheet 1 cell values · Accessed Oct 5, 2026
Used for: What you need, Hardware & parts, Cost, How it works and what you build - S005 PCB README and board notes
Board variants, author test status, dimensions and file formats (Altium projects, Gerbers, schematic images, PCB BOMs).Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · revision
b9e5e82· PCB/README.md, board Readme files and PCB folder inventory · Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, Which files are tested, Source files and licenses - S006 Firmware README and source header
Firmware projects, IAR 7.50 build route, prebuilt HEX files and laser-safety warning.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · revision
b9e5e82· Firmware/README.md, Firmware/test2_capture_image/README.md, main.c header · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Which files are tested, Source files and licenses - S007 Bundled STMicroelectronics peripheral library notice
Vendor library under MCD-ST Liberty SW License Agreement V2.Revision, date & where cited
STMicroelectronics (bundled in upstream repository) · github.com · revision
b9e5e82· StdPeriphLib source file header · Accessed Oct 5, 2026
Used for: What you need, Source files and licenses - S008 ROS node notes and source header
ROS 1 node derived from xv_11_laser_driver with BSD header; per-device calibration coefficients required.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · revision
b9e5e82· ROS/Readme.txt, ROS/roomba_lidar/manifest.xml, src/lidar_parser.cpp header · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, How it works and what you build and 2 more - S009 PC utilities README
Raw-capture and scan-display utilities, calibration values and source publication note.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · revision
b9e5e82· Accessed Oct 5, 2026
Used for: Assembly & first use, Source files and licenses - S010 Project wiki home
Component breakdown of scanning head and base, and list of assembly pages.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · Wiki page snapshot sha256 321727ab5724 · Accessed Oct 5, 2026
Used for: What you need, Hardware & parts, Assembly & first use, How it works and what you build and 1 more - S011 Wiki: laser alignment and focusing
Alignment procedure using test firmware, a USB-UART converter and the raw-capture utility.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · Wiki page snapshot sha256 8ce9bd2d2568 (page edited May 23, 2026) · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, How it works and what you build and 2 more - S012 Wiki: lidar calibration
Calibration is the final assembly step; coefficients feed the ROS node; procedure is in a linked video.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · Wiki page snapshot sha256 24e9451a755a · Accessed Oct 5, 2026
Used for: Is this for you?, Assembly & first use, How it works and what you build, Source files and licenses - S013 Mechanics file inventory
STL holders and plates plus DXF base plate and encoder ring.Revision, date & where cited
Ilia Samokhin (iliasam) · github.com · revision
b9e5e82· Mechanics/ archive inventory · Accessed Oct 5, 2026
Used for: What you need, How it works and what you build, Source files and licenses - S014 Upstream image and reuse attribution
Media-only review: Upstream photograph of the OpenSimpleLidar assembly and its electronics. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Ilia Samokhin and OpenSimpleLidar contributors · github.com · revision
b9e5e82· Image SHA-256 0ab6c20025e354eecd9f4334665b5e3856493e2abb9359c7bc57eee6439f30be; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Initial intake profile from release v1.1 sources (Growbotics lead verified against upstream).
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.