Opentrons OT-2
Robot / hardware buildProgrammable laboratory liquid handler with a dedicated OT-2 software route, published customization files and configuration-specific calibration requirements. [8] [10] [12] [15]
Build & first use →Official websiteSource code
- For
- Laboratories and developers matching protocols, pipettes, tips and labware to an OT-2 [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- Apache-2.0 · license not fully assessed for mechanical design, electronics · Details by part
Overview
OT-2 is a programmable laboratory liquid handler. Its documented architecture combines Cartesian motion, two pipette mounts and separately driven plungers. The historical architecture source describes a Raspberry Pi 3 Model B running Linux and a modified Smoothieboard exchanging G-code over UART. These are source-reported architecture details, not a teardown of a current purchased unit. [5]
Is this for you?
- Known limitations
- Current documentation caps OT-2 Protocol API at 2.28
- Hardware customization files do not establish a complete independently fabricable robot
- No physical pipetting or protocol validation performed by this catalog
Source-scoped limitations and editorial review boundary.
3D preview
OT-2 detailed reference model. The complete first-party OT-2 detailed STEP reference model published to support dimensional customization and hardware integration. Its README permits community modification, but the repository provides no identified license or exact reuse terms; this preview records that ambiguity and does not claim manufacturing or redistribution clearance. Internal mechanisms, motion behavior, fabrication readiness and physical fit are not verified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP (gzip) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: The Opentrons Team, revision ef9ede131ed1d64daf9a0df5b2140a0a8e56b632. Original and preview: No repository license identified; first-party README permits community modification but exact reuse terms remain unresolved. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Cartesian laboratory liquid handler with two pipette mounts and separate plunger axes
Assembly & first use
- Calibration
Deck calibration, then tip length for the specific pipette/tip combination, then pipette offset; labware positioning is an additional check.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Use the dedicated OT-2 software route
The shared repository's v9.1.1 app release notes state that OT-2 robots no longer appear in that app. The dedicated OT-2 repository's 26.6.0 notes instead describe an OT-2-specific app and exclude Flex robots. This profile preserves dedicated source commit a5611d1694dbd50463636fb66e6df2af1e4d66a4, a development snapshot rather than a verified installed release. [7] [8] [10] [11]
Official versioning documentation retrieved October 1, 2026 lists OT-2 API support through 2.28 and associates that API level with OT-2 software 26.6.0. The same page lists newer API levels for Flex. A newer general API example therefore does not establish OT-2 compatibility: select an API level supported by the actual robot and check its requirements. [14]
The API package documents local protocol simulation on Windows, macOS and Linux, separately from controlling a real robot. Simulation was not run here, and this source review does not establish liquid-transfer accuracy or successful execution of any laboratory procedure. [6]
Calibration belongs to the actual instrument combination
The official procedure orders deck calibration, tip-length calibration and pipette-offset calibration. Tip length is specific to the physical pipette and tip combination, even between nominally identical pipettes. Deck calibration assumes a level deck; it does not correct a bent or tilted deck. The guide also identifies labware positioning as a separate additional check. [15]
The architecture describes USB communication through an internal Ethernet adapter, not a generic serial command connection. It also notes that the robot server normally owns GPIO access: stopping it for custom scripts interrupts app connectivity until the service restarts. That advanced developer route is distinct from routine app operation. No services were changed or hardware connected for this review. [5]
Hardware files support customization, with explicit gaps
The separate hardware repository publishes board designs, wiring information, a deck DXF and scaled robot models for integrations. Its README frames these as customization resources. The preserved file inventory does not establish a complete manufacturing package or current full bill of materials, and no root hardware license was found. Do not transfer the software repository's Apache license to these mechanical or electrical files. [12] [13]
The dedicated software source is Apache-2.0 licensed. Its app release notes also reference an end-user agreement for installed software; the source license alone does not describe all distribution terms. The motor firmware and Buildroot system are separate dependencies whose complete matched payloads were not collected here. [5] [9] [10]
A current complete configuration price remains unknown: robot, pipettes, tips, labware, optional modules and delivery depend on the chosen setup. No fabrication, installation, calibration, wet-lab protocol or performance test is claimed. [5] [12] [15]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Sep 17, 2026 [11]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- a5611d1694dbd50463636fb66e6df2af1e4d66a4 (dedicated OT-2 commit snapshot); historical architecture source 1fb64381ce23a053768e472065bd14e2c6d4c3a0 · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Published customization files include deck DXF, robot reference models, board designs and wiring documentation. No root hardware license found in the preserved inventory; completeness and reuse terms remain unresolved. Software Apache terms are not assigned to these files. [12] [13] |
| electronics | available · License not fully assessed Published customization files include deck DXF, robot reference models, board designs and wiring documentation. No root hardware license found in the preserved inventory; completeness and reuse terms remain unresolved. Software Apache terms are not assigned to these files. [12] [13] |
| firmware | not found · License not fully assessed Architecture links the separate SmoothiewareOT fork and Buildroot system. A complete matched firmware/build image and its dependency licenses were not preserved in this review; this is not a claim that source is unavailable upstream. [5] |
| software | available · Apache-2.0 Dedicated repository source license. App release notes separately reference an end-user license agreement for installed software; source and distribution terms must not be conflated. [8] [9] [10] |
| documentation | available · Apache-2.0 Repository documentation only; separate website and hardware materials retain their own terms. [8] [9] |
Selected protocol-driven liquid-handling route does not require a learned policy or training dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Opentrons/opentrons: README.md
Revision, date & where cited
github.com · revision
1fb6438· Accessed Oct 1, 2026 - S002 Opentrons/opentrons: commit 1fb6438
Revision, date & where cited
github.com · Accessed Oct 1, 2026
- S003 Opentrons/opentrons: LICENSE
Revision, date & where cited
github.com · revision
1fb6438· Accessed Oct 1, 2026 - S004 Opentrons/opentrons: files
Revision, date & where cited
github.com · revision
1fb6438· archive file inventory · Accessed Oct 1, 2026 - S005 OT2_ARCHITECTURE.md
Revision, date & where cited
github.com · revision
1fb6438· Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Calibration belongs to the actual instrument combination and 2 more - S006 api/README.rst
Revision, date & where cited
github.com · revision
1fb6438· Accessed Oct 1, 2026
Used for: Use the dedicated OT-2 software route - S007 app-shell/build/release-notes.md
Revision, date & where cited
github.com · revision
1fb6438· Accessed Oct 1, 2026
Used for: Use the dedicated OT-2 software route - S008 Dedicated OT-2 README.md
Revision, date & where cited
github.com · revision
a5611d1· Accessed Oct 1, 2026
Used for: Use the dedicated OT-2 software route, Source files and licenses - S009 Dedicated OT-2 LICENSE
Revision, date & where cited
github.com · revision
a5611d1· Accessed Oct 1, 2026
Used for: Hardware files support customization, with explicit gaps, Source files and licenses - S010 Dedicated OT-2 app-shell/build/release-notes.md
Revision, date & where cited
github.com · revision
a5611d1· Accessed Oct 1, 2026
Used for: What you need, Use the dedicated OT-2 software route, Hardware files support customization, with explicit gaps, Source files and licenses - S011 Dedicated OT-2 snapshot receipt
Revision, date & where cited
github.com · revision
a5611d1· Accessed Oct 1, 2026
Used for: Use the dedicated OT-2 software route, What we checked - S012 OT-2 hardware customization overview
Revision, date & where cited
github.com · revision
ef9ede1· Accessed Oct 1, 2026
Used for: Is this for you?, Hardware files support customization, with explicit gaps, Source files and licenses - S013 OT-2 hardware archive inventory
Revision, date & where cited
github.com · revision
ef9ede1· complete file inventory · Accessed Oct 1, 2026
Used for: Is this for you?, Hardware files support customization, with explicit gaps, Source files and licenses - S014 Current official OT-2 versioning
Revision, date & where cited
Opentrons / project contributors · docs.opentrons.com · Retrieved October 1 2026; current documentation distinct from pinned historical source · Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Use the dedicated OT-2 software route - S015 Current official OT-2 calibration
Revision, date & where cited
Opentrons / project contributors · docs.opentrons.com · Retrieved October 1 2026; current documentation distinct from pinned historical source · Accessed Oct 1, 2026
Used for: What you need, Assembly & first use, Calibration belongs to the actual instrument combination, Hardware files support customization, with explicit gaps - S017 Upstream image and reuse attribution
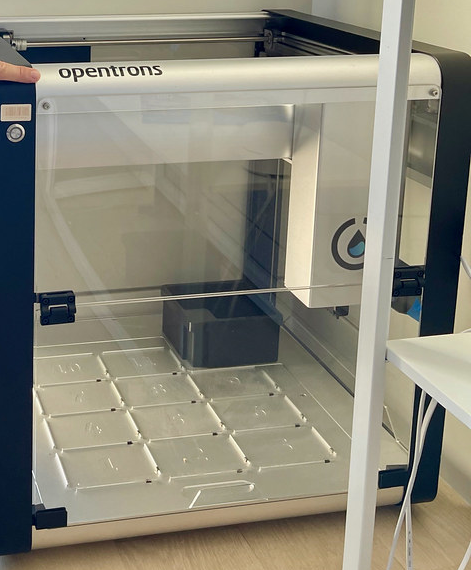
Media-only review: Historical photograph of an Opentrons OT-2 in 2021, cropped to the machine. Pipette generation and installed software are not identified by the photo. Reuse basis: CC-BY-2.0. Full photograph and crop visually inspected. The machine has the OT-2 blue rectangular front frame, transparent front door, white single gantry cover, numbered removable deck slots and rear waste bin, matching the OT-2 enclosure represented in Figure 5(D) of the separately preserved 2023 Frontiers study DOI 10.3389/fbioe.2023.1202836. This model identification is a visual inference supported by the photographer’s original Opentrons lab context and 2021 capture date. It is not the separate 2014 Maker Faire prototype photo 51513082253 or the later Flex. The existing record covers the OT-2 platform and software snapshot, without choosing one pipette generation. Caption explicitly limits the photo to historical 2021 hardware appearance; no claim it shows the reviewed software commit, current pipettes or an unchanged exact internal revision. Crop removes most of the person, retains robot; no retouching. Unrelated renderer/plate-holder figures are not used. Cropped to isolate the historical OT-2 machine from the original portrait from the source image; no retouching. Full original retained. Technical/cost evidence dates unchanged.Revision, date & where cited
Steve Jurvetson · flickr.com · Flickr photo 51513787140, Congratulations to Opentrons on their $200M round on a $1.8B valuation; actual photo-license-info link CC BY 2.0; capture date 2021-07-09; image SHA-256 953221c15683bfc5a81c4e479e68eda6aa383c242667a1ae941a6c7af6700057 · Accessed Oct 26, 2026
Videos
- S016 Opentrons Labworks (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Opentrons Labworks · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S016): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.