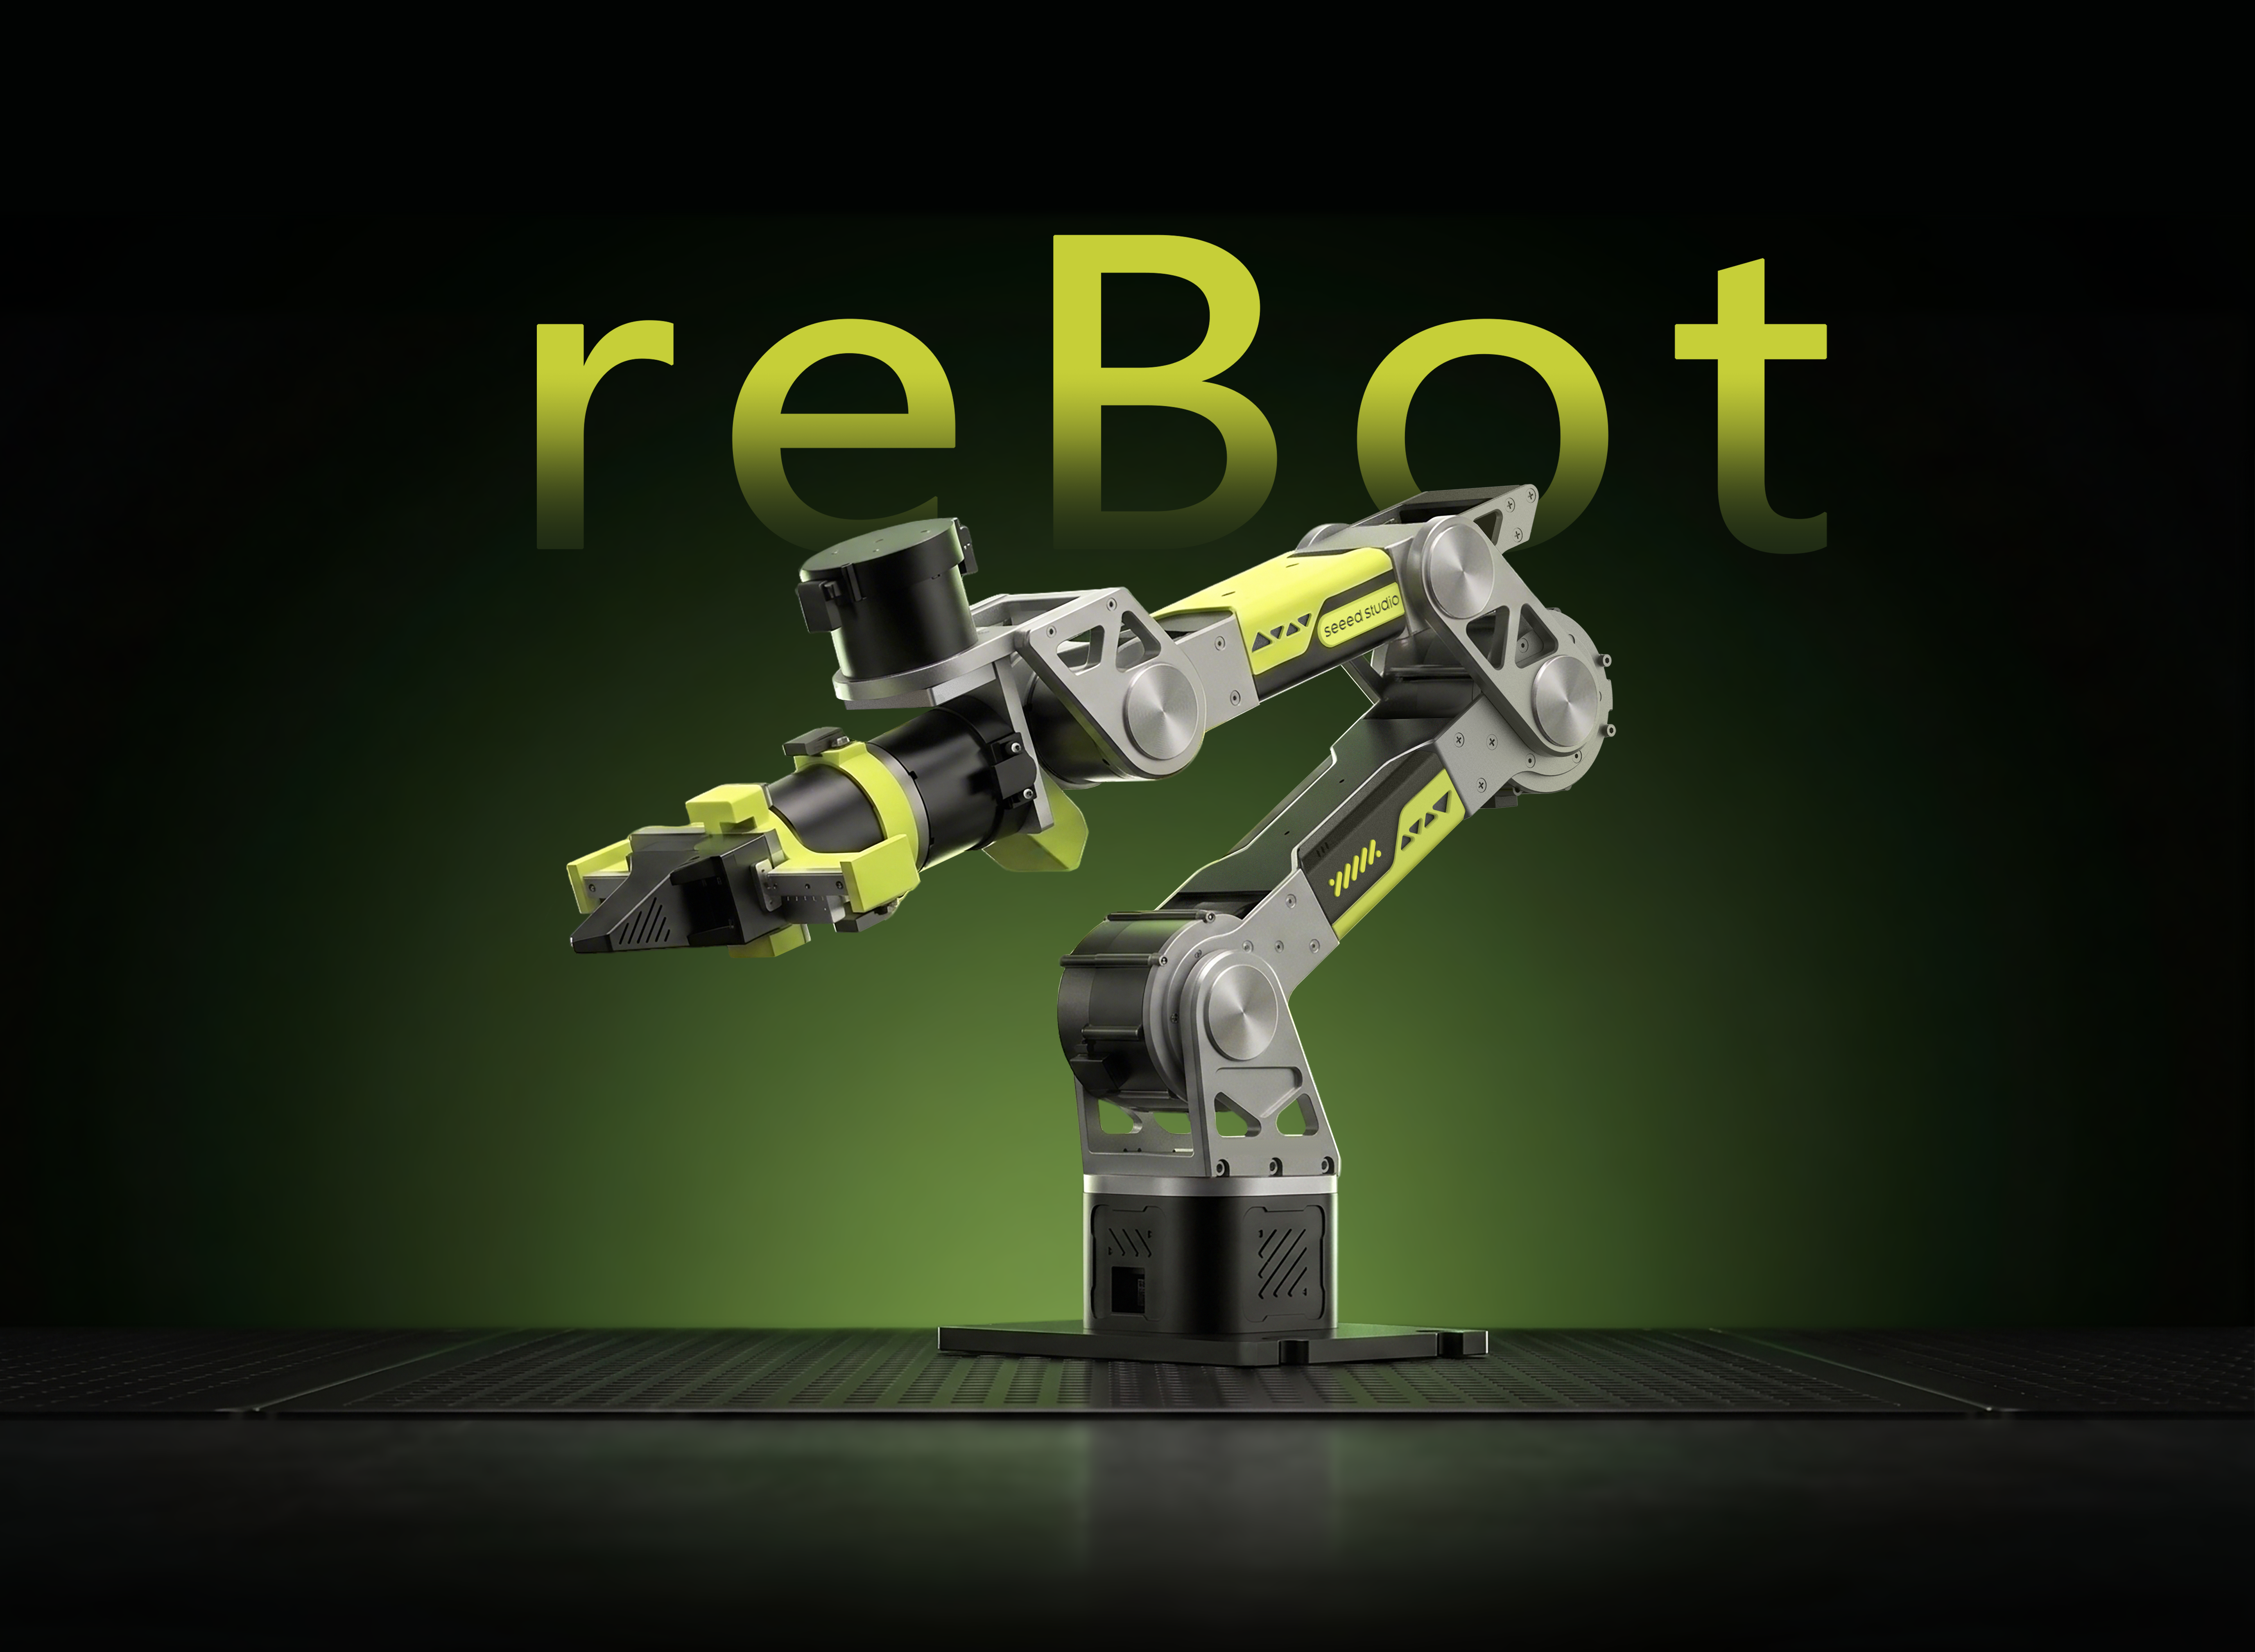
reBot Arm B601
Robot / hardware buildSeeed Studio 6+1 DoF desktop arm with CNC aluminium and printed parts, published as B601-DM (Damiao motors, 24 V) and B601-RS (RobStride motors, 48 V) under CERN-OHL-W-2.0 hardware terms. [1] [4] [5]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Developers and labs able to source CNC metal parts and CAN-bus motors, or buy Seeed kits, and work with ROS 2, LeRobot or Python control [1] [4]
- Cost
- USD 1,436.40 vendor price [11] · checked Oct 5, 2026 · DetailsNot included: power adapter kit (listed at US$64.99), clamps and leader arm (Star Arm 102 listed at US$240.00) and more.
- Source rights
- Some licenses are unresolved. Review licenses
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CERN-OHL-W-2.0 · license not fully assessed for software · Details by part
Overview
Seeed Studio's reBot-DevArm repository publishes two arms with the same appearance: the B601-DM with Damiao motors and the B601-RS with RobStride motors. This entry treats the B601-DM v1.1 BOM as the reviewed configuration and notes where the RS differs. Seeed sells kits and preassembled arms, and the repository supplies STEP files, BOMs and assembly notes for building one. This is source research only; nothing was built, powered or tested. [1] [4] [5]
Is this for you?
- Use cases
- Teleoperation with a leader arm
- LeRobot training workflows
- Isaac Sim simulation
- Depth-camera grasping demos
- ROS 2 kinematics and trajectory planning
- Known limitations
- Published BOM is not Seeed's shipping version
- Motor #2 overheating limits sustained load per vendor test
- No published BOM total
- Software guides hosted on an uninspected wiki
- Full repository not archived (size limit)
- Course steps and reported B601-RS deployment are source-documented, not reproduced by OSR.
- Optional simulation datasets do not establish successful transfer to a physical B601.
- The linked Isaac Sim package has unresolved rights for some bundled scene assets.
- Optional Isaac Sim data is LeRobot v3 with front/external camera keys, while the linked JetPack offline route accepts v2/v2.1 with front/side keys; conversion and checkpoint metadata need verification.
- The course physical-data chapter conflicts on display setting and emergency-stop ordering; obtain safe operating clarification before following it.
Existing limitations retained; new RS workflow limitations checked today.
What you need
- Operating system
- Ubuntu for the course's Isaac Sim 6.1 workstation
- JetPack 7.2 / L4T R39.2 on the linked AGX Orin TensorRT route
Specific software workflow requirements, not a blanket B601 hardware limit.
- Host computer
For the documented B601-RS course path: Ubuntu workstation with NVIDIA RTX GPU (at least 12 GB VRAM for Isaac Sim 6.1); Jetson AGX Orin running JetPack 7.2 for the linked TensorRT deployment route. Training and complete system costs are additional. The linked Orin adaptation recommends reserving 45–50 GB storage and uses separate Python 3.12 TensorRT and Python 3.10 robot-client environments.
Applies to the cited RS course/deployment configuration, not every B601 use.
- Dependencies
- motorbridge >= 0.4.9 and Pinocchio (pin) for the Python control package
- Python 3.10 to 3.11 for reBotArm_control_py
- Tools
- Hex key set
- Hot-melt glue for thread locking
- Crimping for the AC wiring of the suggested power enclosure
Hardware & parts
Upstream bill of materials [4]
- Hardware configuration
Desktop serial arm, 6 DOF plus a rack-driven parallel gripper on an MGN9 rail.
- Actuators
- B601-DM: 4× Damiao DM4310 (V4) and 3× DM4340P (V4)
- B601-RS: 4× RobStride RS00 and 3× RS06
- Controller
CAN-USB driver board connected to a host computer; optional Jetson edge controllers suggested
- Sensors
- No arm sensors beyond motor feedback listed; optional wrist depth or UVC cameras via printed mounts
Cameras are optional accessories.
- Power
B601-DM DC 24 V (Mean Well LRS-350-24 suggested); B601-RS DC 48 V (LRS-600-48 suggested); no supply included
- Degrees of freedom
6
README: 6 DOF + 1 gripper.
- Dimensions
Max reach 767 mm (DM) / 754 mm (RS); weight about 4.5 kg (DM) / 6.7 kg (RS); payload 1.5 kg / 2.5 kg (upstream)
Assembly & first use
Open the upstream getting-started guide [1] · Project documentation [1]
- Choose DM or RS hardware and supply before following a software guide.
- For the cited RS path, mount and calibrate the B601 follower and 102 leader, then verify teleoperation and camera mapping.
- Collect real demonstrations before training and evaluating GR00T; optional Isaac Sim collection can supplement data.
- For JetPack 7.2 Orin deployment, build device-specific TensorRT engines and validate offline before robot actuation.
Cited workflow sequence; OSR did not execute it.
Cost
| Version | Price |
|---|---|
| reBot Arm B601-DM unassembled kit with gripper (motor, structure and gripper kits) | USD 1436.40 [11] Vendor price |
Not determined (page lists CN, US and DE warehouses) · Checked 2026-10-05
| Included | Body motor kit; Body structure kit; Gripper kit |
|---|---|
| Not included | Power adapter kit (listed at US$64.99); Clamps; Leader arm (Star Arm 102 listed at US$240.00); Cameras and host computer; Shipping, duties and taxes |
| Stock | Stock state not established from the static page. |
| Delivery and tax | Store page notes duties/taxes may apply on DAP shipments; delivered total not established. |
Price details
Sum (our arithmetic) of three component prices shown on the preserved static store page: body motor kit US$994.80, body structure kit US$202.80, gripper kit US$238.80. Default warehouse/region and stock not determined; dynamic selections not executed.
Not determined (page lists CN, US and DE warehouses) · Checked 2026-10-05 · Quantity 1
Power supply, host computer; leader arm for teleoperation.
Cost scope
No BOM total is published. At the listed reference prices the seven DM motors alone come to US$1,005 (our arithmetic), before metal, prints, bearings and power. The preserved Seeed store page lists a DM body motor kit at US$994.80, body structure kit at US$202.80, gripper kit at US$238.80 and power adapter kit at US$64.99; the page's default warehouse and stock state were not established. [4] [11]
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
Published specifications and Seeed's own tests
The README lists, for the DM and RS respectively: 1.5 kg and 2.5 kg payload, 767 mm and 754 mm maximum reach, about 4.5 kg and 6.7 kg arm weight, under 0.2 mm repeatability, 6 DOF plus a gripper, and DC 24 V and 48 V supply. [1]
Seeed's performance document for the DM with Damiao V4 motors reports that its tests stopped on motor #2 overheating. With 1.5 kg, reciprocating motion over 5 to 70% of reach ran more than two hours before a manual stop, while static holds triggered overheat protection after 18 minutes at 70% extension and 3 minutes at full extension. It recommends 1.5 kg or less, under 70% of reach, active cooling, and a 10 to 15 minute rest after two hours. The document equates 70% with 450 mm, which does not match 70% of the README's 767 mm reach; that basis is unresolved. These are the vendor's results, not catalog measurements. [1] [6]
What a DM builder must source
The v1.1 BOM lists printed ABS and PLA parts (reference average US$50), CNC-machined 5052 aluminium parts (reference average US$250, some printable to cut cost), four DM4310 (V4) motors at US$120 and three DM4340P (V4) motors at US$175 as reference prices, a CAN-USB board, bearings, an MGN9 rail, a gear and many screws. Screws need hot-melt glue as a thread lock. The arm ships without a power supply; the BOM proposes a Mean Well LRS-350-24 in a printed enclosure, with AC wiring the builder crimps. Seeed warns that this BOM is not its shipping version. [4]
Check file versions before fabricating: the DM file list names reBot_B601_DM_v1.1_20260415.step, while the changelog and repository tree show 20260425 and 20260625 assembly files. The RS BOM swaps in four RS00 and three RS06 motors (US$125 and US$210 reference) and a 48 V LRS-600-48 supply. [4] [5] [8]
An RS-specific learning route now has concrete prerequisites
The Seeed-hosted course starts with a B601-RS follower and reBot Arm 102 leader, camera mapping, calibration and real demonstration collection. Its Isaac Sim 6.1 chapter is explicitly optional and recommends an Ubuntu RTX workstation with at least 12 GB of VRAM. The simulation project records leader-guided B601 scenes as LeRobot v3 episodes; this is a way to collect and inspect simulated data, not a measured transfer result on the physical arm. These requirements describe the RS course setup and should not be applied to the DM motor/bridge configuration without checking the DM guide. [12] [13] [14]
The course's physical-data chapter conflicts with itself: its example enables display while its checklist says to disable it, and its emergency-stop steps give different power-cut ordering. Seek clarification from Seeed and establish a safe stop procedure for the actual workcell before operating the arm; this profile does not resolve that safety instruction. [12]
The linked JetPack 7.2 project targets Jetson AGX Orin with a Python 3.12 TensorRT environment and a separate, tested Python 3.10 B601-RS client environment. Its authors recommend reserving 45–50 GB for the checkpoint, backbone, dataset, ONNX files, engines and temporary files. The project supplies TensorRT export, offline evaluation, a policy server and client, and its README reports a short powered run in a named configuration. Open Source Robotics has not reproduced that run or the earlier collection and training steps. [15]
The optional simulation path records LeRobot v3 episodes and uses front/external camera streams; the JetPack offline example accepts v2/v2.1 data and front/side keys. The course notes a camera-key change for GR00T training. Conversion, key mapping and checkpoint metadata must be reconciled before treating these sources as a connected dataset-to-robot pipeline. [13] [14] [15]
The LICENSE file contains CERN-OHL-W 2.0. The README assigns CERN-OHL-W-2.0 to hardware and Apache-2.0 to "Firmware Code", yet no Apache text file or firmware source was identified in the repository tree. It also says the project used a non-commercial CC BY-SA NC license for its first five months and switched to CERN-OHL-W on May 11, 2026, so earlier copies carried different terms. OSHWA lists certification CN000024, dated May 14, 2026. [1] [3] [8] [9]
The B601 hardware repository exceeded the 150 MiB intake limit in the original review, so only selected documents and the file tree were preserved; its STEP geometry was not inspected. The original reviewed hardware commit was 5d1aef6 of October 5, 2026. This update checked linked RS workflow sources at separate pinned revisions; it did not refresh every original hardware or price claim. [2] [8] [12] [15]
What we checked
Source research only; no installation, simulation launch, training, TensorRT build, physical build or performance test performed. Store prices are historical preserved-page values, not a purchase. No affiliate links or reused media. AI-assisted drafting with a separate LLM editorial judge; no independent human technical review.
Updates
- Upstream last updated
- Oct 5, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 21, 2026
- Next review
- Nov 21, 2026
- Reviewed revision
- 5d1aef60c6f4843217776b2c1290801fdd22b485 (commit snapshot; no published release; B601-DM hardware BOM v1.1, B601-RS v1.0) · repository
Source files and licenses
CERN-OHL-W-2.0 hardware files, BOMs and URDFs are published; firmware source and a licensed software repository were not identified, and the full archive could not be preserved.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-W-2.0 STEP part and assembly files for DM and RS in the repository tree; full archive not preserved (size) and geometry not inspected. Earlier revisions were under CC BY-SA NC per README. [1] [3] [8] [9] |
| electronics | not found · License not fully assessed Purchased motors with built-in drivers, CAN-USB board and harnesses; no custom electronics design files identified in the tree. [4] [8] |
| firmware | not found · License not fully assessed README assigns Apache-2.0 to "Firmware Code", but no firmware source was identified in the repository tree; motors run vendor firmware. [1] [8] |
| software | available · License not fully assessed Original Pinocchio control package remains separately scoped. Newly inspected Isaac Sim project has MIT terms for project-authored code, and the JetPack GR00T adaptation has Apache-2.0 code; neither license applies to the B601's purchased motor firmware, external model weights or all scene assets. [1] [10] [14] [15] |
| documentation | available · CERN-OHL-W-2.0 Repository BOM and specification documents; OSHWA lists documentation under CERN-OHL-W-2.0. Wiki documentation not inspected. [1] [9] |
No trained policy weights distributed in the inspected sources.
No dataset distributed in the inspected sources.
Software and licensing boundaries
The roadmap marks ROS 2, LeRobot, Isaac Sim and Pinocchio integrations as done. The preserved Pinocchio control repository requires Python 3.10 to 3.11 and motorbridge; no license file was identified in it. URDF and STL meshes are provided, without a complete MuJoCo scene. The newly inspected Isaac Sim and JetPack repositories are separate software projects with their own scopes and licenses; neither makes the motor firmware or external model weights open by association. The Isaac Sim package also bundles robot, camera-mount, stationery and workspace assets whose redistribution terms require separate review; some remain unresolved. [1] [7] [10] [14] [15]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 reBot-DevArm README
Two arm models, store links, roadmap/status, hardware specification table, optional hardware, license section.Revision, date & where cited
Seeed Studio / reBot-DevArm contributors · github.com · revision
5d1aef6· README.md at ; preserved snapshot sha256 c9e1cd73ee84… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 3 more - S002 Seeed-Projects/reBot-DevArm: commit 5d1aef6
No published release; archive blocked by the 150 MiB intake limit; dated repository popularity.Revision, date & where cited
Seeed Studio / reBot-DevArm contributors · github.com · ; commit date 2026-10-05T05:48:28Z; manifest retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Is this for you?, An RS-specific learning route now has concrete prerequisites, What we checked - S003 Repository LICENSE file
CERN-OHL-W 2.0 license text.Revision, date & where cited
Seeed Studio / reBot-DevArm contributors · github.com · revision
5d1aef6· LICENSE; preserved snapshot sha256 e258a9c6833b… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: An RS-specific learning route now has concrete prerequisites, Source files and licenses - S004 reBot Arm B601-DM hardware specification and BOM
Version table, printed, CNC and purchased parts with reference prices, power supply option and warnings.Revision, date & where cited
Seeed Studio / reBot-DevArm contributors · github.com · revision
5d1aef6· hardware/reBot_B601_DM/readme.md; preserved snapshot sha256 1a7bf885b42a… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S005 reBot Arm B601-RS hardware specification and BOM
RS version table, motors and power supply with reference prices.Revision, date & where cited
Seeed Studio / reBot-DevArm contributors · github.com · revision
5d1aef6· hardware/reBot_B601_RS/README.md; preserved snapshot sha256 0573cd1132d6… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Overview, Hardware & parts, What a DM builder must source - S006 reBot Arm B601-DM performance testing reference
Seeed's dynamic and static load tests, termination reasons and usage recommendations.Revision, date & where cited
Seeed Studio / reBot-DevArm contributors · github.com · revision
5d1aef6· Performance_Testing.md (v1.0, 2026.04.01); preserved snapshot sha256 aca81d5e96e6… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Is this for you?, Published specifications and Seeed's own tests - S007 reBot Arm mechanical description package
URDF and STL meshes for RS and DM; no complete MJCF scene.Revision, date & where cited
Seeed Studio / reBot-DevArm contributors · github.com · revision
5d1aef6· Rebot_Arm_description/README.md; preserved snapshot sha256 b2957dd49964… of the pinned raw file (full repository archive blocked by size) · Accessed Oct 5, 2026
Used for: Source files and licenses - S008 Repository file tree at the reviewed commit
Hardware STEP, URDF/mesh, media and community files; no firmware or software source files.Revision, date & where cited
Seeed Studio / reBot-DevArm contributors · github.com · revision
5d1aef6· GitHub git/trees API, recursive, 470 entries, not truncated; filenames and sizes only · Accessed Oct 5, 2026
Used for: What a DM builder must source, An RS-specific learning route now has concrete prerequisites, Source files and licenses - S009 OSHWA certification CN000024
Certification date, version and declared hardware, software and documentation licenses.Revision, date & where cited
Open Source Hardware Association (certification listing for Seeed Studio) · certification.oshwa.org · Certification page snapshot sha256 6154545aaad1… · Accessed Oct 5, 2026
Used for: An RS-specific learning route now has concrete prerequisites, Source files and licenses - S010 reBotArm_control_py repository
Pinocchio/motorbridge control package metadata; no license file identified in the archive.Revision, date & where cited
Seeed Studio / reBotArm_control_py contributors · github.com · revision
6415d43· README.md, pyproject.toml and archive filenames at (commit snapshot; archive sha256 9c482aa3557b…) · Accessed Oct 5, 2026
Used for: What you need, Source files and licenses - S011 Seeed Studio reBot Arm B601-DM bundle store page
Kit component prices as rendered in the static page; warehouse, region and stock state not determined.Revision, date & where cited
Seeed Studio · seeedstudio.com · Store page snapshot sha256 0d038f7ef0eb… retrieved 2026-10-05; static HTML, default selection · Accessed Oct 5, 2026
Used for: Cost - S012 Seeed-hosted reBot course: real collection and training
RS hardware/camera collection route and LeRobot setup; course content examined at pinned revision.Revision, date & where cited
Seeed-hosted reBot course contributors · github.com · revision
5d094c0· 03_Get_Your_Own_VLA_Model/01_Collect_Data_from_Real_Env.md at · Accessed Oct 21, 2026
Used for: Is this for you?, Assembly & first use, An RS-specific learning route now has concrete prerequisites - S013 Optional reBot Isaac Sim course chapter
Explicitly optional B601 simulation collection, 102 leader, Isaac Sim 6.1 and RTX 12 GB VRAM requirement.Revision, date & where cited
Seeed-hosted reBot course contributors · github.com · revision
5d094c0· 03_Get_Your_Own_VLA_Model/04_Collect_Data_from_Isaac_Sim.md at · Accessed Oct 21, 2026
Used for: Is this for you?, What you need, Assembly & first use, An RS-specific learning route now has concrete prerequisites - S014 B601 simulation project README and rights
Two scenes, LeRobot v3 recording, optional mock leader and GPU requirements; linked assets have separate rights.Revision, date & where cited
Seeed-Projects contributors · github.com · revision
865d8b3· README.md at · Accessed Oct 21, 2026
Used for: Is this for you?, What you need, An RS-specific learning route now has concrete prerequisites, Source files and licenses - S015 JetPack 7.2 GR00T adaptation and B601 client
Orin full TensorRT workflow, seven engines and separately configured B601-RS client.Revision, date & where cited
jjjadand contributors · github.com · revision
dcf5f6b· README.md at · Accessed Oct 21, 2026
Used for: Is this for you?, What you need, Assembly & first use, An RS-specific learning route now has concrete prerequisites and 1 more - S016 Upstream image and reuse attribution
Media-only review: Upstream illustration of the reBot arm, not a photograph of a tested build. Reuse basis: CERN-OHL-W-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Seeed Studio and reBot-DevArm contributors · github.com · revision
5d1aef6· Image SHA-256 c381ae6c1f5a3bb29d1cfa87e5982c1a64a51e9df530623a58a395f9ec01a826; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Created from Growbotics-listing lead; all claims checked against preserved upstream sources. No physical build or test.
2026-10-21 — Added pinned B601-RS course, Isaac Sim and JetPack 7.2 deployment context; prior DM/RS hardware and cost claims retained.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.