Robonine SO-ARM 102
Robot / hardware buildPrintable leader–follower robot arms for LeRobot teleoperation, with mixed-voltage serial servos and a parallel gripper. [1]
Build & first use →Official websiteSource codeUpstream build guideBill of materials
- For
- Robot builders researching desktop leader–follower arm pair. [1]
- Cost
- No current cost yet. Upstream bill of materials [1] [2]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CERN-OHL-P-2.0, Apache-2.0, CC BY 4.0 · Details by part
Overview
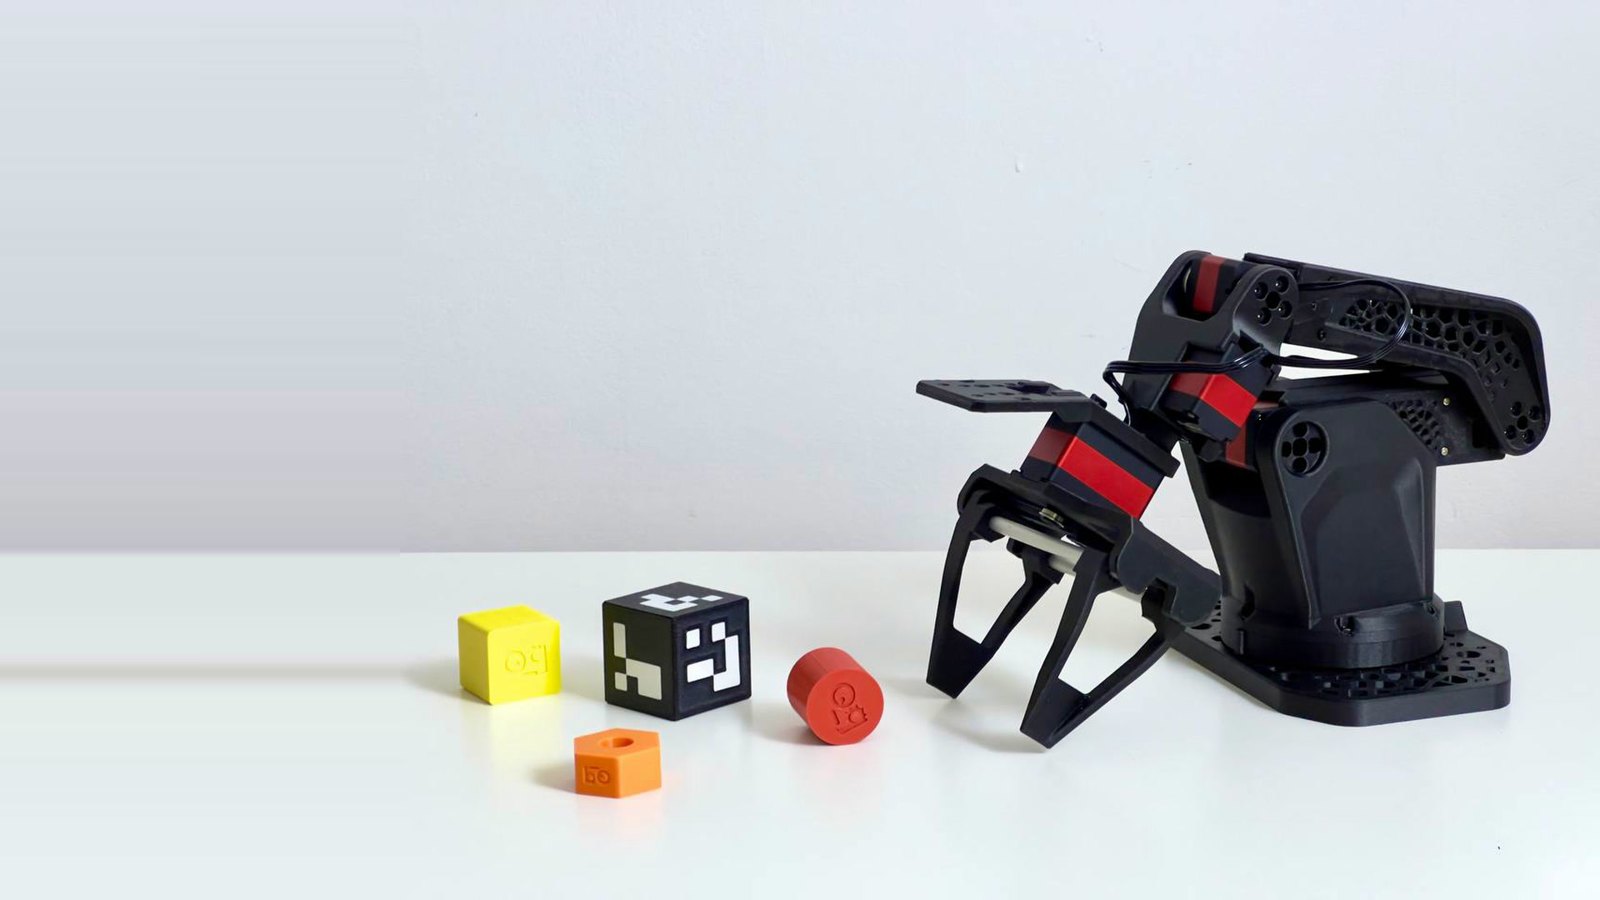
One teleoperation station pairs a hand-guided leader with a powered follower. Robonine supplies STEP, STL and 3MF files. Individual parts fit a 180 × 180 mm bed. The supplied plate layouts use a 256 × 256 mm bed. The layouts specify PET-CF for the follower links, PETG-CF for its base and gripper, and PLA+ for the leader. [1] [2]
Both arms use Waveshare Bus Servo Adapters. The leader uses the 7.4 V model of the STS3215 servo and runs on a 5 V, 2 A supply. Robonine recommends 12 V at 5 A or greater for the follower. The listed supply connectors are 5.5 × 2.1 mm. Verify servo placement and keep the two supplies matched to their arms. For LeRobot, the documented pairing uses the SO-ARM 102 follower plugin with the standard so101_leader type. Robonine links servo ID and calibration instructions from its setup section. [1] [2]
Robonine estimates $342.40 for the listed components and $388.40 including the quantities of filament used, according to its README. The detailed BOM’s filament line costs add to $32.70, while the published filament subtotal is $46.00. Reconcile that difference before using the headline estimate to plan a purchase. Buying the example full packs and spools is about $430. The estimates exclude shipping, tax, tools, a computer, a printer, electricity and labor. The project licenses its hardware designs under CERN-OHL-P-2.0, software under Apache-2.0, and documentation and images under CC BY 4.0. This source review did not verify print fit, current supplier pricing or physical operation. [1] [2] [3]
Is this for you?
- Known limitations
- A delivered price, print tolerances and physical operation remain unverified. Purchased servo firmware has separate terms.
Scoped to the inspected sources and verification performed.
[1] · Editorial assessment
Hardware & parts
Upstream bill of materials [1] [2]
- Hardware configuration
Desktop leader–follower arm pair
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The upstream design is linked below. An interactive preview has not been prepared for this profile.
Model sources
The upstream design is linked below. An interactive preview has not been prepared for this profile.
What we checked
Source review only. No physical build or runtime test. Image credited to upstream.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Nov 15, 2026
- Sources last checked
- Nov 15, 2026
- Next review
- Dec 15, 2026
- Reviewed revision
4325279
Source files and licenses
Includes a documented physical robot design with scope and reuse terms described by artifact.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-P-2.0 No separately licensed implementation located for this layer in the reviewed sources. [1] |
| electronics | not found · License not fully assessed No separately licensed implementation located for this layer in the reviewed sources. [1] |
| firmware | not found · License not fully assessed No separately licensed implementation located for this layer in the reviewed sources. [1] |
| software | available · Apache-2.0 No separately licensed implementation located for this layer in the reviewed sources. [1] |
| documentation | available · CC BY 4.0 No separately licensed implementation located for this layer in the reviewed sources. [1] |
This entry scopes the physical robot and its build documentation.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 roboninecom/SO-ARM102 README.md
Revision, date & where cited
Robonine · github.com · revision
4325279· README.md at · Accessed Nov 15, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S002 roboninecom/SO-ARM102 docs/bom.md
Upstream docs/bom.md for this project.Revision, date & where cited
Robonine · github.com · revision
4325279· docs/bom.md at · Accessed Nov 15, 2026
Used for: Overview, Hardware & parts - S003 roboninecom/SO-ARM102 LICENSING.md
Upstream LICENSING.md for this project.Revision, date & where cited
Robonine · github.com · revision
4325279· LICENSING.md at · Accessed Nov 15, 2026
Used for: Overview
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-11-15 — Initial source-reviewed hardware profile and attributed upstream image.