RoboParty RP1
Robot / hardware buildBipedal humanoid with released SolidWorks source, board fabrication data and separate control and simulation repositories. [1]
Build & first use →Official websiteSource codeUpstream build guideBill of materials
- For
- Robot builders researching full-body bipedal humanoid. [1]
- Cost
- No current cost yet. Upstream bill of materials [1] [2]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

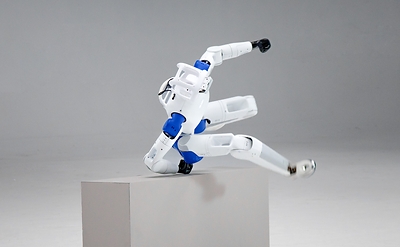
View RoboParty’s photo of the RP1 vaulting a block. [7]
Licenses & related hardware
- License
- CERN-OHL-W-2.0, CC BY-SA 4.0 · license not fully assessed for firmware, software · Details by part
Overview
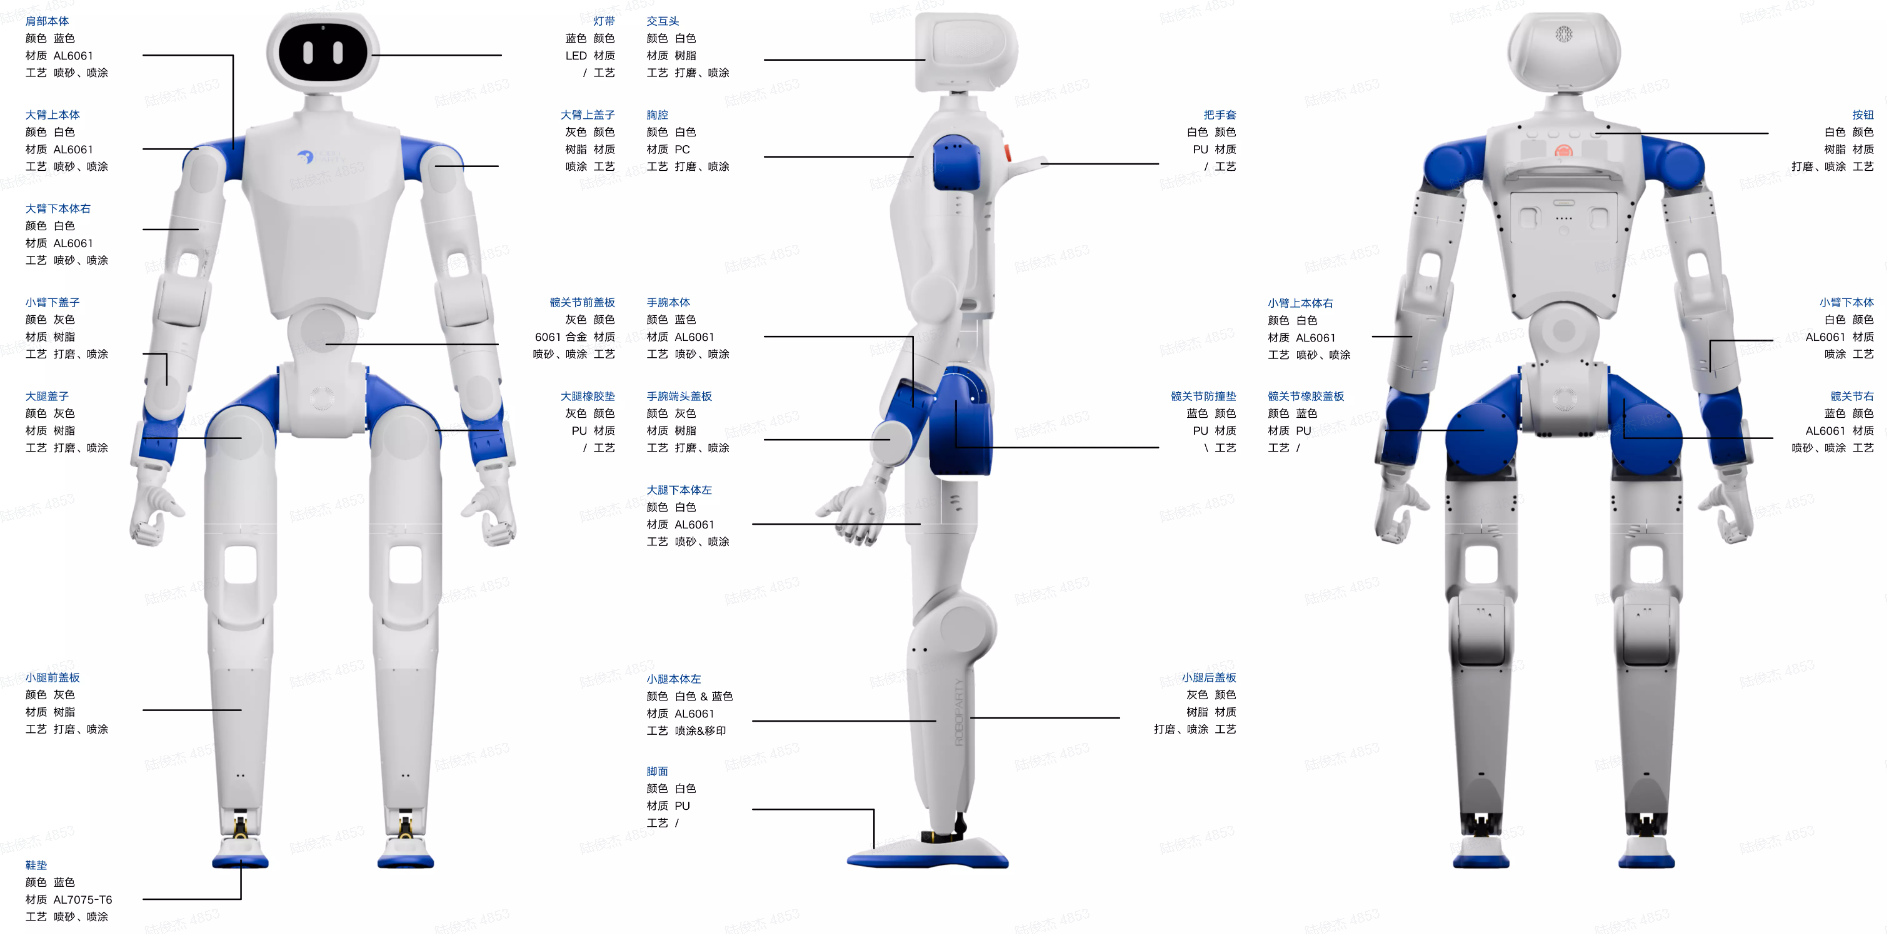
Start with the RP1.3.4 BOMs for the 5DOF + MotionHead or 7DOF + MotionHead configuration. The hardware repository lists native SolidWorks parts and assemblies, a Parasolid model, editable drawings, board production files and harness drawings. Keep the CAD, BOM and control configuration aligned before sourcing machined parts or boards. [1] [2] [4] [5]
RoboParty licenses its own manufacturing design files under CERN-OHL-W-2.0 and explanatory images and documentation under CC BY-SA 4.0. Third-party files retain their original terms. The platform index points to separate robot-description, deployment and firmware repositories. The ROMOMO repository supplies joint drawings, protocol documentation and reports. Complete joint-controller source coverage and compatibility with a particular RP1.3.4 build remain unverified. [3] [5] [6]
Is this for you?
- Known limitations
- A complete current cost, actuator firmware coverage and a matched hardware and control build remain unverified.
Scoped to the inspected sources and verification performed.
[1] · Editorial assessment
Hardware & parts
Upstream bill of materials [1] [2]
- Hardware configuration
Full-body bipedal humanoid
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The upstream design is linked below. An interactive preview has not been prepared for this profile.
Model sources
The upstream design is linked below. An interactive preview has not been prepared for this profile.
What we checked
Source review only. No physical build or runtime test. Image credited to upstream.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Nov 15, 2026
- Sources last checked
- Nov 15, 2026
- Next review
- Dec 15, 2026
- Reviewed revision
471bebd
Source files and licenses
Includes a documented physical robot design with scope and reuse terms described by artifact.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-W-2.0 No separately licensed implementation located for this layer in the reviewed sources. [1] [3] |
| electronics | available · CERN-OHL-W-2.0 No separately licensed implementation located for this layer in the reviewed sources. [1] [3] |
| firmware | available · License not fully assessed Platform firmware and joint-module documentation are listed. Complete joint firmware coverage remains unverified. [5] [6] |
| software | available · License not fully assessed Platform index links separate control and simulation repositories with repository-specific terms. [5] |
| documentation | available · CC BY-SA 4.0 No separately licensed implementation located for this layer in the reviewed sources. [1] [3] |
This entry scopes the physical robot and its build documentation.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Roboparty/RP1_hardware README.md
Revision, date & where cited
RoboParty · github.com · revision
471bebd· README.md at · Accessed Nov 15, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 1 more - S002 Roboparty/RP1_hardware 01_Mechanic/README.md
Upstream 01_Mechanic/README.md for this project.Revision, date & where cited
RoboParty · github.com · revision
471bebd· 01_Mechanic/README.md at · Accessed Nov 15, 2026
Used for: Overview, Hardware & parts - S003 Roboparty/RP1_hardware LICENSES.md
Upstream LICENSES.md for this project.Revision, date & where cited
RoboParty · github.com · revision
471bebd· LICENSES.md at · Accessed Nov 15, 2026
Used for: Overview, Source files and licenses - S004 Roboparty/RP1_hardware 04_BOM/README.md
Upstream 04_BOM/README.md for this project.Revision, date & where cited
RoboParty · github.com · revision
471bebd· 04_BOM/README.md at · Accessed Nov 15, 2026
Used for: Overview - S005 Roboparty/RP1 README.md
Revision, date & where cited
RoboParty · github.com · revision
d675307· README.md at · Accessed Nov 15, 2026
Used for: Overview, Source files and licenses - S006 Roboparty/ROMOMO README.md
Revision, date & where cited
RoboParty · github.com · revision
a9140df· README.md at · Accessed Nov 15, 2026
Used for: Overview, Source files and licenses - S007 RoboParty RP1 launch photograph
The launch announcement labels the image “RP1 traversing obstacles, real-world photograph.” The image shows the white and blue humanoid vaulting a block.Revision, date & where cited
RoboParty · mmx.prnewswire.com · https://www.prnewswire.com/news-releases/born-to-be-open-roboparty-launches-rp1-a-full-stack-open-source-humanoid-302910163.html · Accessed Nov 15, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-11-15 — Initial source-reviewed hardware profile and attributed upstream image.
2026-11-15 — Added a link to the upstream photograph of the physical robot.