ROBOTIS OP3
Robot / hardware buildA 20-joint research humanoid with a 2025 ROS 2 revision and an older ROS 1 software lineage that must be kept distinct. [1]
Build & first use →Official websiteUpstream build guide
- For
- Research laboratories; Experienced ROS developers [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- Apache-2.0 · license not fully assessed for mechanical design, electronics, documentation · Details by part
Overview
ROBOTIS OP3 is a 20-joint humanoid built around DYNAMIXEL XM430-W350-R actuators, an Intel NUC i3 and an OpenCR subcontroller. The current manual separates its 2025 revision from the older model. That distinction affects software as well as hardware: the 2025 documentation specifies ROS 2, 250 GB storage and a different battery configuration from the older tab. A repository release number alone cannot identify the machine a lab is buying or maintaining. [5]
Is this for you?
3D preview
ROBOTIS OP3 simulation assembly. The source ROS description at zero joint positions. This visual model is not a verified manufacturing package or confirmation of every 2025 hardware revision.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: ROBOTIS, revision 0780e54c2064a42089b0cf970d716ae44fec9233. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [5] [6] [7] [8] · Project documentation [5] [6] [7] [8]
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Preserve the software route that matches the robot
The captured stable GitHub release, 0.2.1, has a README describing ROS Kinetic and Ubuntu Xenial. For the 2025 robot, the quick start instead links jazzy-devel branches and the recovery guide describes Linux Mint 22 Xfce with ROS 2 Jazzy. We preserved the OP3 Jazzy branch separately at an immutable commit and label it a development snapshot, not a stable release. Its manager package uses ROS 2 dependencies even though the branch README still carries the old compatibility table. [1] [2] [6] [7] [9]
There is a practical documentation mismatch to resolve before installation: the recovery page writes jazzy-devl in several clone commands, while the quick-start links name jazzy-devel, the branch preserved here. The full environment also depends on separate Framework, message, demo, tool and DYNAMIXEL repositories. Those still need a jointly pinned and tested set. [6] [7] [9]
Hardware files do not establish a ready manufacturing offer
The official hardware page links an OP-series archive containing an OP3 STP assembly, skin files and board PDFs; these files are now preserved locally. Their presence does not establish a complete manufacturing pack, a match to every 2025 component or a reuse license for the whole robot. The ROS package's Apache license is separate from those hardware questions. [8] [9] [10]
The manual describes a fully assembled vendor package. For a future support trial, begin by identifying the exact delivered revision, its software image and the documented camera, joint-offset and walking-tuning tools. Current delivered price, replacement-part supply and our own setup or repair effort remain unverified. No robot motion, calibration or software installation was tested for this profile. [5] [6]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Mar 26, 2018 [2]
- Latest release
- Mar 26, 2018 [2]
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- Legacy release 0.2.1 at ac3c5bae613e93e322b10cbabcda866fdb438e36; 2025 ROS2 route separately preserved at jazzy-devel 50f2367839d4aa9cd6f29ff1fb8ff504fc836655 (development snapshot, not stable release); hardware 65b8e73f2a6ff43ff92470113e5151b393e35448. · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed STP assembly and skin archives preserved; manufacturing rights and exact 2025 configuration match not established. [8] [10] |
| electronics | available · License not fully assessed Board PDFs preserved; not a complete editable manufacturing package for NUC, OpenCR, actuators and all electronics. [8] [10] |
| firmware | not found · License not fully assessed Separate OpenCR and actuator firmware not reconciled to this configuration. [1] [4] |
| software | available · Apache-2.0 Inspected Jazzy package declaration; separate dependency repositories not fully pinned. [9] |
| documentation | available · License not fully assessed Public documentation inspected; separate reuse license not established. [5] [6] [7] [8] |
No learned policy or dataset selected for this platform overview.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 ROBOTIS-GIT/ROBOTIS-OP3: README.md
Revision, date & where cited
github.com · revision
ac3c5ba· Accessed Sep 30, 2026
Used for: Preserve the software route that matches the robot, Source files and licenses - S002 ROBOTIS-GIT/ROBOTIS-OP3: commit ac3c5ba
Revision, date & where cited
github.com · Accessed Sep 30, 2026
Used for: Preserve the software route that matches the robot, What we checked - S003 ROBOTIS-GIT/ROBOTIS-OP3: LICENSE
Revision, date & where cited
github.com · revision
ac3c5ba· Accessed Sep 30, 2026 - S004 ROBOTIS-GIT/ROBOTIS-OP3: files
Revision, date & where cited
github.com · revision
ac3c5ba· archive file inventory · Accessed Sep 30, 2026
Used for: Source files and licenses - S005 ROBOTIS OP3 introduction
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · 2025 and older tabs; distinguished in profile · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S006 ROBOTIS OP3 quick start
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · 2025 and older tabs; distinguished in profile · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S007 ROBOTIS OP3 recovery
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · 2025 and older tabs; distinguished in profile · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S008 ROBOTIS OP3 hardware
Revision, date & where cited
ROBOTIS-GIT / project contributors · emanual.robotis.com · 2025 and older tabs; distinguished in profile · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S009 Preserved Jazzy development branch
Revision, date & where cited
github.com · revision
50f2367· Commit snapshot; not a stable release · Accessed Sep 30, 2026
Used for: Preserve the software route that matches the robot, Hardware files do not establish a ready manufacturing offer, Source files and licenses - S010 OP series hardware archive
Revision, date & where cited
github.com · revision
65b8e73· OP3 file inventory; does not prove manufacturability or complete licensing · Accessed Sep 30, 2026
Used for: Hardware files do not establish a ready manufacturing offer, Source files and licenses - S012 Upstream image and reuse attribution
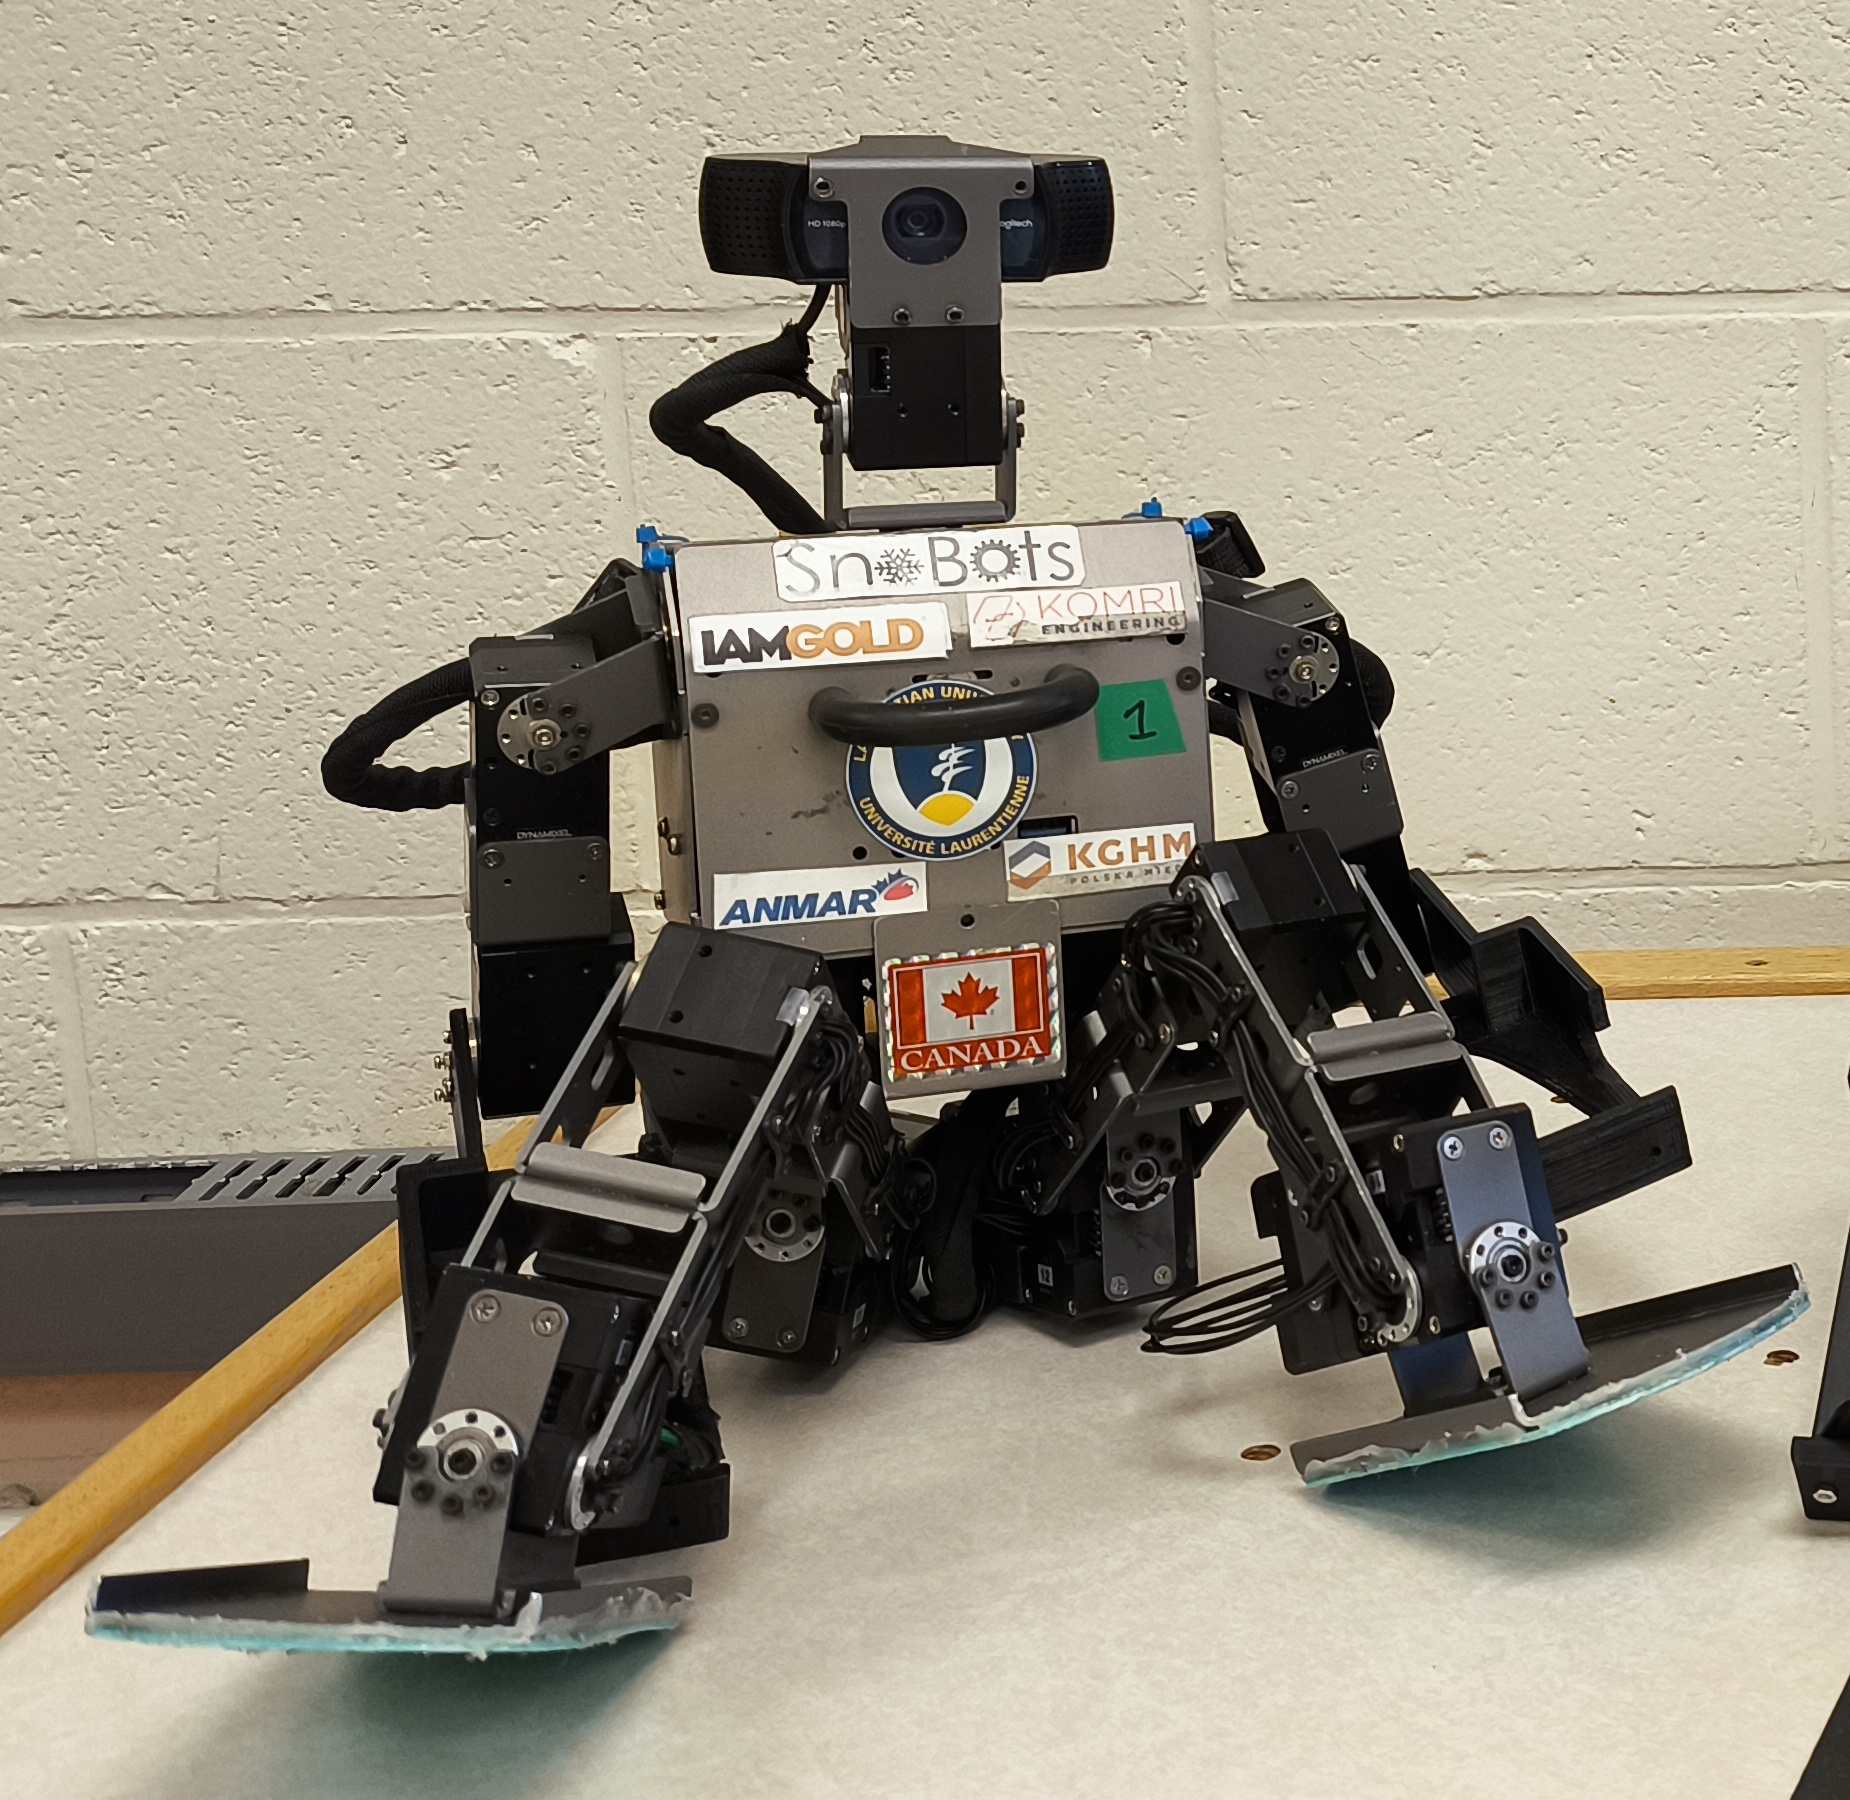
Media-only review: Paper photograph cropped to LIMRL’s ROBOTIS-OP3 “Oscar,” with the study’s modified hands and feet. The photographed experiment uses the older ROS Kinetic software lineage. Reuse basis: CC-BY-4.0. Figure 1 explicitly identifies ROBOTIS-OP3 Oscar on the left and the different Polaris on the right. Crop isolates Oscar. Section 3.1 identifies OP3 hardware and discloses 3D-printed hands/feet plus ROS Kinetic. Caption preserves those modifications and older software scope; it does not present the taller Polaris or claim the 2025 ROS 2 package is running. Paper carries actual author CC BY 4.0 and this is their own laboratory photo without an exclusion. Full embedded source image preserved. Embedded image extracted from page 5 of the source PDF and losslessly decoded to PNG; no retouching. Cropped to isolate LIMRL’s ROBOTIS-OP3 Oscar on the left, excluding the taller Polaris robot; full extracted image retained. Technical/cost evidence dates unchanged.Revision, date & where cited
Meng Cheng Lau and Nicolas Pottier · doi.org · A Modular Vision System for Practical Object Detection on Resource-Constrained Humanoid Robots, page 5 Figure 1, Oscar on left; image SHA-256 22e013e907782e9fbe0c0a77927a3f9643a4594e16a6af86e55c3336912cb9a9 · Accessed Oct 26, 2026
Videos
- S011 ROBOTIS (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel ROBOTIS · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S011): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.