ROBOTO_ORIGIN (RPO)
Robot / hardware buildFull-size DIY humanoid prototype from RoboParty with CNC-machined metal structure, 23 Damiao actuators in the published BOM, ROS 2 deployment and Isaac Lab training code; V2.0 hardware is not compatible with V1.0. [1] [4] [9]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Builders able to order CNC-machined metal parts and PCBs, integrate CAN actuators and run ROS 2 and Isaac Lab [1] [7] [9] [10]
- Cost
- CNY 49,743.53 upstream parts estimate [9] · checked Oct 5, 2026 · DetailsNot included: 3D-printed parts (unpriced), several cable, fastener and bearing lines without prices and V2.0 RBE board (not in this BOM) and more.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- CERN-OHL-W-2.0, GPL-3.0, GPL-3.0-only, CC-BY-SA-4.0 · license not fully assessed for model weights · Details by part
Overview
ROBOTO_ORIGIN (RPO) is RoboParty's full-size DIY humanoid prototype. The README describes its structure, electronics, training and deployment as open source. It says the robot can be assembled from Taobao purchases and "Jialichuang" PCB prototyping. The roboto_origin repository is a daily snapshot that aggregates eight sub-repositories, so module-level issues and fixes belong in those modules. Snapshot synchronization, root documentation and other aggregation issues belong in roboto_origin. It suits builders who can order CNC-machined metal parts and PCBs, wire CAN actuators, and run ROS 2 and Isaac Lab. [1]
Is this for you?
- Use cases
- Walking and running with open training and deployment code
- Navigation and XR teleoperation experiments (separate modules)
- Known limitations
- Full repository archive (about 2.25 GB of files) not preserved; review relies on pinned raw text files and the Git tree listing
- Published English BOM is labelled ATOM 01 v1.0.1 and lists discrete USB-to-CAN and DC-DC parts, while V2.0 integrates them on the RBE board
- V2.0 PCB README names v2.0 board files, while the tree holds RBE_PWR_HUB V2.1 files
- Mechanical source is SolidWorks; STEP and PDF exports are present but were not opened
- Shell (appearance) parts are recommended for static display only
- No physical build, calibration or locomotion test performed for this profile
Source-review findings; no hardware tests.
What you need
Hardware & parts
Upstream bill of materials [1]
- Actuators
- 14 x DM 4340P (48 V)
- 9 x DM 10010L
From the ATOM 01 v1.0.1 BOM; V2.0 parts list not preserved.
- Controller
RDK X5 8 GB in the published BOM; deployment framework verified on Orange Pi 5 Plus and RDK X5.
- Sensors
- Chaohe HI13 M0-USB IMU
- Power
48 V 15 Ah Li-ion pack; V2.0 RBE board provides 48 V distribution and 5 V up to 8 A for the main controller.
- Degrees of freedom
23
Inferred from 14 DM 4340P and 9 DM 10010L actuators in the published BOM; no explicit DoF count in the preserved text.
[9] · Editorial assessment
Assembly & first use
Open the upstream getting-started guide [4] · Project documentation [1]
- Confirm hardware version (V2.0 recommended; not compatible with V1.0)
- Reconcile the V2.0 parts list with the published ATOM 01 BOM before ordering
- Follow the V2.0 installation manual, wiring guide, pin calibration and printed-part calibration in that order
- Order or assemble the RBE power and USB-to-CAN board
- Set up the deployment controller (Orange Pi 5 Plus or RDK X5) with ROS 2 Humble
Editorial reading order across preserved sources; not a reproduced build.
Cost
| Version | Price |
|---|---|
| Published ATOM 01 v1.0.1 internal BOM total | CNY 49743.53 [9] Parts estimate |
China; Taobao and Tmall supplier links · Checked 2026-10-05
| Included | CNC-machined structural parts; 23 Damiao actuators; Battery pack, emergency stop and charger plug; IMU, RDK X5, USB-to-CAN and power modules; Priced fasteners and bearing lines |
|---|---|
| Not included | 3D-printed parts (unpriced); Several cable, fastener and bearing lines without prices; V2.0 RBE board (not in this BOM); Shipping and taxes; Tools and assembly labor; Training workstation |
| Stock | Supplier listings not re-checked. |
| Delivery and tax | Not established; no delivered total. |
Price details
Table total of the ATOM 01 v1.0.1 BOM dated 20260105; the same document header states TOTAL 49713 CNY. Printed parts, several cable and fastener lines and some bearings have no price. Not a fresh quote.
China; Taobao and Tmall supplier links · Checked 2026-10-05 · Quantity 1
V2.0 parts list, RBE board, printed parts, cables and tools must be reconciled separately.
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
Pick the hardware version first
The hardware module contains two incompatible generations. V1.0 is the legacy design with separate power and USB-to-CAN boards. V2.0 is recommended: it adds a reinforced structure, a waist limit switch, limit-pin calibration and one integrated electrical board. The README warns that V2.0 mechanics and interfaces are not compatible with V1.0. [4]
The V2.0 mechanical folder points to a PDF installation manual, a wiring guide, a pin-calibration guide and printed-part calibration slides, in that order. The repository tree lists SolidWorks parts and assemblies, STEP exports, 53 CNC drawing PDFs and 53 STEP files in the CNC folder, and printed calibration fixtures. The README names the manual "安装手册-0317.pdf", but the tree holds "安装手册_0428.pdf". Likewise, the PCB README describes RBE_Board v2.0 files, while the tree holds RBE_PWR_HUB V2.1 Gerber, BOM and schematic files dated 2026-04-09. Confirm you have the newest files before ordering. [7] [8] [13]
The V2.0 board takes 48 V through an XT60 input, feeds four 48 V outputs to the limbs, supplies up to 8 A at 5 V to the main controller and provides USB-to-CAN. The deployment framework is verified on an Orange Pi 5 Plus and an RDK X5 under Ubuntu 22.04 with ROS 2 Humble. Training needs Isaac Sim 5.1.0 and Isaac Lab. [8] [10] [11]
What the published BOM covers
The English BOM is labelled ATOM 01 v1.0.1 and dated 2026-01-05. It lists CNC parts, a 48 V 15 Ah battery, an IMU, an RDK X5, four separate USB-to-CAN adapters, a DC-DC module, and 14 DM 4340P plus 9 DM 10010L actuators. We infer 23 actuated joints from those counts. The header total reads 49,713 CNY, while the table ends at 49,743.53 CNY. Printed parts and many cable and fastener lines have no price. Because the BOM lists discrete converters that V2.0 integrates, it should not be treated as a V2.0 total. The V2.0 folder has its own parts list (V1.1.3 spreadsheet), which we did not open. [4] [7] [9] [13]
What we checked
Source research only; no fabrication, assembly, flashing or locomotion test performed. Full repository archive not preserved. No affiliate links added.
Not yet established
- Requirements: tools
Updates
- Upstream last updated
- Aug 18, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- c71fd9287d28104dca111d7c25b908fa3f45f8e4 (commit snapshot of the aggregation repository; no published stable release found; full archive not preserved because it exceeds 150 MiB) · combined hardware and software repository
Source files and licenses
Licensed mechanical, PCB, firmware and software sources are listed at a pinned commit, but the full archive was not preserved and the published BOM predates the V2.0 electronics.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-W-2.0 V2.0 SolidWorks parts and assemblies, STEP exports, CNC drawings (PDF/SLDDRW) and printed calibration parts are listed in the tree but were not downloaded (repository over 150 MiB). Vendor motor, battery, bearing and standard-part models are excluded from the open license. [4] [5] [6] [7] [13] |
| electronics | available · CERN-OHL-W-2.0 RBE board Gerber, BOM, pick-and-place, schematic PDF and STEP are listed; no editable EDA project was identified in the tree. Files not downloaded. [5] [8] [13] |
| firmware | available · GPL-3.0 Firmware module (USB2CAN, OrangePi/RDK build tooling) listed; nested orangepi-build is GPL-2.0 per the scope map. Not downloaded or reviewed in detail. Damiao actuator firmware is vendor-supplied. [3] [13] |
| software | available · GPL-3.0-only Deployment (GPL-3.0-only), training (BSD-3-Clause per the scope map), navigation and XR teleoperation modules; embedded third-party components keep their own terms. [3] [10] [11] |
| model weights | available · License not fully assessed Nine ONNX policy files (walking, AMP, parkour, get-up, dance, wave and others) are listed in the deployment module; not downloaded. The module default is GPL-3.0-only for RoboParty-authored material, but no weight-specific terms or training provenance were identified. [3] [13] |
| documentation | available · CC-BY-SA-4.0 Hardware-module READMEs and manuals are CC-BY-SA-4.0 except where they are hardware design source (CERN-OHL-W-2.0). The external documentation site was not preserved. [4] [5] [7] |
No dataset is part of the reviewed build configuration.
Licenses differ by module
The root GPL-3.0 does not relicense the modules. In rpo_hardware, RoboParty-owned CAD, PCB, BOM, URDF and manufacturing files are CERN-OHL-W-2.0, software and firmware are GPL-3.0-only, and user documentation is CC-BY-SA-4.0. Vendor models for motors, batteries, bearings, fasteners and boards are excluded from those grants, and third-party files without an identifiable license are to be treated as reference-only. The training module is BSD-3-Clause. The exterior shell is CERN-OHL-W-2.0, but upstream recommends it for static display only. The deployment module also lists nine ONNX policy files; we found no terms specific to those weights. [3] [5] [6] [12] [13]
The full repository, about 2.25 GB of files, exceeded our 150 MiB archive limit. This profile therefore rests on pinned copies of the cited text files and the Git tree listing; none of the CAD, Gerber or PDF files was opened. No assembly, flashing or locomotion test was performed. [2] [13]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 ROBOTO_ORIGIN README
Project scope, snapshot-aggregation role, module map and license statement.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· README.md at c71fd928; preserved raw-file snapshot sha256 bec41319642956f3 · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use - S002 Roboparty/roboto_origin: commit c71fd92
Selected commit, blocked full-archive status, dated popularity counts.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · ; default-branch snapshot, no stable release in first 100; archive blocked over 150 MiB · Accessed Oct 5, 2026
Used for: Is this for you?, What we checked, Source files and licenses - S003 Repository license scope map
Per-module license scope for the aggregated snapshot.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· LICENSES.md at c71fd928; preserved raw-file snapshot sha256 8fe5f2bf953d6a31 · Accessed Oct 5, 2026
Used for: Source files and licenses - S004 rpo_hardware README (snapshot module)
V1.0 versus V2.0 comparison, incompatibility note and license table.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· modules/rpo_hardware/README.md at c71fd928; preserved raw-file snapshot sha256 e509700f5332ebc9 · Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Pick the hardware version first and 2 more - S005 rpo_hardware licensing
CERN-OHL-W-2.0, GPL-3.0-only and CC-BY-SA-4.0 scopes.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· modules/rpo_hardware/LICENSES.md at c71fd928; preserved raw-file snapshot sha256 eb8e32c649b93efd · Accessed Oct 5, 2026
Used for: Source files and licenses - S006 rpo_hardware third-party notices
Vendor models and standard parts excluded from the open licenses.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· modules/rpo_hardware/THIRD_PARTY_NOTICES.md at c71fd928; preserved raw-file snapshot sha256 7680fa7f435b91bb · Accessed Oct 5, 2026
Used for: Source files and licenses - S007 V2.0 mechanical README
Manual reading order and folder structure for V2.0 mechanics.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· modules/rpo_hardware/V2.0/roboto_origin_mechanic/README.md at c71fd928; preserved raw-file snapshot sha256 9fed041d7bc9e7ce · Accessed Oct 5, 2026
Used for: Is this for you?, Assembly & first use, Pick the hardware version first, What the published BOM covers and 1 more - S008 V2.0 PCB README (RBE_Board)
Integrated 48 V power and USB-to-CAN board specification and file list.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· modules/rpo_hardware/V2.0/roboto_origin_pcb/README.md at c71fd928; preserved raw-file snapshot sha256 615efa4bf663d706 · Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Pick the hardware version first and 1 more - S009 Internal Roboto D-BOM (English)
ATOM 01 v1.0.1 BOM dated 20260105 with CNY line prices and totals.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· assets/BOM_EN.md at c71fd928; preserved raw-file snapshot sha256 932ff6baf3a9381d · Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Cost and 1 more - S010 roboparty_deploy README (snapshot module)
ROS 2 Humble deployment framework and verified controllers.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· modules/roboparty_deploy/README.md at c71fd928; preserved raw-file snapshot sha256 a3d0e202bc618419 · Accessed Oct 5, 2026
Used for: What you need, Hardware & parts, Assembly & first use, Pick the hardware version first and 1 more - S011 roboparty_train README (snapshot module)
Isaac Lab training workspace requirements.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· modules/roboparty_train/README.md at c71fd928; preserved raw-file snapshot sha256 ec778c21873dd096 · Accessed Oct 5, 2026
Used for: What you need, Pick the hardware version first, Source files and licenses - S012 rpo_appearance README (snapshot module)
Shell STLs recommended for static display; CERN-OHL-W-2.0.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · github.com · revision
c71fd92· modules/rpo_appearance/README.md at c71fd928; preserved raw-file snapshot sha256 f9182ef45f89b5d5 · Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, Source files and licenses - S013 Pinned repository file tree (GitHub API)
Paths and sizes of V2.0 SolidWorks, STEP, drawing, PCB and URDF files.Revision, date & where cited
RoboParty (Shanghai RoboParty Technology Co., Ltd.) · api.github.com · Recursive Git tree at c71fd928; preserved JSON sha256 ce40719ea719c6c6; listing only, no files downloaded beyond the cited text files · Accessed Oct 5, 2026
Used for: Is this for you?, Assembly & first use, Pick the hardware version first, What the published BOM covers and 1 more - S014 Upstream image and reuse attribution
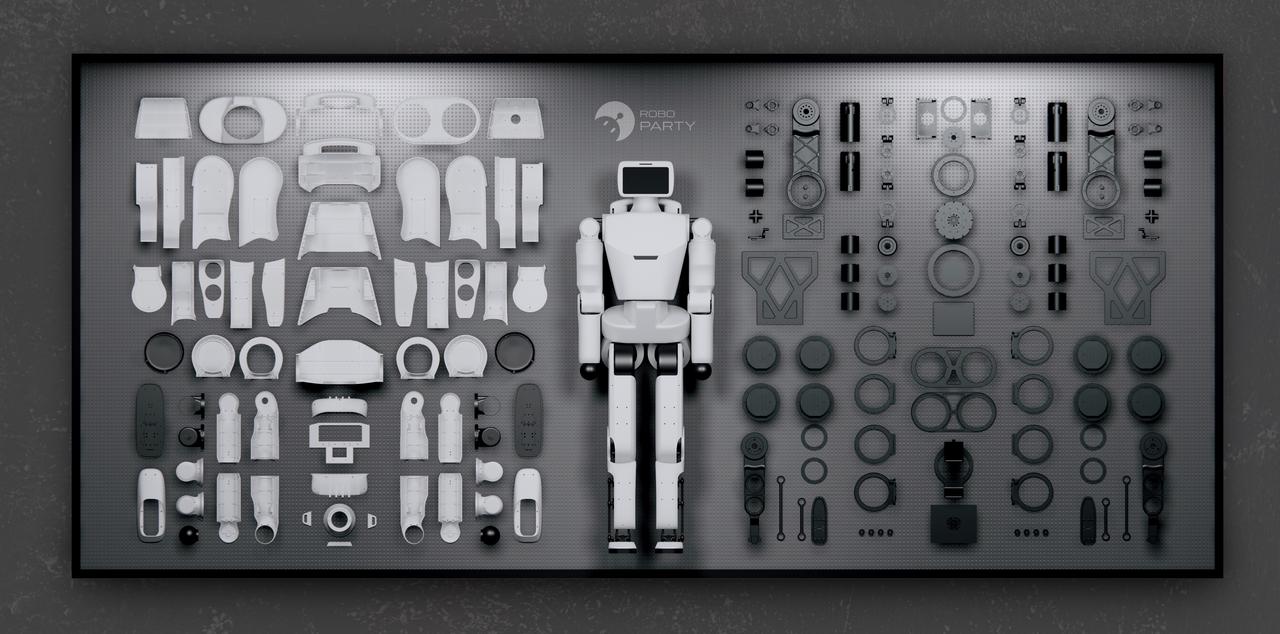
Media-only review: Upstream photograph of the Roboto Origin robot alongside laid-out components; the layout is not a verified bill of materials. Reuse basis: GPL-3.0-only; inspected LICENSES.md and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
RoboParty contributors · github.com · revision
c71fd92· Image SHA-256 d5a9e75642b986fb897ae1ff4fba0eb650e724d1a07f6e5293fabaa5bcbbac4b; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Initial source-researched profile from pinned commit c71fd928 using raw-file snapshots and the Git tree listing.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.