ROSbot
Robot / hardware buildROSbot 2R mobile platform with separately versioned ROS packages and CORE2 microcontroller firmware; this entry distinguishes the 2R configuration from newer ROSbot hardware. [1]
Build & first use →Official website
- For
- ROS developers working with a specific ROSbot 2R hardware configuration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- Apache-2.0 · license not fully assessed for mechanical design, documentation · Details by part
Overview
ROSbot 2R is a four-wheel mobile robot with a Raspberry Pi host and a CORE2 controller for low-level work. This profile selects the regular-wheel 2R configuration and the preserved ROS package release 0.12.0. The manufacturer's current manual also covers other generations, so a component listed for ROSbot 3 or 2 PRO should not be silently substituted into the 2R configuration. [1] [2] [5]
Is this for you?
- Known limitations
- Pinned ROS packages and separately collected firmware do not form a fully tested installation
- Dependency manifest uses moving branches
- Simulation distance-sensor message types differ from hardware in the pinned API guide
- Mechanical fabrication and complete board sources not established
3D preview
ROSbot 2R chassis and wheel assembly. The regular-wheel chassis, cover and drive geometry from the preserved 2R description. The external camera and lidar models are omitted; this partial preview does not represent the complete sensor-equipped robot or a verified manufacturing package.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original URDF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Husarion contributors, revision eb5f8205dbe7b7fdbc5cdfe64e89b1a9b9bc5dd2. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. URDF visual origins, mesh scales and joint transforms applied at zero joint positions, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Host computer
ROSbot 2R manual specifies Raspberry Pi 4, 4 GB RAM and 32 GB microSD.
Hardware & parts
- Hardware configuration
ROSbot 2R four-wheel mobile platform; selected regular-wheel differential-drive configuration.
Configuration selection; mecanum and other generations require separate settings.
[5] · Editorial assessment
- Sensors
- Orbbec Astra RGB-D camera
- RPLIDAR A2
- BNO055 IMU
- Wheel encoders and onboard distance sensing
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Identify the hardware before selecting software
The 2R component table names a Raspberry Pi 4 with 4 GB RAM, Orbbec Astra camera, RPLIDAR A2 and BNO055 IMU. Its regular and mecanum wheel options have different diameters. The low-level controller handles motors and other real-time tasks while the host runs higher-level software. These are manufacturer-reported configuration details, not measurements of a robot inspected here. [5]
The reviewed repository contains robot descriptions, controller configuration, bring-up and simulation packages. Its meshes and URDF help represent the robot; they do not establish a complete fabrication-ready mechanical design or bill of materials. This is therefore coverage of a platform with available control sources, not a claim that the entire purchased robot can be manufactured from the collected files. Current complete cost and component sourcing were not verified. [1] [4] [5]
The controller firmware is a separate artifact
The ROS repository instructs users to update the low-level firmware and run a micro-ROS agent before hardware operation. Checking compatibility with the preserved ROS package revision is this profile’s editorial recommendation; no specific tested revision pair was established. This review separately preserved the linked firmware repository, whose README describes STM32F4, Mbed OS and a PlatformIO development workflow. It requires recursive submodules, so its top-level archive alone is not a complete firmware build environment. No firmware was compiled or flashed. [1] [10]
The firmware guide's agent example uses a Humble image, a default baud rate of 576000 and board-specific serial devices; its Raspberry Pi entry is /dev/ttyAMA0. Those values need to match the selected firmware and host configuration. The manufacturer's multi-generation manual provides separate firmware-installation routes, including ROSbot Docker images for the 2R. Preserve the actual firmware/image pair rather than treating a moving image tag as an immutable revision. [5] [10]
The ROS package dependency manifest likewise points to several moving branches. The reviewed package and firmware commits are evidence-backed snapshots, but this publication has not established a completely pinned, installed system across every external dependency. [2] [7] [10]
Simulation and hardware do not expose identical sensor messages
The pinned API guide describes bring-up that combines wheel odometry and IMU data through robot_localization. It also documents a specific simulation mismatch: physical distance sensors publish Range messages, while the selected simulation exposes LaserScan messages, using the first range element for the corresponding distance. A consumer expecting the hardware message type therefore needs an explicit adaptation for that simulation route. [6]
The repository's simulation instructions select Gazebo Fortress. Successful simulation under those instructions would still not prove the firmware transport, wheel configuration or physical sensor frames are correct on a 2R. Confirm those separately before interpreting odometry or attempting navigation. These are proposed checks; no simulation, calibration or driving test was performed here. [1] [5] [6] [10]
The selected ROS package manifests declare Apache License 2.0, while the separate firmware repository supplies the Apache-2.0 license text. No root license text was found in the inspected ROS package archive. Those software findings do not establish blanket rights to hardware CAD, website content, downloaded images or external components. [4] [8] [9] [11]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed URDF and meshes for robot description; complete editable manufacturing CAD, BOM and hardware license not established. [4] [9] |
| electronics | not found · License not fully assessed Controller and wiring descriptions inspected; complete configuration-specific board design source not preserved. [5] [10] |
| firmware | available · Apache-2.0 Separate CORE2 firmware repository; submodules, build tools and binary compatibility not fully preserved or tested. [10] [11] |
| software | available · Apache-2.0 Selected ROS package manifests declare Apache License 2.0; no root license text found in this archive. Scope is package metadata, not blanket hardware or external dependency rights. [8] [9] |
| documentation | available · License not fully assessed Manufacturer documentation available; website-wide reuse terms not established. [5] |
Physical platform, control and simulation profile with no particular learned policy or dataset selected.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 husarion/rosbot_ros: README.md
Revision, date & where cited
github.com · revision
eb5f820· Accessed Oct 1, 2026
Used for: Overview, What you need, Assembly & first use, Identify the hardware before selecting software and 2 more - S002 husarion/rosbot_ros: commit eb5f820
Revision, date & where cited
github.com · Accessed Oct 1, 2026
Used for: Overview, The controller firmware is a separate artifact, What we checked - S004 husarion/rosbot_ros: files
Revision, date & where cited
github.com · revision
eb5f820· archive file inventory · Accessed Oct 1, 2026
Used for: Is this for you?, Assembly & first use, Identify the hardware before selecting software, Simulation and hardware do not expose identical sensor messages and 1 more - S005 Official multi-generation ROSbot hardware manual
Revision, date & where cited
husarion / project contributors · husarion.com · Retrieved manual; claims below select ROSbot 2R sections · Accessed Oct 1, 2026
Used for: Overview, What you need, Hardware & parts, Assembly & first use and 4 more - S006 ROSbot ROS 0.12.0: ROS_API.md
Revision, date & where cited
github.com · revision
eb5f820· Accessed Oct 1, 2026
Used for: Is this for you?, Assembly & first use, Simulation and hardware do not expose identical sensor messages - S007 ROSbot ROS 0.12.0: rosbot/rosbot_hardware.repos
Revision, date & where cited
github.com · revision
eb5f820· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, The controller firmware is a separate artifact - S008 ROSbot ROS 0.12.0: rosbot/package.xml
Revision, date & where cited
github.com · revision
eb5f820· Accessed Oct 1, 2026
Used for: Simulation and hardware do not expose identical sensor messages, Source files and licenses - S009 ROSbot ROS 0.12.0: rosbot_description/package.xml
Revision, date & where cited
github.com · revision
eb5f820· Accessed Oct 1, 2026
Used for: Simulation and hardware do not expose identical sensor messages, Source files and licenses - S010 Separately preserved CORE2 firmware: README.md
Revision, date & where cited
github.com · revision
2f0351a· Accessed Oct 1, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S011 Separately preserved CORE2 firmware: LICENSE
Revision, date & where cited
github.com · revision
2f0351a· Accessed Oct 1, 2026
Used for: Simulation and hardware do not expose identical sensor messages, Source files and licenses - S013 Upstream image and reuse attribution
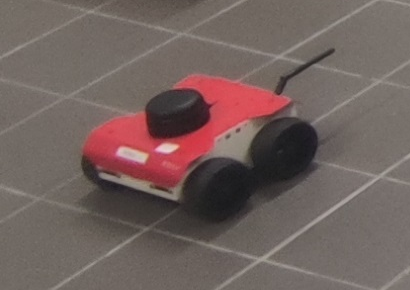
Media-only review: Photograph of a ROSbot 2R with RPLidar A2 in the authors’ SLAM study (2025 preprint), cropped from Figure 13(b). No top-mounted RGB-D camera is visible. Reuse basis: CC-BY-4.0. Actual version-specific arXiv license inspected: CC BY 4.0, not the default arXiv distribution grant. Section 4.2 explicitly identifies the physical experimental robots as ROSBot 2R with RPLidar A2 and labels Figure 13(b) experimental environment. Full room photo, source embedded image and crop visually inspected; red/white four-wheel platform, front sensors, black lidar and antenna match. Crop isolates the complete left robot from the authors’ own room photograph; Figure 13(a) adjacent manufacturer-style rendering is excluded. This is the 2R platform in an experimental sensor configuration, not 2.0, XL or 3. Caption states no top-mounted RGB-D camera visible and does not infer internal boards, firmware or hardware tests. No later model substituted. Existing technical/cost evidence dates unchanged. Embedded image extracted from page 24 of the source PDF and losslessly decoded to PNG; no retouching. Cropped to isolate the complete left ROSbot 2R in the authors’ experimental room photograph; full extracted image retained. Technical/cost evidence dates unchanged.Revision, date & where cited
Muhammad Farhan Ahmed, Matteo Maragliano, Vincent Frémont and Carmine Tommaso Recchiuto · arxiv.org · Efficient Multi-robot Active SLAM, arXiv2310.06160v2, PDF page24, Figure13(b), leftmost complete robot; image SHA-256 d976dc885d1314837647e76153dfe5e78378e8d26061484b4f64f69191637683 · Accessed Oct 26, 2026
Videos
- S012 Husarion (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Husarion · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-04 — Added 1 YouTube reference(s) (S012): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.