RUKA
End effectorA learned-control humanoid hand with external fabrication instructions, CAD and controller data. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- not fully assessed for mechanical design, documentation · Details by part
Is this for you?
- Known limitations
- Downloaded print-page labels use XM430 while dated BOM specifies XL330. Linked STL requests returned HTTP 403. Resolve configuration and retrieval gap; preserve exact teleoperation submodule and OSF data if required.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
3D preview
RUKA source MJCF hand. The repository's hand_assembly.xml visual model and body hierarchy at its all-zero reference pose, including the palm and five fingers. Source mesh placement and named fingertip markers are retained. Collision boxes, test objects, actuators, tendons, electronics and physical operation are not shown or verified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original MJCF source bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Anya Zorin, Irmak Guzey, Billy Yan, Aadhithya Iyer, Lisa Kondrich, Nikhil X. Bhattasali and Lerrel Pinto, revision fe4f60805e7415bbeda8e7d49ef6fc094d653c41. Original and preview: MIT. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. Source visual shapes and body transforms evaluated at the reference pose by MuJoCo, then metres converted to millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Dexterous hands
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Configuration and sourcing
The original RUKA BOM and current website print files have not yet been matched to one build configuration.
December 19, 2024 BOM lists 11 XL330-M288-T motors, U2D2, tendons, PTFE tube, springs, pins, power wiring and 5 V 30 A supply; tools separately listed. The upstream December 19, 2024 single-hand BOM totals are $519.94 without tools and $762.76 with tools, including its printer allowance. These are dated BOM figures, not current supplier quotations. Host compute and teleoperation input equipment are not listed in that BOM. [1] [2] [3] [4] [5] [6]
Print/postprocess parts, install inserts, assemble finger/wrist mechanisms and tendons, wire supply, assign motor IDs and match controller checkpoints. The README describes a Conda environment, USB-port configuration and OSF credentials for its download script. The learned-controller route requires OSF checkpoints and build-specific tendon calibration; this review has not established that the external checkpoints match the selected hardware. [1] [2] [3] [4] [5] [6]
Integration
Documentation reports direct Franka and xArm mounting and a separate Kinova adapter; no particular arm generation tested here. [1] [2] [3] [4] [5] [6]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- fe4f60805e7415bbeda8e7d49ef6fc094d653c41; Original RUKA; original dated BOM and current website print files not yet matched
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Repository MIT; external fabrication files and OSF weights/data licensing not established. [1] [2] [3] [4] [5] [6] |
| electronics | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] |
| firmware | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] |
| software | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] [6] |
| model weights | not found · License not fully assessed No complete matched external training-data/weight set verified for this configuration. [1] [2] [3] [4] [5] [6] |
| datasets | not found · License not fully assessed No complete matched external training-data/weight set verified for this configuration. [1] [2] [3] [4] [5] [6] |
| documentation | available · License not fully assessed Repository MIT; external fabrication files and OSF weights/data licensing not established. [1] [2] [3] [4] [5] [6] |
Design limits and source rights
Downloaded print-page labels use XM430 while dated BOM specifies XL330. Linked STL requests returned HTTP 403. Resolve the BOM/print-file mismatch and retrieve the selected geometry before buying a matched set.
Live teleoperation has two documented routes: MANUS gloves with a streaming SDK and the Bidex_Manus_Teleop submodule, or Oculus with the externally installed OpenTeach application. Pin the MANUS submodule; recording the OpenTeach revision is an editorial reproducibility recommendation. The README also provides saved keypoints for initial controller use, which is distinct from sourcing live teleoperation input equipment. [1] [2] [3] [4] [5] [6]
The repository MIT text covers software and associated documentation and requires preservation of the copyright and permission notice. Rights for the external fabrication files and OSF weights/data remain unestablished. [1] [2] [3] [4] [5] [6]
This is a source-researched design profile. We have not assembled or tested this configuration; no complete current setup price is established.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 ruka-hand/RUKA: README.md
Revision, date & where cited
github.com · revision
fe4f608· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S002 ruka-hand/RUKA: LICENSE
Revision, date & where cited
github.com · revision
fe4f608· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S003 ruka-hand/RUKA: files
Revision, date & where cited
github.com · revision
fe4f608· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S004 bom
Revision, date & where cited
ruka-hand / project contributors · docs.google.com · source.bin · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S005 cad
Revision, date & where cited
ruka-hand / project contributors · ruka.gitbook.io · text.txt · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S006 mounts
Revision, date & where cited
ruka-hand / project contributors · ruka.gitbook.io · text.txt · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S007 Upstream image and reuse attribution
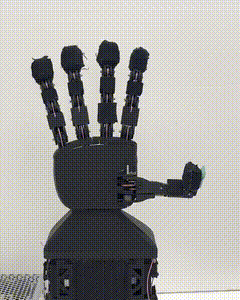
Media-only review: Still from an upstream demonstration: the RUKA robotic hand. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Still taken from the upstream animation; no other changes. This does not refresh technical or cost evidence.Revision, date & where cited
RUKA Hand contributors · github.com · revision
fe4f608· Image SHA-256 7b0c90ec5318d2f604132b03d530e0f8bfe61b85ca85e2008df89ef27da6592e; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.