SSG-48
End effectorA motor-driven adaptive gripper with a reported 48 mm stroke and CAN control. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- EUR 773.50 vendor price [9] [10] · checked Sep 30, 2026 · DetailsNot included: pictured jaws, default shaft coupler and separate PAROL6 cable required and more.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- Apache-2.0 · license not fully assessed for firmware, software · Details by part
Overview
SSG-48 is an adaptive electric gripper for builders who want controllable jaw movement and a documented route to mounting it on PAROL6. Its README reports a 48 mm stroke and 400 g mass. This review uses the V1.1 mechanical release; those specifications are upstream claims, not measurements from our own hardware. [1] [3]
Is this for you?
- Known limitations
- Resolve BOM M4×10 versus manual M4×20 coupler screws; match V1.1 CAD/BOM to controller firmware and vendor unit; adapter template links in docs are empty; quote complete power/USB-CAN/host setup.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
[1] [2] [3] [4] [5] [6] [7] [8] [9] [10] · Editorial assessment
3D preview
SSG-48 gripper body. The gripper body only. Separate jaws, fingers and control electronics are not assembled into this preview.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Source Robotics, revision bf8b3364a197c86d6ecbae72b4e13062fa844cc6. Original and preview: Apache-2.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
Hardware & parts
- Hardware configuration
Electric grippers
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
- Assembly
Print PETG parts, remove supports and install inserts; assemble guides and drive; wire the controller; calibrate travel after each power-up, then activate before commanding a grasp.
Research synopsis of upstream route; not independently executed instructions.
[1] [2] [3] [4] [5] [6] [7] [8] [9] [10] · Editorial assessment
Cost
| Version | Price |
|---|---|
| Black assembled SSG-48 vendor listing; exact revision unconfirmed | EUR 773.50 [9] [10] Vendor price |
Storefront displayed Germany/EUR; destination not selected · Checked 2026-09-30
| Included | One black gripper as described by vendor; full accessory contents unconfirmed |
|---|---|
| Not included | Pictured jaws; Default shaft coupler; Separate PAROL6 cable required; No complete host, power, delivery or tax package established |
| Stock | Black variant marked available in product feed; gray unavailable. No checkout performed. |
| Delivery and tax | Not established for a destination; no delivered total. |
Price details
September 30 storefront snapshot; not a V1.1 self-source cost.
Storefront displayed Germany/EUR; destination not selected · Checked 2026-09-30 · Quantity 1
Host, power, tools and host-arm integration must be reconciled; one end-effector subsystem, not a complete arm.
Price and revision boundaries
The supplier's September 30, 2026 storefront snapshot lists the black SSG-48 at EUR 773.50 and marks that variant available; gray is unavailable in its product feed. Shipping is calculated at checkout. This is the vendor listing captured on September 30, 2026, not the cost of self-sourcing the V1.1 design, and its exact hardware revision and full package contents have not been reconciled. The supplier explicitly excludes the pictured jaws and the default shaft coupler, asks PAROL6 buyers to contact it for an 8 mm coupler, and lists a separate required PAROL6 cable. Destination taxes, power supply, host and integration accessories remain outside a verified delivered setup total. [9] [10]
The mechanical repository carries Apache-2.0, while the separately preserved Spectral controller firmware carries GPL-3.0. Neither establishes source availability or rights for every purchased electronic component. One release-level detail needs resolving before ordering: the BOM lists four M4 × 10 mm screws, while the assembly manual calls for four M4 × 20 mm screws at the shaft coupler. Check the selected coupler geometry or obtain upstream clarification rather than guessing a length. Controller firmware, wiring and adapter revisions also need matching. No assembly, calibration or grasp test has been performed for this profile. [4] [5] [2] [8]
Project notes
What a self-sourced build needs
The release BOM calls for one GBM5208-75 motor, one Spectral Micro BLDC controller, two MGN7C carriages and a 100 mm linear guide, plus a coupler, magnet, fasteners, inserts and cables. The assembly manual specifies PETG printing and includes support removal, insert installation and assembly steps. A preserved parts archive therefore supplies the custom geometry, but the motor, controller and motion hardware still need purchasing. [4] [5]
The separately preserved control documentation describes CAN as the primary interface and UART as secondary. It requires travel calibration after power-up, activation before movement and a USB-to-CAN adapter for the PC GUI. Those requirements belong in a first-working-setup budget alongside power and host equipment. Installation documentation shows a PAROL6 coupler, but its generic coupler and jaw-template download links are empty. An arbitrary robot arm is not a verified fit. [6] [7]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- bf8b3364a197c86d6ecbae72b4e13062fa844cc6; V1.1 mechanical release; supplemental control/docs snapshots separately pinned
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · Apache-2.0 Mechanical repository Apache-2.0. Separately preserved Spectral firmware GPL-3.0. Controller fabrication rights/files are not established by the gripper license. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] |
| electronics | not found · License not fully assessed A complete configuration-matched source set for this layer is not established by this review; purchased parts and linked repositories must be assessed separately. This is not a claim that the layer is closed source. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] |
| firmware | available · License not fully assessed Separate source archive preserved; hardware/firmware/API revision matching remains unresolved. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] |
| software | available · License not fully assessed Separate source archive preserved; hardware/firmware/API revision matching remains unresolved. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] |
| documentation | available · Apache-2.0 Mechanical repository Apache-2.0. Separately preserved Spectral firmware GPL-3.0. Controller fabrication rights/files are not established by the gripper license. [1] [2] [3] [4] [5] [6] [7] [8] [9] [10] |
This configuration is reviewed as a physical end effector with ordinary control, without a selected learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Source-Robotics/SSG-48-adaptive-electric-gripper: README.md
Revision, date & where cited
github.com · revision
bf8b336· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S002 Source-Robotics/SSG-48-adaptive-electric-gripper: LICENSE
Revision, date & where cited
github.com · revision
bf8b336· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Cost and 1 more - S003 Source-Robotics/SSG-48-adaptive-electric-gripper: files
Revision, date & where cited
github.com · revision
bf8b336· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Assembly & first use and 1 more - S004 bom
Revision, date & where cited
github.com · revision
bf8b336· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Cost and 2 more - S005 manual
Revision, date & where cited
github.com · revision
bf8b336· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Cost and 2 more - S006 control
Revision, date & where cited
github.com · revision
2fbdc06· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, What a self-sourced build needs and 1 more - S007 installation
Revision, date & where cited
github.com · revision
2fbdc06· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, What a self-sourced build needs and 1 more - S008 firmware_license
Revision, date & where cited
github.com · revision
2e7febc· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Cost and 1 more - S009 offer
Revision, date & where cited
Source-Robotics / project contributors · source-robotics.com · text.txt · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Cost and 1 more - S010 offer_variants
Revision, date & where cited
Source-Robotics / project contributors · source-robotics.com · source.bin · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Cost and 1 more - S014 Upstream image and reuse attribution
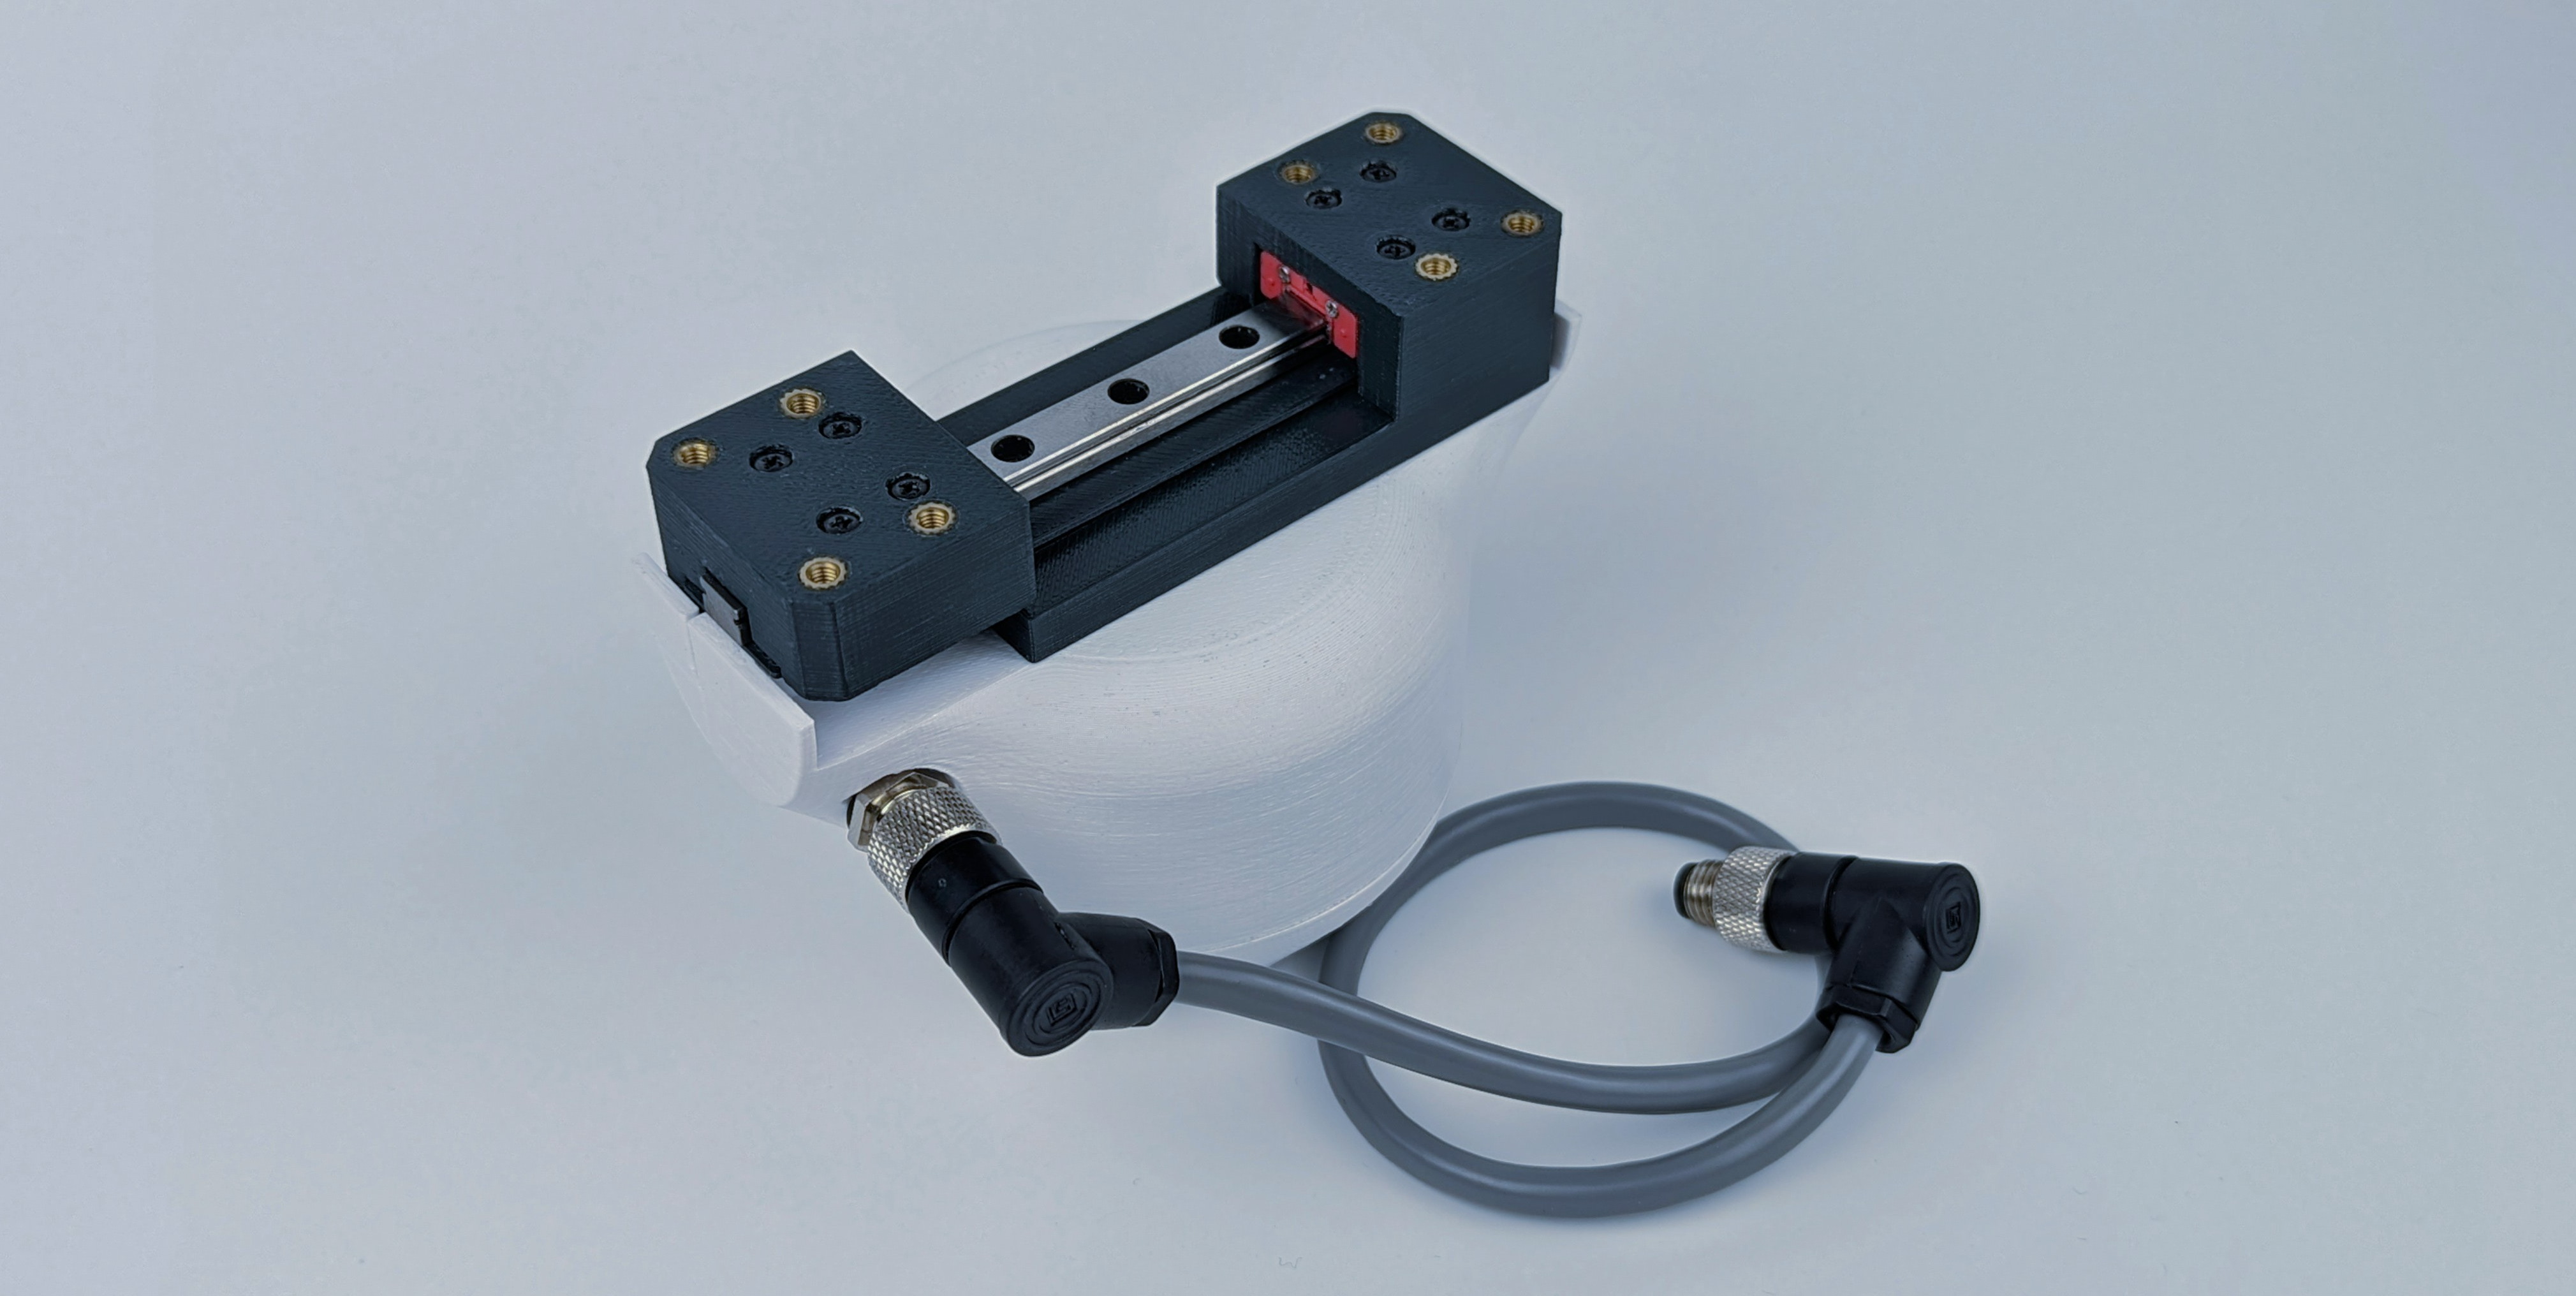
Media-only review: Upstream photograph of the SSG-48 gripper and its connection cable. Reuse basis: Apache-2.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Source Robotics and SSG-48 contributors · github.com · revision
bf8b336· Image SHA-256 9824239002f42d56e78c9e2f2e2735161a863fa2e9ee915b86a9298465061fd1; repository · Accessed Oct 25, 2026
Videos
- S011 Source Robotics (YouTube channel)
The project’s own YouTube channel, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube channel Source Robotics · youtube.com · Accessed Oct 4, 2026
- S012 SSG-48 3D printed gripper assembly (YouTube video)
Video from the project’s own channel (Source Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Source Robotics · youtube.com · Accessed Oct 4, 2026
- S013 SSG-48 Adaptive open source electric gripper (YouTube video)
Video from the project’s own channel (Source Robotics), linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Source Robotics · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-04 — Added 3 YouTube reference(s) (S011, S012, S013): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.