Stanford Doggo
Robot / hardware buildA historical eight-actuator quadruped using coaxial leg mechanisms, Teensy control and customized ODrive firmware. [1]
Build & first use →Official website
- For
- Legged robotics researchers; Experienced mechanical and embedded-system builders [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for mechanical design, electronics, firmware · Details by part
Overview
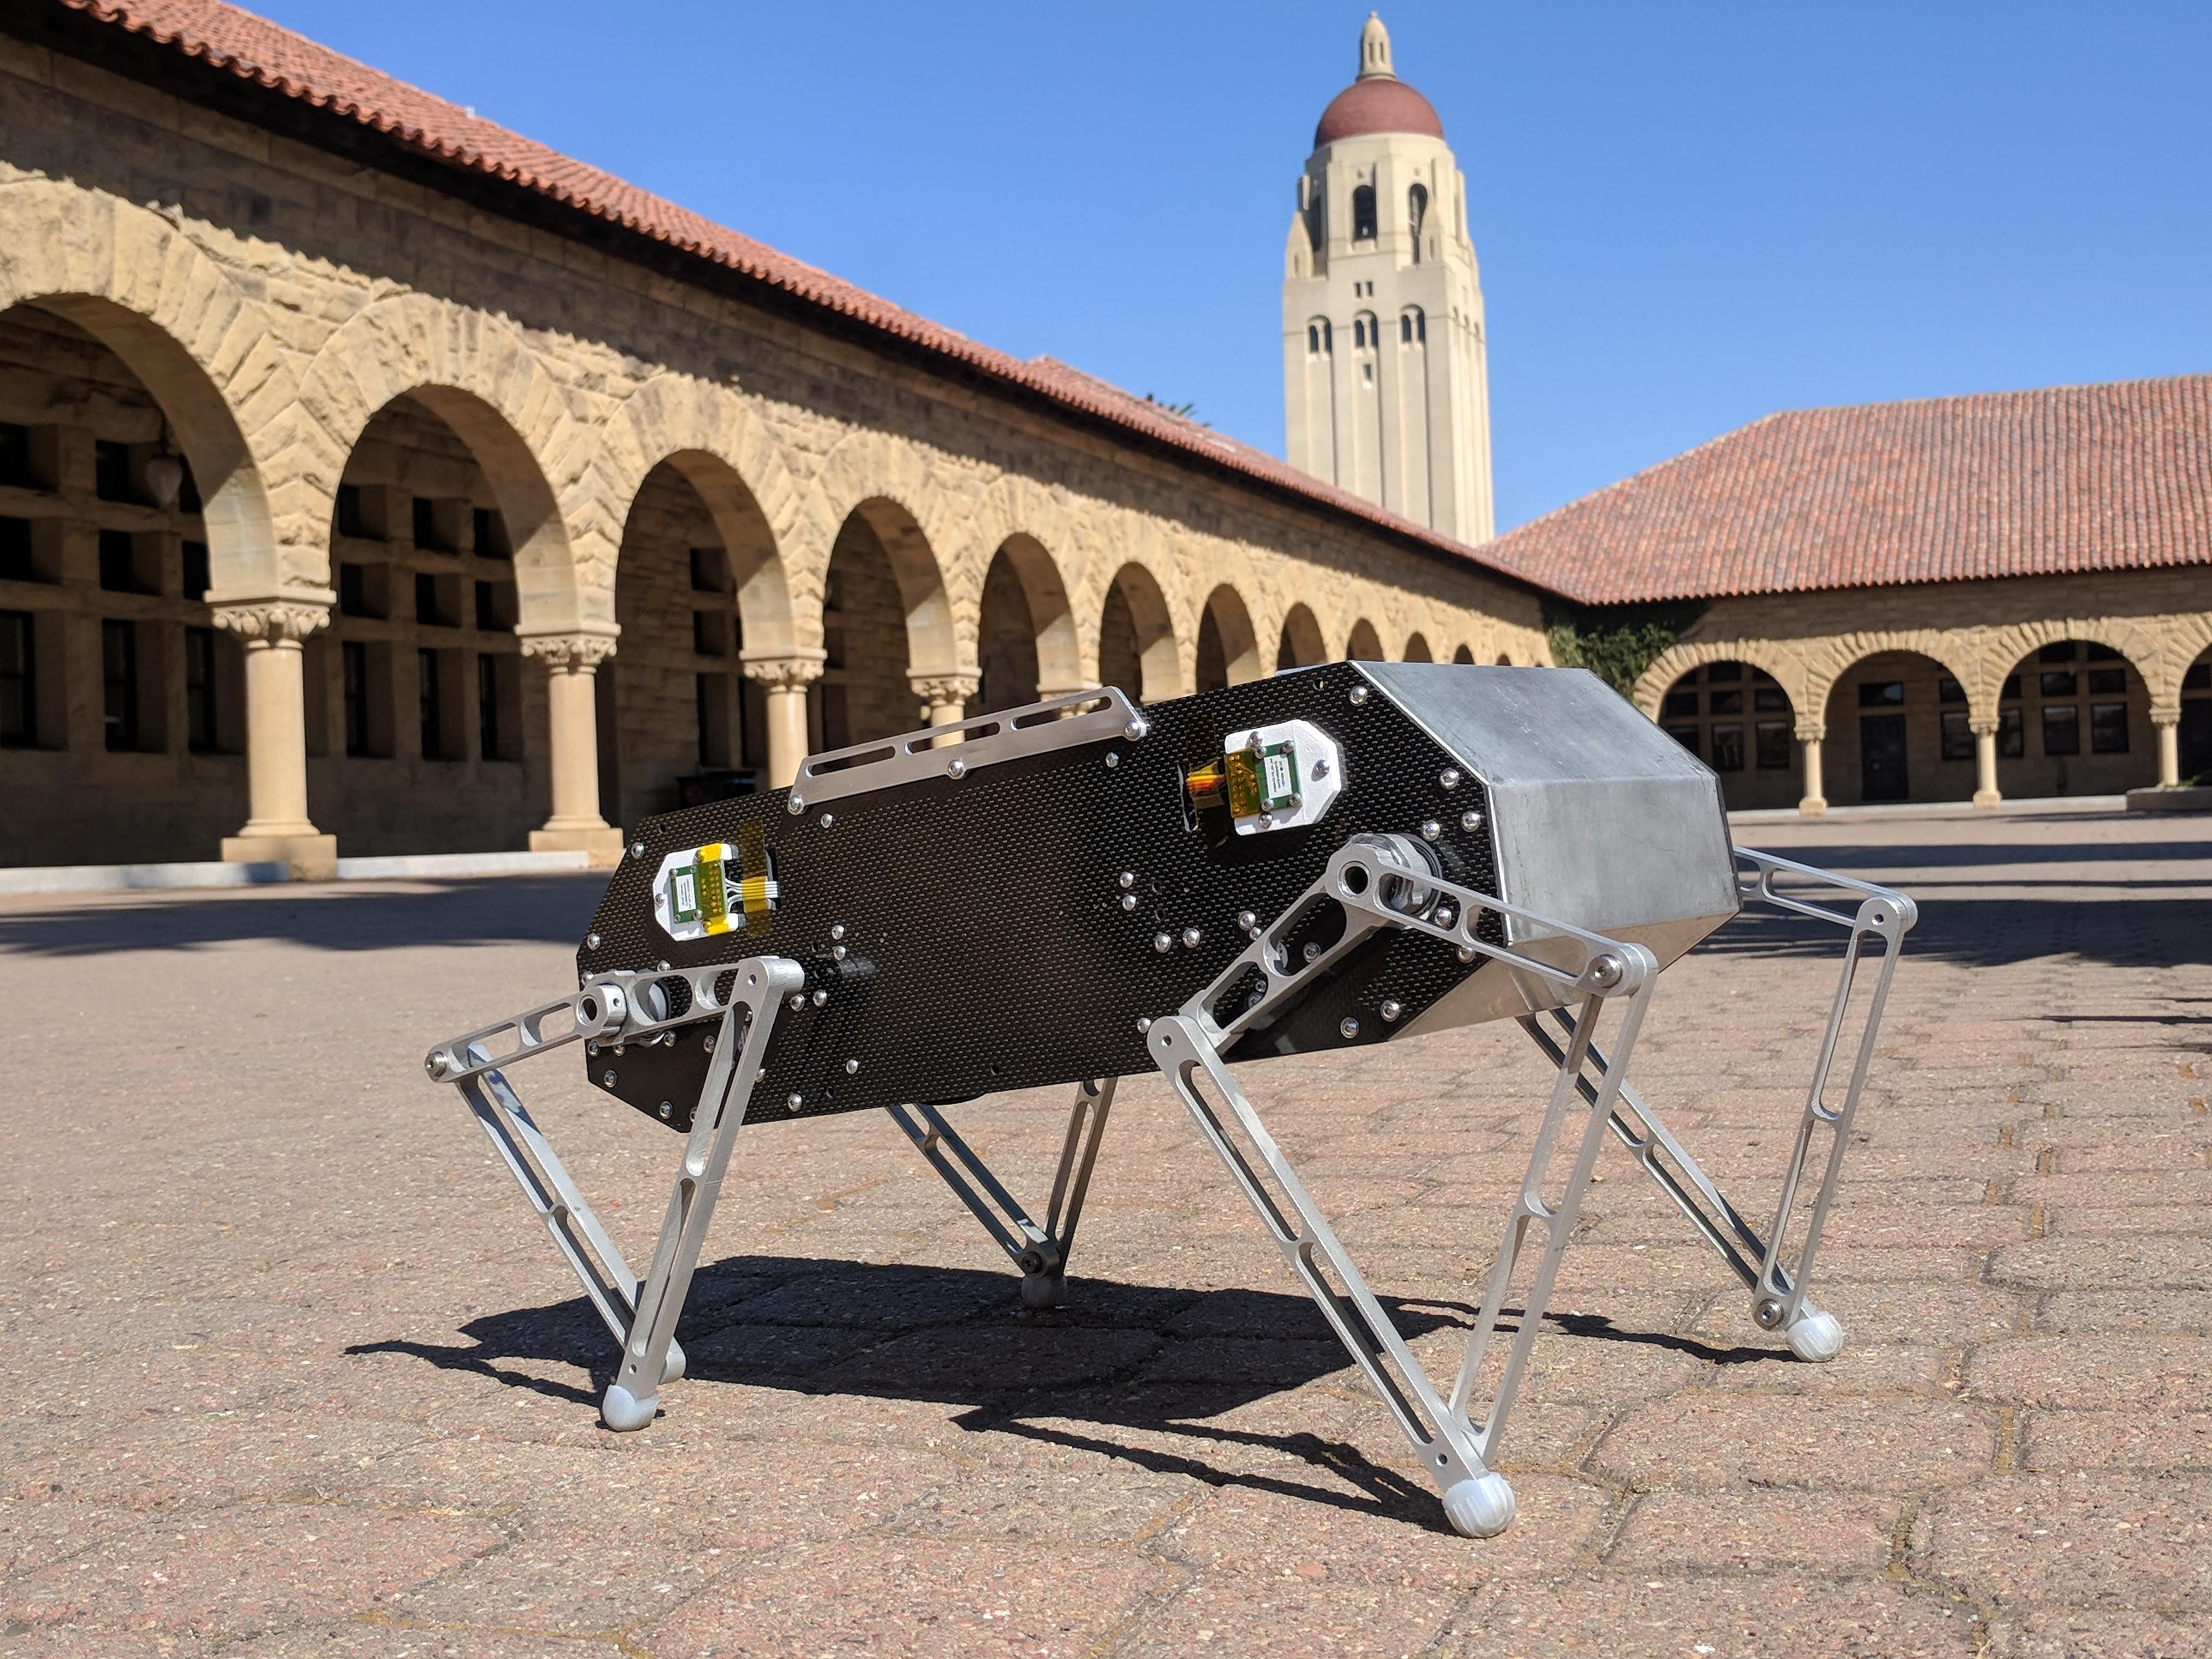
Doggo is an eight-actuator quadruped with four two-axis legs, coaxial shafts and belt-driven mechanisms. We preserved parent release 1.0 and the exact Doggo and ODrive commits referenced by that release. The current project README carries an end-of-life notice, so the archived release should be treated as a historical research starting point. [1] [2] [5] [6] [9]
Is this for you?
- Known limitations
- Current project README carries an end-of-life notice
- Release README and BOM differ on ODrive voltage, encoder designation and relay choice
- Exact release-pinned firmware lists some advertised gait commands as nonworking or unstable
- Nested firmware dependencies and complete CAD/configuration matching unresolved
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Model sources
Design-source links are available, but the reviewed record does not establish unambiguous reuse rights for a hosted CAD preview.
Project notes
The fabrication pack needs reconciliation
The release's FullCAD file is an Autodesk link, not the CAD assembly itself. Its BOM also links a contributor collection by Sean Kirmani; we preserved that collection, including fabrication files. These are separate sources, and their exact correspondence to the release has not been established. [4] [7] [8]
The mechanical work spans waterjet or routed structural parts, coaxial shafts, printed components and molded silicone feet. Upstream's design notes describe pulley-print orientation and the tradeoff between belt tension and friction. That makes dimensional fitting and assembly practice relevant to reproduction, beyond whether a STEP or STL file downloads successfully. [1]
There are purchasing mismatches to resolve. The release README describes 48 V ODrive hardware and a Gigavac relay, while the captured BOM lists 24 V ODrives and a solid-state relay replacement. It also uses a different encoder designation. Do not combine those references into a presumed matched electrical configuration. The workbook's historical prices and approximate fabrication quotes do not establish a current complete delivered cost. [1] [7]
Read the selected firmware's behavior list
The release-pinned Teensy README identifies trot as its working forward gait, labels bound unstable, and lists walk and pronk as nonworking. Those specific limitations qualify the broader movement descriptions in the parent overview. They also show why preserving the matching firmware matters when choosing a demonstration to reproduce. No gait or startup calibration was tested here. [1] [5]
The parent project has an MIT notice, but the separate firmware repositories, nested libraries and externally hosted CAD need their own license and revision reconciliation. A build or support offer remains dependent on a chosen electrical configuration, complete fabrication sources, resolved dependencies and measured setup and repair work. [3] [4] [5] [6] [8]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer
- A step-by-step setup summary
Updates
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Contributor parts collection preserved; full Autodesk assembly and exact release matching unresolved. Root MIT notices do not settle all external CAD provenance. [4] [7] [8] |
| electronics | available · License not fully assessed Wiring illustration and BOM available; this is not complete purchased-board manufacturing source. [1] [4] [7] |
| firmware | available · License not fully assessed Exact Doggo and ODrive gitlinks preserved; nested libraries and file-level licenses not fully reconciled. [5] [6] |
| software | available · MIT Parent repository notice; does not automatically cover separate firmware repositories or external CAD. [3] [4] |
| documentation | available · MIT Parent documentation; separately hosted BOM rights not inferred. [1] [3] |

Reviewed historical control route selects no learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
Project sources
- S001 Nate711/StanfordDoggoProject: README.md
Revision, date & where cited
github.com · revision
b38b8e0· Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S002 Nate711/StanfordDoggoProject: commit b38b8e0
- S003 Nate711/StanfordDoggoProject: LICENSE
Revision, date & where cited
github.com · revision
b38b8e0· Accessed Sep 30, 2026
Used for: Read the selected firmware's behavior list, Source files and licenses - S004 Nate711/StanfordDoggoProject: files
Revision, date & where cited
github.com · revision
b38b8e0· archive file inventory · Accessed Sep 30, 2026
Used for: The fabrication pack needs reconciliation, Read the selected firmware's behavior list, Source files and licenses - S005 Release-pinned Doggo
Revision, date & where cited
github.com · revision
91e7699· Exact release 1.0 submodule gitlink · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S006 Release-pinned ODrive
Revision, date & where cited
github.com · revision
4335a55· Exact release 1.0 submodule gitlink · Accessed Sep 30, 2026
Used for: Overview, Read the selected firmware's behavior list, Source files and licenses - S007 Doggo BOM workbook
Revision, date & where cited
Nate711 / project contributors · docs.google.com · BOM and Custom Fabricated Parts tabs; row numbers included · Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 2 more - S008 BOM-linked contributor fabrication collection
Revision, date & where cited
Nate711 / project contributors · github.com · revision
f5aadba· Sean Kirmani parts collection linked in BOM; distinct repository · Accessed Sep 30, 2026
Used for: The fabrication pack needs reconciliation, Read the selected firmware's behavior list, Source files and licenses - S009 Current project end-of-life notice
Revision, date & where cited
github.com · Current README, distinct from preserved release 1.0 · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 1 more - S013 Upstream image and reuse attribution
Media-only review: Upstream photograph of a Stanford Doggo quadruped build. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Nathan Kau and Stanford Doggo contributors · github.com · revision
b38b8e0· Image SHA-256 61f8d4f209759d7f938bbd0e6565cb0401c8eb0e87f42aa0701e0a1bed9f77fc; repository · Accessed Oct 25, 2026
Videos
- S010 Stanford Doggo Coaxial Mechanism (YouTube video)
Video uploaded by Nathan, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Nathan · youtube.com · Accessed Oct 4, 2026
- S011 Stanford Doggo Backflip (YouTube video)
Video uploaded by Nathan, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Nathan · youtube.com · Accessed Oct 4, 2026
- S012 Stanford Doggo ICRA Submission Video (YouTube video)
Video uploaded by Nathan, linked from the project’s own documentation. Not reviewed by us for accuracy.Revision, date & where cited
YouTube video Nathan · youtube.com · Accessed Oct 4, 2026
Correction guidance · Discussion is not enabled · Profile format 0.5.0-draft.1
Change history
2026-10-04 — Added 3 YouTube reference(s) (S010, S011, S012): official channel or videos linked from the pinned upstream sources. Existing claims, source-check dates and evidence are unchanged.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.