Stringman
Robot / hardware buildRoom-scale four-line cable robot (Arpeggio hardware) with two corner anchors and a hanging camera gripper, driven by a host-run Python motion controller; a public prototype. [5] [10]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Builders with a suitable rectangular room, a capable host computer and experience assembling 3D-printed mechanisms and Raspberry Pi systems [5] [10]
- Cost
- USD 655.00–965.00 published pricess for 3 versions [7] [8] [9] [10] · checked Oct 5, 2026 · DetailsNot included: printed parts and filament, host computer and shipping, taxes and assembly labor.
- Source rights
- Some licenses are unresolved. Review licenses
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- Ecosystem
- LeRobot, Raspberry Pi
- License
- Apache-2.0, CC-BY-SA-4.0 · no license identified for electronics · license not fully assessed for mechanical design · Details by part
Overview
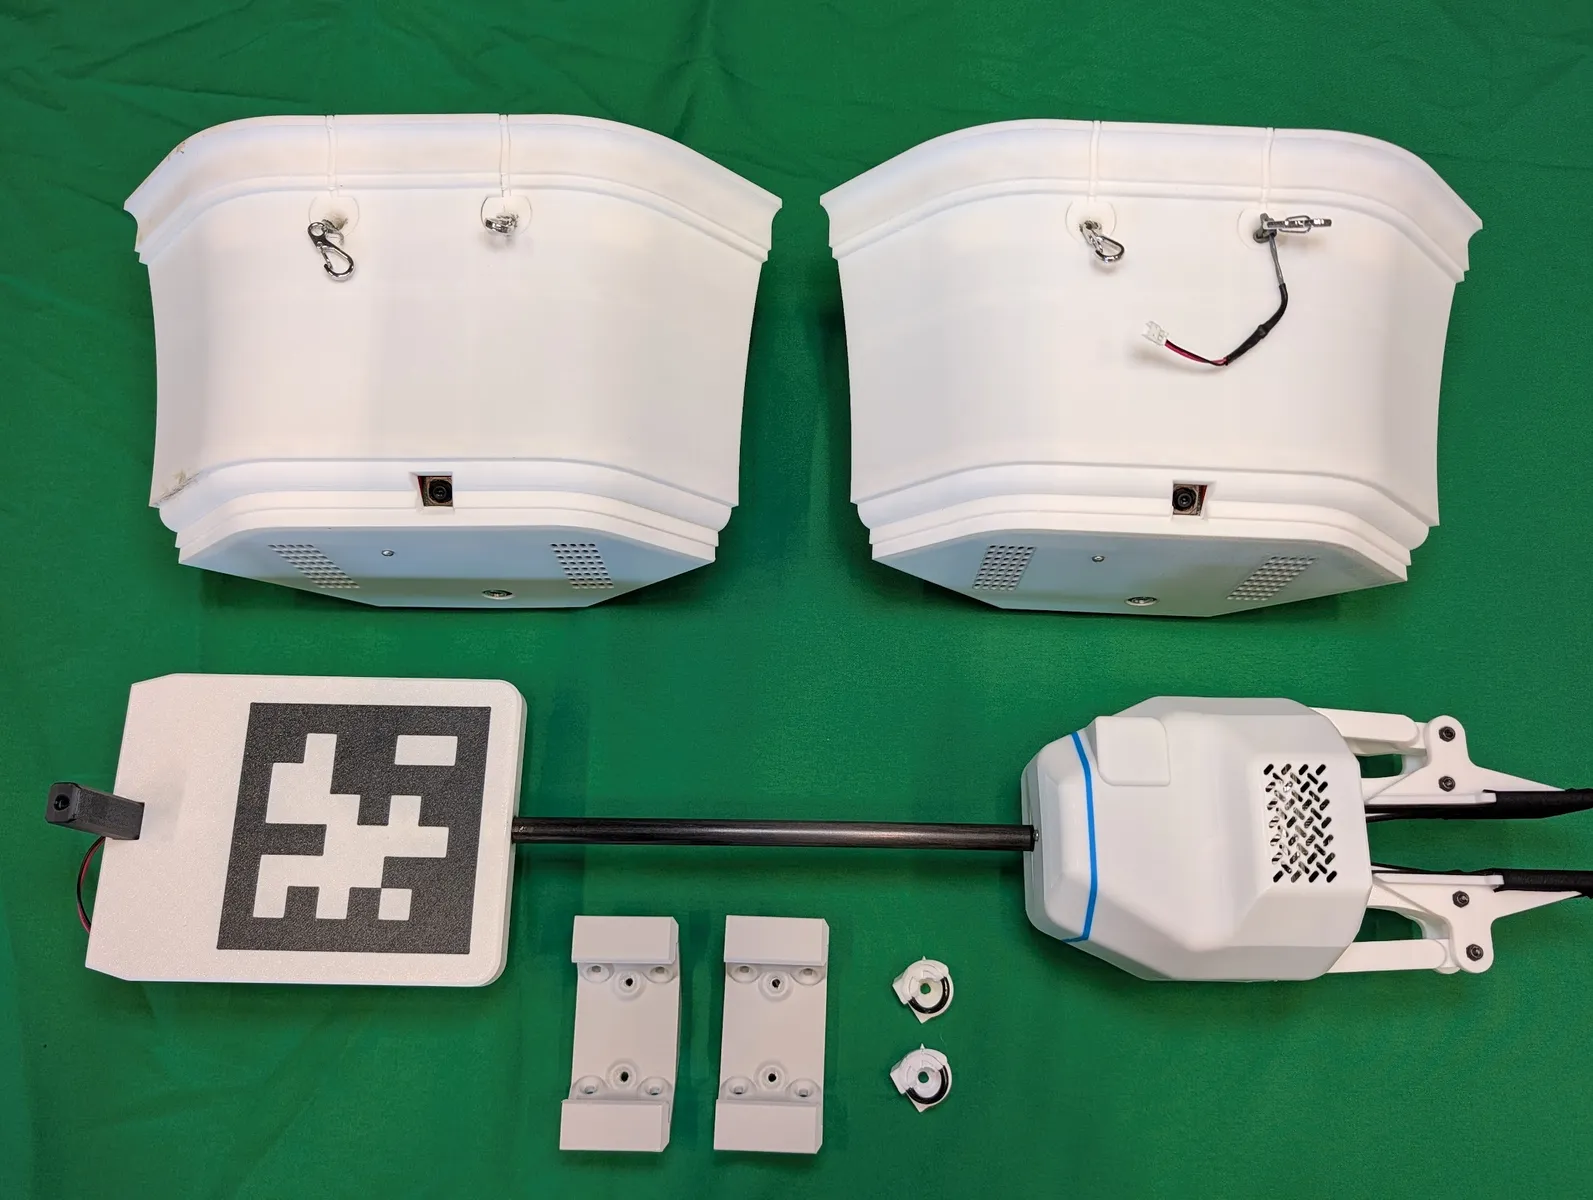
Stringman, from Nathaniel Nifong's Neufangled Robotics, is a cable-driven robot that hangs from the corners of a room. In the current "Arpeggio" hardware, two anchors in opposite corners each reel two lines, ceramic eyelets sit in the other two corners, and a gripper hangs from the four lines. Cameras on the anchors and gripper watch printed markers so a host program can estimate positions. The documentation calls it a public prototype that is "not yet reliable enough" for a home appliance. Nothing was built, installed or run for this entry. [1] [4] [5] [10]
Is this for you?
- Use cases
- Teleoperated pick-and-drop in a room
- Recording demonstrations and running AI policies
- Known limitations
- Documented as a public prototype, not appliance-reliable
- Hardware license statements conflict between documentation pages
- Anchor compute board differs between BOM and architecture page
- CAD and STL archives external and not preserved
Source-review boundaries; no hardware tests.
More on fit and limitations
Who it suits
It suits people with a roughly rectangular room, a wall stud in each anchor corner, outlets near two opposite corners, an ordinary shared Wi-Fi network and a capable host computer. The kit page calls the build multi-day and "fairly difficult", estimating 4 to 8 hours of assembly; the Arpeggio print guide estimates about 80 hours of printing. [5] [10] [11]
What you need
Hardware & parts
Upstream bill of materials [6] [7]
- Hardware configuration
Cable-driven parallel robot: two corner anchors with motorized spools, two eyelets, and a gripper hanging from four lines.
- Actuators
- 4× Damiao DM-H6215 hub motors in two anchors
- 2× Feetech STS3215 servos in the gripper (grip and wrist)
- Sensors
- Raspberry Pi Camera Module 3 per anchor
- Camera Module 3 Wide on the gripper
- TOF400C-VL53L1 laser rangefinder
- Force-sensing resistor in a finger
Assembly & first use
Open the upstream getting-started guide [5]
- Check room suitability (corners, studs, outlets, Wi-Fi)
- Download STLs and print (about 80 h)
- Build anchors and gripper per Arpeggio guides
- Install nf_robot on the host and run stringman-headless
- Mount, string and run full calibration
Cost
| Version | Price |
|---|---|
| Stringman Arpeggio, one system (gripper + two anchors), BOM sheet | USD 673.69 [7] [8] Parts estimate |
Upstream USD (US suppliers) · Checked 2026-10-05
| Included | Motors, servos, Raspberry Pis, cameras, sensors; Custom PCBs and wiring harnesses; Line, power cable, slip ring, bearings, fasteners; Two power supplies |
|---|---|
| Not included | Printed parts and filament; Host computer; Shipping, taxes and assembly labor |
| Stock | Supplier stock not rechecked. |
| Delivery and tax | Not established. |
Price details
BOM sheet grand total (gripper US$187.69 + anchors US$486.01) from per-unit prices at the maintainer's batch sizes; printed parts not listed; not re-quoted.
Upstream USD (US suppliers) · Checked 2026-10-05 · Quantity 1
Printed parts and a host computer.
US store; ships to listed countries · Checked 2026-10-05
| Included | Pis, cameras, motors, wires, screws and PCBs from the BOM; PCTG finger drive gear |
|---|---|
| Not included | Other printed parts; Host computer |
| Stock | Sold out at retrieval. |
| Delivery and tax | Shipping shown at checkout; Canada tariff noted on kit page. |
Price details
Store list price; page showed Sold out at retrieval. Kit page says price is based on about US$630 landed parts cost plus margin.
US store; ships to listed countries · Checked 2026-10-05 · Quantity 1
Print STLs; host computer.
| Version | Price |
|---|---|
| Stringman, fully assembled | USD 965.00 [9] Vendor price |
US store · Checked 2026-10-05
| Included | Assembled system ready for installation and calibration |
|---|---|
| Not included | Host computer; Shipping and taxes |
| Stock | Not established. |
| Delivery and tax | Not established. |
Price details
Store list price for the fully assembled system; stock state not established from the static page.
US store · Checked 2026-10-05 · Quantity 1
Host computer; wall mounting.
Cost scope
The Arpeggio BOM sheet totals US$673.69: US$187.69 for the gripper and US$486.01 for the anchors. Its unit prices are derived from the maintainer's batch purchases, so it is not a one-off delivered quote; printed parts, shipping and tax do not appear in the sheet. The store lists the hardware kit at US$655 and the assembled robot at US$965. The kit page showed "Sold out" at retrieval, and the kit excludes printed parts other than a PCTG gear; the assembled robot's stock state was not established. Neither price includes the host computer. These are dated figures, not re-quoted. [7] [8] [9] [10]
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
Configuration and requirements
The Arpeggio BOM lists four Damiao DM-H6215 hub motors, two Raspberry Pi 3A+ boards with Camera Module 3, custom anchor HATs, a slip ring, braided fishing line and FEP power cable for the anchors. The gripper uses a Raspberry Pi Zero 2W, a wide camera, two STS3215 servos, a laser rangefinder and a force-sensing resistor. The system-architecture page instead says all three components run on a Pi Zero 2W, so the anchor board needs confirming. The kit page claims a 2 kg payload anywhere in a room up to 7 m from ceiling corner to opposite floor corner. [7] [8] [10] [12]
The motion controller, stringman-headless, runs on a host computer from the nf_robot Python package (version 7.0.2 at this commit, Python 3.12 or newer), and the README notes PyTorch and CUDA dependencies of about 5.5 GB. It asks for at least 8 cores and 8 GB of RAM, plus acceleration for local AI inference. A web UI runs locally, and binding the robot to a neufangled.com account for remote relay is optional. LeRobot policies connect through a telemetry websocket. [1] [4]
What we checked
Source research only; no installation, physical build or performance test performed. Store prices are from preserved pages, not a purchase. No affiliate links. AI-assisted drafting with a separate LLM editorial judge; no independent human technical review.
Updates
- Upstream last updated
- Oct 5, 2026 [2]
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- 8e72ee45f2397117ba6611a676d75a9bf73513a2 (software commit snapshot, nf_robot 7.0.2; hardware version Arpeggio per docs; no published release) · software repository
Source files and licenses
Software, PCB projects and documentation are available; mechanical CAD is external and unpreserved, and hardware licensing statements conflict.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Onshape CAD and STL archives linked from the downloads page; not preserved or inspected. License statements conflict: downloads page says CERN-OHL-W 2.0 with a liability addendum; documentation home says Apache 2.0. License left unset pending clarification. [5] [6] |
| electronics | available · No license identified KiCad anchor and gripper HAT projects and Gerbers in stringman-pcbs; no license file identified in that repository, and the downloads-page license names CAD, STLs, print guide and BOM but not PCBs. [6] [13] |
| firmware | available · Apache-2.0 Component-side code (Raspberry Pi services) is in the same nf_robot repository; motor and servo firmware are vendor-supplied. [1] [3] |
| software | available · Apache-2.0 Host motion controller and UI; PyTorch and model downloads carry their own terms. [1] [3] [4] |
| model weights | not found · License not fully assessed README says production targeting and grasping models are downloaded from Hugging Face; their location and license were not inspected. [1] |
| documentation | available · CC-BY-SA-4.0 Documentation site states CC BY-SA 4.0. [5] |
No dataset is distributed in the inspected sources.
Sources and licenses
The cranebot3-firmware repository holds the code for both the host and the robot components under an Apache-2.0 LICENSE. Hardware design files live elsewhere: Onshape CAD, STL archives and a Google Sheets BOM linked from the documentation, and KiCad projects in a separate stringman-pcbs repository. The Onshape documents and STL archives were not preserved. The downloads page releases the CAD, STLs, print guide and BOM under CERN-OHL-W 2.0, with a user-responsibility addendum, while the documentation home page says the design is published under Apache 2.0, a conflict to resolve with the maintainer. No license file was identified in stringman-pcbs. The documentation is stated to be CC BY-SA 4.0. [1] [3] [5] [6] [13]
The software repository has no published release; this entry covers commit 8e72ee4 of October 5, 2026, which had 103 GitHub stars at retrieval, a dated popularity signal only. The documentation itself warns that the gripper sometimes crashes into things when moving fast, that "some of them have broken during operation" and that AI policies can act unpredictably, and it tells users to keep the kill switch at hand. Payload and calibration robustness remain unverified. [2] [5]
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 cranebot3-firmware README (nf_robot)
Controller installation, headless motion controller, optional cloud binding, minimum system specs, telemetry, LeRobot policy connection, component images.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · github.com · revision
8e72ee4· README.md at · Accessed Oct 5, 2026
Used for: Overview, What you need, Assembly & first use, Configuration and requirements and 1 more - S002 nhnifong/cranebot3-firmware: commit 8e72ee4
No published release; default-branch commit snapshot archived; dated repository popularity.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · github.com · ; commit date 2026-10-05T13:35:46Z; manifest retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: What we checked, Source files and licenses - S003 cranebot3-firmware license
Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · github.com · revision
8e72ee4· LICENSE (Apache License 2.0 text) · Accessed Oct 5, 2026
Used for: Source files and licenses - S004 nf_robot package metadata
Package name, version 7.0.2, author, Python requirement, dependencies.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · github.com · revision
8e72ee4· pyproject.toml at · Accessed Oct 5, 2026
Used for: Overview, What you need, Configuration and requirements, Source files and licenses - S005 Stringman documentation home
Room requirements, architecture summary, prototype status, safety and license statements.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · neufangled.com · Page snapshot sha256 94a24898a384… retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S006 Stringman downloads page
Links to software, Arpeggio and Pilot STLs, Onshape CAD, BOM sheets, KiCad PCBs; hardware license statement.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · neufangled.com · Page snapshot sha256 60726ff019ac… retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, Source files and licenses - S007 Stringman Arpeggio BOM — gripper sheet
Gripper parts, batch and unit prices, gripper subtotal.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · docs.google.com · CSV export of the Gripper tab (gid 204754068); snapshot sha256 48f84ee1ea57… · Accessed Oct 5, 2026
Used for: Hardware & parts, Cost, Configuration and requirements - S008 Stringman Arpeggio BOM — anchors sheet
Anchor parts, anchor total and grand total.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · docs.google.com · CSV export of the "2 Anchors" tab (gid 1686100532); snapshot sha256 746062ef0fdc… · Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, Cost, Configuration and requirements - S009 Neufangled Robotics store
Assembled robot and hardware kit list prices.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · neufangled.com · Page snapshot sha256 fa1a853923d3… retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Cost - S010 Stringman Hardware Kit page
Kit price, sold-out state, contents, payload claim, difficulty and pricing basis.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · neufangled.com · Page snapshot sha256 9b44e4bb7dc0… retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 3 more - S011 Stringman Arpeggio print guide
Hardware version, total print time and default print settings.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · neufangled.com · Page snapshot sha256 938360bce80f… retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Is this for you?, Assembly & first use - S012 Stringman system architecture
Component computers, motion controller role and telemetry websocket.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · neufangled.com · Page snapshot sha256 f577fd1e5b17… retrieved 2026-10-05 · Accessed Oct 5, 2026
Used for: Is this for you?, Configuration and requirements - S013 stringman-pcbs repository
KiCad anchor and gripper HAT projects and Gerber packages; no license file identified.Revision, date & where cited
Nathaniel Nifong / Neufangled Robotics · github.com · revision
e56d90b· Filename inventory of archive (commit snapshot, sha256 ac8c6faa9561…) · Accessed Oct 5, 2026
Used for: Source files and licenses - S014 Upstream image and reuse attribution
Media-only review: Photograph of Stringman Arpeggio components laid out: two corner anchors, the hanging gripper and marker pole, mounts and eyelets. This is the component set before room installation; concealed electronics and software revision are not established by the photograph. Reuse basis: CC-BY-SA-4.0. Actual creator documentation names the selected hardware generation Arpeggio, separates Pilot under Earlier Versions, and embeds this own photograph as The parts that make up a Stringman robot. Actual separate Arpeggio Gripper Build Guide expressly says Hardware Version: Arpeggio and ends with the same white covered gripper/black carbon pole/flat marker assembly in complete_gripper.webp. Source imagery shows the two matching corner housings, mounting brackets and eyelets. This is an uninstalled component/context photograph, not a demonstration of the whole suspended room installation. No exact hidden motor/board revision, nf_robot7.0.2 execution, calibration, price or performance is inferred from pixels. The hardware generation matches selected Arpeggio; the software pin is not advanced. Excludes earlier Pilot/Arpeggio hybrid store photographs and NYU or other unrelated robots. The creator homepage expressly grants CC BY-SA4 for its documentation, independently of the design Apache/CERN and software licensing. This first-party documentation photograph carries no separate third-party credit or narrower exclusion. Original WEBP unchanged, automatic display derivatives retain same grant, attribution/source/license and changes notice. Prior facts/costs/source-check dates remain unchanged. Original image unchanged; displayed responsively. Technical/cost evidence dates unchanged.Revision, date & where cited
Neufangled Robotics / Stringman documentation contributors · neufangled.com · Creator documentation, What it is and how it works, image alt The parts that make up a Stringman robot, parts-green.webp; Safety and Legal documentation-specific CC BY-SA4 link; named Arpeggio anchor/gripper guides.; image SHA-256 f5a15bed4ec2bbfd7f5a265728363774d73bb8ba02c5bc67f75972776903782c · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Created from Growbotics-listing lead; all claims checked against preserved upstream sources. No physical build or test.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.