TurtleBot2 (Kobuki era)
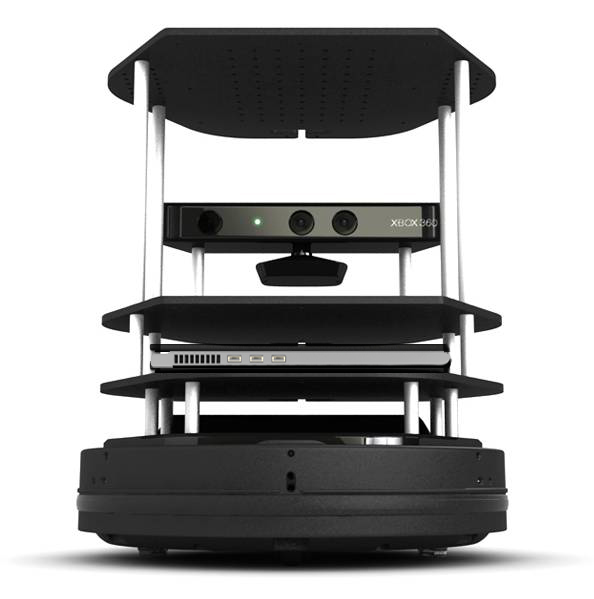
Robot / hardware buildA historical mobile research robot built around a purchased Kobuki base, depth camera and released TurtleBot structure drawings. [1] [2]
Build & first use →Official websiteSource codeBill of materials
- For
- Researchers maintaining a TurtleBot2; Builders studying historical mobile robot design [1]
- Cost
- No current cost yet. Upstream bill of materials [1]
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- not fully assessed for mechanical design, documentation · Details by part
Overview
The TurtleBot on Yale's list is the Kobuki-era TurtleBot2, rather than TurtleBot3 or TurtleBot4. ROS describes a purchased Kobuki base, a ROS-compatible netbook, a depth camera and a structure of plates and poles. The pinned Kobuki resources archive contains DWG and PDF drawings and STEP/IGS models for those structural pieces. That makes this a useful historical design reference, even though it is not a verified complete robot manufacturing package. [1] [2] [4]
Start with the TurtleBot2 platform description to identify the intended camera and host, then inspect the pinned structure drawings and models. A Kobuki STEP model helps fit a plate; it does not establish that the base electronics or mechanics can be fabricated from this repository. The TurtleBot2e guide describes a later DragonBoard/Astra configuration and should not be silently combined with the netbook/Kinect-era design. [1] [2] [3]
ROS describes the TurtleBot project as open hardware and names a documentation license, but this review did not settle reuse rights for every drawing, purchased base component or software layer. It also did not verify current sourcing, a complete delivered cost, a compatible ROS installation or operation of an assembled robot. [1] [2]
Is this for you?
- Known limitations
- The Kobuki resource tree includes structure drawings and a base model, but a model is not proof of open base manufacturing source.
- The TurtleBot2e DragonBoard/Astra revision is separate from the Kobuki/Kinect-era robot Yale describes.
- Current kit sourcing, compatible ROS stack and full electronics rights have not been verified.
Configuration and source-layer limits from the inspected references.
What you need
Hardware & parts
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. Historical TurtleBot2 structure drawings are preserved, but the purchased base and assembly geometry are not reconciled for a preview.
Model sources
Historical TurtleBot2 structure drawings are preserved, but the purchased base and assembly geometry are not reconciled for a preview.
What we checked
Source research only; no fabrication, hardware commissioning, software installation or performance test performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Aug 30, 2020 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 24, 2026
- Next review
- Nov 24, 2026
- Reviewed revision
- Kobuki resources 56ca24d70d697970a1144919c2a8c84fe26dce22 (commit snapshot); historical TurtleBot2 configuration described by ROS · repository
Source files and licenses
The published structural drawings support a historical design-reference profile, with the purchased Kobuki base and unreviewed software explicitly separated.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed Structure plate/pole drawings and model files are inspectable; base model is not manufacturing source for purchased Kobuki. [1] [2] |
| electronics | not found · License not fully assessed No complete Kobuki controller/electronics manufacturing package established in the inspected resources repository. [1] [2] |
| software | not found · License not fully assessed ROS stack is named but not pinned and inspected in this hardware-design reference. [1] |
| documentation | available · License not fully assessed Hardware overview and drawing references are available; the platform page's documentation license does not automatically cover every repository artifact. [1] [2] |
No independent artifact in the selected configuration established during this review.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 ROS TurtleBot2 platform page
Names Kobuki, camera, netbook and structure and links historical design documentation.Revision, date & where cited
Open Robotics / ROS Robots · robots.ros.org · TurtleBot2 hardware and open-source sections · Accessed Oct 24, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 2 more - S002 Pinned Kobuki/TurtleBot2 drawing repository
Contains DWG/PDF and STEP/IGS files for TurtleBot plates, poles and Kobuki model.Revision, date & where cited
Kobuki project contributors · github.com · revision
56ca24d· hardware/drawings and hardware/models · Accessed Oct 24, 2026
Used for: Overview, Is this for you?, What you need, What we checked and 1 more - S003 TurtleBot2e revision guide
Names the SBC/Astra successor configuration; not the Yale-listed exact robot.Revision, date & where cited
TurtleBot community · github.com · revision
c21e07f· README revision definition · Accessed Oct 24, 2026
Used for: Overview, Is this for you? - S004 Yale open robotics hardware listing
Describes a Kinect-equipped TurtleBot built on the Kobuki base.Revision, date & where cited
Yale Grab Lab · eng.yale.edu · TurtleBot listing · Accessed Oct 24, 2026
Used for: Overview - S005 Upstream image and reuse attribution
Media-only review: Upstream photograph of a TurtleBot configuration with its mobile base, sensor and shelves; peripherals vary between builds. Reuse basis: CC-BY-3.0; inspected the published page, image caption and reuse footer; no image-specific exception found for this selected image. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
TurtleBot and ROS Robots contributors · robots.ros.org · Image SHA-256 e8ac278a3fd067caf0318e055ddd8e94601044b0c4e6fefe0b9eab13b6bbf2d3; source revision page SHA-256 2b972d0dcc9d7b13e09918949ba99b9f6bf031c71fad337e00140ff86cb99716 · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.