Wheelbot
Robot / hardware buildReaction-wheel unicycle research platform, scoped to v2.5 CAD and firmware with a documented state-estimation error and historical development tools. [1]
Build & first use →Official websiteBill of materials
- For
- Controls researchers able to fabricate mechanics and commission embedded electronics [1]
- Cost
- No current cost yet. Upstream bill of materials [7]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- GPL-3.0-only · Details by part
Overview
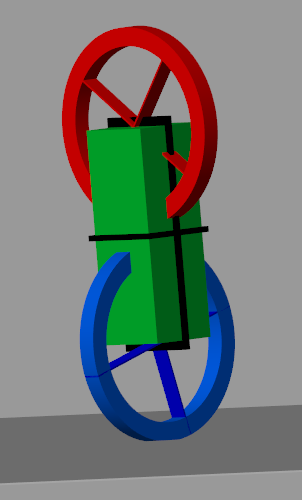
Wheelbot is a reaction-wheel unicycle research platform. This entry covers the v2.5 repository, which supplies mechanical files, motherboard circuitry, embedded firmware and MATLAB/Simulink models. The README links a newer Mini Wheelbot as a separate design; its parts and instructions should not be silently substituted into a v2.5 build. [1] [2]
Is this for you?
- Known limitations
- Pinned firmware retains the body-rate transform identified as erroneous in the README
- Mini Wheelbot is a separate newer design
- Documented simulation and host tools are historical
- No complete current configuration-specific robot budget verified
Code was inspected; no execution or repair validation.
3D preview
Wheelbot v2.5 source-positioned assembly. The complete Wheelbot v2.5 assembly represented by all 31 official STL exports in their shared source coordinate frame. Source directory groups and exported SolidWorks assembly-path names are retained. Display colors only distinguish part categories; joint kinematics, material identity and physical operation are not verified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original source-positioned STL bundle (ZIP) · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Andre Rene Geist and Wheelbot contributors, revision cd3b0945aa3f41ca25f0ad4868fb214ecb8b4de7. Original and preview: GPL-3.0-only. Preview conversion by Open Source Robotics; source files unchanged inside the downloadable bundle. Preview coordinates are centered and rounded to six decimal places. All source STL components retain the shared assembly-coordinate vertices exported by the project; directory groups and assembly-path names are retained, and no component placement was inferred. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
What you need
- Dependencies
- MATLAB/Simulink for documented simulation workflow
- Maevarm M2 and uDriver-v2 hardware/firmware environment
- Historical Python interface described on Ubuntu 18.04
- Tools
- Markforged Onyx One with Onyx material in documented print setup
- Fabrication of copper reaction-wheel rings
- MATLAB/Simulink R2020a recommended by upstream
- Embedded firmware development and board assembly tools
First three are documented; fabrication/embedded skills follow the supplied artifacts.
[1] · Editorial assessment
Hardware & parts
Assembly & first use
- Select v2.5 rather than the linked Mini Wheelbot design
- Inspect the assembly, board files and component list
- Reconcile the documented body-rate transform erratum with the selected firmware
- Prepare simulation using the upstream LQR-design step before the Simulink model
- Commission hardware only after configuration and implementation review
Editorial research sequence; no build, simulation or commissioning performed.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
The archived firmware has a published erratum
The README identifies an incorrect transform from averaged body rates to Euler rates in the original state estimator. The inspected main.c still contains the matrix described as erroneous. Upstream explains that its experiments stayed close to the upright equilibrium, where the transforms were nearly equal; that explanation is not a general validation of the implementation away from upright. The repository includes a notebook explaining the corrected calculation. [1] [5] [6]
Before using this snapshot for a new experiment, reconcile the erratum with the selected firmware and verify the resulting estimator. This publication has not patched, compiled or tested a correction. The known implementation issue is distinct from the broader absence of a reproduction test. [1] [5]
Fabrication includes more than printed parts
The documented print setup uses a Markforged Onyx One, Onyx material and 0.2 mm layers. The mechanical folder also supplies a drawing for cut copper reaction-wheel rings and an interactive assembly PDF. These are useful manufacturing references, but they do not establish that a different print material or an unreviewed wheel substitution will preserve the intended mechanics. [1] [6]
The motherboard connects to a Maevarm M2 and supplies the uDriver-v2. A separate M2 dongle handles wireless communication with the computer. The archived spreadsheet lists motherboard components, package names and part references; it is not a complete robot BOM or a current delivered-build quote. The full cost remains unknown. [1] [7]
Preserve the development environment with the design
The simulation folder separates symbolic dynamics derivation from the Simulink model used for estimator and LQR tuning. The README recommends MATLAB R2020a and says to run the LQR-design step (s00_designLQR) before running s01_unicycle.slx. It describes the Python computer interface on Ubuntu 18.04. Those are historical setup details, not evidence of compatibility with current tool versions. [1]
The repository includes a GPL v3 license. External boards, software libraries and development tools require their own rights and availability checks. This profile records a useful research design and a concrete estimator issue; no manufacturing, firmware build, simulation or physical balancing experiment was performed. [3]
What we checked
Source research only; no installation, physical build or performance test performed. No affiliate links added.
Not yet established
- Requirements: operating system, host computer
Updates
- Upstream last updated
- Mar 4, 2025 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 1, 2026
- Next review
- Oct 31, 2026
- Reviewed revision
- cd3b0945aa3f41ca25f0ad4868fb214ecb8b4de7 (commit snapshot; no published stable release found) · combined hardware and software repository
Source files and licenses
Available project sources support research coverage; complete build and commercial qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · GPL-3.0-only Root GPL v3 license accompanies this archive; external libraries, purchased boards and tools retain separate terms. [1] [3] [6] |
| electronics | available · GPL-3.0-only Root GPL v3 license accompanies this archive; external libraries, purchased boards and tools retain separate terms. [1] [3] [6] |
| firmware | available · GPL-3.0-only Root GPL v3 license accompanies this archive; external libraries, purchased boards and tools retain separate terms. [1] [3] [6] |
| software | available · GPL-3.0-only Root GPL v3 license accompanies this archive; external libraries, purchased boards and tools retain separate terms. [1] [3] [6] |
| documentation | available · GPL-3.0-only Root GPL v3 license accompanies this archive; external libraries, purchased boards and tools retain separate terms. [1] [3] [6] |
This profile selects the mechanical/control research platform, not a learned policy or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 AndReGeist/wheelbot-v2.5: README.md
Revision, date & where cited
github.com · revision
cd3b094· Accessed Oct 1, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 5 more - S002 AndReGeist/wheelbot-v2.5: commit cd3b094
- S003 AndReGeist/wheelbot-v2.5: LICENSE
Revision, date & where cited
github.com · revision
cd3b094· Accessed Oct 1, 2026
Used for: Preserve the development environment with the design, Source files and licenses - S004 AndReGeist/wheelbot-v2.5: files
Revision, date & where cited
github.com · revision
cd3b094· archive file inventory · Accessed Oct 1, 2026 - S005 Wheelbot v2.5 firmware
Revision, date & where cited
github.com · revision
cd3b094· body-rate transform at lines 334-350 · Accessed Oct 1, 2026
Used for: Is this for you?, Assembly & first use, The archived firmware has a published erratum - S006 Wheelbot archive inventory
Revision, date & where cited
github.com · revision
cd3b094· Preserved filenames; not a completeness or manufacturing test · Accessed Oct 1, 2026
Used for: Assembly & first use, The archived firmware has a published erratum, Fabrication includes more than printed parts, Source files and licenses - S007 Motherboard component spreadsheet
Revision, date & where cited
github.com · revision
cd3b094· Extracted cell values from pinned XLSX; board list, not complete robot BOM · Accessed Oct 1, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Fabrication includes more than printed parts - S008 Upstream image and reuse attribution
Media-only review: Upstream illustration of the Wheelbot assembly and wheel arrangement, not a photograph. Reuse basis: GPL-3.0; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Andreas René Geist and Wheelbot contributors · github.com · revision
cd3b094· Image SHA-256 0896179a46c8e0b712a4c5e58880212f62ab00c781aaa80ef455c2066b6bd0ea; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.