Yale OpenHand
End effectorA family of adaptive hands with shared CAD parts and a separate Dynamixel control repository. [1]
Build & first use →Official website
- For
- Research builders evaluating end-effector fabrication and integration [1]
- Cost
- No current cost or bill of materials established yet.
- Source rights
- Named licenses are documented by part. Includes noncommercial terms. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details
Licenses & related hardware
- License
- CC-BY-NC-3.0 (noncommercial) · Details by part
Is this for you?
- Known limitations
- One exact model BOM, hardware/control revision relationship, current fabrication supplies and compatible arm adapter remain unresolved.
- No physical assembly, calibration, performance or support qualification performed.
Source review and explicit limits of this work.
What you need
Hardware & parts
- Hardware configuration
Adaptive grippers
Editorial grouping from hardware design.
[1] · Editorial assessment
Assembly & first use
Cost
No current, complete configuration-specific build cost has been established for this profile.
3D preview
Preview not available yet. The reviewed design license includes a noncommercial restriction. The original design is linked; a hosted derivative needs a separate reuse decision.
Model sources
The reviewed design license includes a noncommercial restriction. The original design is linked; a hosted derivative needs a separate reuse decision.
Project notes
Configuration and sourcing
Model T uses one actuator for adaptive grasping; Model T42 uses two for planar manipulation and precision grasping. This profile compares the family rather than choosing a complete build. Flexure-joint fingers involve molded urethane, so the finger choice changes the fabrication route. [1]
Model-dependent Dynamixel servos, U2D2, external motor supply, printed parts, tendons and finger materials; choose one model before quantities. [1] [2] [3] [4] [5]
Choose model and finger construction, resolve shared SolidWorks parts/configurations, follow fabrication guide, configure servo IDs and check model-specific travel. [1] [2] [3] [4] [5]
Integration
The control README supports T, T42 and O. Standalone Python control uses numpy, scipy and pyserial; the upstream-tested versions are Python 2.7 and 3.6. The documented ROS path uses ROS Kinetic with Python 2. These are historical documented environments, not verified current compatibility. U2D2 supplies communication, not motor power. [1] [2] [3] [4] [5]
What we checked
Source research only. No hardware assembly, performance testing, procurement or support qualification performed.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Oct 26, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
- b10197dcd79e7bcfa92c6d5a0bfa479e6a789fba; Family indexed together; Model T42 is a possible two-actuator review scope, not a selected build
Source files and licenses
Source-researched component coverage; complete build, commercial rights and performance qualification remain separate.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CC-BY-NC-3.0 Hardware CC BY-NC 3.0; separate openhand_node control repository MIT. [1] [2] [3] [4] [5] |
| electronics | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| firmware | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| software | not found · License not fully assessed Inspected sources do not establish a complete revision-matched source set for this layer. This finding does not mean the purchased components are closed source. [1] [2] [3] [4] [5] |
| documentation | available · CC-BY-NC-3.0 Hardware CC BY-NC 3.0; separate openhand_node control repository MIT. [1] [2] [3] [4] [5] |
This configuration is reviewed as a physical end effector with ordinary control, without a selected learned policy or dataset.
Design limits and source rights
One exact model BOM, hardware/control revision relationship, current fabrication supplies and compatible arm adapter remain unresolved. [1] [2] [3] [4] [5]
The hardware uses CC BY-NC 3.0, with attribution and a noncommercial restriction; commercial reuse requires a separate permission basis. The separate openhand_node control repository uses MIT, requiring its copyright and permission notice to be retained. Those licenses do not establish source rights for the purchased components. [1] [2] [3] [4] [5]
This is a source-researched design profile. We have not assembled or tested this configuration; no complete current setup price is established.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 grablab/openhand-hardware: README.md
Revision, date & where cited
github.com · revision
b10197d· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Hardware & parts, Assembly & first use and 3 more - S002 grablab/openhand-hardware: LICENSE.md
Revision, date & where cited
github.com · revision
b10197d· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S003 grablab/openhand-hardware: files
Revision, date & where cited
github.com · revision
b10197d· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S004 control
Revision, date & where cited
github.com · revision
a7feecf· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S005 control_license
Revision, date & where cited
github.com · revision
a7feecf· Accessed Sep 30, 2026
Used for: Is this for you?, What you need, Assembly & first use, Configuration and sourcing and 2 more - S006 Upstream image and reuse attribution
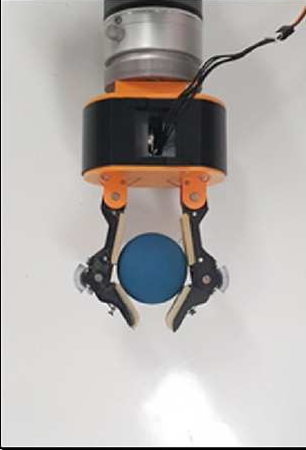
Media-only review: Photograph of the Yale OpenHand Model T42 grasping a ball in the authors’ 2019 experiment; cropped from Figure 12(E). The attached UR5 arm is separate equipment. Reuse basis: CC-BY-4.0. The existing profile indexes the OpenHand family and identifies T42 as a possible review scope, not a selected build. The paper explicitly identifies Figure 12(E) as the Yale Model T42 and describes its own UR5-mounted comparison experiment, rather than crediting this photograph as a third-party reprint. The photographed T42 is the two-finger articulated hand with orange body, black joints and compliant pads, distinct from the paper’s alternative grippers in rows A-D. The caption identifies the historical 2019 experimental configuration; no claim of an exact later CAD revision or selected build. Actual full figure, embedded PDF image and crop visually inspected; no AI editing. The paper’s copyright statement links CC BY 4.0. Embedded image extracted from page 10 of the source PDF and losslessly decoded to PNG; no retouching. Cropped to isolate the Model T42 holding a ball in the leftmost photograph of Figure 12(E); full extracted image retained. Technical/cost evidence dates unchanged.Revision, date & where cited
Che-Ming Chang, Lucas Gerez, Nathan Elangovan, Agisilaos Zisimatos and Minas Liarokapis · frontiersin.org · On Alternative Uses of Structural Compliance for the Development of Adaptive Robot Grippers and Hands, DOI 10.3389/fnbot.2019.00091, page 10, Figure 12(E), leftmost photograph; image SHA-256 5d39e622288c8768d5abcba73c31196728ba0e58ad2c658757555794ace134cc · Accessed Oct 26, 2026
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Deep source acquisition, licensing and configuration review in isolated end-effector research staging.
2026-09-30 — Classified in the end-effector hierarchy with cited mechanism and platform evidence; build and rights limitations retained.
2026-10-26 — Added attributed upstream media with linked reuse terms; technical evidence dates unchanged.