YUBI gripper
End effectorDYNAMIXEL-driven two-finger gripper with a camera, assembly CAD and robot-specific mounting parts. [1]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Robotics researchers evaluating the gripper and its mounting options. [1]
- Cost
- No current cost yet. Upstream bill of materials [2]
- Source rights
- Named licenses are documented by part. Review licenses
- Unknowns
- host computer, tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Overview
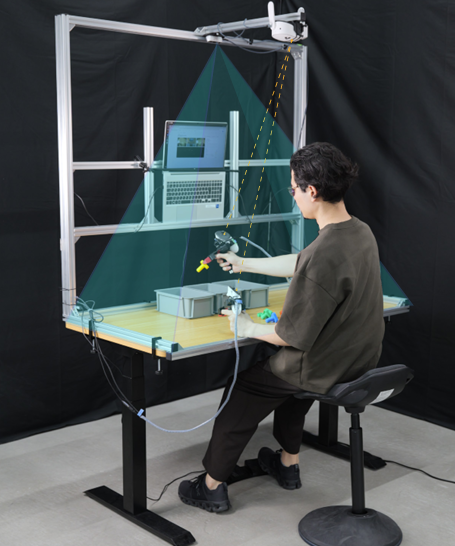
YUBI separates the robot-mounted gripper from its operator glove and data-collection rigs. This profile covers the DYNAMIXEL gripper: the hardware repository supplies an assembly STEP, individual parts, a parts list and an assembly guide. The preview shows the upstream assembly geometry, including representations of purchased components; it is not proof that those components have open manufacturing designs. [1] [2]
Is this for you?
3D preview
YUBI gripper assembly. Assembly geometry from the upstream STEP; purchased components are represented, not separately source-qualified.
The 3D preview loads after the page.
Drag to orbit · Scroll or pinch to zoom · Right-drag to pan. Use the view buttons for front, side and top views. The tree shows names supplied by the source; unnamed bodies remain labeled as such.
Download original STEP · File checksums and provenance
Separate bodies can be inspected in the model tree. Explode is a viewing aid, not an assembly sequence.
Model sources
The preview uses the linked original design. Source grouping is retained where present; the caption identifies whether this is an assembly or one component.
Source, license and scale
Source: Toyota Motor Corporation, revision dd8bd13d2fd8e5003057243576f88be333d95fc5. Original and preview: CERN-OHL-W-2.0. Preview conversion by Open Source Robotics; original file unchanged. Preview coordinates are centered and rounded to six decimal places. STEP preview triangulated in millimetres. No physical part tested.
Viewer: three-cad-viewer 5.0.7 (MIT license). Confirm scale and manufacturing settings before printing.
Hardware & parts
Assembly & first use
Open the upstream getting-started guide [1]
- Assembly
Version-2 illustrated guide covers servo, gear train, fingers, camera and UR5e attachment.
Cost
No current, complete configuration-specific build cost has been established for this profile.
Project notes
Printed parts are only part of the build
The version-2 gripper BOM specifies one XM430-W350-R servo, an ELP-USBFHD01M-L180 camera, two spur gears, three bearings, shafts, inserts, fasteners and rubber contact sheets. The case and several other parts are PLA; the gear shaft is machined A2024 aluminum, while the two finger attachments allow machined or printed alternatives. The UR5e mounting bracket and flange are also listed as machined A2024 parts. Obtain machining and purchased-component quotes before treating the CAD download as a printable complete gripper. No current complete price is established. [2]
The assembly guide proceeds through inserts and locating pins, servo wheel and shaft, finger pads, gear train, upper plate, flaps, camera and UR5e mounting. One ordering discrepancy needs resolution: the guide names SB-304540 inserts for the upper plate, while the BOM groups four SB-304550 inserts. Confirm the intended insert against the hole geometry before ordering. [2] [3]
Choose the mount and control path separately
The current README lists Franka, OpenArm and Unitree G1 flanges; the preserved gripper BOM and assembly guide describe a UR5e configuration. Those are distinct mounting paths, not interchangeable instructions. The cobot tag records documented interface evidence, not a tested fit or a safety certification. [1] [2] [3]
The linked software repository describes operator-side bringup: encoder and camera inputs, Docker/Compose, ROS 2 and separate data-collection services. Its quick setup remains marked under construction. That README does not establish a matched robot-side XM430 control and power setup for this mechanical assembly; resolve the actuator interface, supply and travel calibration before a powered build. [6]
Toyota releases the hardware under CERN-OHL-W-2.0. Its commercial-use guide permits manufacturing and sale subject to that license and explains source and notice obligations. No hardware assembly or performance test was performed for this profile. [4] [5]
What we checked
Source research only. No physical build, procurement, calibration or performance testing.
Not yet established
- Requirements: operating system, host computer, tools
- A step-by-step setup summary
Updates
- Upstream last updated
- Not established
- Latest release
- Not established
- Profile updated
- Sep 30, 2026
- Sources last checked
- Sep 30, 2026
- Next review
- Oct 30, 2026
- Reviewed revision
dd8bd13
Source files and licenses
Licensed mechanical source is available; purchased components and complete robot integration are not fully open or verified.
| Layer | Availability / license |
|---|---|
| mechanical design | available · CERN-OHL-W-2.0 Repository hardware license; purchased components retain their own rights. [1] [4] |
| electronics | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. [1] [2] |
| firmware | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. [1] [2] |
| software | not found · License not fully assessed No complete matched robot-side source set established in the inspected mechanical repository and parts list; purchased parts require separate review. This does not assert that all related code is absent. The linked operator-side software README is inspected separately (S006); it does not establish matched actuator control. [1] [2] [6] |
| documentation | available · CERN-OHL-W-2.0 Repository hardware license; purchased components retain their own rights. [1] [4] |
Mechanical tooling profile without a selected learned controller or dataset.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Hardware overview
Revision, date & where cited
Toyota Motor Corporation · github.com · revision
dd8bd13· README.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Assembly & first use and 2 more - S002 Version-2 gripper BOM
Revision, date & where cited
Toyota Motor Corporation · github.com · revision
dd8bd13· docs/BOM/YUBI Gripper_DYNAMIXEL_BOM.md at · Accessed Sep 30, 2026
Used for: Overview, Is this for you?, Hardware & parts, Printed parts are only part of the build and 2 more - S003 Gripper assembly guide
Revision, date & where cited
Toyota Motor Corporation · github.com · revision
dd8bd13· docs/AssemblyInstruction/YUBI Gripper_DYNAMIXEL_AssemblyGuide.pdf at · Accessed Sep 30, 2026
Used for: Is this for you?, Assembly & first use, Printed parts are only part of the build, Choose the mount and control path separately - S004 Hardware license
Revision, date & where cited
Toyota Motor Corporation · github.com · revision
dd8bd13· LICENSE at · Accessed Sep 30, 2026
Used for: Choose the mount and control path separately, Source files and licenses - S005 Commercial use guidance
Revision, date & where cited
Toyota Motor Corporation · github.com · revision
dd8bd13· COMMERCIAL.md at · Accessed Sep 30, 2026
Used for: Choose the mount and control path separately - S006 YUBI operator-side software README
Operator-side stack, not a verified actuator bringup.Revision, date & where cited
AIRoA contributors · github.com · revision
1eccb04· README.md at · Accessed Sep 30, 2026
Used for: Choose the mount and control path separately, Source files and licenses
Correction guidance · Discussion is not enabled · Profile format 0.6.0-draft.1
Change history
2026-09-30 — Replaced duplicate CAD still with an attributed upstream image; image scope and reuse evidence reviewed.