Zeroth-01 Bot
Robot / hardware buildSmall 3D-printed humanoid using sixteen Feetech serial-bus servos and a Milk-V Duo S; the main repository is now a pointer, so the BOM and STLs come from the separate docs repository. [1] [2] [5] [7]
Build & first use →Official websiteUpstream build guideBill of materials
- For
- Hobbyists and developers comfortable with 3D printing, serial-bus servos, embedded Linux images and Python [1] [5] [11]
- Cost
- USD 350.00 upstream parts estimate [1] [10] · checked Oct 5, 2026 · DetailsNot included: 3D printing filament and printer time, fasteners and wiring (not itemized) and tools and more.
- Source rights
- Some licenses are unresolved. Review licenses
- Unknowns
- tools, operating system not fully established. Review gaps
Source researched · Not tested by us
Sources checked · Research details

Licenses & related hardware
- License
- MIT · license not fully assessed for mechanical design, software · Details by part
Overview
Zeroth-01 is a small 3D-printed humanoid intended for sim-to-real reinforcement learning, vision and speech. Its README calls it a public beta with breaking changes expected and a stable V1.0 planned for June 2025. The docs pages call it a public alpha. No stable release appeared among the first 100 release entries checked for the repository. [1] [2] [5]
Is this for you?
- Use cases
- Basic locomotion, vision and speech demos
- Sim-to-real RL policy deployment experiments
- Known limitations
- Main repository pinned snapshot contains only README, LICENSE, an image and submodule pointers
- Docs first-run steps reference experiments/run.py, which the cleanup commit removed from the main repository
- BOM is marked not finalized; servo price varies by seller; fasteners and wiring not itemized
- Editable CAD is an external Onshape document that was not preserved
- License coverage of the STL package in the docs repository is not established
- Current kos-zbot installation guide targets a Raspberry Pi 4B, while the November 2024 BOM lists a Milk-V Duo S
- No physical build, flashing or locomotion test performed for this profile
Source-review findings; no hardware tests.
What you need
- Dependencies
- OpenLCH buildroot image for the Milk-V
- Python 3.12 conda environment for the SDK and inference script
Hardware & parts
Upstream bill of materials [5]
- Actuators
- 16 x Feetech STS3250 serial bus servos (STS3215 described as too slow for the legs)
- Controller
Milk-V Duo S with a Waveshare bus servo adapter
- Sensors
- 9-DOF IMU
- RP2040 LCD board listed as LCD IMU
- Milk-V CAM-GC2083 camera
- Electret microphone
- Power
RC LiPo battery with a 12 V to 5 V, 3 A converter
Assembly & first use
Open the upstream getting-started guide [5] · Project documentation [10] [12]
- Confirm the current servo and controller choice (docs mark the BOM as not finalized)
- Print the November 2024 STL package or export from the Onshape CAD
- Assemble legs, torso and arms following the step headings
- Flash the OpenLCH image to an SD card and connect to the Milk-V over USB
- Locate the matching inference code, since experiments/ is absent from the current main repository
Editorial reading order across preserved sources; not a reproduced build.
- Assembly
Step-by-step photo guide from ankle servos through legs, torso, shoulders, arms and hands.
Cost
Not stated; listed suppliers include AliExpress, Amazon, Adafruit, Waveshare and DigiKey · Checked 2026-10-05
| Included | Electronics and actuator components on the BOM page (servos, controller, servo adapter, IMUs, camera, battery, converter, audio parts) |
|---|---|
| Not included | 3D printing filament and printer time; Fasteners and wiring (not itemized); Tools; Shipping and taxes; Assembly work |
| Stock | Servo price and stock depend on seller; not re-quoted. |
| Delivery and tax | Not established; no delivered total. |
Price details
Upstream "starts at $350" statement. The 11/28/2024 BOM page lists individual amounts but marks the BOM not finalized and says the servo price depends on the seller (previously 222.24 for sixteen). Not a fresh quote.
Not stated; listed suppliers include AliExpress, Amazon, Adafruit, Waveshare and DigiKey · Checked 2026-10-05 · Quantity 1
Printed parts, fasteners, charger and a host computer must be reconciled separately.
Cost and licensing
Both the README and the docs home page say the BOM starts at USD 350. The BOM lists the servo price as dependent on the seller, previously USD 222.24 for sixteen. Printing, fasteners, tools, shipping and taxes are not covered by any figure we found. [1] [5] [10]
The main repository is MIT-licensed, but it now holds little besides the README. The docs repository's MIT text names Shu Ding as copyright holder, and it is not established whether that license was meant to cover the STL package stored there. No license was identified for the Onshape CAD. No license file was found in the kos-zbot archive; ksim-gym-zbot is MIT. [3] [9] [13] [14]
3D preview
Preview not available yet. Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Model sources
Design-source links are available. A configuration-matched assembly and its file-level reuse scope have not yet been reviewed for a hosted preview.
Project notes
Where the sources are
A May 2025 "Clean up" commit removed the experiments folder, its teleoperation URDF meshes and other files from zeroth-robotics/zeroth-bot. At the pinned commit, the repository holds only a README, a license, one image and two submodule pointers to K-Scale Labs repositories. The README sends builders to K-Scale's documentation site, which we did not preserve. This review instead uses the separate zeroth-robotics/docs repository, last committed in December 2024. It holds the BOM, the printing and assembly guides, and the STL package. [1] [2] [4] [12]
Configuration documented in November 2024
The BOM page, dated 11/28/2024 and marked not finalized, lists:
- sixteen Feetech STS3250 serial-bus servos (the note says STS3215 servos are too slow for the legs);
- a Milk-V Duo S controller and a Waveshare bus servo adapter;
- an RP2040 LCD board, a 9-DOF IMU and a Milk-V camera;
- an RC LiPo battery, a 12 V to 5 V 3 A converter, and a microphone, speaker and amplifier.
Fasteners and wiring are not itemized. The assembly steps place servos at the ankles, knees, hips, shoulders and elbows. We infer sixteen degrees of freedom from that, but the docs give no explicit count. [5] [8]
The printing guide links an Onshape CAD document, which was not preserved, and a November 2024 STL zip. It recommends 0.16 mm layers, five wall loops and tree supports. The assembly checklist names head, neck and mounting back plates. The zip contains Head and Neck files, but no file named for a mounting back plate; we did not check whether the zip's 3MF print plate includes one. [6] [7] [8]
Software no longer matches the docs
The first-run page clones zeroth-bot and runs experiments/run.py, a path the cleanup commit removed. The setup page flashes an OpenLCH image to the Milk-V. The current kos-zbot installation guide instead lists a Raspberry Pi 4B and a BNO055 IMU as prerequisites. That suggests the software has moved to different hardware than the November 2024 BOM, though this is our inference. We preserved the current default branches of kos-zbot and ksim-gym-zbot, not the submodule commits pinned by zeroth-bot. [2] [4] [11] [13] [14]
Before printing or ordering
As editorial guidance from the gaps above: confirm with the maintainers or community which controller, servo and software combination is current. Reconcile the mounting back plate against the print package. Get current servo prices and budget separately for the parts no figure covers.
No printing, assembly, flashing or walking test was performed for this profile.
What we checked
Source research only; no printing, assembly, flashing or locomotion test performed. No affiliate links added.
Not yet established
- Requirements: operating system, tools
Updates
- Upstream last updated
- May 24, 2025 [2]
- Latest release
- Not established
- Profile updated
- Oct 25, 2026
- Sources last checked
- Oct 5, 2026
- Next review
- Nov 5, 2026
- Reviewed revision
- 97bf404c26ed10253e8426ff797a6a1ad3dc3b24 (commit snapshot; no published stable release found); docs 4b8db2311228a445c9d0d6264e02f3a8b102831c · combined hardware and software repository
Source files and licenses
An STL package, BOM and assembly guide survive in the docs repository; editable CAD is external, software lives in unreviewed submodules and STL license coverage is unclear.
| Layer | Availability / license |
|---|---|
| mechanical design | available · License not fully assessed STL zip (November 2024) is in the docs repository, whose only license file is an MIT text naming Shu Ding; whether it was meant to cover the STLs is not established. Editable CAD is an external Onshape document; no license identified for it. [6] [7] [9] |
| electronics | not found · License not fully assessed Purchased modules only; the releases table leaves the schematics entry blank. [5] [10] |
| firmware | not found · License not fully assessed No embedded firmware source identified; servos are Feetech units. kos-zbot is a Python service and OS image tooling for the robot computer, recorded under software. [4] [13] |
| software | available · License not fully assessed Current default branches of kscalelabs/kos-zbot (no license file identified in the inspected archive) and kscalelabs/ksim-gym-zbot (MIT) were preserved; the submodule commits pinned by zeroth-bot (5b728967, 022f5cd6) were not. The docs inference script path no longer exists in the main repository. [1] [4] [13] [14] |
| model weights | not found · License not fully assessed The docs refer to a premade inference model; no model file or terms were identified in the preserved sources. [11] |
| documentation | available · MIT Docs repository is MIT-licensed as declared; copyright line names Shu Ding, which may come from a site template (inference). [9] [12] |
No dataset is part of the reviewed build configuration.
References
Each source links to the exact revision we read. “Used for” shows where this page relies on it.
- S001 Zeroth-01 Bot README
Project status, $350 BoM statement, pointers to K-Scale docs and submodules, MIT statement.Revision, date & where cited
Zeroth Robotics / zeroth-bot contributors · github.com · revision
97bf404· README.md at 97bf404c · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Cost, Where the sources are and 1 more - S002 Repository revision, cleanup commit and acquisition metadata
Selected commit, removed paths in the cleanup commit, archive checksum and dated popularity counts.Revision, date & where cited
Zeroth Robotics / zeroth-bot contributors · github.com · revision
97bf404· "Clean up (#98)"; default-branch snapshot, no stable release in first 100 · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, Assembly & first use, Where the sources are and 2 more - S003 zeroth-bot repository license (MIT)
MIT text, copyright 2024 Jingxiang Mo.Revision, date & where cited
Zeroth Robotics / zeroth-bot contributors · github.com · revision
97bf404· Accessed Oct 5, 2026
Used for: Cost - S004 zeroth-bot pinned archive inventory and submodule map
Archive holds README, LICENSE, an image and empty submodule paths pointing to kscalelabs repositories.Revision, date & where cited
Zeroth Robotics / zeroth-bot contributors · github.com · revision
97bf404· archive member list; .gitmodules; Git tree API entries (submodule pins) · Accessed Oct 5, 2026
Used for: Is this for you?, Where the sources are, Software no longer matches the docs, Source files and licenses - S005 Bill of Materials page source
Component list, quantities, listed USD amounts and the STS3250 servo note.Revision, date & where cited
Zeroth Robotics / docs contributors · github.com · revision
4b8db23· pages/build/bom.mdx (last updated 11/28/2024) · Accessed Oct 5, 2026
Used for: Overview, Is this for you?, What you need, Hardware & parts and 4 more - S006 3D printing guide source
Onshape CAD link, STL zip link, print settings and printed part names.Revision, date & where cited
Zeroth Robotics / docs contributors · github.com · revision
4b8db23· Accessed Oct 5, 2026
Used for: Is this for you?, Hardware & parts, Assembly & first use, Configuration documented in November 2024 and 1 more - S007 STL package file listing
File names and sizes inside the November 2024 STL package.Revision, date & where cited
Zeroth Robotics / docs contributors · github.com · revision
4b8db23· public/20241118stl.zip member names (nested archive; listing only, no geometry check) · Accessed Oct 5, 2026
Used for: Configuration documented in November 2024, Source files and licenses - S008 Assembly guide source
Printed-part checklist and assembly step headings.Revision, date & where cited
Zeroth Robotics / docs contributors · github.com · revision
4b8db23· Accessed Oct 5, 2026
Used for: Hardware & parts, Assembly & first use, Configuration documented in November 2024 - S009 Docs repository license
MIT text with copyright line "2022 Shu Ding".Revision, date & where cited
Zeroth Robotics / docs contributors · github.com · revision
4b8db23· Accessed Oct 5, 2026
Used for: Is this for you?, Cost, Source files and licenses - S010 Docs overview, releases and about pages
$350 starting price statement, release table and named creators.Revision, date & where cited
Zeroth Robotics / docs contributors · github.com · revision
4b8db23· pages/index.mdx; pages/releases.mdx; pages/about.mdx · Accessed Oct 5, 2026
Used for: Assembly & first use, Cost, Source files and licenses - S011 Software setup and first-run page sources
OpenLCH image flashing, Milk-V connection and experiments/run.py inference instructions.Revision, date & where cited
Zeroth Robotics / docs contributors · github.com · revision
4b8db23· pages/build/setup.mdx; pages/build/run.mdx · Accessed Oct 5, 2026
Used for: Is this for you?, What you need, Assembly & first use, Software no longer matches the docs and 1 more - S012 Docs repository revision and acquisition metadata
Selected docs commit and archive checksum.Revision, date & where cited
Zeroth Robotics / docs contributors · github.com · revision
4b8db23· ; default-branch snapshot · Accessed Oct 5, 2026
Used for: Assembly & first use, Where the sources are, Source files and licenses - S013 kos-zbot repository (current default branch)
Robot-side Python service and Raspberry Pi 4B image tooling; no license file in the archive. Not the submodule commit pinned by zeroth-bot.Revision, date & where cited
K-Scale Labs / kos-zbot contributors · github.com · revision
fce2882· default-branch snapshot; README.md, Installation.md, archive inventory · Accessed Oct 5, 2026
Used for: Is this for you?, Cost, Software no longer matches the docs, Source files and licenses - S014 ksim-gym-zbot repository (current default branch)
RL training template and MIT license. Not the submodule commit pinned by zeroth-bot.Revision, date & where cited
K-Scale Labs / ksim-gym-zbot contributors · github.com · revision
a482112· default-branch snapshot; README.md, LICENSE · Accessed Oct 5, 2026
Used for: Cost, Software no longer matches the docs, Source files and licenses - S015 Upstream image and reuse attribution
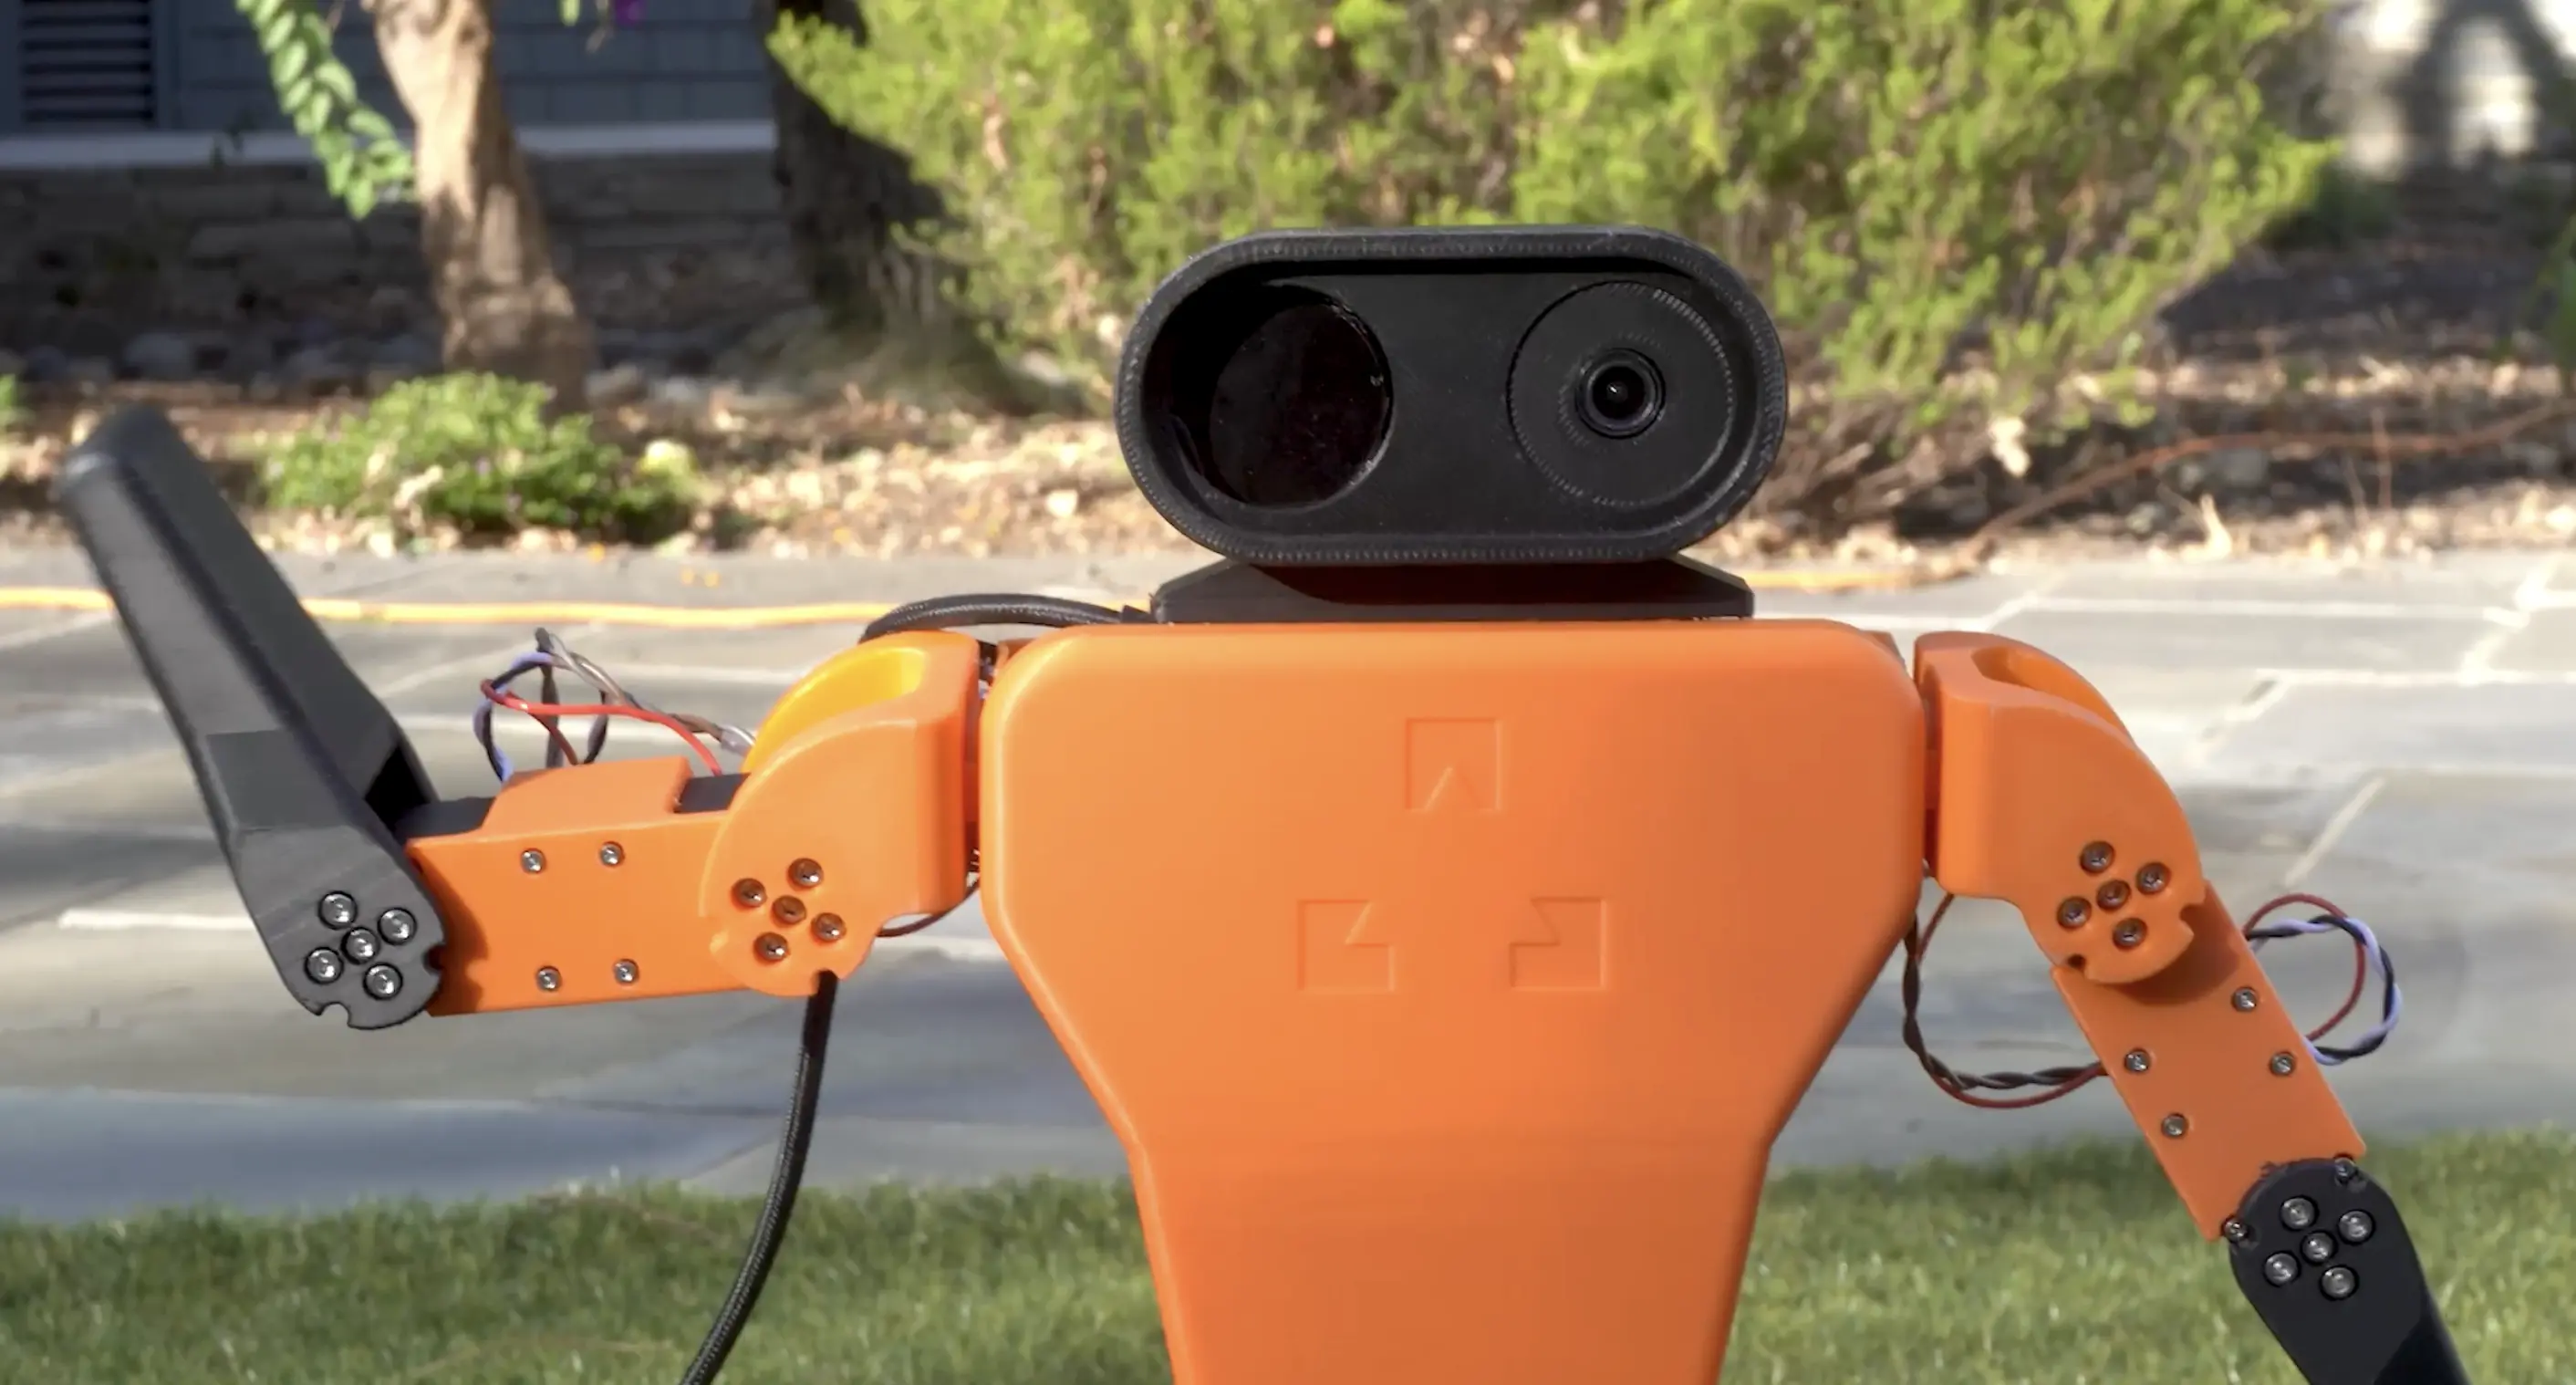
Media-only review: Upstream photograph of the Zeroth Bot humanoid outdoors. Reuse basis: MIT; inspected LICENSE and the pinned file inventory for nearer notices. Original image unchanged; displayed responsively. This does not refresh technical or cost evidence.Revision, date & where cited
Jingxiang Mo and Zeroth Robotics contributors · github.com · revision
97bf404· Image SHA-256 d43c26b93674e217c4d797985fbab37a976af8910fb29bc3c570e524b4e67e4f; repository · Accessed Oct 25, 2026
Correction guidance · Discussion is not enabled · Profile format 0.7.0-draft.5
Change history
2026-10-05 — Initial source-researched profile from main repository 97bf404c and docs repository 4b8db231.
2026-10-25 — Added an attributed upstream image with linked reuse terms; technical evidence dates unchanged.