Legged robots & hardware
CMU MicroDuck
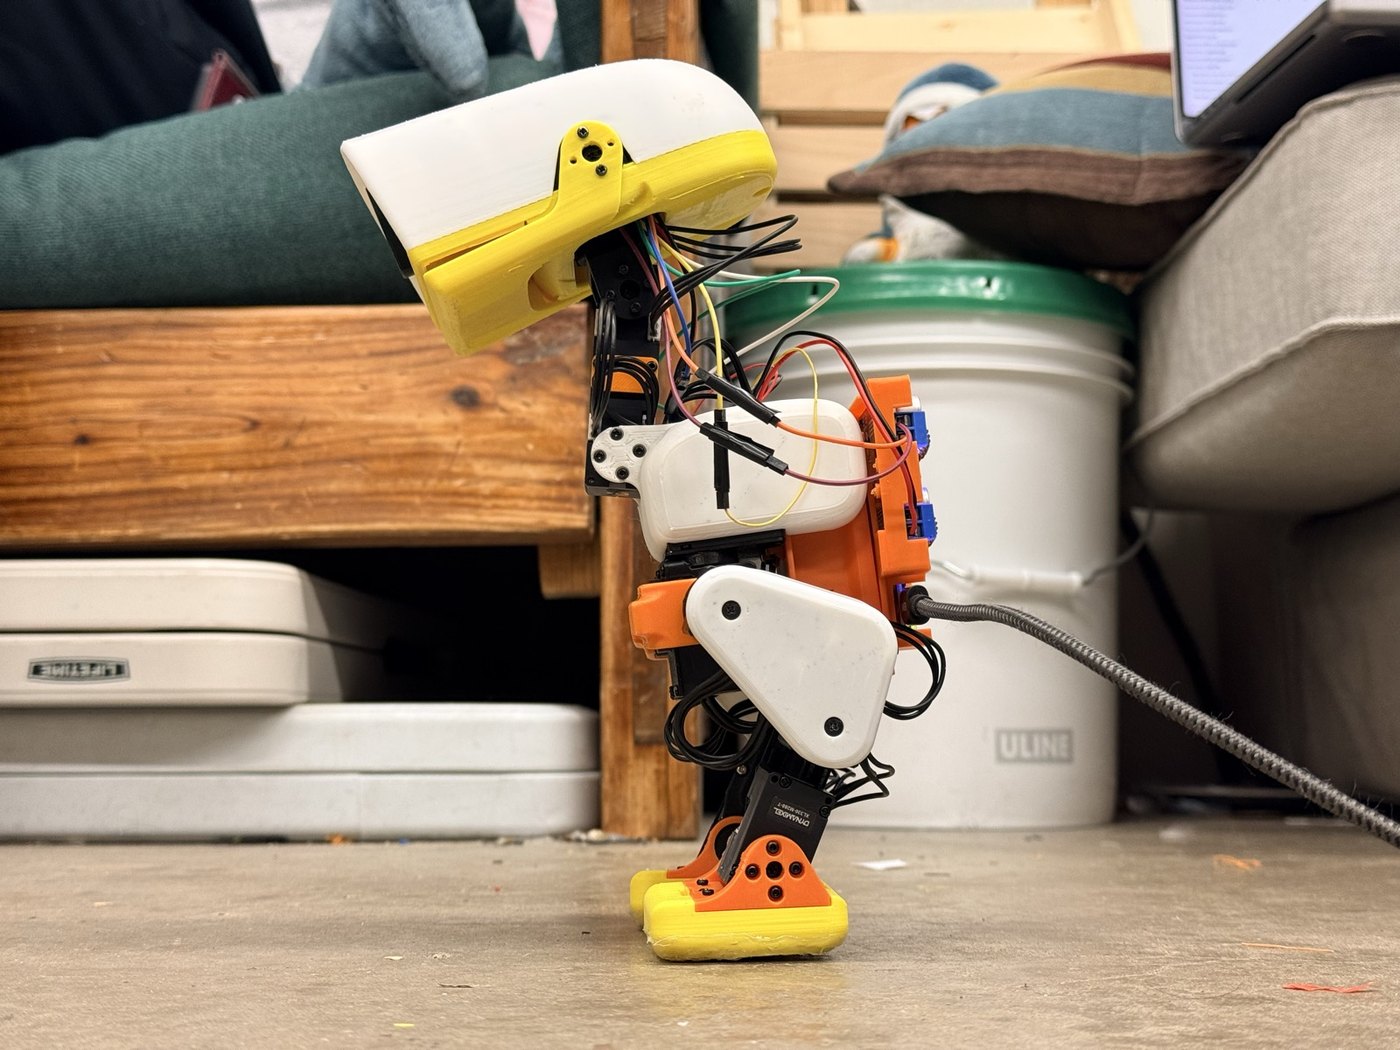
CMU RoboClub’s 15-joint MicroDuck build with a Radxa head computer and touch-sensitive cap.
Robots, controllers, sensors and other physical components. Grippers, hands and tools are under End effectors.
183 entries · Newest published first
Source researched · Not hands-on tested
Legged robots & hardware
CMU RoboClub’s 15-joint MicroDuck build with a Radxa head computer and touch-sensitive cap.
Arms & manipulation hardware
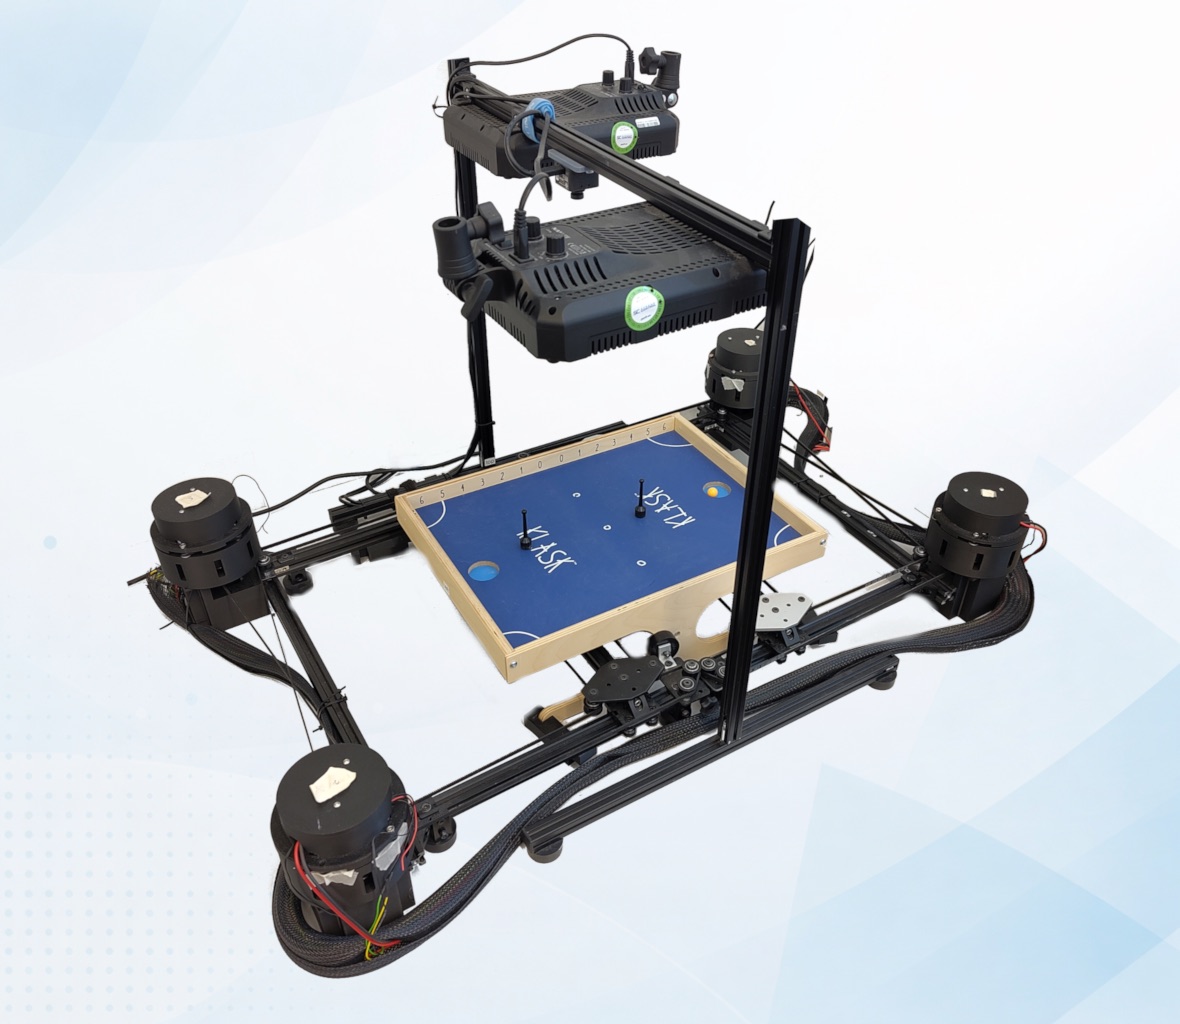
Desktop robotic KLASK game table with motorized magnetic pegs, overhead vision and ROS 2 control.
Arms & manipulation hardware
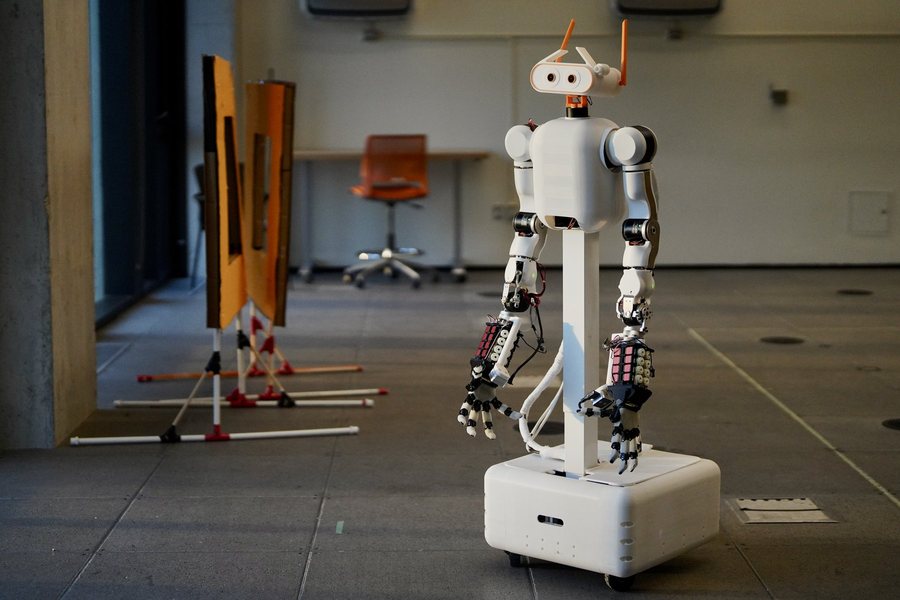
Wheeled bimanual research robot with dexterous hands, a lifting torso, and teleoperation and learning software.
Desktop leader–follower arm pair
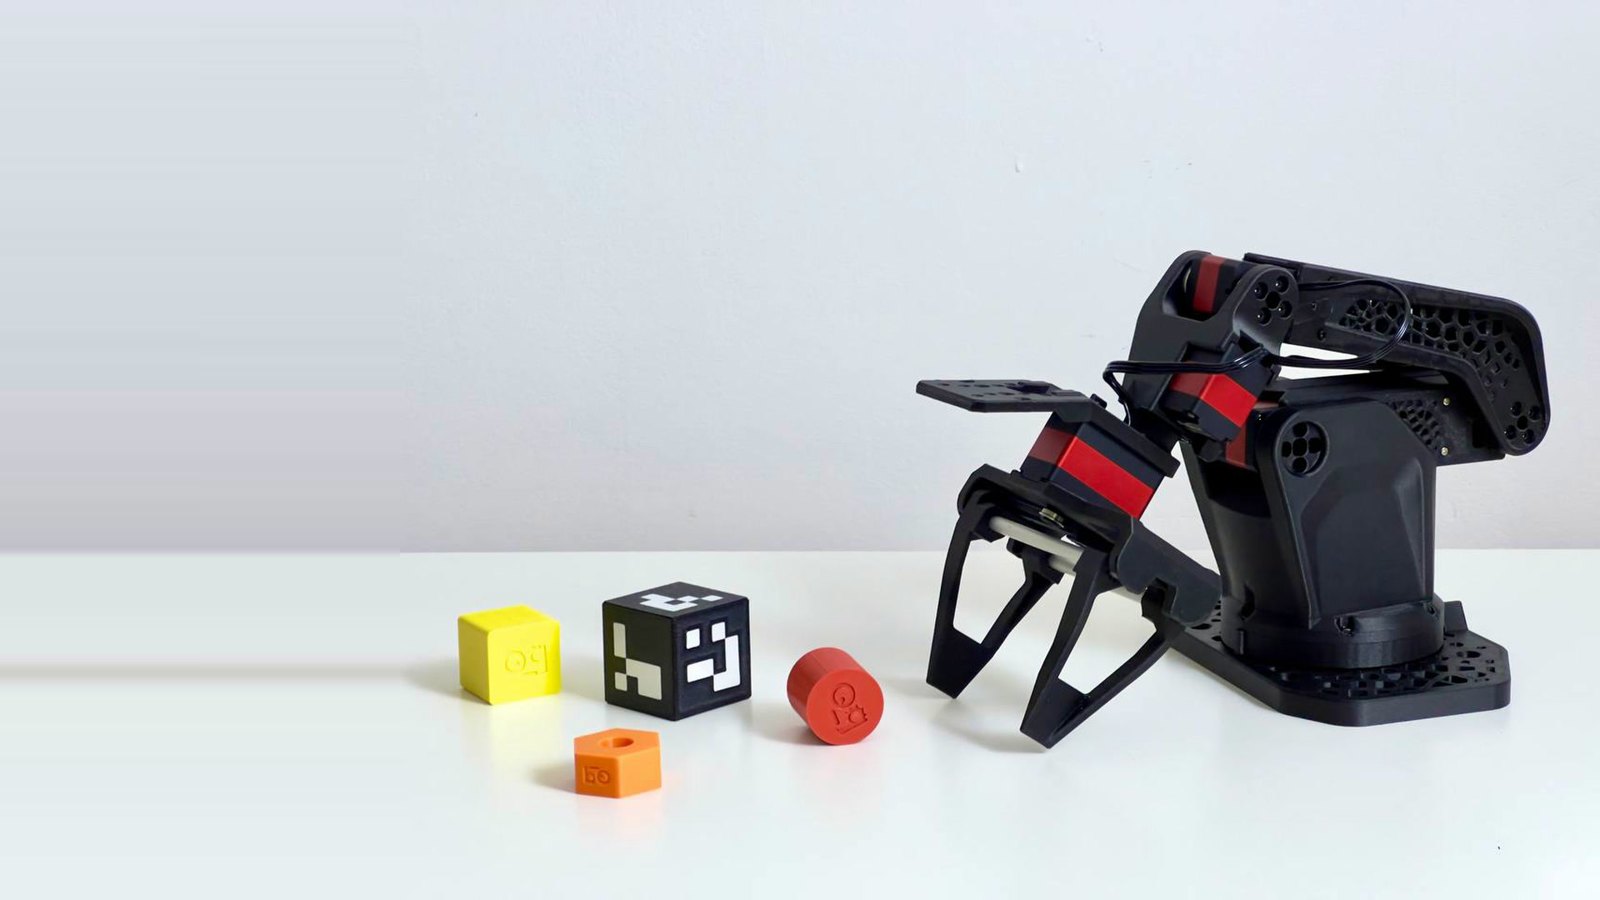
Printable leader–follower robot arms for LeRobot teleoperation, with mixed-voltage serial servos and a parallel gripper.
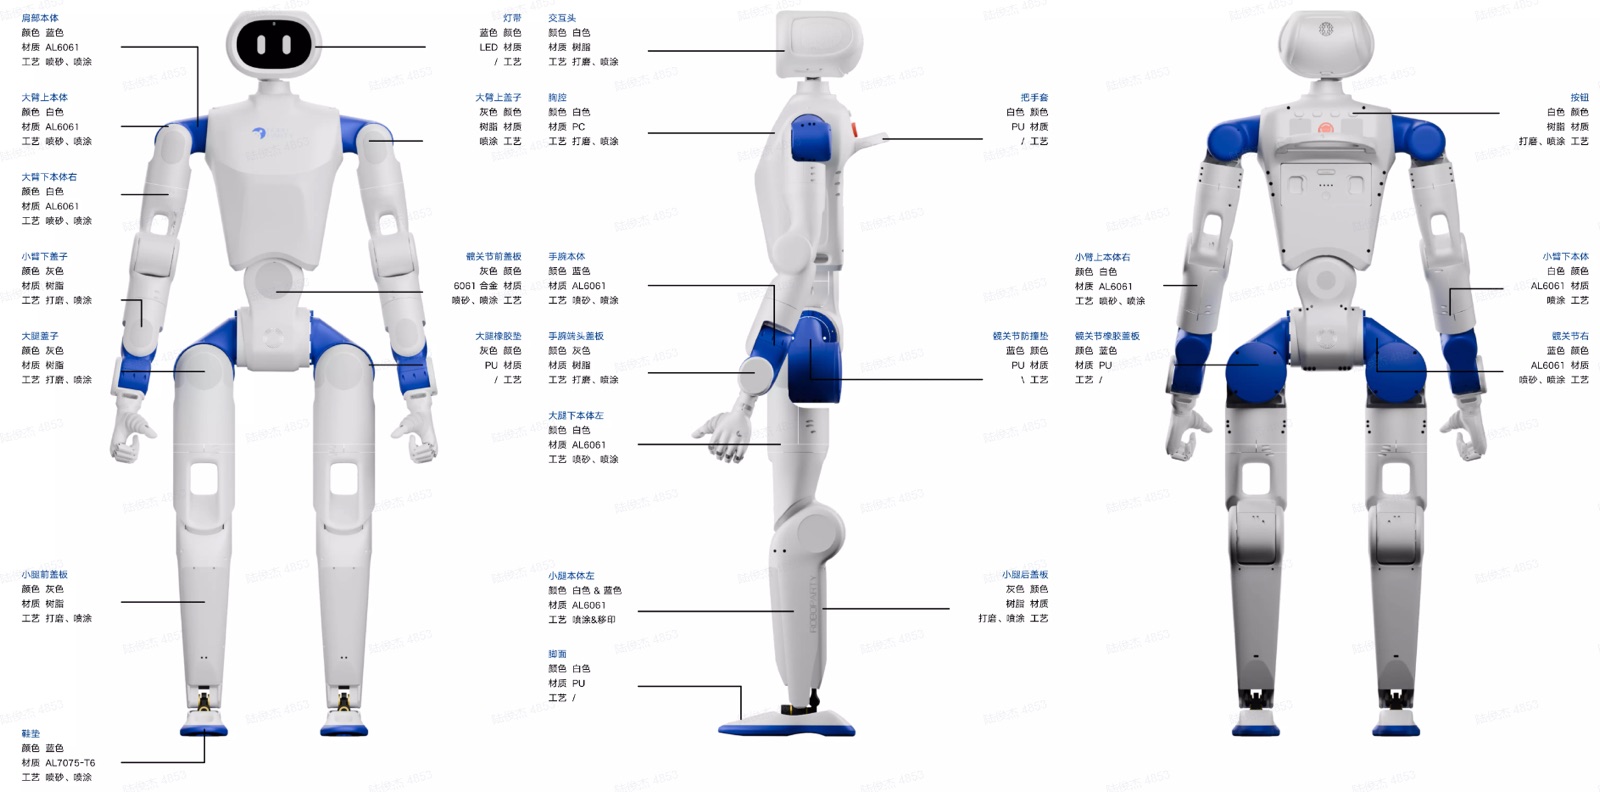
Full-body bipedal humanoid
Bipedal humanoid with released SolidWorks source, board fabrication data and separate control and simulation repositories.
Legged robots & hardware
Parametric Grasshopper and Rhino examples for 3D-printed compliant muscles and ligaments used in tendon-driven robots.
Small biped with neck motor
Printable small biped design using eleven Unitree 8010 motors and a Raspberry Pi 4B reference controller.
Differential-drive wheeled mobile robot
Differential-drive educational robot built around a Raspberry Pi 5 and a Pico-based control board.
Other robotics hardware
Small vibration-driven swarm robot platform with manufacturing files, shell design and embedded C examples.
Other robotics hardware
Zynq XC7Z020-based robot control interface board design reference with dual Ethernet and Altium sources.
Other robotics hardware
Jubilee-related biopaste extrusion-tool design with auger and plunger variants and unfinished fabrication/operation documentation.
Other robotics hardware
Load-cell interface design intended to convert a 0–5 V sensor output into a Pi-readable I2C sensing path.
Other robotics hardware
Syringe extrusion end-effector for gels and pastes using printed and purchased parts on a separate Jubilee platform.
Other robotics hardware
Tape-feeder hardware component for the LumenPnP pick-and-place platform, with FreeCAD mechanical design and KiCad electronics.
Other robotics hardware
Repair-oriented Kilobot hardware revision with KiCad design and a separately sourced overhead-controller/firmware workflow.
Other robotics hardware
Four-channel amplifier board source-design reference with Altium circuit/PCB and hardware-revision notes.
Other robotics hardware
Humanoid force-sensing foot component with strain-gauge sampling board and AVR Dynamixel-bus firmware.
Control board
AVR servo-controller board with Eagle circuit/board design and Arduino-compatible control source.
Other robotics hardware
Raspberry Pi 3/Camera V2 vision enclosure and holder design reference with historical ROS-system documentation.
Other robotics hardware
Electronics design reference for the Open Bionics hand ecosystem, with Eagle source and a draft parts list.
Other robotics hardware
ESP32-S3/TMC2209 stepper-driver component with TLE5012B feedback and inspectable EasyEDA schematic/PCB source.
Other robotics hardware
Robot mechanical parts, Teensy-oriented electronics and experimental embedded-control source with sparse build documentation.
Other robotics hardware
ESP32 communication/controller-board component linking robot sensor/actuator data to a host over raw Ethernet or ESP-NOW.
Other robotics hardware
Power-distribution/switching circuit and incomplete STM32 control/telemetry firmware design reference.
Other robotics hardware
Twelve-servo quadruped design with printable or laser-cut parts, XBoard electronics and Maple Mini firmware.
Other robotics hardware
Two-joint underactuated control testbench with two T-Motor actuators and selectable active/passive joint configurations.
Other robotics hardware
Three-link brachiation research robot with a tail, passive grippers and two QDD actuators; source includes inherited AcroMonk material that needs configuration reconciliation.
Other robotics hardware
Single-actuator pendulum control testbench with a fabricated mount/lever, source CAD and Python simulation/controller implementations.
Arms & manipulation hardware
Metal-arm leader/follower data-collection platform with single, dual and four-arm software configurations; the original CyberGear-hand assembly must be kept separate from the RobStride01-hand variant.
Legged robots & hardware
Metal-fabricated quadruped research platform with 12 RobStride03 motors, a ROS control package and MuJoCo descriptions; assembly files and parts lists are separate Drive snapshots.
From JPY 1,935,800.50 upstream estimate
Humanoids
Six-servo Otto humanoid with V12 printable designs and a separately supplied historical control bundle; the four-servo base robot and newer alternatives are distinct.
Humanoids
Printable humanoid with released STL and editable Fusion models, Arduino firmware, board-design sources and a legacy host-tool workflow.
Wheeled robots & hardware
Dual-arm wheeled manipulator with two SO-101 follower arms, a cart-mounted omni-wheel base and a LeRobot plugin route; costs and files depend on configuration.
About USD 660.00 upstream estimate
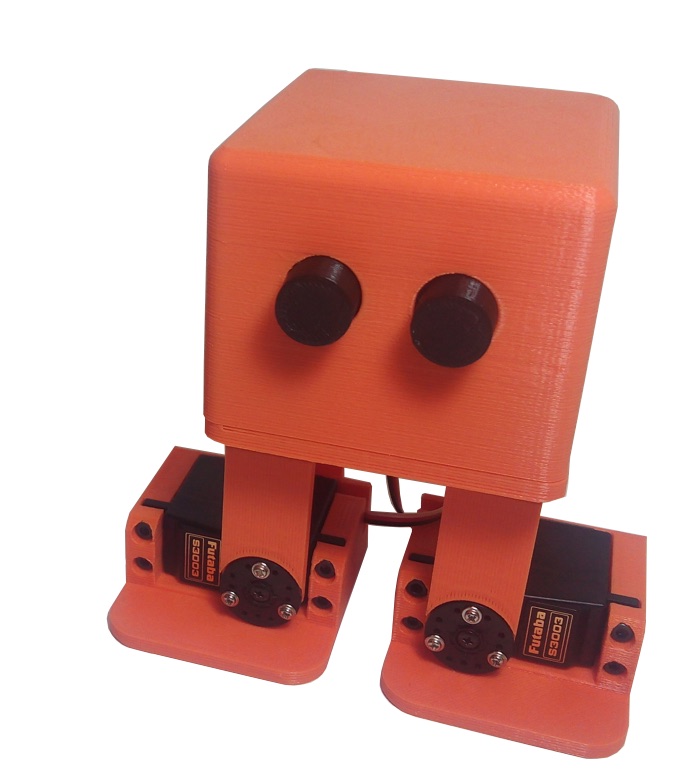
Legged robots & hardware
Historical four-servo educational biped with FreeCAD sources, printable parts and Arduino calibration/motion code; selected coverage is the original printable design.
Wheeled robots & hardware
A self-balancing wheel-biped hardware reference with aluminum profiles and released assembly CAD; controls, complete costs and exact reuse terms remain unresolved.
Wheeled robots & hardware
A four-wheel-legged research robot with front hip-yaw steering, STEP design files and ROS 2/HIMLoco control sources; project-wide reuse rights and complete build costs are unresolved.
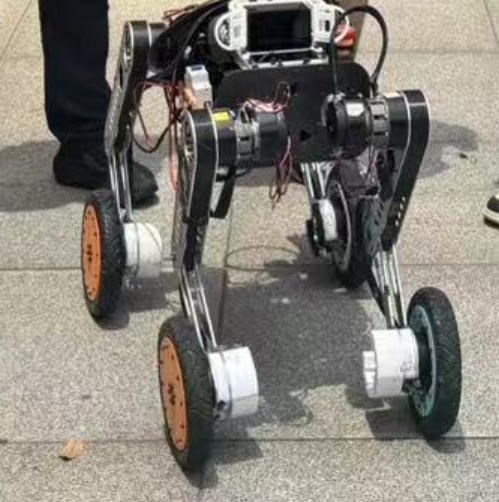
Wheeled robots & hardware
A 16-actuator Robocon wheel-legged quadruped with STEP designs and ROS 2 control sources; final-workspace assets, electronics/firmware coverage and licensing need reconciliation.
Wheeled robots & hardware
An ESP32 wheel-leg robot with STEP, fabrication files and browser control; a source-available design reference with unresolved reuse rights.
Wheeled robots & hardware
An ESP32-S3 wheel-leg design with four leg servos, STL parts and SBUS/touch feedback code; documentation and reuse rights need reconciliation.
3D-printed quadruped
A 3D-printed quadruped research design with a v2.1 Raspberry Pi case update and separate gait-control code.
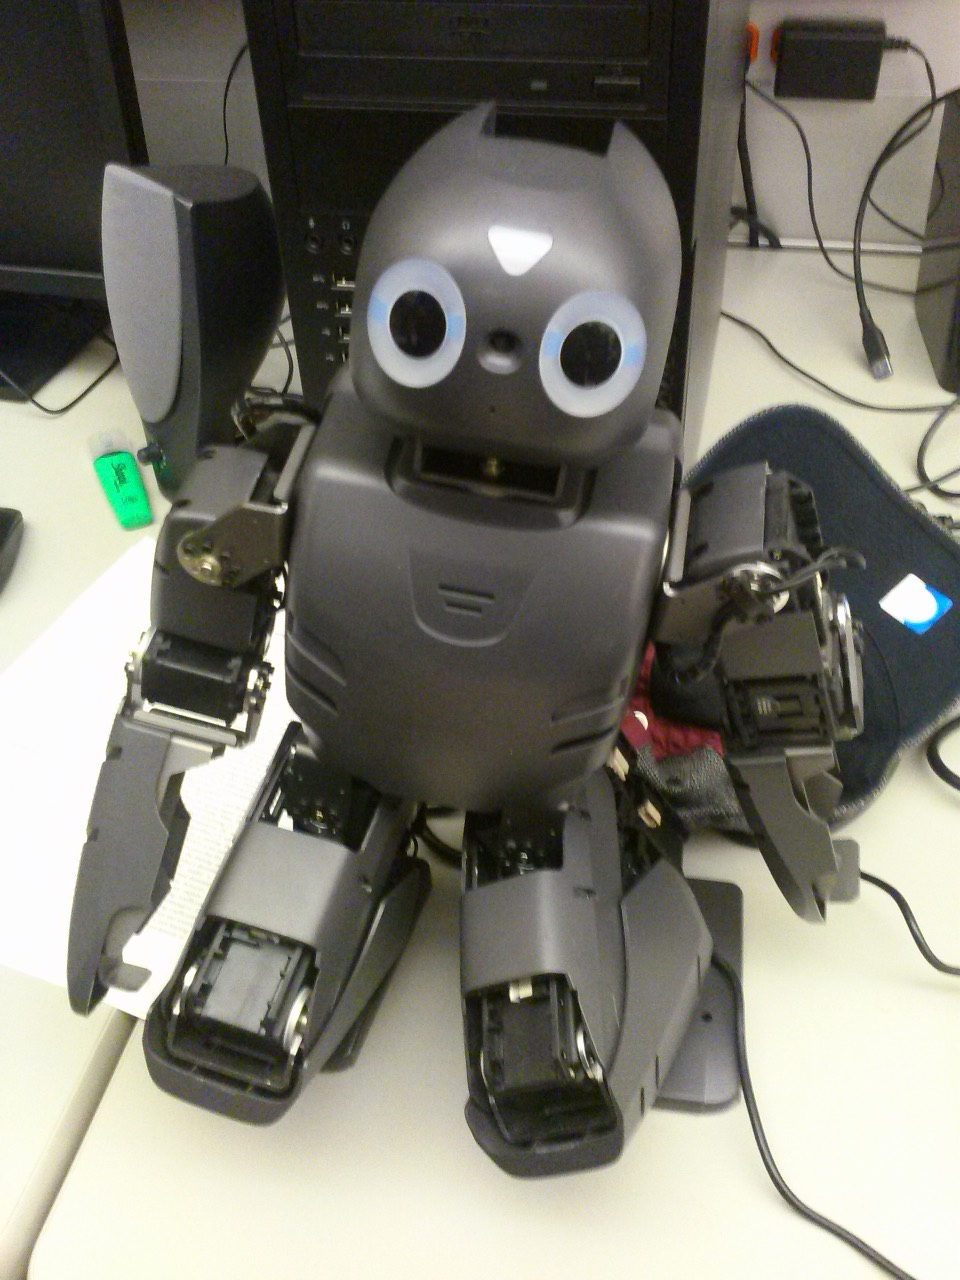
Miniature biped humanoid
A historical small humanoid platform with original mechanical CAD and an assembly manual; electronics and software rights remain separate.
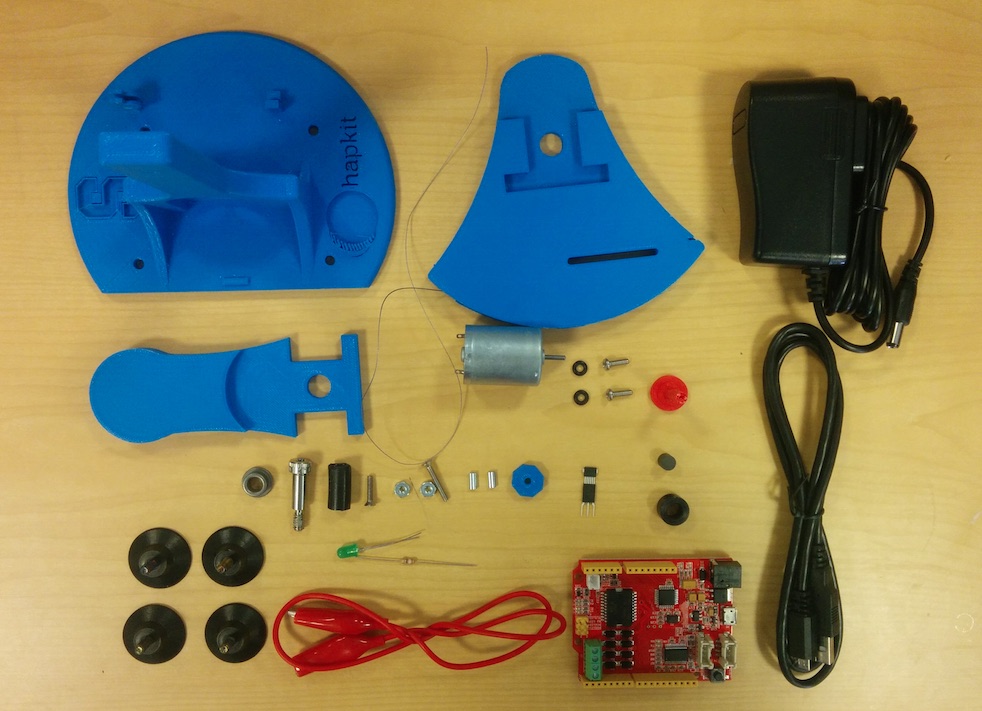
Other robotics hardware
A one-degree-of-freedom force-feedback device with printable parts, assembly instructions and controller examples.
Small mobile swarm robot
A documented Kilobot swarm-robot revision with PCB design, BOM and build guidance from Western Carolina University.
95 cm, 20-actuator humanoid prototype
The original 95 cm humanoid prototype with 28 released STEP body parts and software patches for a historical DARwIn-OP framework.
Pneumatic soft actuator mold design
Printable molds for TU Berlin's pneumatic soft-hand actuators, released with the RBO Hand 2 CAD set.
Sensor component
A 5×8 tactile sensor array with released board layouts, bill of materials and AVR firmware.
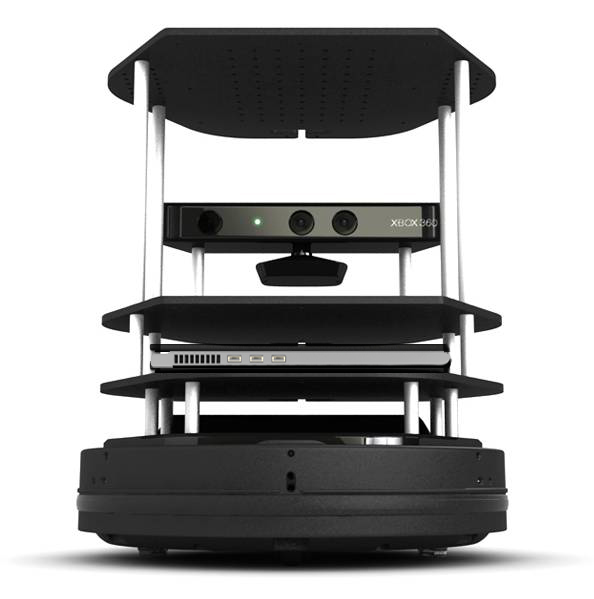
Kobuki-based wheeled mobile robot
A historical mobile research robot built around a purchased Kobuki base, depth camera and released TurtleBot structure drawings.
Tracked rover with printed body
A historical tracked mobile robot with released printable body designs, an Eagle interface board and onboard code in separate repositories.
Arms & manipulation hardware
Fashion Star 6+1 joint leader arm with published 102-LD parts, drawings and a reBot B601 teleoperation route; hardware reuse rights remain unresolved.
Humanoids
A full-size humanoid mechanical-design reference with component drawings and STEP files; a complete BOM, assembly procedure and commissioned robot are not established by this review.
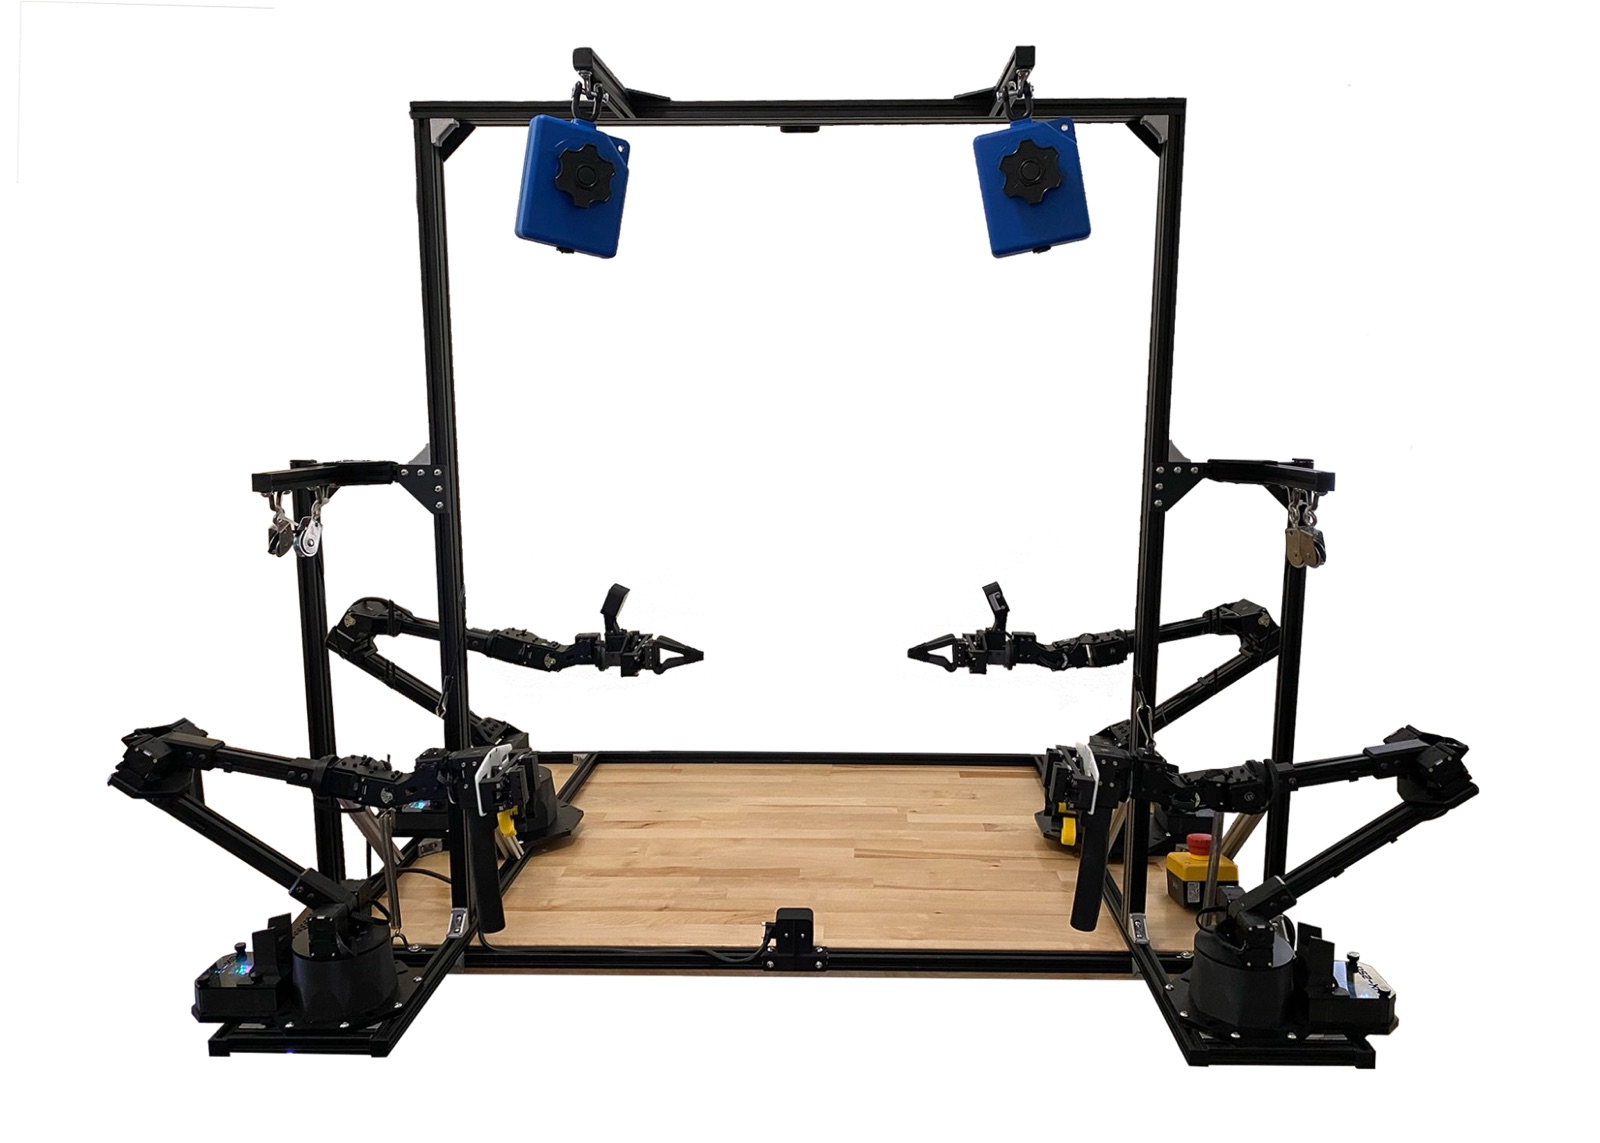
Arms & manipulation hardware
A bimanual teleoperation workcell with revised rail grippers, passive leader-arm gravity compensation and published parts for adapting four purchased robot arms.
Wheeled robots & hardware
A powered-caster mobile base with published fabrication files, arm mounts and phone teleoperation; complete manipulation uses a separately supplied arm.
Wheeled robots & hardware
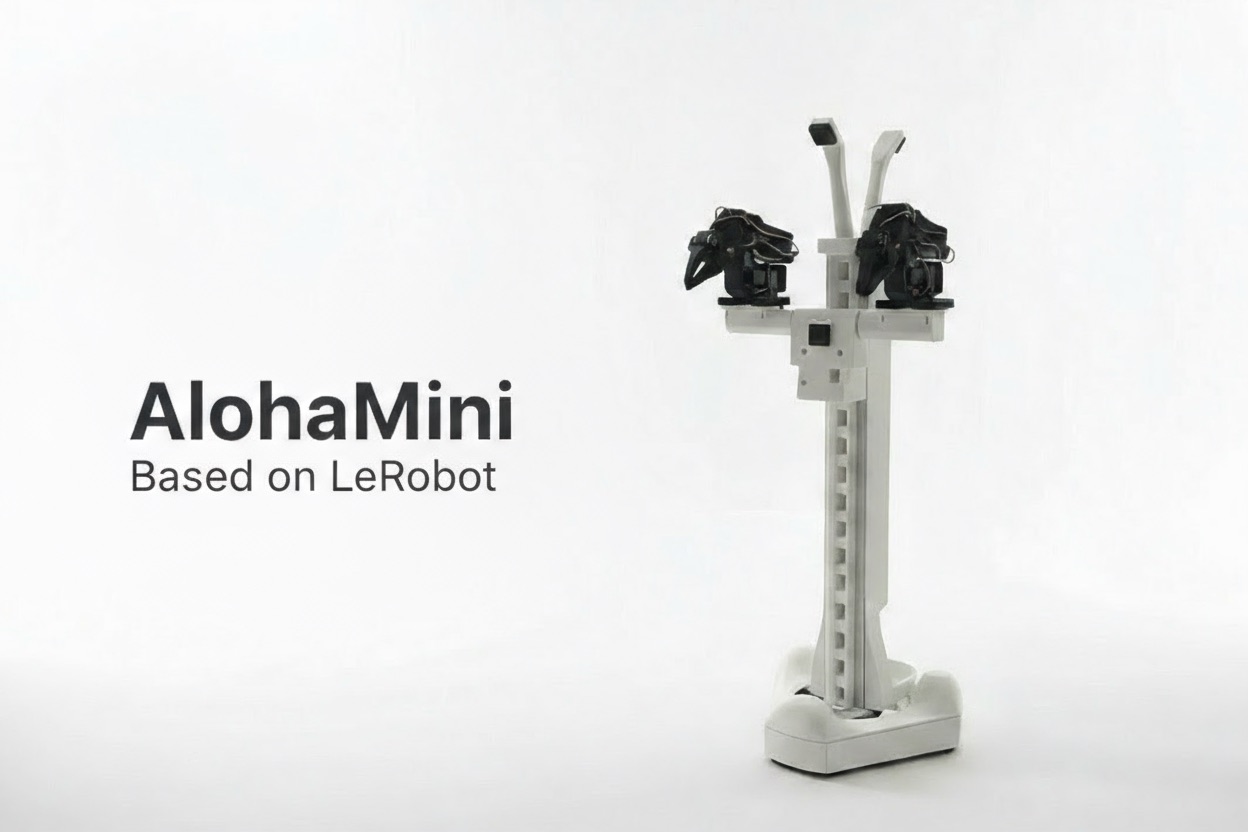
Printable three-wheel mobile base with a motorized lift and two AM-ARM200 arms, run as a Raspberry Pi 5 host with a PC client through the lerobot_alohamini fork.
From USD 950.00 upstream estimate
Arms & manipulation hardware
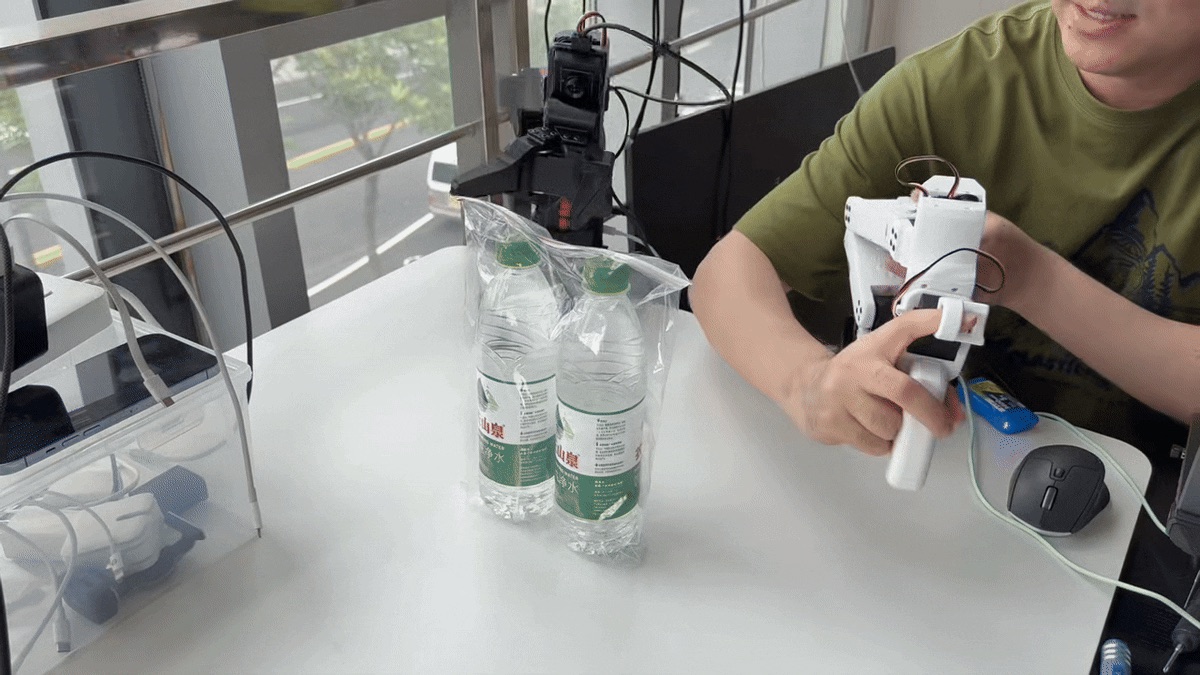
Printable 6+1 DoF leader/follower arm pair using Feetech STS3215 and STS3095 servos, with LeRobot support supplied through the separate lerobot_alohamini fork.
From USD 144.44 upstream estimate
Leg subassembly
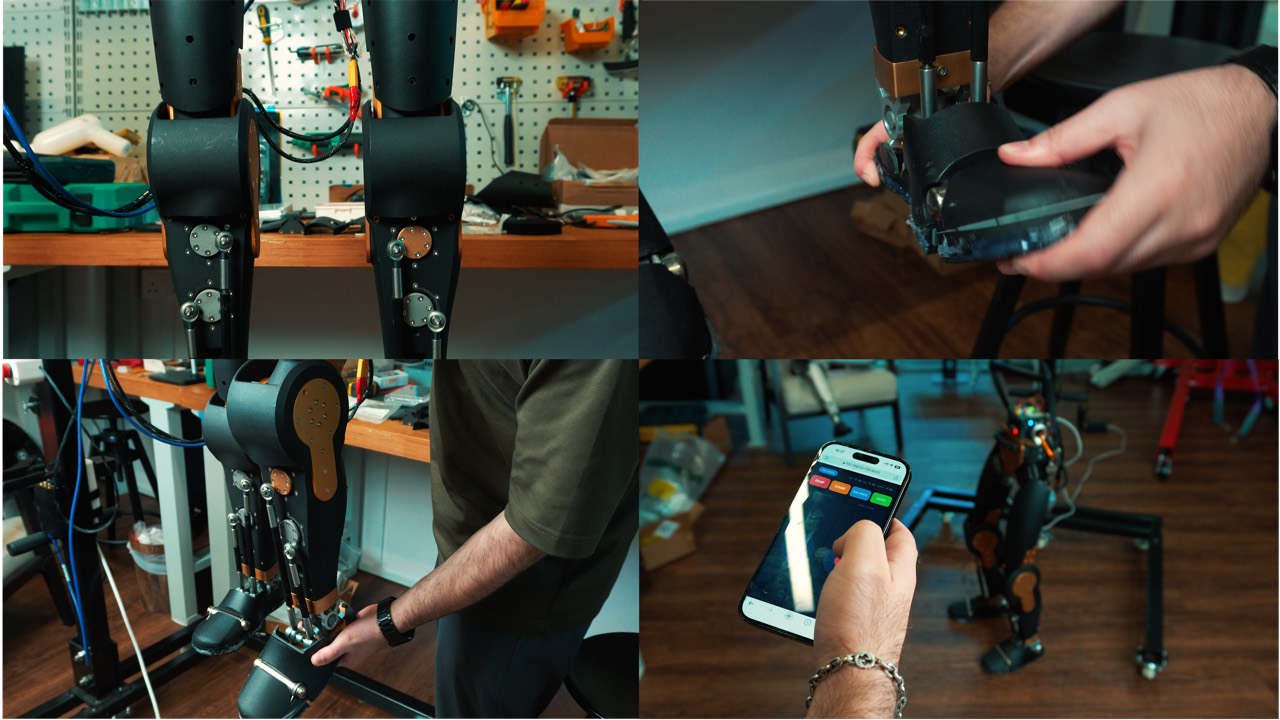
Twelve-actuator bipedal leg set (lower body only) with articulated toes and a two-motor RSU ankle, published as STL simulation meshes, an MJCF model and an LFS-stored STEP assembly.
Sensor component
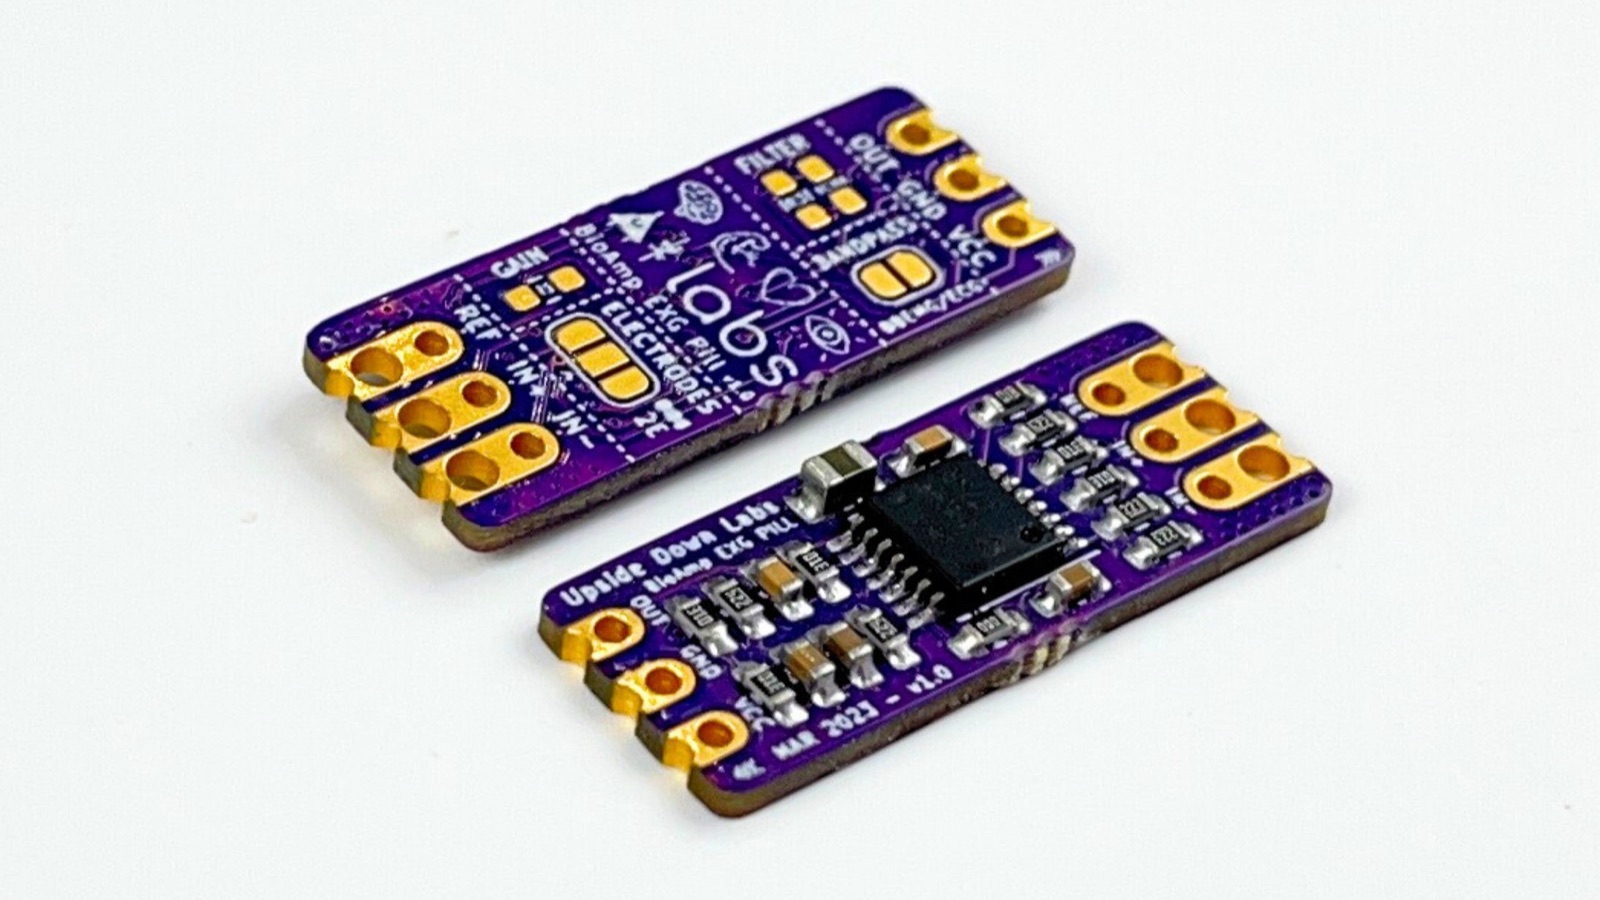
Open-hardware biopotential analog front-end board (2.54 × 1.00 cm) for ECG, EMG, EOG and EEG acquisition with a 5 V microcontroller ADC; a sensor component with EMG servo and claw-control example sketches, not a robot.
From USD 69.00 vendor price
Aerial robots
Teensy 4.0 quadcopter taught step by step in a 222-page build and programming manual, with a PCB upper frame and separate per-chapter Arduino code repositories; manual and code are licensed CC BY-NC-SA 4.0.
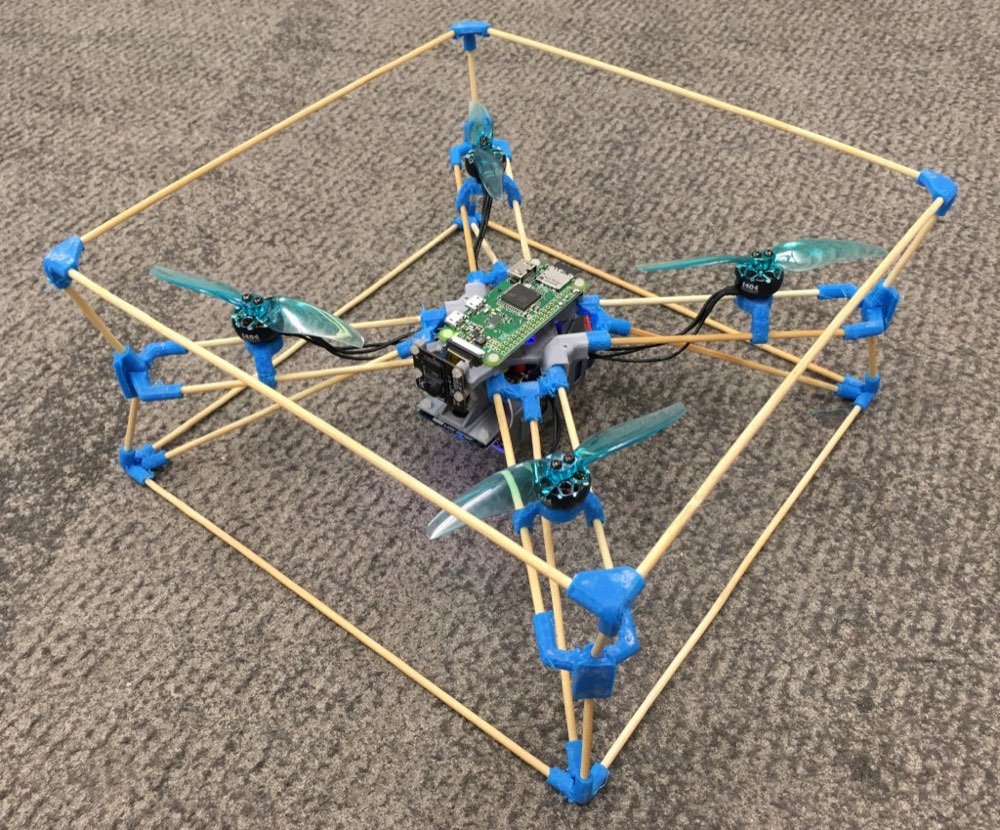
Aerial robots
Sub-250 g collision-resilient quadcopter with a bamboo or carbon-rod frame joined by printed TPU parts, an INAV flight controller and a Raspberry Pi Zero W controlled through the MIT-licensed cognifly-python library; no license file was identified for the frame files.
About CAD 407.90 upstream estimate
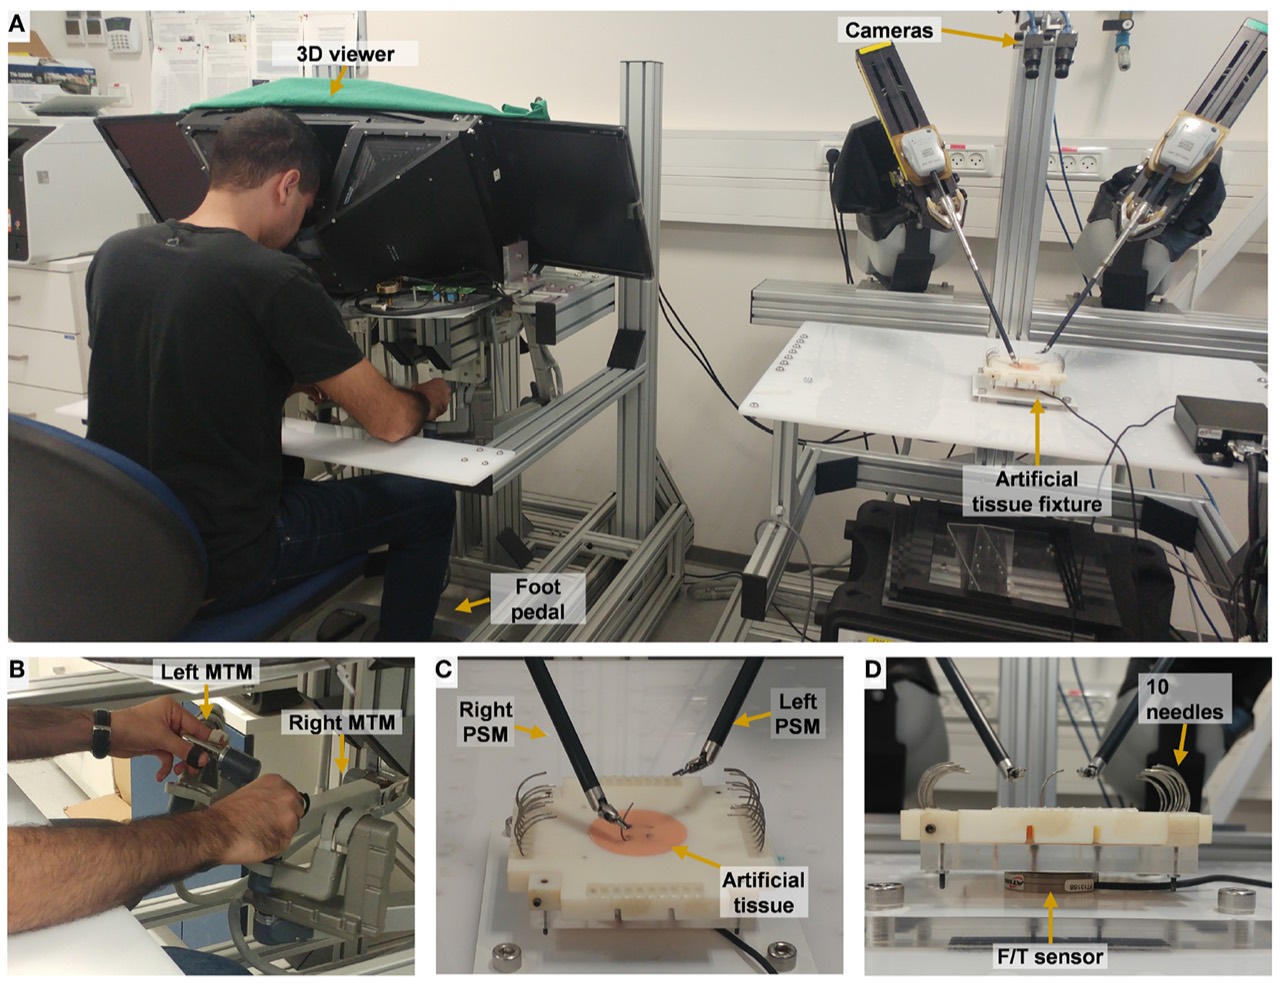
Arms & manipulation hardware
Open controller electronics, FPGA firmware and cisst/SAW software for research systems built from retired da Vinci arms and consoles; the arms themselves are supplied hardware, not an open design.
Aerial robots
ESP32 quadcopter with a 3D-printed frame, four brushed motors switched by MOSFETs, an SPI IMU board, Arduino firmware with Wi-Fi/MAVLink control and a Gazebo simulator; no repository license file was identified.
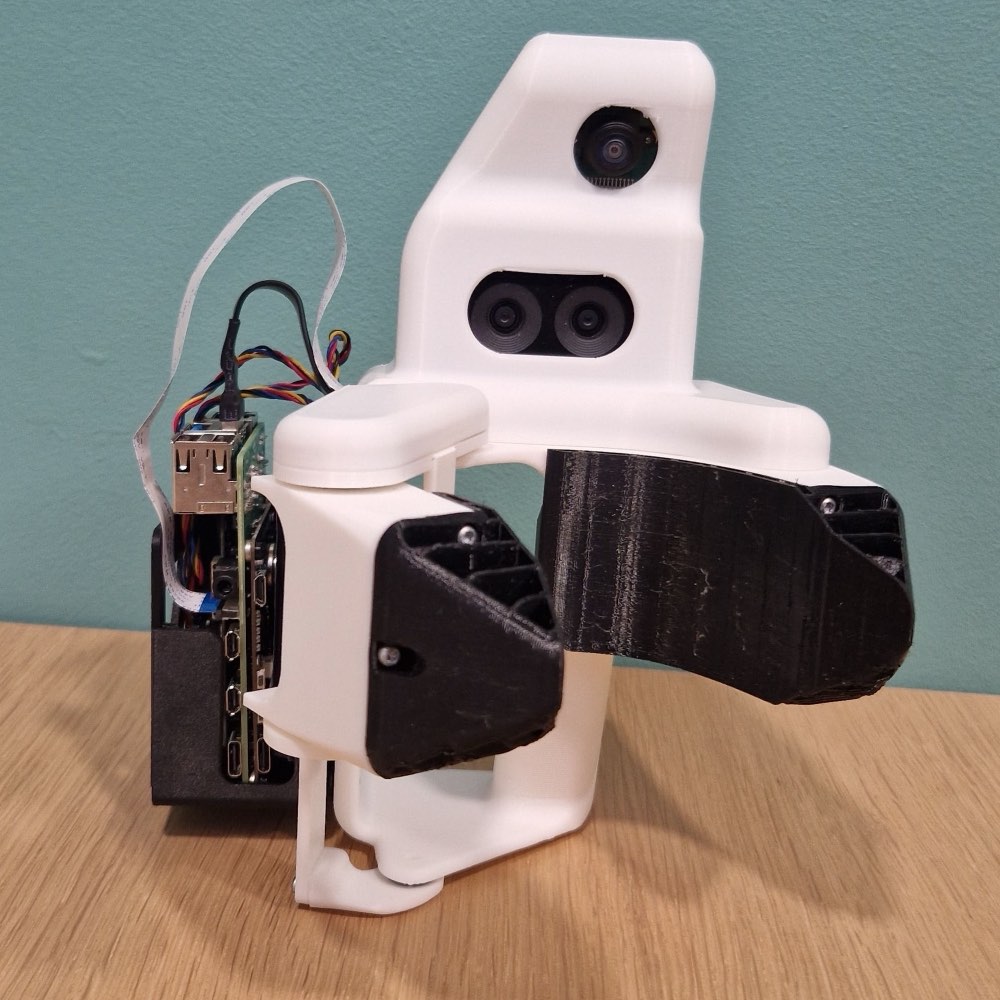
Other robotics hardware
Pollen Robotics handheld demonstration recorder (Raspberry Pi 4, fisheye camera, OAK-D SR, finger angle sensors) with an offline SLAM pipeline that exports LeRobot datasets.
About EUR 585.03 upstream estimate
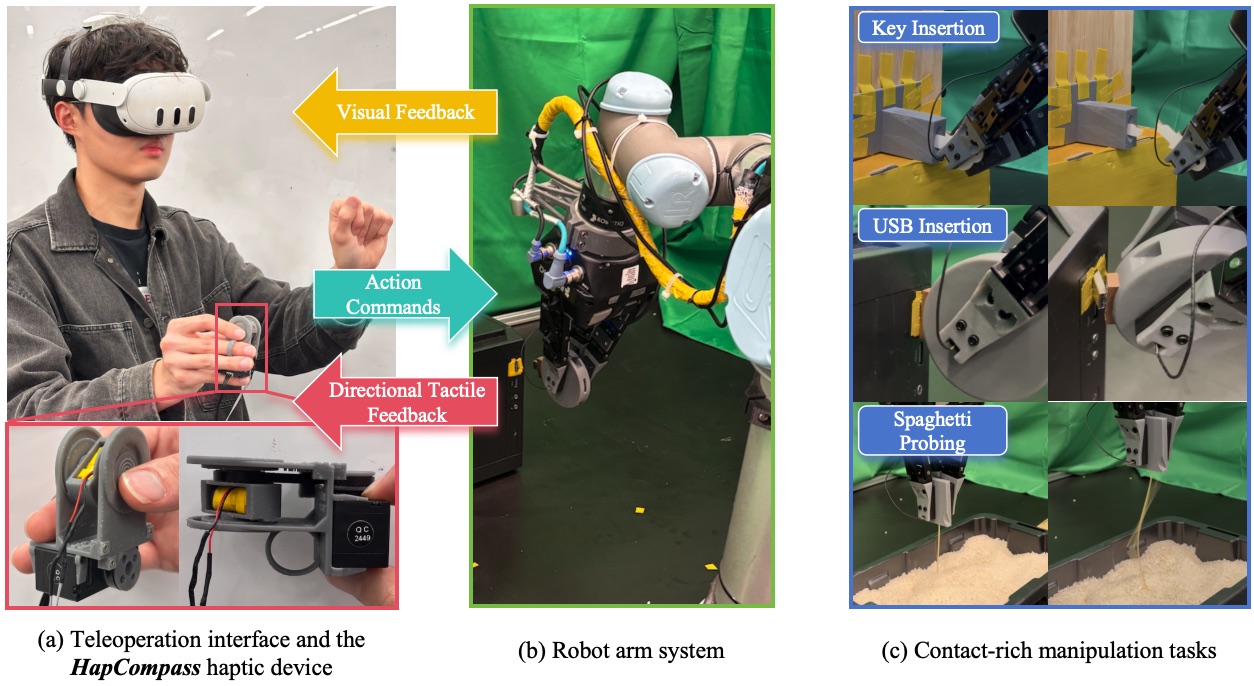
Haptic peripheral
Fingertip-worn haptic device that rotates one linear resonant actuator with a Dynamixel servo to render 2D directional cues during robot teleoperation; printable parts, an editable source design and a priced BOM are released, but no control code was identified.
About USD 241.12 upstream estimate
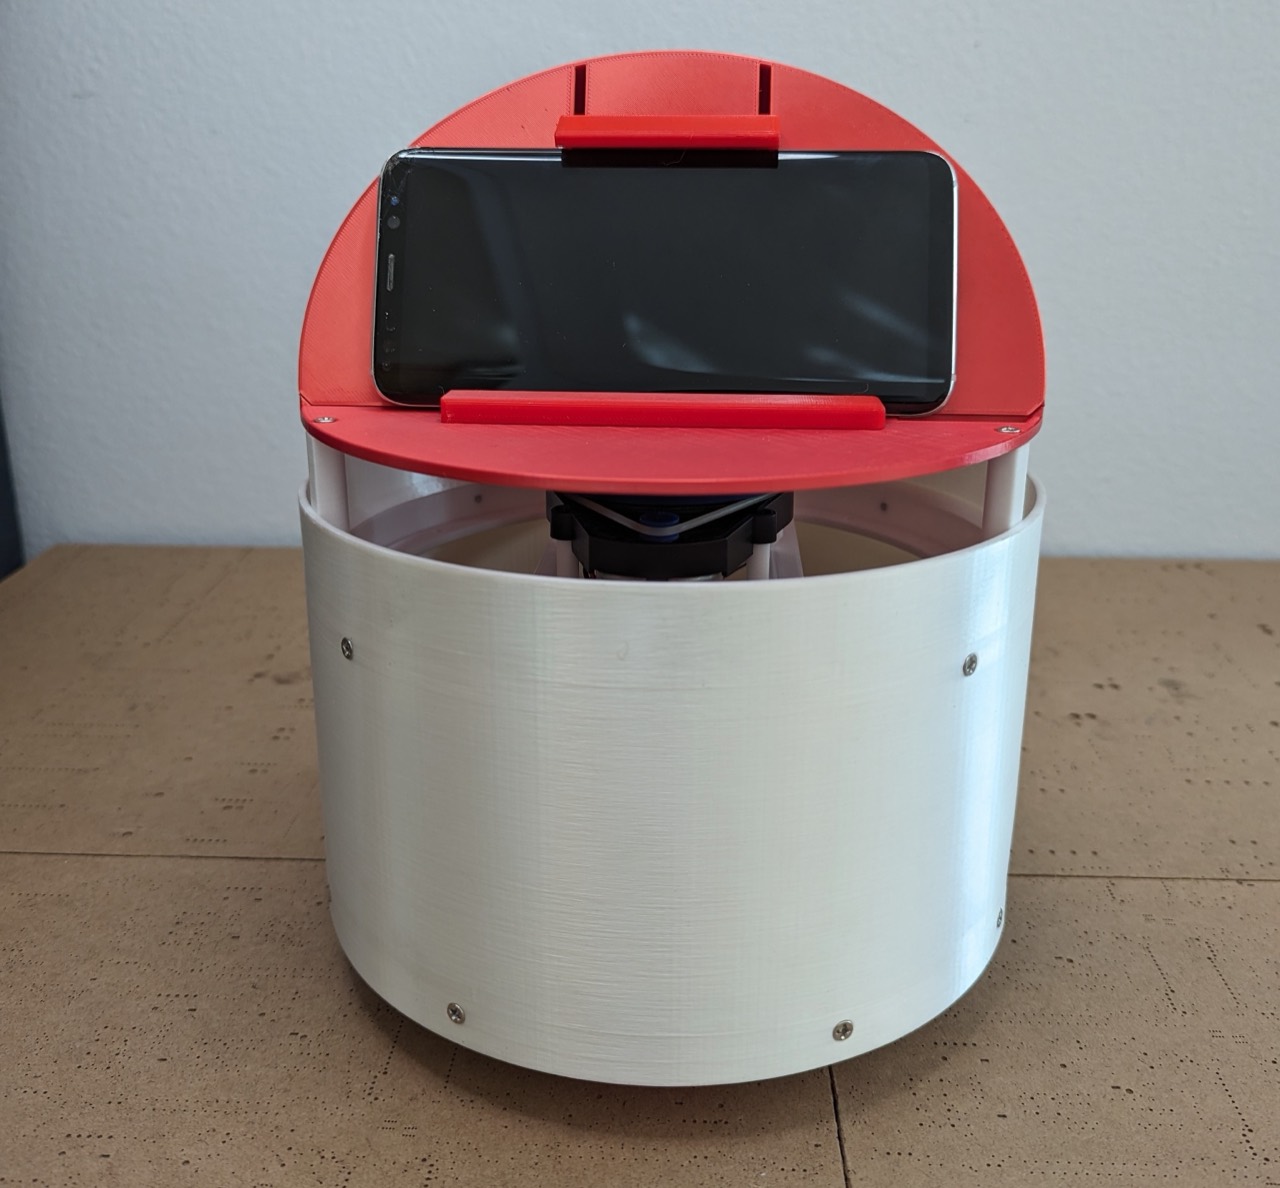
Wheeled robots & hardware
200 mm 3D-printable differential-drive pet robot with an ESP32, BLDC gear motors and a choice of hobby LiDARs, run through the shared Kaia.ai ROS 2 stack; sized for common 220 mm-class printers.
About USD 66.00 upstream estimate
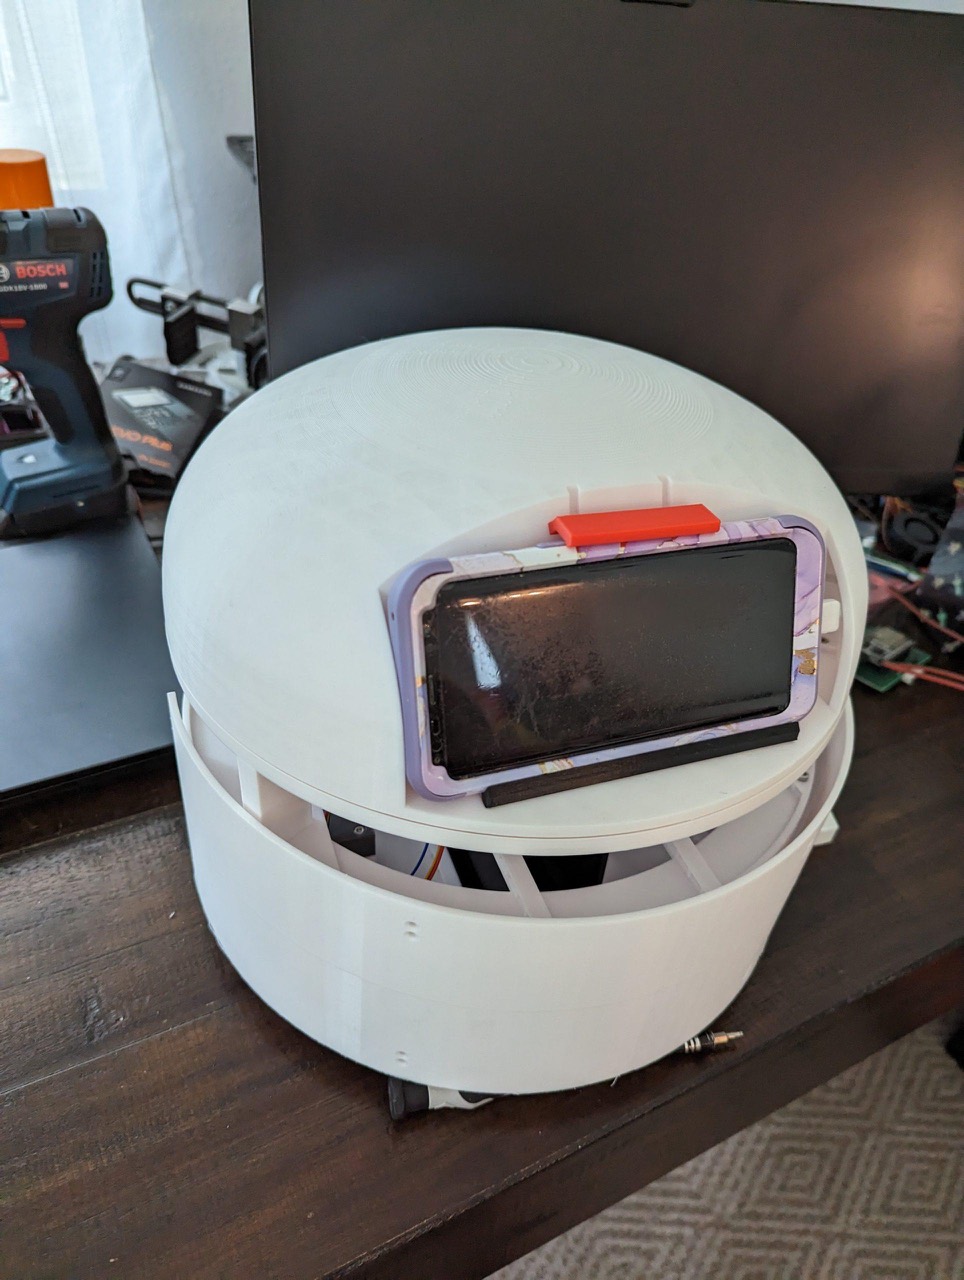
Wheeled robots & hardware
300 mm 3D-printable differential-drive pet robot with an ESP32, BLDC gear motors, a 360-degree LiDAR and a phone or tablet head, run through the shared Kaia.ai ROS 2 stack; pet character and skills are upstream work in progress.
About USD 199.60 upstream estimate
Aerial robots
3D-printed tricopter/flying-wing VTOL with two tilting front motors and a fixed rear motor, tuned on ArduPlane; STL/3MF artwork and parameter files are licensed CC BY-NC-SA 4.0 and native CAD is withheld.
Teleoperation input
Unpowered 3D-printed six-joint leader arm read by AS5600 encoders through an ESP32, used to teleoperate an SO-ARM follower in MuJoCo or through LeRobot.
About INR 2,619.00 upstream estimate
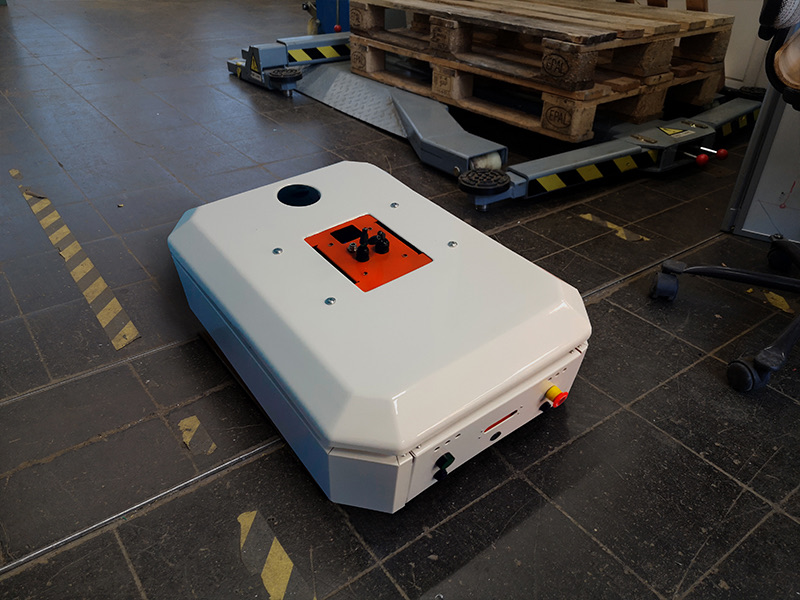
Wheeled robots & hardware
Differential-drive AMR base with a sheet-metal chassis, Raspberry Pi 5, Teensy 4.0, two 60 W ZD BLDC gearmotors, RPLIDAR A1 and ROS 2 Jazzy; upstream discloses open safety gaps such as no battery fuse or hardware E-stop.
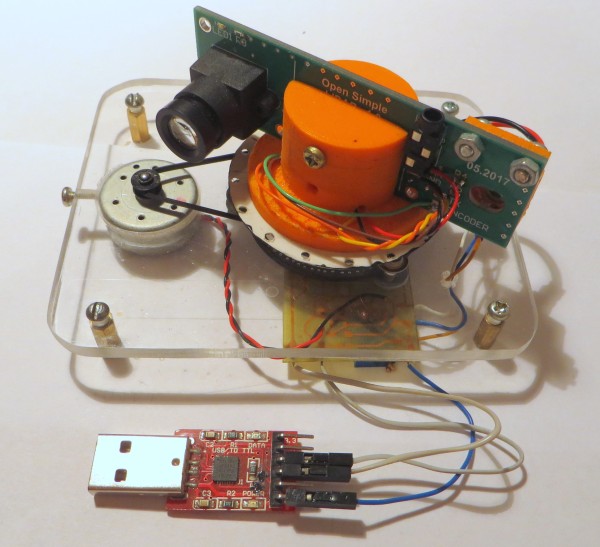
Sensor component
DIY triangulation scanning laser rangefinder (STM32F030, TSL1401CL line sensor, 780 nm laser, slip-ring head) rated by its author at 5 scans/s, 2-degree steps and up to 4 m; a sensor component for robots, not a robot.
About USD 23.17 upstream estimate
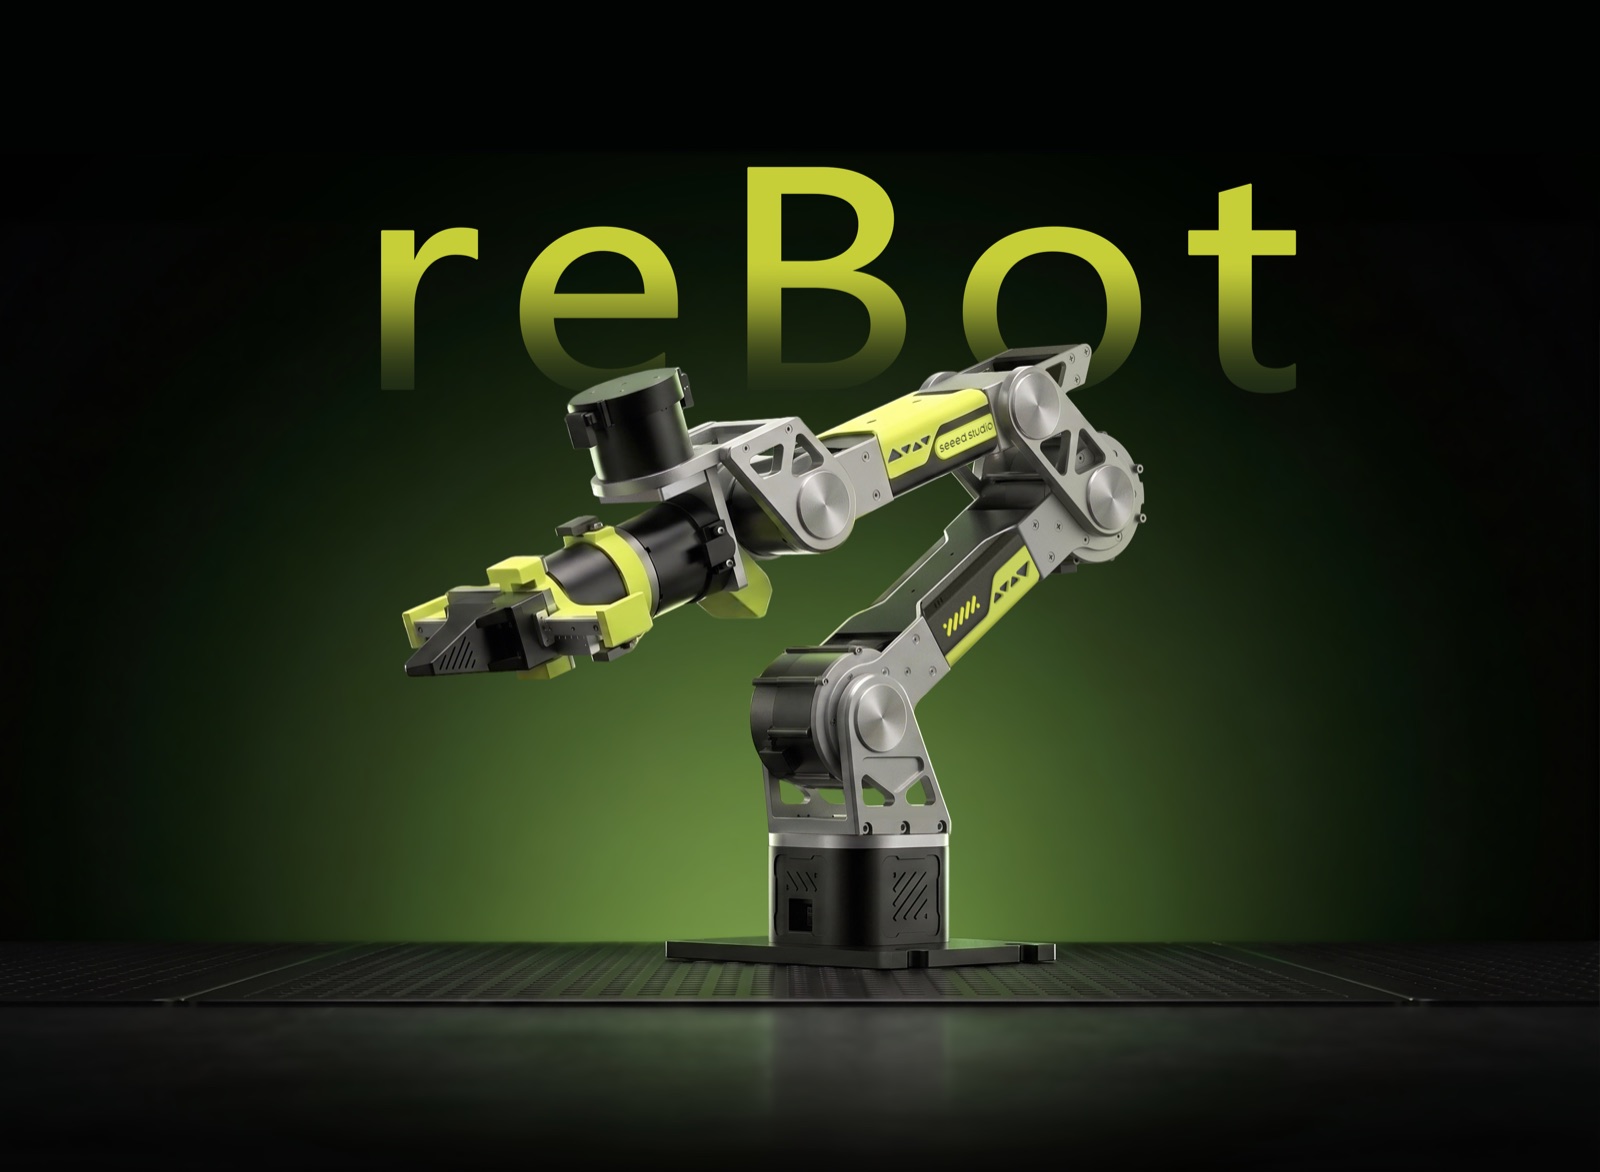
Arms & manipulation hardware
Seeed Studio 6+1 DoF desktop arm with CNC aluminium and printed parts, published as B601-DM (Damiao motors, 24 V) and B601-RS (RobStride motors, 48 V) under CERN-OHL-W-2.0 hardware terms.
About USD 1,436.40 vendor price
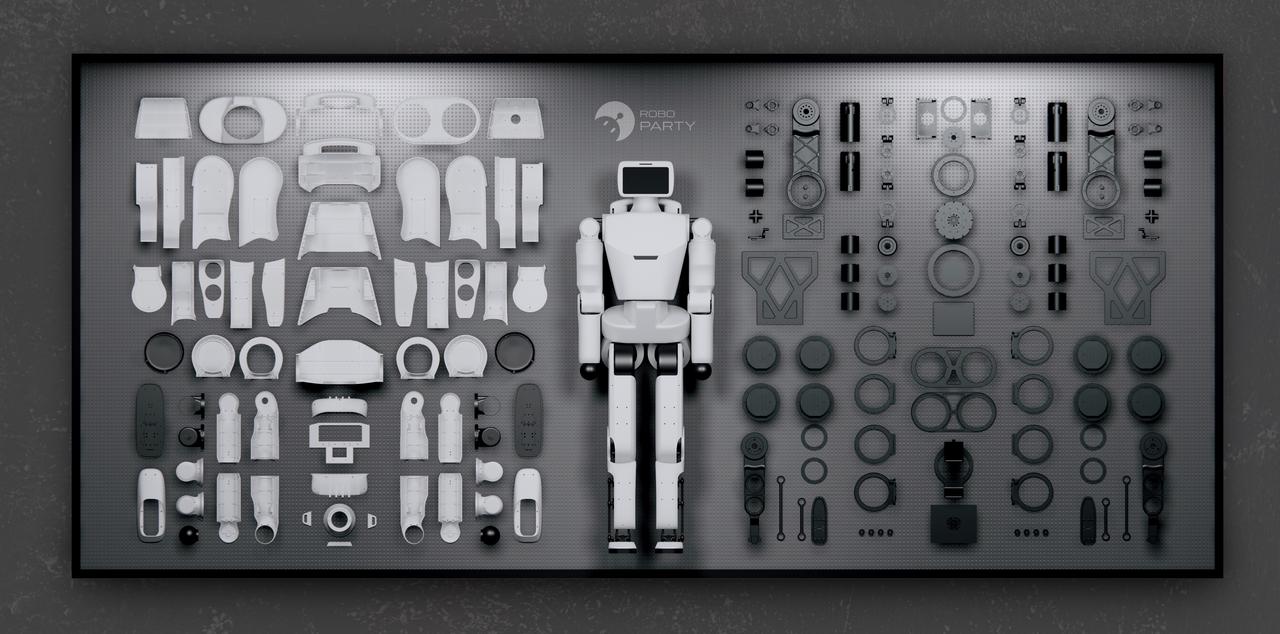
Humanoids
Full-size DIY humanoid prototype from RoboParty with CNC-machined metal structure, 23 Damiao actuators in the published BOM, ROS 2 deployment and Isaac Lab training code; V2.0 hardware is not compatible with V1.0.
About CNY 49,743.53 upstream estimate
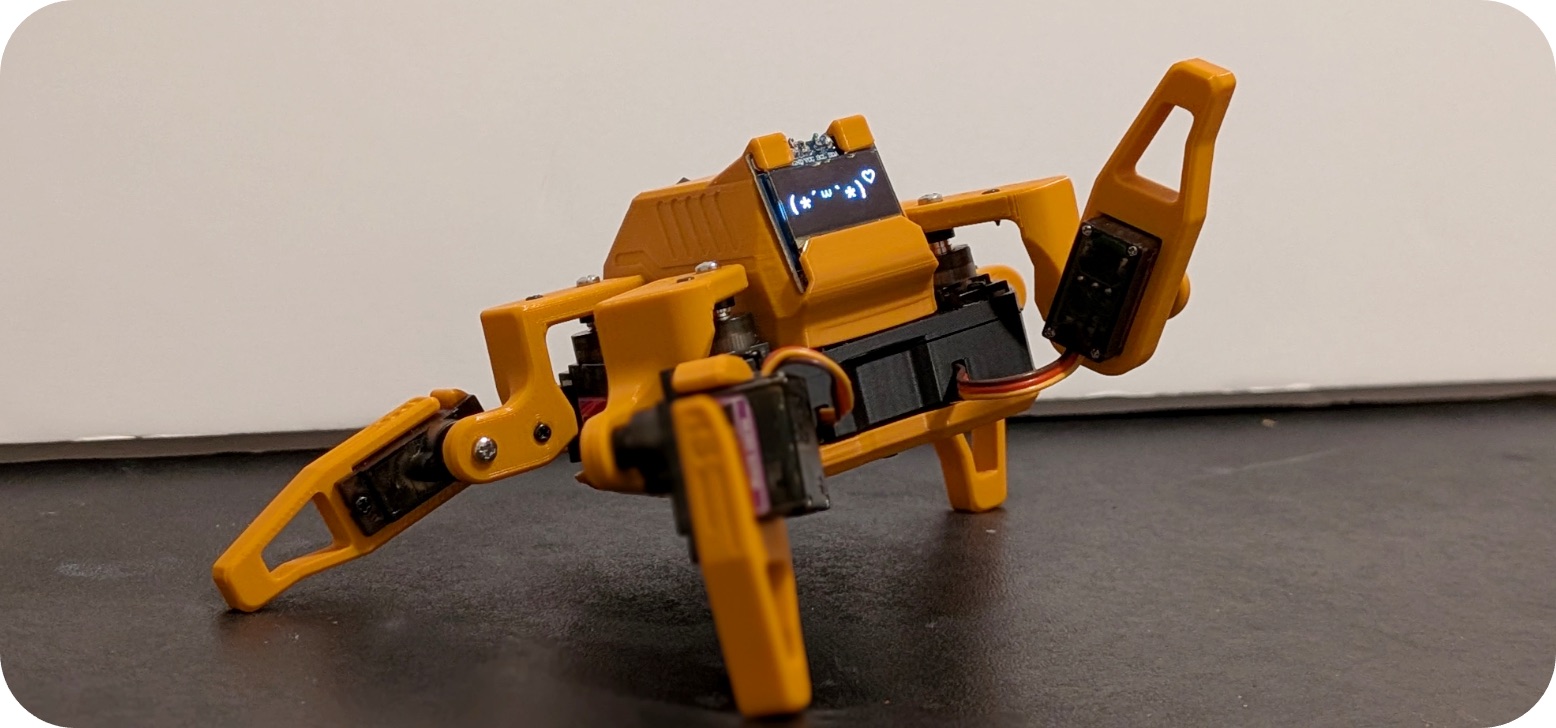
Legged robots & hardware
Small 3D-printed ESP32 quadruped with eight MG90S servos, an OLED face and Wi-Fi control; four controller-board routes need matching firmware pin settings.
About USD 50.00 upstream estimate
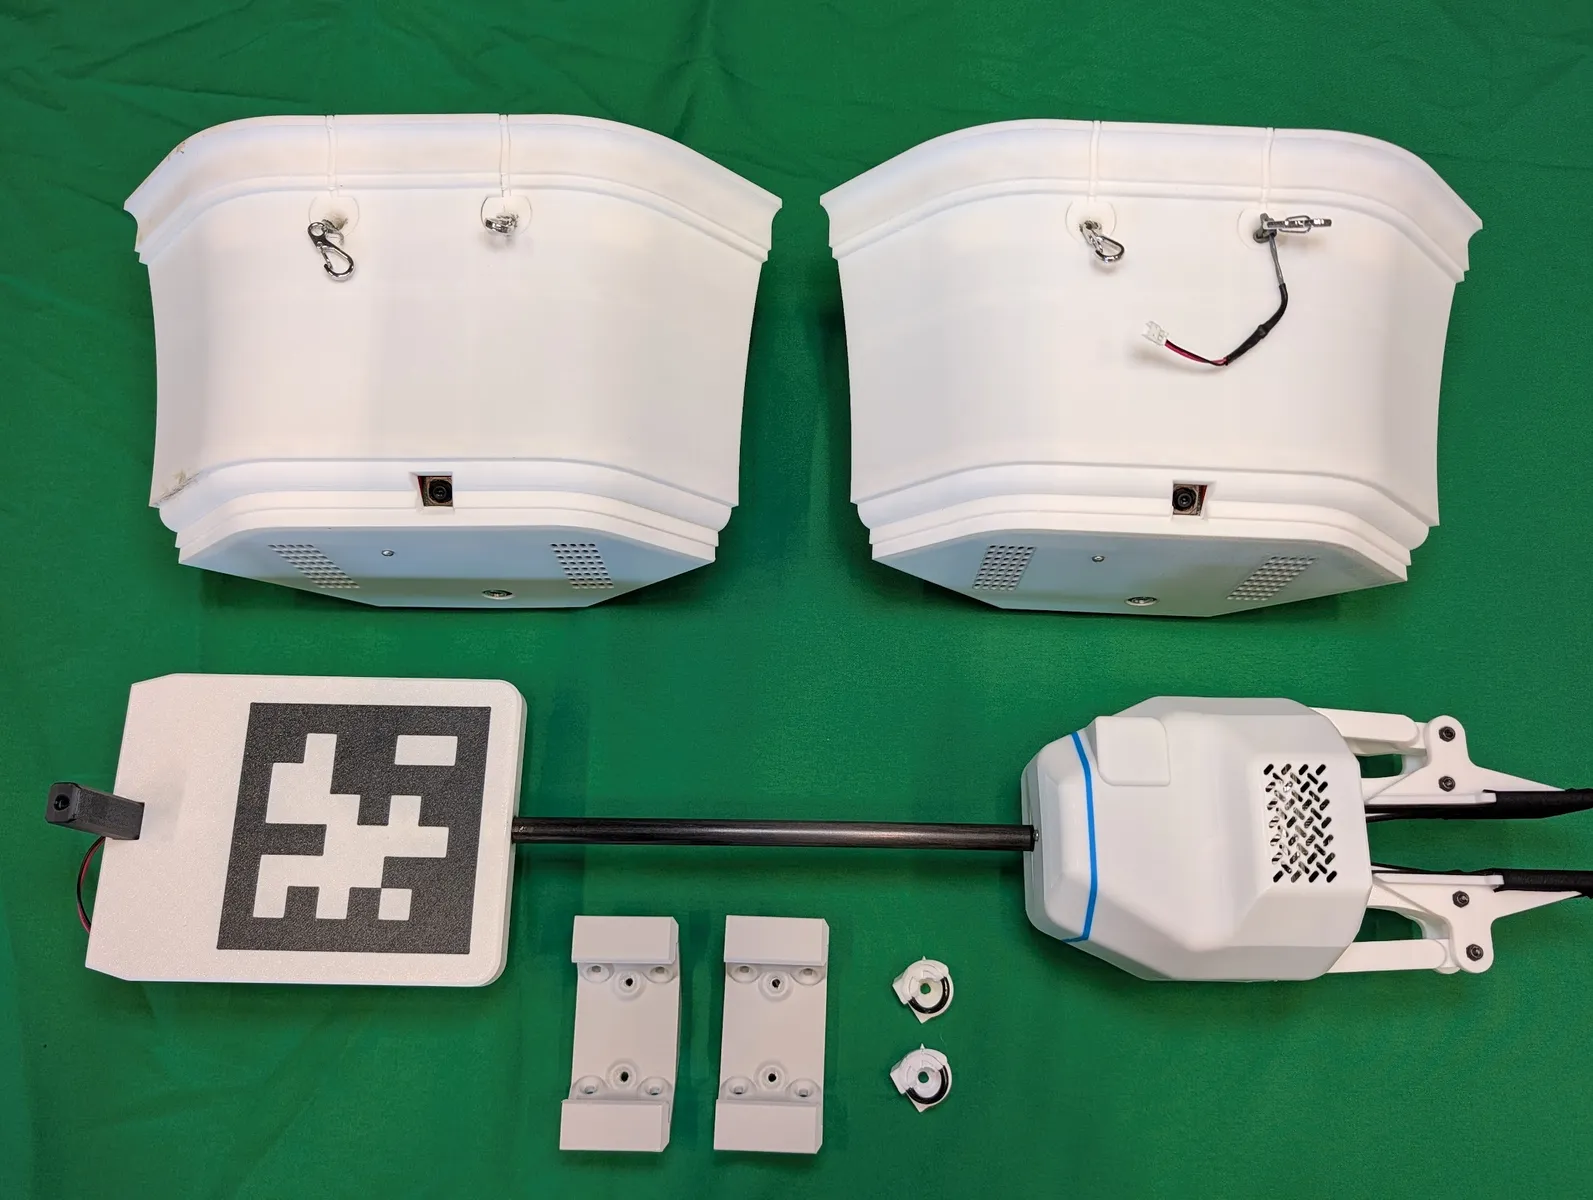
Other robotics hardware
Room-scale four-line cable robot (Arpeggio hardware) with two corner anchors and a hanging camera gripper, driven by a host-run Python motion controller; a public prototype.
From USD 655.00 upstream estimate
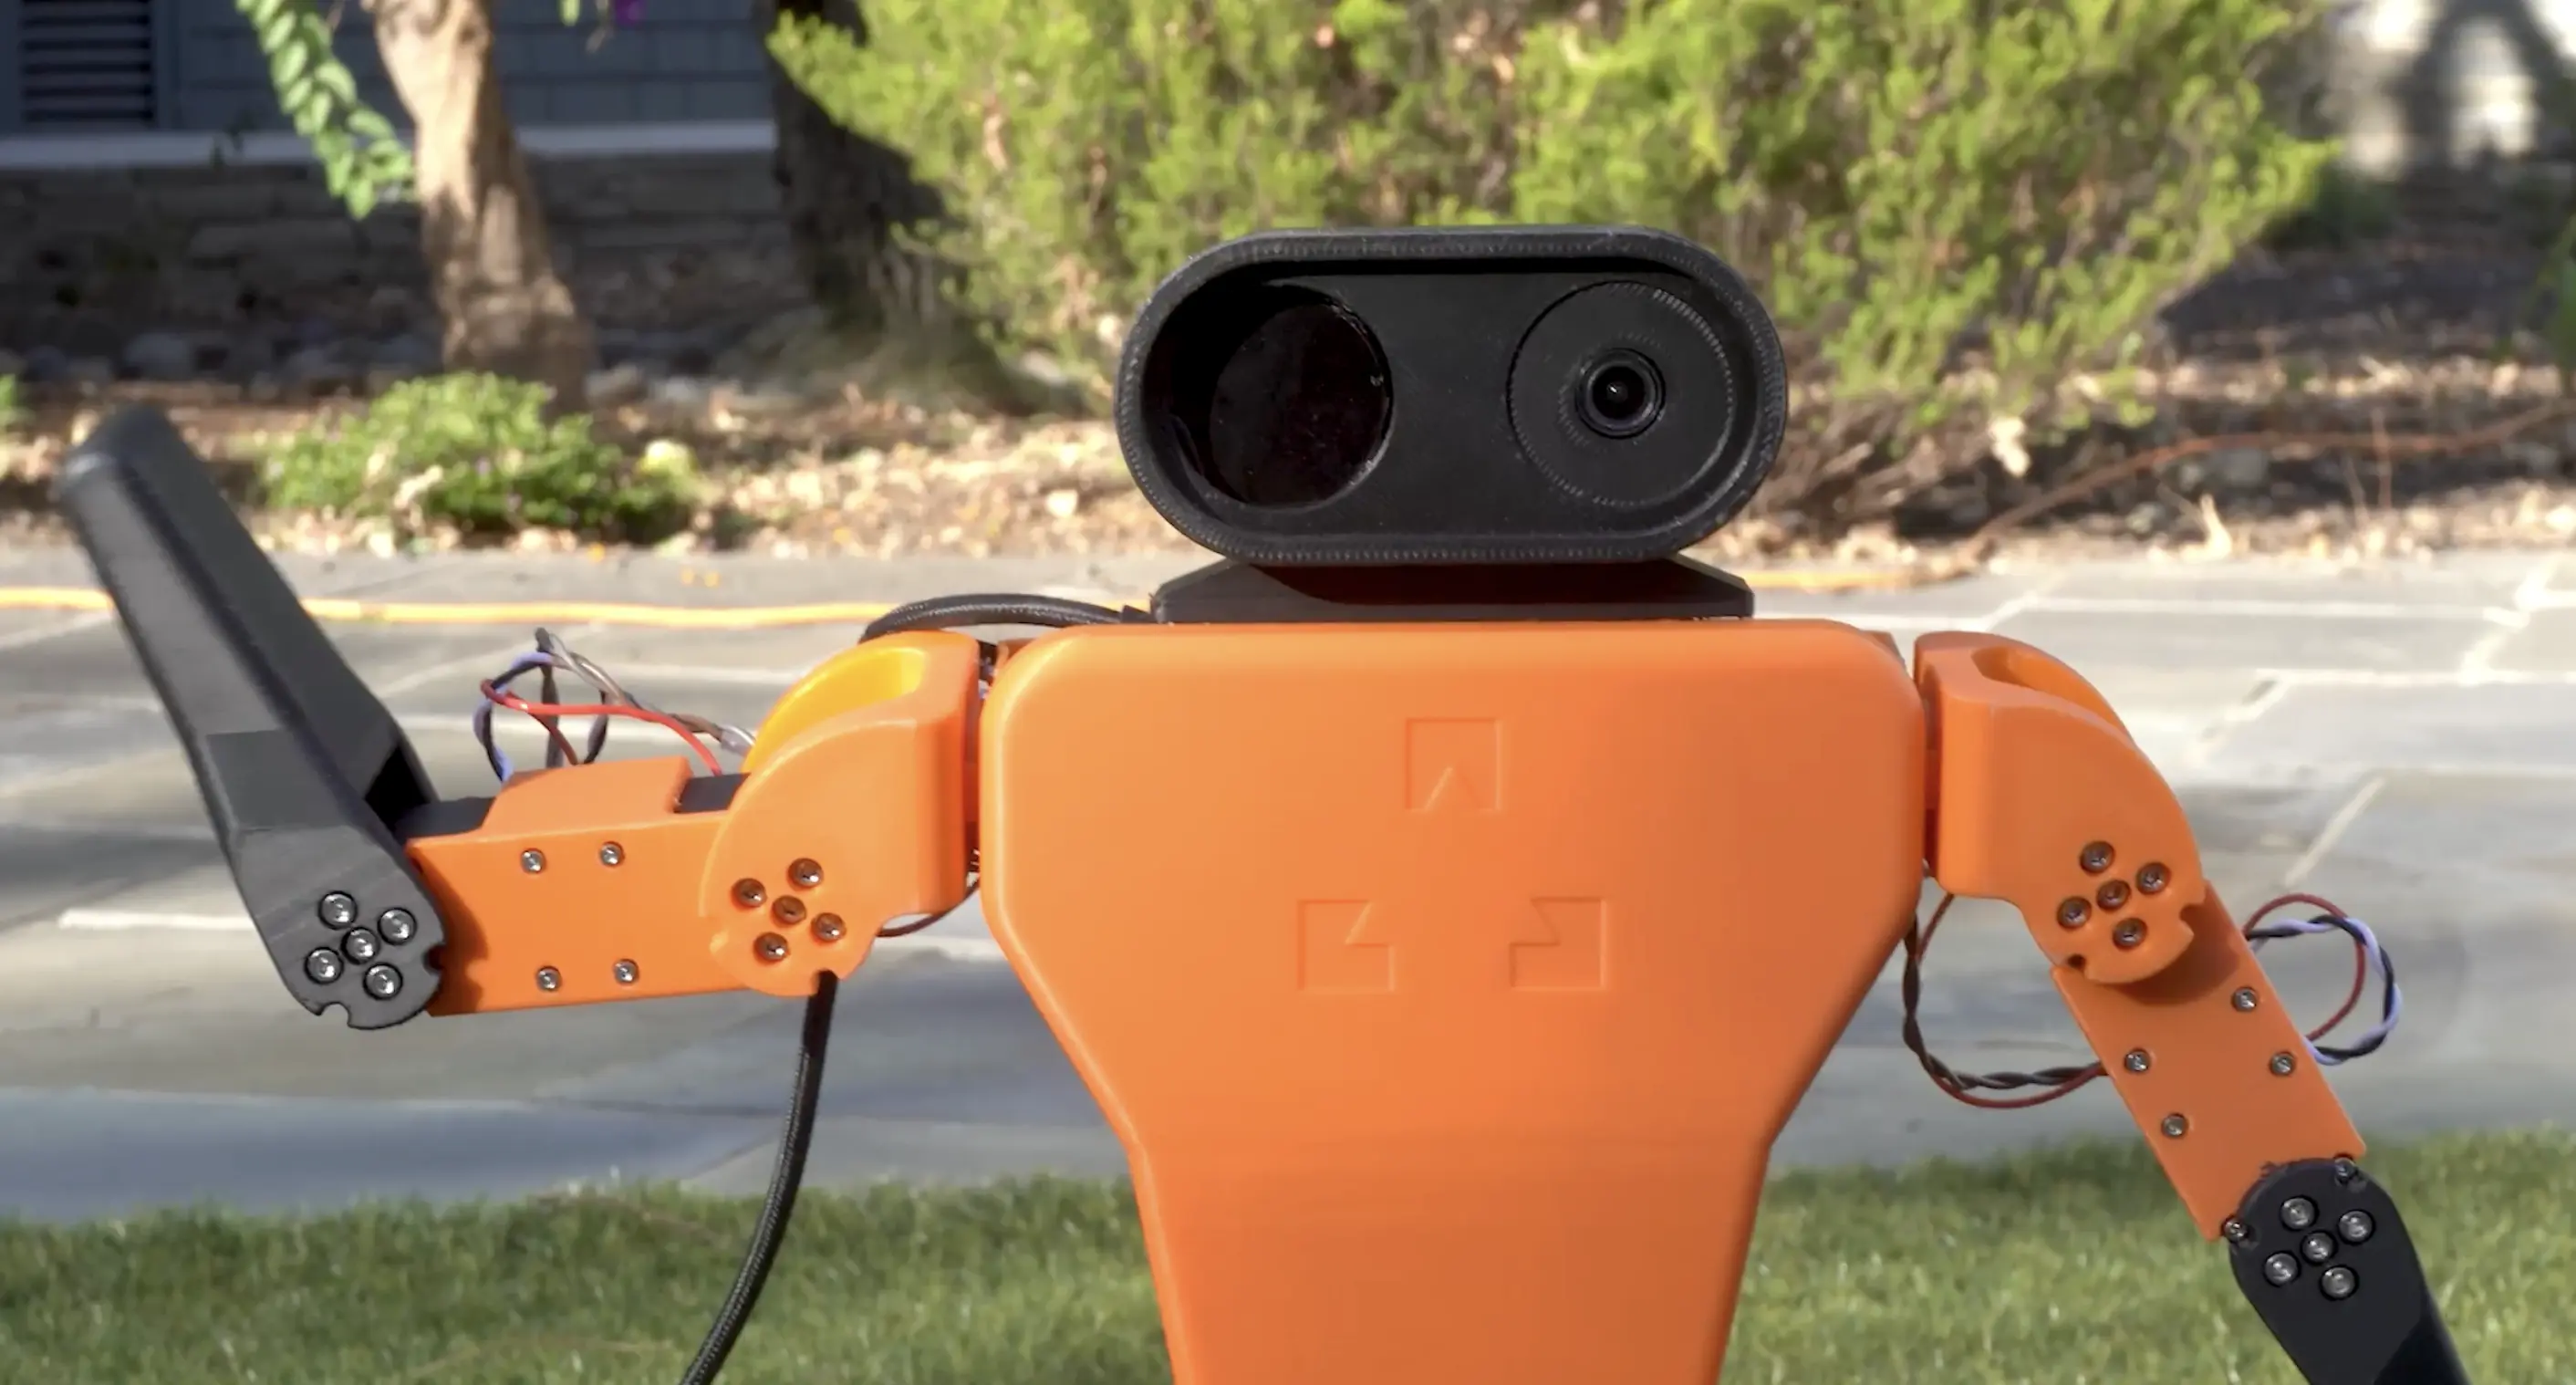
Humanoids
Small 3D-printed humanoid using sixteen Feetech serial-bus servos and a Milk-V Duo S; the main repository is now a pointer, so the BOM and STLs come from the separate docs repository.
About USD 350.00 upstream estimate
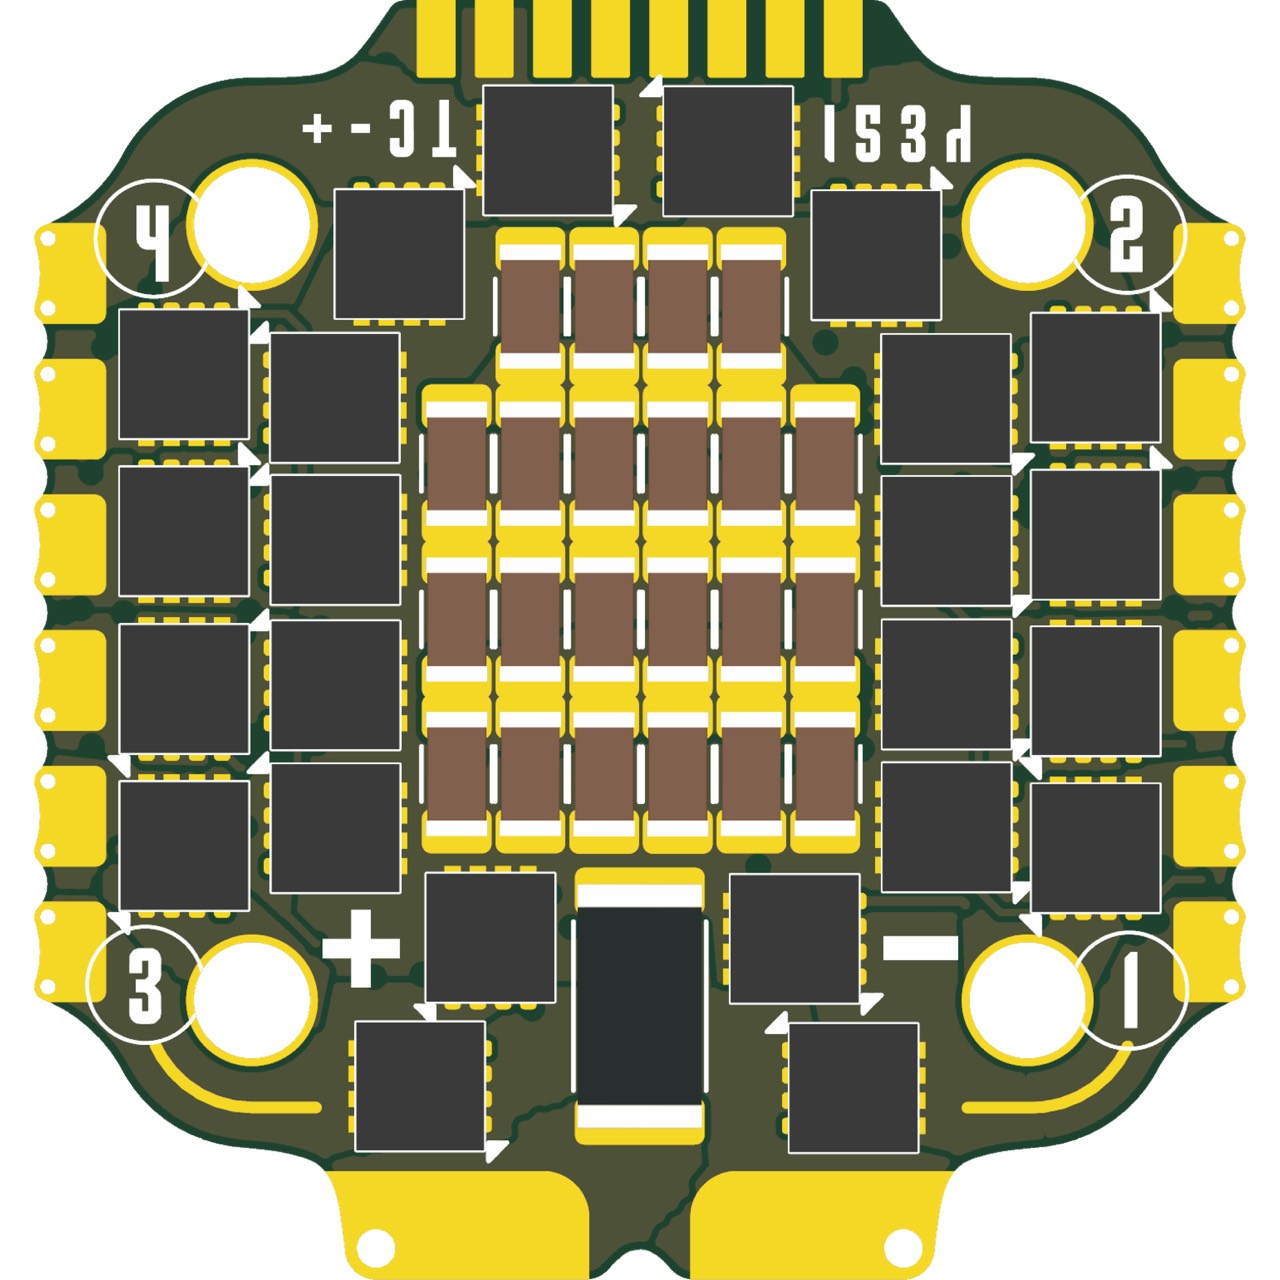
Motor controller
OpenESC-20x20 is a four-channel brushless motor controller with available KiCad sources and unresolved differences between headline ratings and technical test notes.
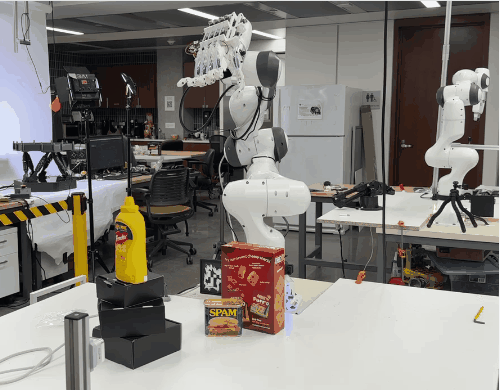
Tendon-driven dexterous robotic hand
BiDexHand V4 is a 16-DoF tendon-driven hand with printed parts, a Servo2040 PWM route and ROS 2 control packages.
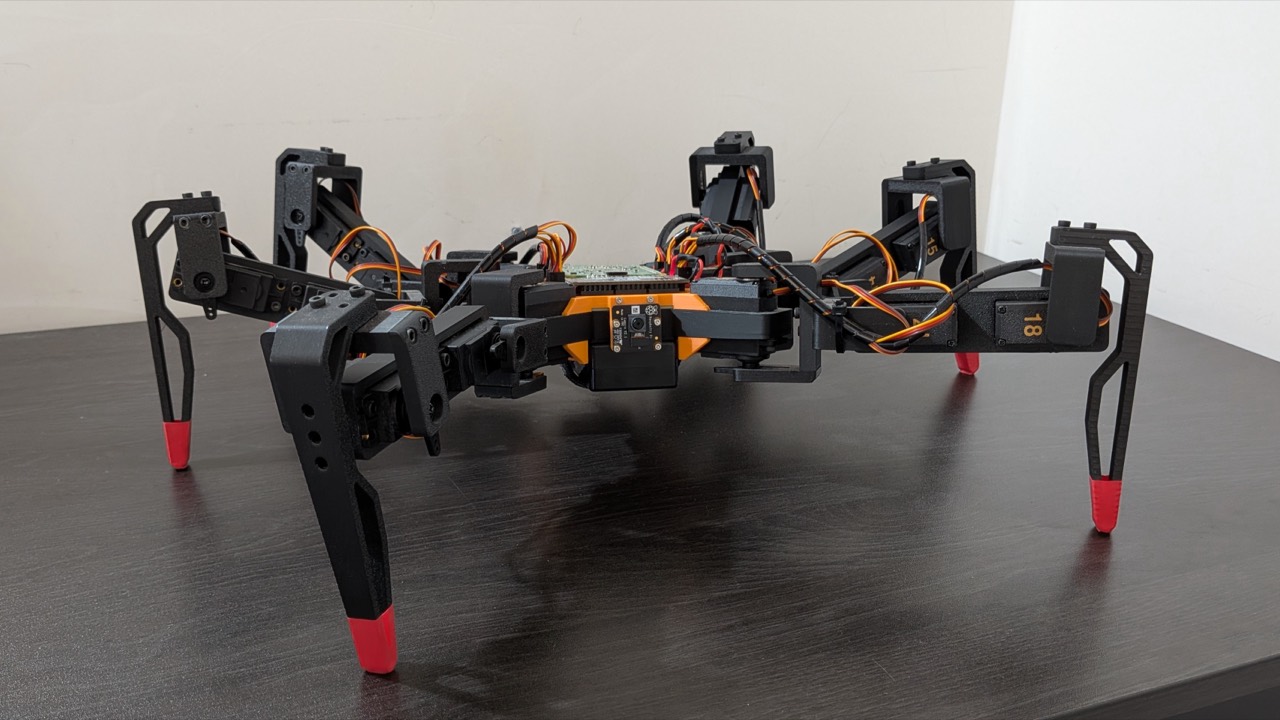
Six-legged servo hexapod
Printed 18-servo hexapod with separate mechanical designs, Servo2040 firmware and a Raspberry Pi controller.
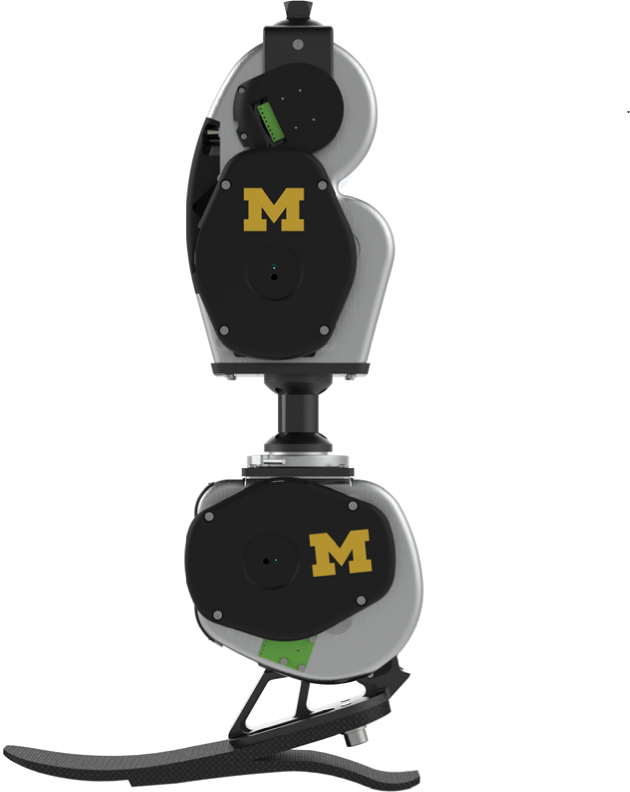
Leg subassembly
Modular knee-and-ankle research platform with published assembly documentation, externally hosted design downloads and a separately licensed Python SDK.
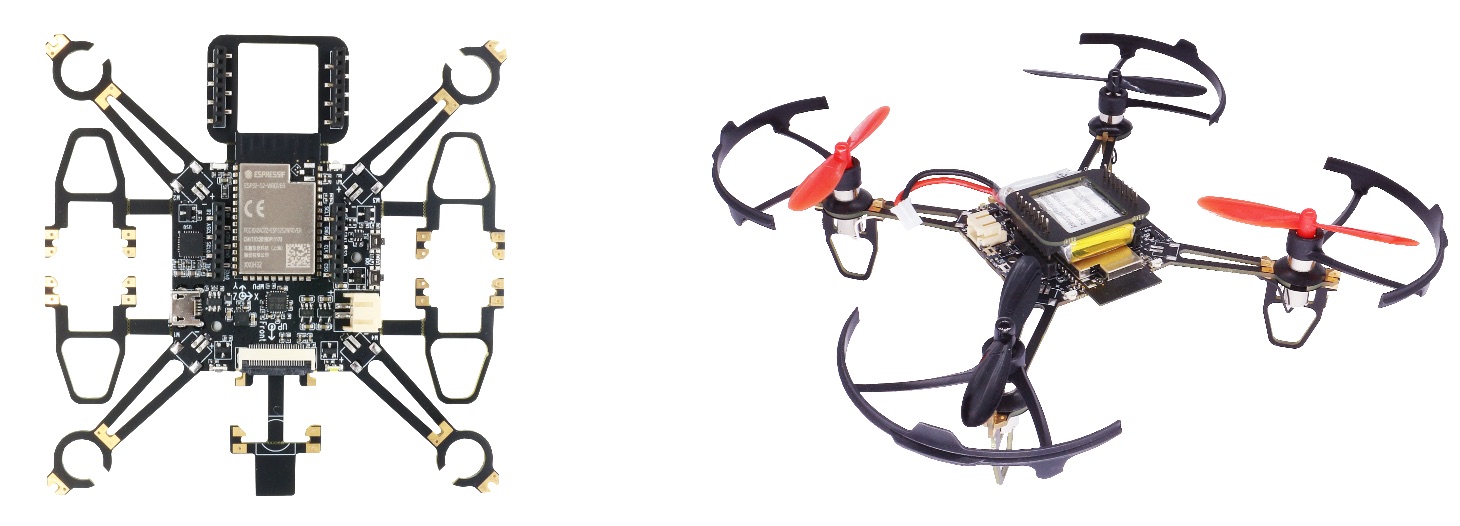
Aerial robots
ESP32-based educational quadcopter with a documented S2 V1.2 build and sensor-dependent assisted flight modes.
Six-legged servo hexapod
Historical six-legged servo robot with available frame designs, Servotor32 control sources and a Python 2-era host application.
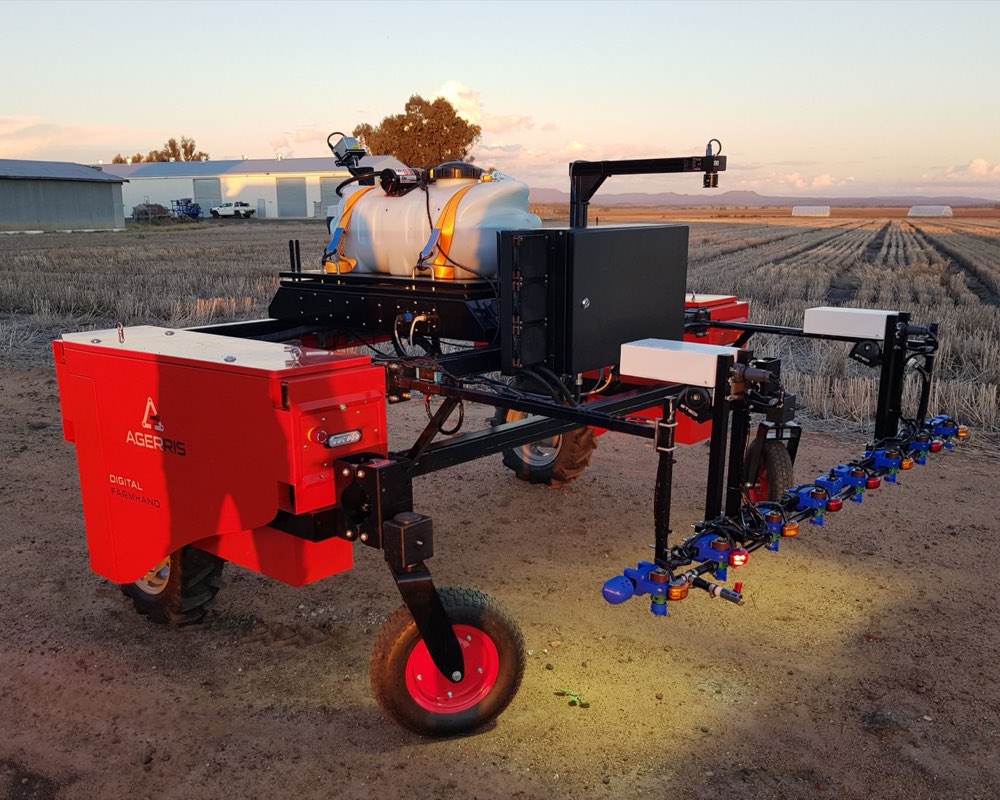
Wheeled robots & hardware
Raspberry Pi camera and relay subsystem for targeted weed treatment, with printable enclosures and configuration-specific wiring requirements.
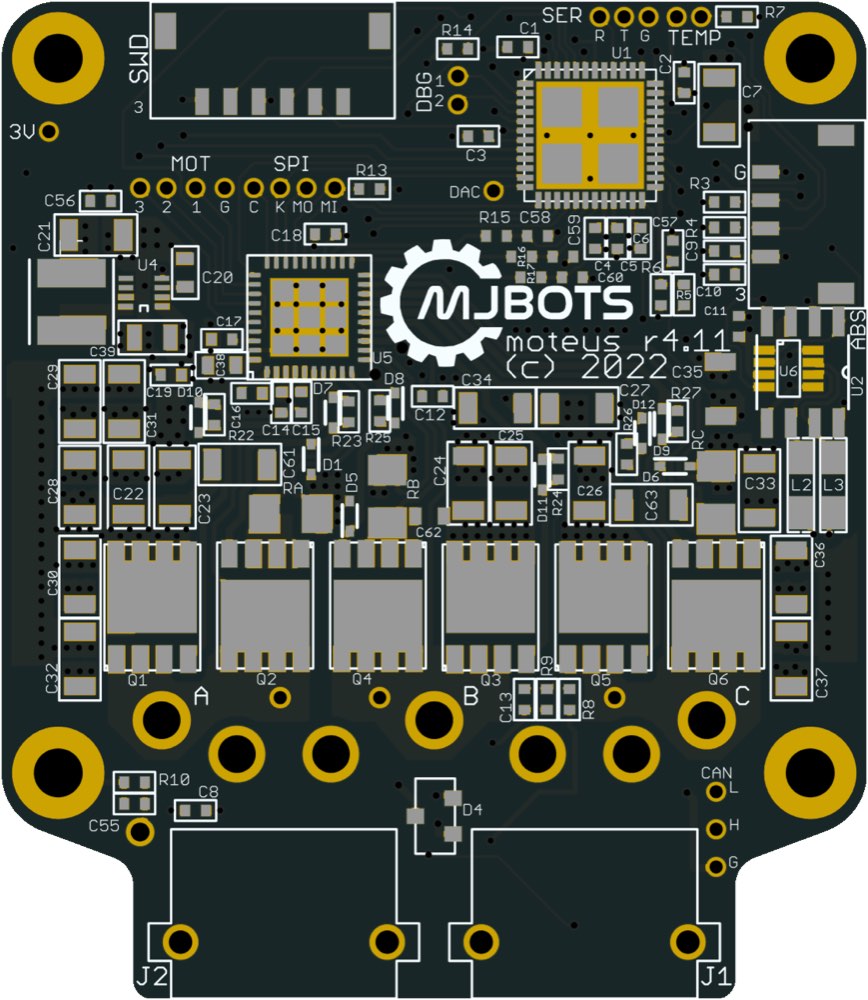
Motor controller
Open brushless servo-controller designs with CAN-FD control, board-specific electrical limits and motor calibration requirements.
Motor controller
Legacy dual-axis brushless motor control with public v3.x firmware; v3.6 board designs and newer-generation firmware have different openness boundaries.
Control board
ROS-oriented STM32F7 controller with Arduino firmware sources and separate REVH hardware files whose precise reuse license remains unresolved.
Actuator component
Brushless belt-reduced research actuator core with a v1.1 prepared encoder-kit route, precision printing requirements and separately integrated motor control.
Arms & manipulation hardware
TriFingerEdu v1 is a nine-axis torque-controlled manipulation platform built from three FingerEdu modules, with a documented TI evaluation-board control route.
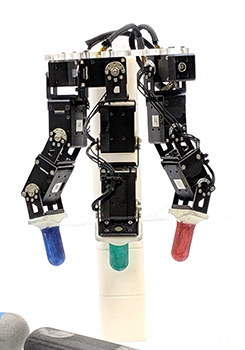
Arms & manipulation hardware
Nine-axis three-finger manipulation benchmark with a separately instrumented object. Historical v0.9 hardware and legacy software requirements are scoped separately.
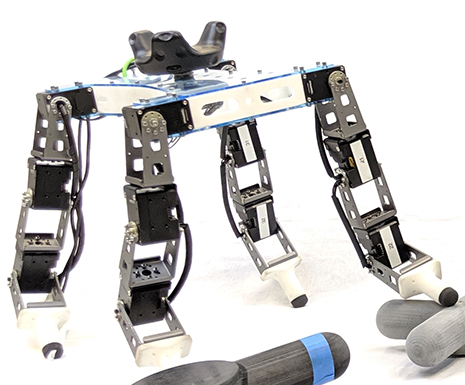
Legged robots & hardware
Twelve-axis quadruped benchmark with Dynamixel actuation and external-tracking support. Historical v0.9 hardware and legacy software requirements are scoped separately.
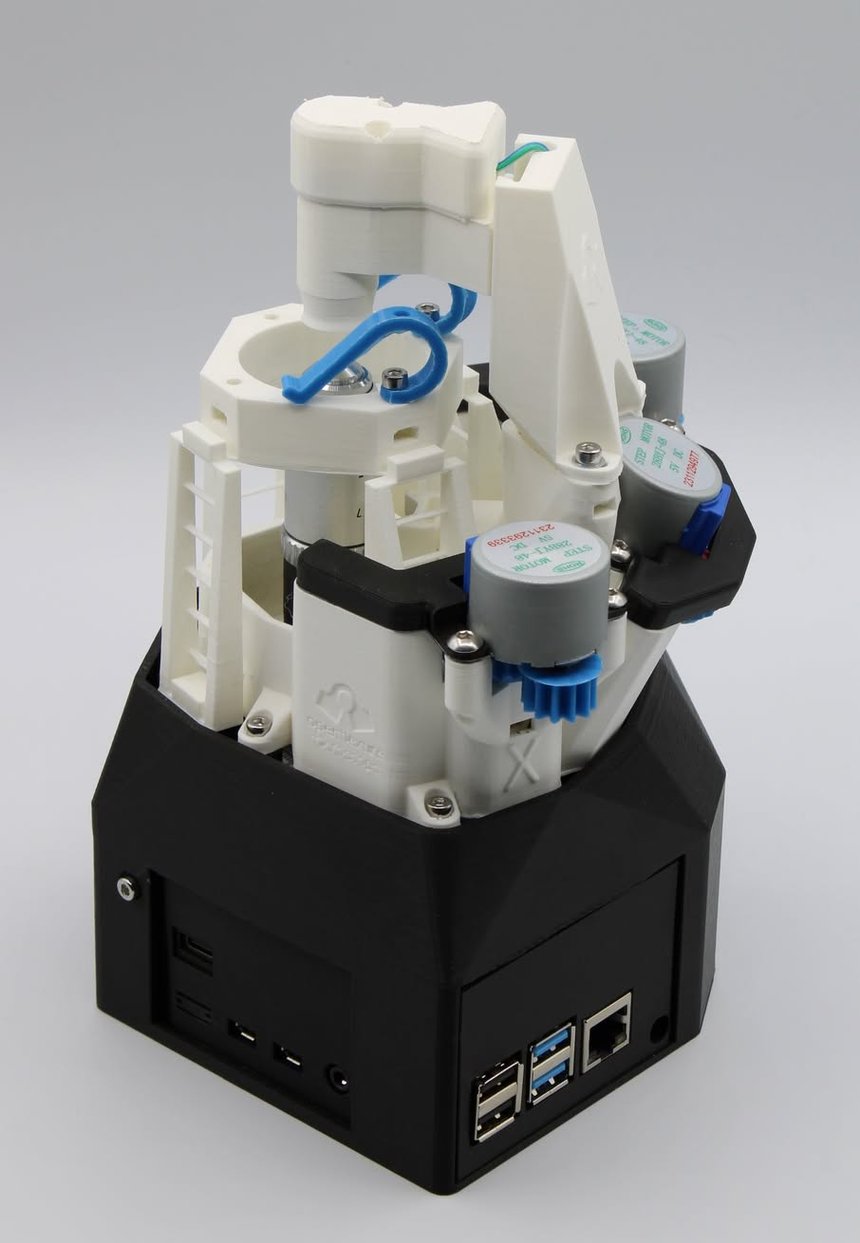
Arms & manipulation hardware
Motorized printed microscope with an RMS-objective build route, separate controller and software dependencies, and explicit beta-version compatibility limits.
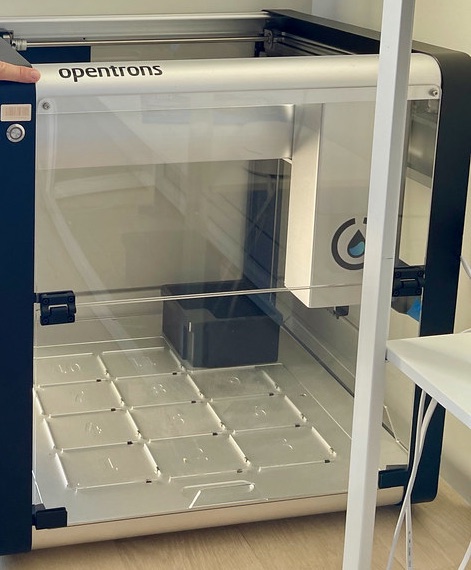
Arms & manipulation hardware
Programmable laboratory liquid handler with a dedicated OT-2 software route, published customization files and configuration-specific calibration requirements.
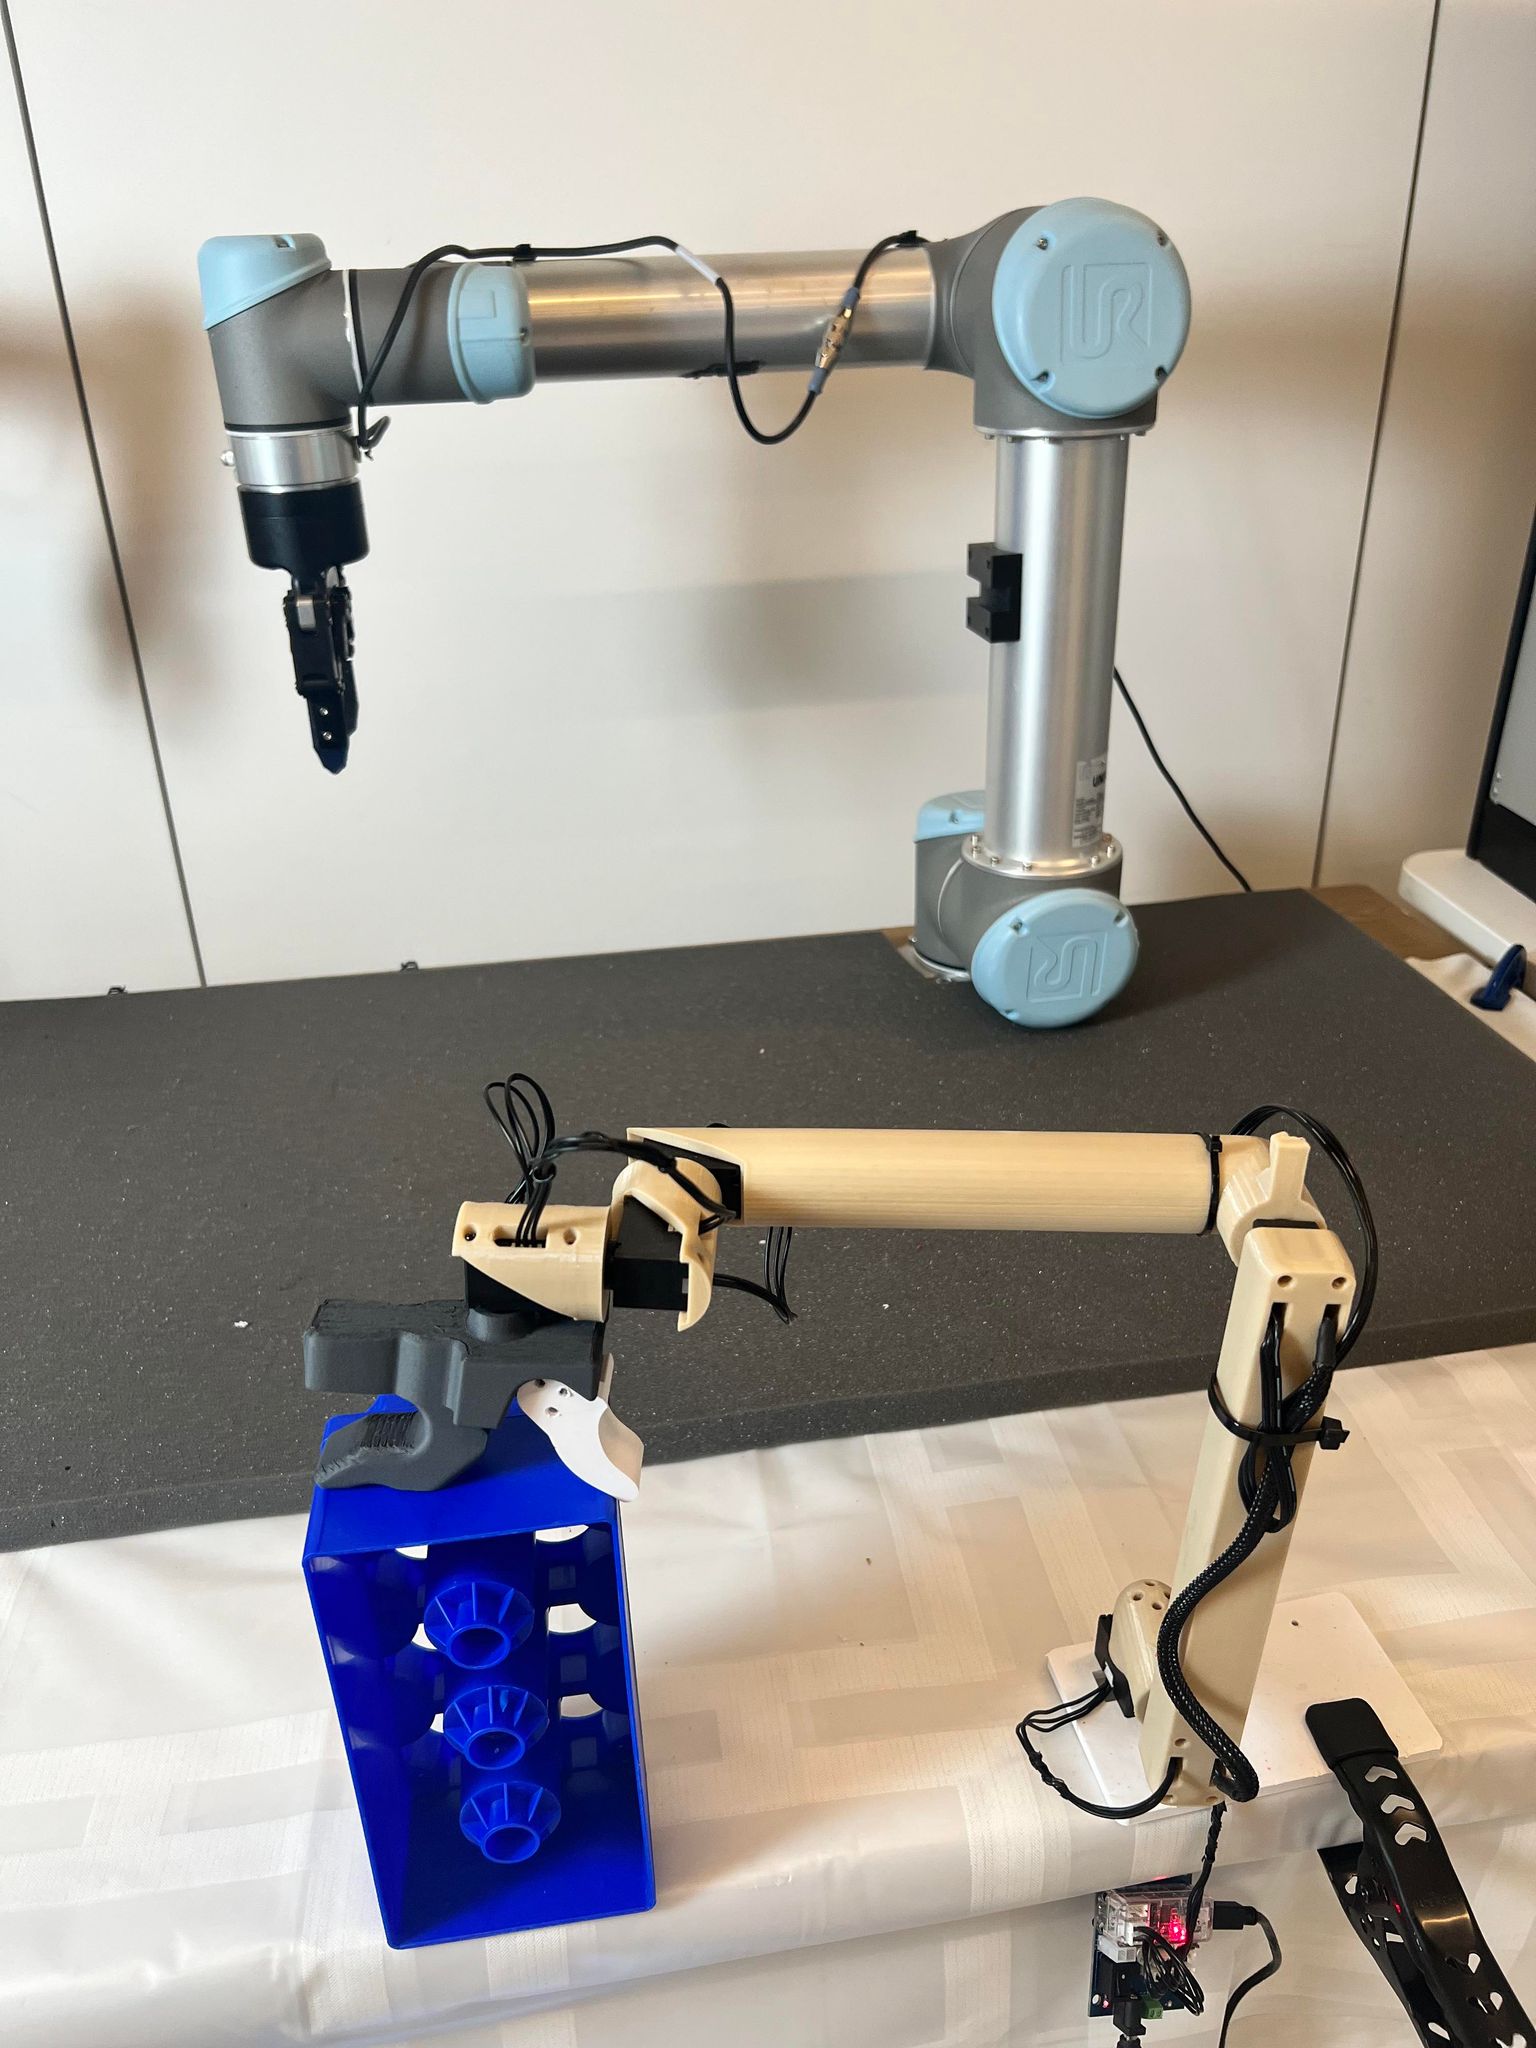
Teleoperation input
Joint-matched teleoperation leaders for robot manipulators; selected coverage follows the YAM passive configuration and distinguishes the separate Franka FR3 ROS 2 workflow.
Arms & manipulation hardware
Printed rotary pendulum with Arduino Nano control and a MuJoCo-to-hardware learning pipeline; preserved sources include rig-specific distilled policy weights and differing bring-up microstep guidance.
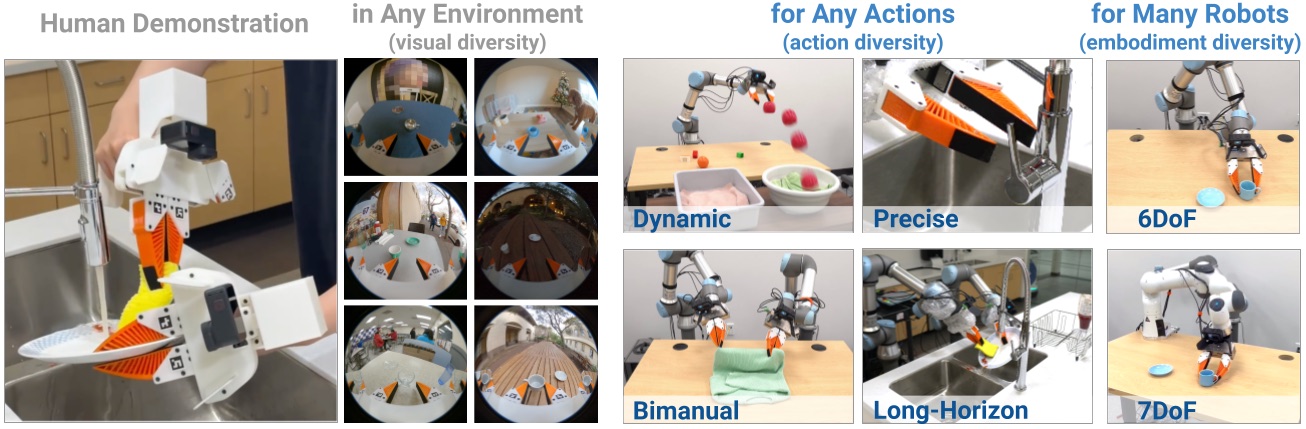
Arms & manipulation hardware
Handheld gripper-based demonstration collection and diffusion-policy workflow, with separate robot deployment hardware and explicit SLAM, timing and source-artifact gaps.
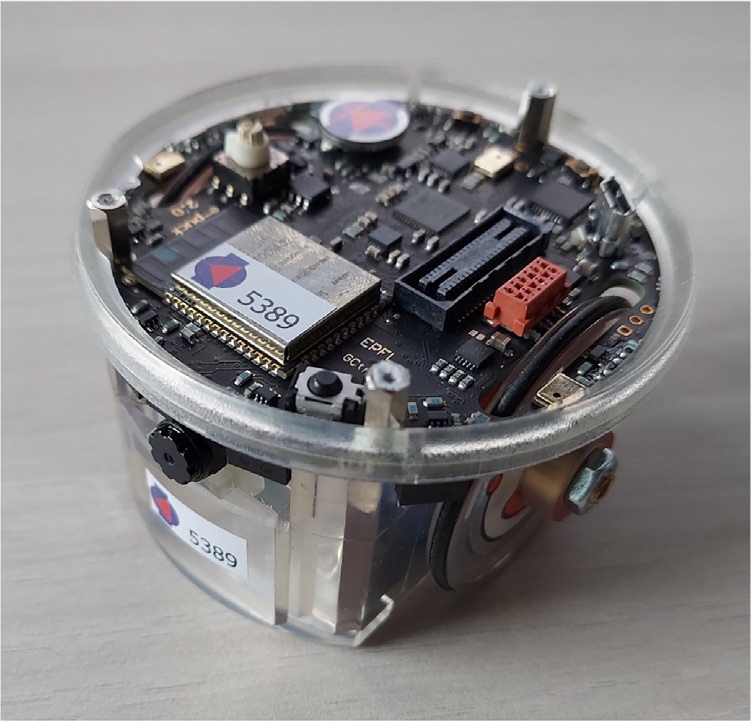
Wheeled robots & hardware
Small wheeled research robot; this profile covers e-puck2 using its official hardware guide, pinned Qt monitor and separately preserved STM32F407 firmware sources.
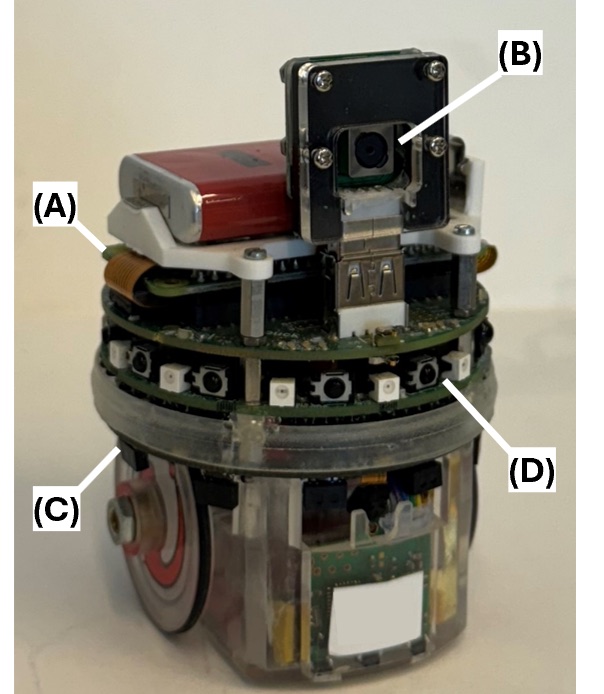
Controller extension
Raspberry Pi extension for e-puck and e-puck2 robots, with Linux integration, separate controller firmware and an optional YRL expansion board.
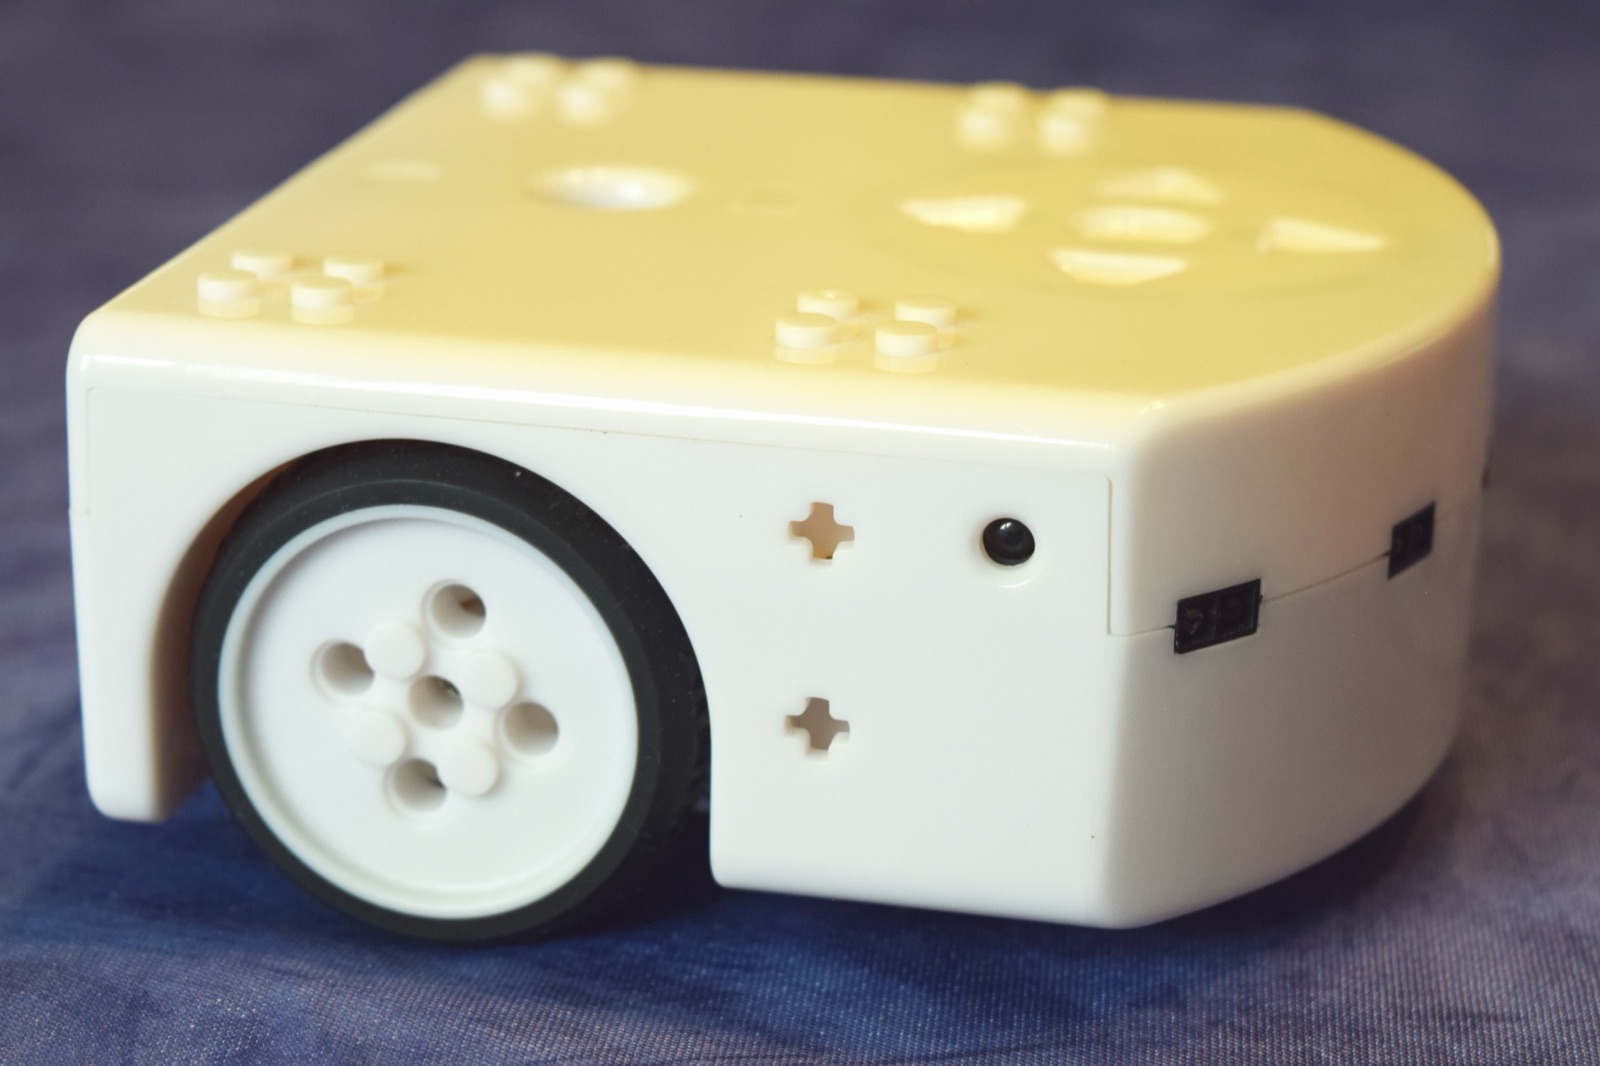
Wheeled robots & hardware
Educational wheeled robot; this profile selects Thymio II PCB version 2.1 design sources and separately preserved V14 firmware, with explicit generation and dependency boundaries.
Wheeled robots & hardware
DIY robotic mower reference platform; this review selects the 1.0a10-Azurit release and records its PCB configuration, stored-setting behavior and conflicting license notices.
Wheeled robots & hardware
RTK-guided mower conversion ecosystem; this review selects the v2 YardForce route and preserves its separate carrier-board and xCore firmware revisions.
Wheeled robots & hardware
Experimental agricultural robot integration stack using ROS 2 Jazzy, ESP32/Lizard control and RTK GNSS; the selected sources distinguish Gazebo mission results from incomplete hardware validation.
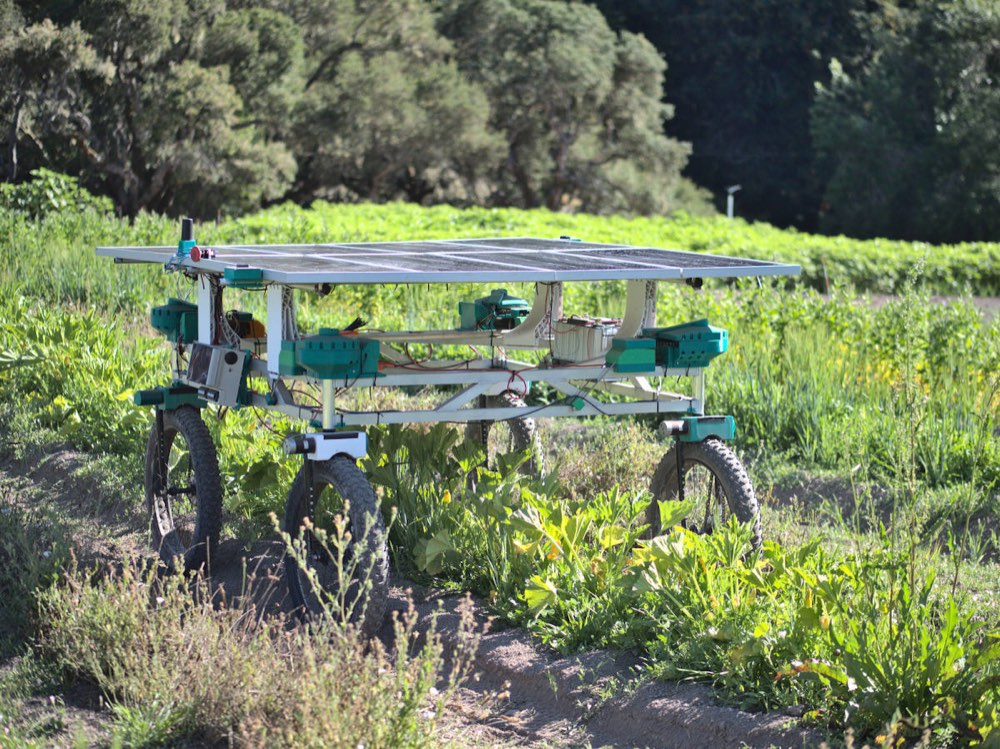
Wheeled robots & hardware
Precision farming rover with separate software, electronics and mechanical sources; the documented Docker simulation substitutes fake sensor data and is not evidence of field performance.
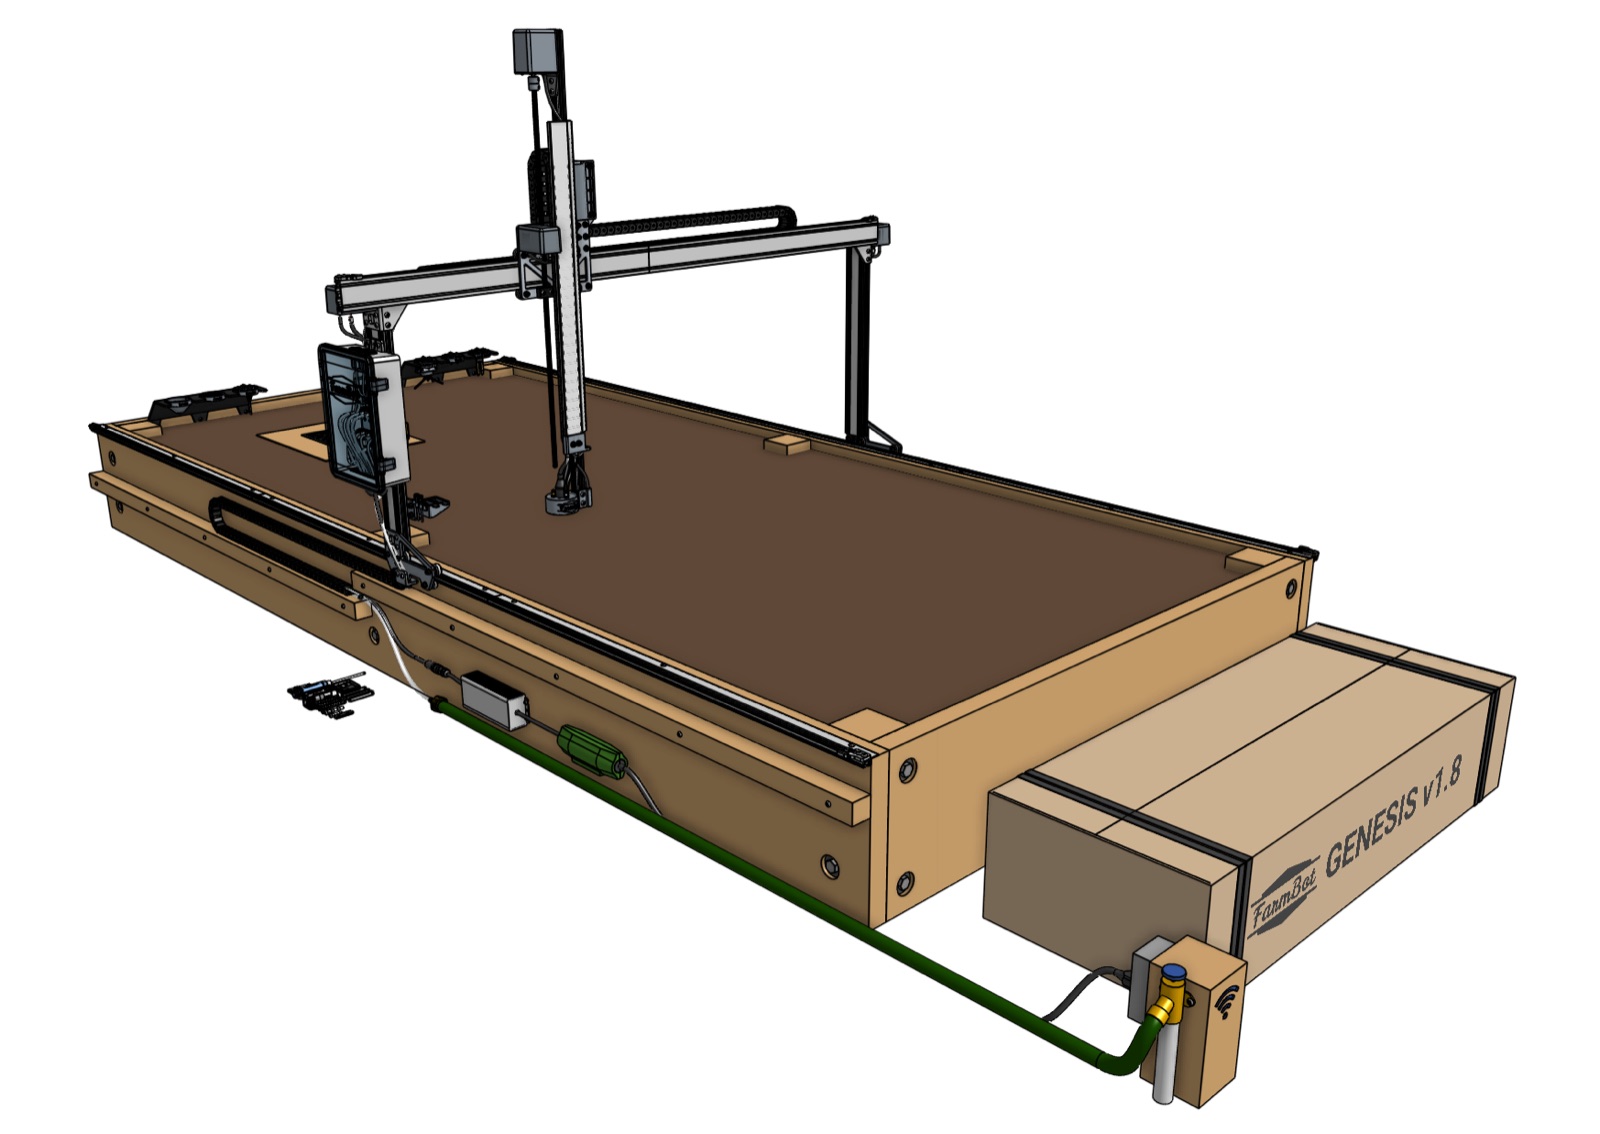
Arms & manipulation hardware
Track-mounted gardening robot with a moving gantry and interchangeable tools; this profile selects FarmBot Genesis v1.8 documentation and distinguishes the standard and XL installations.
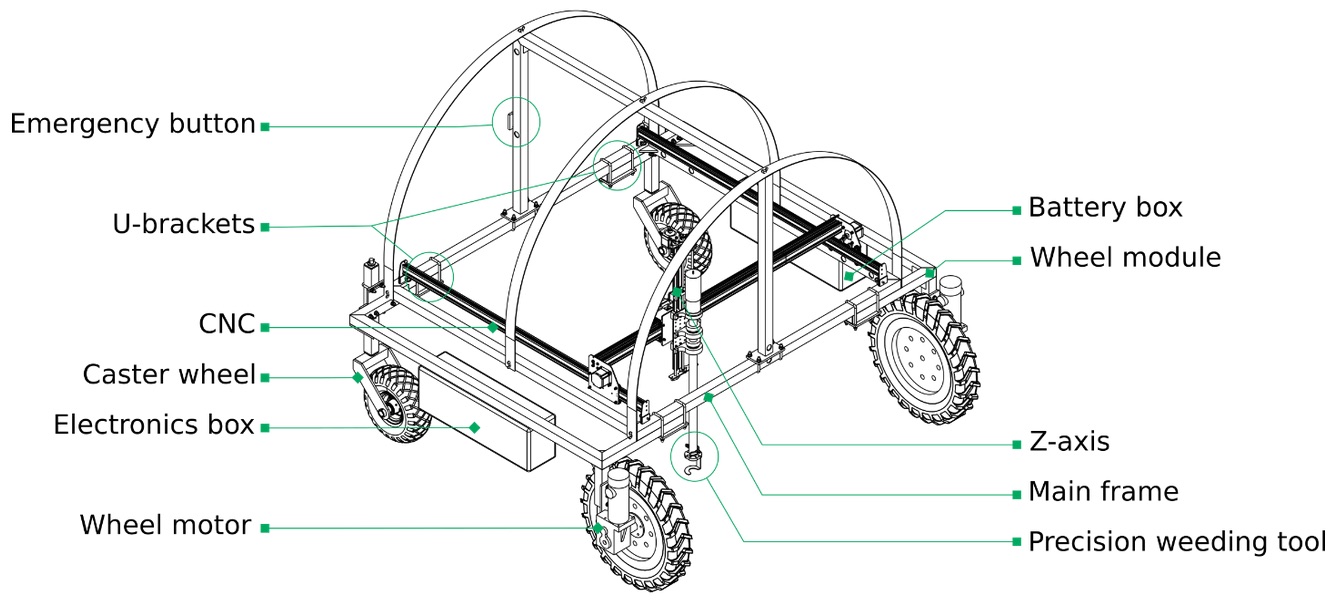
Wheeled robots & hardware
Agricultural weeding rover with published prototype V3 design files and an adapted CNC weeding tool; unfinished electronics and steering details require configuration work.
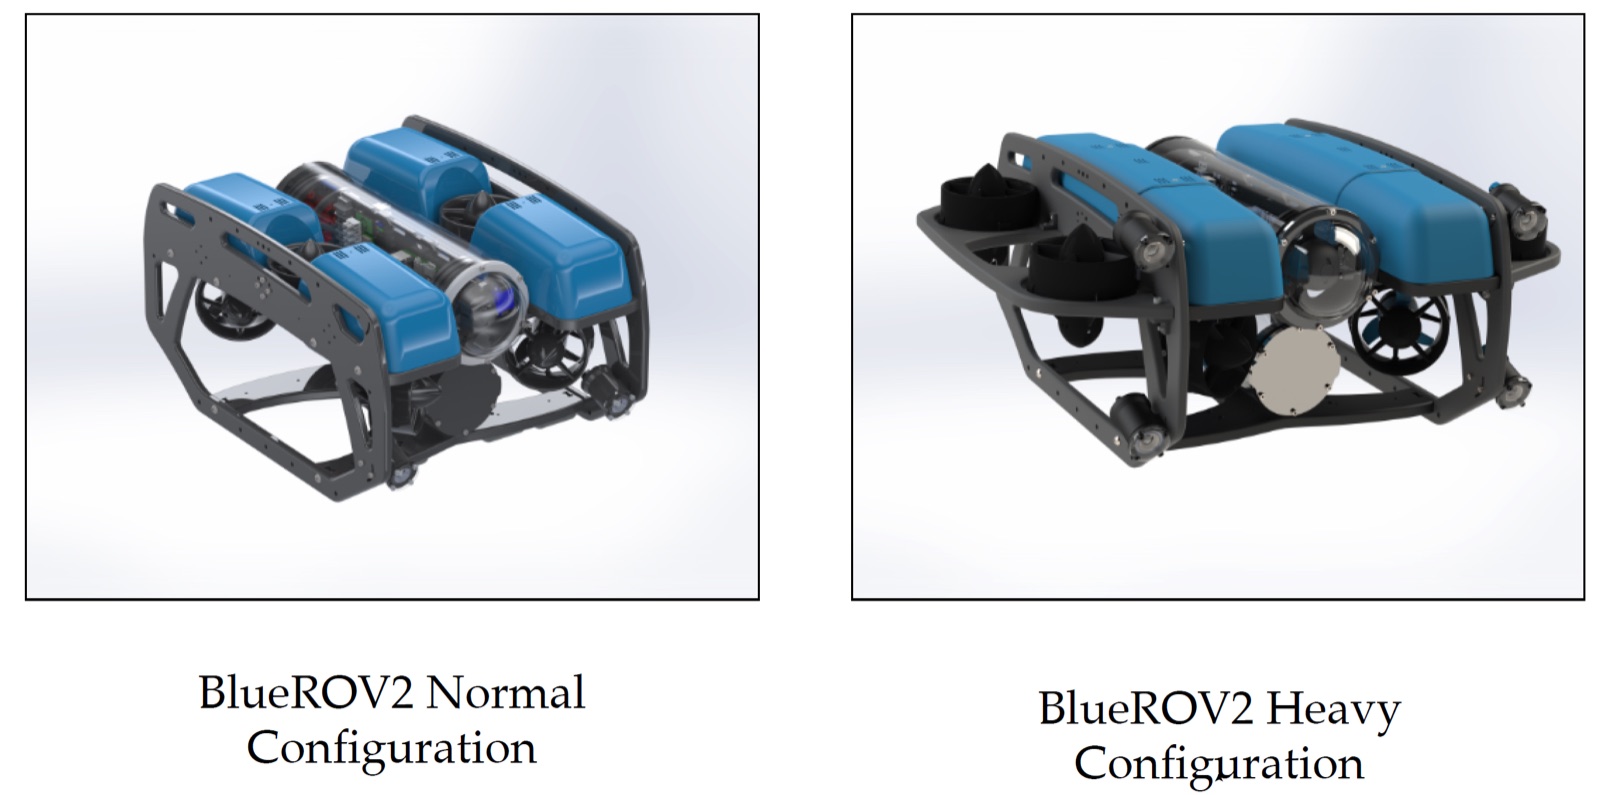
Marine robots
Commercial underwater ROV with published integration CAD and open software; this profile selects the standard six-thruster R4 configuration and distinguishes it from the Heavy upgrade.
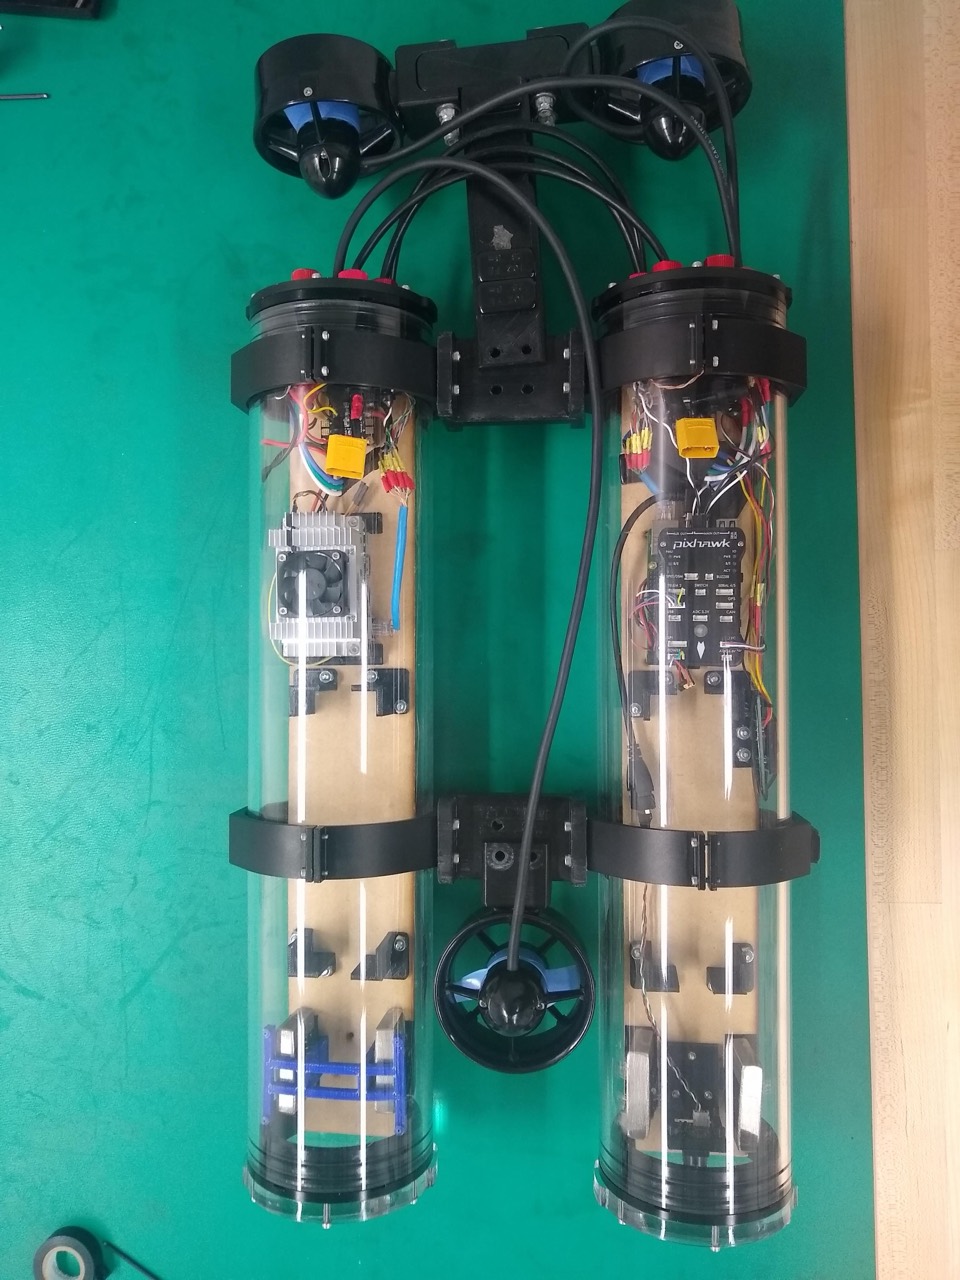
Marine robots
Research autonomous underwater vehicle with Pixhawk, Raspberry Pi and Jetson TX2; this review selects the documented LoCO 1.0 configuration and separates later internal structure alternatives.
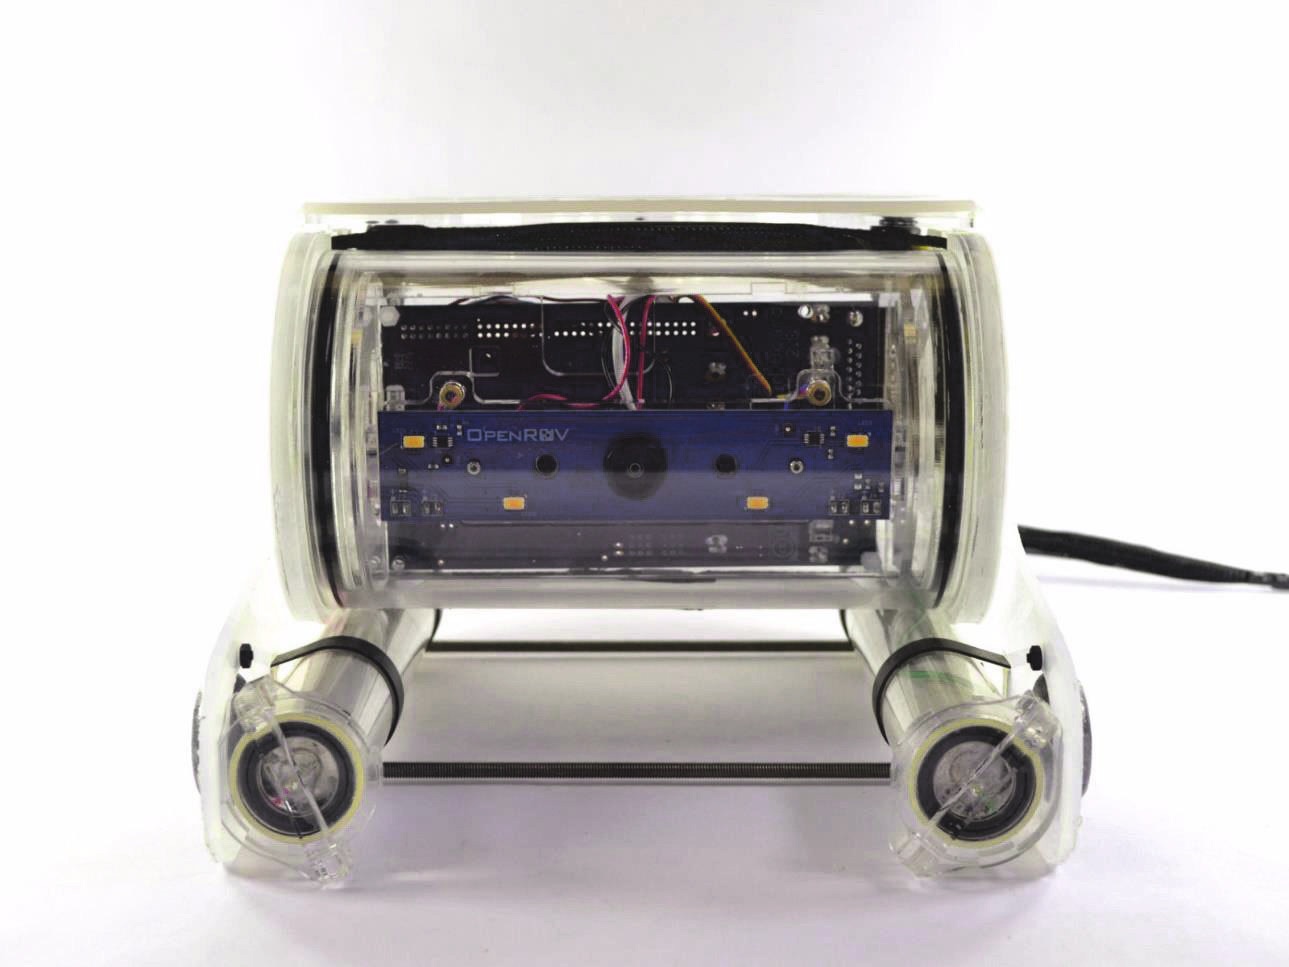
Marine robots
Historical DIY underwater exploration platform; this entry selects the OpenROV 2.8 mechanical files and the corresponding named controller-board package for source research.
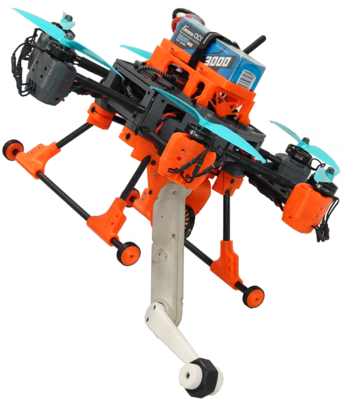
Aerial robots
Research aerial manipulator combining a six-motor flying platform with a two-link torque-controlled extremity and an external motion-capture setup.
Aerial robots
Educational quadrotor platform pairing a PX4 flight controller with Raspberry Pi and ROS; this entry selects Clover 4.2 construction and the documented ROS Noetic image route.
Aerial robots
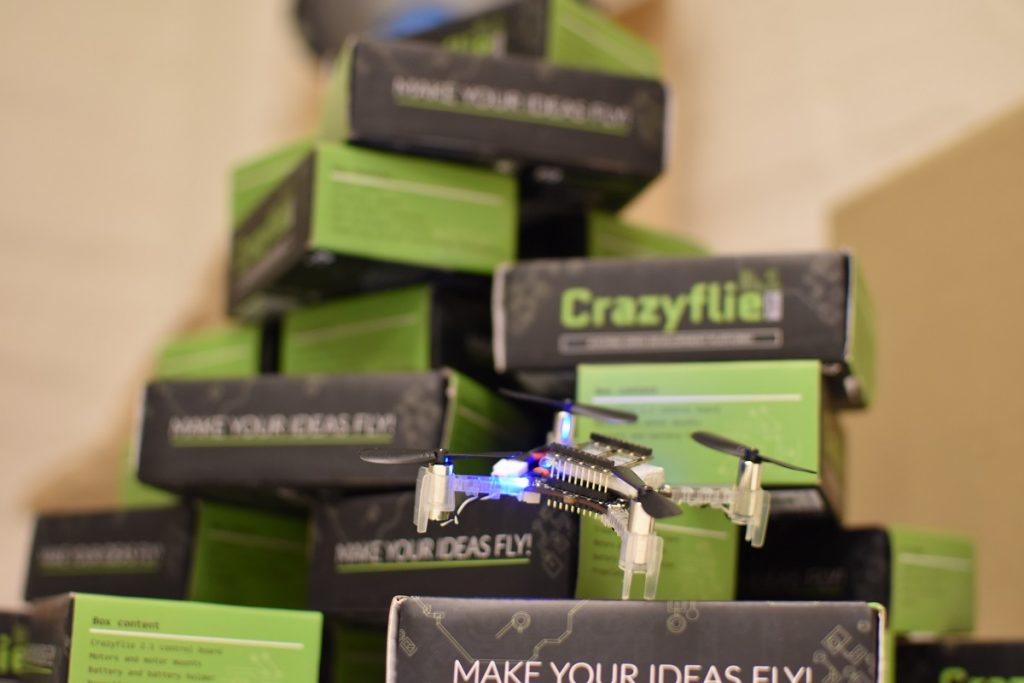
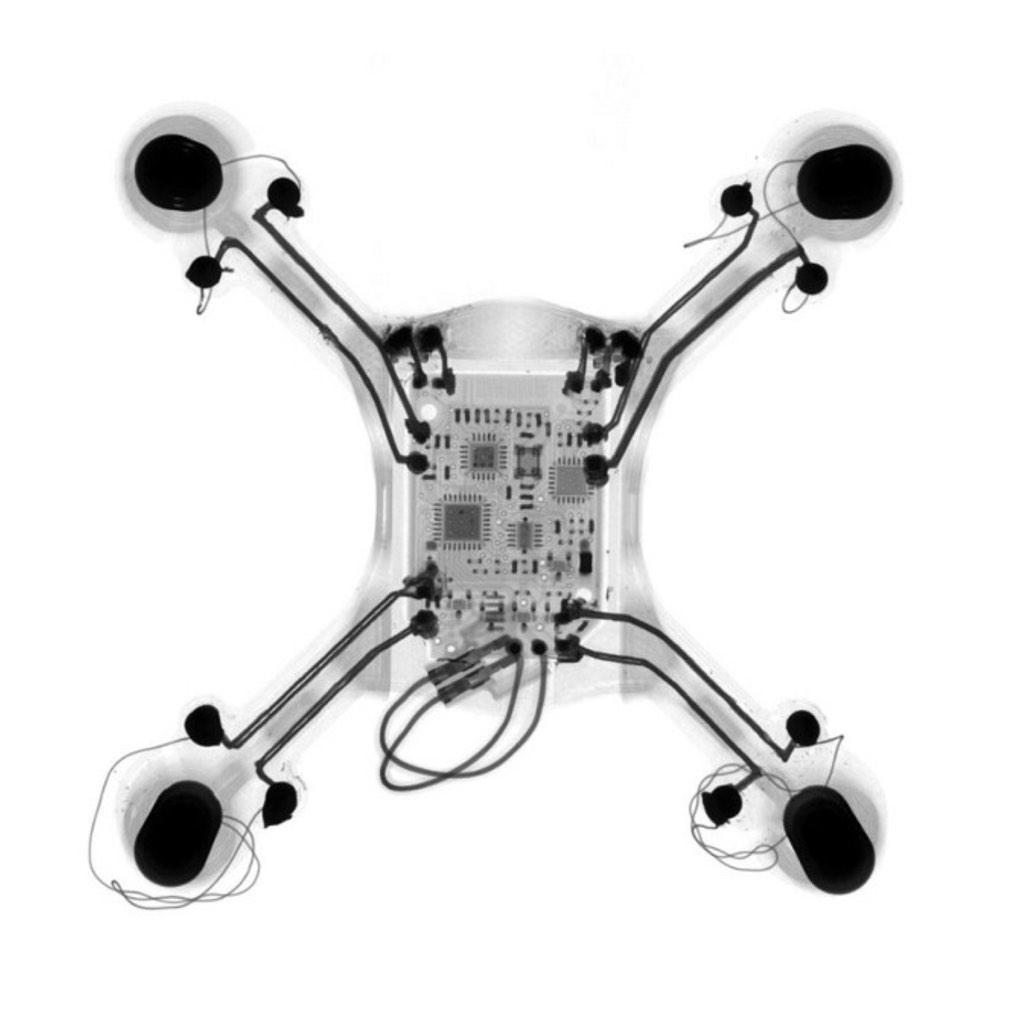
Small quadrotor development platform; this profile selects the brushed Crazyflie 2.1 hardware and distinguishes its firmware target from Brushless and Bolt variants.
Aerial robots
Laser-cut quadrotor frame for carrying a smartphone or compact camera; the preserved frame files and original Spanish manual leave complete software and electronics reproduction unresolved.
Wheeled robots & hardware
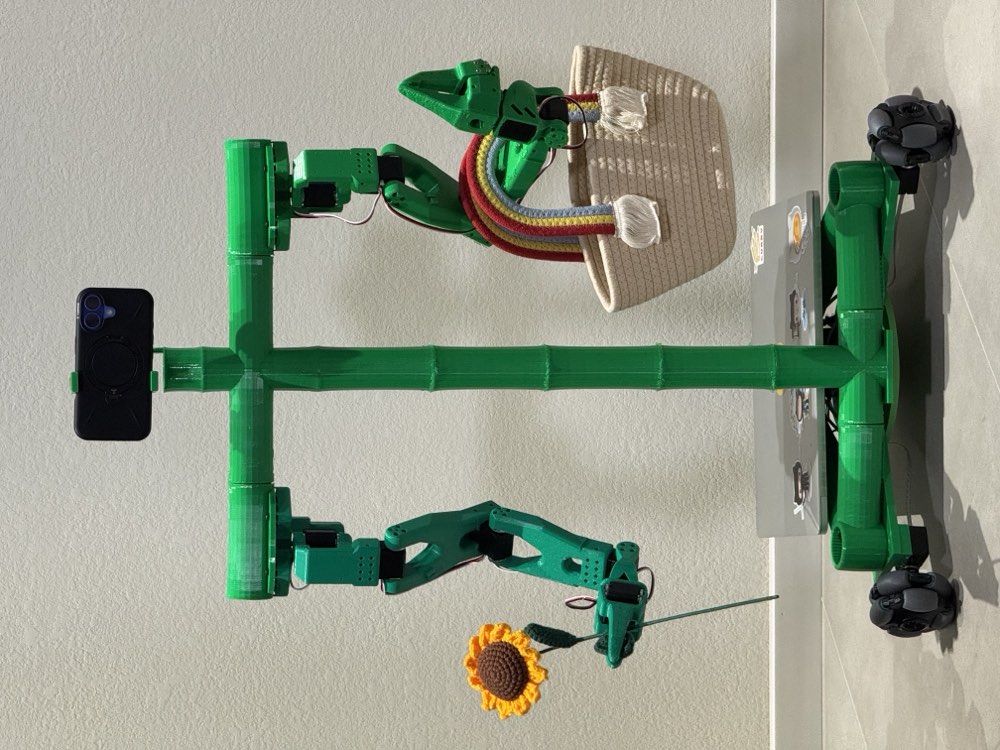
Two-arm mobile manipulator with a three-wheel omnidirectional base, released printable parts and a modified LeRobot control repository.
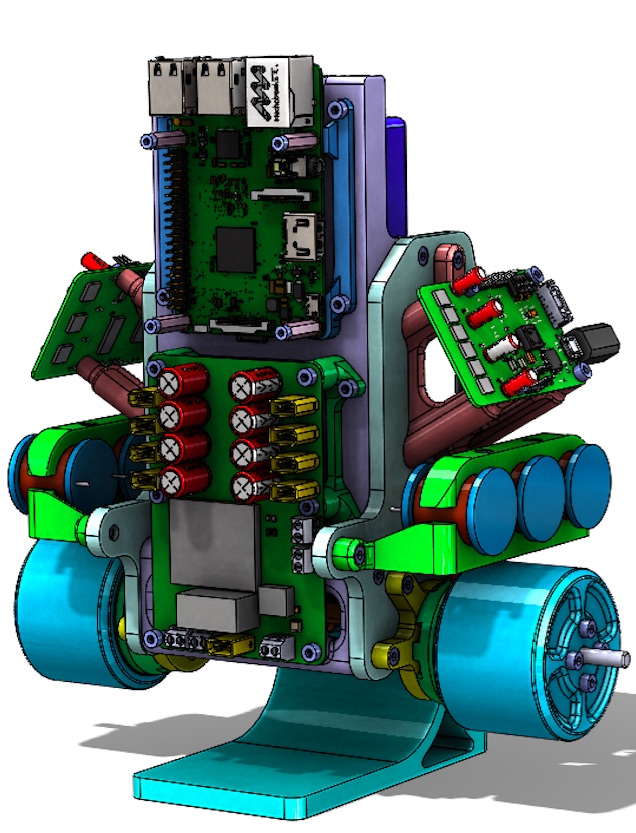
Two-wheel inverted-pendulum balancing robot.
Two-wheel balancing robot with ROS 1 control and Gazebo simulation sources; physical construction uses custom motor drives, a Pi CAN shield and power distribution board.
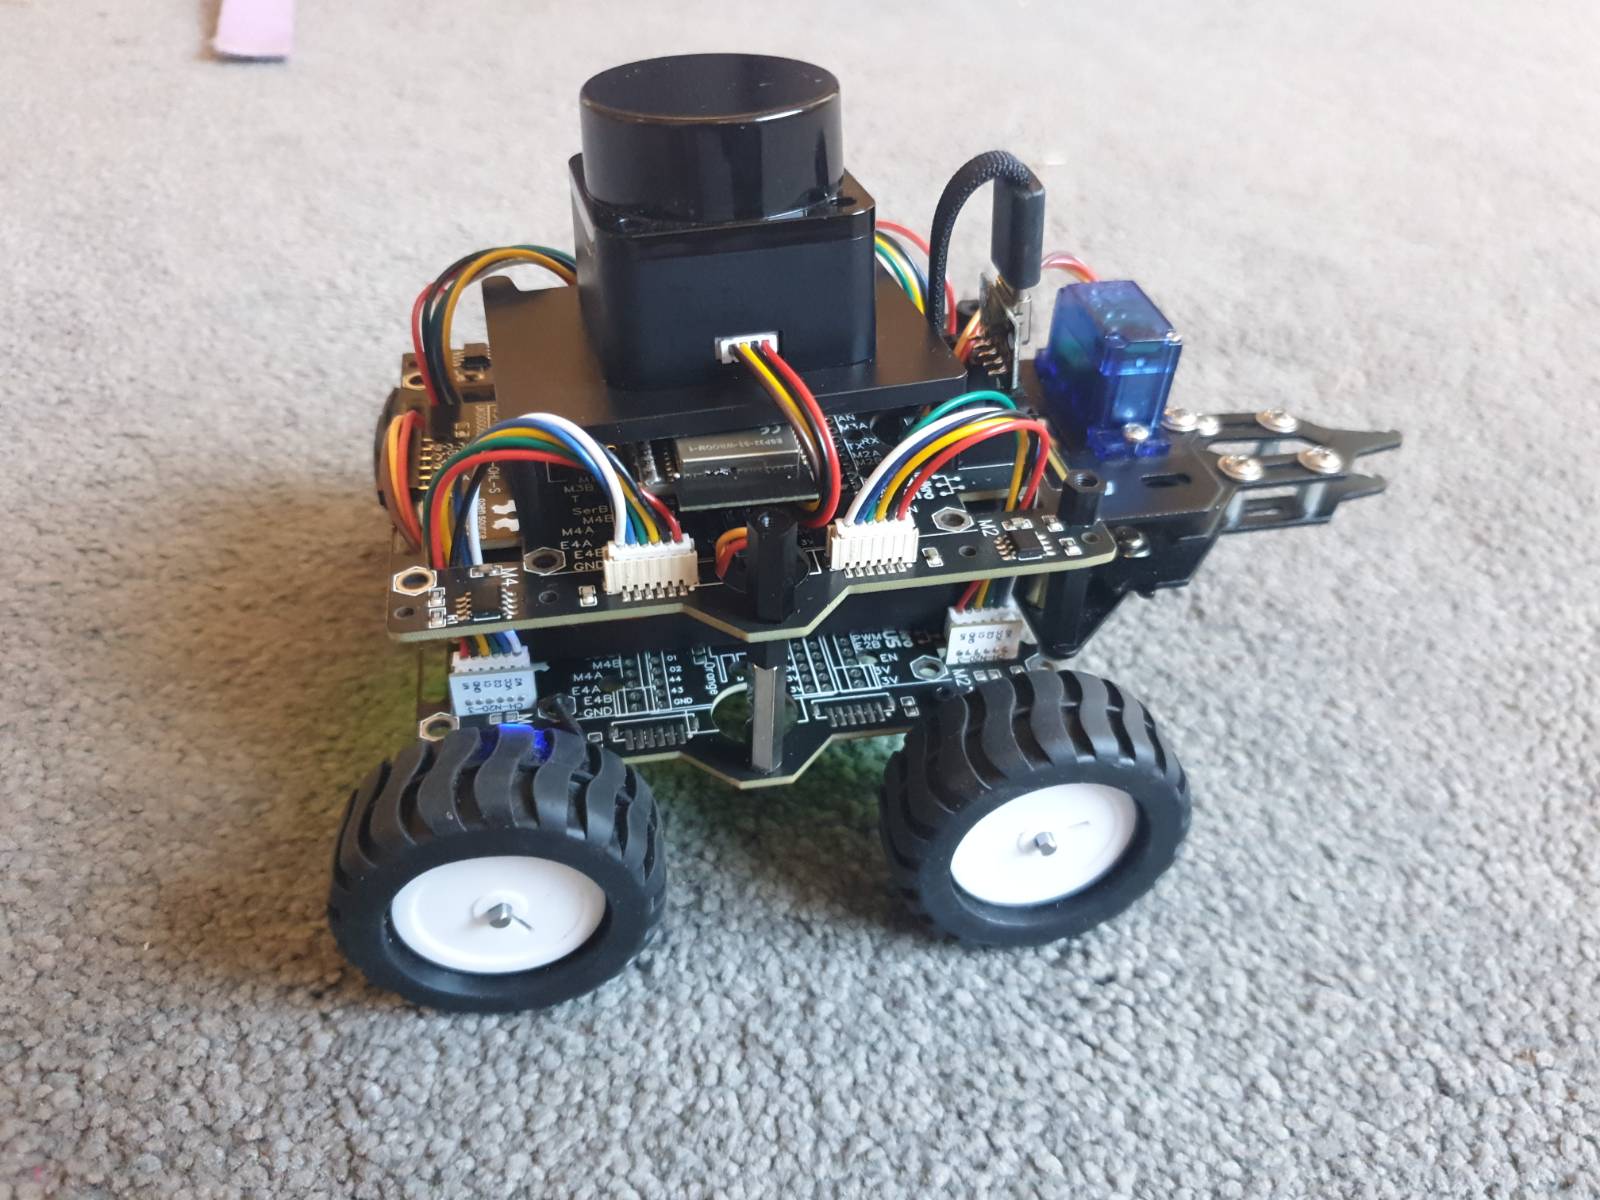
Wheeled robots & hardware
Small modular robot with a PCB chassis, ESP32-S3 and two- or four-wheel variants; separate Microblocks, MicroPython and ROS 2 routes have different maturity.
Wheeled robots & hardware
Two-wheel balancing robot project using a Raspberry Pi, pi3hat and moteus motor controllers, with printed parts and source-defined balance settings.
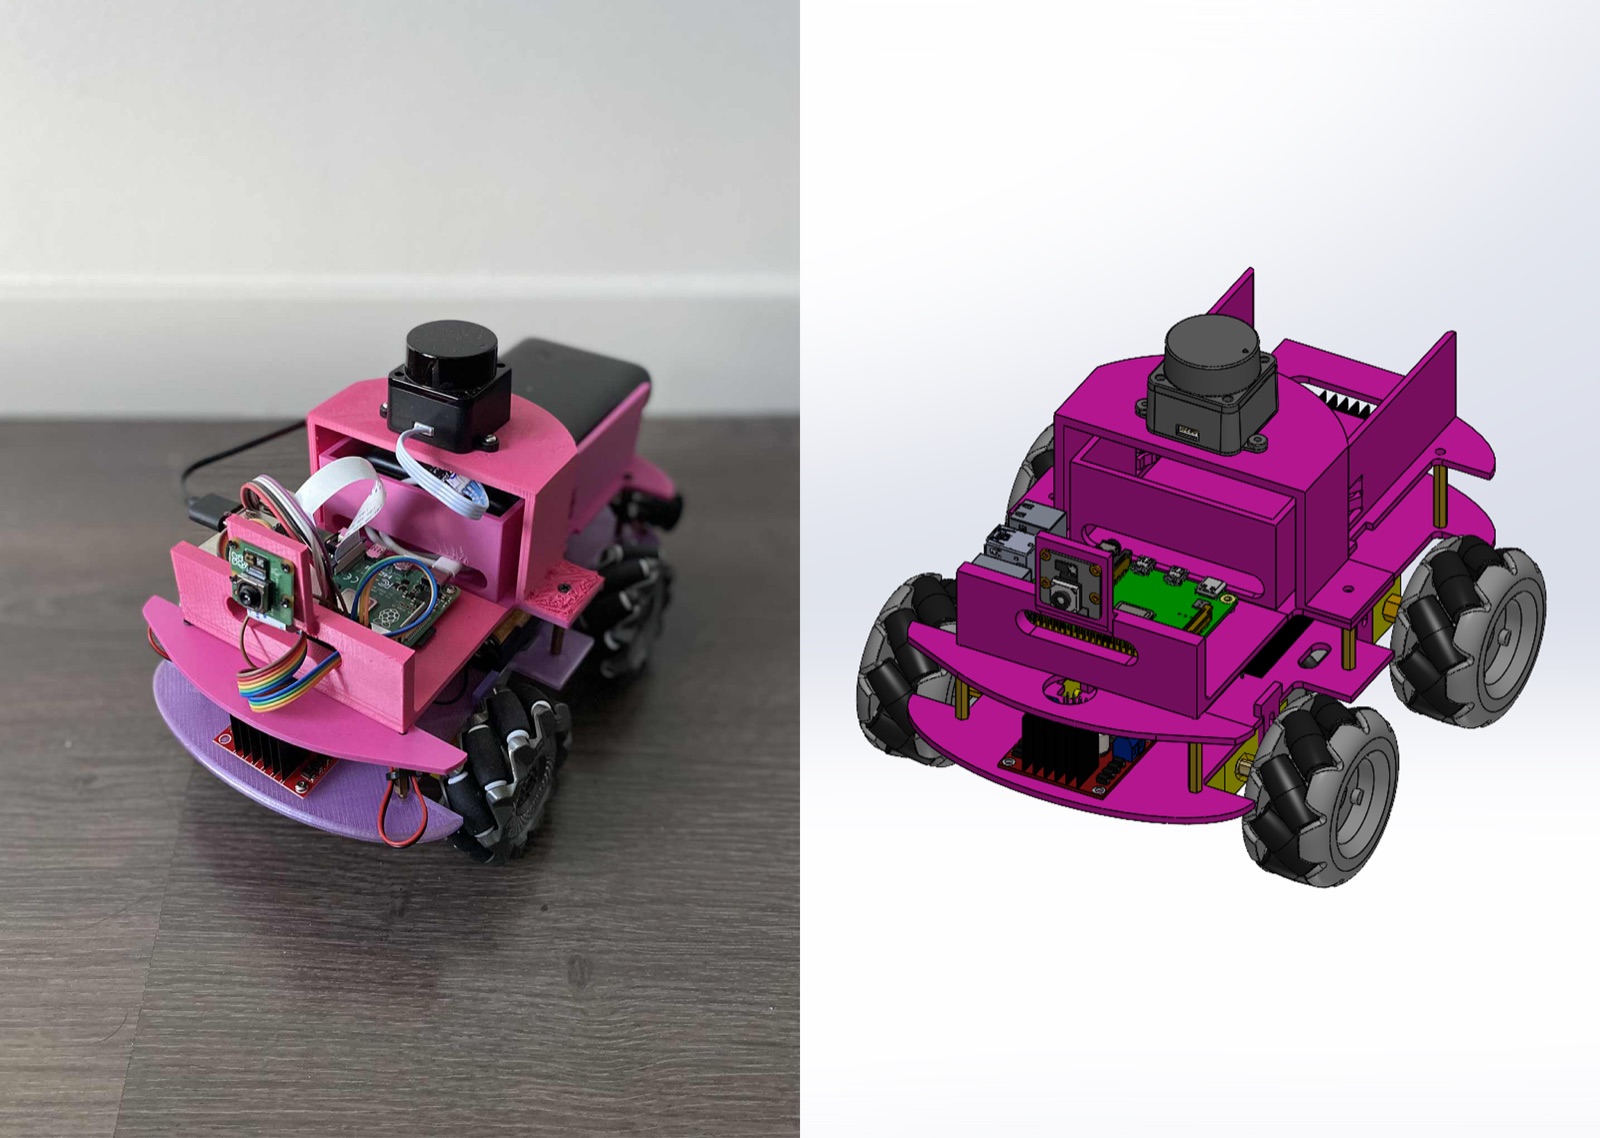
Wheeled robots & hardware
Raspberry Pi mecanum robot with ROS 2 navigation using lidar and an IMU; its published wheel commands are not measured wheel speeds.
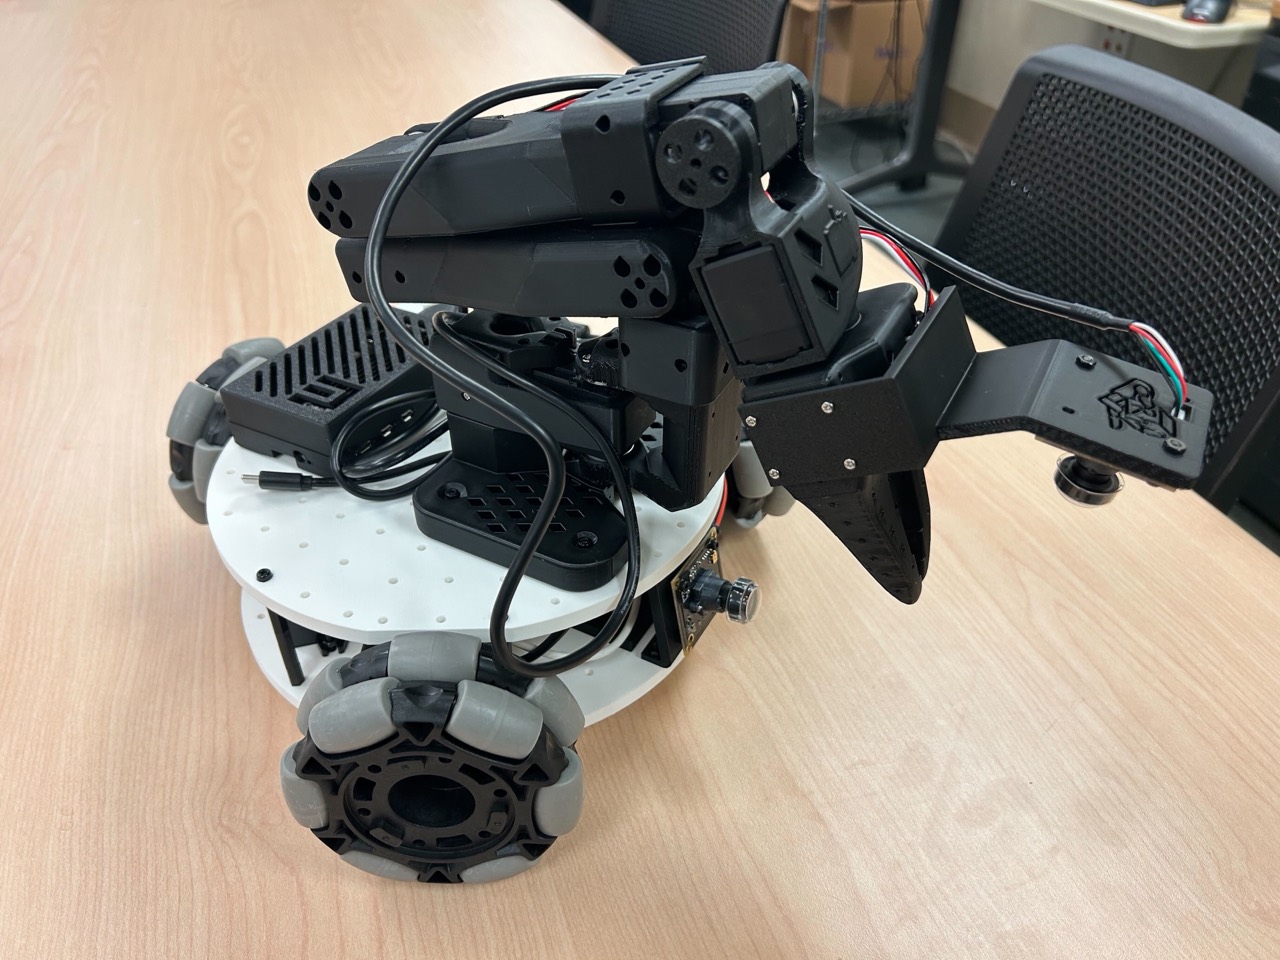
Wheeled robots & hardware
Three-wheel mobile manipulator with SO-100/SO-101 arm options, printed parts and a separate LeRobot teleoperation stack.
From USD 546.97 Known US parts subtotal · Oct 4, 2026
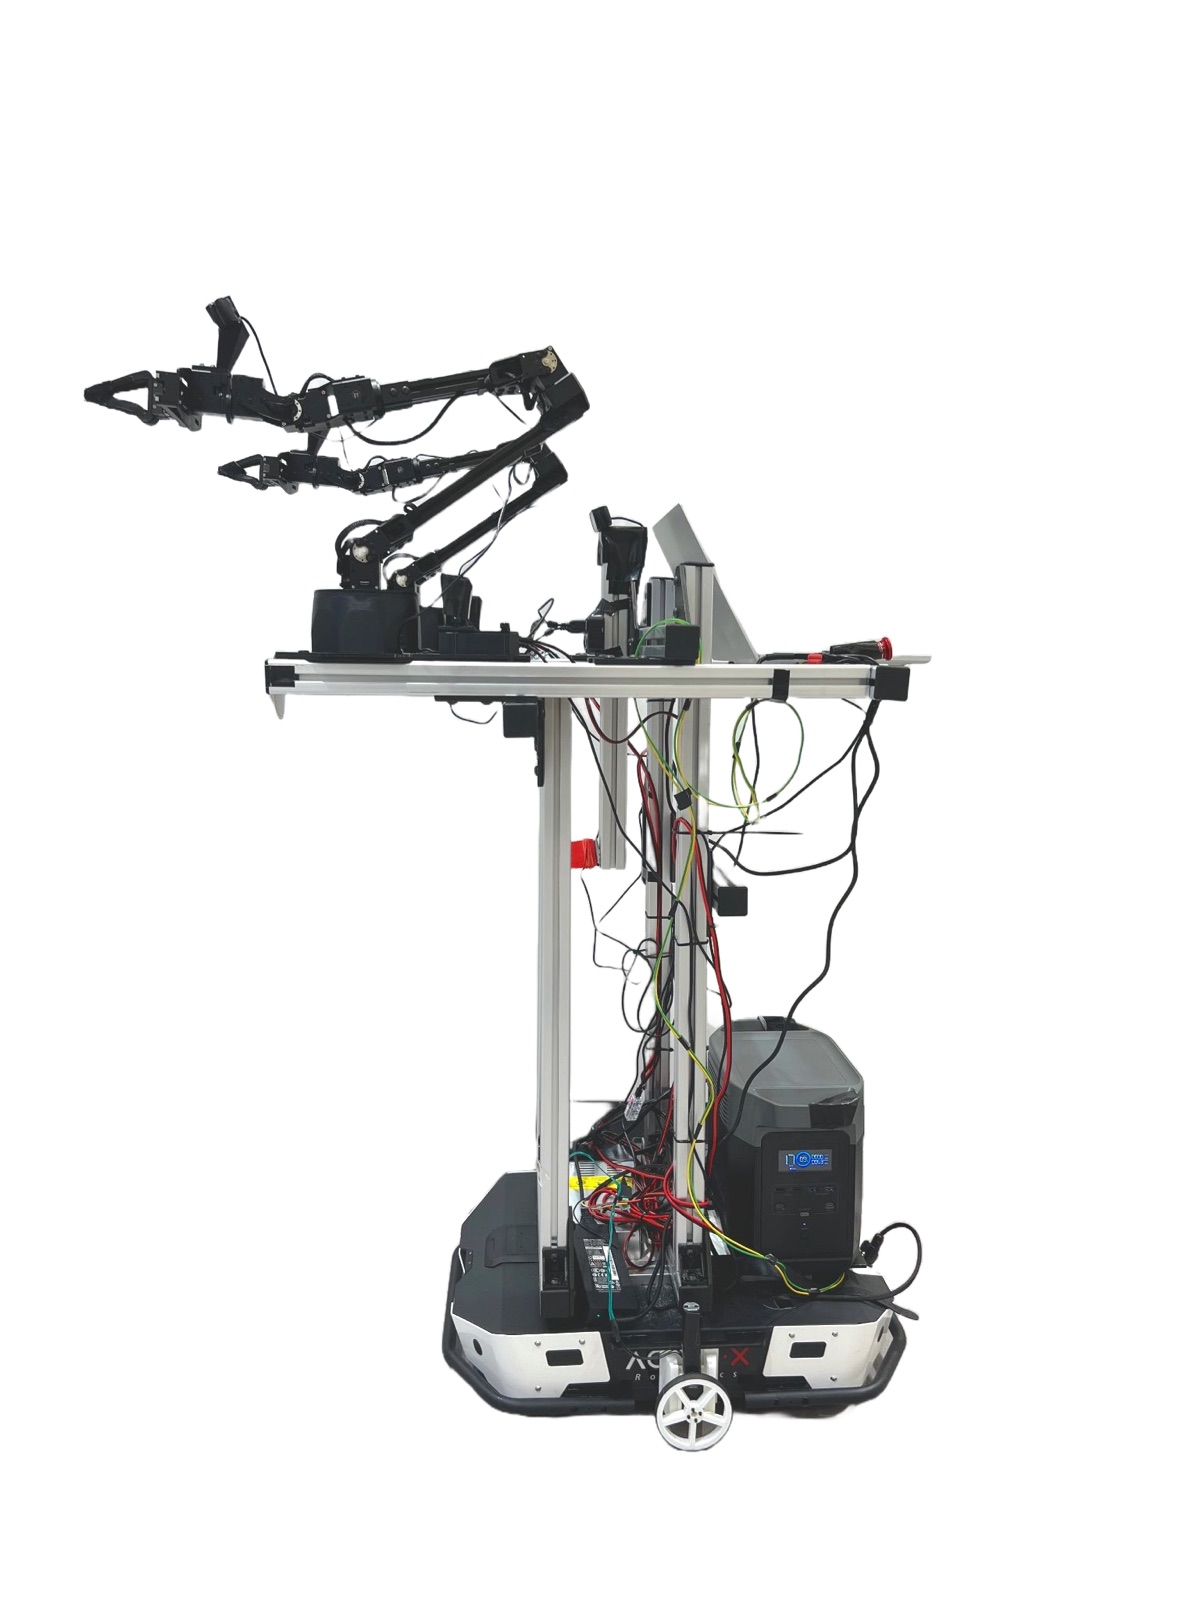
Wheeled robots & hardware
Hardware-and-software platform combining two leader arms, two follower arms and an AgileX Tracer base for whole-body teleoperation and demonstration collection.
About USD 31,757.86 upstream estimate
Wheeled robots & hardware
Small tracked Jetson robot; this profile covers the preserved 1.5.1 source, whose container recipe targets ROS 2 Foxy and whose STL files carry noncommercial terms.
Wheeled robots & hardware
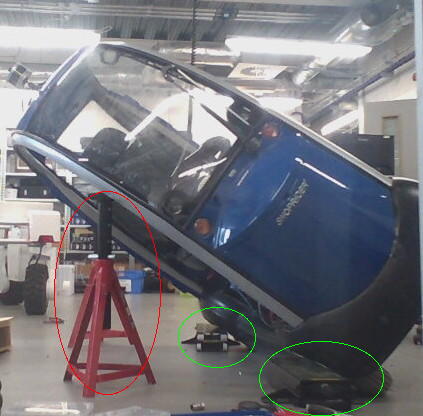
Research vehicle conversion built around a specific mobility scooter, with Arduino throttle control, actuator steering and a legacy ROS/Gazebo stack.
Wheeled robots & hardware
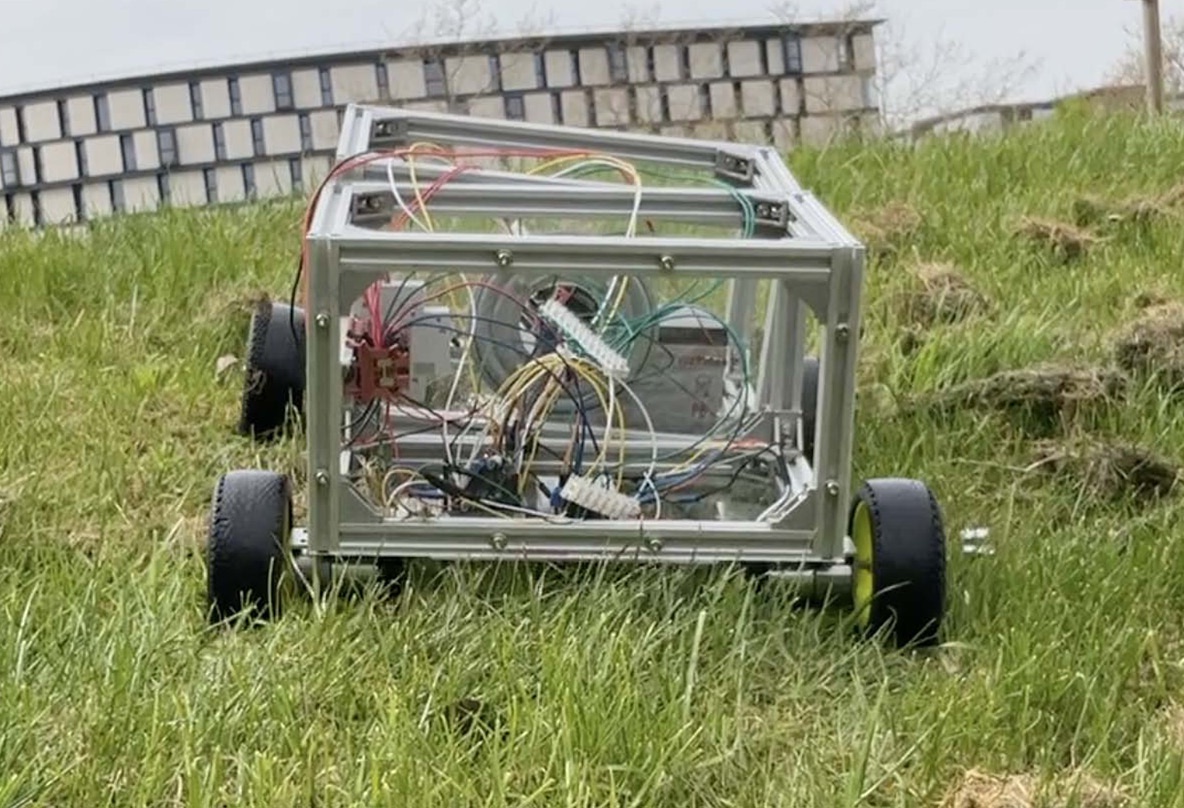
Four-wheel mobile base built from aluminum extrusions, with a documented articulated chassis, radio control and encoder-based motor control.
Wheeled robots & hardware
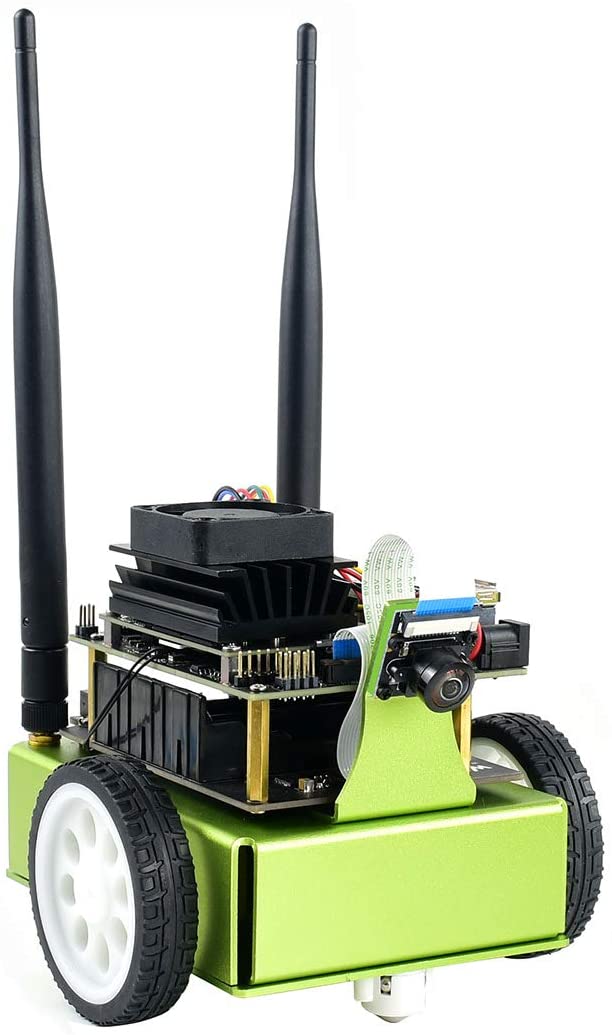
Small Jetson Nano educational robot with printed chassis and browser-based control; the reviewed 0.4.3 build uses legacy Nano-specific images and matched wheel/caster parts.
Wheeled robots & hardware
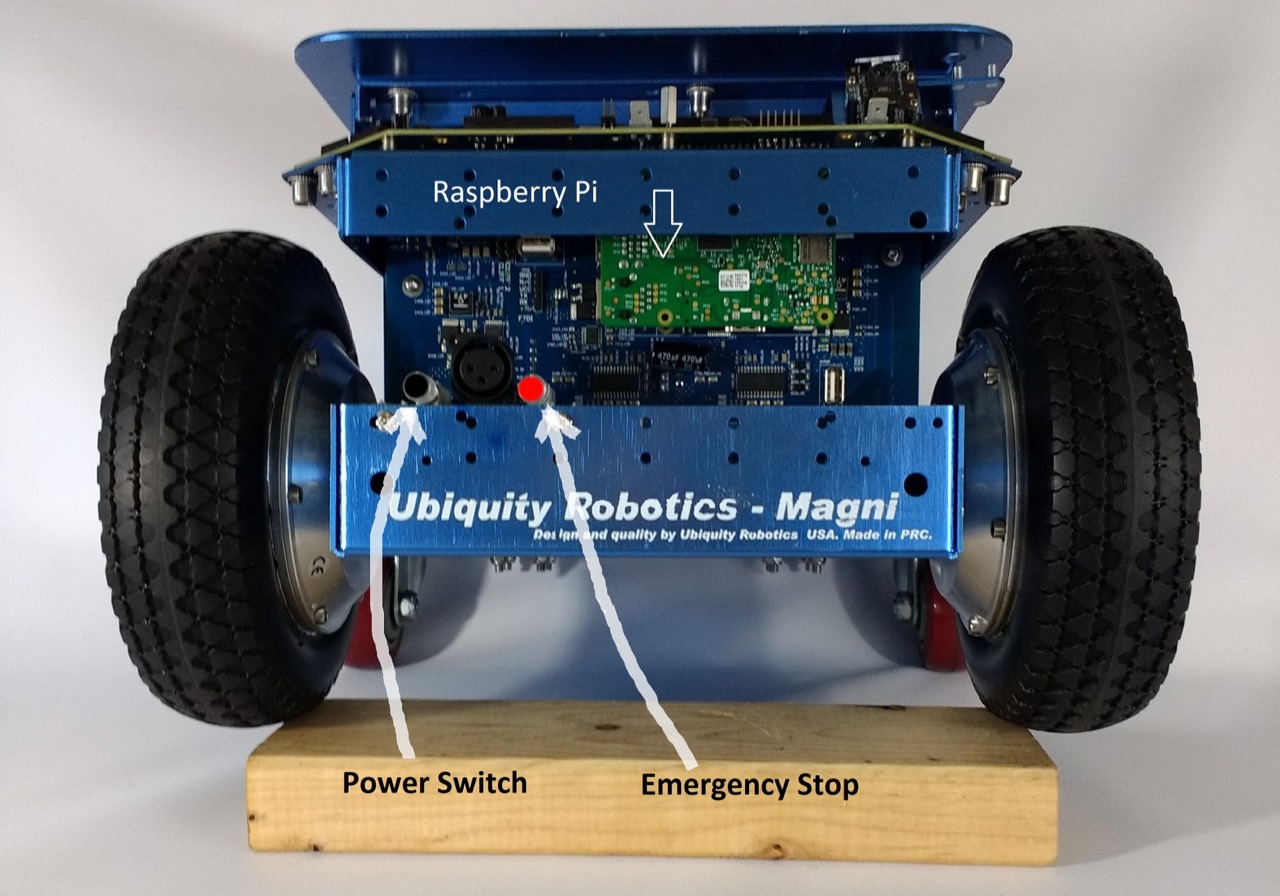
Mobile robot base with available ROS host software; the reviewed setup follows separately preserved Noetic sources, with unreleased controller firmware and revision-specific hardware constraints.
Wheeled robots & hardware
ROSbot 2R mobile platform with separately versioned ROS packages and CORE2 microcontroller firmware; this entry distinguishes the 2R configuration from newer ROSbot hardware.
Wheeled robots & hardware
Python RC-car platform for manual driving and optional learned control; reviewed Raspberry Pi/PCA9685 build guidance has OS-version conflicts and an incomplete parts budget.
Wheeled robots & hardware
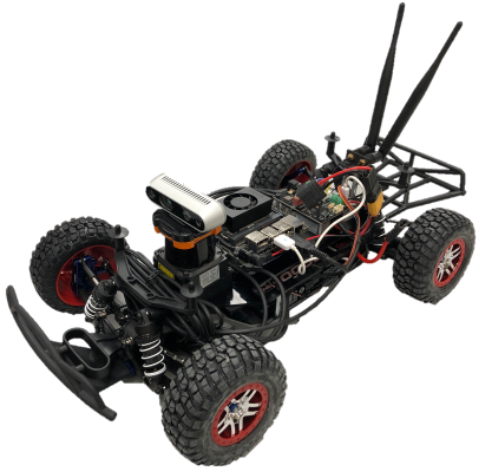
Ackermann-steered racing research platform; the preserved Xavier NX/Slash guide differs from its newer Orin Nano Super/Fiesta parts list and requires configuration-specific calibration.
Wheeled robots & hardware
Configurable ROS 2 mobile-robot stack; this profile selects a two-wheel differential-drive, ESP32 control route with separately versioned firmware and measured chassis parameters.
Wheeled robots & hardware
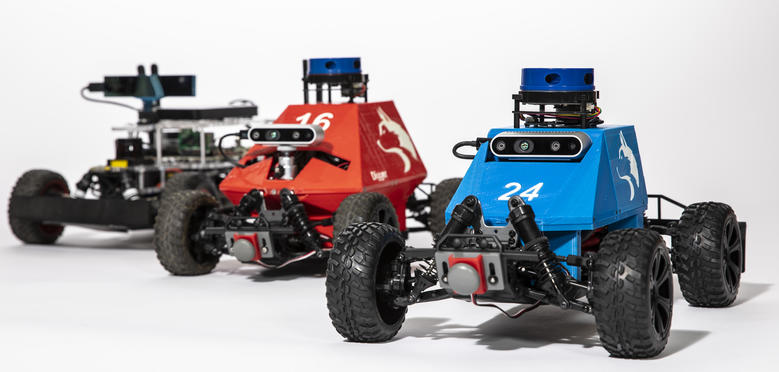
RC-based research racecar; the reviewed Nano route uses V3 printed parts and separately versioned ROS control packages, with older firmware/image assumptions requiring validation.
Wheeled robots & hardware
Six-wheel printed rover with separately preserved build files and ROS software; the reviewed default software uses ROS Melodic and requires per-robot calibration.
Wheeled robots & hardware
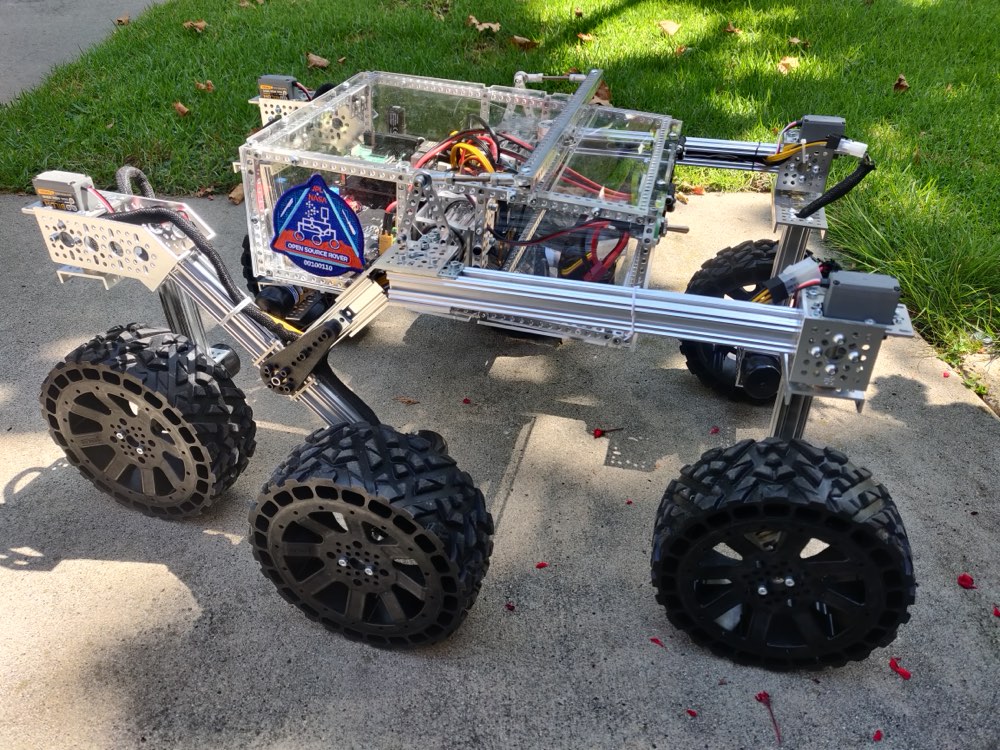
Six-wheel rocker-bogie rover with off-the-shelf mechanical parts and separate ROS control software; reviewed hardware and software snapshots need version and calibration reconciliation.
Wheeled robots & hardware
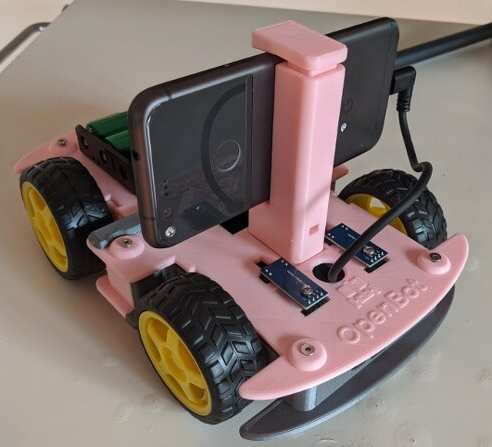
Smartphone-controlled wheeled robot platform; the reviewed DIY configuration combines an Arduino Nano and L298N driver, with phone and firmware requirements distinct from the advertised body cost.
Wheeled robots & hardware
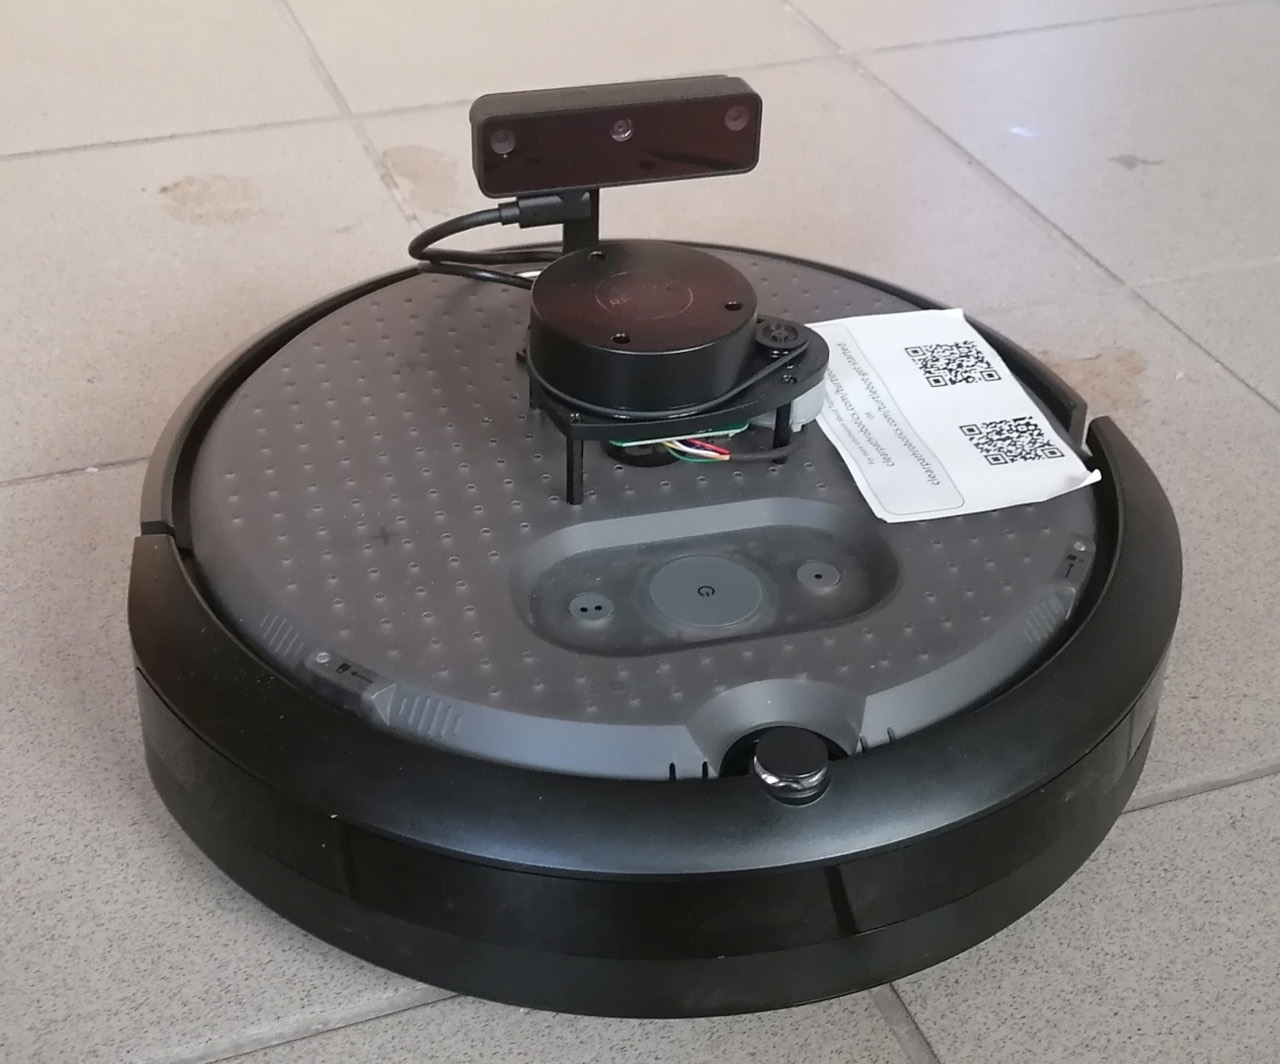
ROS 2 mobile research platform on an iRobot Create 3 base, with distinct Standard/Lite sensor packages and distribution-specific base-firmware requirements.
Legged robots & hardware
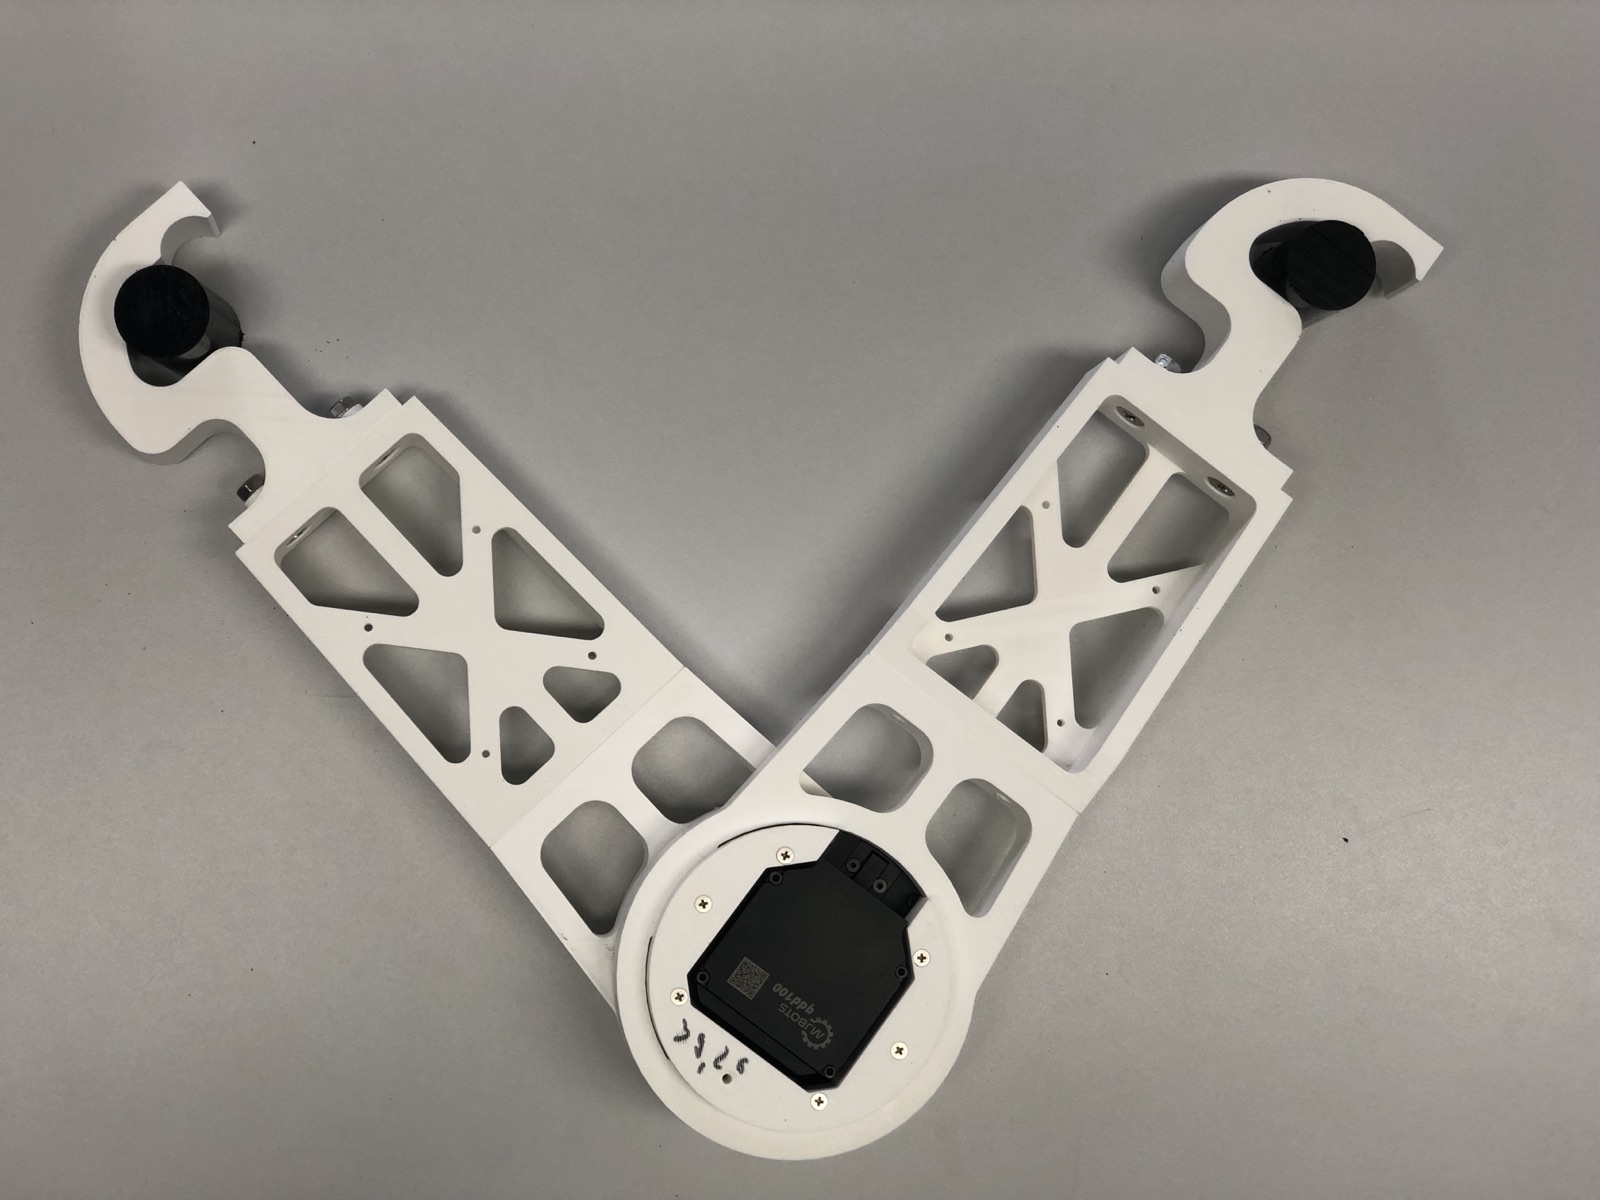
Underactuated bar-swinging research robot with one QDD actuator, passive hooks and simulation/control sources; requires a ladder test rig, and the reviewed hardware script conflicts with its guide.
Legged robots & hardware
Twelve-servo Raspberry Pi/Arduino quadruped with downloadable CAD and Python gait code; hardware is noncommercial source-available and manual calibration is required.
Printed quadruped with three joints per leg.
Twelve-servo printed quadruped prototype with CAD, PCB files and ROS control sources; calibration, gait refinement and build instructions remain incomplete.
Wheeled robots & hardware
Reaction-wheel unicycle research platform, scoped to v2.5 CAD and firmware with a documented state-estimation error and historical development tools.
Legged robots & hardware
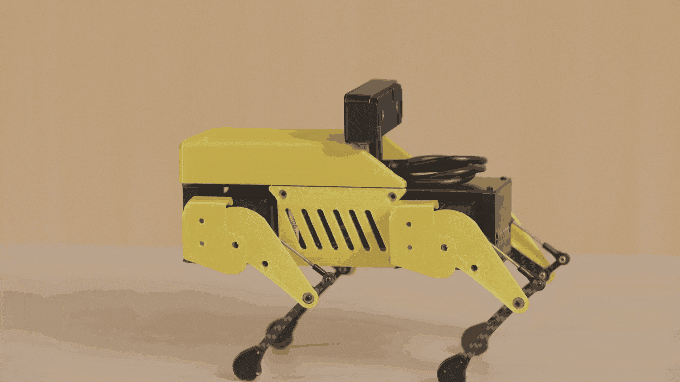
Original Mini Pupper quadruped with twelve custom servos, Raspberry Pi hardware and separate movement/ROS stacks; hardware generation, image and calibration route must be matched.
Legged robots & hardware
Quadruped source collection with distinct A1 and A2 configurations, printable structural parts, C++ control and browser-based simulation; this review centers on the documented A1 operating configuration.
Legged robots & hardware
Nybble/Bittle robot-family entry centered on OpenCat 1.2.5 NyBoard firmware, calibration and host tools; software openness does not establish complete frame or electronics manufacturing sources.
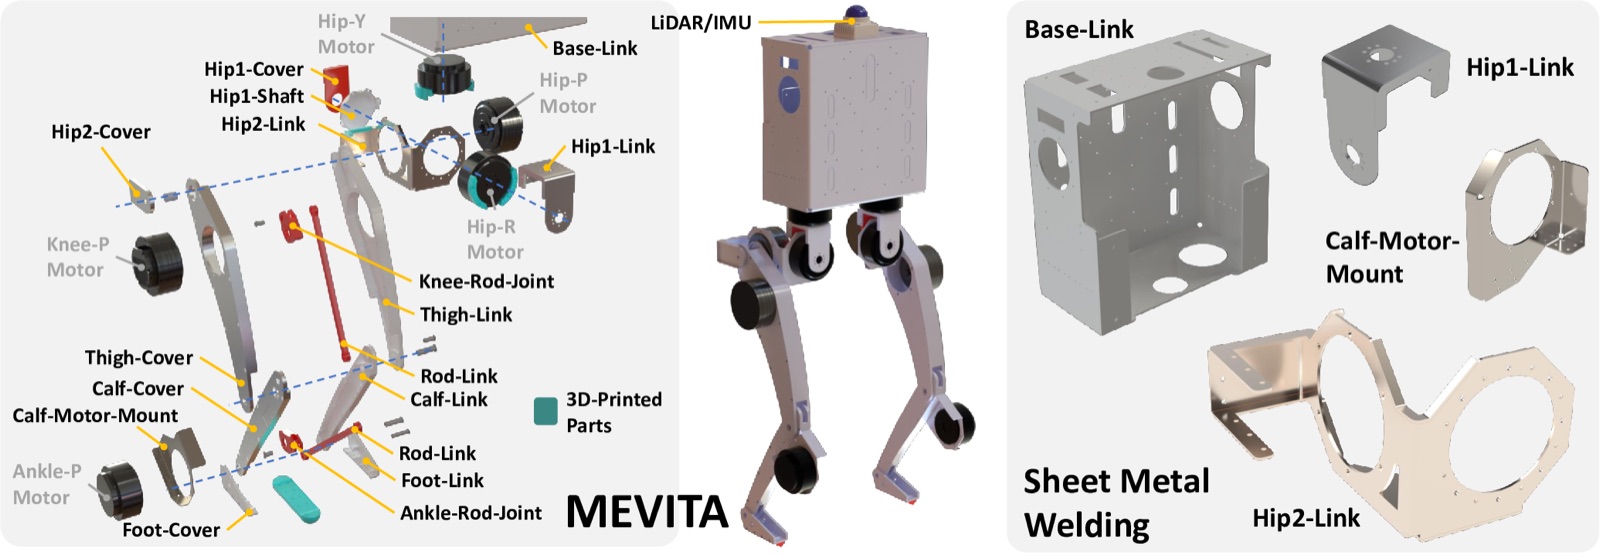
Biped with five controlled joints per leg.
Ten-joint biped with purchased actuators, machined and welded metal parts, and a ROS 1 learning-to-control workflow; external hardware rights and build completeness need separate checks.
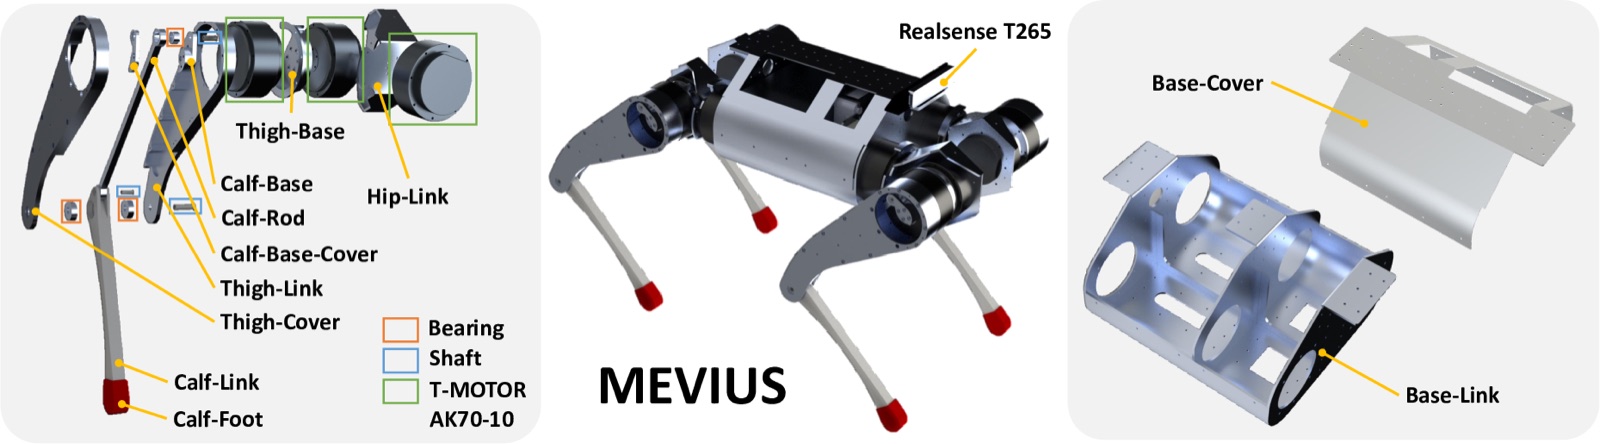
Legged robots & hardware
Twelve-joint quadruped with purchased actuators and fabricated metal parts; its preserved ROS 1 control snapshot warns that the supplied policy is not very stable.
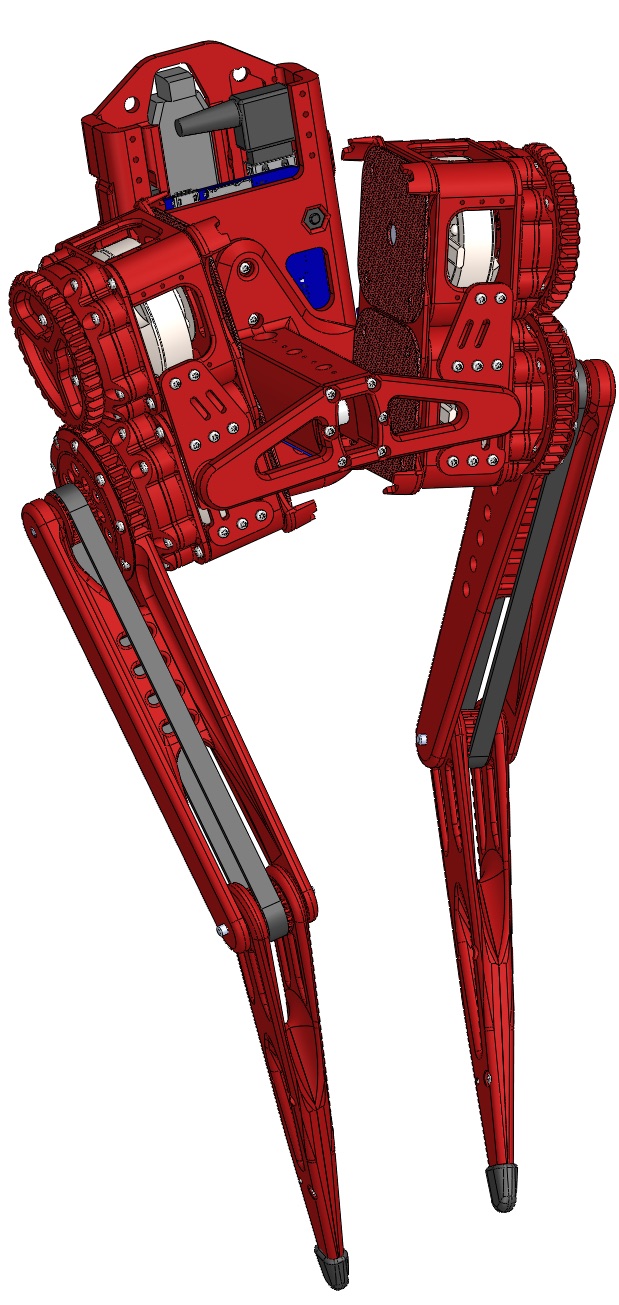
Desktop biped with two three-axis legs.
Printed desktop biped with four custom torque actuators, two positioning servos and a shared Python simulation/hardware interface; controller-source licensing remains unresolved.
Humanoids
Humanoid design and one-leg benchmark exploring low leg inertia through belts and parallel linkages; the maintainer has put the project on hold.
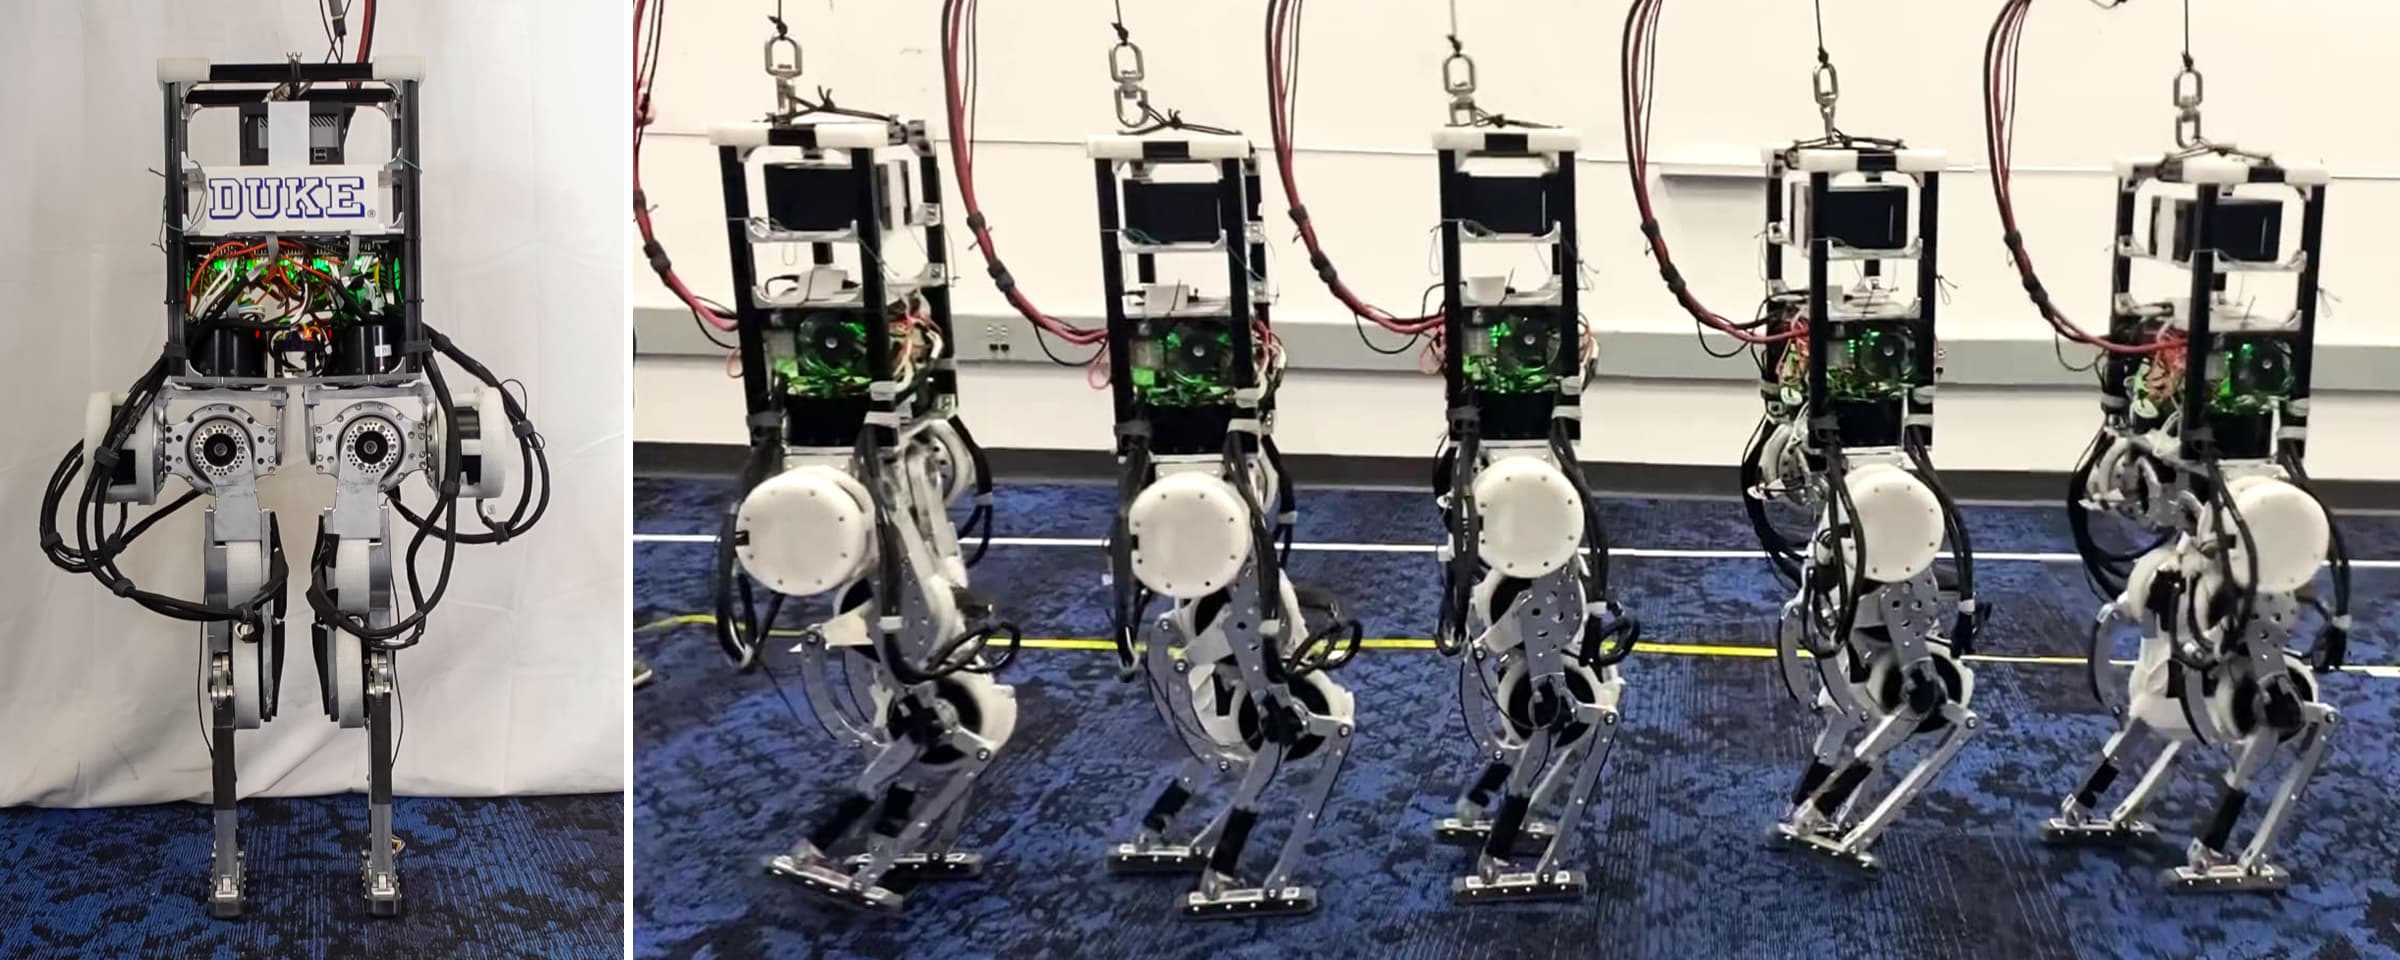
Humanoids
Ten-degree-of-freedom research biped with machined aluminum parts, EtherCAT motor control and learned locomotion; artifact and dependency licenses need separate checks.
Humanoids
Printable humanoid with FreeCAD sources, a Servo 2040 control route and MuJoCo examples; power selection and several servo mappings remain unresolved.
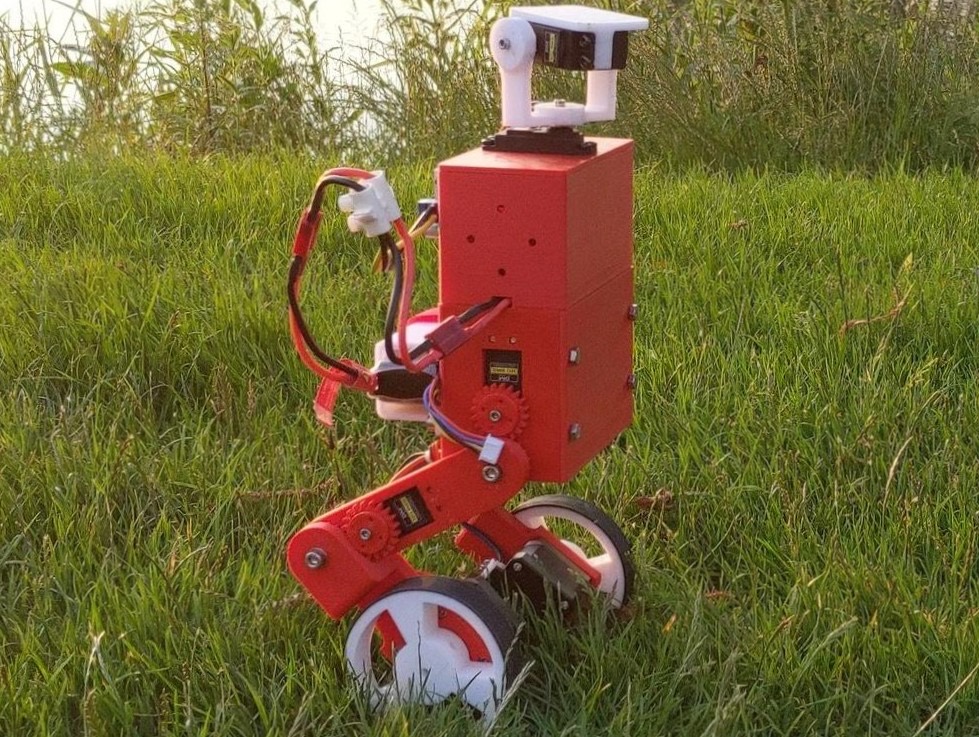
Legged robots & hardware
Wheeled balancing robot with articulated servo legs, Arduino balance firmware and Raspberry Pi inverse-kinematics examples; electronics and controller integration remain incomplete.
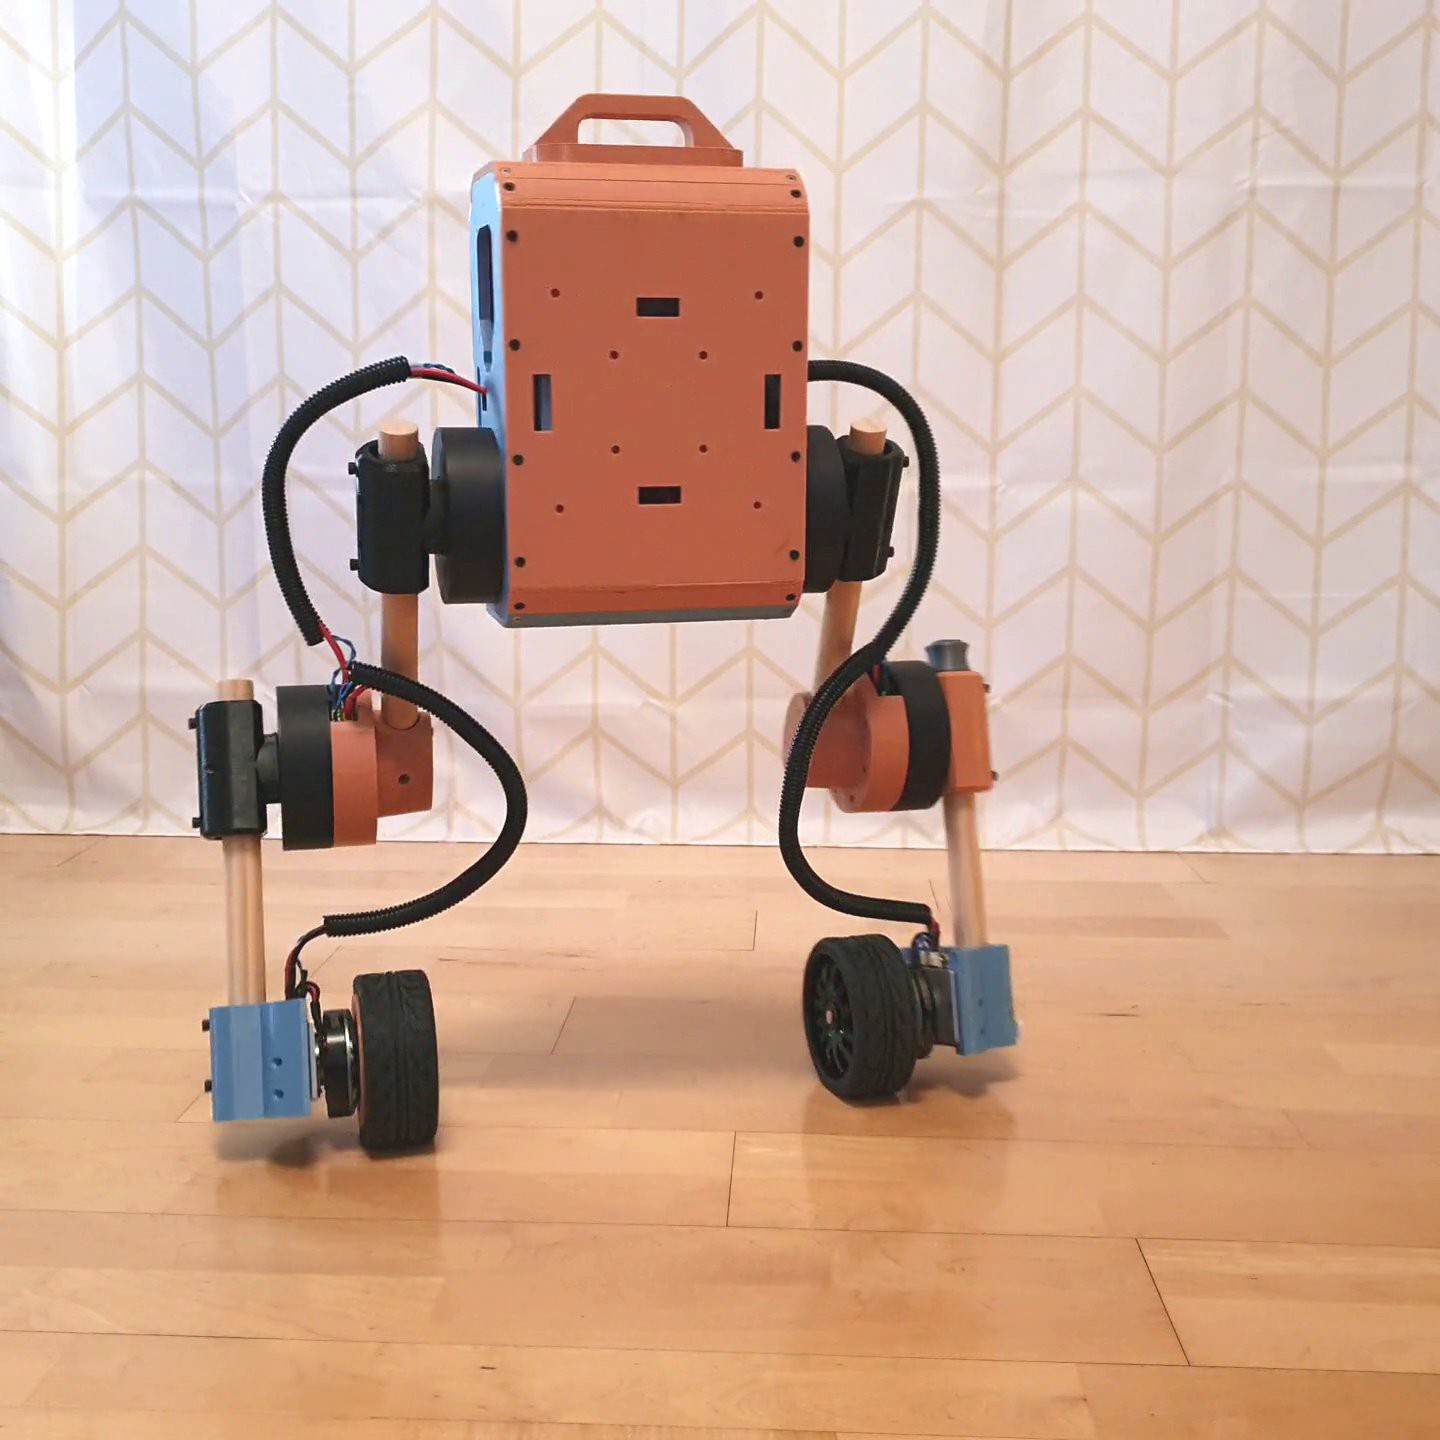
Legged robots & hardware
Wheeled biped with four leg servos, two driven wheels and a Raspberry Pi control stack; the reviewed build guide needs revision matching.
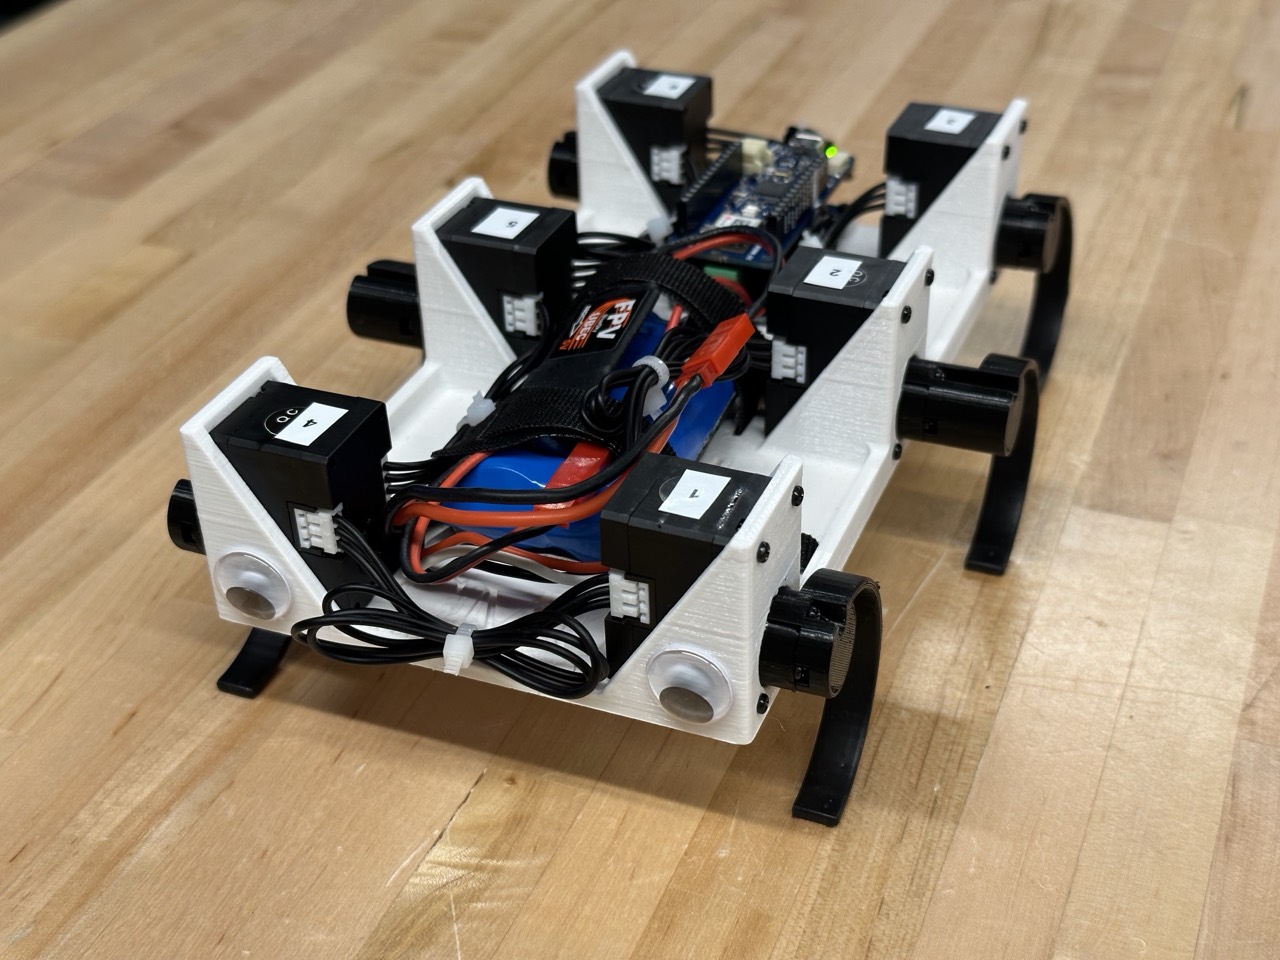
Six-legged walking robot
A six-legged educational robot with printable chassis and legs, Dynamixel motors and Arduino control.
About USD 286.51 upstream estimate
Two leader arms and two follower arms
A four-arm bimanual teleoperation and demonstration-recording system with a separate learning stack.
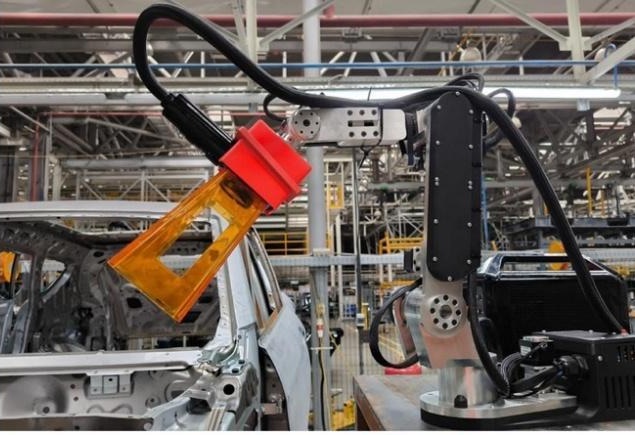
Six-axis articulated arm
A six-axis workshop arm with printed or aluminum structure; this review covers MK3 and its matching 6.3-series controls.
Biped humanoid
A 1.2 m humanoid design with separate media and motion computers, fabricated metal/nylon structure and an unfinished locomotion-policy release.
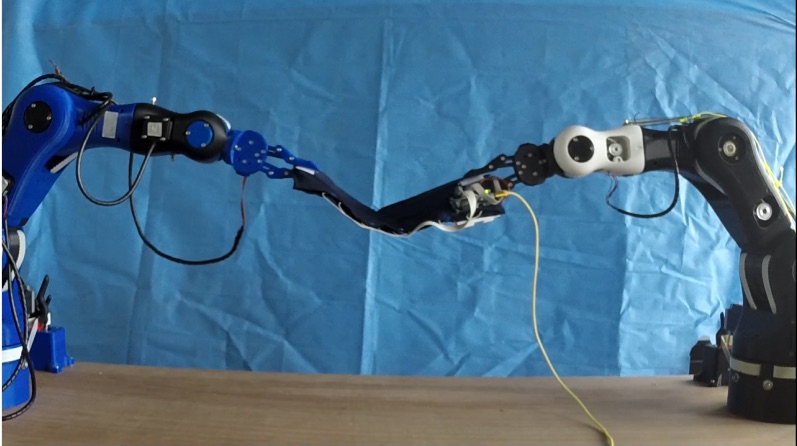
Printed articulated arm
A printed educational robot arm with CAD, firmware, BOM and assembly documents in one source repository.
Printed-gearbox humanoid
A humanoid built around printed gearboxes, with separate simulation assets and low-level control code that requires joint calibration after power cycles.
From USD 3,349.90 Known US parts subtotal · Oct 4, 2026
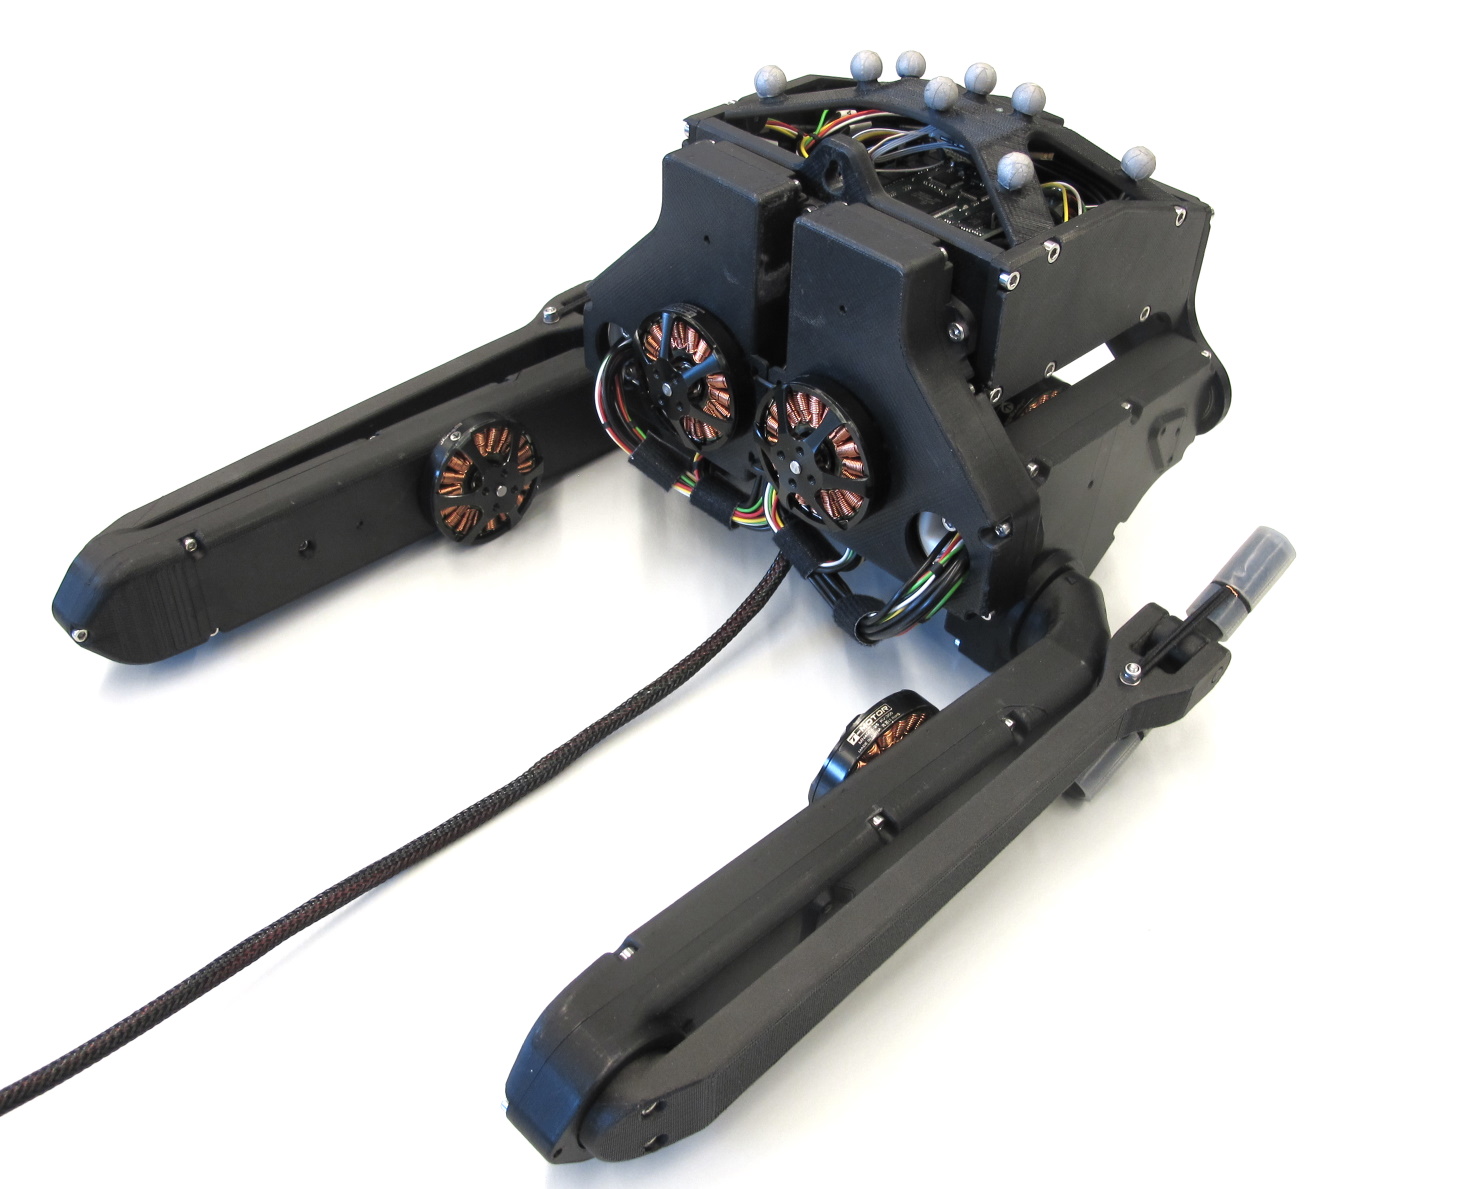
Legged robots & hardware
A six-actuator research biped with passive ankles, tethered power/data and no active yaw control.
Compact articulated arm
A compact custom arm combining CNC parts, harmonic reducers and custom motor-control electronics.
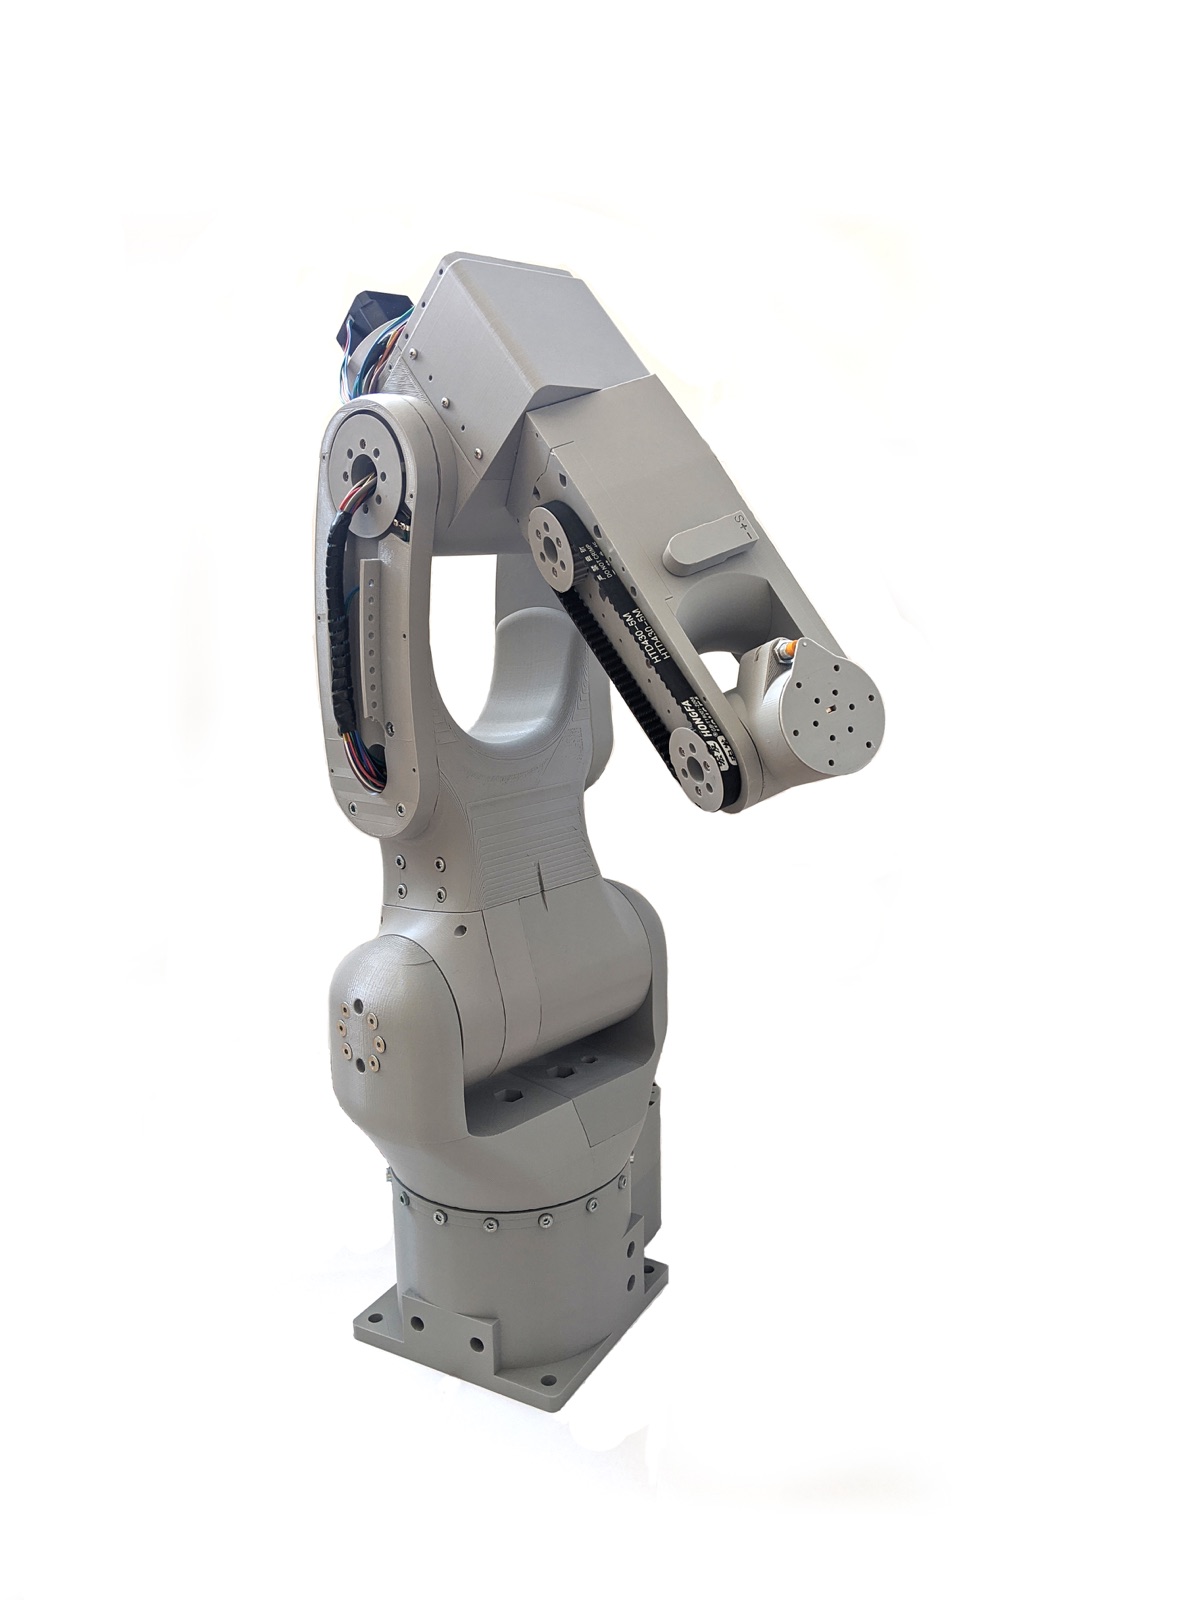
Desktop articulated arm
A six-axis printed arm built around cycloidal gearboxes, with separate mechanical and control documentation.
Humanoids
A humanoid development project with a separate arm-and-exoskeleton branch of work for LeRobot teleoperation.
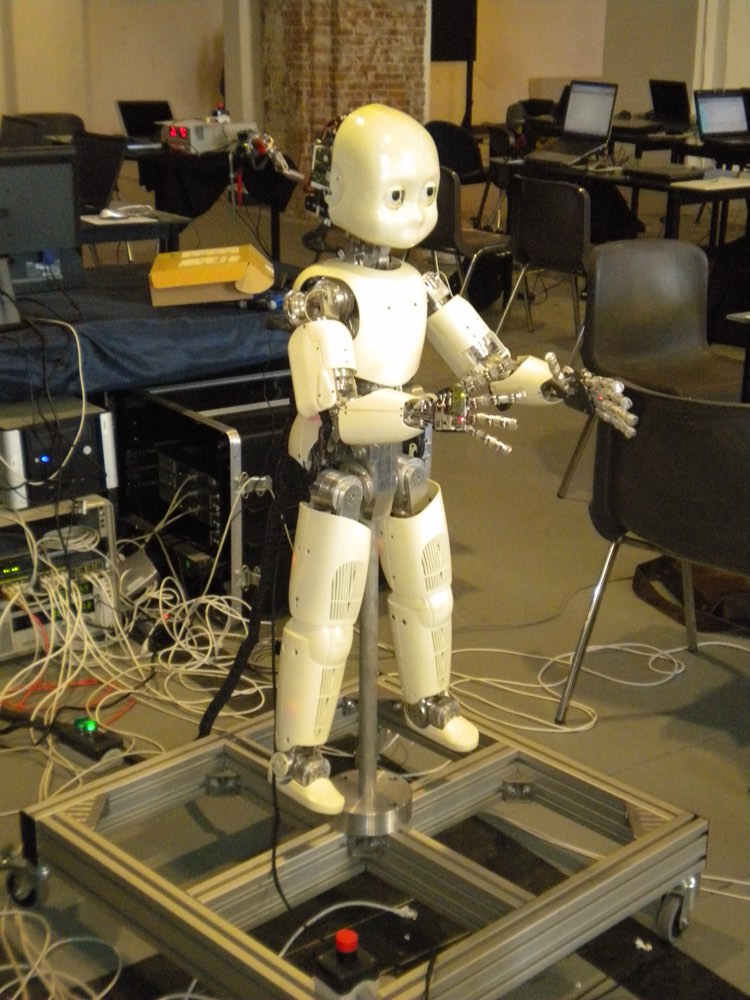
Humanoids
A research humanoid family whose hardware revisions, robot configuration and software distribution must be matched before reproduction.
Humanoids
A humanoid soccer research platform with a released load-bearing plastic body design and a separately maintained ROS framework.
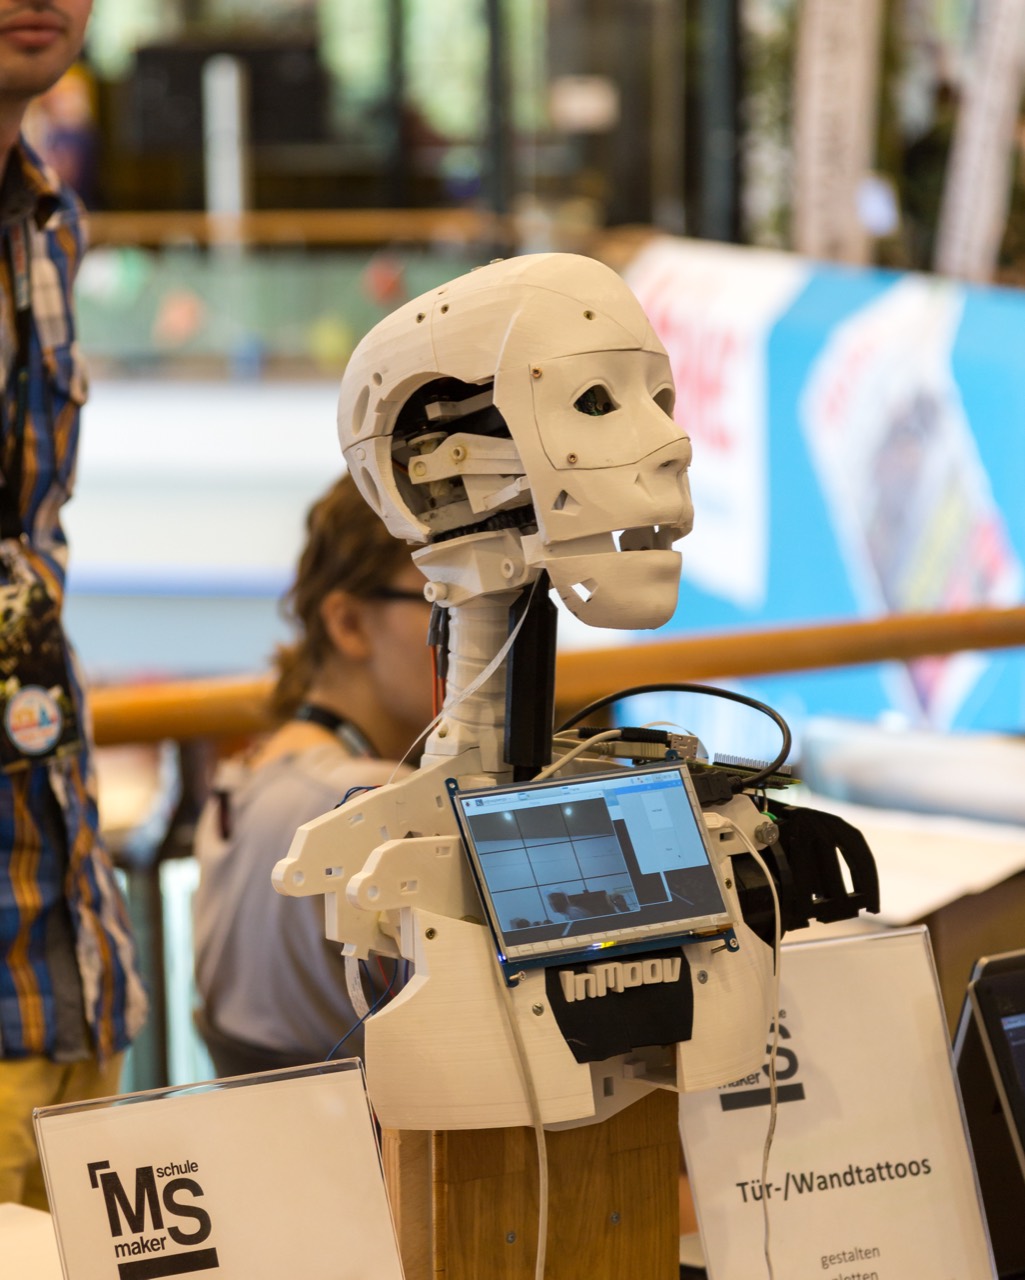
Humanoids
A modular printable humanoid with body-section tutorials, tendon-driven hands and a separate MyRobotLab control route.
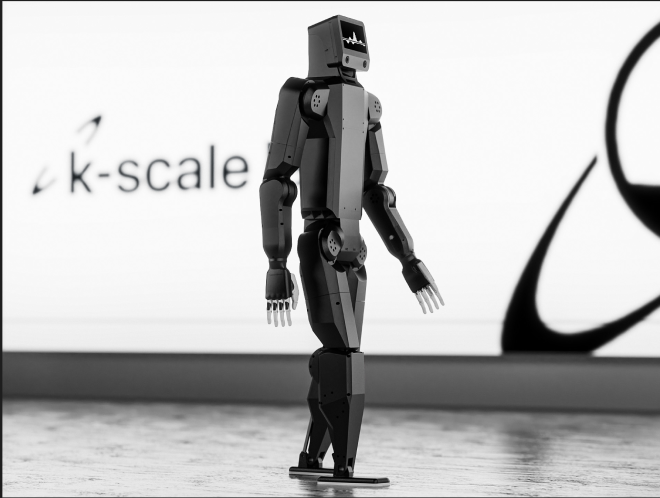
Modular humanoid
A public-alpha humanoid project whose CAD, operating system, simulation and inference code live in separate sources.
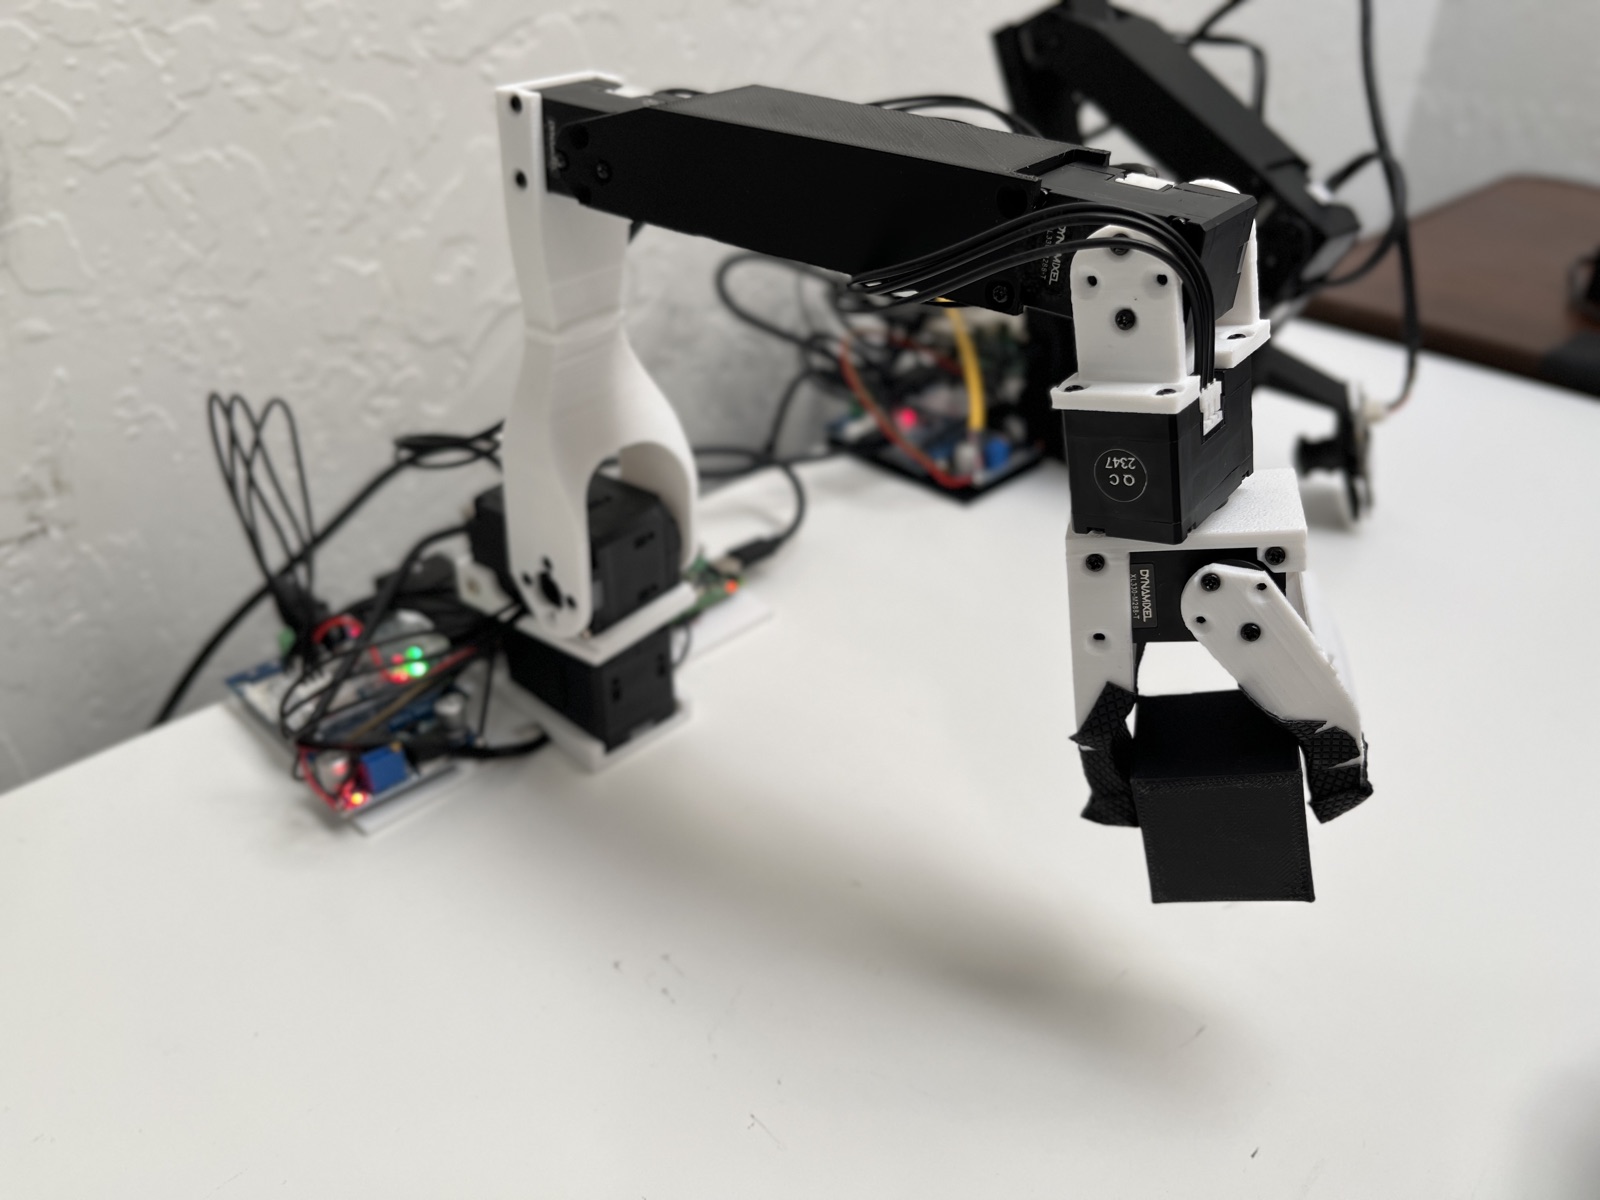
Desktop robot arm
A printable Dynamixel arm with a separate leader design for teleoperation and robot-learning experiments.
From USD 245.85 Known US parts subtotal · Oct 4, 2026
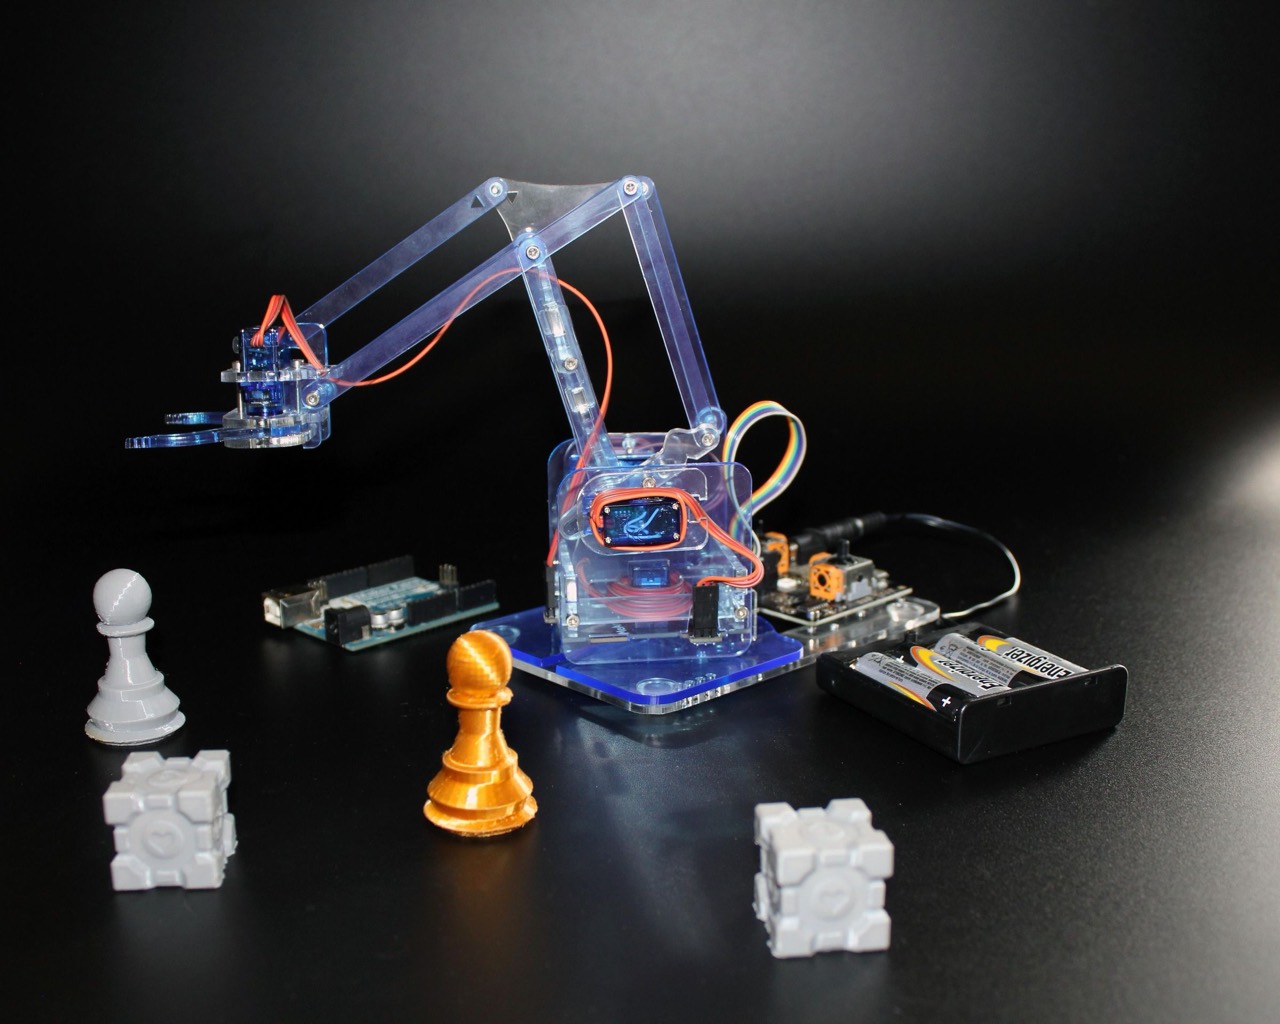
Laser-cut articulated arm
A four-degree-of-freedom educational arm made from versioned laser-cut parts.
Compact printed humanoid
A roughly 30 cm printed humanoid using 19 DYNAMIXEL servos, a Raspberry Pi Zero 2 W and a custom-fabricated robot HAT.
From USD 585.27 Known US parts subtotal · Oct 4, 2026
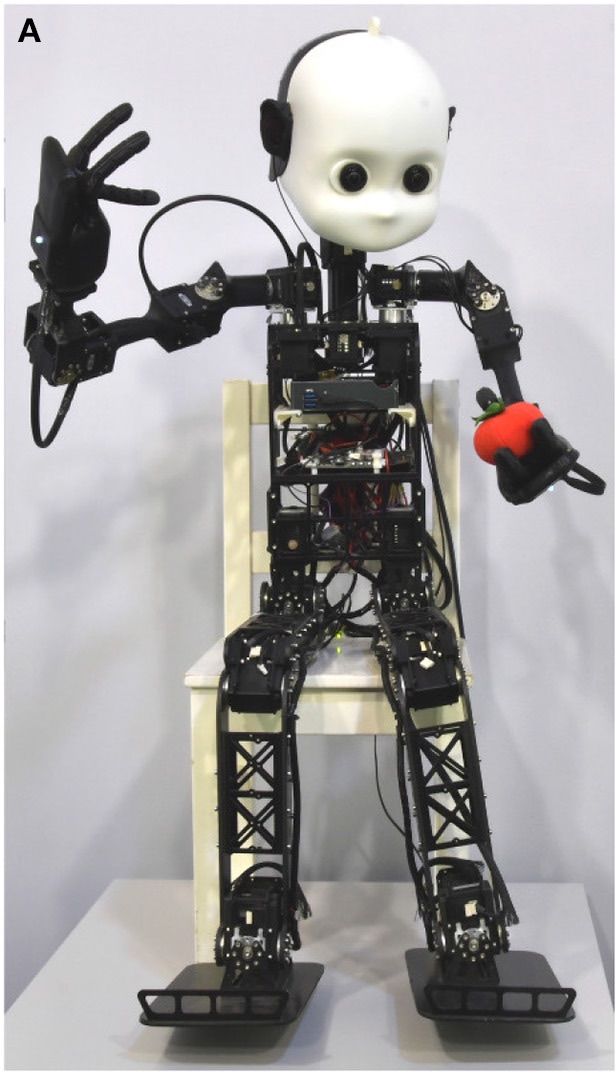
Humanoid interaction platform
A humanoid interaction research platform with distinct FDM and SLS-oriented mechanical designs and a separate software repository.
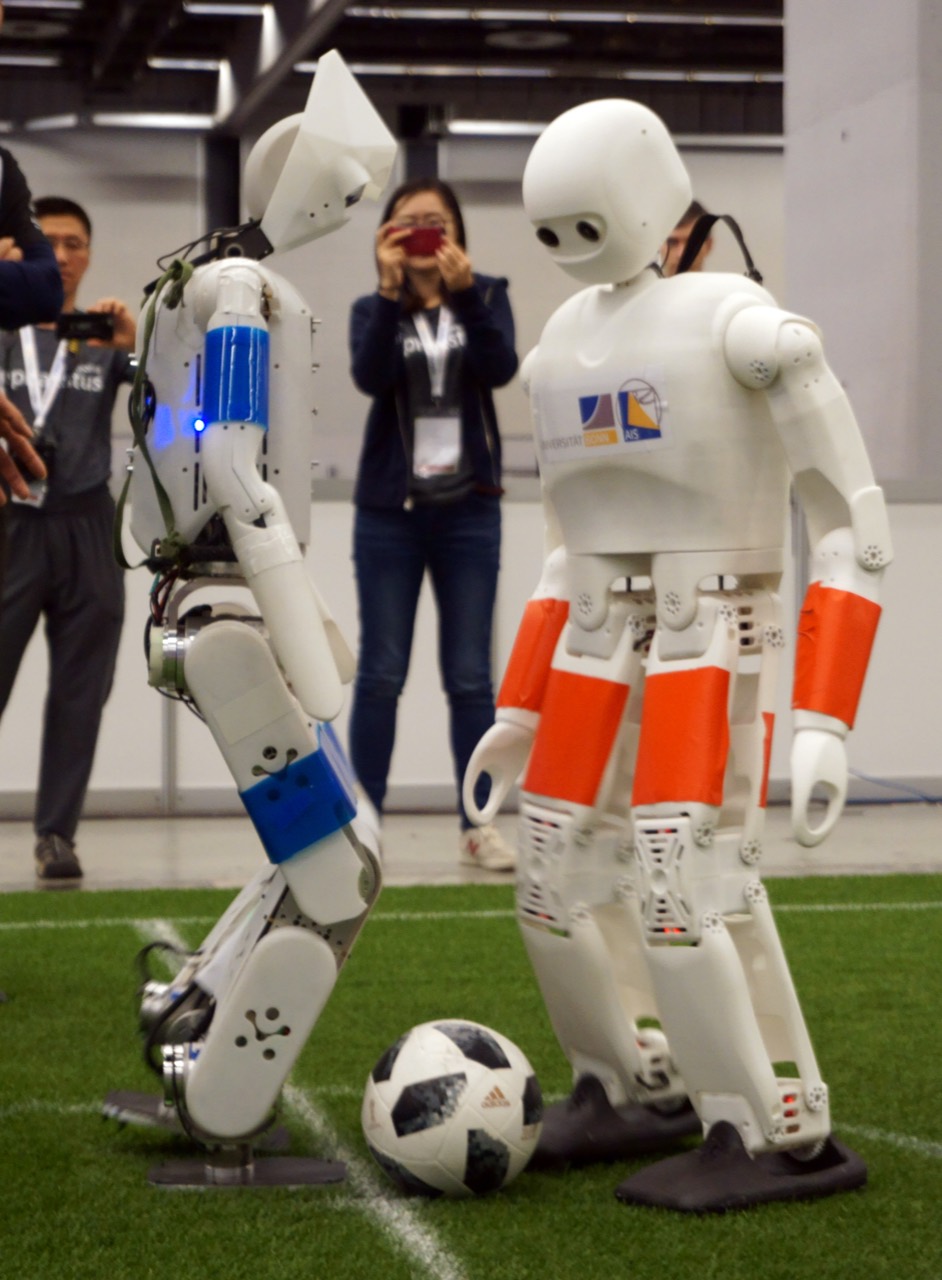
Humanoids
Two humanoid soccer research designs with separate CAD, actuator selections and fabrication requirements.
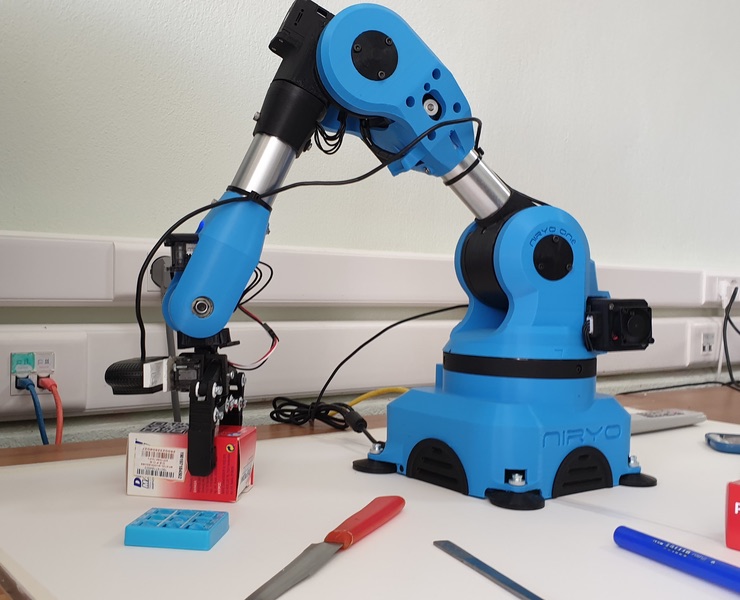
Printed articulated arm
Printable Niryo One arm designs with a separate ROS stack and a documented older-hardware archive.
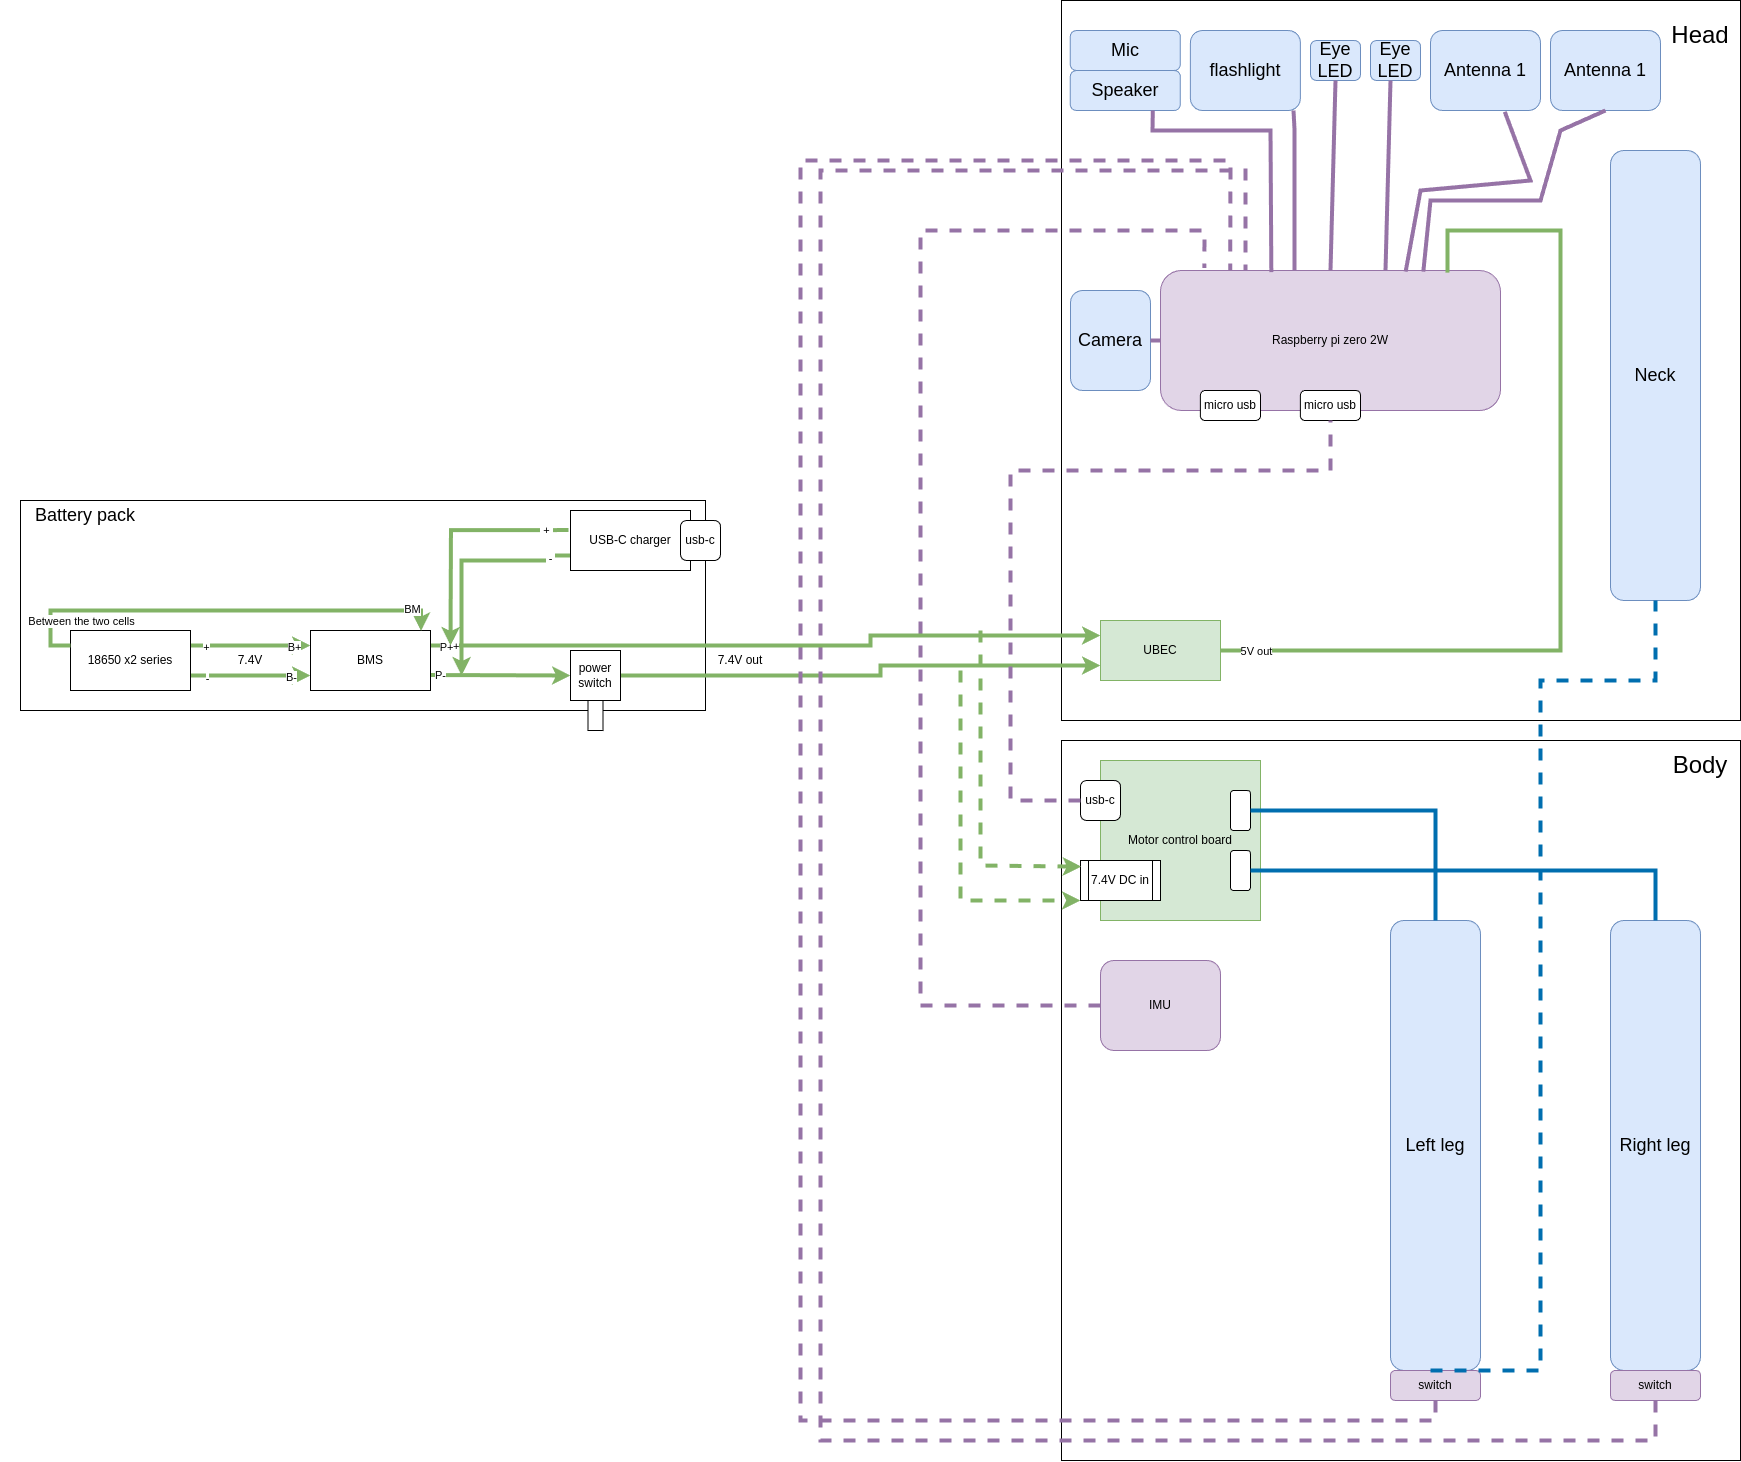
Legged robots & hardware
A small printed biped with bus servos, a Raspberry Pi runtime and learned walking policies; the reviewed v2 build still has documentation and configuration gaps.
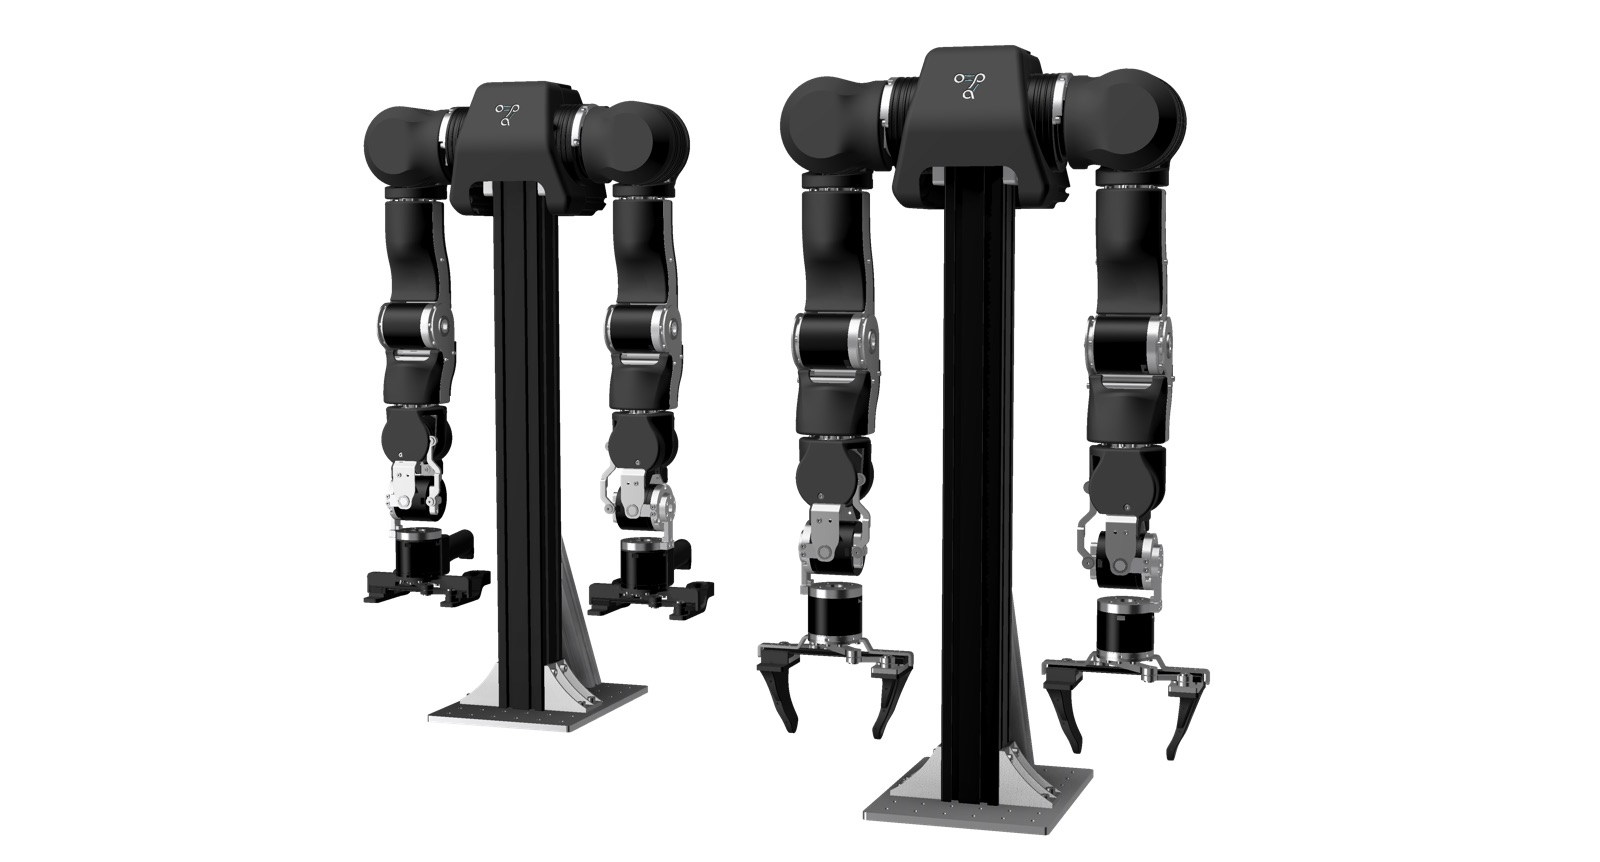
Articulated arm platform
An arm research platform whose hardware release separates the arm, evaluation cell and KER assemblies.
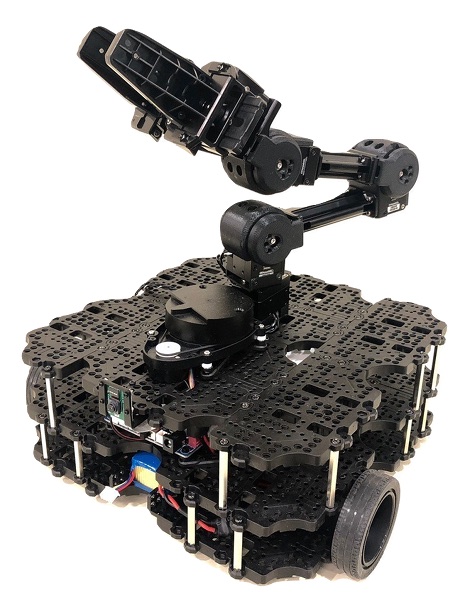
Four-joint arm with actuated gripper
A four-joint DYNAMIXEL arm with a separate gripper axis, documented for PC-based ROS control or standalone OpenCR operation.
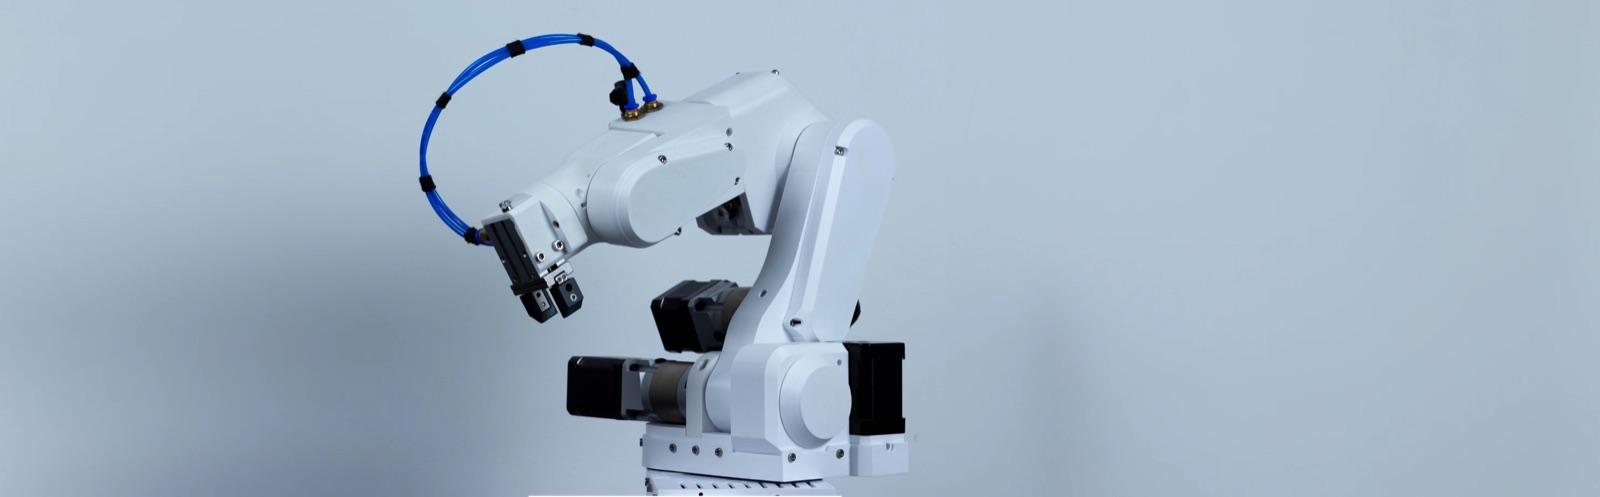
Printed desktop arm
A printed desktop arm with a separate Commander application and a required PAROL6 control board.
Humanoids
A printable humanoid whose #5 basic design replaces the #4 part set and uses Raspberry Pi 5 compute.
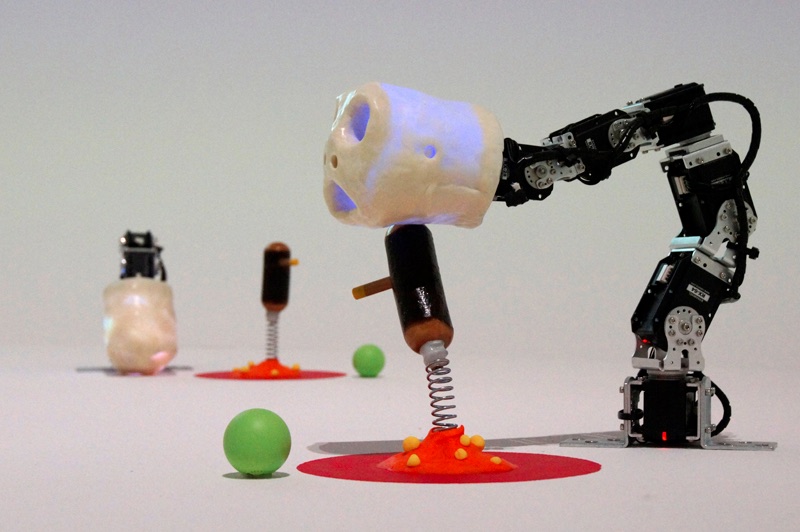
Six-axis articulated arm
A six-axis research arm using Dynamixel MX-28 motors and Python control.
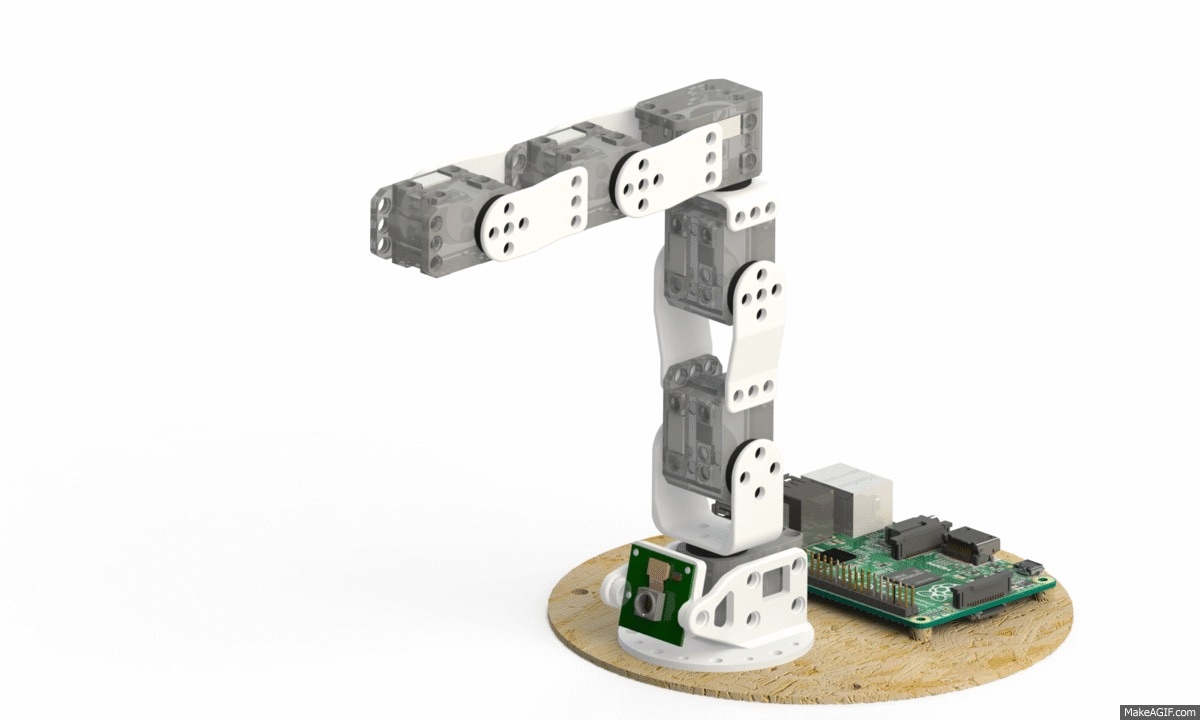
Six-axis educational arm
A six-axis educational arm using printable parts, Dynamixel XL-320 servos and Raspberry Pi control.
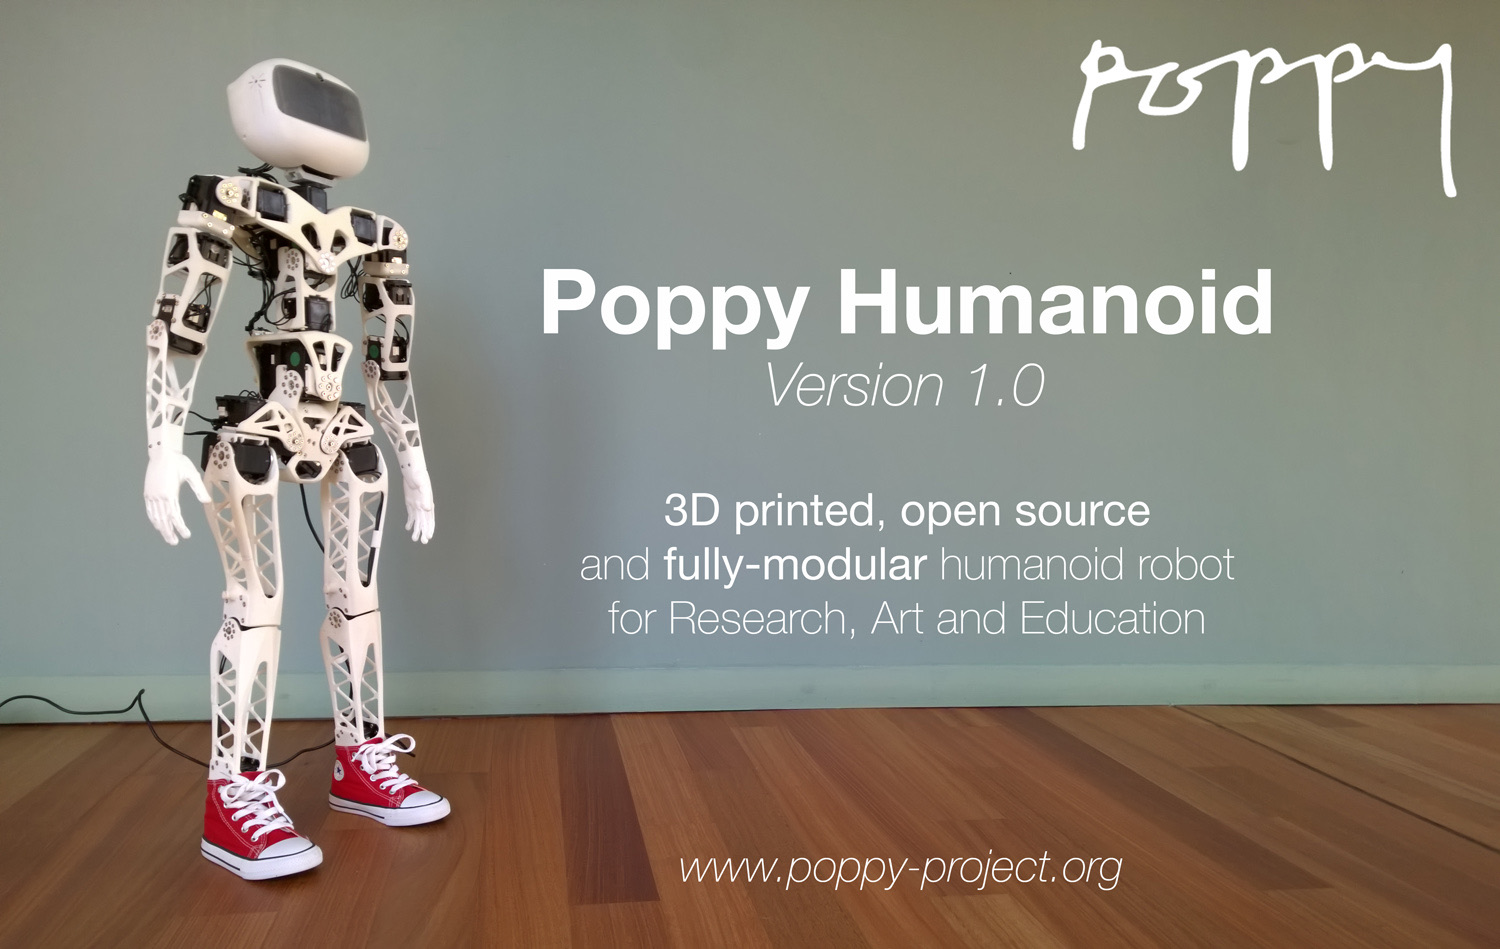
Printed humanoid
A printed research humanoid using 25 Dynamixel actuators and a documented legacy Odroid setup.
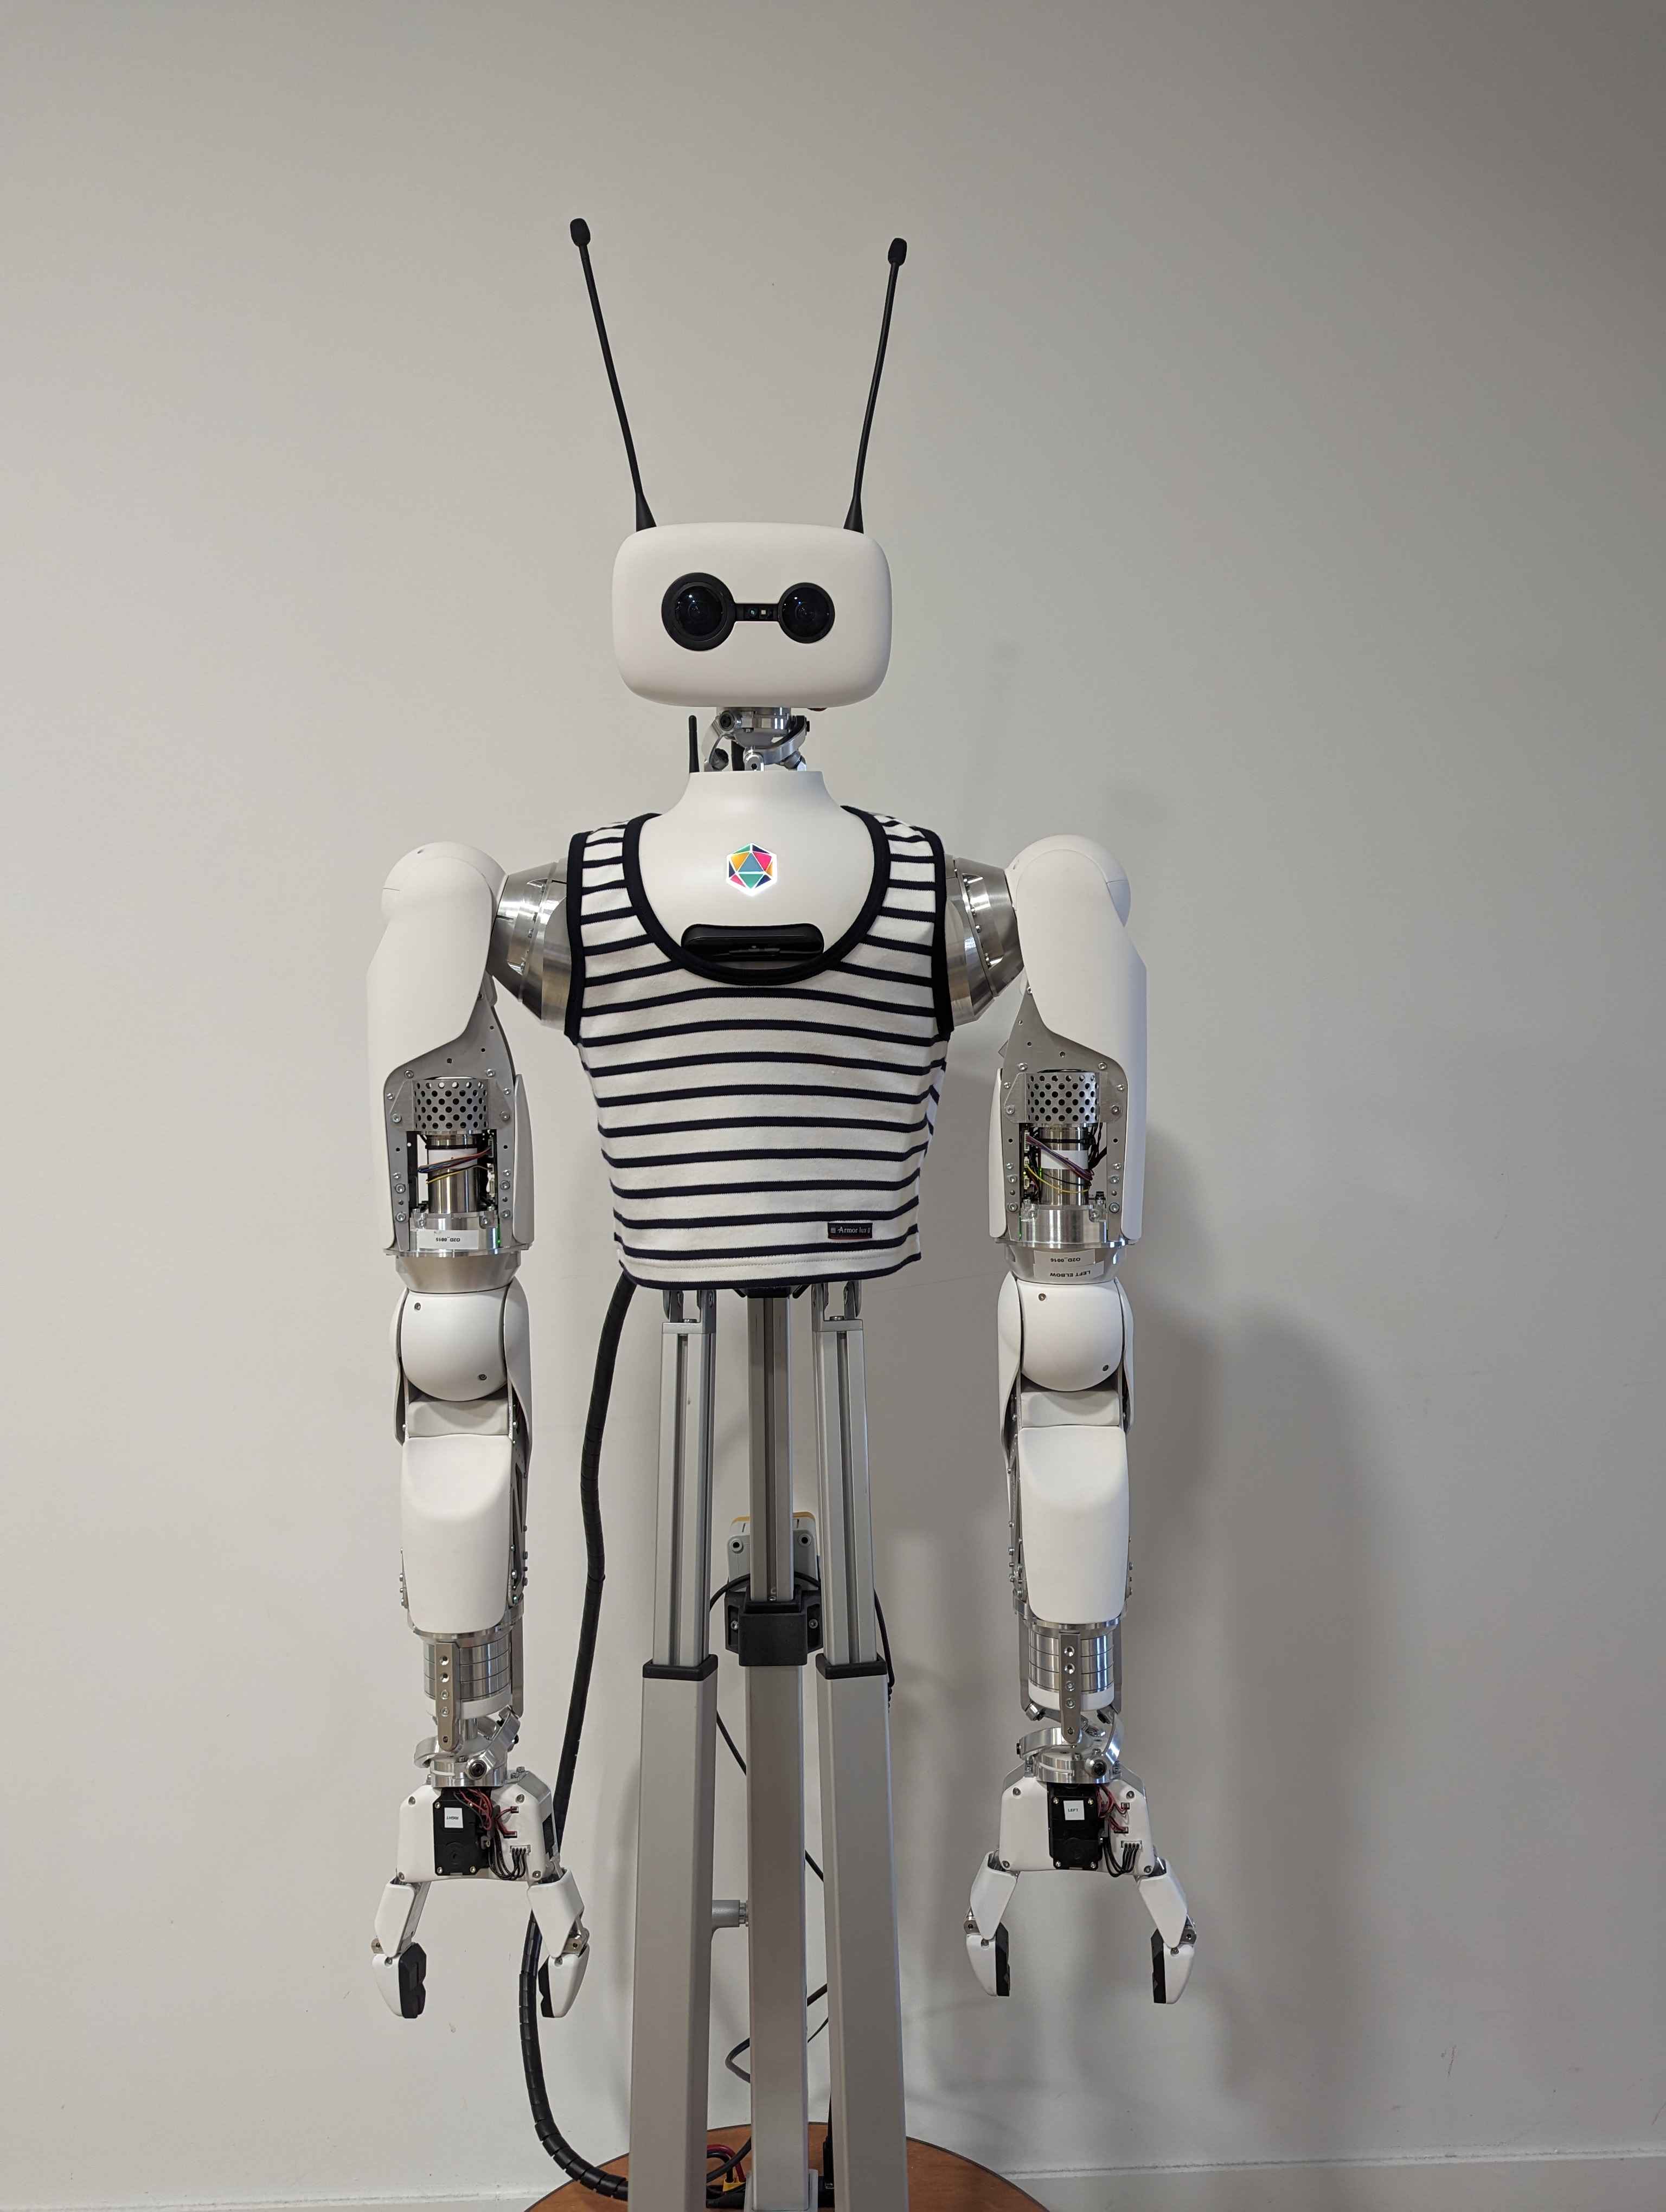
Humanoid platform
A Reachy 2 ROS 2 workspace providing robot descriptions, control interfaces and simulation launch components.
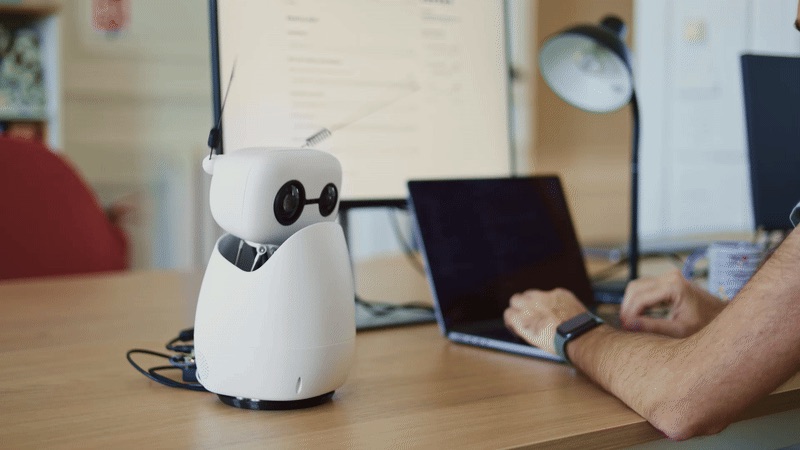
Expressive desktop robot
An expressive desktop robot with separate Wireless, USB-connected Lite and simulation setup routes.
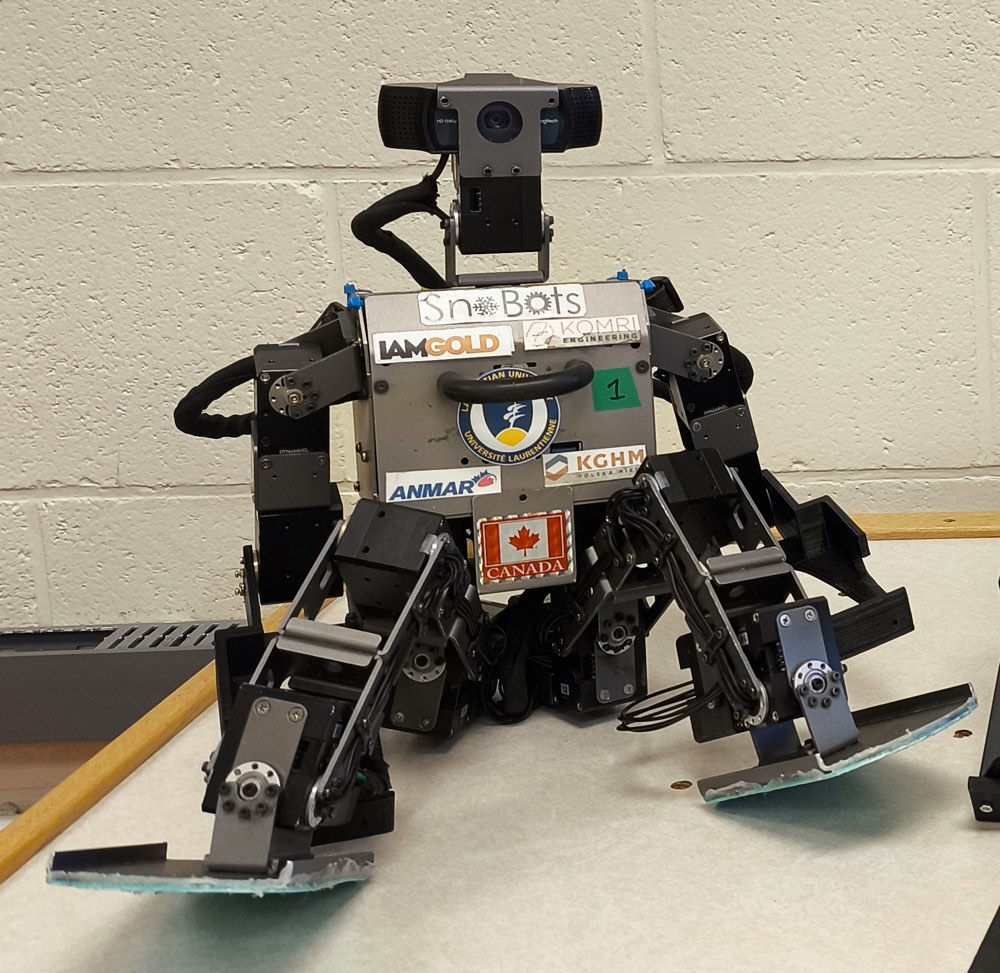
Biped humanoid
A 20-joint research humanoid with a 2025 ROS 2 revision and an older ROS 1 software lineage that must be kept distinct.
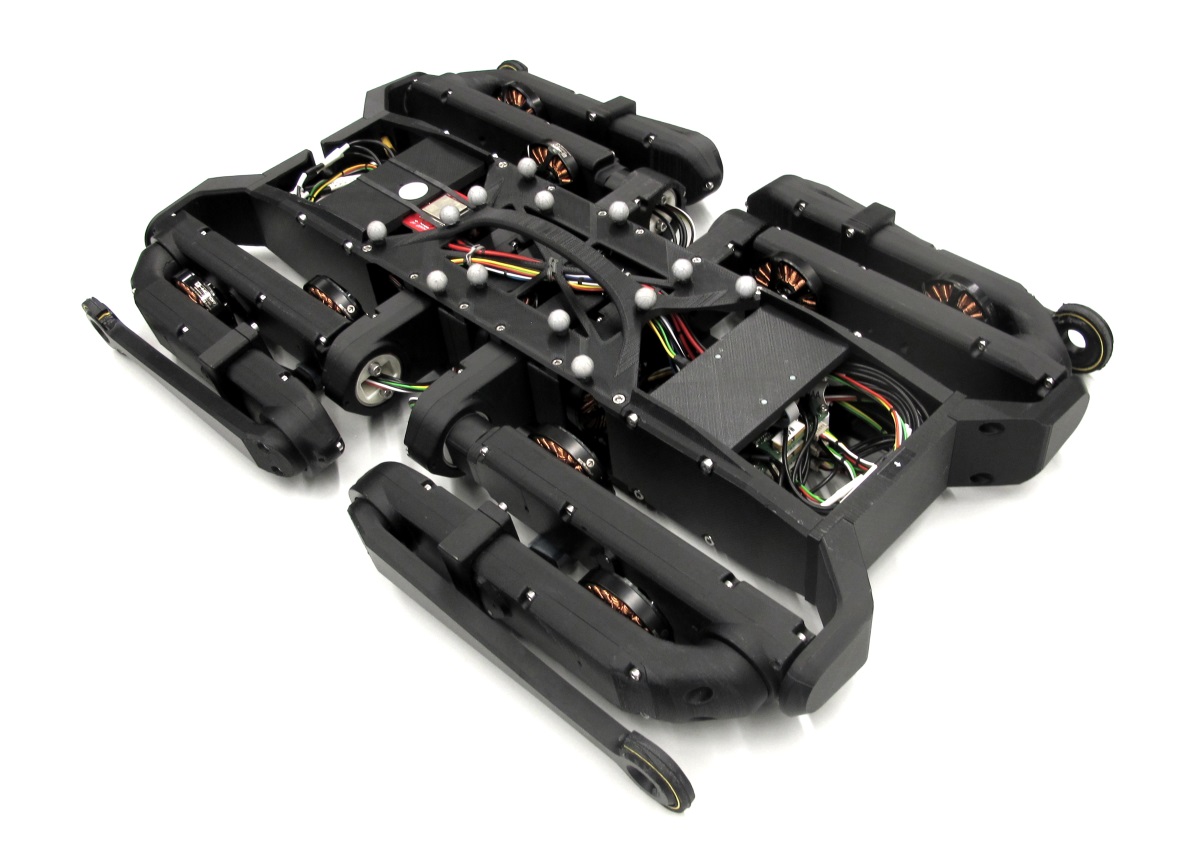
Legged robots & hardware
A modular torque-controlled quadruped family; this review distinguishes wired Solo12 from its battery-and-wireless upgrade.
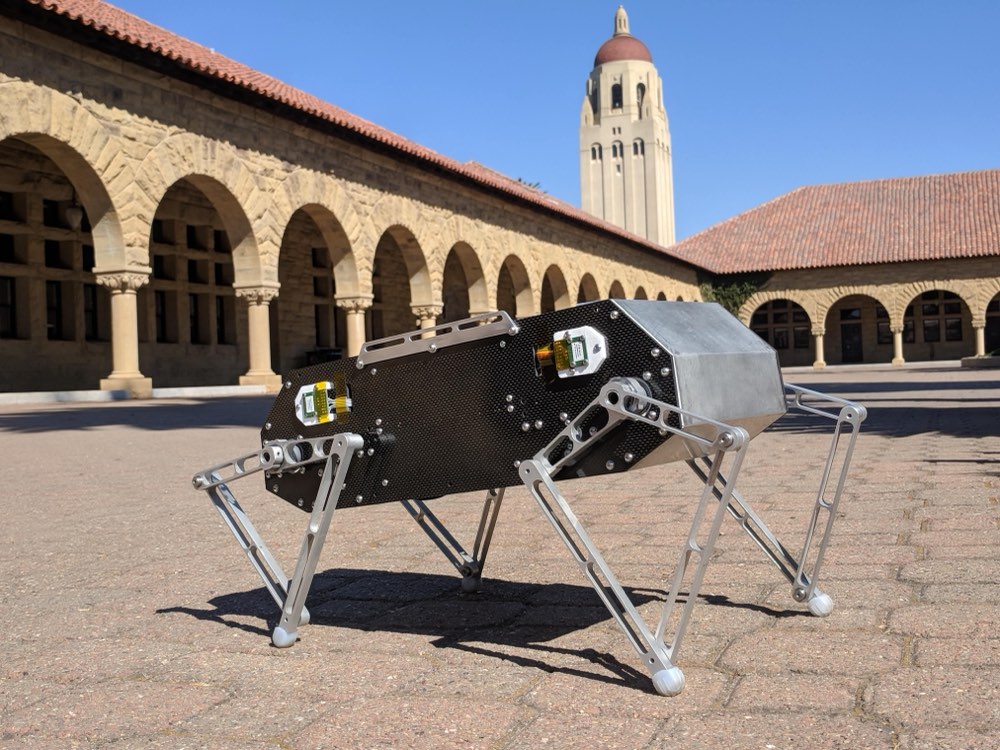
Legged robots & hardware
A historical eight-actuator quadruped using coaxial leg mechanisms, Teensy control and customized ODrive firmware.
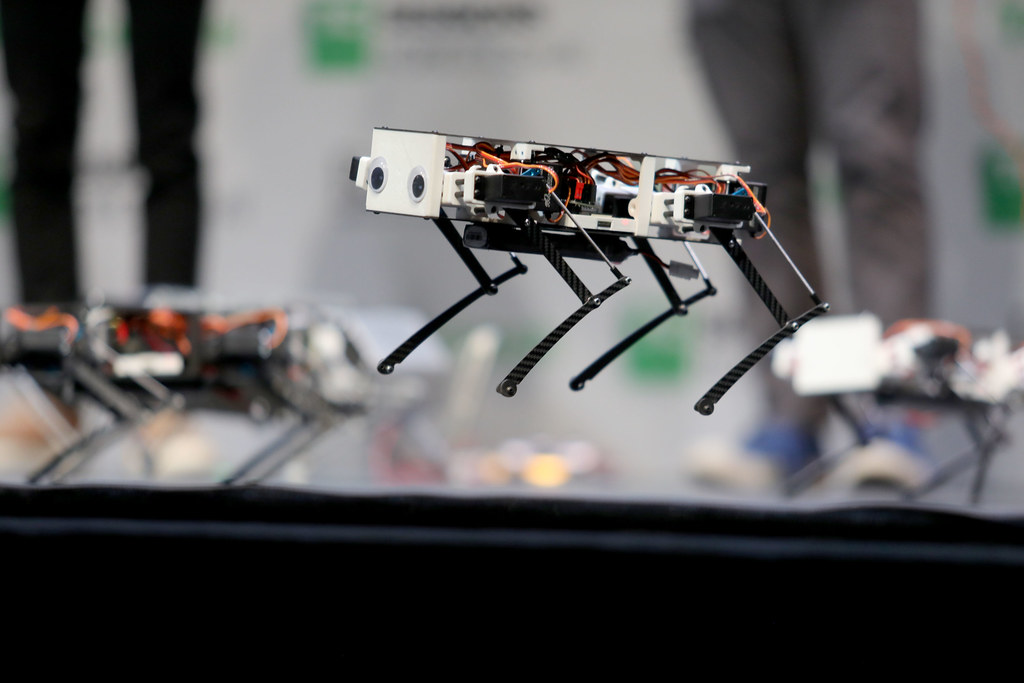
Original Pupper v1 servo-driven quadruped
The original servo-driven Stanford Pupper, a Raspberry Pi quadruped whose upstream support has ended in favor of a separate v3 design.
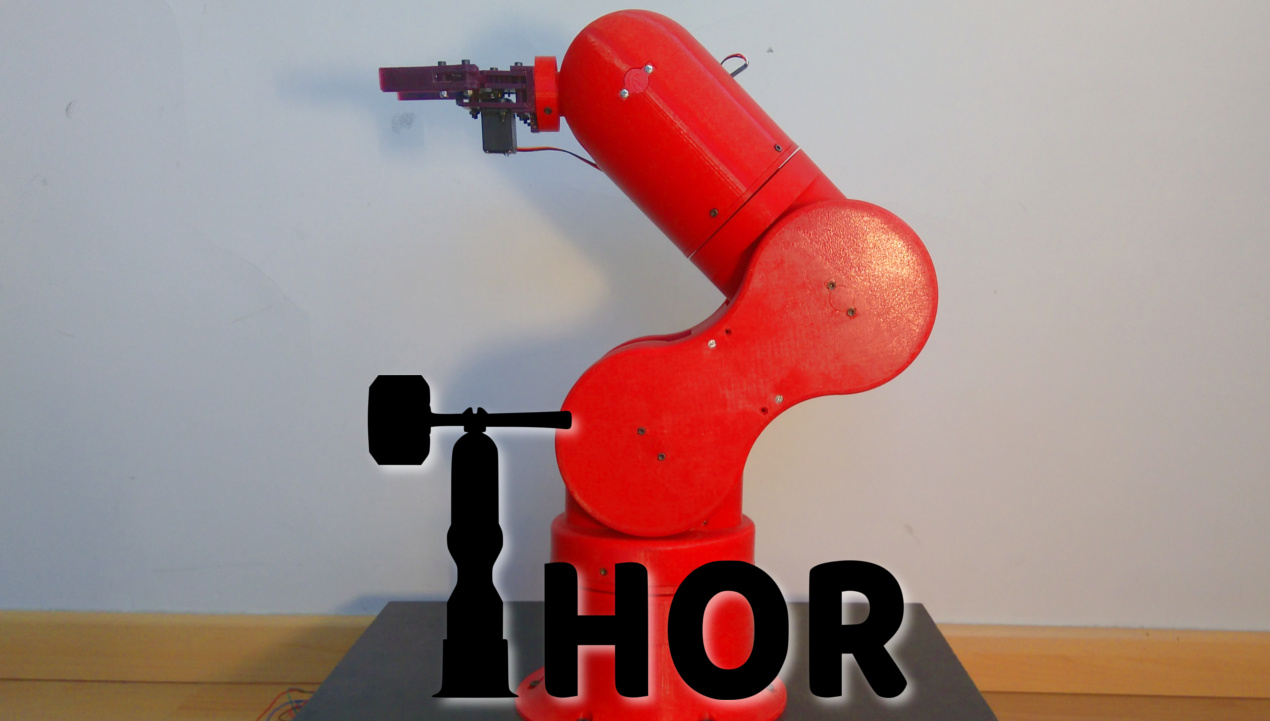
Articulated six-axis arm
A printable six-degree-of-freedom teaching arm with editable FreeCAD, STEP and STL mechanical sources.
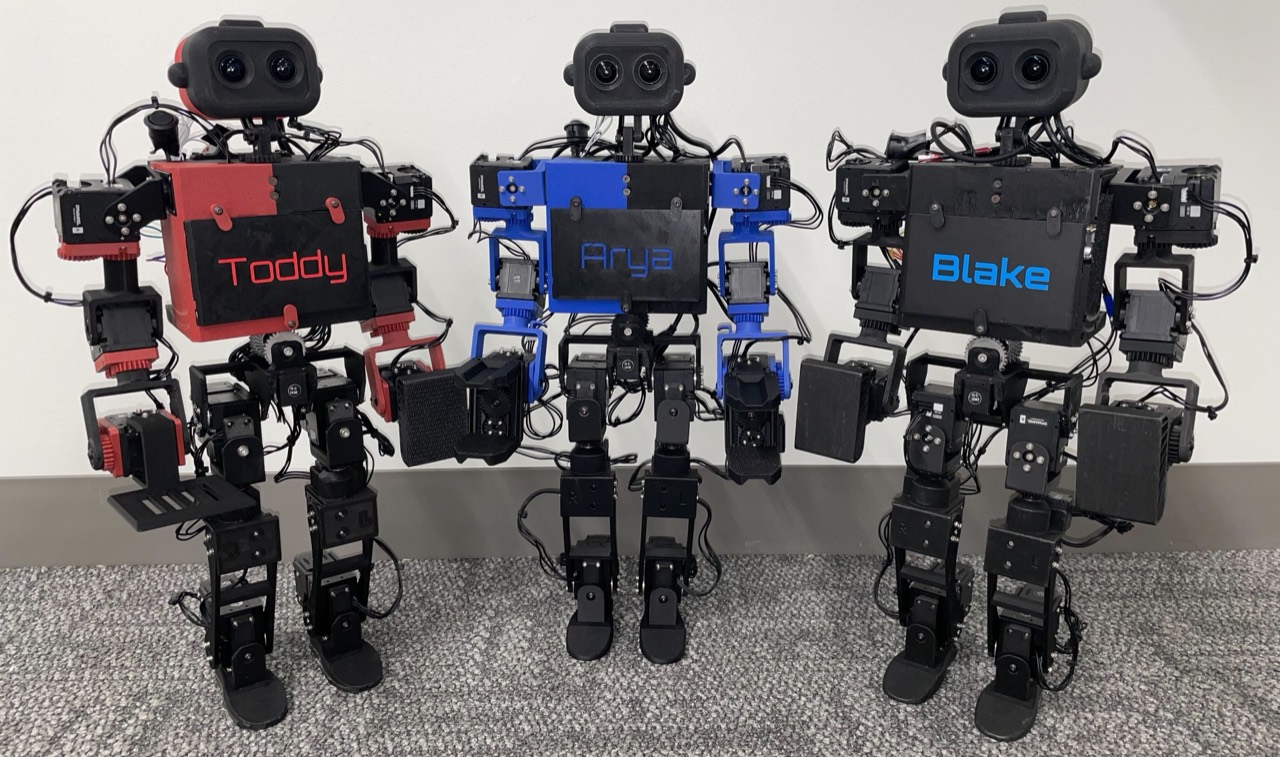
Printed research humanoid
A humanoid research platform with distinct 2XC and 2XM motor configurations, separate PCB sourcing and noncommercial hardware terms.
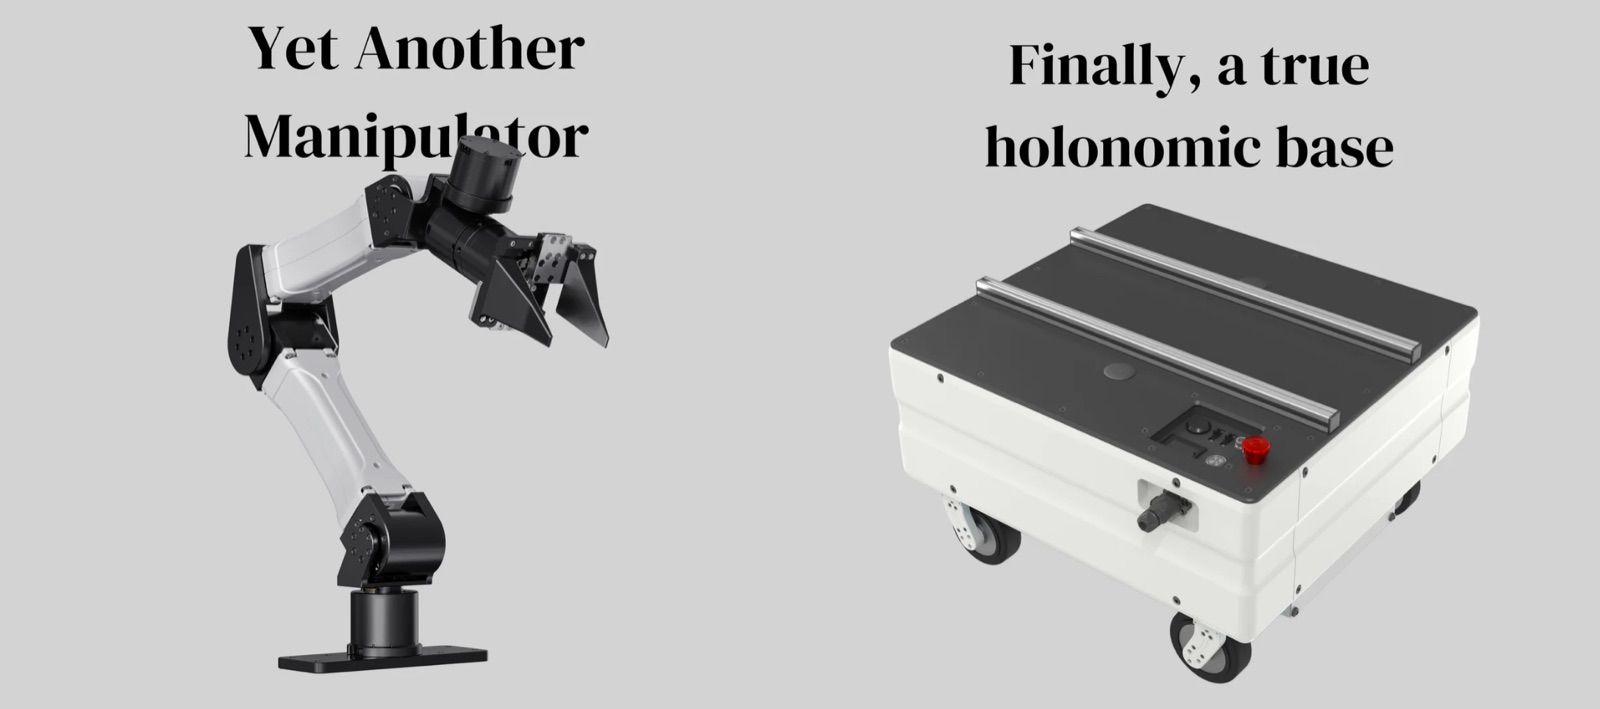
Six-axis articulated arm
A family of six-axis YAM arms supported by a Python and CAN control library with revision-specific models.
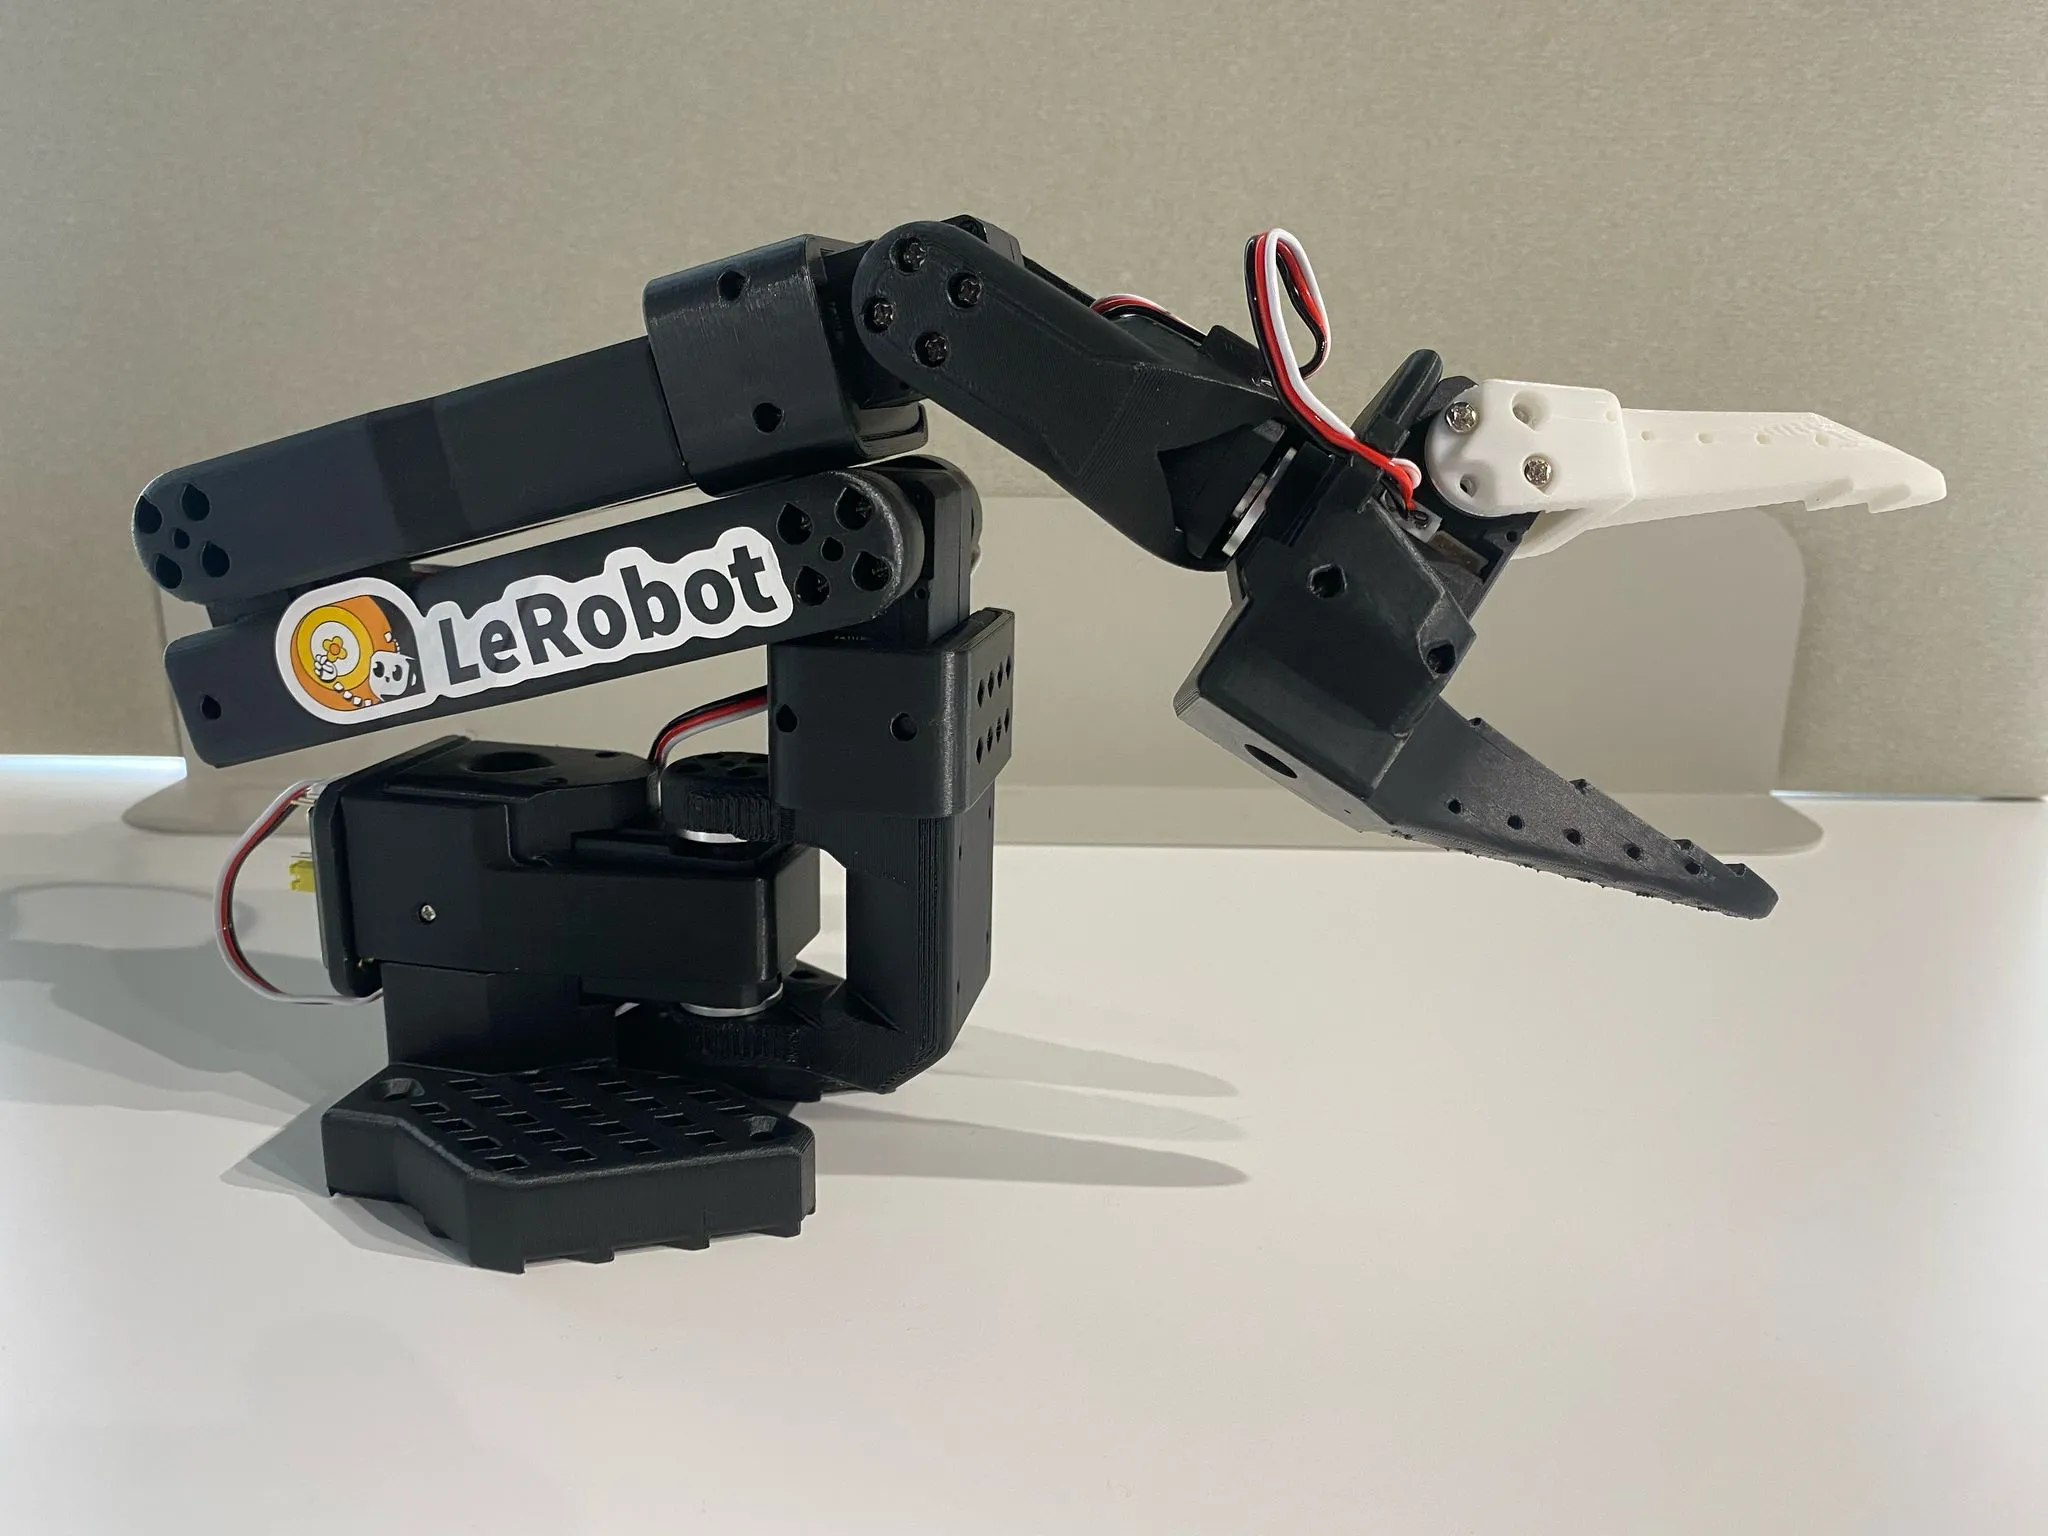
Desktop manipulator
A printable robot arm for teleoperation and robot-learning experiments.
From USD 150.28 Known US parts subtotal · Oct 4, 2026
Wheeled mobile platform
A mobile robot platform for learning and experimenting with navigation.
About USD 783.50 vendor price
No matching entries. Try another term or clear the filters.
We know about these designs but do not profile them. Each note says why. Follow the links for the official project and its license.
Platform tags identify documented interfaces or applications; they do not establish tested fit or certification. Methodology · About the spec